Week 3.2 - 2R Robotic Arm Challenge
AIM :-
To Write a program in Matlab to simulate the forward kinematics of a 2R Robotic Arm, as shown in the video.
OBJECTIVE :-
simulate the forward kinematics of a 2R Robotic by Arm using the matlab.
Errors :-
1. mentioned sin cos in degrees and some links are missing
rectifiying by sind,cosd.
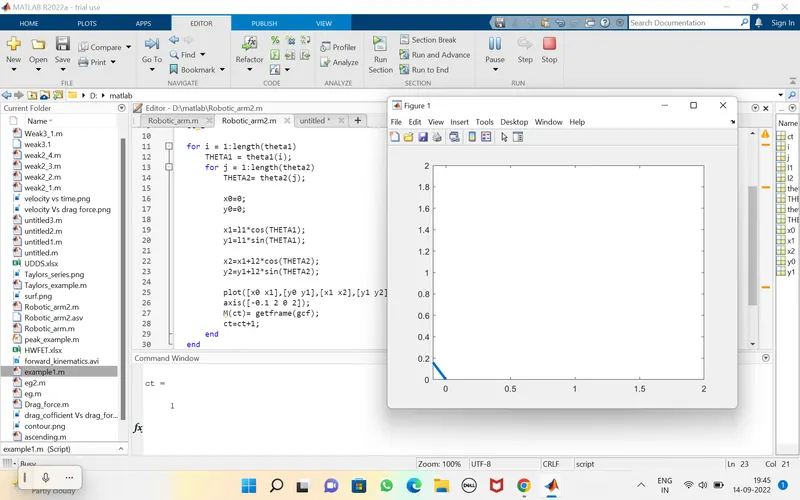
2. Error
x1,y1 and x2,y2 coordinate error by ,inproper giving THETA 1 and THETA 2
Rectified
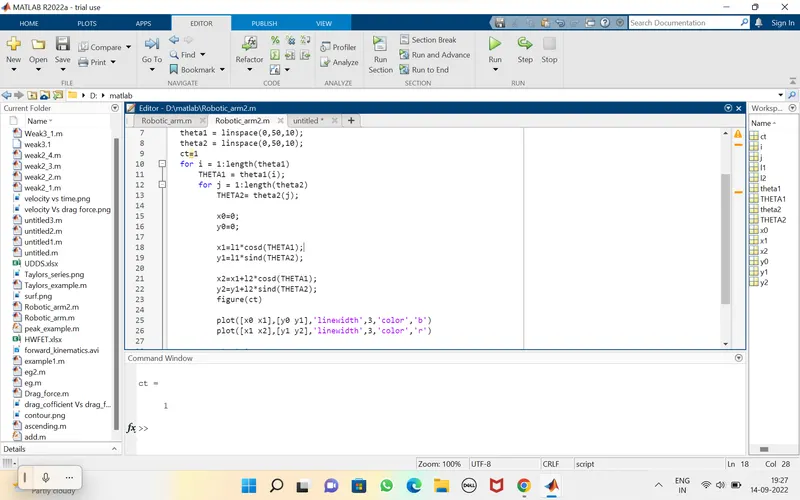
3. Error
Here so many plots are shown in window beacuse using the command hold
Rectified
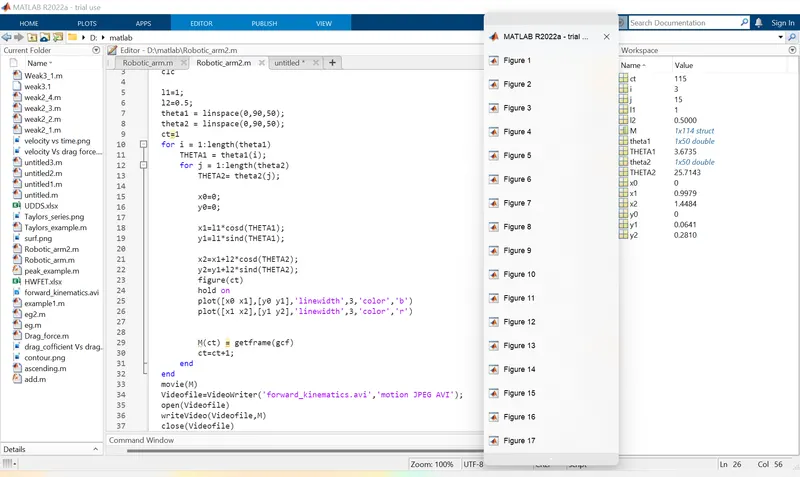
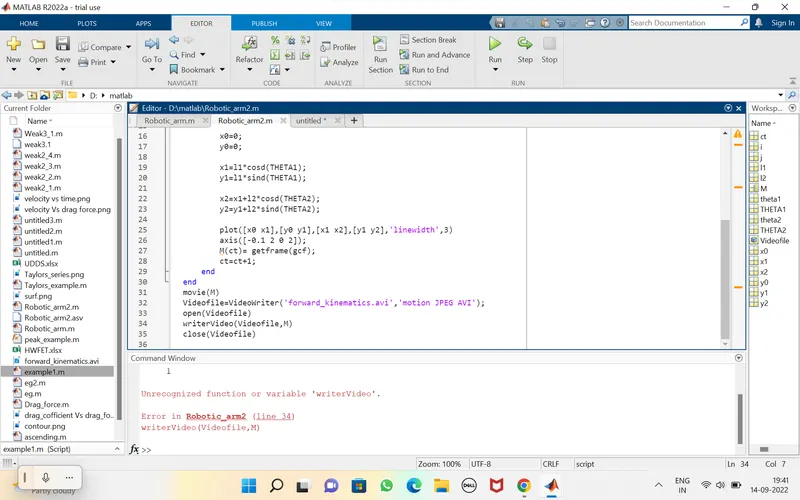
4. Error
Small error in line 34 instead giving writevideo given the Writervideo
Rectified
5. Error
Saved video file was not played beacuse interpted the edit window while running the code
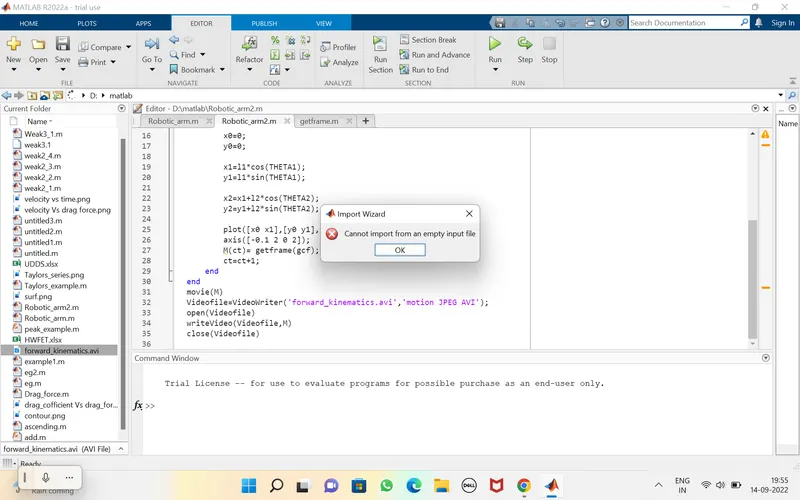
CODE :-
% program to compute the two arm robotic manupilator
clear all
close all
clc

l1 = 1;                                           % length of link 1 is to 1
l2 = 0.5;                                         % length of link 2 is to 0.5
theta1 = linspace(0,90,50);                       % link 1 angle theta 1 is 0 to 90
theta2 = linspace(0,90,50);                       % similarly theta for 2
ct = 1;                                          % counter is set to 1 initiatially

for i = 1:length(theta1)                          % FOR loop is 1 to its length of theta 1
    THETA1 = theta1(i);
    for j = 1:length(theta2)                      % nested FOR loop for theta 2
        THETA2= theta2(j);

        x0=0;                                     % coordinates x0 is 0
        y0=0;                                     % cordinates y0 is 0

        x1=l1*cosd(THETA1);                        % coordinate x1 is l1 times costheta1
        y1=l1*sind(THETA1);                        % similarly for y coordinate

        x2=x1+l2*cosd(THETA2);
        y2=y1+l2*sind(THETA2);

        plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)         % ploting
        title('forward kinematics')                                 % adding a title to plot
        axis([-0.1 2 0 2]);                                         % increasing the limits of plot axis
        M(ct)= getframe(gcf);                                       % getting every frame
        ct=ct+1;                                                    % adding previous frame to next frame
    end                                                             % ENDFOR
end                                                                 % ENDFOR
movie(M)                                                            % creating all frames into a movie
Videofile=VideoWriter('forward_kinematics.avi','motion JPEG AVI');  % saving it into a specific filename
open(Videofile)                                                     % opening the file
writeVideo(Videofile,M)                                             % write it to video file
close(Videofile)                                                    % closing the video file
VIDEO LINK :- https://drive.google.com/file/d/1uFUfMzm66W6uHGD_H4Bxszpmm7bc4Hyi/view?usp=sharing
https://drive.google.com/file/d/1uFUfMzm66W6uHGD_H4Bxszpmm7bc4Hyi/view?usp=sharing
CONCLUSIN :-
Hence the forward kinemaitcs of 2r robotic arm is generated by using the matlab.