Project - Speed Control of a Direct Current (DC) motor
design parameters to model a DC motor
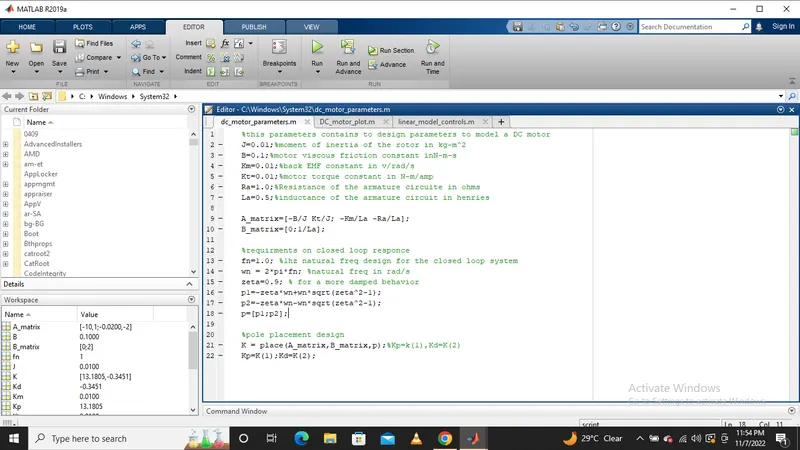
J=0.01;%moment of inertia of the rotor in kg-m^2
B=0.1;%motor viscous friction constant inN-m-s
Km=0.01;%back EMF constant in v/rad/s
Kt=0.01;%motor torque constant in N-m/amp
Ra=1.0;%Resistance of the armature circuite in ohms
La=0.5;%inductance of the armature circuit in henries
requirments on closed loop responce
fn=1.0; %1hz natural freq design for the closed loop system
wn = 2*pi*fn; %natural freq in rad/s
zeta=0.9; % for a more damped behavior
p1=-zeta*wn+wn*sqrt(zeta^2-1);
p2=-zeta*wn-wn*sqrt(zeta^2-1);
p=[p1;p2];
p1 =-5.6549 + 2.7388i
p2 =-5.6549 - 2.7388i
pole placement design
A_matrix=[-B/J Kt/J; -Km/La -Ra/La];
B_matrix=[0;1/La];
K = place(A_matrix,B_matrix,p);%Kp=k(1),Kd=K(2)
Kp=K(1);Kd=K(2);
Kd =-0.3451
Kp =13.1805
Ki=17.5 (tunned manually)
SPEED CONTROLLER OF DC MOTOR
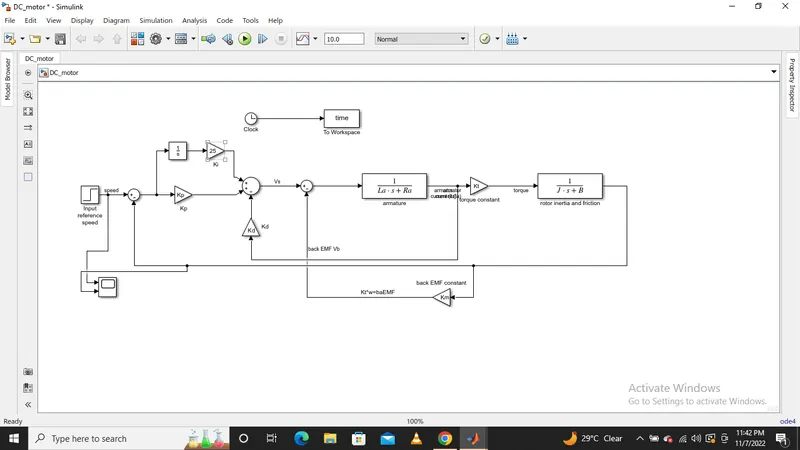
SCOPE OUTPUT(comparison of reference speed and output speed)
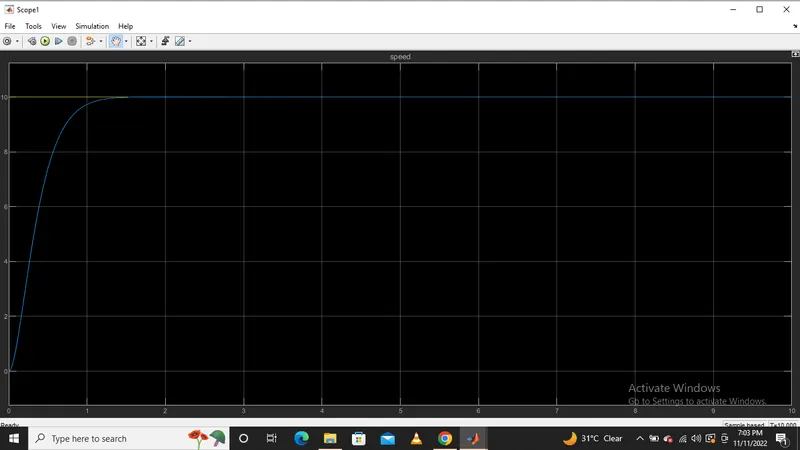
hence conclude the motor controller maintained a desired speed (10) for the motor.