Project - Speed Control of a Direct Current (DC) motor
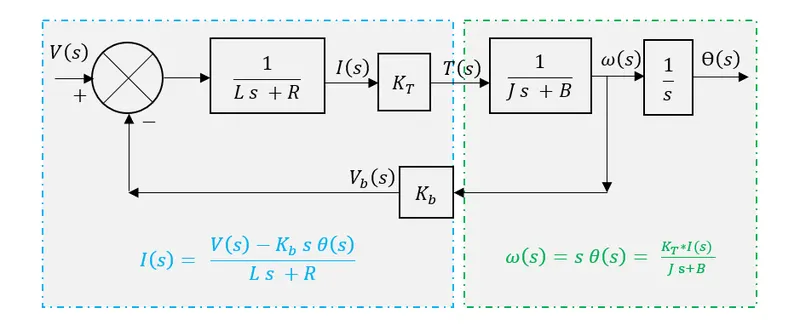
Modelling of a DC motor
A system is stable if every bounded input yields a bounded output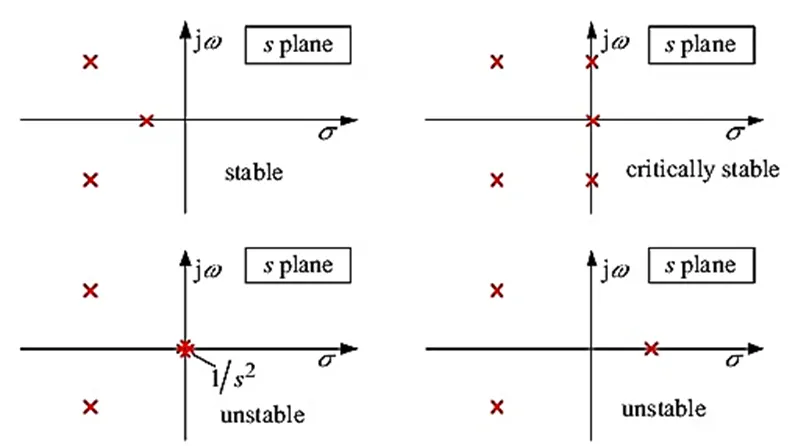
The location of the poles decides the stability of the system.
Matlab code for the model for the DC motor
clear all
clc
J = 0.01;%Inertia
b = 0.1;%friction
Vb = 0.01; %back emf
Ra = 1;%resistance
La = 0.5; % inductance
Kt = 0.01; % torque constant
% Design of a PID controller
A = [-b/J Kt/J; Vb/La -Ra/La];
B = [0; 1/La]
wn = 6.2832;
fn = 1;
zeta = 1.2; % under damped system.
p1 = -zeta*wn + wn*sqrt(zeta^2-1);
p2 = -zeta*wn - wn*sqrt(zeta^2-1);
P = [p1;p2];
k = place(A,B,P)
kp = k(1)
kd = k(2);
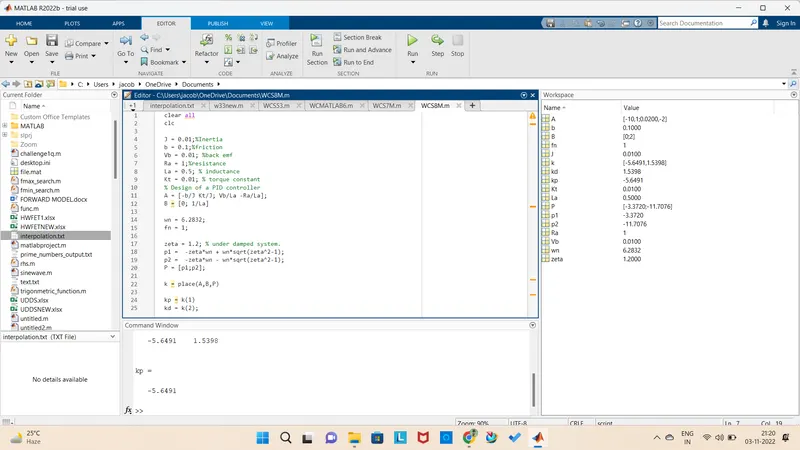
screenshot of matlab script
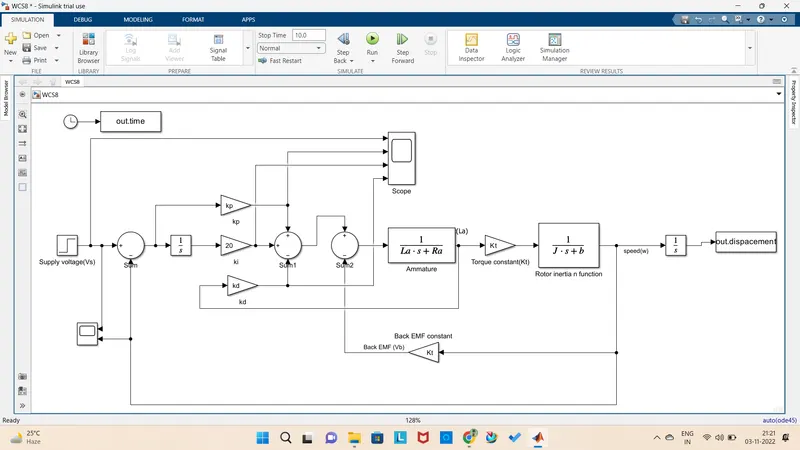
Simulink model
scope for the model
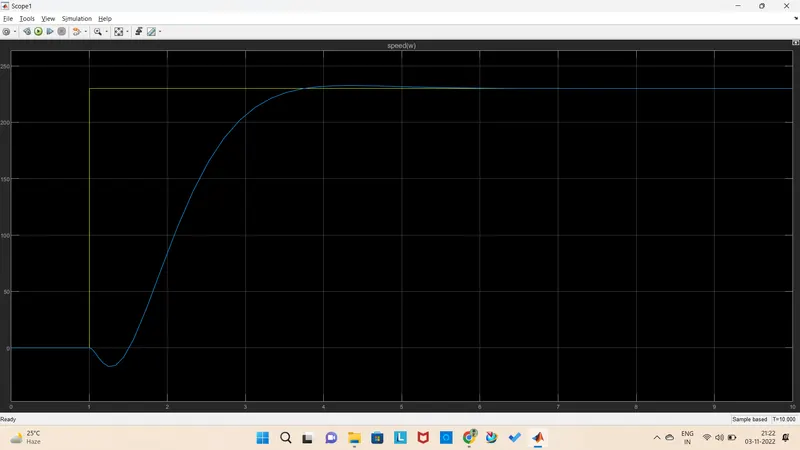
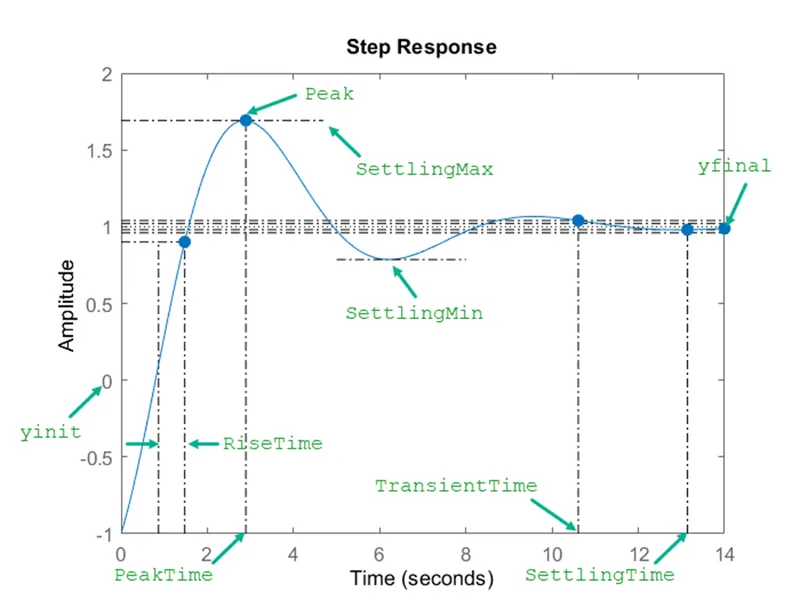
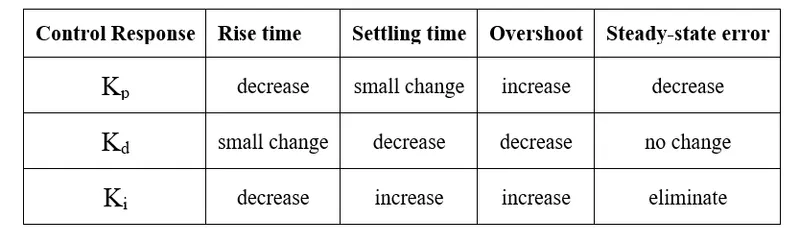
Here i have used proportional gain,integral gain and derivative gain to control design objectives for settling time, overshoot, and steady-state error .