Project - Speed Control of a Direct Current (DC) motor
Project - Speed Control of a Direct Current (DC) Motor
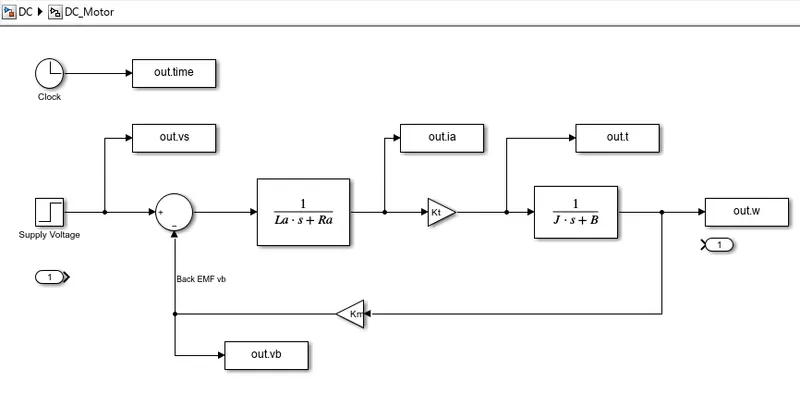
Simulink model of a Dc Motor is constructed, then make it as subsystem called DC_Motor.
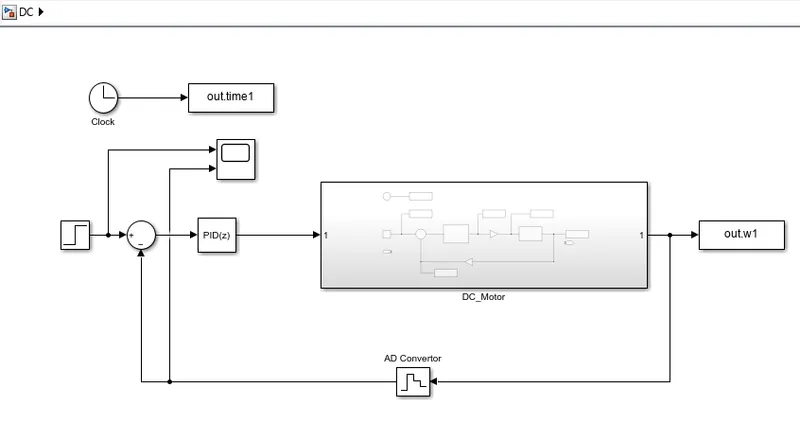
Then,Subsystem Dc motor is connected to the discrete PID controller to maintain the desired speed as it is.
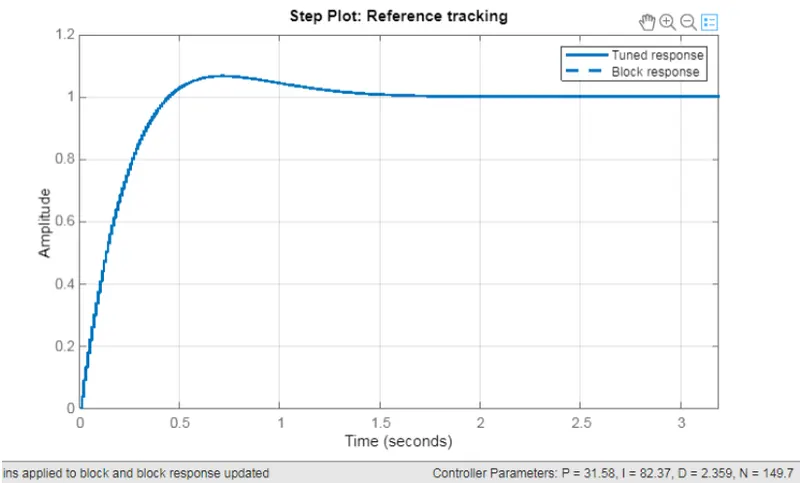
After that Pid controller begin with Kp,Ki,Kd as 1.0,1.0,0 after tuning accordingly, we can adjust Kp,Ki,Kd as
31.58, 82.37, 2.35 respectively. To obtain Control Design Objectives.
Simulink Model for the DC motor Subsystem:
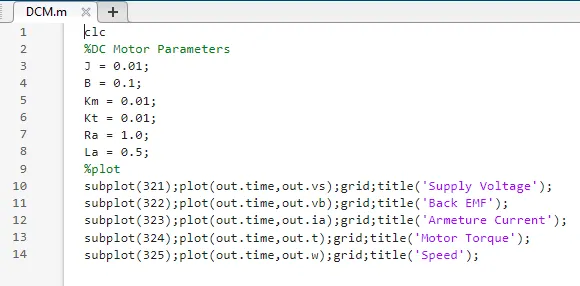
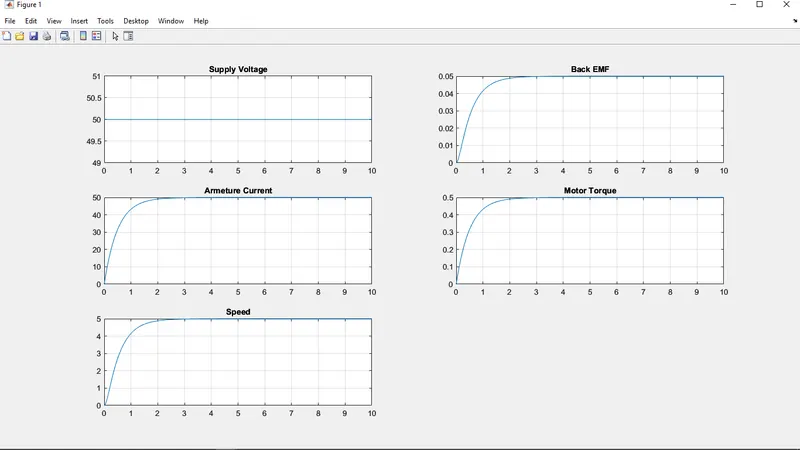
Plotting of Initial DC Motor Behaviour in Various Scenario Without any Controller -
Simulink Model DC Motor with Discrete PID Contoller :
Kp =1, ki =1, kd =0
But after tuning we set kp ki kd to 31.5 82.3 2.3 which is used to obtaine the control objectives of the settling time overshoot time and steady state error.
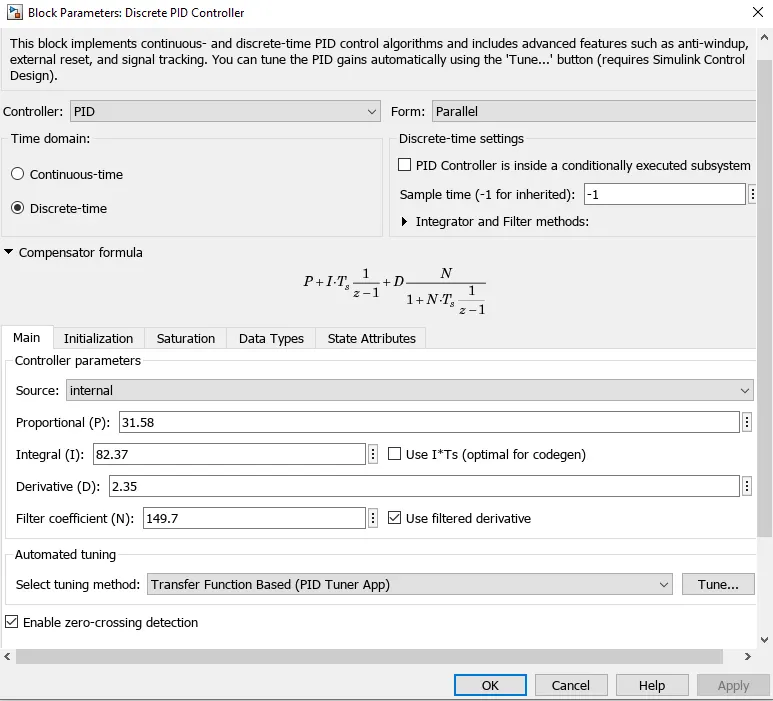
Plot Tuning as settling time as 1.5 sec:
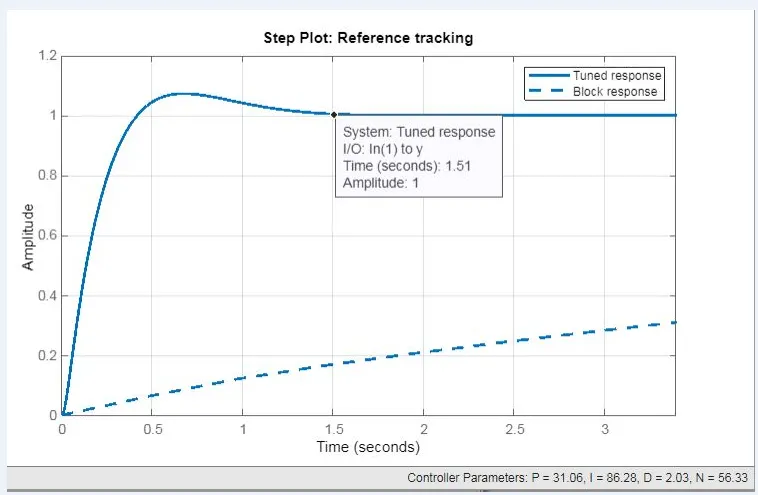
Plotting while Tuning as overshoot is less than 5% :
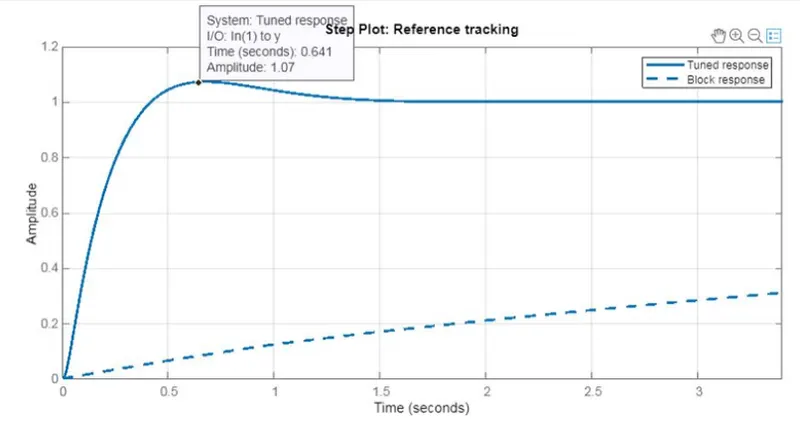
Plotting while Tuning as Steady State Error is less than 1% :
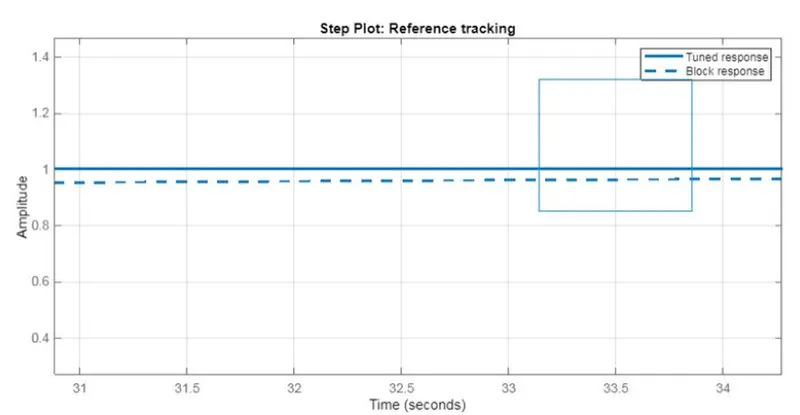
Final Plot After Updating into Block :
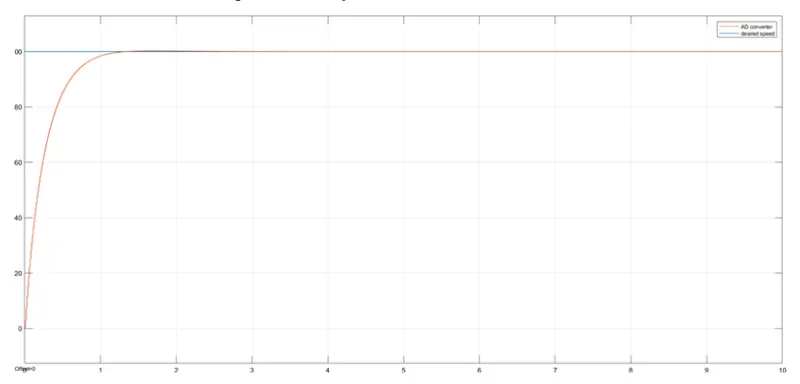
Scopes:
Desired Speed = 50 -
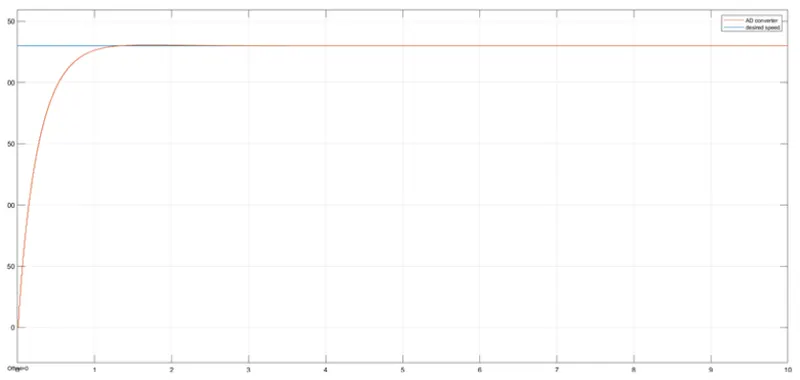
Desired Speed = 230 -
Conclusion :
We desined a Simulink model for the DC motor and also we Use PID control design knowledge gained in the training to design develop and test a controller to maintain a desired speed for the motor.