Project - Speed Control of a Direct Current (DC) motor
Answer
steps:
* Open matlab & program with the given values and known equation to find out the CONTROL GAIN MATRIX (K) *Find out the values of poles from the known equation
* Use 'place' command to find the K matrix
Datas
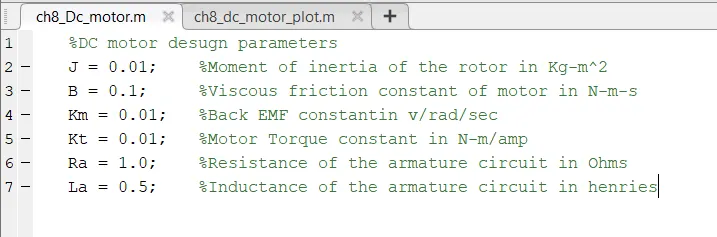
STEPS INVOLVED IN BUILDING THE MODEL
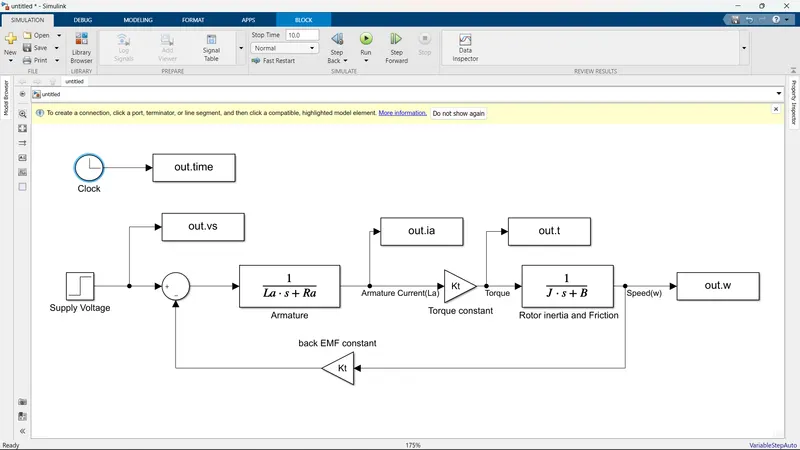
* Import the blocks such as cloak workspace.step.sum.gain.inegrator derivative,mux,scope
* Input the step time and final value in step block (0s& 12v)
* Arrange the block according to the motor speed equation
* input the the proprtional gain, derivative gain values found after programming in to the respected gain block
* Double click on transfer function block and add the denominator coefficients according to the equation
* input a temperory value to the integral gain block
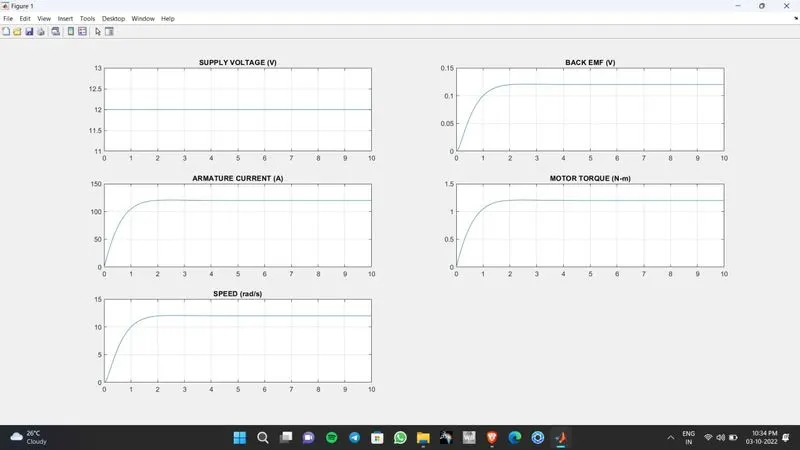
* plot the supply voltage,Back EMF, armature current torque, speed against times
* change the solver type to fixed and solver to ode 4 runga kutta and step size to 0.01 s
* Save it and run
* compare the input and response,according to the observation change the Ki value to obtain the control design objective
such as overshoot, setting time and steady state error
Plot Commands
Block diagram
Graphs
Conclution
After completion of both the task, the graphical result shows the there is no difference came while doing with first method and second method. The amplitude,frquency and output everything was the same.
The first method is simple and fast,the other one took long time.