Project 1
Develop a double-acting actuator model using Simscape Multibody and Simscape components. The mechanical system of the cylinder needs to be built using Simscape Multibody library components / blocks, and the hydraulic system needs to be modelled using Simscape library physical components.
Answer
Steps :
-
Open matlab
-
Here we have to build a piston and cylinder
-
Import blocks required to build cylider and piston such as cylindrical solid, revolved solid,mechanism configuration solver, world frame from multibody library
-
Input the parameter values like density, radius,colour,opacity and assemble them by adding frame (left and right)
-
Cylinder assembly:
Bottom cap (solid) :
Geometry - Radius -0.1m
Length - 0.05m
Inertia - Density - 8050 kg/m^3
Graphic - Visual properties - color - [0.6 0.6 0.6]
Frames - Frame1 - right -
Barrel (Solid) :
Geometry- Cross section - [0.08, 0.5/2; 0.08,-0.5/2; 0.1, -0.5/2; 0.1, 0.5/2] m
Inertia - Density - 8050 kg/m^3
Graphic - Visual properties - color - [0.6 0.6 0.6]
Opacity - 0.3 -
Head cap(Solid):
Geometry- Cross section - [0.04, 0.05/2; 0.04, -0.05/2; 0.1, -0.05/2; 0.1, 0.05/2] m
Inertia - Density - 8050 kg/m^3
Graphic - Visual properties - color - [0.6 0.6 0.6]Prismatic joint :
State target - Specify position target - Priority - low
Value - 0
Internal mechanics - Equilibrium position - 0 m
Spring stiffness - 10 N/m
Damping coefficient - 1e6 N/(m/s)
Limit - Specify lower limit - Spring stiffness - 1e9 N/m
Damping coefficient - 1500 N/(m/s)
Specify upper limit - Spring stiffness - 1e9 N/m
Damping coefficient - 1500 N/(m/s)
Piston assembly :
Piston (Solid):
Geometry - Radius -0.08m
Length - 0.05m
Inertia - Density - 8050 kg/m^3
Graphic - Visual properties - color - [0.8 0.0 1.0]Rod(Solid):
Geometry - Radius -0.04m
Length - 0.5m
Inertia - Density - 8050 kg/m^3
Graphic - Visual properties - Diffuse color - [0.9 0.9 0.9]
Frames - Frame1 - leftHydraulic System:
Bottom chamber- Interface cross sectional area- pi*0.08^2 m^2
Dead volume- 1e-4 m^3
Fluid dynamic compressibility- OffHead chamber- Interface cross sectional area- pi*(0.08^2-0.04^2) m^2
Dead volume- 1e-4 m^3
Fluid dynamic compressibility- On
Initial liquid pressure- 4e6 PaPS constant- Constant- 0.45 m
Mechanical System :
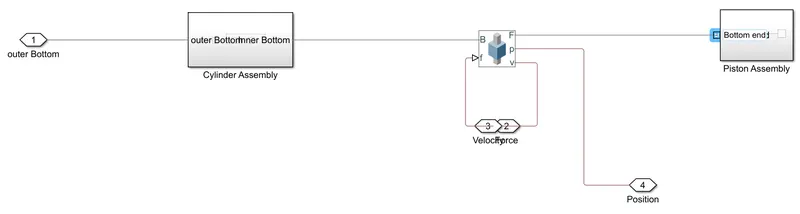
- Now let's connect these piston & cylinder
Cylimder Assembly :
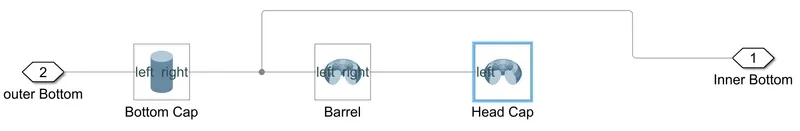
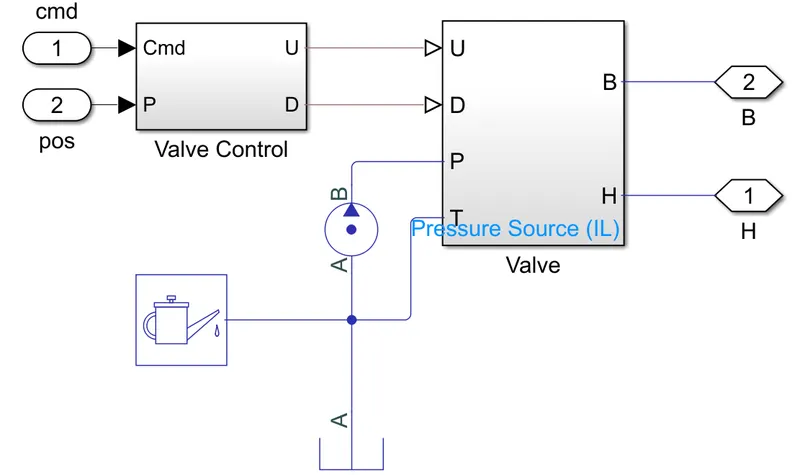
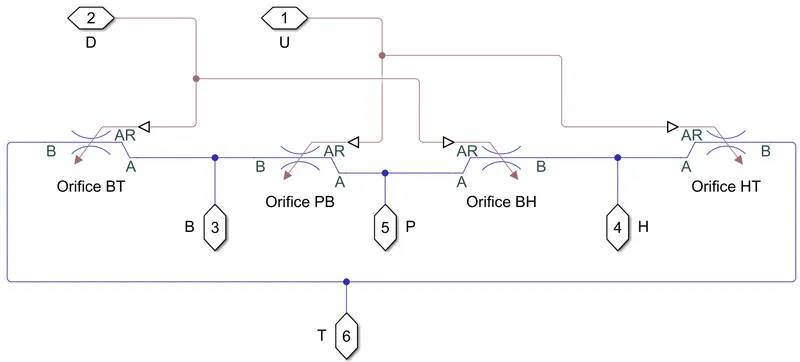
- Here we can see 4 orifices are connected which is nothing but the 4 ports of a 4/3 DC valve
Piston Assembly :
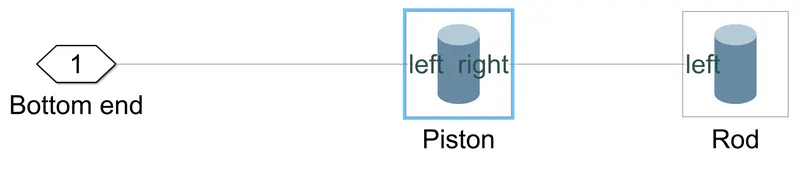
Hydralic System :
STEPS INVOLVED IN BUILDING HYDRAULIC SYSTEM USING SIMSCAPE COMPONENTS
• Import Blocks such as Translational mechanical convertor, PS constant, substract, Mechanical translational reference from the simscape library.
• Connect these blocks as illustrated in the diagram.
• Input the values of PS constant, Bottom chamber, Head chamber related parameters.
Finally connect the both mechanical & Hydraulic system by a translational multibody interface.
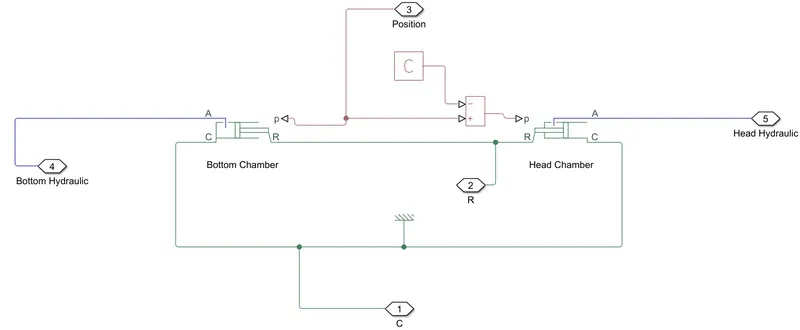
Hydralic Circuit :
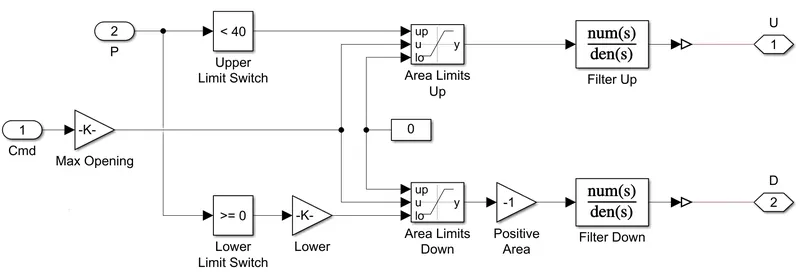
Valve Control:
Valve :
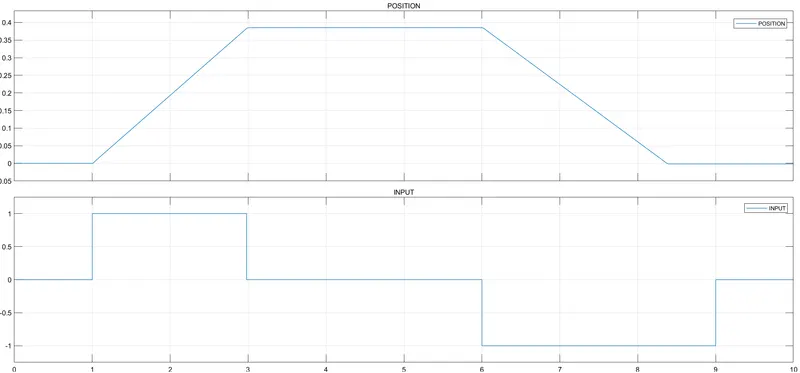
Graphical Responce :
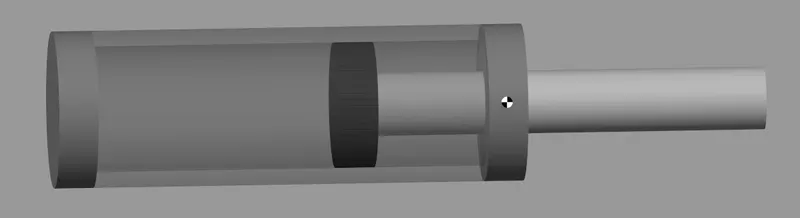
CONCLUSION :
The double-acting actuator model that we created and successfully emulated. The piston moves forward and backward in response to the input signal. It can be seen from the graph that the output fluctuates according to the output.