Project - Position control of mass spring damper system
Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
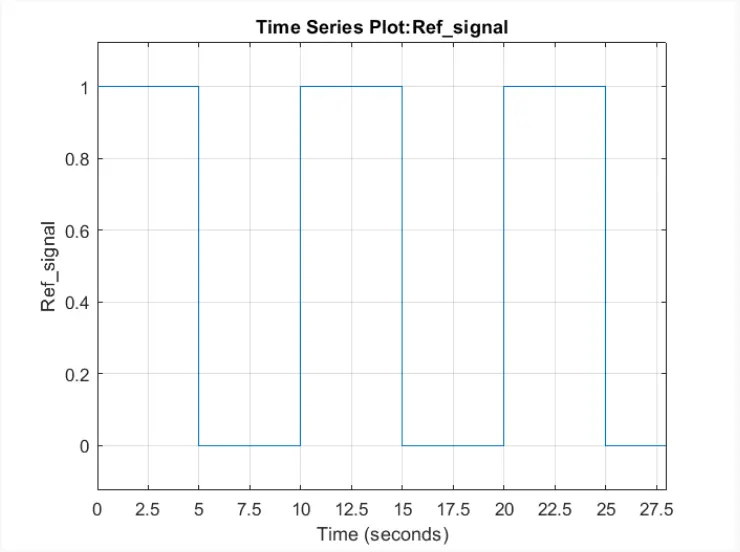
The reference signal is shown in the following figure.
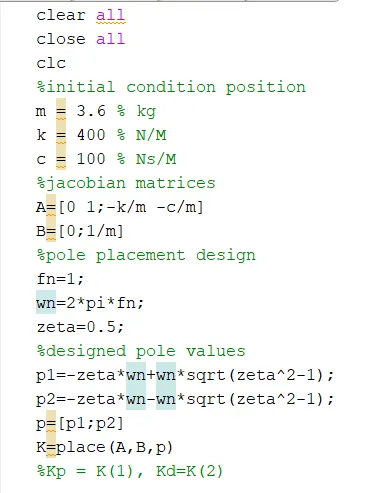
parameters:-
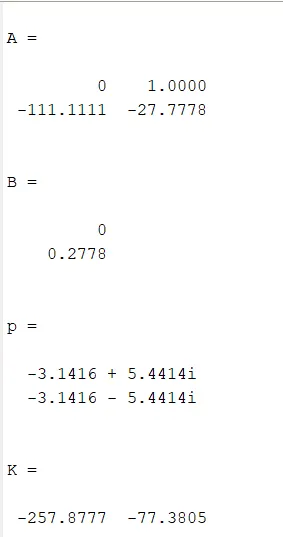
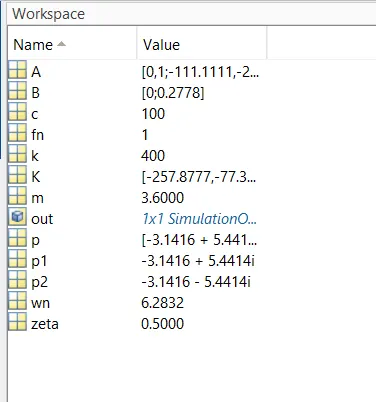
model:-
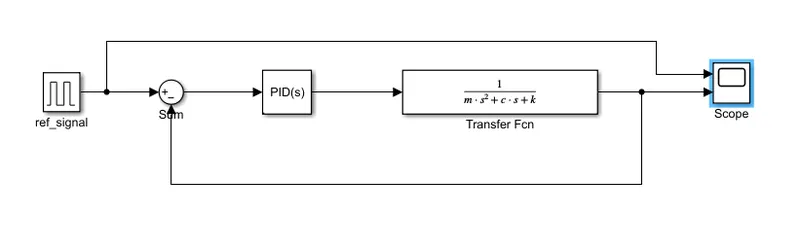
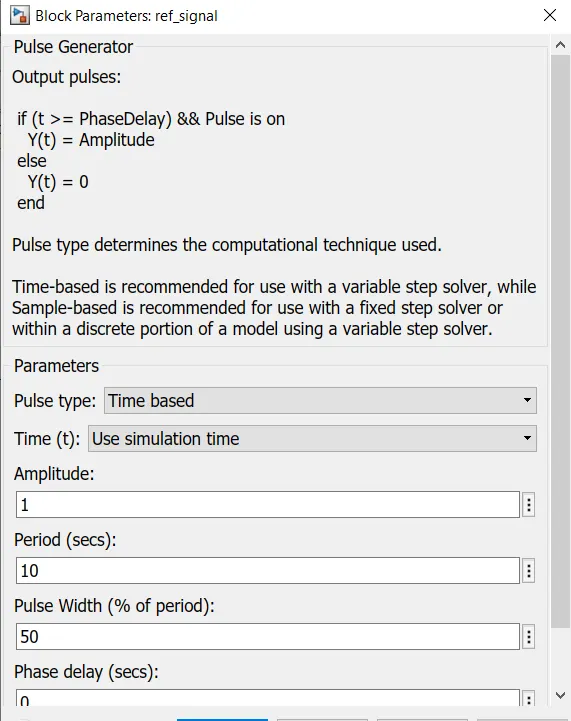
here Kp=K(1) & Kd=K(2)
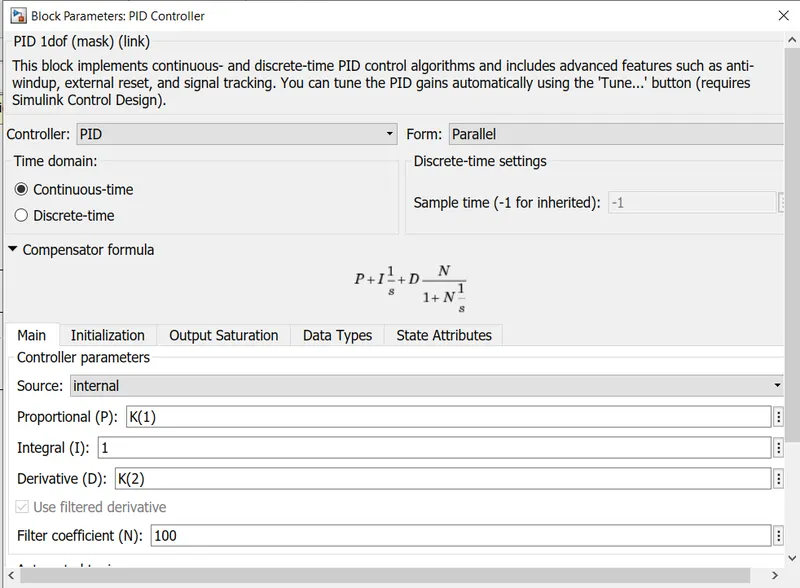
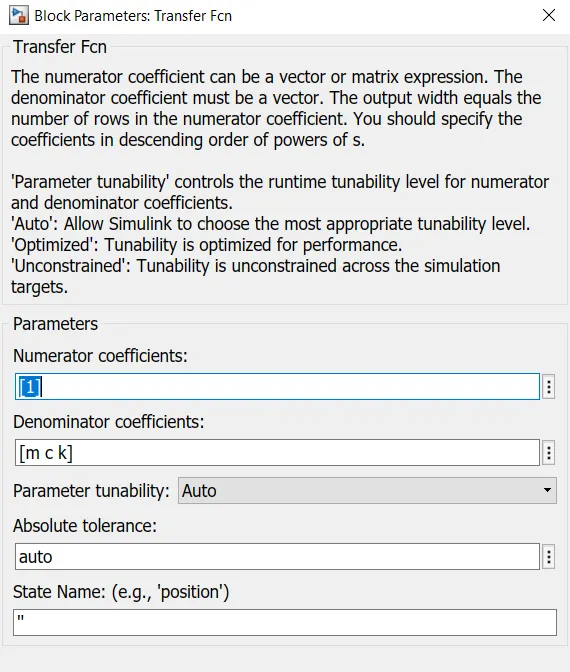
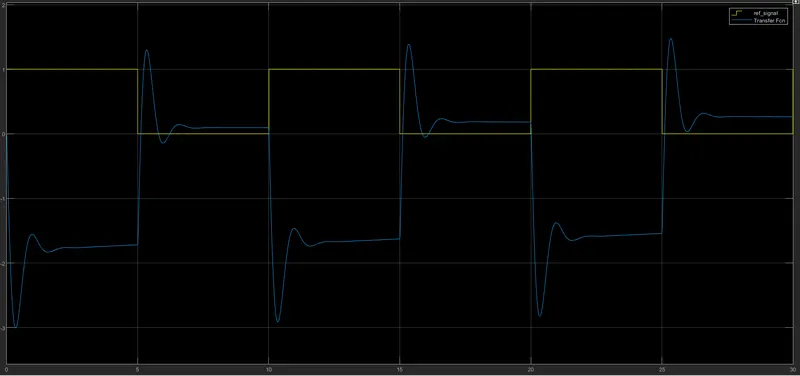
result:- in this result we can see with positive input signal we are getting negative response, which is due to untuned PID values.
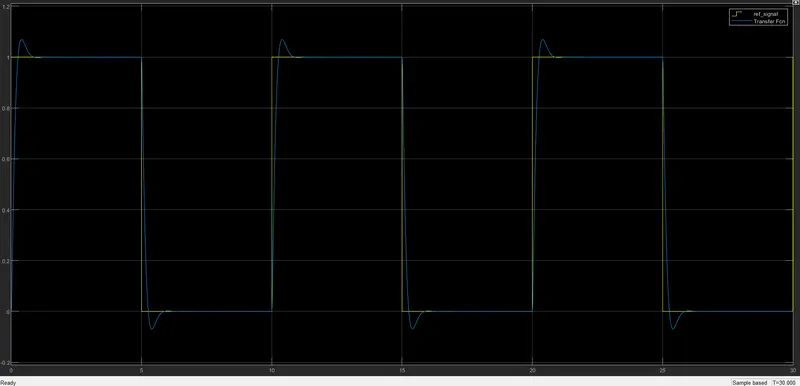
for tuning the response signal we have use auto tune method from PID controller, below is the tuned response
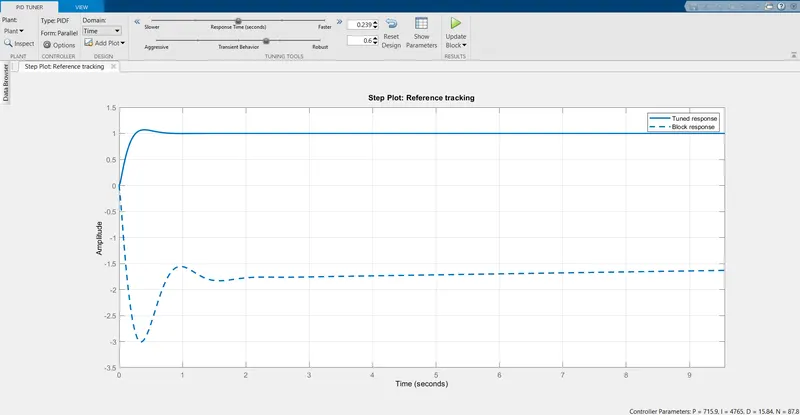
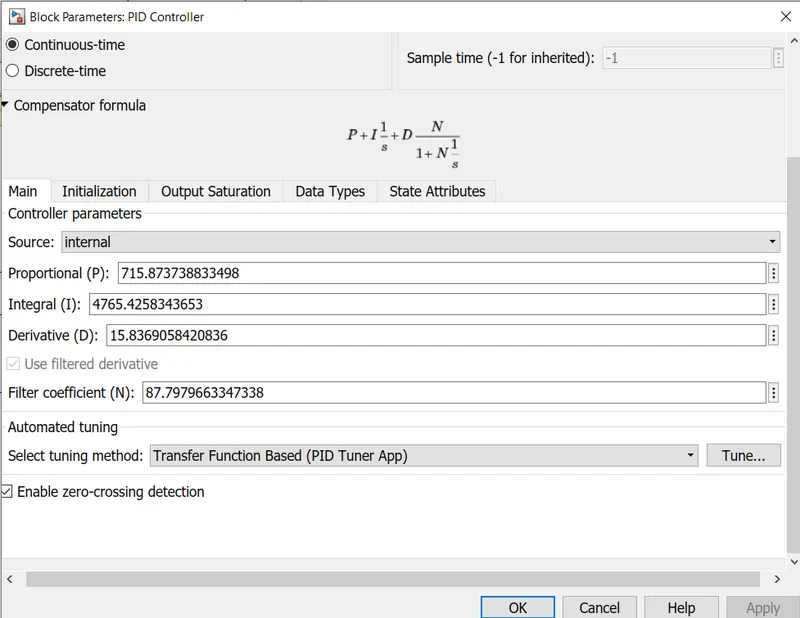
tuned parameters:-
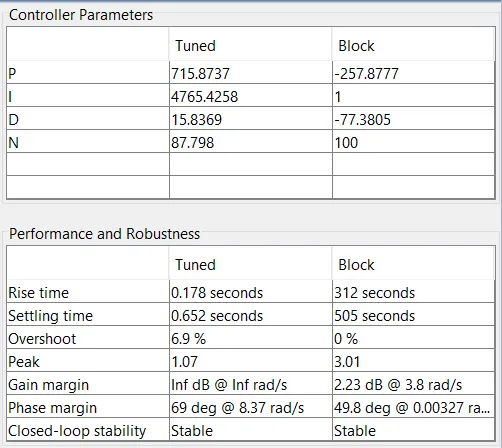
tuned result:- we are getting nearly same output as input, as compared to earlier result.