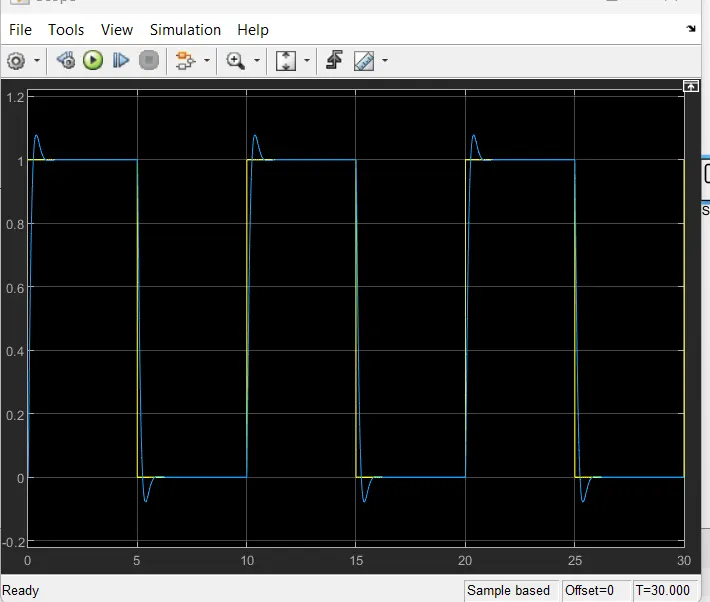
Project - Position control of mass spring damper system
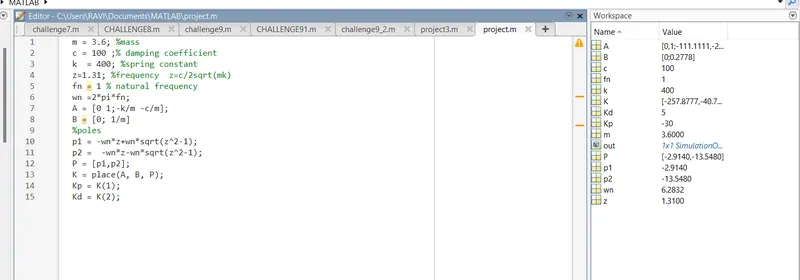
simulink model
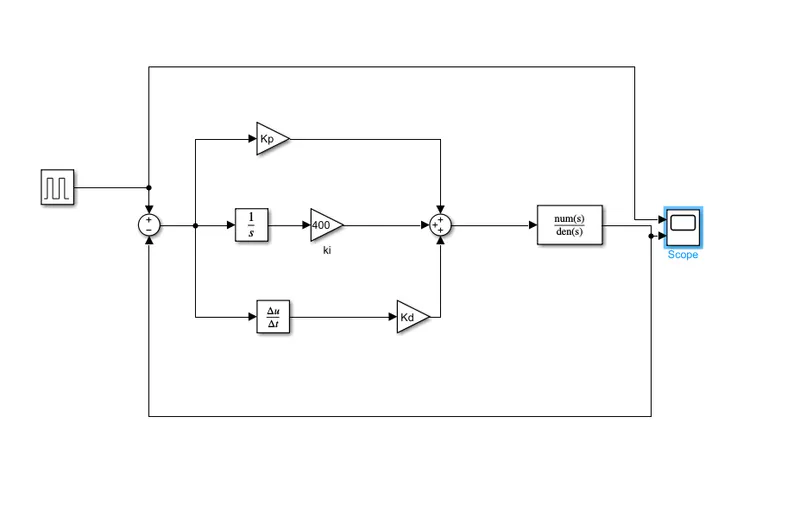
blocks used are to create the model are gain,sum,integrator,differential,transfer,pulse generator and scope.
initially, pulse generator is placed and based on the values given that are mentioned in the particular blocks.
here, time taken to run the simulation is 30seconds.
after the connections are made save the file and run the file inorder to plot the result
result:
in the above result,the yellow coloured wave indicates the reference wave and the blue wave indictes the actual wave which follows the reference wave.
we conclude that as of the given values where z=1.31(critically over damped condition). the actual wave is similar to the reference wave.
simulink model by tuning of PID controller
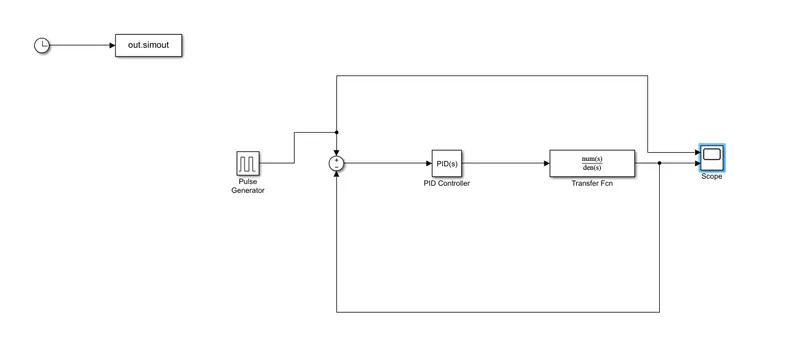
its the another method to plot the result.
in this pulse generator, PID controller transfer function, scope blocks are used.
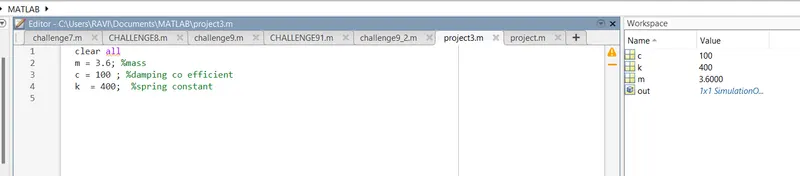
as per the given m, c,k, values which are mentioned the transfer function block.
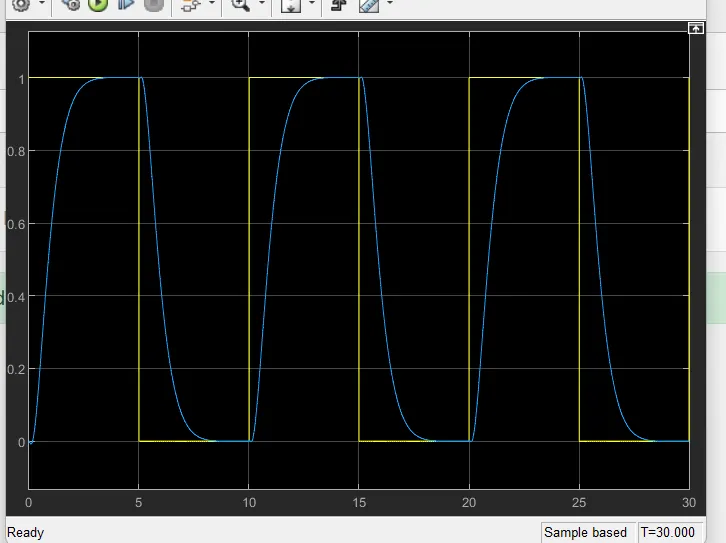
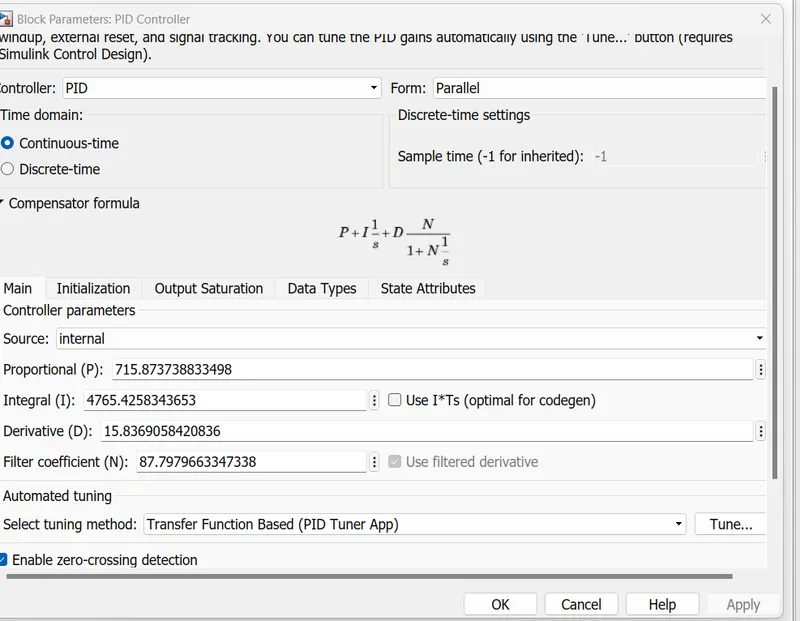
In PID controller by changing the tune we can acquire different waves. thus P I D values displays according to the tuning.
result: