Project - Position control of mass spring damper system
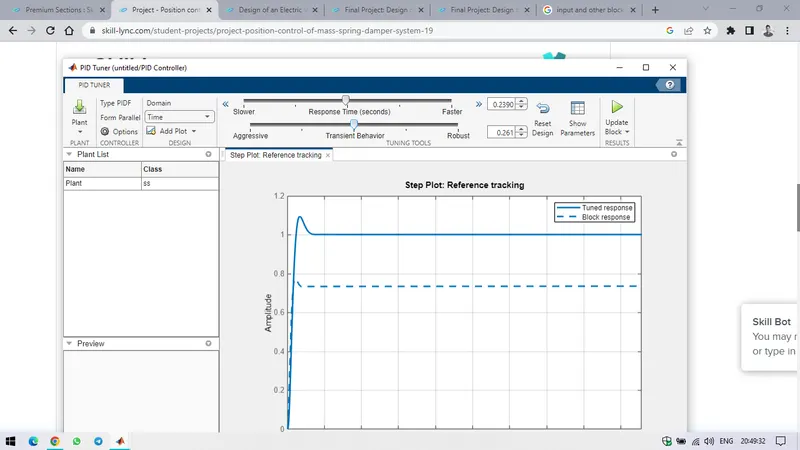
Q. Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Take
m = 3.6; %kg
k = 400; %N/m
c = 100; %Ns/m
AIM :
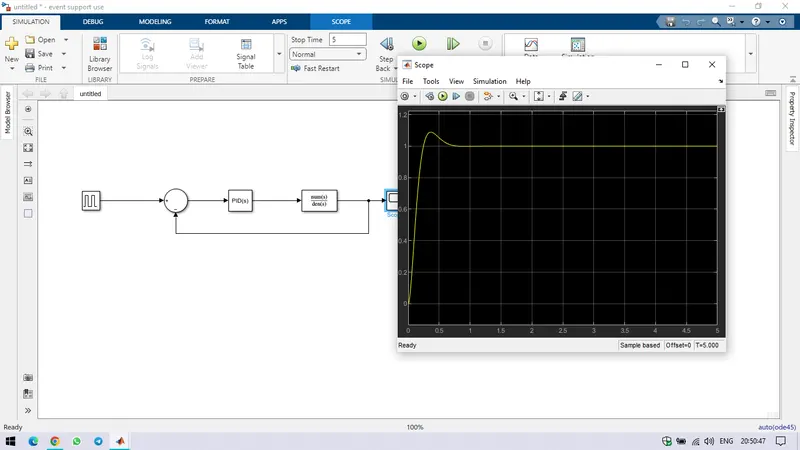
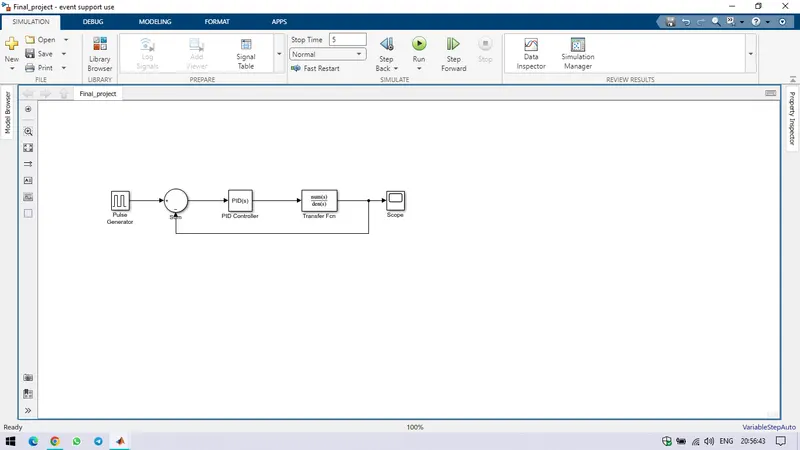
We Create a model of mass spring damper system using Simulink with PID Controller.
Model :
.m Code :
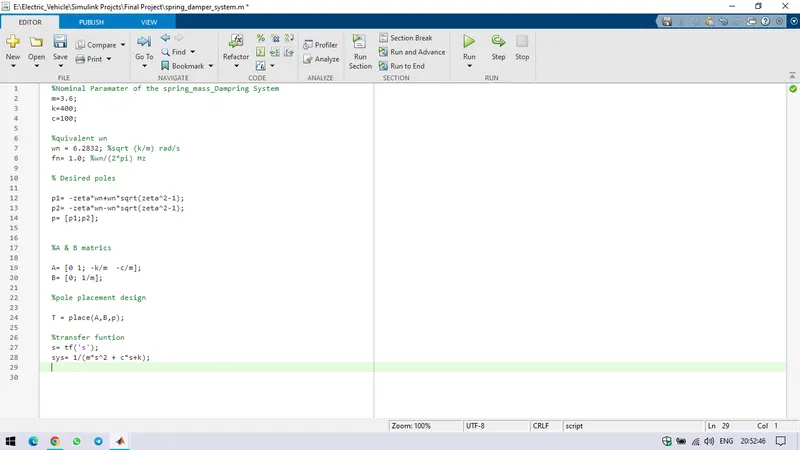
%Nominal Paramater of the spring_mass_Dampring System
m=3.6;
k=400;
c=100;
%equivalent wn
wn = 6.2832; %sqrt (k/m) rad/s
fn= 1.0; %wn/(2*pi) Hz
% Desired poles
p1= -zeta*wn+wn*sqrt(zeta^2-1);
p2= -zeta*wn-wn*sqrt(zeta^2-1);
p= [p1;p2];
%A & B matrics
A= [0 1; -k/m -c/m];
B= [0; 1/m];
%pole placement design
T = place(A,B,p);
%transfer funtion
s= tf('s');
sys= 1/(m*s^2 + c*s+k);
Plot :