Project
- AIM:-
To study and analysis the system-level all terrain vehicle model in simulink
and obserb results.
2. OBJECTIVE:-
Prepare a technical report explaining the model properties & comment on the result.
3. DESCRIPTION:-
3.1.BAJA All-Terrain vehicle(ATV)
- INTRODUCTION
An all -terrain -vehicle (ATV),also known as quad,as defined light utility vehicle (LUV).
a quad bike,or simple a quad as defined by the ,American National Standard institute
(ANSI);is a vehicle travel on low pressure tires,with a seat that is straddled by the operator
along with handelbars for streeing control.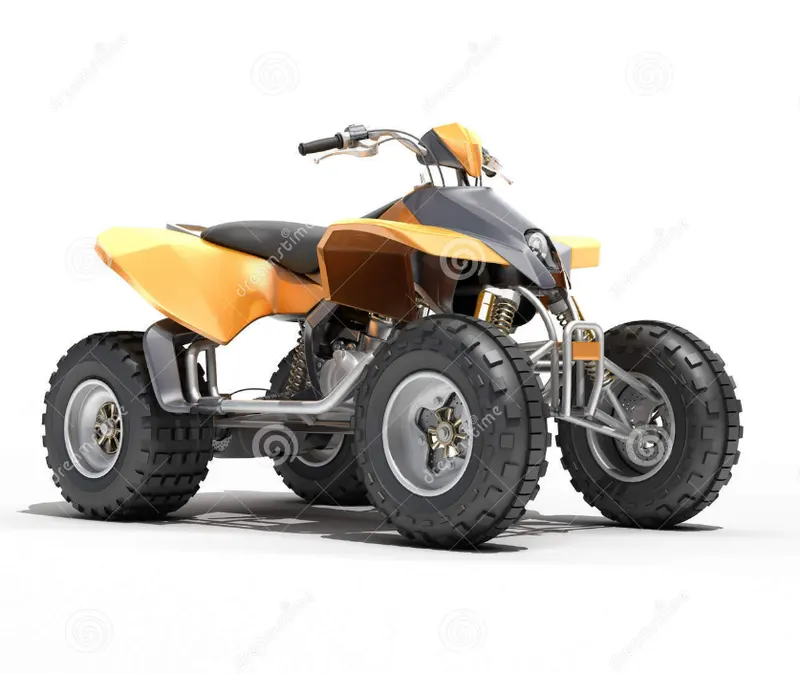
The ATV model is commonly called a four-wheeler in Australia,South Africa, parts of canada,india and the united states
of america.they are used extensively in agriculture, beacause of their speed and light footprint .by the current ANSI.
ATVs are intended for use single operator,although some companies have developed ATVs intended for use by the operator
and one passenger.these ATVs ..
The rider sits on the operator these vehicle like a motorcycle, but the extra wheels give more statbility at lower speed
atthough most are equiped with three or four wheels. six wheels models exists and existed histrically for specialized..
Application multiple user analogues with side-by-side seating are called utili terrain vehicle (UTVs) or side by side
to distinguish classes of vehicle.both class tend to have similar power terrain parts. Engine sizes of ATVs .
19th century ROYAL ENFIELD built and sold first powerd quadercycle in
1893.it had many bicycle components including handle baars ,The royal enfield resembles a modern ATV-style quad bike
but was designed as form of HORSELESS CARRIAGE for road use.
1.CONTINUOUSLY VARIABLE TRANSMISSION : -
CVTs one of the advantages of a cvts its ability to continuous changes its gear ratio this means that no matter what
the engine speed it is always performing at its peak efficiency.CVTs often offer better fuel economy as a result especially
when the driving in the city..
Digital trends says that most occupied with CVTs offer a smoother ride than a similar car with a
Regular automatic this is the beacause transmission never shifts there is no abrupt downshifting when car needs additional
power and there is no feeling gear haunt that you sometimes feels with traditional automatic.
- BAJA ATV MODEL :-
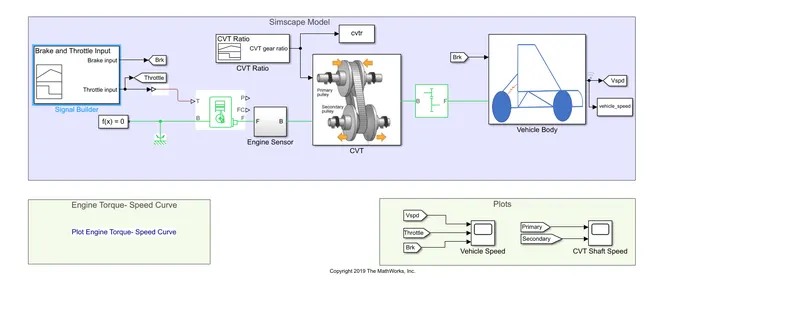
A CVTs automatic transmission that can change seamlessly through a continuous range of gear ratio.
this contrast with other transmission that provide a limited number of gear ration.this contrast with
other transmission number gear ratios fixed step the flexibility of CVTs.are used..
automobile,tractors,motor, scooter, snowbiles,and earthmoving equipment
The most common type of CVTs used as two pulleys connected by a belt or chain,however several other design
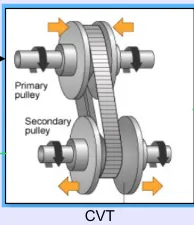
The above figure consist of primary pully,variator which is connected to the primary pulley move inward such that radius
of primary pulley is less than the radius of secondary pulley which leads to speed reduction and when variator which is
connected to the primary pulley move inward then variotor which is connected to the primary pulleyis move outward
such that radius of secondary pulley which leads to overdrive.
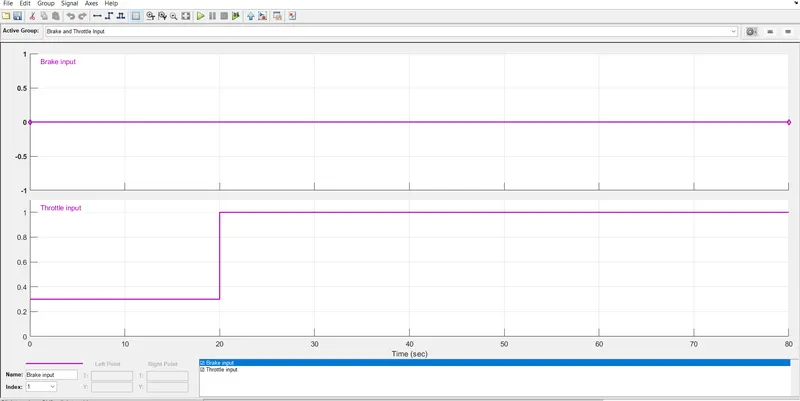
- Input signal is provided using signal builder in which brake input is provided as zero and trottle
input is provided as 0.3 upto 20 sec and varied to 1 for remaining second.
- GENERIC ENGINE: -
Represent a system-level model of spark-ignition and diesel engines suitable for use at initial stages
of modeling when only the basic parameter are available. optional idle speed and red line controllers .
are included. the throttle input signal T lies between zero and one and specifies the torque .if the engine
torque demanded from the engine as a falls below the stall speed, the engine torque .if engine speed is
maximum speed, the simulation stop and issues are error message.Connection F and B are mechanical
rotational conserving ports associated with the engine crankshaft and engine block,respectively.
connecton P and FC are physical signal output ports through which engine power and fuel consumtion
rate of speed..
- TORQUE SPEED CURVE.
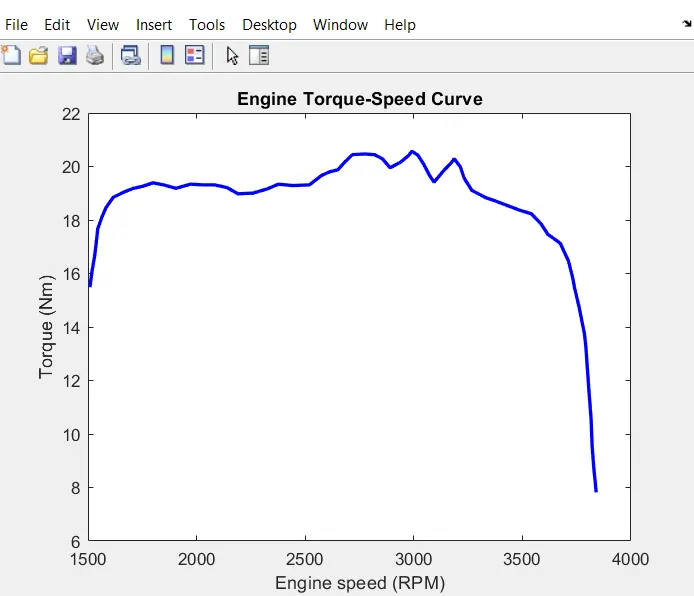
- Engine Torque - speed curve -
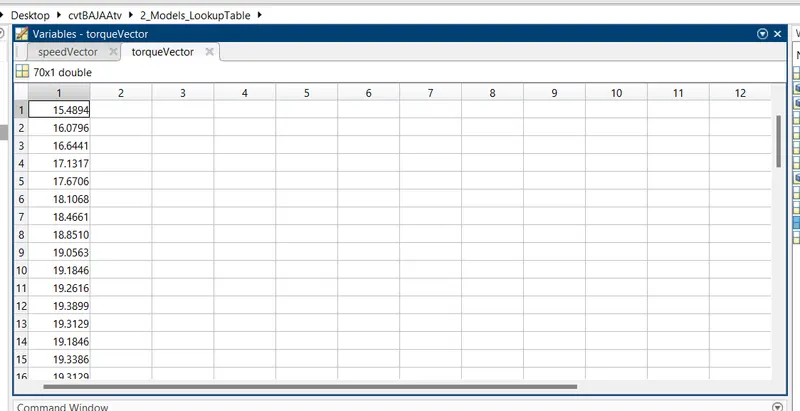
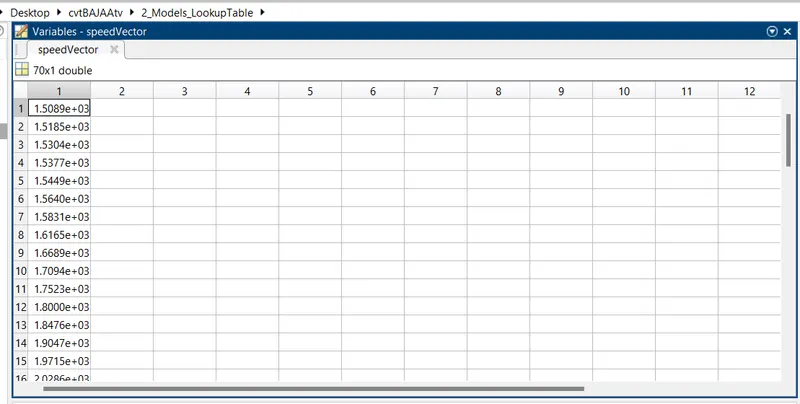
The value of speed vector and torque vector is obtained from the diagram and logged the values in the
in the workspace of matlab file.
- VEHICLE SPEED DATA :
- ENGINE SENSOR :
Engine sensor which sense the rpm of the engine and it is connected to the CVTs blocks.
- CVT BLOCKSET :
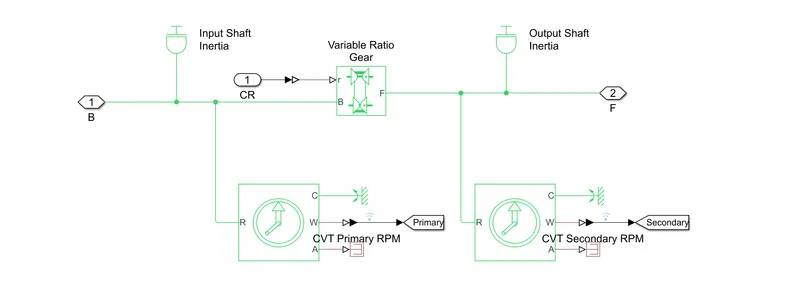
- Input shaft represent the primary pulley and output shaft represents the secondary pulley and
mechanical rotational sensor is connected to input and output shafts and variable ratio Gear represent
a variable ratio of gear box such as implemented by mechsnical belt of CVTs , electrical or hydaulic transmission.
The physical signal input 'r' defined the ratios of input to output angular shaft velocities.connection B (base) .
and F (Follower) are mechanical rotaional conserving ports.specifies the relation between base and follower
Rotational conserving ports .
Specify the relation between base and follower rotation as well as directions with
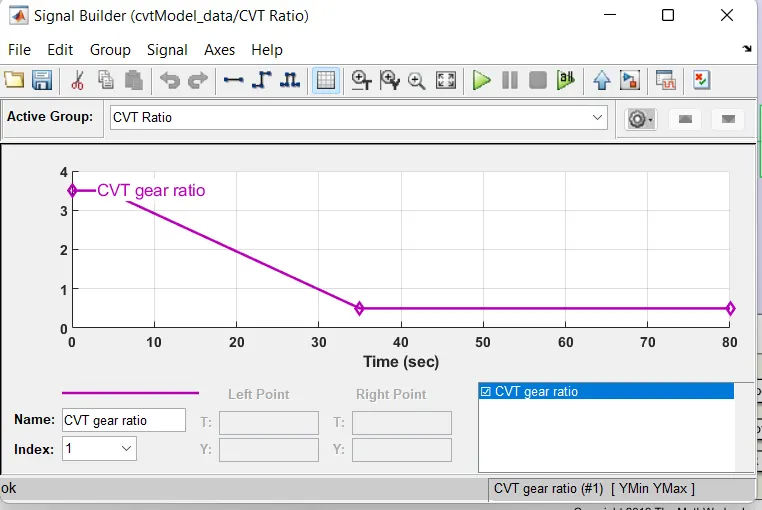
The output shaft rotates directions with the output shaft rotates parameter .CVTs ratio is generated by
Signal builder .
1. CVTs RATIO :
- SIMPLE GEAR :
Represents a system - level model of spark -ignition stages of modeling when only the basis of parameter
are available.optional idle speed and red line controllers are included . the throttle input signal T lies on
between zero and one specifies the torque . if the engine speed falls below the stall speed , the engine torue
is balanced to zero . if the engine speed exceeds the maximum speed , the simulation stop and issues and error
message . Connection F and B are mechanical mechanial rotational conserving ports associated with the engine
Cranckshaft and engine block , repectively . Connection P and FC are signal output ports through which engine
power and fuel consumption rate are reported .
- VEHICLE BODY :
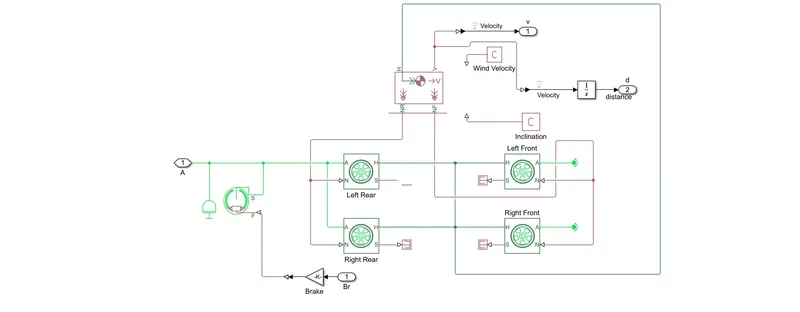
Represent a two - axle vehicle body in longitudinal motion.The block account for body mass, aerodynamic drag , road
inclined and weight distribution between axles due to acceleration and road profile the vehicle can have wheels on each
cycle .optionally include pitch and suspension dynamic and additional variable mass and inertia. the vehicle move does
not move vertically relative to the ground . Connection H is the mechanical translational conserving port associated with
horizental motion of the vehicle body . the resulting traction motion developed by tries should be connected to this port .
Connection W and beta are physically signal imput port corresponding to headwind
Speed and road inclination , angle , repectively . if variable mass is modeled , the signal input port CG . M are exposed
CG accepts a two - element vector representing the Xand Y distance offset from vehicle CG additional load mass . M
represent additional mass .if both variable mass and pitch dynamics are included , The physical signal port J accepts the
Inertia of the additional mass about its own CG .
- RESULTS :
VEHICLE SPEED :
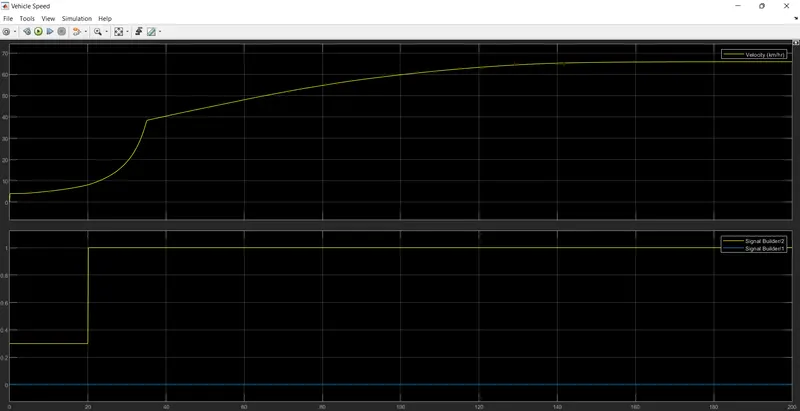
The above plot shows that when trottle is at 0.3 for 20 sec speed of vehicle is increases correspondingly and at full
trottle that is at 1 the vehicle speed is jumped nearly 40 kmph and then proportinally ..
CVT SHAFT SPEED :
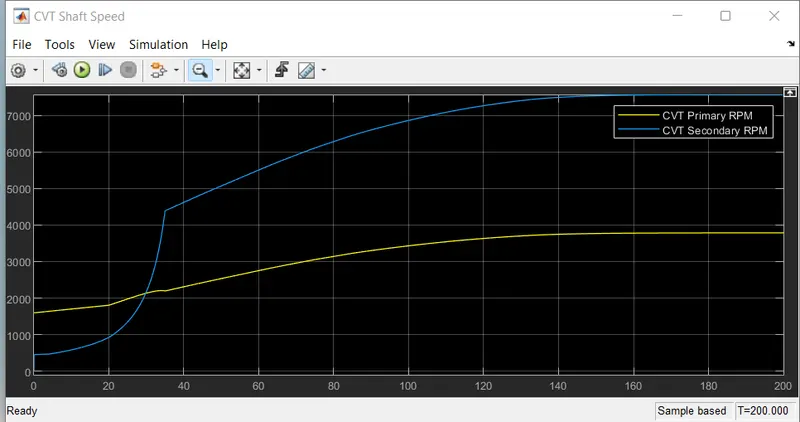
From the above plot it can be observed that the CVTs secondary RPM plot and the velocity of the vehicle from the
previous plot behaves same beacause the secondary pulley is connected to the vehicle output ,
Now the simulation data inspector ,
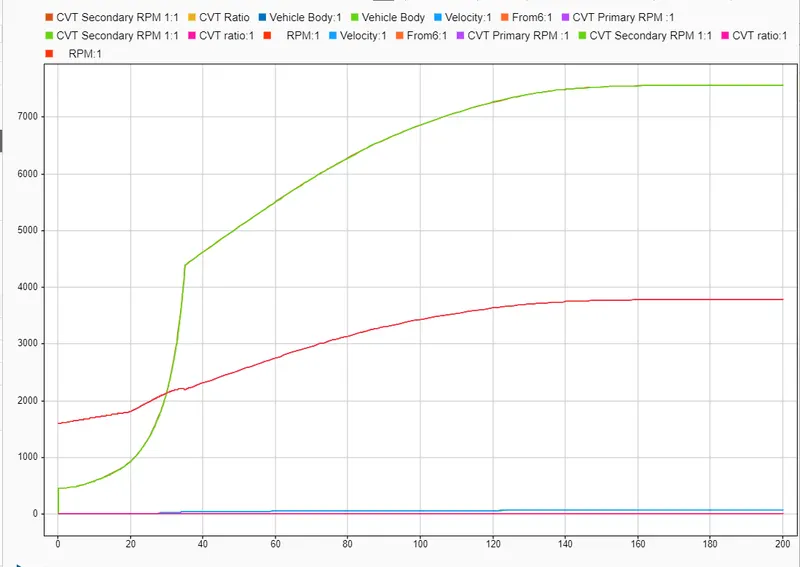
In above plot red plot represent the vehicle with 100kg mass and the blue plot represent the vehicle with 250kg.
Mass and from plot it is clear that lighter the vehicle maximum speed can be obtained and it is clear from the plot
that the velocity of the vehicle of vehicle with a mass 100 kg is slightly more than the velocity of vehicle with a
Mass of extreamly high postion cycle is rotating parts load supply of a mass of 250 kg .
- BAJA ATV MODEL WITH LOOKUP TABLE :
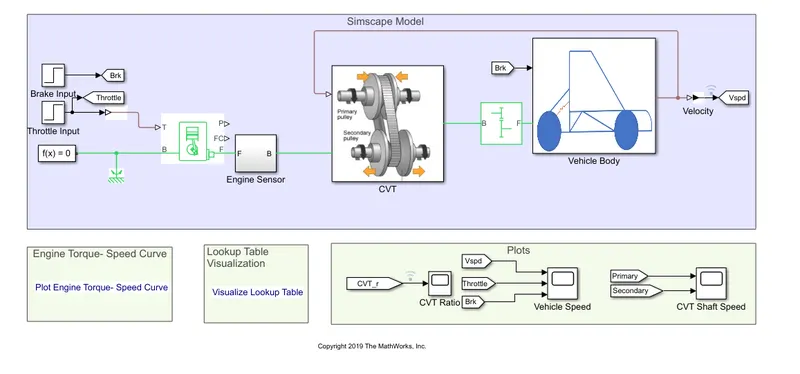
The above model of Baja ATV with CVTs along with the look up table is similar to the previous model wchich include
Generic engine , CVT ,only difference is that the CVT ratio is provided in lookup table .
- LOOK UP TABLE :
A look up table is an array of data that maps input values to output values , a lookup operation retrieves the
Corresponding output not explicit define the input values , simulink can estimate an output values using interpolation
Extrapolation , or rounding ..
Where ;
- An interpolation is a process for estimating values that lies between known data points .
- An extrapolation is a process for estimating values that beyond the range of known data points .
- A rounding is a process for approximating a values by altering its digit accordingly to known rule.
A look up table block uses an array of data to map input values to output values , approximation a
Mathematical function given input values , simulink perform a look up table operation to retrieve the values
Corresponding output values from the table . if values , the block eastimate the output values based on nearby
Table values.
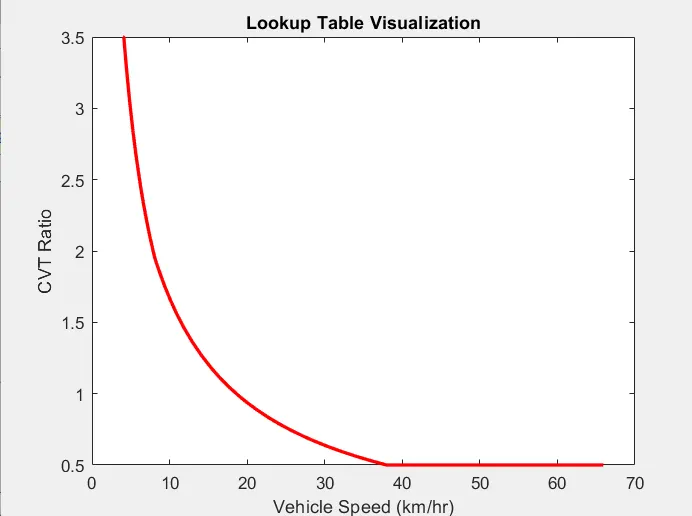
- CVT BLOCK :
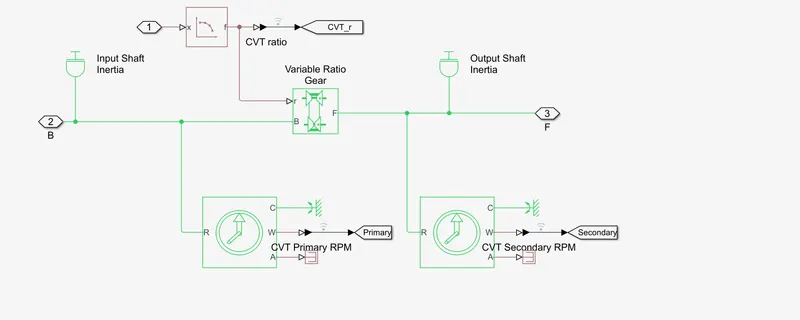
- Input shaft represent the primary pulley and output shaft represent the secondary pulley and mechanical rotational
Sensor is connected to input and output shafts and variable retio gearbox such as implemented by mechanical belt
CVTs , electric ,or hydraulic transmission . the physical signal input 'r' defined the ratio of input to output angular
shaft velocities . connection B (base) and F (followers) are mechanical rotational conserving ports . Specify the relation
betweeen base and follwer rotation direction with the output shaft rotates parameter . CVTs ratio is obtained from the
look up table ..
RESULT : -
- VEHICLE SPEED : -
The above plots shows that when trottle is at 0.3 for 20sec speed of vehicle is increases correspondingly and output
at full trottle that is at 1 the vehicle speed is jumped nearly to 40 kmph and then increases proportionally and the result
remains same as the input parameter remains same .
- CVT SHAFT SPEED :
From the above plot it can be observed that the CVTs secondary RPM plot and the velocity of the vehicle from the
Plot behaves same beacause the secondary pulley is connected to the vehicle output ..
CVTs RATIO :-
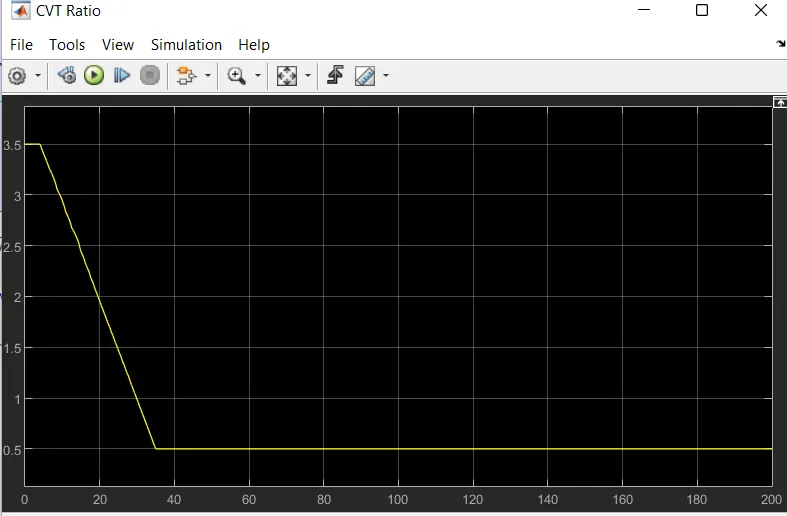
- The above data is obtained from look up table ..
- BAJA ATV MODEL WITH DASHBOARD : -
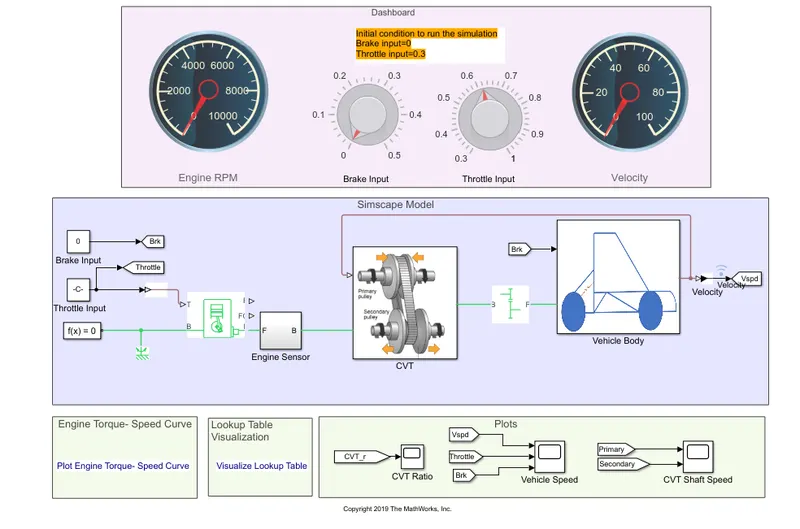
- The study is based 'BAJA ATV MODEL ' with dashboard as shown in figure above here input data like trottle
and brake input is given from the dashboard instead of providing the signals through signal through signal builder
and all the remaining blocks are same .
The main purpose of using dashboard is to study the output values with the
Vibration of input data of throttle and brake in the digital reading .
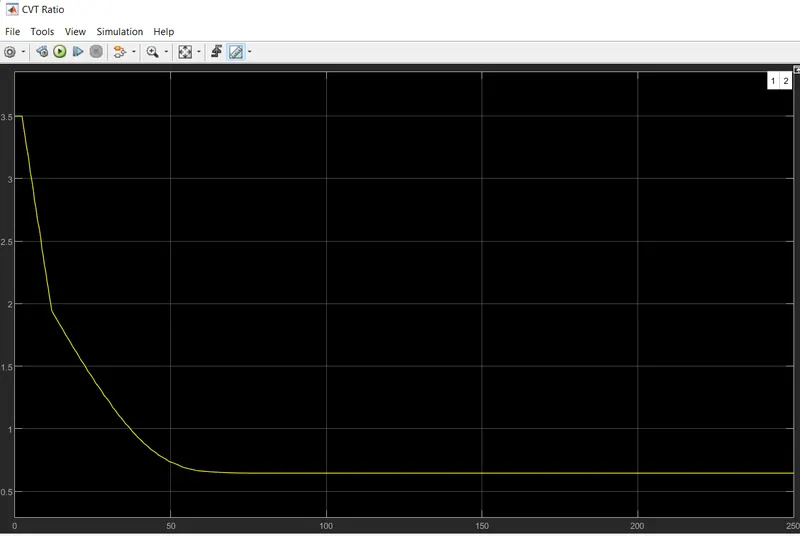
- CVT RATIO :
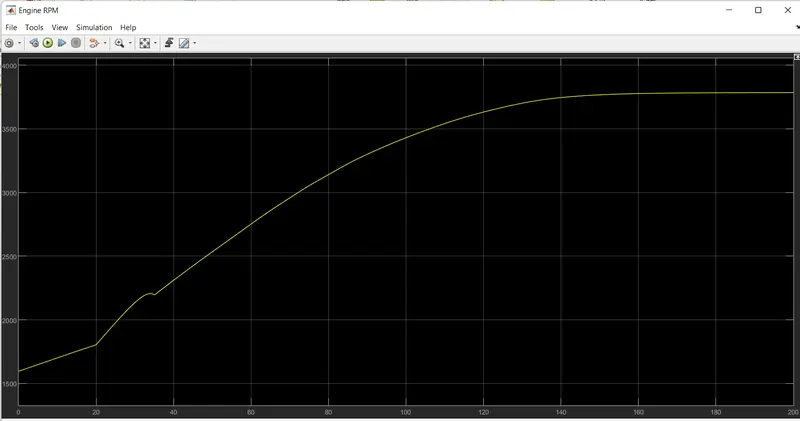
- ENGINE RPM :-
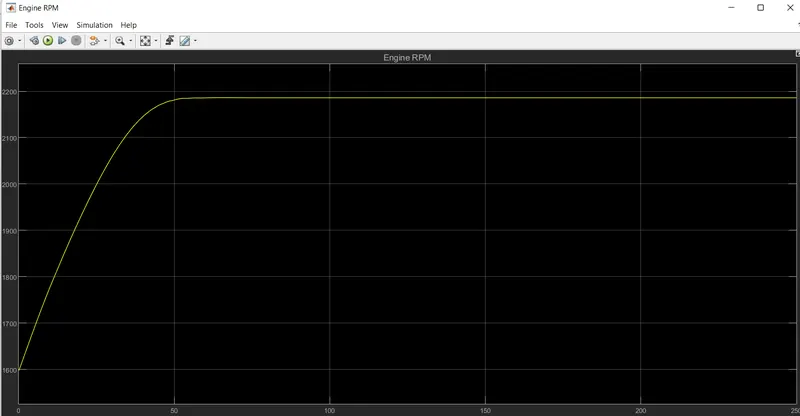
The engine RPM on many kind of disc recording media the rotational speed of the medium under the read
head is standard given in rpm in the study BAJA ATVs model providing is part of the waveform.
- BAJA ATV MODEL WITH DASHBOARD AND LOOK TABLE :
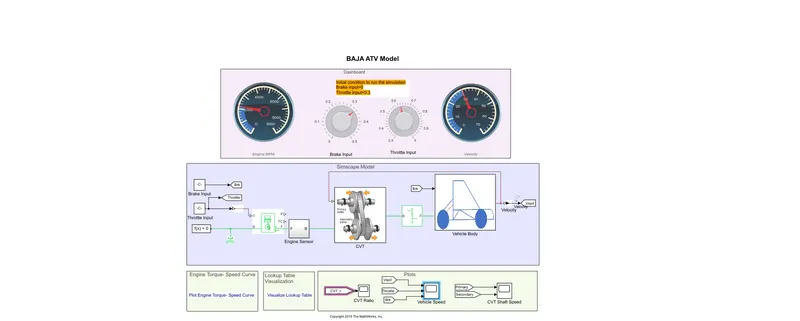
The above model is similar to the previous one with lookup table and the only difference is that the input signal
is provided through knob in the dashboard and corresponding velocity of the vehicle is observed .
- CVT SHAFT SPEED : -
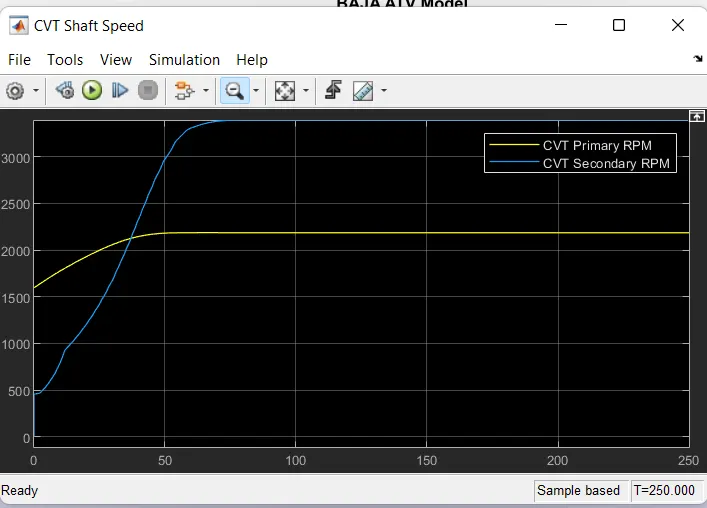
From the above plot it can be observed that the CVTs secondary RPM plot and the velocity of the vehicle from
The previous plot behaves connected to the vehicle output .
- CONCLUSION : -
Simulation of all 4 model of BAJA ATV vehicle has been performed and output is
Plotted for corresponding model by varying the input data .