Project
To Study and analyze the BAJA all Terrain ATV model using simlink and compare between diferent models
Objectives
1. To Prepare a techinal report explainig the function of the subsystem & block used for preparing the model.
2.To Explain in details all the differences between all the five models provided
3. To understad and comment on the results.
Type of model studies:
1. BAJA ALL -Terrain Vehicle (ATV)
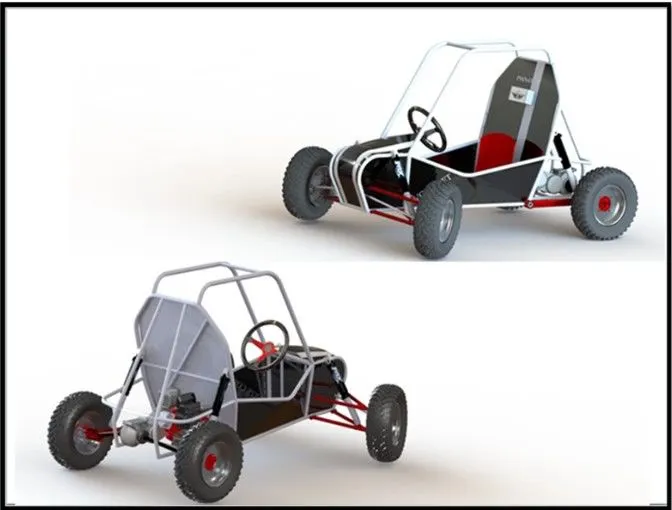
BAJA is basically an ATV completition where students get to design and develop their own ATV keeping in mind various considerations of design as well as safety.An is designed in order to run an various terrains such as soil ,gravel,peddels,etc..
As per the name an ATV (All terrain vechicle) is designed to run and manoeurve on different terrains or in other words we can say that an ATV designed espacially for off roading purpose.
2.Continuous variable transmission:
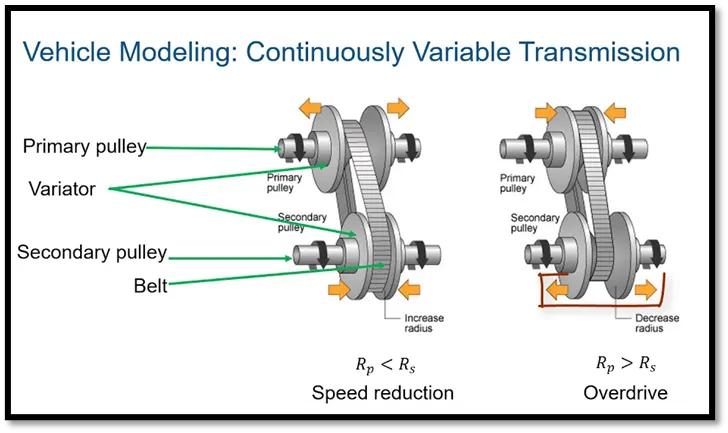
A continous transmission CVT is an that can change seamlessly through a continuous range of gear ratio. This contracts with other transmission that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.CVT are used in automobile,tractor,motor scootor,snowmobiles,bicycles and earthmoving equipements. The most comman type of CVT uses two pulleys connected by a belt or chain based other designs .
SIMPLE CVT model:
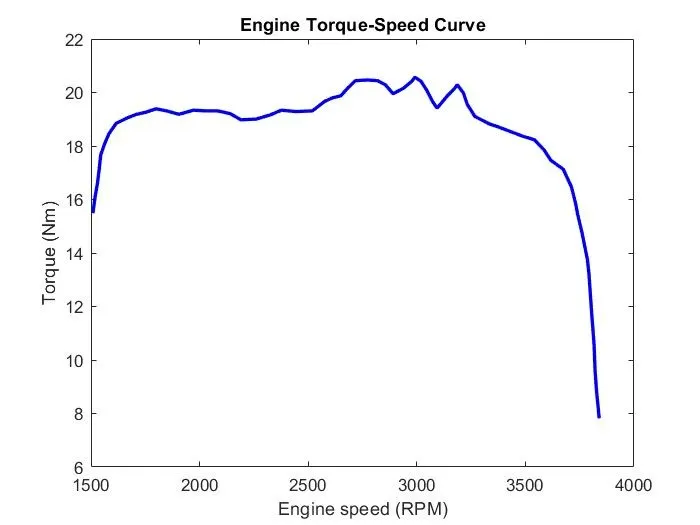
This submission contains a set of models crated with simlink,simscape,and simscapeDriveline.More specifically,the file contained includes BAJA ATV model with continuosly variables transimission CVT. These models shoe how to bulid a ATV with CTV which mostly used in BAJA competitins.Simscape ans simscape driveline have been used to complete the system . the engine data used in the model is provided as an image which shows the engine speed RPM Vs Torque curve. This ia an open loop model CVT.
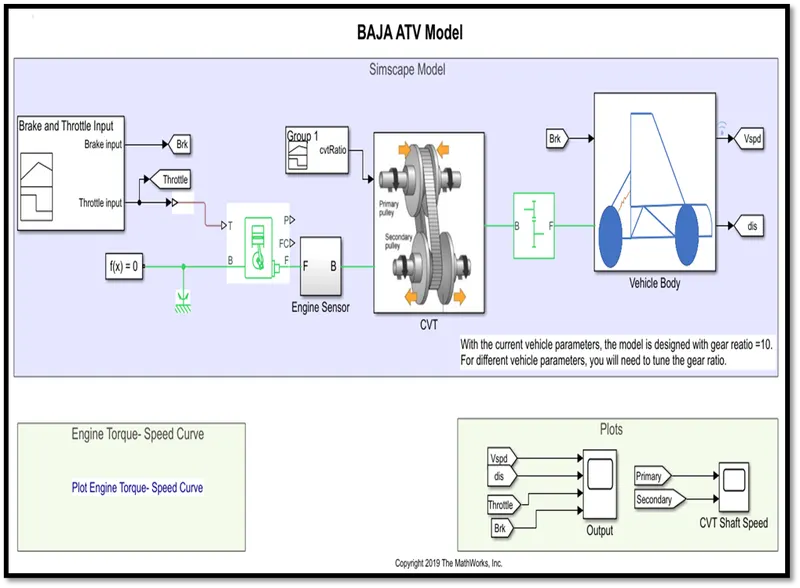
We can see in the above model the input for engine is acceleration.Then the engine was connected with CVT and gave RPM and then simple input to CVT. The Secondary pulley of CVT gave input to simple gear and then simple gear input to vechile body block in vechile body Goto and from block input for engine,CVT and vehicle body from the signal builder block.
In ths above moddel ATV model was made with some inbuild block and subsystem asa follows.
Main Components of ATV Simulation:
Generic Engine
For engine here used generic engine inbild block.The Generic Engine block reperesents a general internal combustion engine.This block is a suitable generic engine for spak -ignition and disel.SPeed-power and speed -torque parameterizations are provided. A throttle physical signal input SPecifices the normalizes `omaga`engine torqe.
optional dynamic physical signal port outputs the engine fuel consumptionrate based on the fuel consumption model that you choose.optional speed and redline controllers prevent engine stall and enables curies control.
The throttle input signal T lies between Zero and one and specifices the torque ddemanded from the engine as fraction of the maxminum possible torque.
Connections F and B are mechanical rotational conserving parts associated with the engine crankshaft and engine block repectively connections P and FC are phyxical signal output ports through which engine power and fuel consumption rate are reported.
Input For the engine:
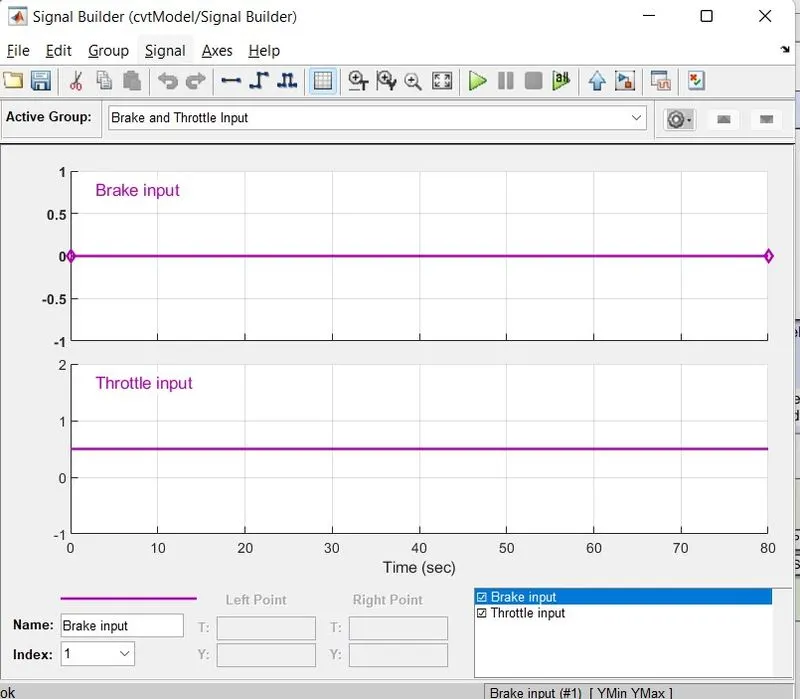
Throttle and breaking these are two inputs for engine her signal builder is used to give input signal for the engine.
we can observe that currently there is no break input and a constant throttle is provided to the system.
Here the data for engine speed and torque is extracted from the following image of speed and torque data with help of GRABIT file exchange option. This function extracts the data point from image and saved in work sapce to use.
Egine Sensor
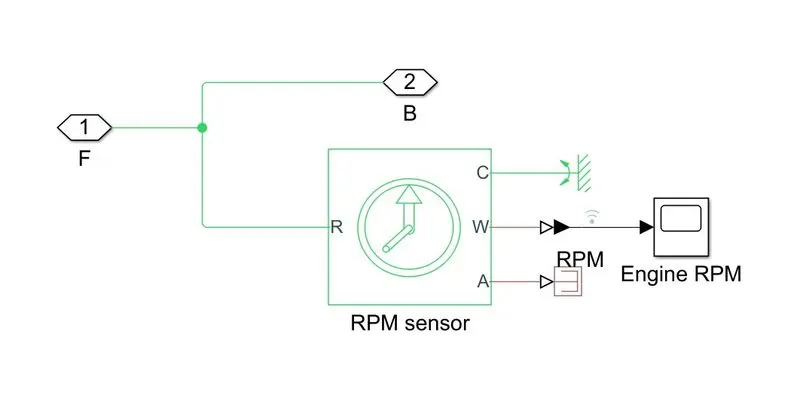
Engine sensor is the ideal Rotational MOtion Sensorblock represents an ideal mechanical rotational motion sensor,that is a device that covertsan across variables measured between two mechanical rotational nodes into a control signal propostational to angular velocity or angle .you can specify the intial angular position as a block parameter.
The sensor is ideal since it does not account for interia,fraction,delay,energyconsumption,and so on. connections R and C are mechanical rotational converving parts that connect the block to the nodes signal output for velocity and angular displacement respecively.
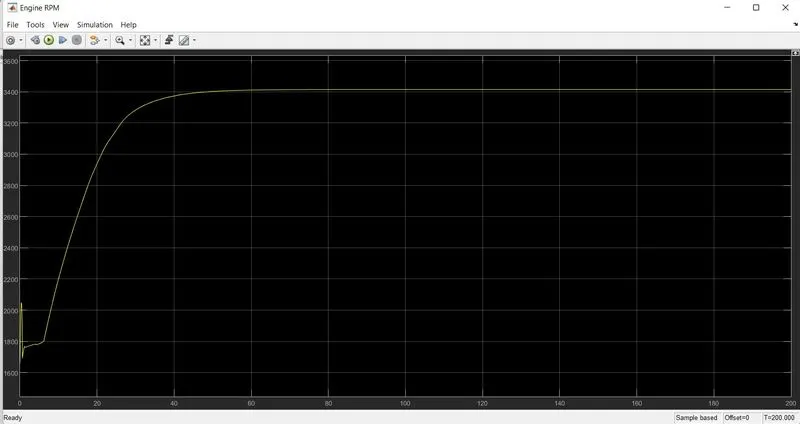
The Block postive direction is from port R and C .This means that the velocity is measured
CVT subsystem
Here we are using gear drive of a CVT which is lower speed insted of oveedrive you can see the difference in following image.
Here we are using gear reduction drive of CVT which is lower speed instead of over drive you can see the difference in followiing image.
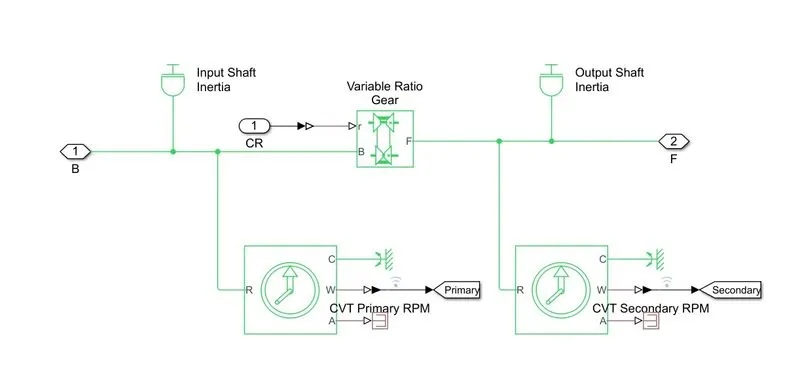
For CVT there is not any block so here sub system for that was created which conatins the folllowing blocks,
- GO to send siganal to from blocks that have specified tag if tag visibility is scoped then a go to tag visibility block must be used to define the visibility of the tag. the block icon displayed the selected tag name and scoped tag name are enclosed in braces.
- Inport peovide an input an enclosed in braces{}.
- interia The block represents an ideal mechanical roatational interia.
- PMC_port: physical modelling connection port block for subsystem
- Variable ratio gear tranmission Represents a variable ratio gear box such as implemented by mechanical belt CVT,electricor hydralic tranmission.The physical signal input r defines the ratio of input to output angular shaft velocities.connections B and F are mechainical ratational conserving ports .Specifiy the relation between base and follower rotational direction with the output shaft rotates parameters.
- Ps terminator use this block to terminate physical signal outputs .unconnected physical signal output ports do not generate warnings but connections to PS terminator can be used to indicate that the signal was not inadvertently left unconnected.
- Mechanical Rotational Reference This block represents a mechanical rotational reference point that a frame or a ground. use it to connect mechanical rotational parts that ar rigidly affixed to the frame
- PS simlink converter converts the input physical siganl to simlink output signal
- The unit expression in output signal unit parametre must match or be commensurate from the physical signal and determine the conversion from the physical signal to the simlink output signal.
Input for CVT
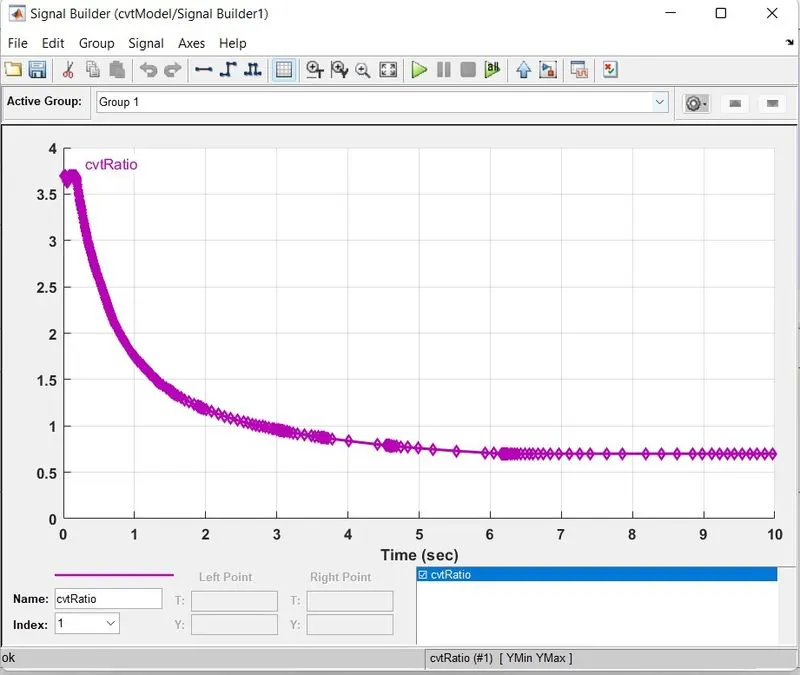
The input for CVT subsystem is CVT ratio and engine rpm.Engine rpm We discuss and CVT ratio is given by signal builder
- Simple gear
Represents a fixed ratio gear or gear box. No interia or compliance is modelled in this block.You can optionally include gear meshing,backlash, and viscous bearing losess.connectionsB and F relation between base and follower ratational direction with output shaft rotates parameter.optinal include effects and expose thermal conserving port H by setting fraction model to a temperture dependent setting
With the current ratio vechile parametre the model is designed with gear ratio=10.
To connect the engine and CVT we need speed reduction so we add simple gear block.
- Vechicle Body sub system
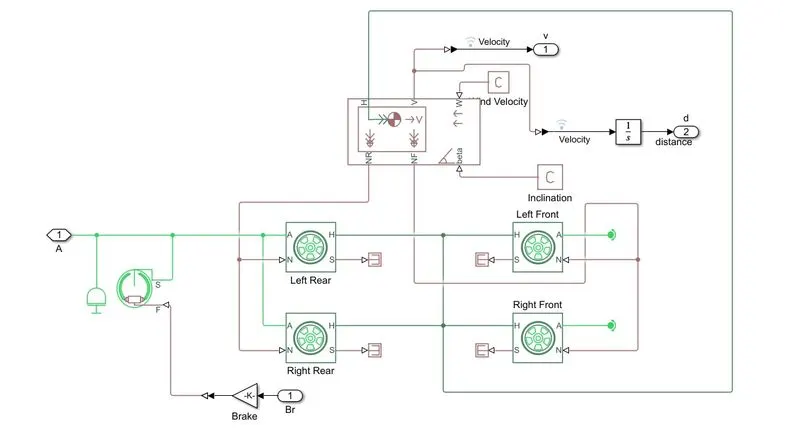
The above model is graphical representation of vehicle bidy and wheel
For the vechicle body is a block but for input connect tire and brake to block so here subsytem was crated.
Vehicle Body:Repersents a two axle vechicle body in logitudinal motion.The block accounts for body mass,areodynamic drag ,road incile and weight distribution between axle due to acceleration road profile.The vechicle can have same or different number of wheels on each axle .
Connection H is the mechinacal translational conserving port associated with horizonatal motion of vechilcle body .The resulting traction motion develops by tires should be connected to this port.
Connections V,NF and NR are physcial signal output ports foe vechicle velocity and front and rear normal wheel forces.Wheel forces are considers postive if acting downwards.Connections W and beta are physical signal input ports correspondingt to headwind speed and road inclination angel.If variable mass is modelled the physical signal input port CG to additional load mass CG .M represents the addition mass if both variables mass and pitch dynamics are includes the signal port J accects the interia of the additional mass about its own CG.
Tire:
Representes the logitudinal behaviour of a highway tire characteried by the tire magic formula. The block is built from tire road intrction and simscape fundation librarywheel and axle blocks.
connection S is a conservin rotational associated with the drum shaft.Connection F is a physica; signal portrepresenting the force input to the actuator.Positive force crates friction torque that resist shaft roatation.
Output Results
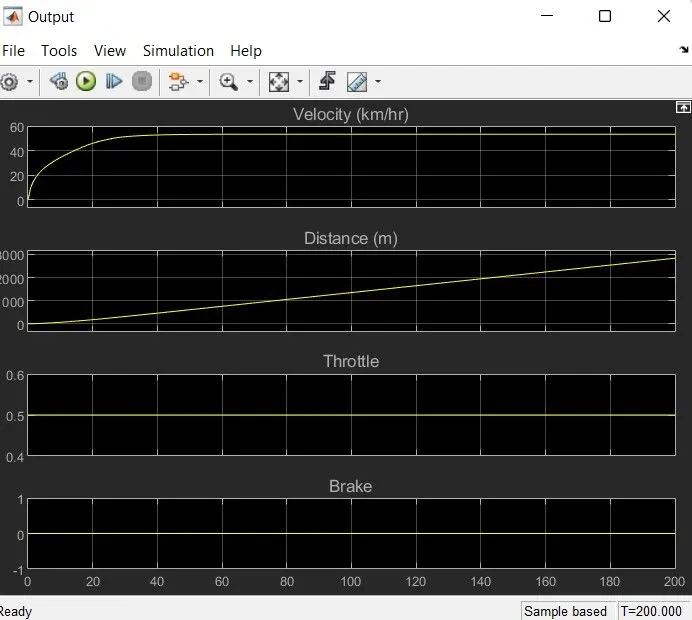
In the above graph w can see that the velocity increase over time 40 sec but after that it will be constant.We cover 3 km distance with0.5 throttled input and no brake applied.
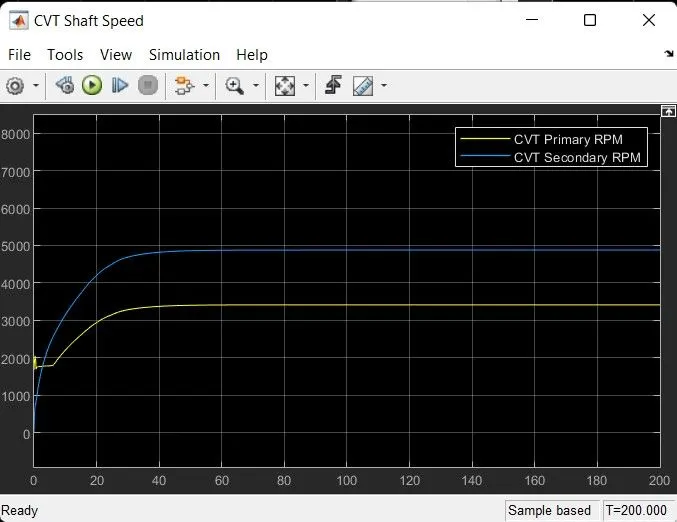
Here we can see that secondary pulley rpm is grater than primarypulley when we accelete the vechicle the primary pulley because we accelearate the vechicle the primary pulley will expand a secondary pulley wil extract this process is nothing but speed redction.
MODEL(Simple CVT model with Dashboard)
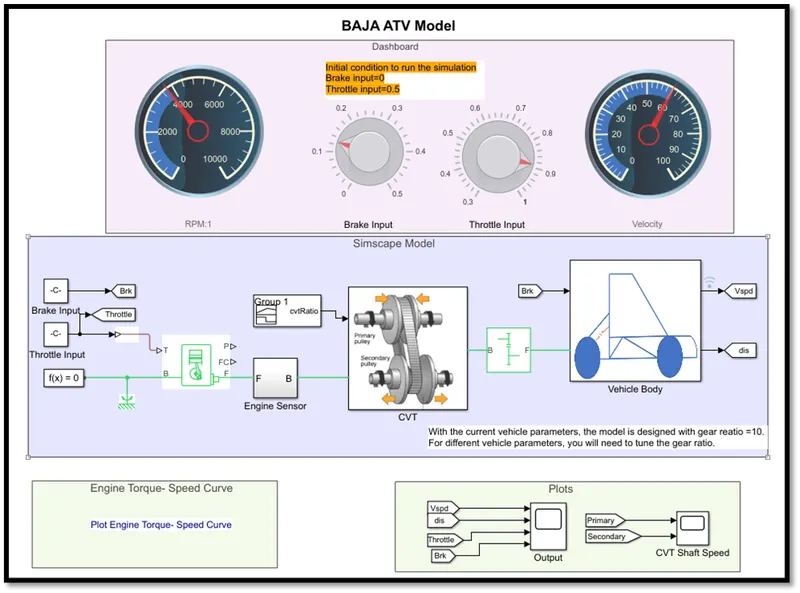
in this model we are used the same model but with different input in running time for actual simulation with help of different block other parameters are all same.To giive input dashboard knobs are used which are connected with constant block which provide input in running time.We gave infinite time for running so we can change the speed and observe the results.This is an open loop model of CVT.
Blocks Used :-
- Circular guage :- Display an input value on a customized guage. Here we connect this block to rpm engine and velocity of body.
- Circular Knob :- Set a value to tune paarameters or variables.Here we connect the block to input constant block which is brake and throttle.
Output Results :-
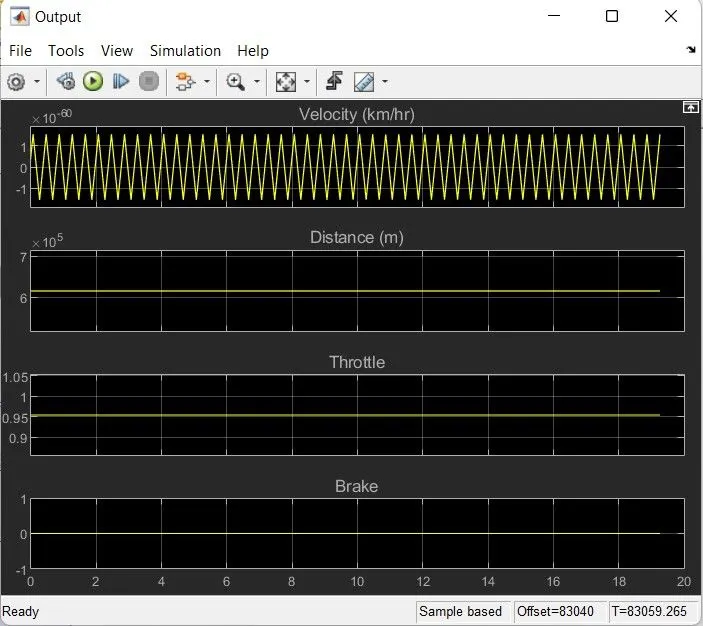
Here we can see that the response of model to the throttle input and brake input.When we start the simulation the velocity at 60Km/hr then we reduce throttle gradually then velocity also decreaded.When we apply a brake then also, we can see that the velocity decreased so we can say that the vehicle speed totally depends on throttle and brake input.
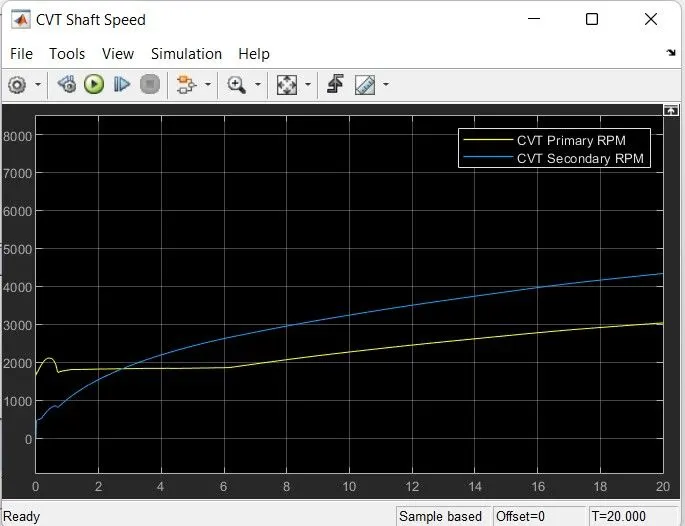
Here we can see that velocity and CVT RPPM graph are identical and primary pulley rpm is less than the secondary pulley rpm because we are using reduction drive for CVT.
MODEl :-
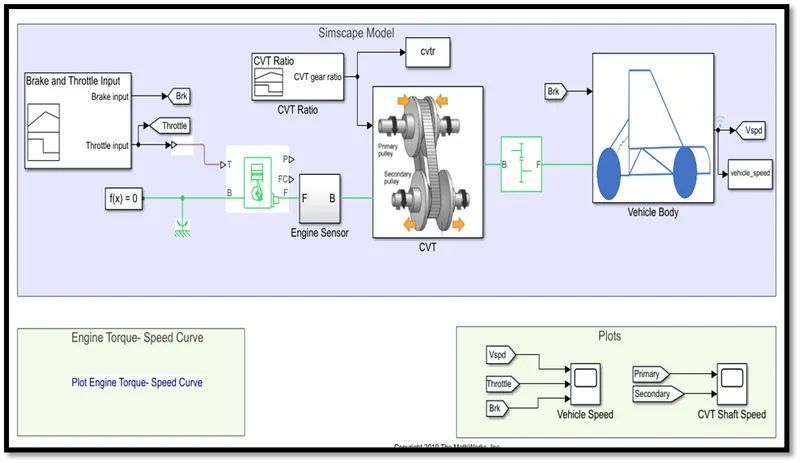
Here we are only changing our input data for more visualization.
New input :-
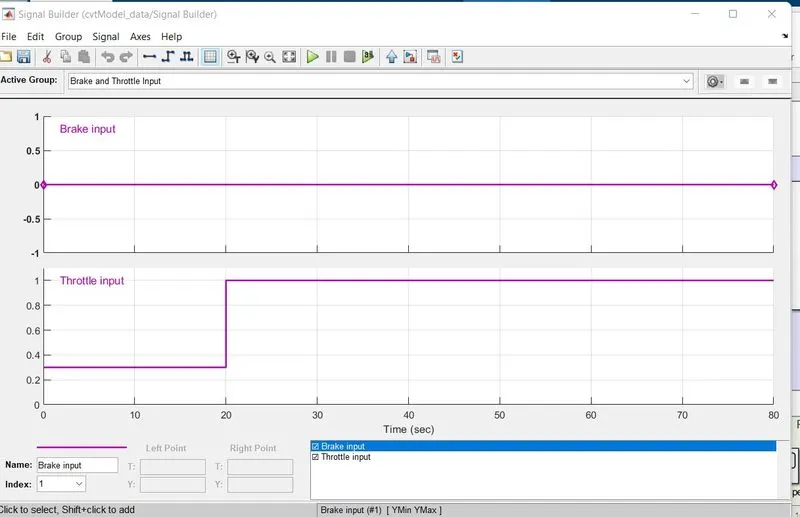
Output for new results :-
Output for new results
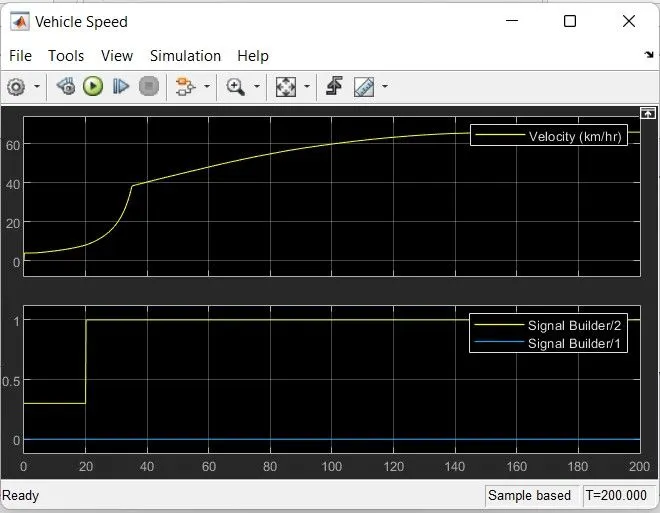
Here we can see that we give input throttle and brake and velocity graph also rresponding according to input given.
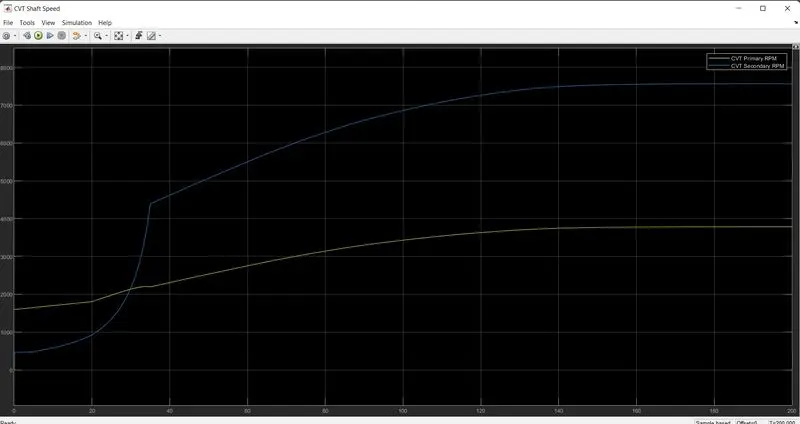
Here we can observe tilll 30 sec the secondary pulley RPM is less than secondary because input we gave sudden acceleration after 20 seconds then constant to 1. So, after 30 again the secondary pulley RPM increaded and primary pulley RO+PM decreased . Hence, we can say that till 30 sec the CVT is in overdrive and after 30 sec in speed reduction drive.
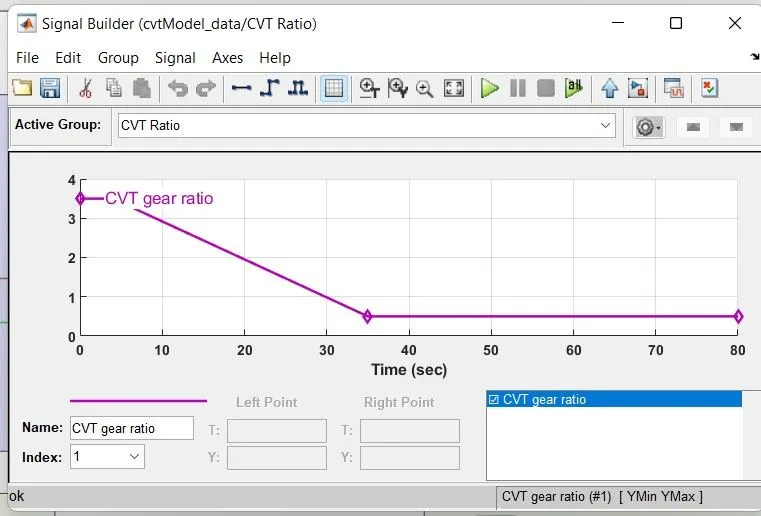
Here we used a simple model to extract the CVR ratio data
Code to extract data :-
%% load and simulate the model
cvtModel_data
sim('cvtModel_data')
%% Visuslize the lookup table
plot(vehicle_speed,cvtr,'r','LineWidth',2)
xlabel ('vehicle Speed (km/hr)')
ylabel ('CVT Ratio')
tittle ('Lookup Table Visualization')
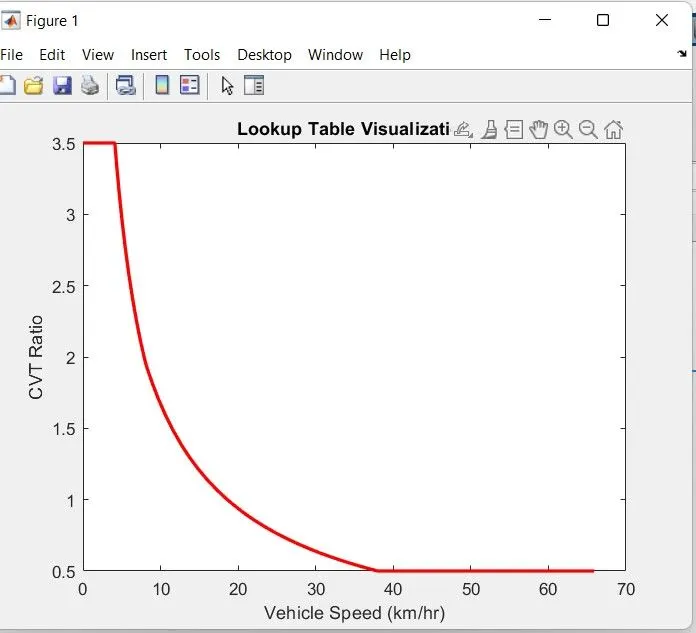
Her we get the CVT ratio to vehicle speed plot for lookup iinput.
Mapped CVT Model :-
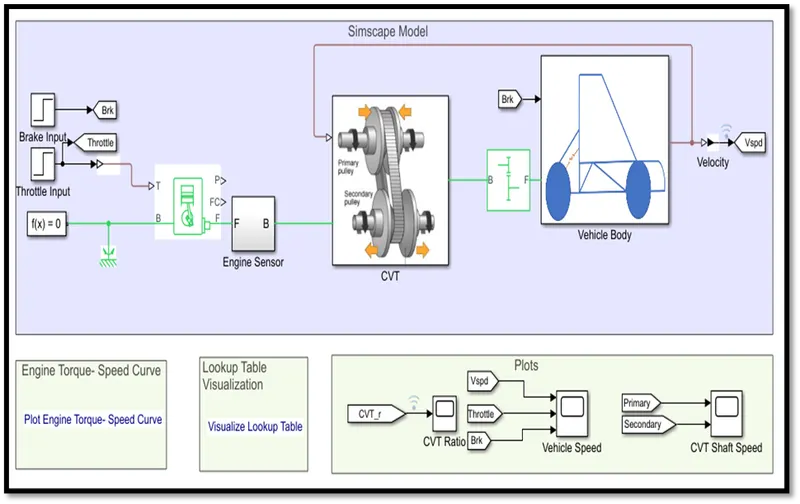
Here we are used lookup table for input the CVT ratio with the help of lookup table visualization and input with step block. This is a close loop model of CVT.
Blocks used in model :-
Lookup table :- A lookup table is an array of data that maps input values to output values, thereby approximating a mathematical function.Given a set of input values, a lookup opeatioon retrives the corresponding output values from the table. If the lookup table does not explicity define the input values from the table.if the lookup table does not explicity define the input values,Simulink cab estimate an output value using interpolation,extrappolation, or rounding, where:
- An interpolation is aprocess for estimating values thst lie between known data points.
- An extrapolation is aprocess for estimating values thaat lie beyond the range of known data points.
- A rounding is a process for approximating a value by altering its digits according to a konwn rule.
A lookup table block uses an array of data to map input values to output values,approximating a mathematical function.Given input values,Simulink performs a "lookup" operation to retrive the corresponding output values from the table.If the lookup table does not define the iinput values, the block estimates the output values based on nearby table values.
Since table lookups and simple estimations can be faster than mathematical function evaluations, using lookup table blocks might result in speed gains when simulating a model. Consider using lookup tables in lieu of mathematical function evaluations when:
- An analytical expression is expensive to compute.
- No analytical expression exists,but the relationship has been determined empirically.
PS lookup table:-
This block represents a physical signal converter whoose input-output relationship is specified by a lookup table. The table grid must be in strictly ascending or strictly descending order,but the spacing can be nonuniform. Right-click on the block and select foundation library plot table to visualize the table data based on the selsected interpolation and extrapolation methods.
This block does not propogate signal units and will be removed in a future release. Use the upgrade advisor to update this block to the latest version.
Input for step block:-
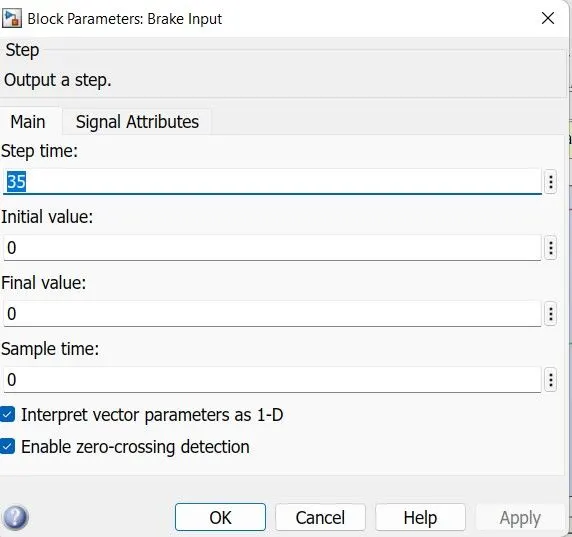
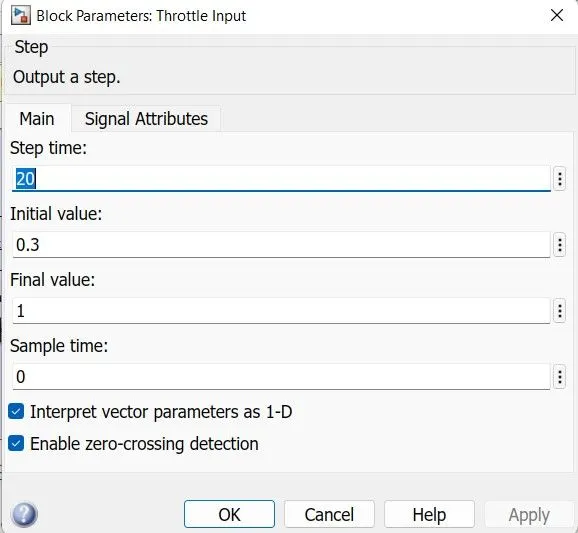
Input for CVT ratio;_
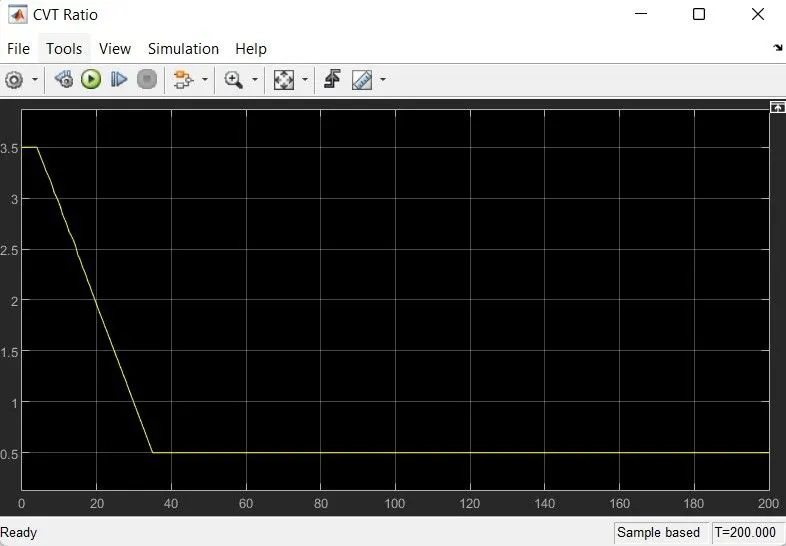
Output Results:-
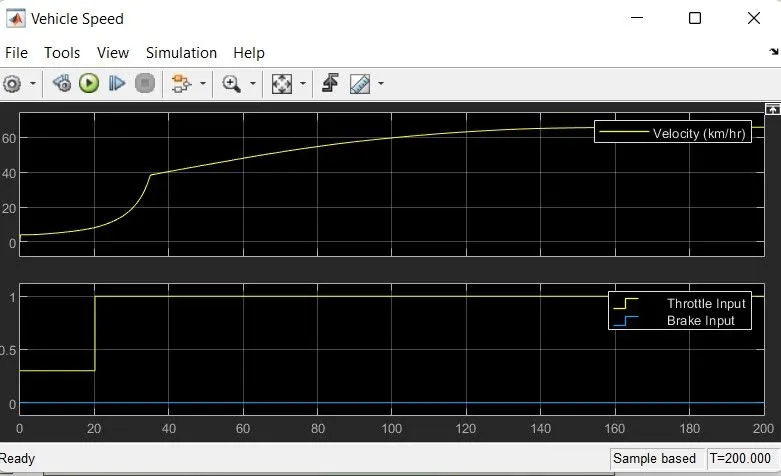
Here we can see that we give input throttle and brake and velocity graph also responding according to input given.
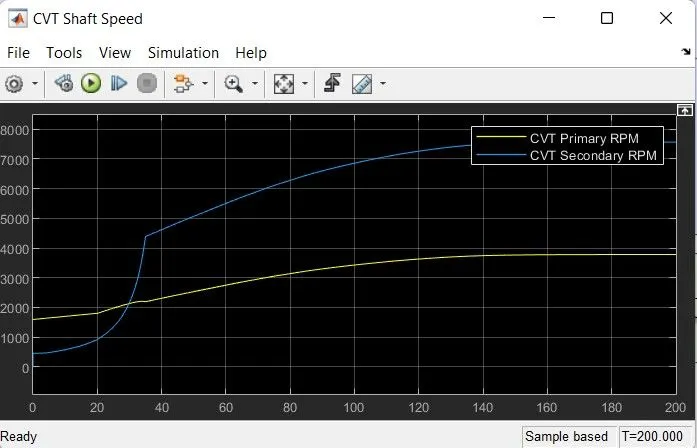
Here we can observe till 40 sec the secondary pulley RPM is less than secondary because input we gave sudden accleration after 20 second the constant to 1. So,after 40 sec again the secondary pulley RPM increased and primary puley RPM decreased. Hence, we can say that upto 40 sec the CVT is in override and after 40 sec in speed reduction drive.
Mapped CVT model with dashboard:
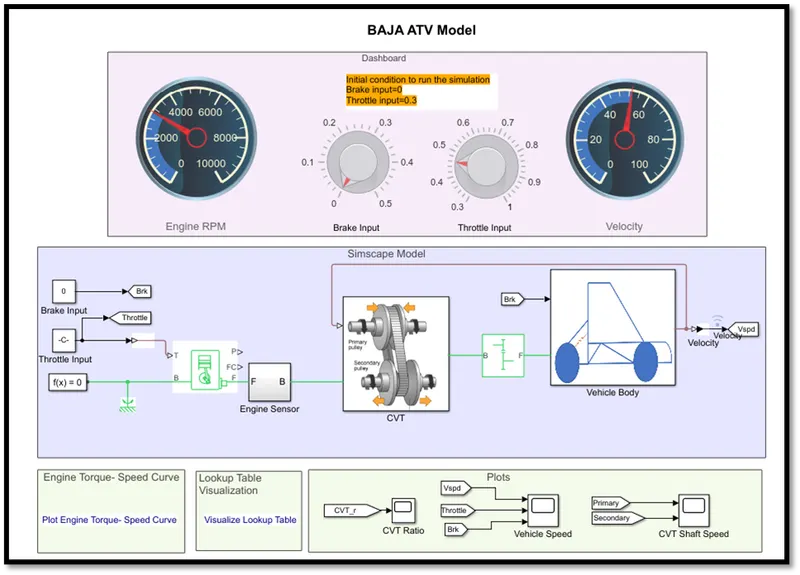
Here we are used lookup table for input the CVT ratio and input with control knob as above dashbaord model. This is a close loop model of CVT.
Input for CVT Ratio :-
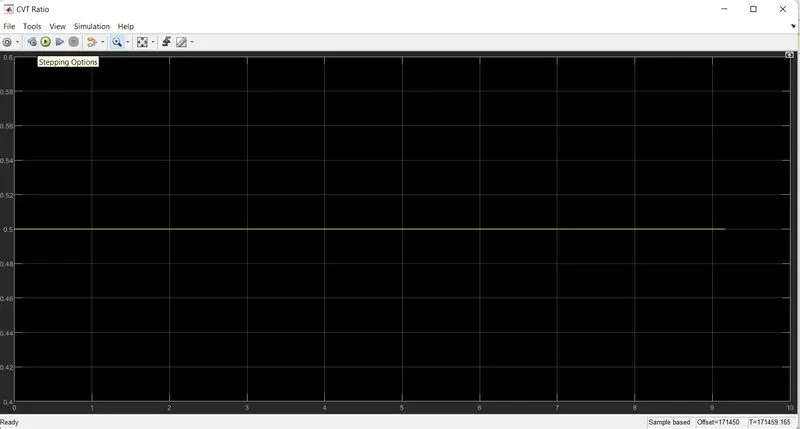
Output for Results :-
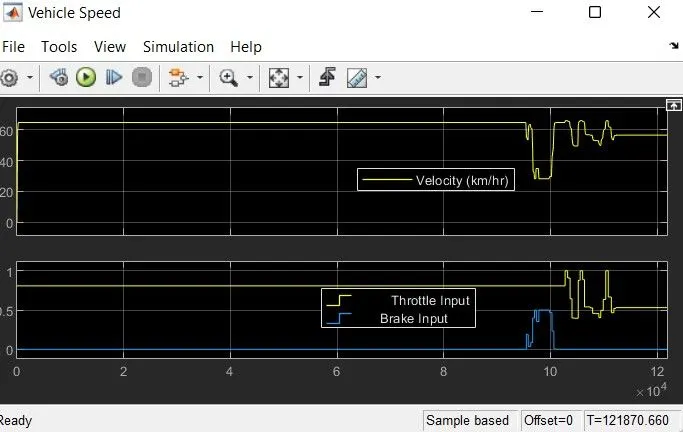
In the above figure we can see that velocity follows the same path as the input which is throttle and brake input
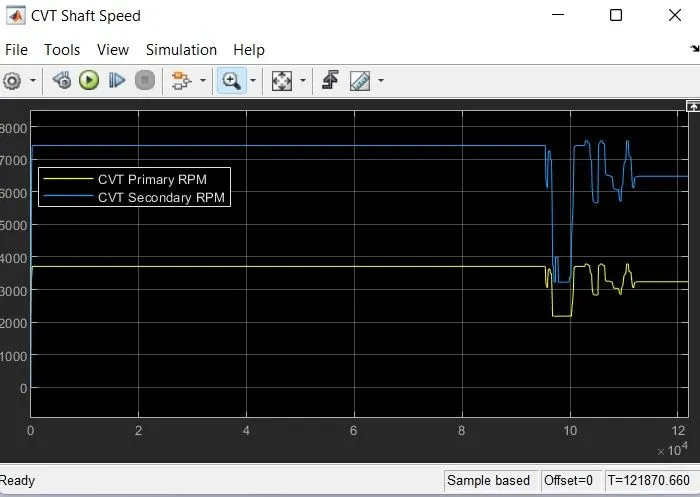
Here we can see that the velocity and CVT RPM graph are identical and primary pulley RPM is less than the secondary pulley RPM because we are using speed reduction drive for CVT.
Conclusion :-
We can conclude that we have sucessfully simulated the Baja All Terrain Vehicle with different methods like open loop model and close loop model. We got satisfactory results for the simulation. We can use this model to simulate actual data for SAE competition.