Project
AIM :-
To carry out system level simulation of an all terrain vehicle.
Introduction :-
An all-terrain vehicle (ATV) is defined as a motorized off-highway vehicle designed to travel on four low-pressure or non-pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control.
Case 1.
Simulink model for BAJA ATV with CVT :-
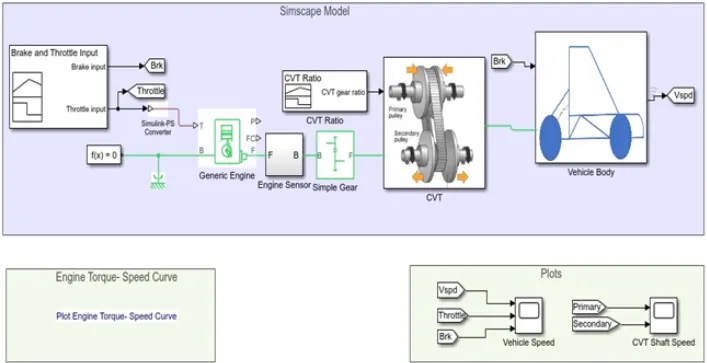
Componentsin the model :-
CVT:-
A CVT transmission, or continuously variable transmission, seamlessly changes through an unending range of effective gear ratios while you drive, whereas other kinds of mechanical transmissions offer a fixed number of gear ratios and have hard shifts between each.
CVT Block :-
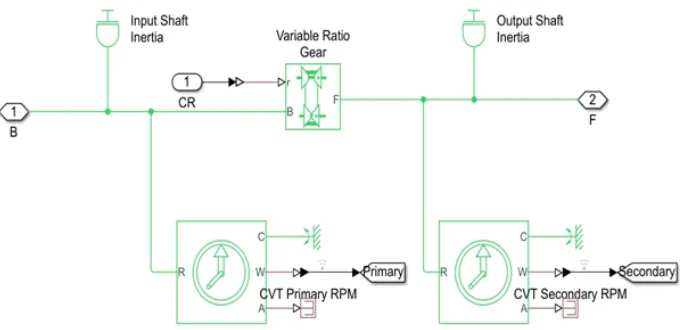
Variable Transmission Ratio:-
Engine :-
Input signal :-
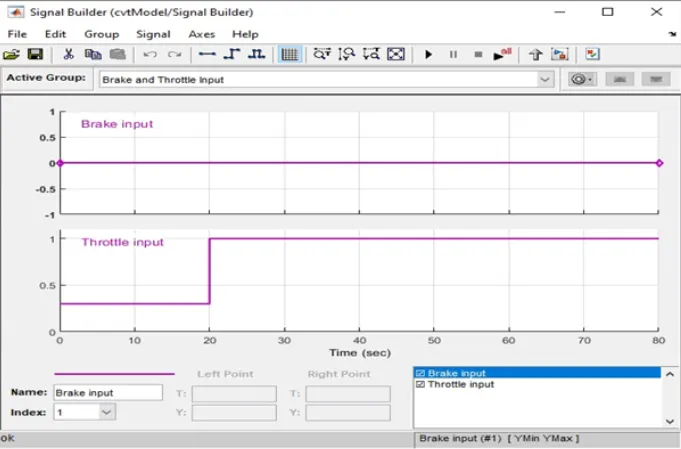
A signal builder is used to create signal for brake & throttle.
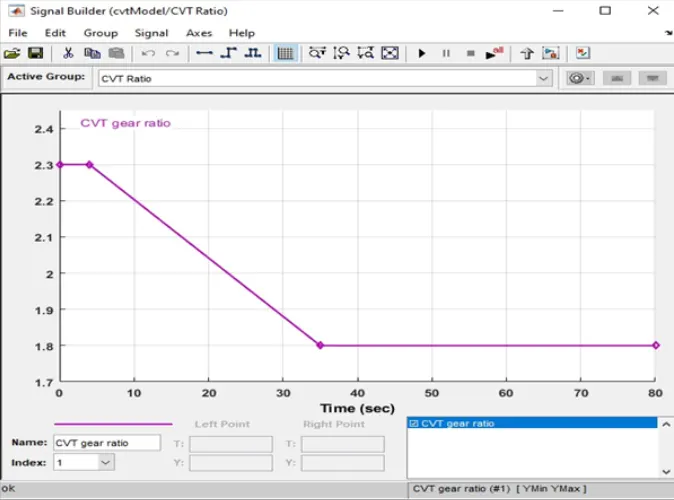
CVT gear ratio input :-
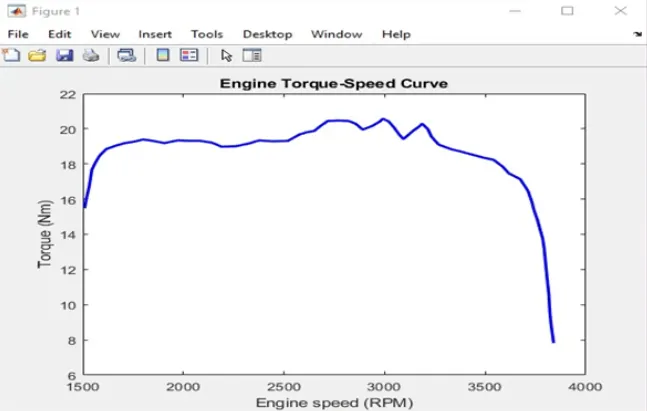
Torque vs RPM input :-
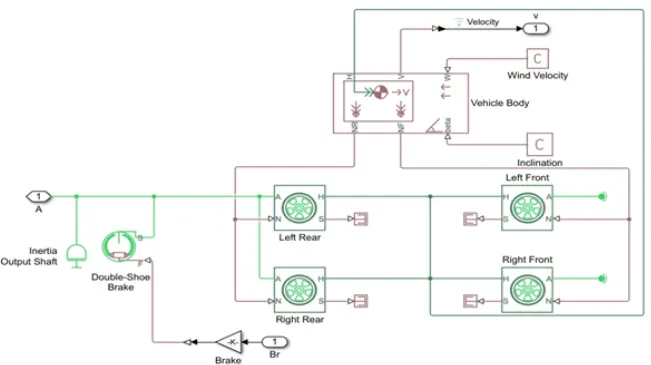
Vehicle Body :-
Output :-
Case 1:-
Vehicle speed:-
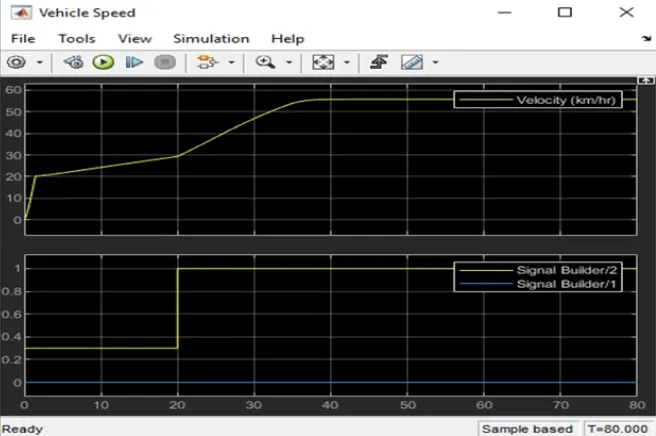
From the graph we can see that max speed of vehicle is 55km/hr at full throttle=1 after 30 seconds & remain constant.
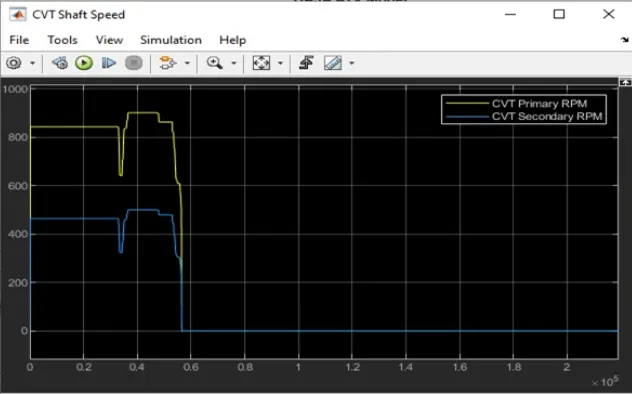
CVT shaft rpm :-
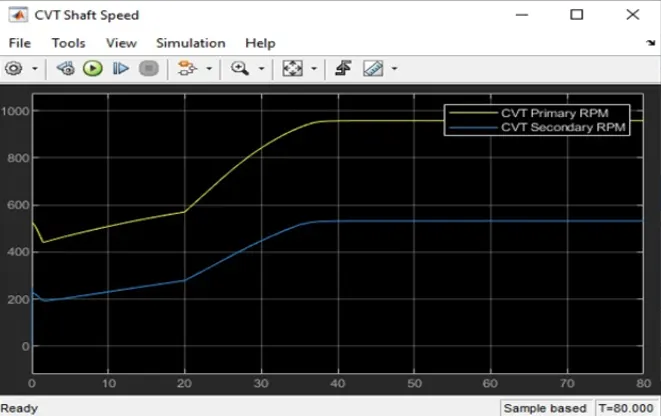
This shows the variation in angular velocities of input & output shafts of variable gear transmission system.
Case 2.
Simulink model for BAJA ATV with CVT using dashboard :-
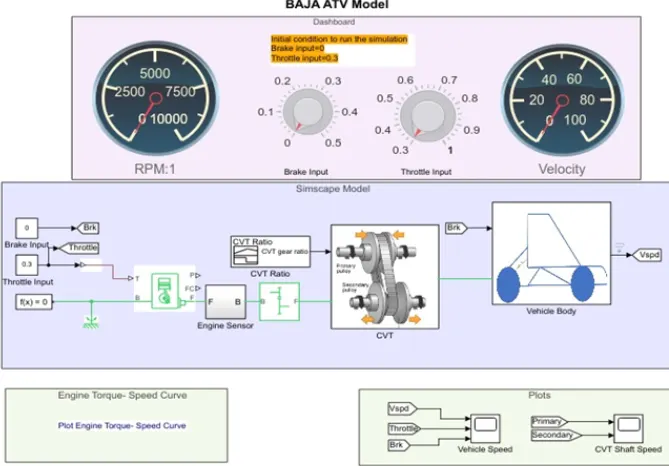
This dashboard contains knobs to control inputs. In this throttle & brka are not provided using signal builder.
Output:-
Case 2
Vehicle speed:-
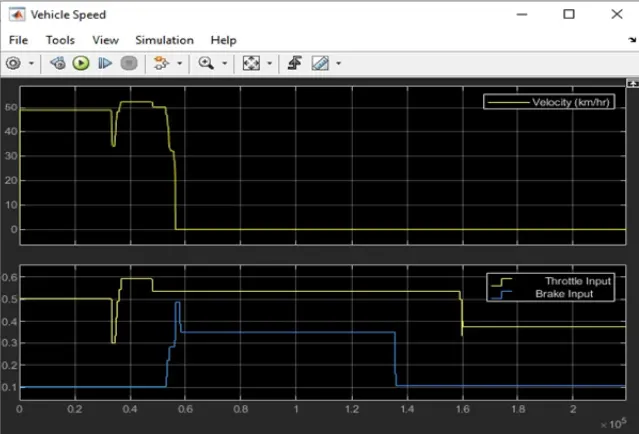
It shows that velocity of the vehicle increases drastically from 0 to 50 kmphwhen throttle value is 0.5 & brake input is 0. Once braking value increases from 0.1 to 0.5, the velocity of the vehicle decreases to 0 at constant throttle value.
CVT shaft rpm:-
Conclusion :-
We have analysed different model of atv with cvt & recorded the outputs with respect to variations in input throttle & brake .