Project
BAJA ALL TERRAIN VEHICLE SIMULATION:
Objective
The purpose of this challenge is to study the various characteristics of ATV vehicle under different parameter variations and CVTs role in ATV vehicle which is an major role in this vehicle.
Firstly,What is ATV?
ATV is ALL TERRAIN VEHICLE which is 4 wheeled ,single seater which is used for Rugged areas.It will have the high suspensions to engage in a rugged and uneven road paths.An all-terrain vehicle (ATV) is defined as a motorized off-highway vehicle designed to travel on four low-pressure or non-pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control.
Components Used:
1.Generic Engine
2.CVT
3.Vehicle Body
1.Tire
2.Brake System
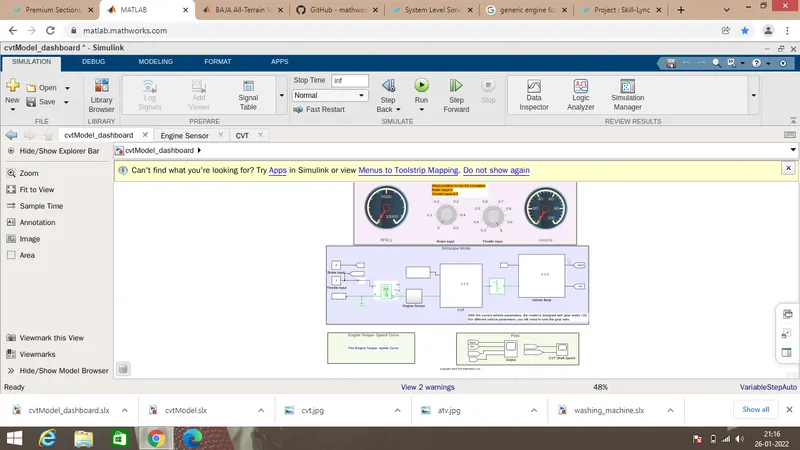
Simulink Dasboard Model
CVT
CVT is Continuous Variable Transmission which is used to make the transmission smoother than the traditional one. In Traditional gear system ,gear shifting process makes the vehicle to engage with the engines to the wheel takes time. But ,in the case of CVT ,there is smooth variations in the gear transition to achieve the desired torque,velocity and speed.
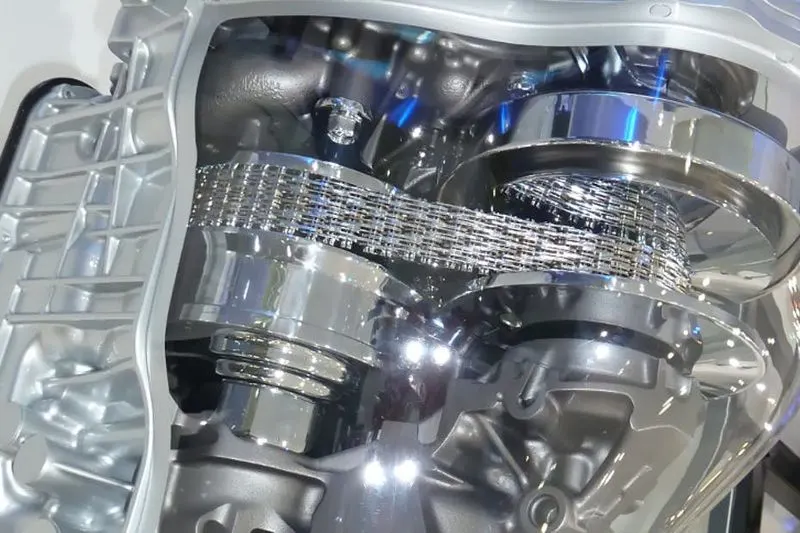
There is a two conical shaped pulley system which are connected with the steel belt.Different sized pulleys are Primary Pulley which is connected to the Engine and Secondary pulley to the wheel.
CVT model:
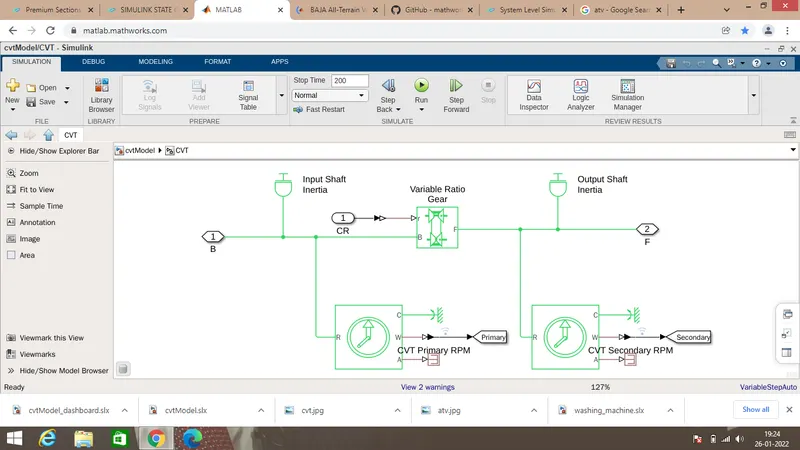
CVT model consists of Input shaft Inertia in the Primary side and Output shaft Inertia in Secondary side.
CR is the CVT ratio input.
Ideal Rotational Motion sensor to monitor the RPM of the primary(input) and Secondary (Output)
How CVT Works?
The width of the pulleys increases according to the variation in Throttle.In order to inrease the output of the the primary pulley size gets increased and Secondary pulley size will gets decrease .
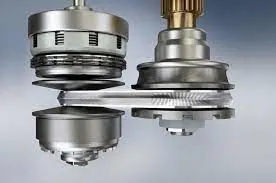
The speed get decreased when Input Pulley size increases and the Output Pulley size decreases.
Driver Pulley is Input shaft and Driven Pulley is Output shaft.
Tire System
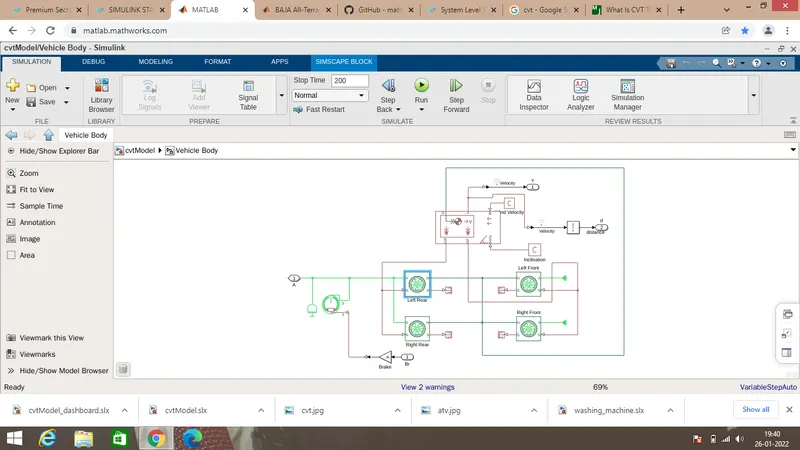
In this model, the nature of tyre is simulated with the terminals A,H,N,S.
H-Thrust developed by the tire is applied to vehicle
A-wheel axle(Mechanical conserving port)
N-Normal force acting on the tire
S-Tire slip
The parameters of tire diameter,inertia to be applied can be given through the parameter section.
Brake System
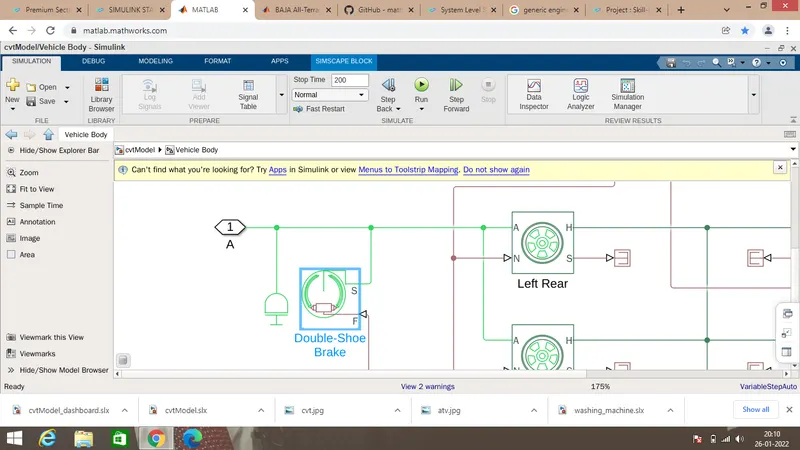
Double shoe Brake is used to apply the brake.
Brake signal is given through the Signal builder through Brk Port.If Brake is applied,the input signal is 1.and 0 for release.
Engine Sensor
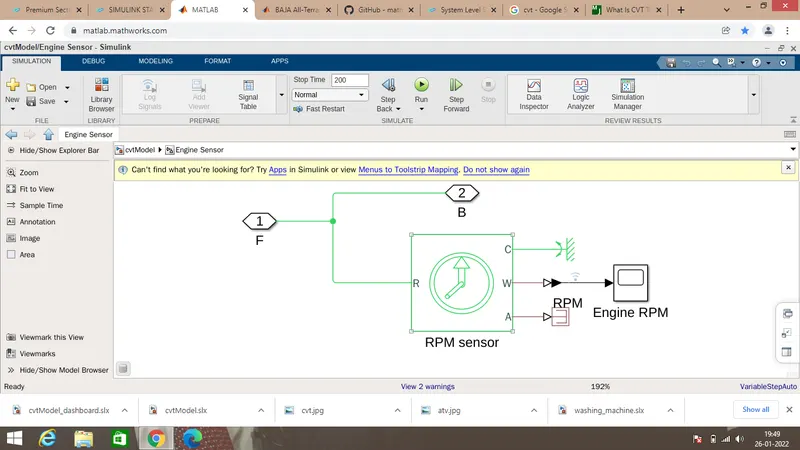
Engine sensor is used to sense the speed of the engine(rpm) .
Generic Engine:
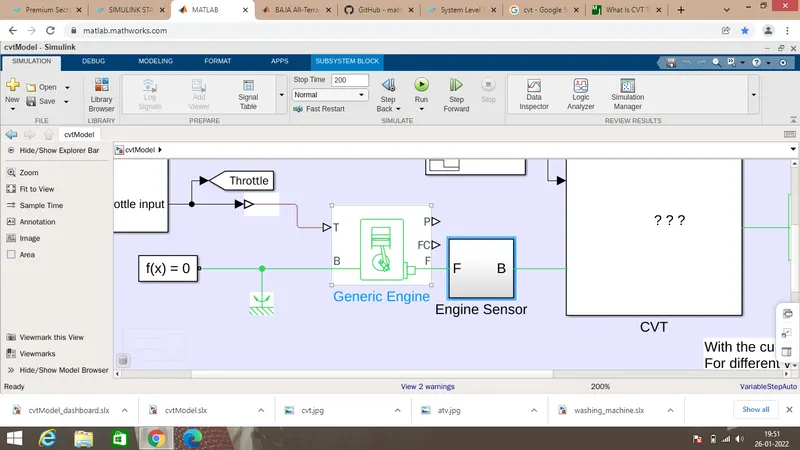
In Generic engine model,
Throttle and Brake inputs are given through the signal builder on the port T,and the engine output is taken from the port F. F port is connected to the CVT Port B through the Engine Sensor .
i.e,The engine shaft is connected to the CVT's primary Input side. As the throttle input is given , the engine start rotates, and the engine shaft is coulped with the CVT primary side. On accordance with the Gear ratio the Secondary(Output )Rpm acts.
Throttle and Brake Inputs:
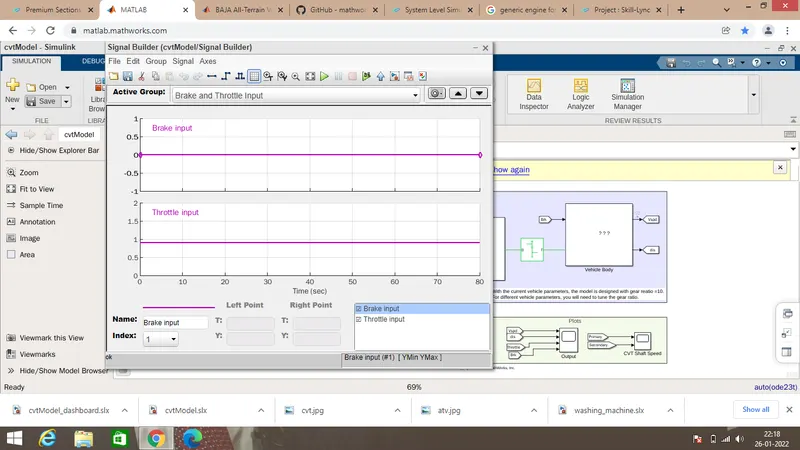
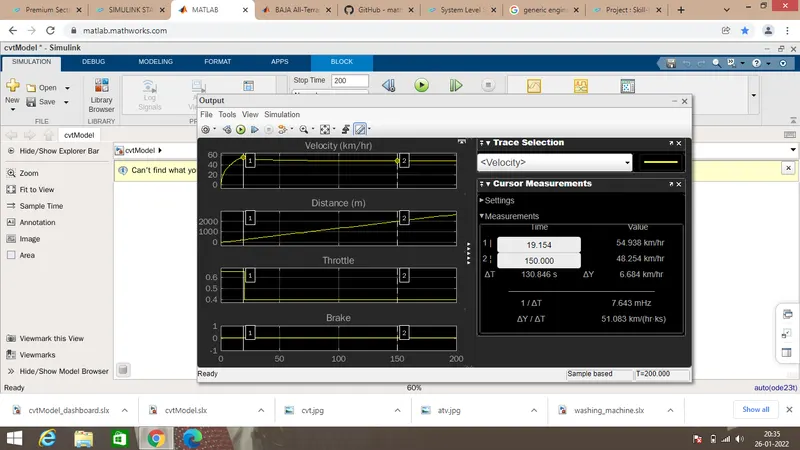
Case:1:When the throttle Positions are o.65 and 0.4,the velocity varies.
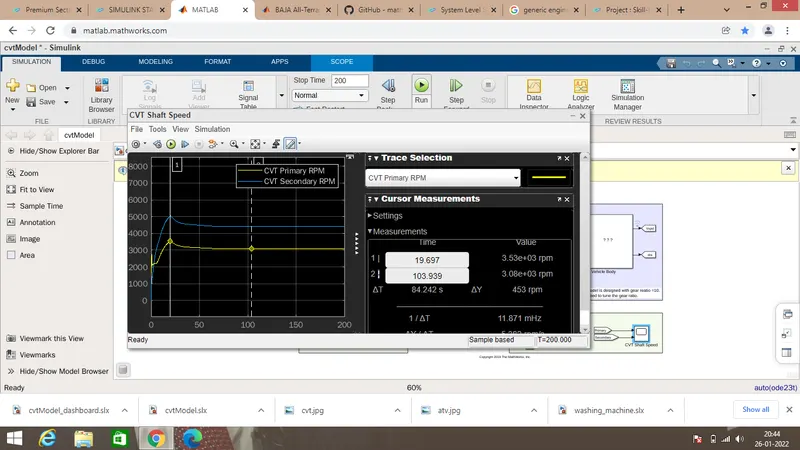
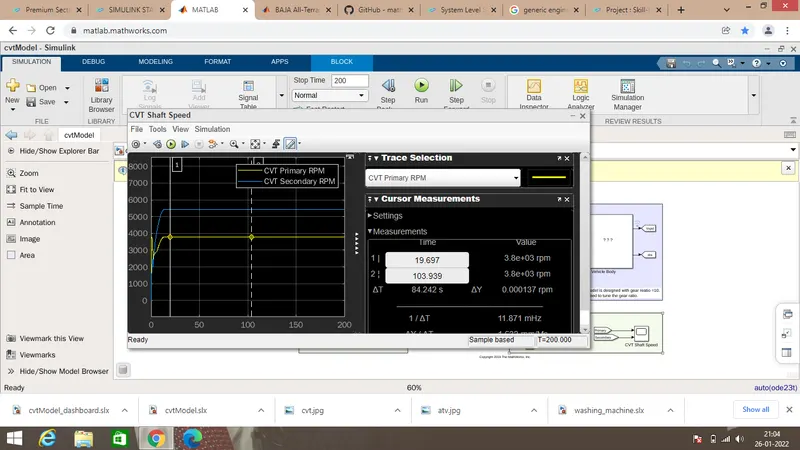
The CVT output for the same case:
Engine RPM
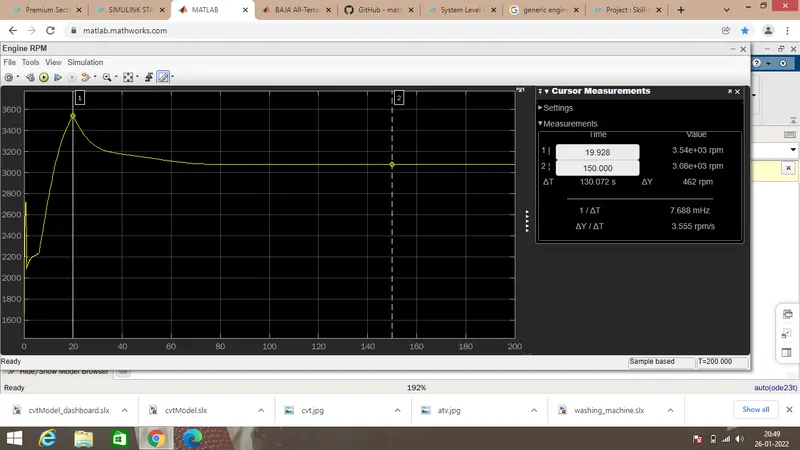
At the 20th sec, when the throttle decreases, the engine rpm gets reduced.
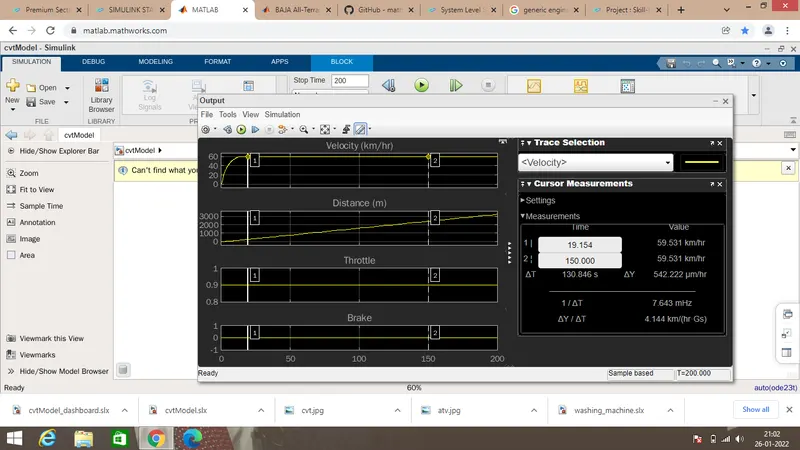
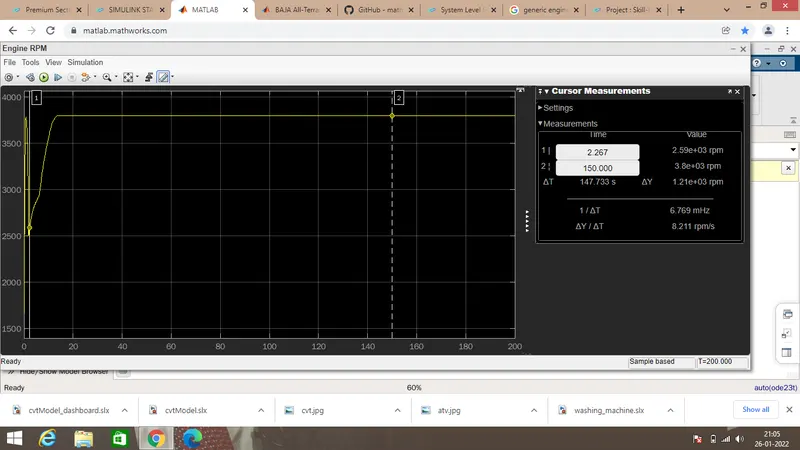
Case-2: When Throttle is 0.9,the results are
Velocity,Distance,Throttle,Brake
CVT scope
Engine RPM
Speed -Torque Curve:
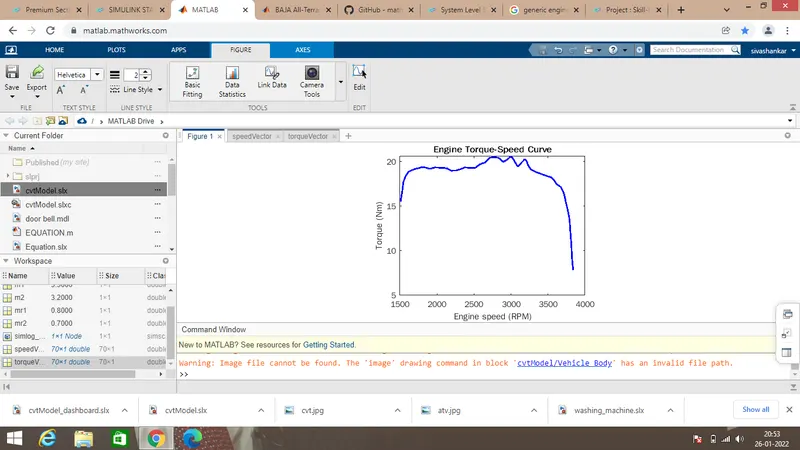
As the Torque reduced gradually when maximum speed attains.
Speed Vector:
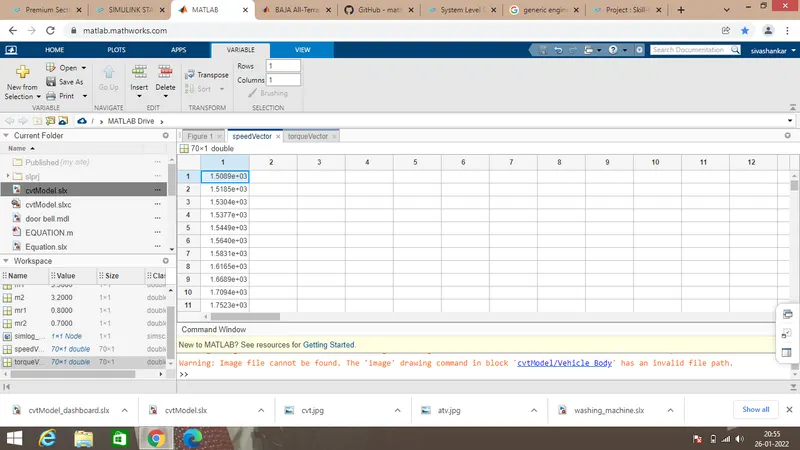
Torque Vector
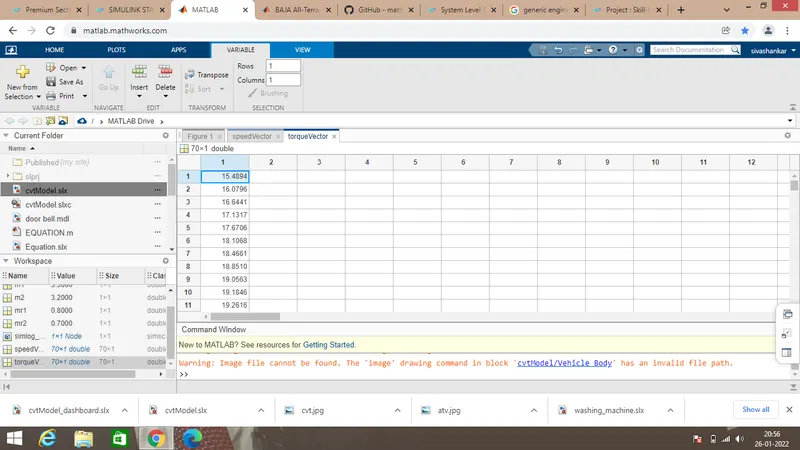
Mass of the vehicle=250kg:
Velocity values:
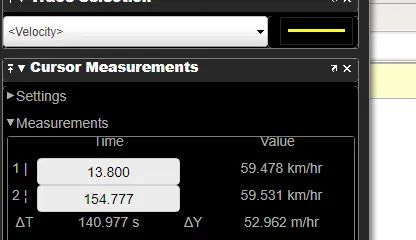
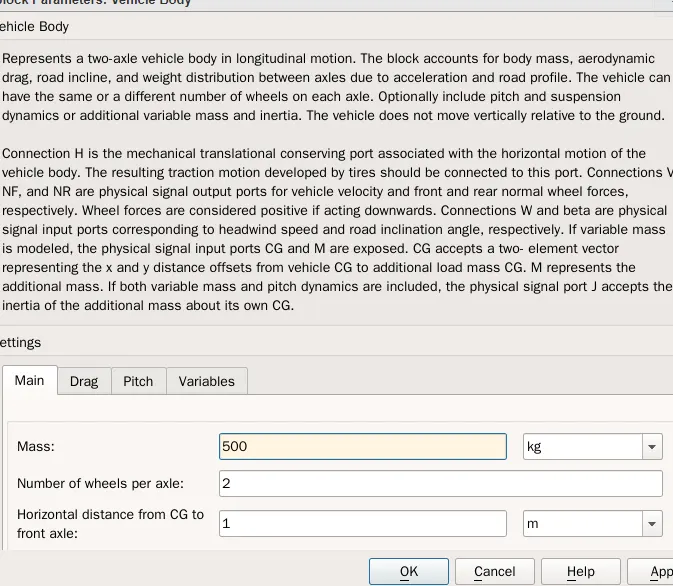
Mass of the vehicle is 500kg.
Velocity and distance values are plotted in graph
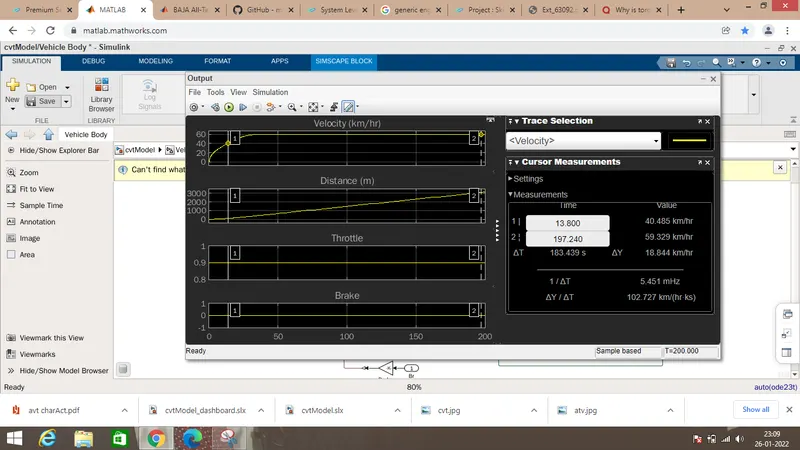
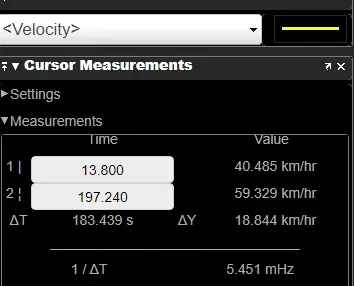
When the mass of the vehicle increases, the time to reach the maximum velocity of the vehicle is get delayed.
When mass=250kg, velocity reached 59kmph at 13th sec;
When mass=500kg, velocity reached 40kmph at 13th sec, and 59kmph reached at 36sec.
Comments:
1.From the results,CVT is used in wide range. CVT plays a vital role in it.
2.Gear transmission is smooth with the speed of the engine. The delay and shifting surges are eliminated with CVT . But, there is a surges at the 2 secs of simulation.After that,the raise in velocity ,rpm,output speed of the vehicle are gradually increasing smoothly with the help of CVT.
3.CVT gear ratio to be finely tuned for the better results for any vehicles.
3.Mass of the vehicle body affect the performance of the vehicle. The time to reach the maximum velocity get reduce .Light weight of the vehicle will give maximum performance.
4.Torque gradually decreases as the speed increase. Speed inversely proportinal to Torque.After the speed increases, there is a constant velocity with respective time. so the torque needed to rotate will get reduce.