Project
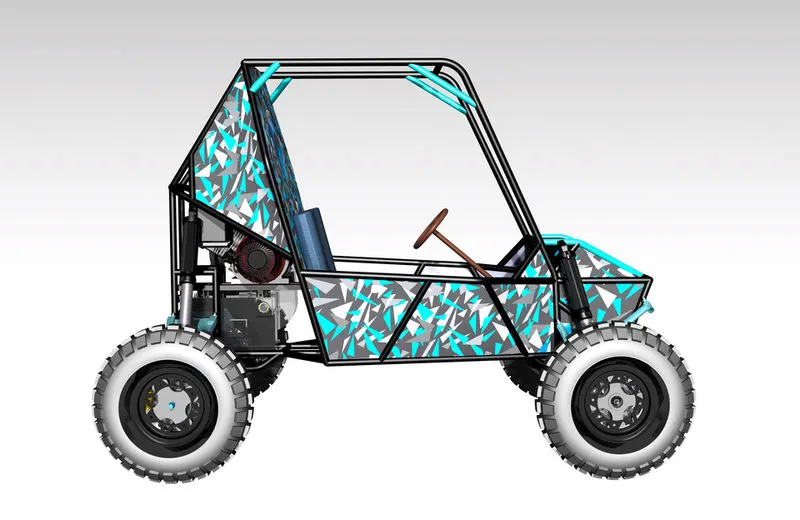
Aim: To carry out a system level simulation of a Baja all-terrain vehicle report explaining the model properties of the result.
Objective:
- A technical report of the Baja ATV model.
- A different property and command on the result.
- Analyse all components and understand the relation and flow of the block.
Task 1
To study Baja ATV based models without using a dashboard.
Theory:
- Simulink Model of BAJA ATV without dashboard
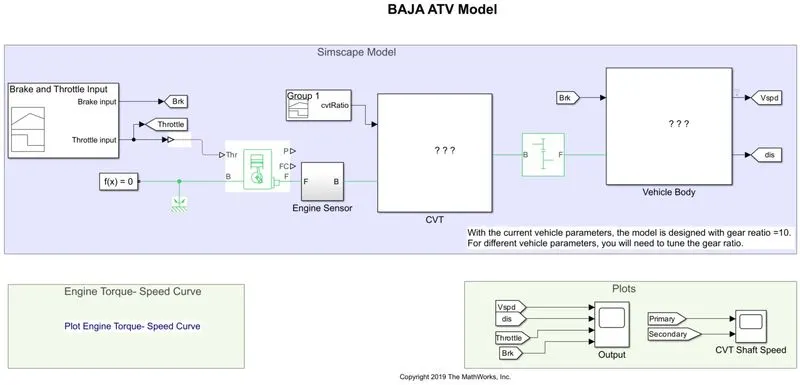
- Simulink block used
- Signal Builder
- Solver Configuration
- Goto Tag
- Simulink ps converter
- Mechanical Rotational Reference
- Generic Engine
- Scope
- Engine Sensor
- RPM Sensor
- Mechanical Rotational Reference
- Scope
- CVT
- Input shaft Inertia
- Output Shaft Inertia
- Variable Ratio Gear
- Ideal Rotation Motion Sensor
- CVT Primary RPM
- CVT secondary RPM
- Vehicle Body
- Double Shoe Brake
- Vehicle Body
- WInd velocity
- Integrator
- Inclination
- 4 Tire
BAJA ATV Model With Dashboard
- In this simulink model of baja Atv, break input and throttle are given by signal builder.
- After the input given by signal builder to the generic engine, then generic engine gives signal to engine sensor
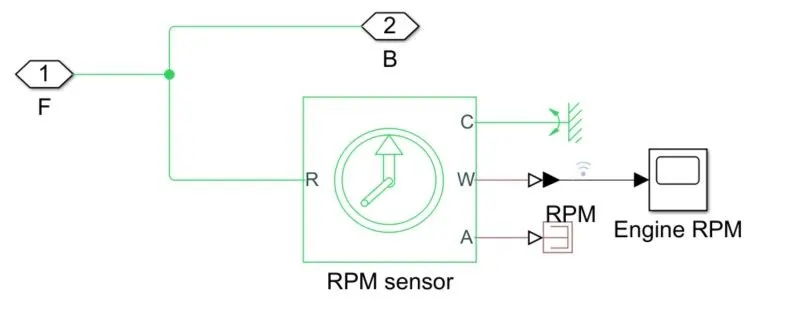
- Engine Sensors
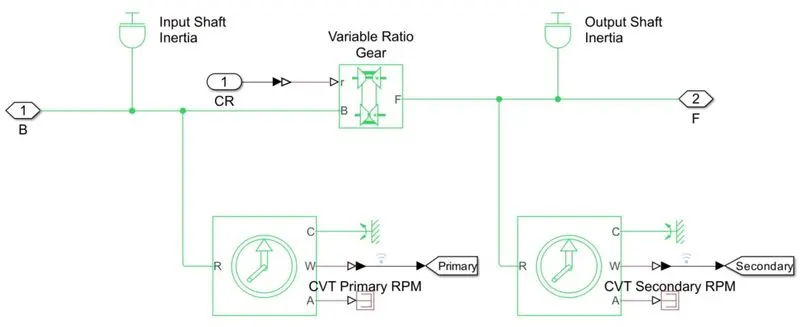
- CVT
- Vehicle Body
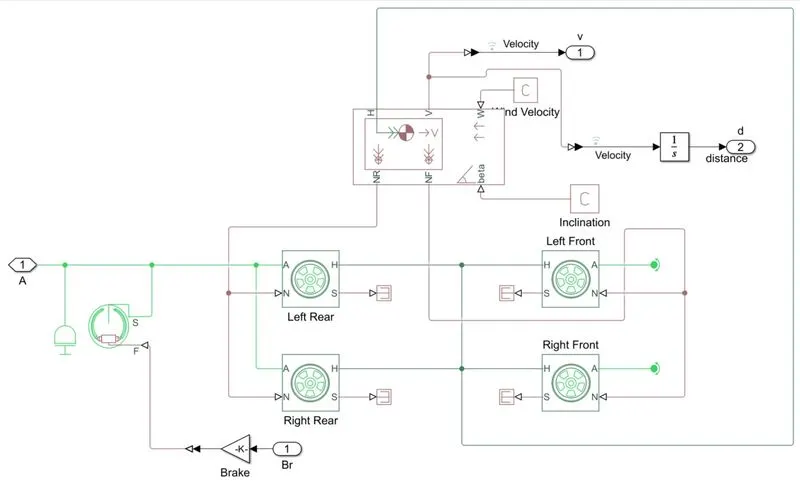
- Flow Process
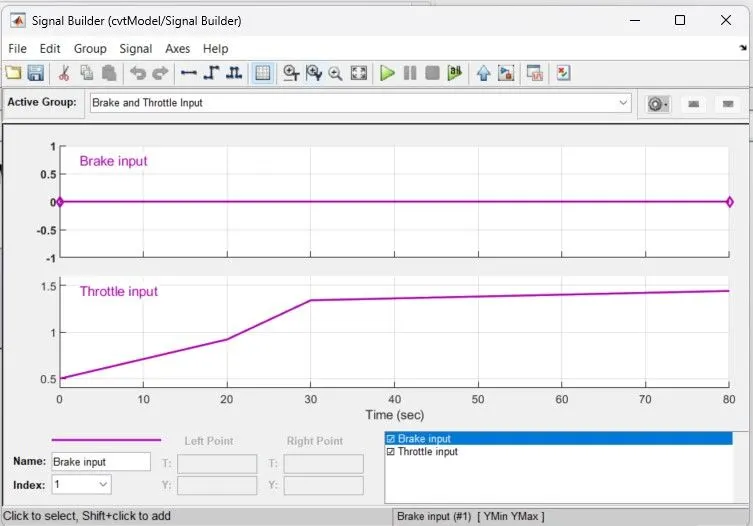
- A brake input is constant at 0
- A throttle signal is generated using signal builder, and given input to a generic engine.
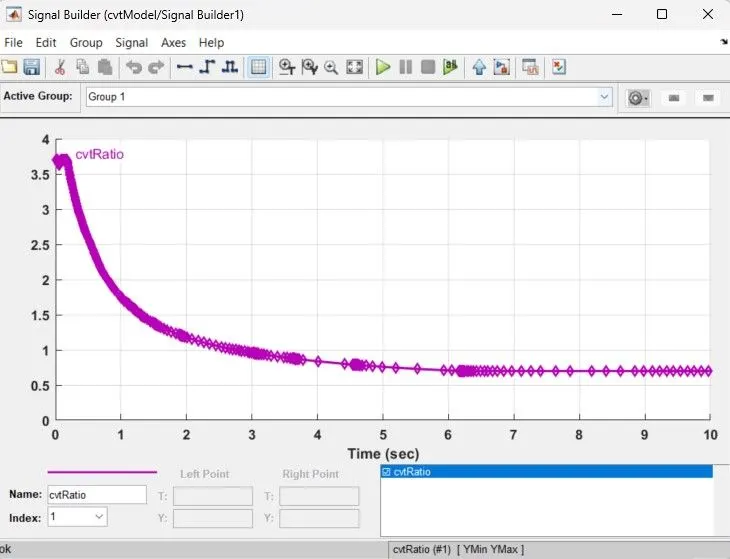
- CVT ratio is the speed controlled by the variable CVT ratio and the to control output speed in the vehicle axle.
Result:
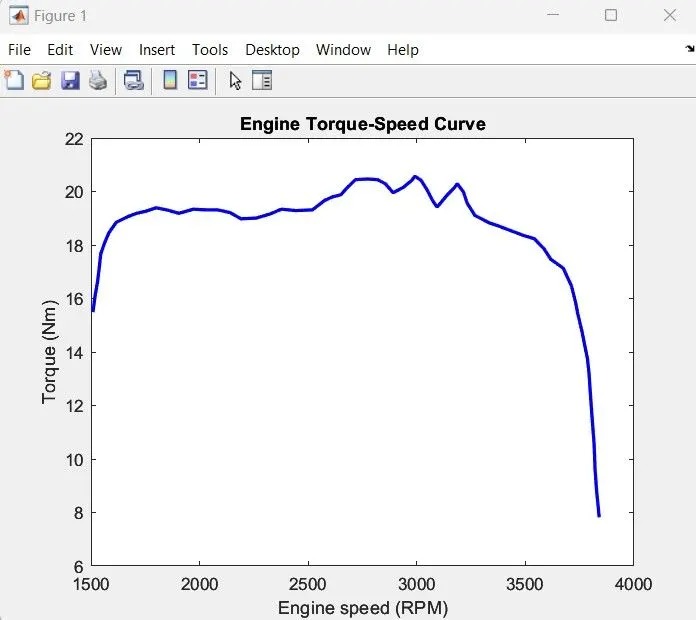
- Torque Speed
- This plot is common for both cases.
- This plot is common for both cases.
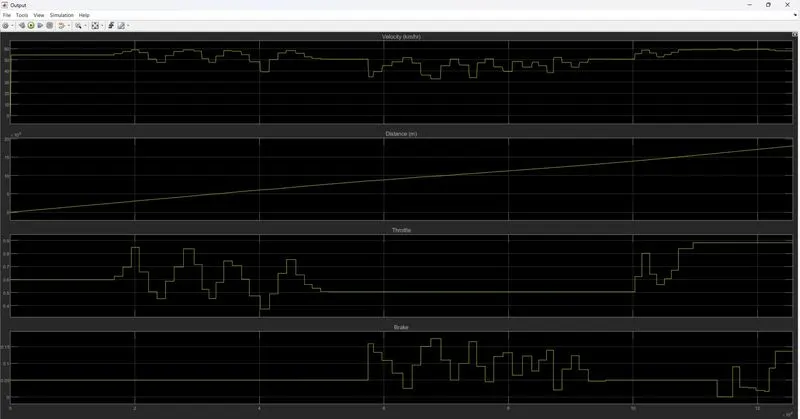
- Vehicle Speed output based on given output of brake power and throttle
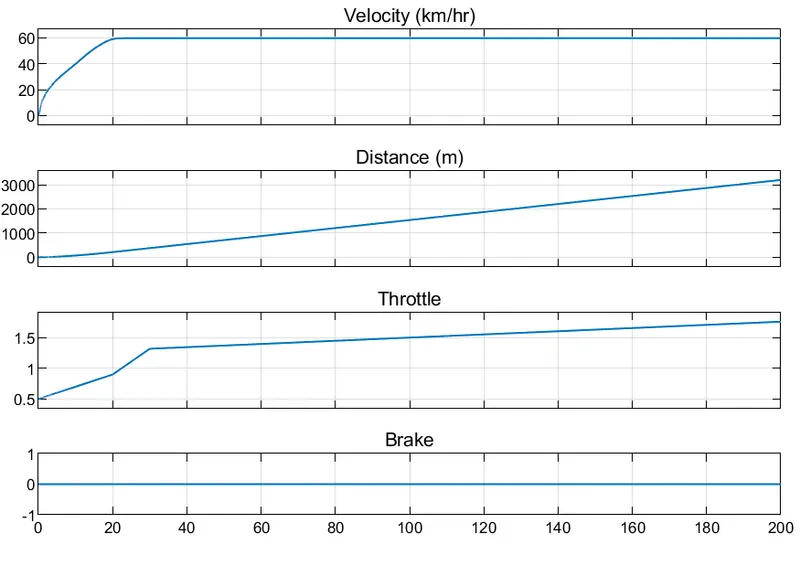
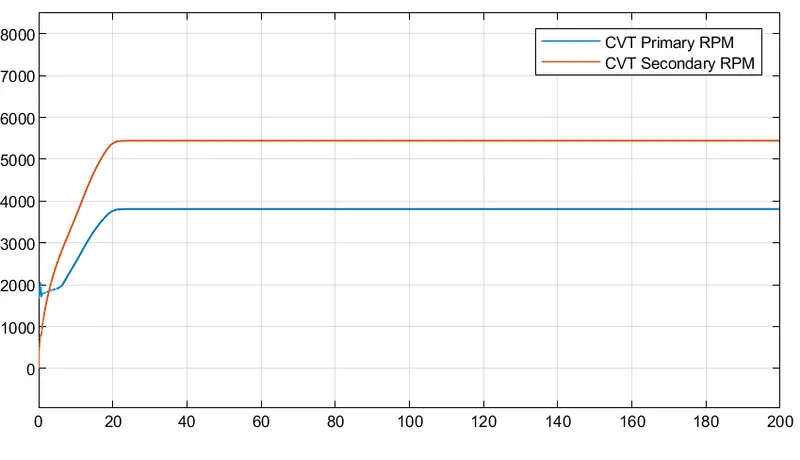
- The engine reduce speed and is controlled by various CVT ratios
Task 2
To study Baja ATV based models using a dashboard
- Simulink Model of BAJA ATV without dashboard
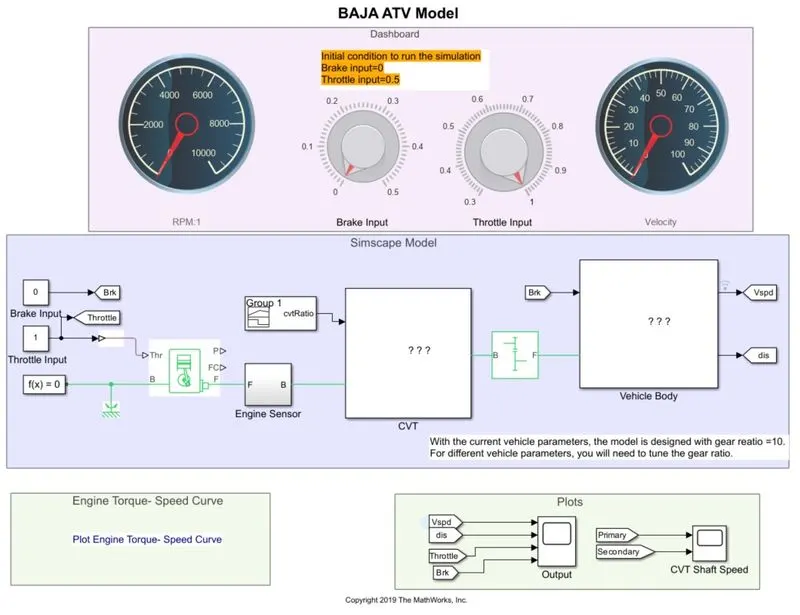
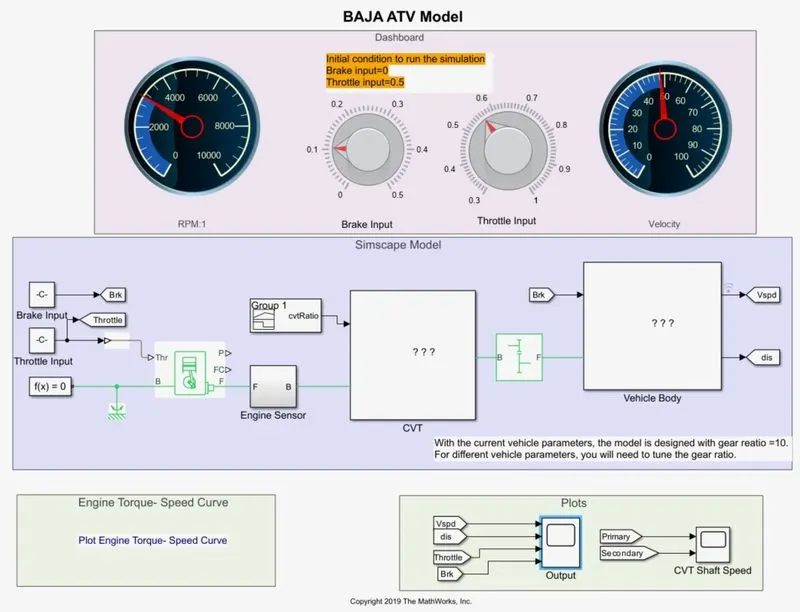
For giving inputwe had used a knob block, constant and Custom Gauge, for giving input to the system. from where we can control the system that board is called as dashboard. - Dashboard to control and give feeding to the system. The main advantages of the dashboard is we can control while running the program, break input and throttle input are controlled by the user.
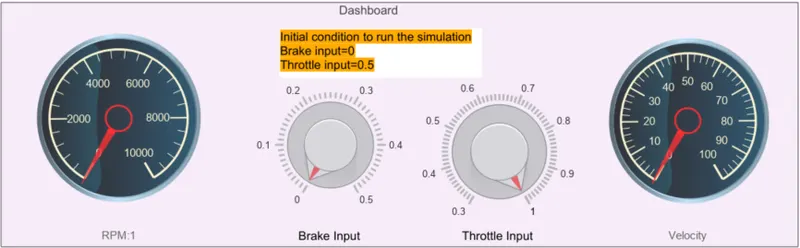
Running Simuling block
Result
- Workspace
- Vehicle Speed output based on given output of brake power and throttle
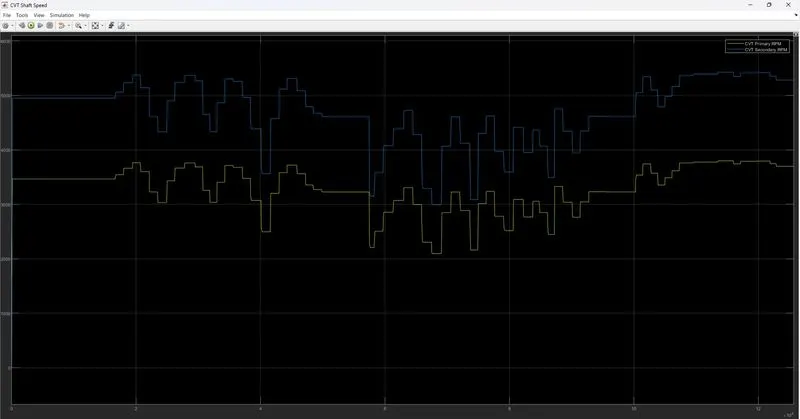
- CVT speed
Conclusion
- It can be concluded that the simulation for the BAJA ATV model was successfully done.
- CVT primary shaft speed is greater than the secondary shaft speed which is directly proportional to their shaft diameter.
- The speed might get zero at a particular resistance of breaking.