Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
AIM:-
To implementation of code for “Measuring distance of an object using ultrasonic distance sensor (28015 Ping) and also smoothen the sensor data using moving average filter”.
CODE:-
void setup
Serial begin
Pin mode
digital write
PROGRAM:-
Master code:
#include//To use LCD functions

#include//To use I2C communication

LiquidCrystal lcd(2,3,4,5,6,7);

int distance;//variable to print the data from slave
void setup()

{

Serial.begin(9600);

Wire.begin();//To begin I2C communication

lcd.begin(16,2);//To begin LCD display

lcd.clear();
}
void loop()

{

Wire.requestFrom(8,4);// adress 8 and request 4 byte

distance=Wire.read();

lcd.setCursor(0,0);//Move cursor to the first line

lcd.print(distance);//To print the received message from slave 1

lcd.print(" inches");

delay(50);

Wire.end();//End the transmission

}
Slave code:
#include<Wire.h>//To use I2C communication

int sig = 2;//Ultrasonic Sig pin

int duration, inches, cm;//Variables used for calculation

static int avg;//Declaring avg as static int type

void setup()

{

Serial.begin(9600);

Wire.begin(8);//To begin I2C communication with address 8

Wire.onRequest(distance);//Call function from master

}
void loop()

{

delay(100);

}
void distance()//Called function

{

pinMode(sig, OUTPUT);//Declaring pin2 as output

digitalWrite(sig, LOW);//Sensor is triggered by pin2

delay(5);

digitalWrite(sig, HIGH);

delay(10);

digitalWrite(sig, LOW);

pinMode(sig, INPUT);//Declaring pin2 as input

duration = pulseIn(sig, HIGH);//To read the pulse

inches = (duration/74)/2;//converting time into a distance

Wire.write(inches);//Return value to master

delay(10);

}
RESULT:-
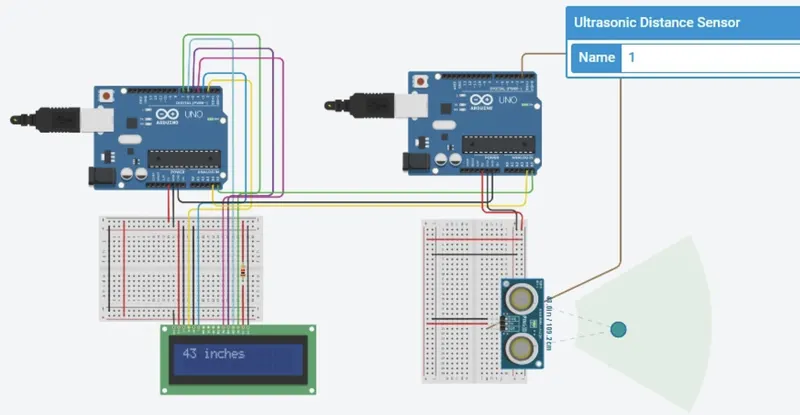
implementation of code for “Measuring distance of an object using ultrasonic distance sensor (28015 Ping) and also smoothen the sensor data using moving average filter has done