Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
Aim:
Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter.
Overview of the Project:
In this project the implementation of code for "Measuring distance of an object using ultrasonic distance sensor (28015 Ping) and also smoothen the sensor data using moving average filter".
Goals:
- Measuring the distance in terms of inches of an object using Ultrasonic Distance Sensor (28015 Ping).
- The sensor data is smoothened by using Moving average filter technique to eliminate the high frequency variations from the sensor data.
Key Highlights of the Project:
- Measuring the distance travelled by the wave to the object and gets bounced back from the object to sensor.
- Smoothening the sensor data by moving average filter technique, the filter has a window of certain size. That window determines that how many data the filter can take.
Deliverables of this project:
- The distance travelled by a wave to the object for which we want to measure the distance using Ultrasonic Distance Sensor (28015 Ping).
- Eliminate the high frequency jitters from the sensor data by Moving Average filter to smoothen the sensor data.
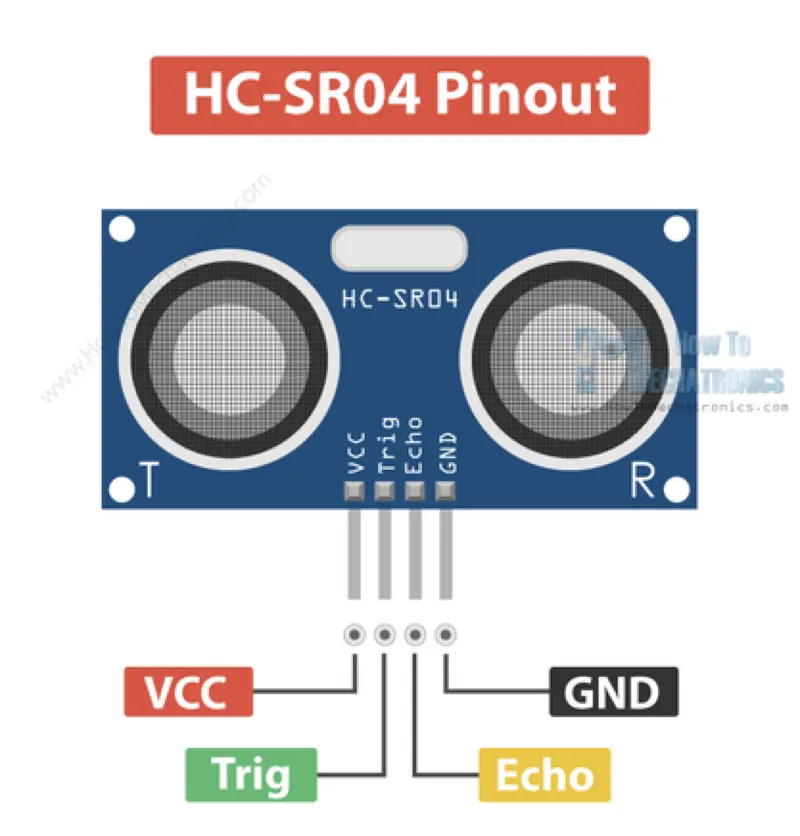
Ultrasonic Sensor (HC-SR04):
- Interfacing HC-SR04 to a microcontroller is very much easy. trig pin is used to trigger an ultrasonic sensor and then "listen" for the echo pulse. The sensor measures the time required for the echo return, and returns this to the microcontroller as a variable pulse width via the echo pin.
- The HC-SR04 is an affordable and easy to use distance measuring sensor which has a range from 2cm to 450cm.
- It emits an ultrasound at 40000 Hz which travels through the air and if there is an object or obstacle on its path It will bounce back to the module. Considering the travel time and the speed of the sound you can calculate the distance.
- In order to generate the ultrasound we need to set the Trig pin on a High State for 10 µs. That will send out an 8 cycle ultrasonic burst which will travel at the speed of sound. The Echo pins goes high right away after that 8 cycle ultrasonic burst is sent, and it starts listening or waiting for that wave to be reflected from an object.
- If we receive a reflected pulse, the Echo pin will go down. According to the amount of time the Echo pin was HIGH, we can determine the distance the sound wave traveled, thus the distance from the sensor to the object.
basic formula for calculating distance:
Distance = Speed x Time
We actually know both the speed and the time values. The time is the amount of time the Echo pin was HIGH, and the speed is the speed of sound which is 340m/s. There’s one additional step we need to do, and that’s divide the end result by 2. and that’s because we are measuring the duration the sound wave needs to travel to the object and bounce back.
Code:
#include
LiquidCrystal lcd(1, 2, 4, 5, 6, 7); // Creates an LCD object. Parameters (rs, enable, d4, d5, d6, d7)
const int trigPin = 9; //set trigger pin 9
const int echoPin = 10; // set echo pin 10
long duration;
int distanceCm, distanceInch;
void setup()
{
lcd.begin(16,2); // Initializes the interface to the LCD screen, and specifies the dimensions (width and height) of the display
pinMode(trigPin, OUTPUT); //Initialize triggerpin as an output
pinMode(echoPin, INPUT); //Initialize echopin as an input
}
void loop()
{
digitalWrite(trigPin, LOW);
delayMicroseconds(2);
digitalWrite(trigPin, HIGH);
delayMicroseconds(10);
digitalWrite(trigPin, LOW);
duration = pulseIn(echoPin, HIGH);
distanceCm= duration*0.034/2;
distanceInch = duration*0.0133/2;
lcd.setCursor(0,0); // Sets the location at which subsequent text written to the LCD will be displayed
lcd.print("Distance: "); // Prints string "Distance" on the LCD
lcd.print(distanceCm); // Prints the distance value from the sensor
lcd.print(" cm");
delay(10);
lcd.setCursor(0,1);
lcd.print("Distance: ");
lcd.print(distanceInch);
lcd.print(" inch");
delay(10);
}
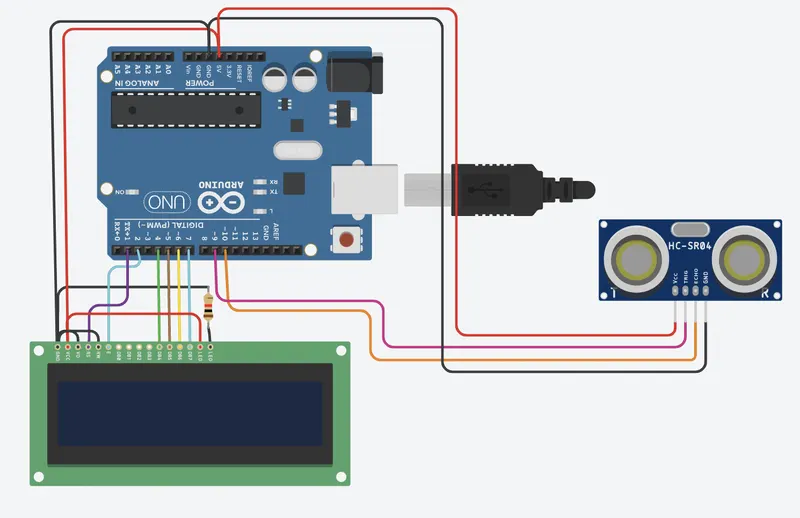
Circuit Module:
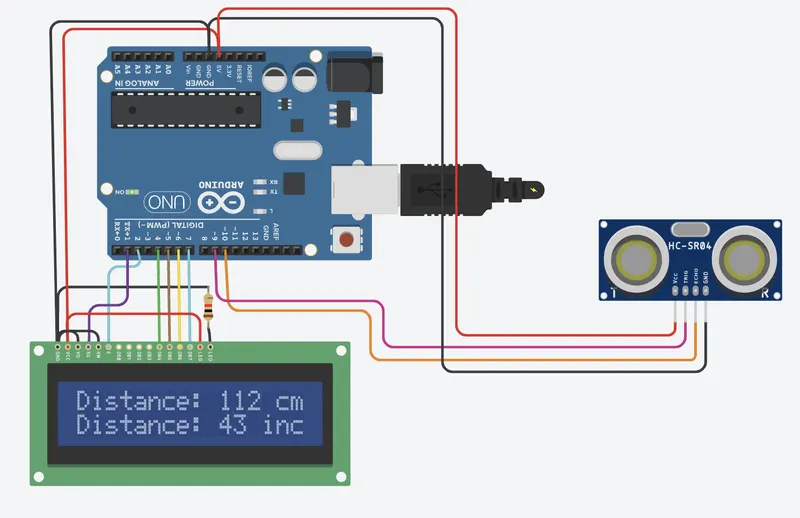
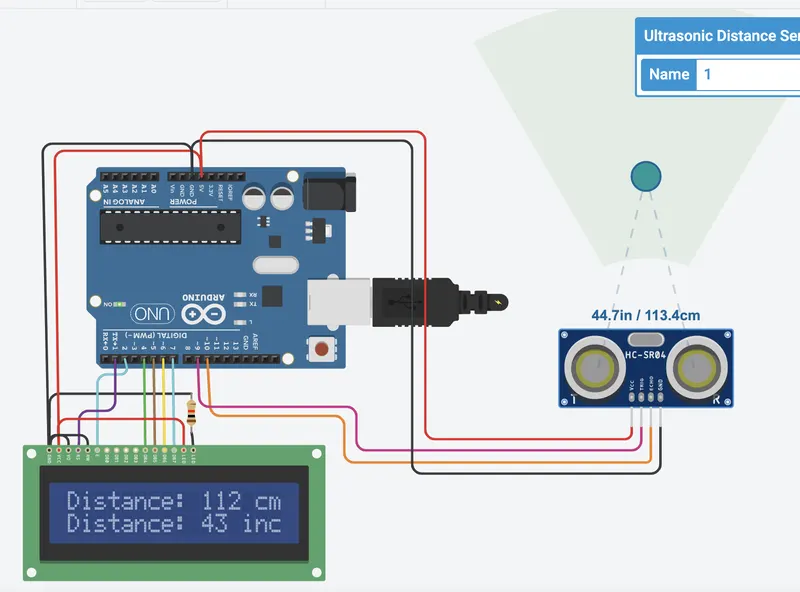
Output:
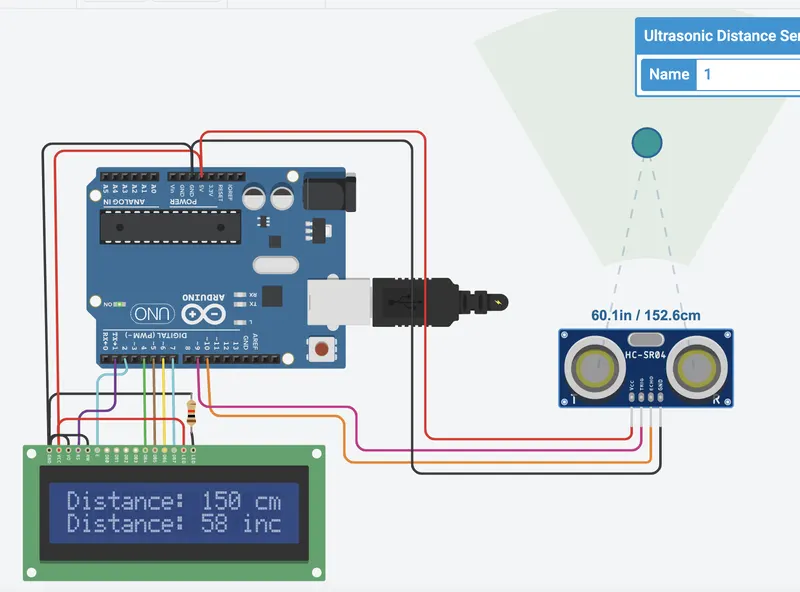
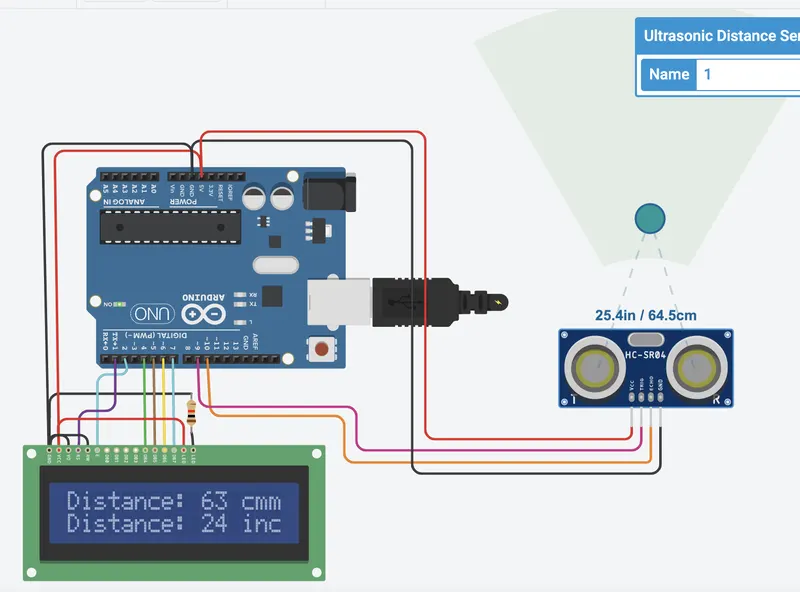
Expected Outcomes:
The students will get the Knowledge on Ultrasonic sensor (28015 Ping) to measure the distance travelled by wave to the object, the hardware connection of 2 Arduino's connected to the sensor and smoothening the sensor data by removing high frequency variations using Moving Average Filter Technique.
Conclusion:
So, we have successfully done this project and get the output, that we need to know about using the HC-SR04 Ultrasonic sensor with Arduino UNO. The ultrasonic sensor is a high pulse with the same duration as the time difference between transmitted ultrasonic bursts and the received echo signal.