Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Solution:-
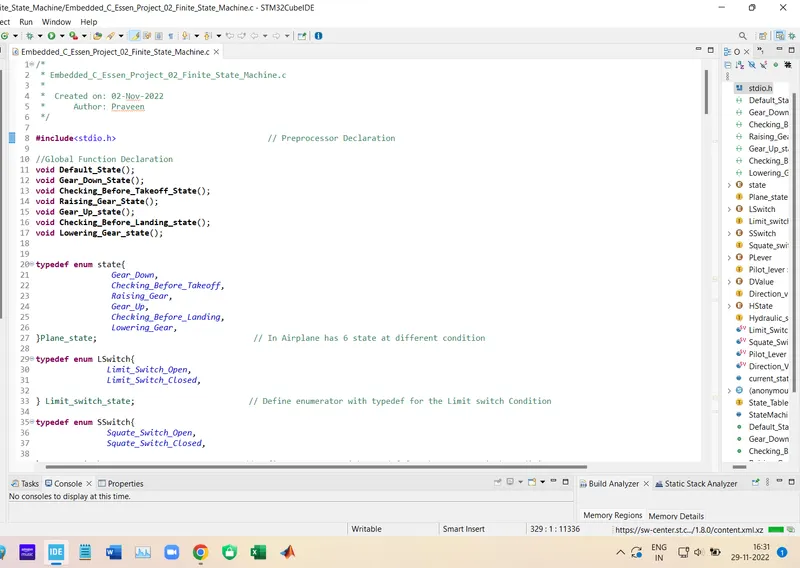
#include<stdio.h>                                // Preprocessor Declaration

//Global Function Declaration
void Default_State();
void Gear_Down_State();
void Checking_Before_Takeoff_State();
void Raising_Gear_State();
void Gear_Up_state();
void Checking_Before_Landing_state();
void Lowering_Gear_state();


typedef enum state{
	            Gear_Down,
				Checking_Before_Takeoff,
				Raising_Gear,
				Gear_Up,
				Checking_Before_Landing,
				Lowering_Gear,
}Plane_state;                                 // In Airplane has 6 state at different condition

typedef enum LSwitch{
               Limit_Switch_Open,
			   Limit_Switch_Closed,

} Limit_switch_state;                        // Define enumerator with typedef for the Limit switch Condition

typedef enum SSwitch{
               Squate_Switch_Open,
			   Squate_Switch_Closed,

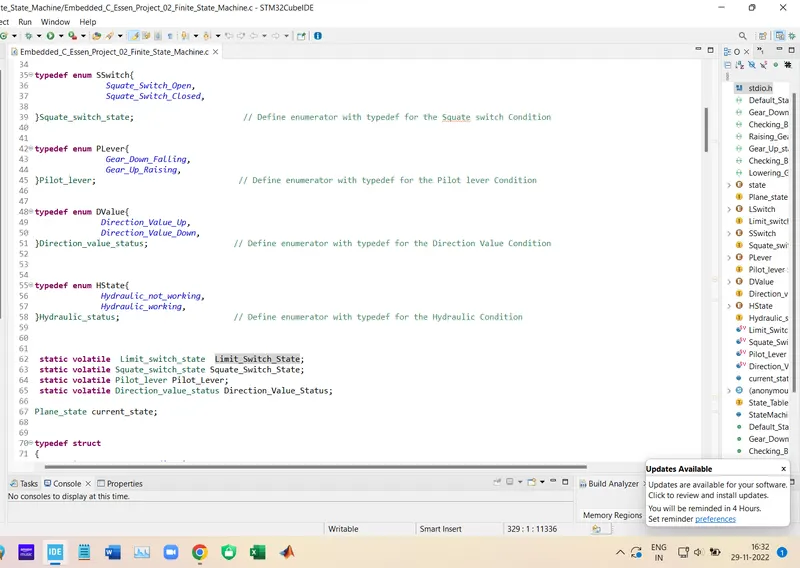
}Squate_switch_state;                       // Define enumerator with typedef for the Squate switch Condition


typedef enum PLever{
	           Gear_Down_Falling,
			   Gear_Up_Raising,
}Pilot_lever;                              // Define enumerator with typedef for the Pilot lever Condition


typedef enum DValue{
	          Direction_Value_Up,
	          Direction_Value_Down,
}Direction_value_status;                  // Define enumerator with typedef for the Direction Value Condition


typedef enum HState{
	          Hydraulic_not_working,
	          Hydraulic_working,
}Hydraulic_status;                        // Define enumerator with typedef for the Hydraulic Condition


 static volatile  Limit_switch_state  Limit_Switch_State;
 static volatile Squate_switch_state Squate_Switch_State;
 static volatile Pilot_lever Pilot_Lever;
 static volatile Direction_value_status Direction_Value_Status;

Plane_state current_state;


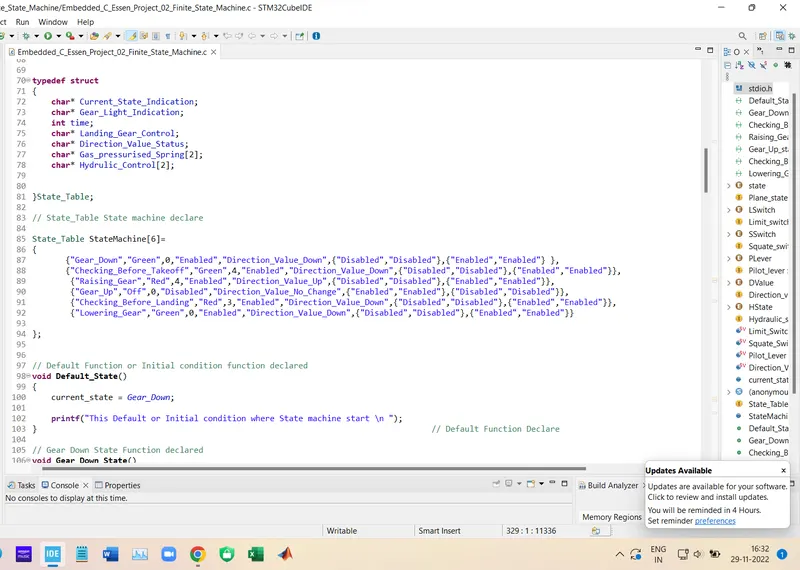
typedef struct
{
	char* Current_State_Indication;
	char* Gear_Light_Indication;
	int time;
    char* Landing_Gear_Control;
    char* Direction_Value_Status;
    char* Gas_pressurised_Spring[2];
    char* Hydrulic_Control[2];


}State_Table;

// State_Table State machine declare

State_Table StateMachine[6]=
{
       {"Gear_Down","Green",0,"Enabled","Direction_Value_Down",{"Disabled","Disabled"},{"Enabled","Enabled"} },
       {"Checking_Before_Takeoff","Green",4,"Enabled","Direction_Value_Down",{"Disabled","Disabled"},{"Enabled","Enabled"}},
		{"Raising_Gear","Red",4,"Enabled","Direction_Value_Up",{"Disabled","Disabled"},{"Enabled","Enabled"}},
		{"Gear_Up","Off",0,"Disabled","Direction_Value_No_Change",{"Enabled","Enabled"},{"Disabled","Disabled"}},
		{"Checking_Before_Landing","Red",3,"Enabled","Direction_Value_Down",{"Disabled","Disabled"},{"Enabled","Enabled"}},
		{"Lowering_Gear","Green",0,"Enabled","Direction_Value_Down",{"Disabled","Disabled"},{"Enabled","Enabled"}}

};


// Default Function or Initial condition function declared
void Default_State()
{
	current_state = Gear_Down;

	printf("This Default or Initial condition where State machine start \n ");
}                                                                                   // Default Function Declare

// Gear Down State Function declared
void Gear_Down_State()
{
	current_state = Gear_Down;

	printf("Enter the status of Pilot's lever and Squat switch position : for Raising 1,Open 0 \n ");
	fflush(stdout);
	scanf("%d %d", &Pilot_Lever,&Squate_Switch_State);                                  // Taking input from User

	if(Pilot_Lever == Gear_Up_Raising && Squate_Switch_State == Squate_Switch_Open)
	{
		current_state = Checking_Before_Takeoff;

		printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
		fflush(stdout);
		printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
		fflush(stdout);
		printf(" Direction_Value_Status is : %s \n",StateMachine[current_state].Direction_Value_Status );
		fflush(stdout);

	}
	else
	{
		printf("Again Enter value for state in Gear down state ");
		Gear_Down_State();
	}
}

// Checking before takeoff state function declared
void Checking_Before_Takeoff_State()
{
	current_state = Checking_Before_Takeoff;

	printf("Enter the status of Pilot's lever, Squat switch position, Direction Value  \n ");
	fflush(stdout);
	scanf("%d %d %d",&Pilot_Lever,&Squate_Switch_State,&Direction_Value_Status);

	if(Pilot_Lever == Gear_Up_Raising && Squate_Switch_State == Squate_Switch_Open && Direction_Value_Status ==  Direction_Value_Up )
	{
     	current_state = Raising_Gear;

     	printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
		fflush(stdout);
		printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
		fflush(stdout);
		printf("Direction value status is : %s \n",StateMachine[current_state].Direction_Value_Status);
		fflush(stdout);
		printf("Time delay is : %d \n",StateMachine[current_state].time);
		fflush(stdout);
	}
	else if(Pilot_Lever == Gear_Down_Falling && Squate_Switch_State == Squate_Switch_Closed && Direction_Value_Status == Direction_Value_Down )
	{
	     	current_state = Gear_Down;

			printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
			fflush(stdout);
			printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
			fflush(stdout);
			printf("Direction value status is : %s \n",StateMachine[current_state].Direction_Value_Status);
			fflush(stdout);
	}
	else
	{
		printf("Again Enter the value in Checking before take off state \n");
		Checking_Before_Takeoff_State();
	}

}

// Raising Gear state function declared
void Raising_Gear_State()
{
	current_state = Raising_Gear;

    printf("Enter the status of Pilot's lever and Limit switch position- for rising 1 & falling 0, Open 0 & Closed 1 \n");
	fflush(stdout);
	scanf("%d %d",&Pilot_Lever,&Limit_Switch_State);

	if(Pilot_Lever == Gear_Up_Raising && Limit_Switch_State == Limit_Switch_Closed)
	{
		current_state = Gear_Up;

		printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
		fflush(stdout);
		printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
		fflush(stdout);
		printf("Gear Control status is : %s \n",StateMachine[current_state].Landing_Gear_Control);
		fflush(stdout);
		printf("Gas pressure spring status is : %s \n",StateMachine[current_state].Gas_pressurised_Spring[current_state]);
		fflush(stdout);
		printf("Hydraulic Control status is : %s \n",StateMachine[current_state].Hydrulic_Control[current_state]);
		fflush(stdout);


	}
	else if(Pilot_Lever == Gear_Down_Falling &&  Limit_Switch_State == Limit_Switch_Open)
	{
		current_state = Checking_Before_Landing;

		printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
		fflush(stdout);
		printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
		fflush(stdout);
		printf("Direction value status is : %s \n",StateMachine[current_state].Direction_Value_Status);
		fflush(stdout);
		printf("Gas pressure spring status is : %s \n",StateMachine[current_state].Gas_pressurised_Spring[current_state]);
		fflush(stdout);
		printf("Hydraulic Control status is : %s \n",StateMachine[current_state].Hydrulic_Control[current_state]);
		fflush(stdout);
	}
	else
	{
		printf("Again Enter value in Raising Gear state \n");
		Raising_Gear_State();
	}
}

// Gear up state function declared
void Gear_Up_state()
{
	current_state = Gear_Up;

	printf("Enter the status of Pilot's lever:- for rising 1 & falling  \n");
    fflush(stdout);
	scanf("%d",&Pilot_Lever);

		if(Pilot_Lever == Gear_Down_Falling)
		{
		current_state = Checking_Before_Landing;

		printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
		fflush(stdout);
		printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
		fflush(stdout);
		printf("Gear Control status is : %s \n",StateMachine[current_state].Landing_Gear_Control);
		fflush(stdout);
		}
		else
		{
			printf("Again Enter value in GearUp state state \n");
			Gear_Up_state();
		}
}


// Cheching before landing State function declared
void Checking_Before_Landing_state()
{
	current_state = Checking_Before_Landing;

	printf("Enter the status of Pilot's lever,Direction Value - for rising 1 & falling 0, up 0 & down 1 \n");
	fflush(stdout);
	scanf("%d %d",&Pilot_Lever,&Direction_Value_Status);

	if(Pilot_Lever == Gear_Down_Falling && Direction_Value_Status == Direction_Value_Down )
	{
	current_state = Lowering_Gear;

	printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
	fflush(stdout);
	printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
	fflush(stdout);
	printf("Direction value status is : %s \n",StateMachine[current_state].Direction_Value_Status);
	fflush(stdout);
	}
	else
	{
		printf("Again Enter value in Checking before landing state \n");
		Checking_Before_Landing_state();
	}
}

// Lowering Gear State Declared function
void Lowering_Gear_state()
{
	current_state = Lowering_Gear;

		printf("Enter the status of Pilot's lever,Direction Value - for rising 1 & falling 0, up 0 & down 1 \n");
		fflush(stdout);
		scanf("%d %d", &Pilot_Lever, &Limit_Switch_State);

		if(Pilot_Lever == Gear_Down_Falling &&  Limit_Switch_State ==  Limit_Switch_Open )
		{
		current_state = Gear_Down;

		printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
		fflush(stdout);
		printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
		fflush(stdout);
		printf("Direction value status is : %s \n",StateMachine[current_state].Direction_Value_Status);
		fflush(stdout);
		}
		else if(Pilot_Lever == Gear_Up_Raising && Limit_Switch_State ==  Limit_Switch_Closed )
		{
		current_state = Checking_Before_Takeoff;

		printf("Current State of Airplane is : %s \n ",StateMachine[current_state].Current_State_Indication);
		fflush(stdout);
		printf("Lever Gear_Light_Indication is : %s \n",StateMachine[current_state].Gear_Light_Indication );
		fflush(stdout);
		printf("Direction value status is : %s \n",StateMachine[current_state].Direction_Value_Status);
		fflush(stdout);
		}
		{
			printf("Again Enter value Lowering Gear State \n");
			 Lowering_Gear_state();
		}
}

static void(*statetable[])(void) = { Gear_Down_State,Checking_Before_Takeoff_State,Raising_Gear_State,Gear_Up_state,Checking_Before_Landing_state,Lowering_Gear_state};

// Main Function Declaration
int main()
{
	Default_State();                      // Calling the initial function or default starting function
while(1)
{
	statetable[current_state]();        // State Table Current value calling
}
}
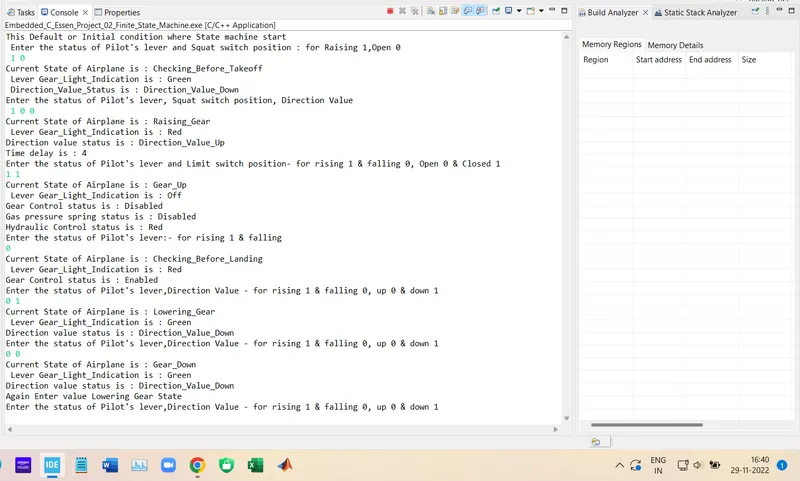
Screenshots:-
Result:-