Project 2 Adaptive Cruise Control
MAIN PROJECT
ON
'ADAPTIVE CRUISE CONTROL MODEL'
AIM:
Adapative cruise control has to modelled by using the given requirements, This Adaptive Cruise Control Feature for passenger cars allows the host vehicle to adapt to the speed in line with the flow of traffic. Driving in heavy traffic or keeping a safe distance to the preceding vehicle calls for a high level of concentration. The Adaptive Cruise Control feature can reduce the stress on the driver by automatically controlling the vehicle speed & maintaining a predefined minimum distance to the preceding vehicle.
BLOCKS USED:
1) Inport block
2)Outport Block
3) Add Block
4) Chart( State Machine )
OBJECTIVE:
Adaptive cruise control has been built as per given requirement, below picture showa the model
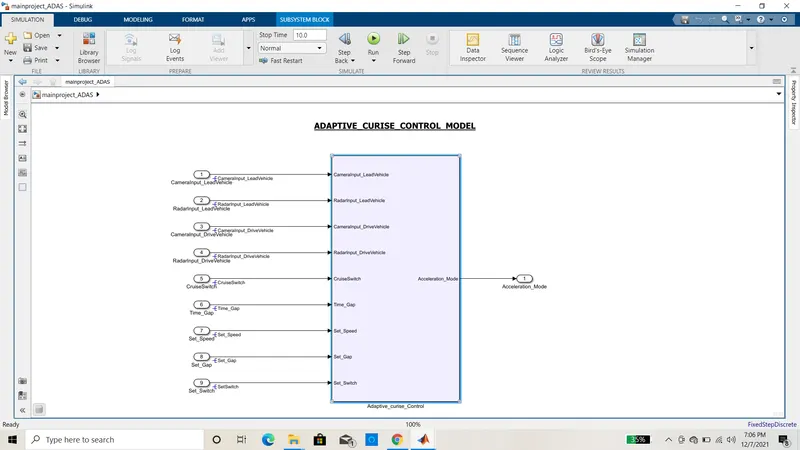
Above built model has been made to susbsytem named as ADAPTIVE CRUISE CONTROL it has 3 subsytem's in it named as LEAD_VEHICLE, DRIVE_VEHICLE and ACC_ALGORITHM again in acc_ algorithm we have subsytem called ACC_LOGIC CHART.
Screenshot attached below shows the 3 subsytem's.
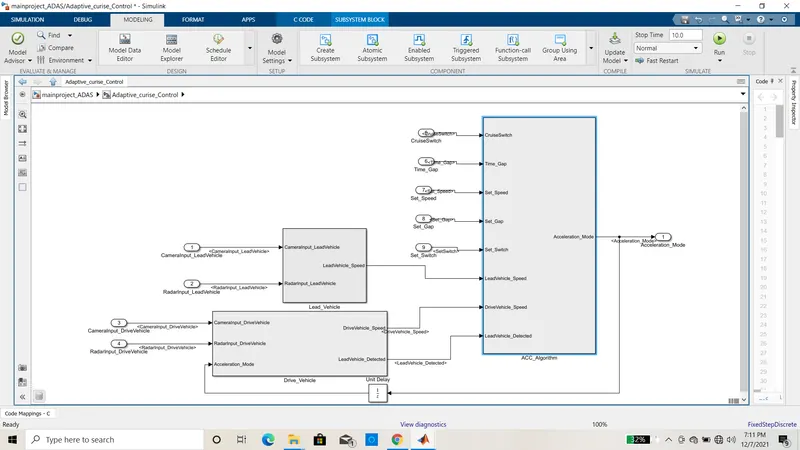
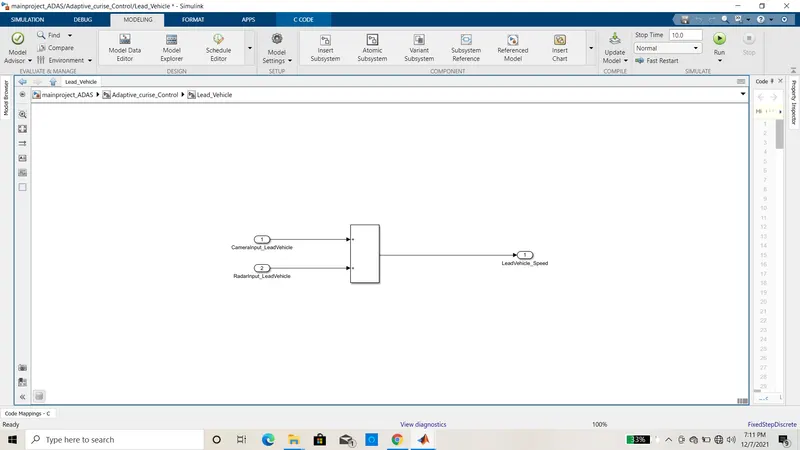
LEAD_VEHICLE
Below shown figure is lead_vehicle model two inputs are given to add block input 1 is CAMERAINPUT_LEADVEHICLE and input 2 is RADARINPUT_LEADVEHICLE output of the add block is LEADVEHICLE_SPEED.
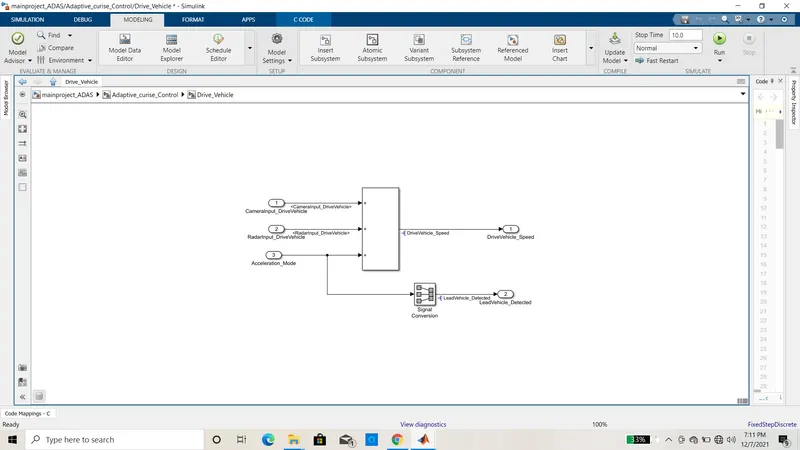
DRIVE_VEHICLE
Picture shown below is drive vehicle model it also as 3 inputs to the add block namely CAMERAINPUT_DRIVEVEHICLE, RADARINPUT_DRIVEVEHICLE, and ACCELERATION_MODE(this signal is feedback from the output of overall model which again connected to the signal conversion block) this are given as input and the output is DRIVEVEHICLE_SPEED.
ACC_ALGORITHM:
Acc allgorithm is the 3rd subsystem in which in contains chart of (ACC_logic) this chart has 8 input's 5 are given to chart state machine inputs and remaninig 3 are the output ports of LEAD_VEHICLE and DRIVE_VEHICLE with the input ports named as
CRUISE-SWITCH, SET_SWITCH, SET_SPEED, TIME_GAP, SET_GAP, LEADVEHICLE_SPEED, DRIVEVEHICLE_SPEED and DRIVEVEHILE_DETECTED.
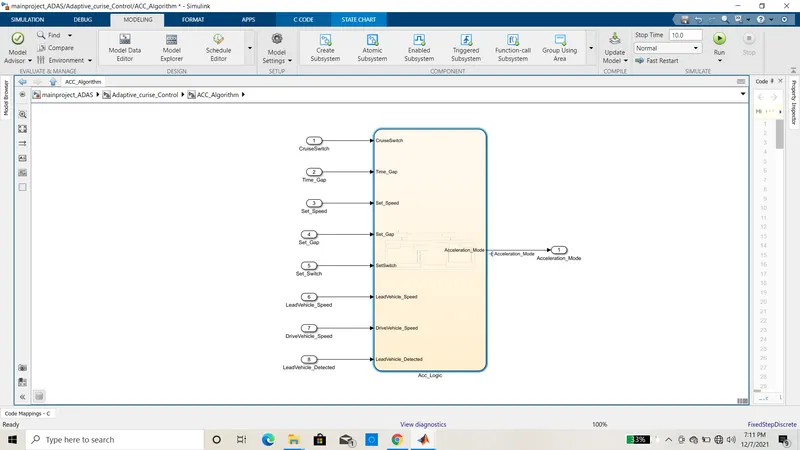
ACC_LOGIC picture is shown below
It has 5 inputs
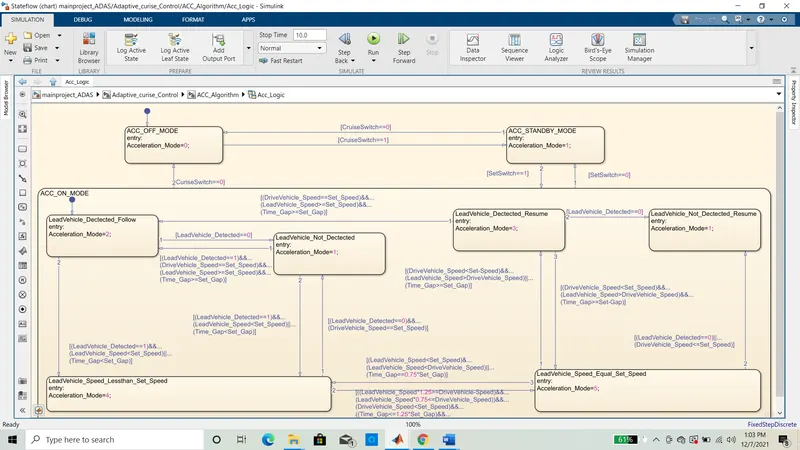
Chart has 3 main Statemachine blocks named as ACC_OFF_MODE, ACC_STANDBY_MODE, and ACC_ON_MODE.
ACC_ON_MODE contains many blocks inside it Leadvehicle_detected_follow, LeadVehicle_Not_detected, LeadVehicle_Detected_Resume, Lead_Vehicle_Not_Detected_Resume, LeadVehicle_Speed_Lessthan_Speed and LeadVehicle_Speed_Equal_Set_Speed.
FUCTIONING OF CHAT
When cruise switch is equal to 1 it moves to acc stand by mode if not returns to acc off mode, in acc standby mode when set swtich is equal to 1 it moves to acc on mode of leadvehicle_detected follow if it's equal to 0 it moves to leadvehicle not detected if it is 1 it moves leadvehicle speed lessthan set speed, if leadvehicle speed is equal to set speed or greater than set speed it moves to acc on mode it if is 0 it moves to leadvehicle not detected resume, if it is less tahn or equal to set speed it moves to leadvehicle speed equal to set speed.
Simulink data dictionary is created for the model given by requiremnt and linked to the model.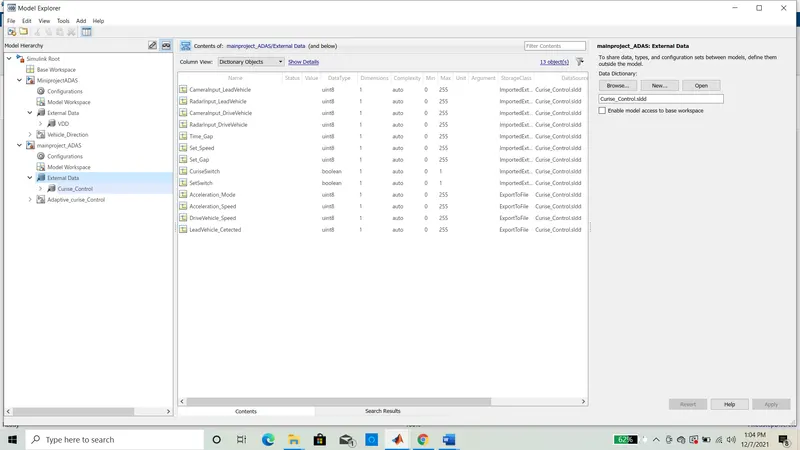
Code for the model has created by taping on the emebbed coder, next click on the generate code in that tap on the c code it automatically generated the code, screenshot below shows the code.
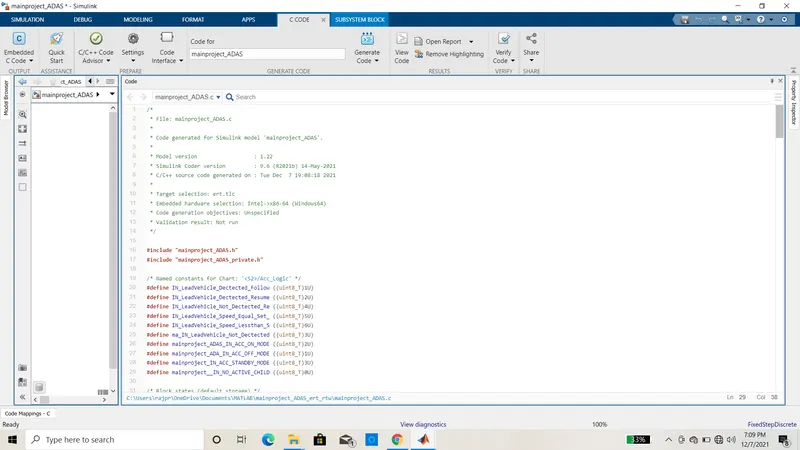
MODEL BASED DEVLOPEMENT realted process has done such as Creating the SLDD file, requirement tagging, configuration parameters setting, model advisor check and code generation.
simulation time for model is 0.01sec.