Project 2
Theory:-
P1 Mild Hybrid Electric Vehicle:-
The P1 architecture, with the electric machine connected directly to the crankshaft, is the solution adopted by Honda on their first generation Integrated Motor Assist (IMA) technology. The electric motor functions as a generator, during vehicle deceleration, as an engine starter, and as a motor (to assist the engine) during vehicle accelerations. One of the biggest advantage of this solution is that the electric motor can provide higher torque than the BiSG, since there is no belt limitation (due to slip). However, since there is no speed / torque ratio between the electric machine and crankshaft, the torque requirements on the electric motor can be quite demanding.
Two examples of P1 MHEV architectures are:
- Honda Insight Hybrid 2009 (with Integrated Motor Assist technology)
- Mercedes Benz S400 Bluehybrid 2010
For example, the main characteristics of the P1 MHEV.
1] ELectric Machine Performance:-
Maximum torque up to 34 Nm.
Maximum power: 10KW
Efficiency: Up to 94 Percent
2] Hybrid Modes:-
Idle stop and stop
Moving stop and start
Engine load shift
Torque assist
Torque boost
Energy recuperation
Brake generation
3] Advantages:-
Higher efficiency
The 12V starter can be removed
4] Disadvantages:-
Output torque limited by thje size of the elctric machine
Energy recuperation affected by engine friction losses
High impact on existing vehicle architecture
Higher overall cost of the electrical components
Air cooling not possible for electric machine
5] Overall characteristics:-
Torque Boosting capacity: High
Electrical energy recuperation: Medium
Driveability improvements: Medium
Electrical Creep/drive: Possible
In this model We use Forward Model:-
It also known as dynamic simulation. Dynamic models are used for detailed simulations. In this model force/torque/power is the input and the vehicle state variable velocity and acceleration are outputs. The models and simulations are more realistic due to physical casualty hence appropriate for control development. There is a feedback loop to meet the desired vehicle state. It is mainly used to simulate a vehicle on a driving cycle to analyze the dynamic behavior of the system and helps significantly in control development.
Process:-
Load the Project2 folder as the Current Folder in Matlab.
Run the “Project2_InitFile.m” Matlab script.
The Drive cycle selection is done here.
Model:
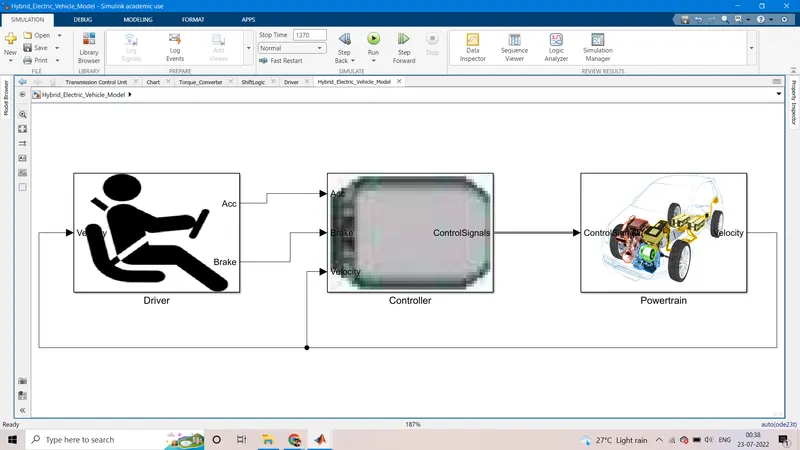
Driver, Controller & Powertrain are the 3 main components of the hybrid electric vehicle where velocity from the powertrain acts as feedback/input to the driver subsystem.
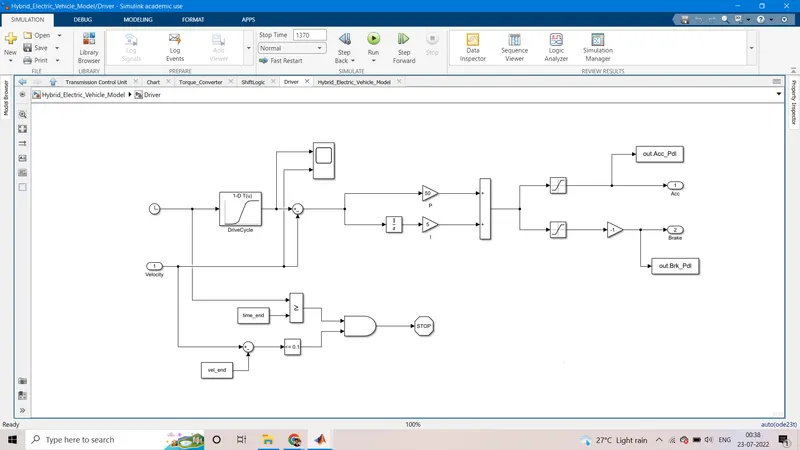
It is modeled using a ‘Driver’ block, which is a basic PI controller that generates accelerator and brake pedal outputs to match the desired and actual vehicle speeds. In this we use drive cycles fro the based on these results of fuel consumption and emissions the vehicle gets certified and it also forms a basis of uniform asessment. It is based on time, velocity then its all integrate and creates output accelration pedal and brake pedal.
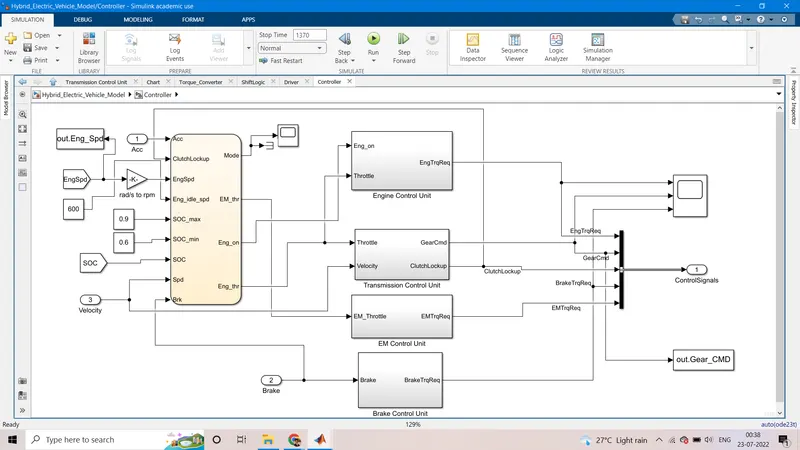
The Controller block is the brains of the vehicle, representing the electronic controls units. It is based on the driver inputs, it generates desired engine torque, desired transmission gear desired motor torque and desired brake torque. These inputs are fed to the ‘Powertrain’ block which represents the drivetrain of the vehicle. In this we require to create stateflow block it explain in next figure.
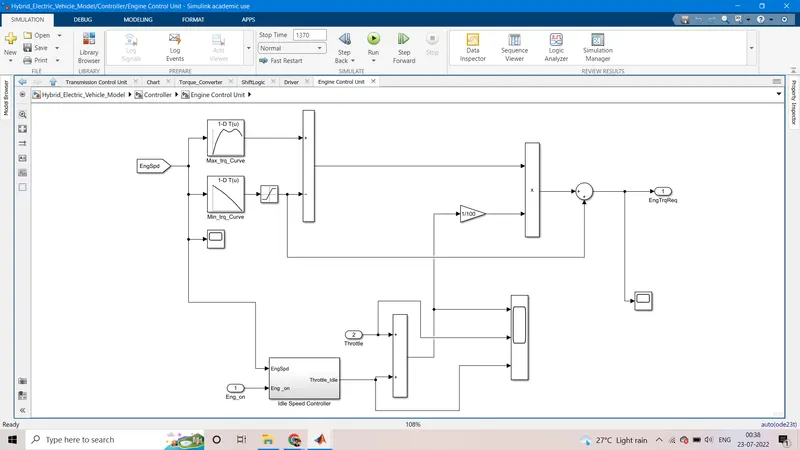
In this control model We use engine control unit in that give input Engine speed through creating look up table. in that table we give input Maximum torque and map speed then also create 2nd look up trable in that give input ct torque and map speed then it substracts and multiplied. the engine speed also give to ideal contro speed to integrate from this we meet output of engine required torque.
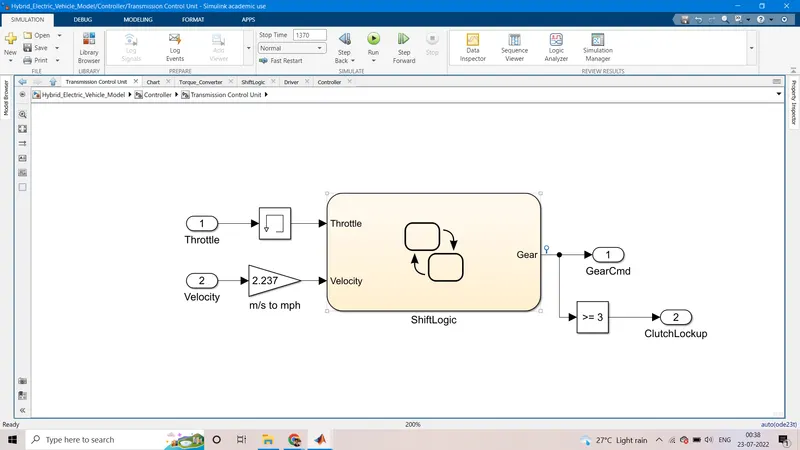
In this unit we create steadfy flow variable state for controlling of gears of vehicle as in ascending and descending order with respect to time, speed, distance. and give input to this steady state is vehicle speed in m/s to mph.
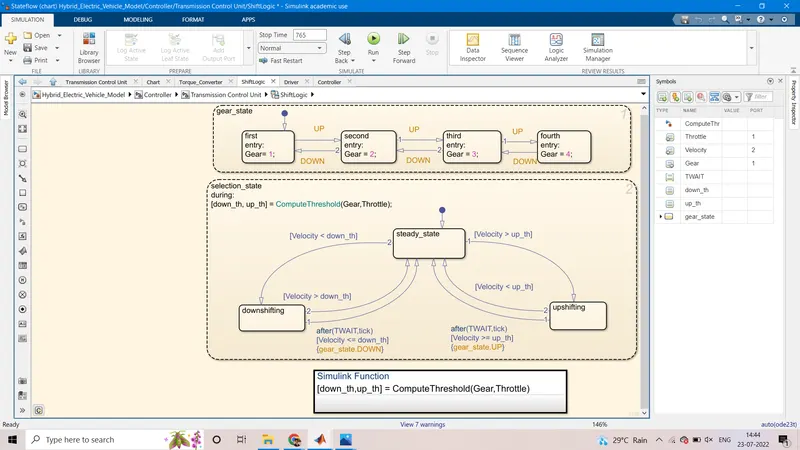
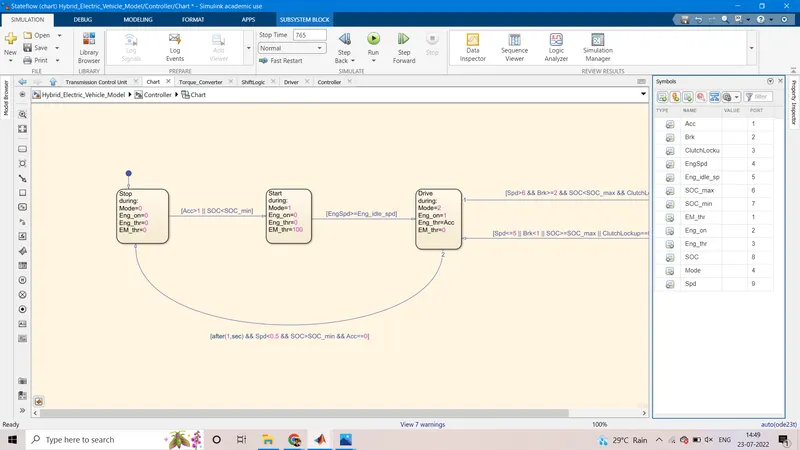
The default state is when all parameters are zero & the parameters vary with respect to the conditions given on the transition arrows. This means that the vehicle will start, stop, drive & have regeneration braking with respect to these conditions. These conditions will depend on parameters like Acceleration,engine speed, state of charge, idle speed, brake & clutch lockup, which will be given as the input to the chart.
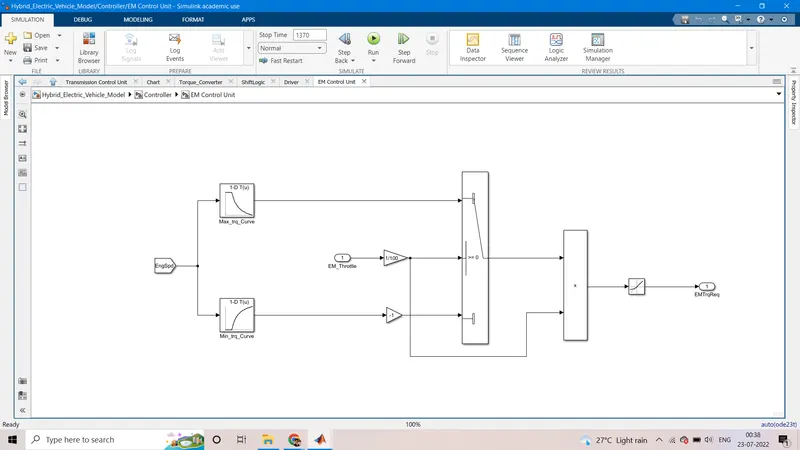
Here we compute motor required torque where motor throttle acts as the input & is determined by using engine speed with the help of 1-d lookup tables & a switch block.
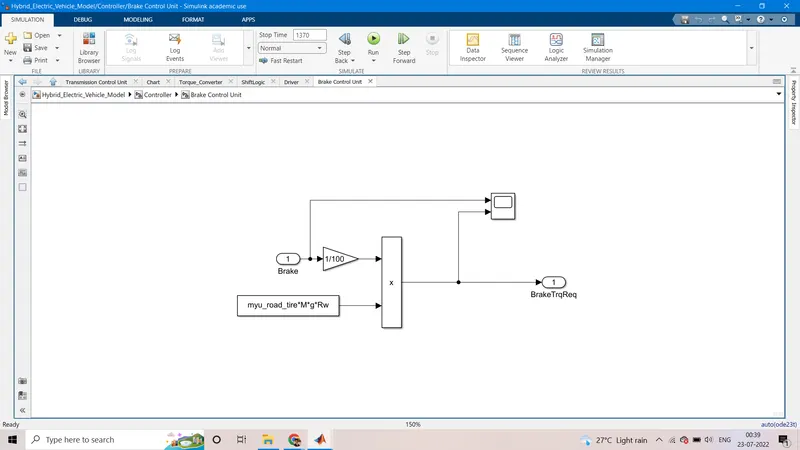
In this calculate brake torque and then all three control signals output is give to powertrain.
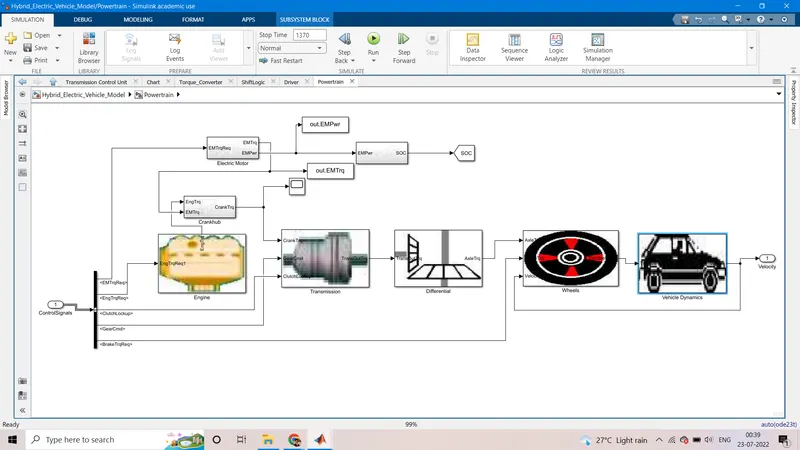
The major components of the powertrain are Engine, Transmission, Differential, Wheels & vehicle dynamics, crankhub, battery & electric motors. The control signals from the controller subsystem form the input for the powertrain subsystem. The output velocity from powertain is the input to the driver subsystem.
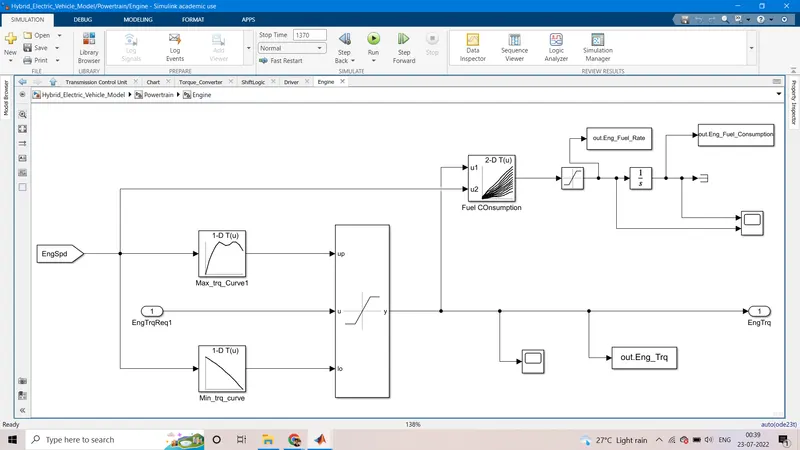
In this model we used map based model to model the fuel consumption of engine. It is based on maximum Torque and minimum torque from the controller. and then it saturated torque and give output then saturated torque and speed map give fuel consumption takes the speed and torque then the output goes into saturated then its integrated.
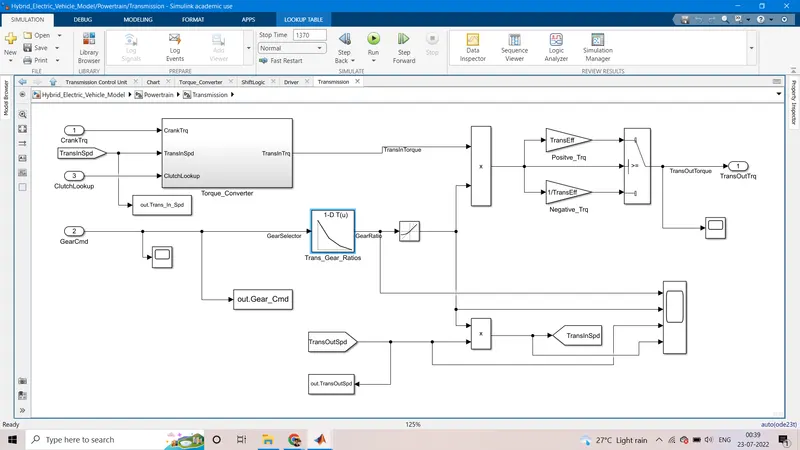
In this part we take engine torque, gear selector from controller for transmission of gear ratio. The ratio is multiplied by transmission input torque and then the transmission efficiency positive torque and negative torque gives transmission input speed. In this case, torque converter connects the engine to the transmission it is part of the transmission. In it's basically engine dynamics and that is decoupled.
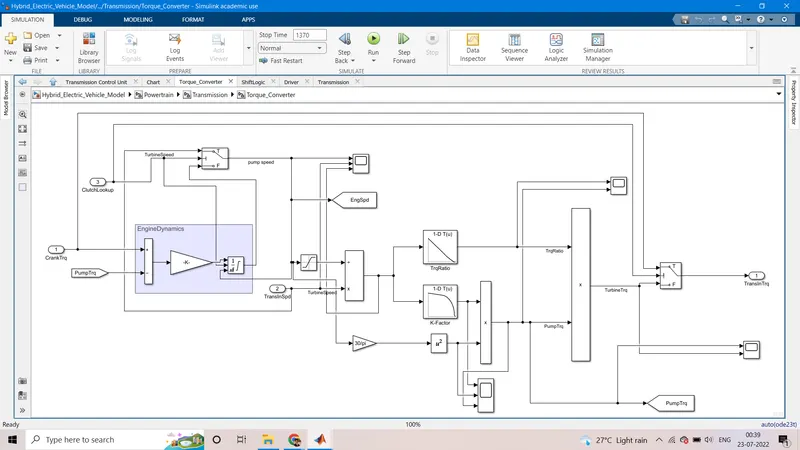
The torque converter uses crank torque, transmission in speed, cluctch lockup as the inputs & by using multiple switch, gain & look up tables determines the transmission input torque.
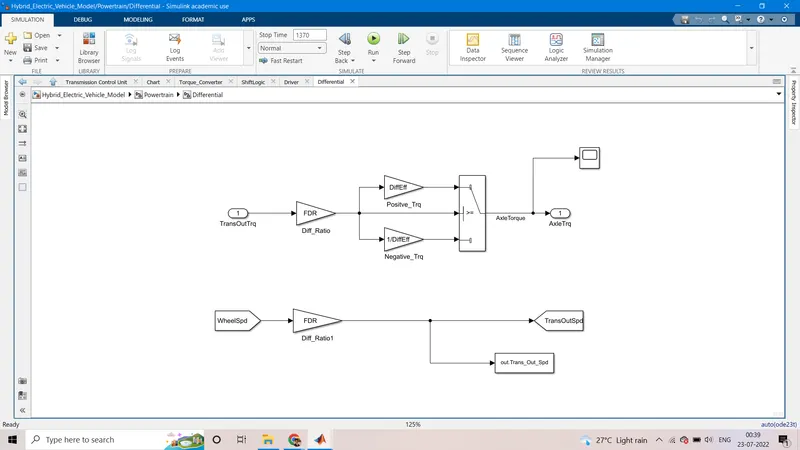
In this taking input is the transmission output then its going to the differential ratio multiplied the output and input torque then meet axle torque. The axle torque is a lower than the transmission torque and differential ratio.
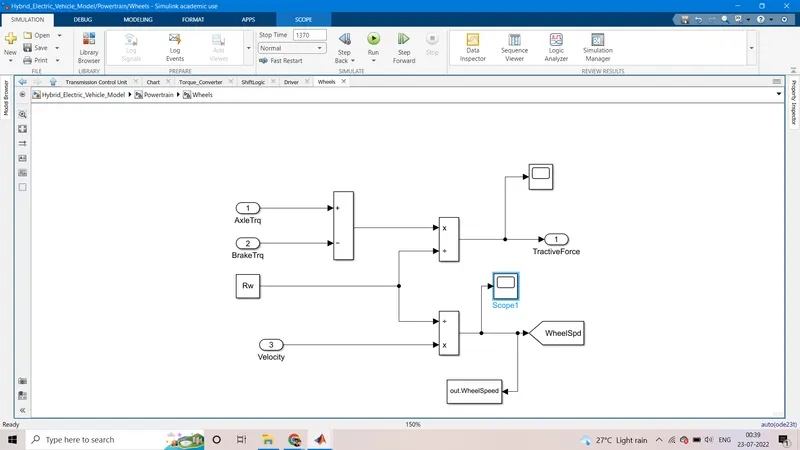
In this model we take the axle torque from differentail and brake torque from controller. it is substracts and multiplied rolling radius and velocity then we meet the tractive force from axle and brake torque. and the wheelspeed is meet using velocity.
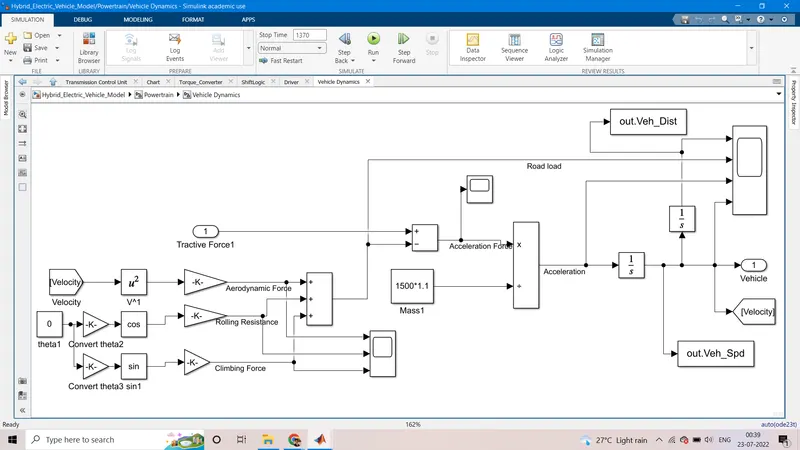
In this takes tractive force and road load. It is dictates vehicle speed based on tractive force and road load.
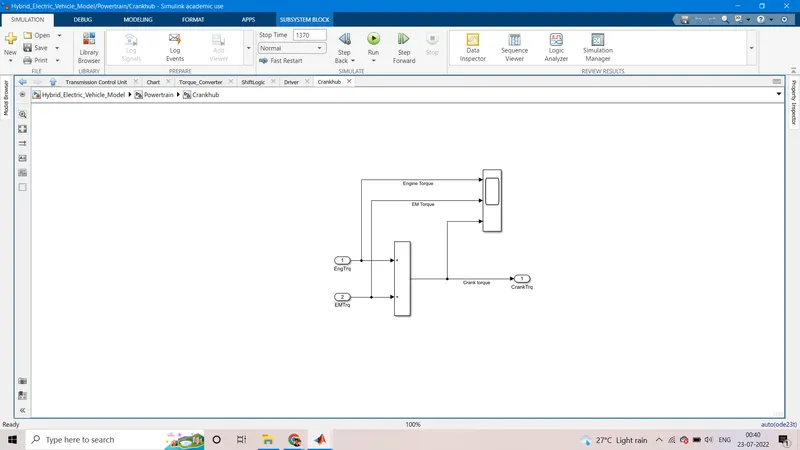
Crankhub adds the engine and motor torque to give the output as crank torque.
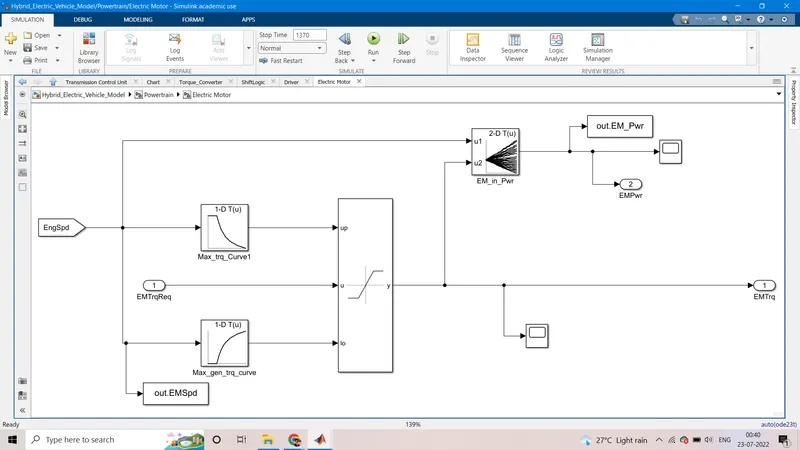
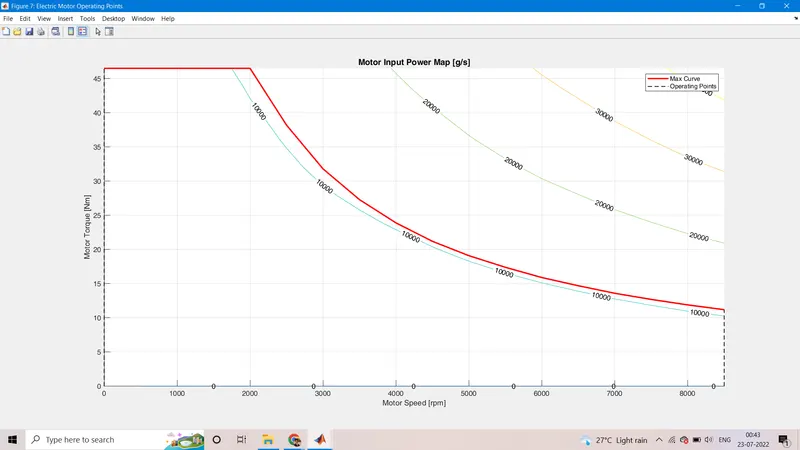
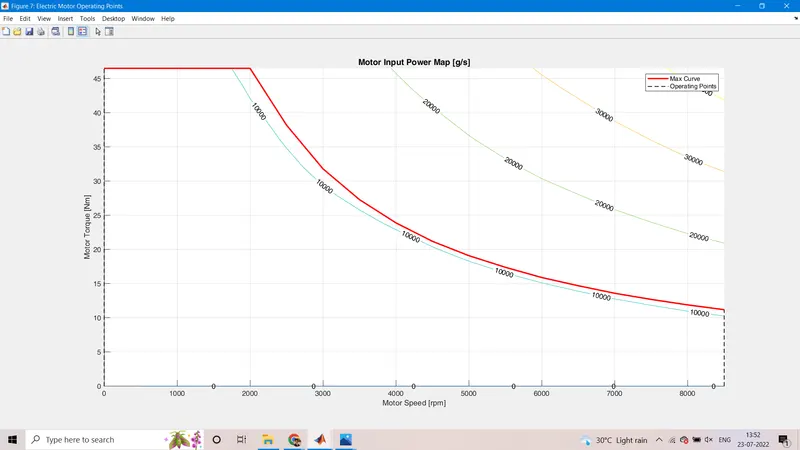
Electric motor uses motor required torque & engine speed along with lookup tables & saturation block to determine motor torque & motor power.
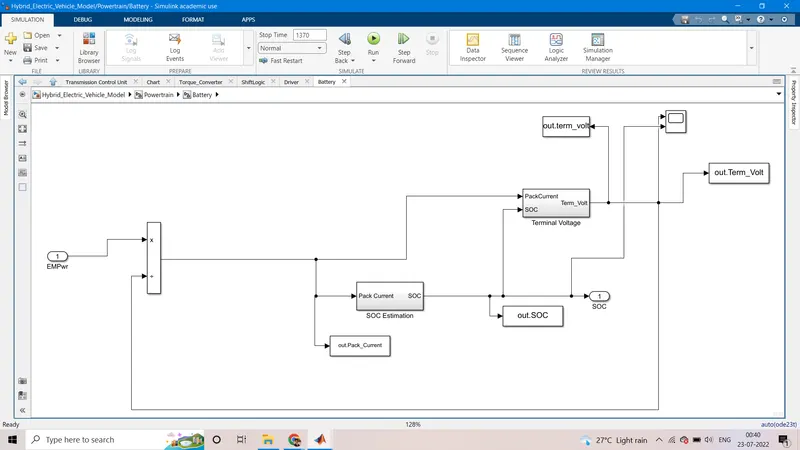
In this we give input as power then it multiply and give to pack current. then from soc estimation meet output SOC its give to terminal voltage as input and then meet terminal voltage as output.
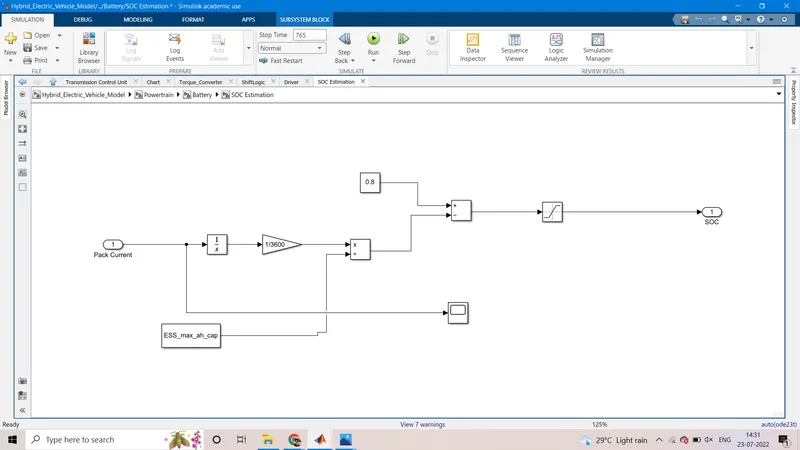
In this we integrate pack current and convert it rad to amp then saturated and meet SOC.
Then we create one coding file for creating plots and to meet all answers. that file is shown in next segment.
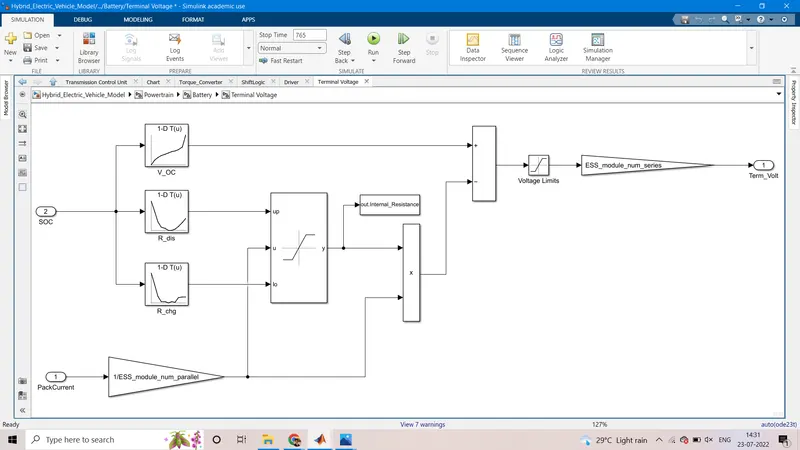
In this use input SOC it is connected to 1d lookup table 1st table variable interpolated as state of charge and open voltage circuit. In 2nd table variable interpolated as resistance discharge and state of charge and in 3rd table variable interpolated as resistance charge and state of charge. Then it is passed to switch block for controlling the threshold. then they give voltage limits as max volts and min volts. then meet terminal Voltage.
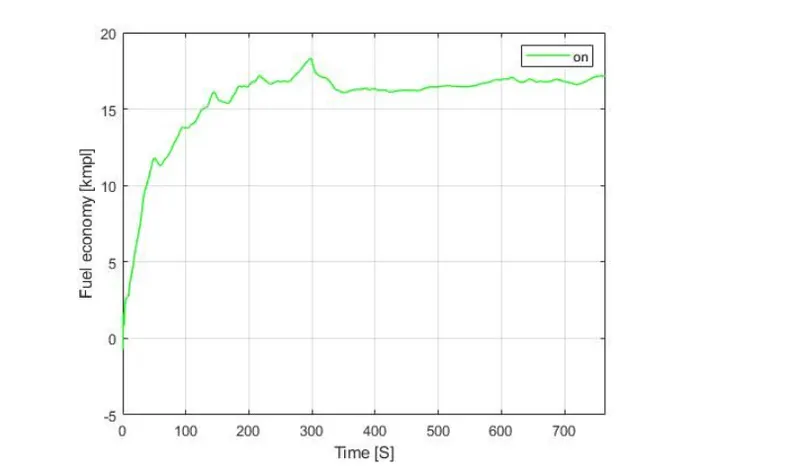
Fuel Economy Numbers for project 2
| S.No | Drive cycle | Fuel Economy Number (Kmpl) |
| 1 | UDDS | 15.0773 |
| 2 | HWFET | 17.1613 |
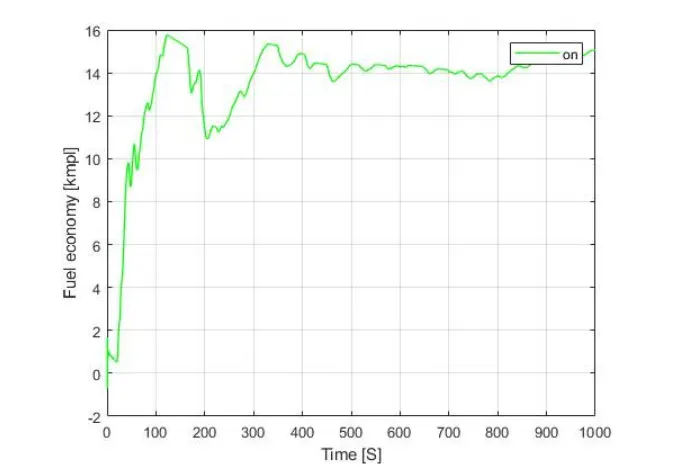
As we see the fuel economy is high in HWFET compared to UDDS. It is because in urban driving the vehicle encounters more traffic and it has to stop for fever distance and it consumes more fuel at the starting. In HWFET the vehicle encounters no traffic and it moves without use of too much braking so it will have more fuel economy number.
Comparing with fuel economy numbers for project 1
| S.No | Drive cycle | Fuel Economy Number (Kmpl) |
| 1 | UDDS | 14.209 |
| 2 | HWFET | 16.503 |
As we see the fuel economy numbers for project 2 are bit higher when compared to project 1 because of implementing the electric motor as it is P1 hybrid it may not have much variation in the fuel economy but as we implement other architechture it will increase by huge amount.
Plots:
1. UDDS
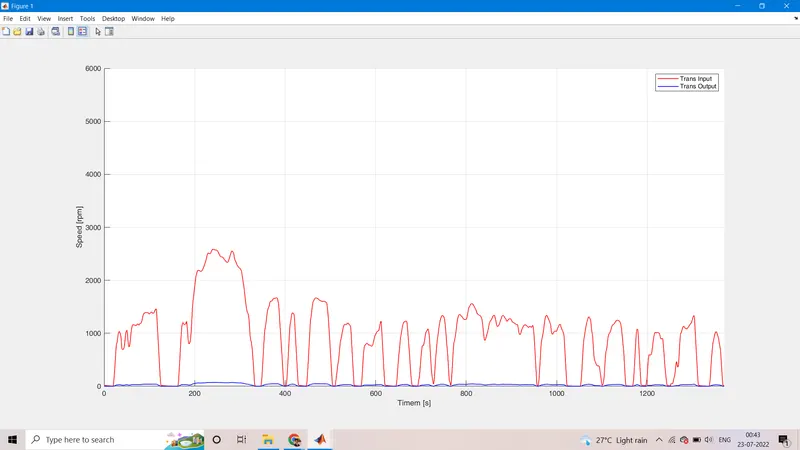
The transmission input speed follows the drive cycle & output speed is comapratively lower but seems to follws the drive cycle as well.
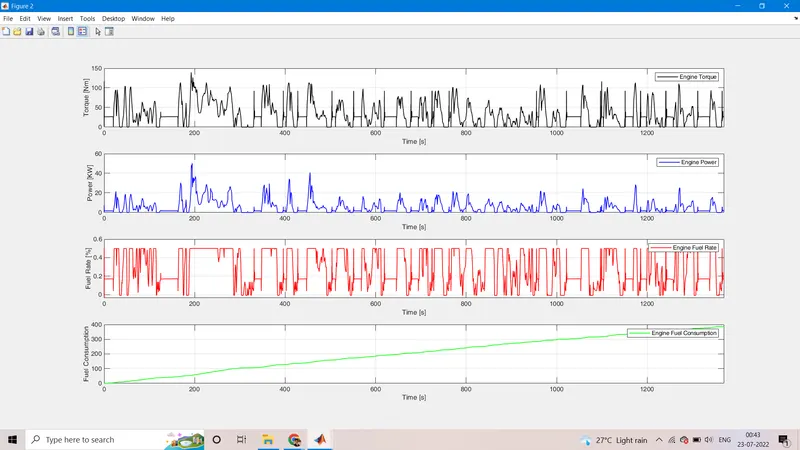
The engine torque & power are proportional to the drive cycle, whereas the fuel consumption rate peaks as the velocity increases but flattens at about 50% due to the saturation limit set. The fuel consumption increases linearly with time.
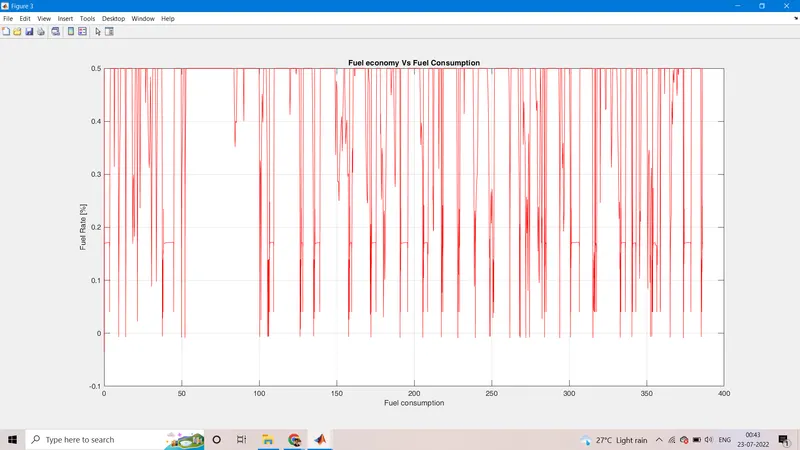
The rate of fuel consumption can be any value within the saturation limit as long as the fuel consumption is possible & is independent of the fuel already consumed.
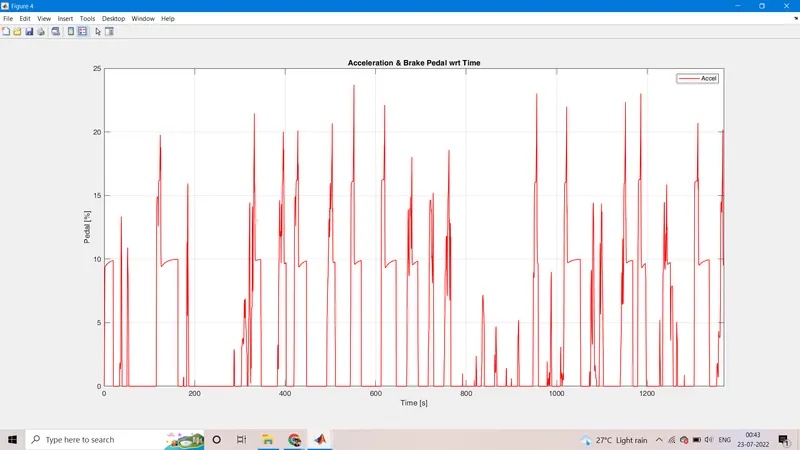
The pedalling is directly proportional to velocity requirement & spikes & valleys with respect to the speed requirements.
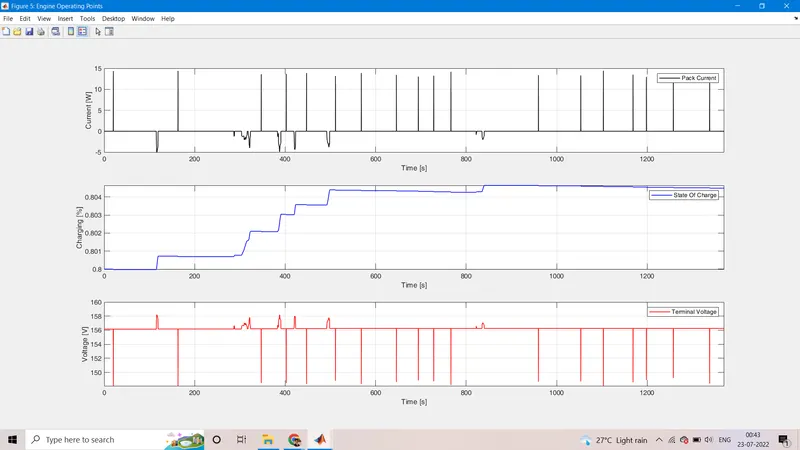
For the given setup, the pack current remains zero for most of the cycle & only chips in for a short period of time when engine alone cannot fulfill the torque requirements by design. The battery can charge when braking due to regenration effect & in this periods, pack current can be negative as well. As current for motoring is not utilized for most of the time the charge in the battery keeps increasing in steps due to periods of regeneration. The terminal voltage remains constant near the nominal voltage for most of the time & drops momentarily to lower values only when higher torque is required & spikes at the time of regeneration.
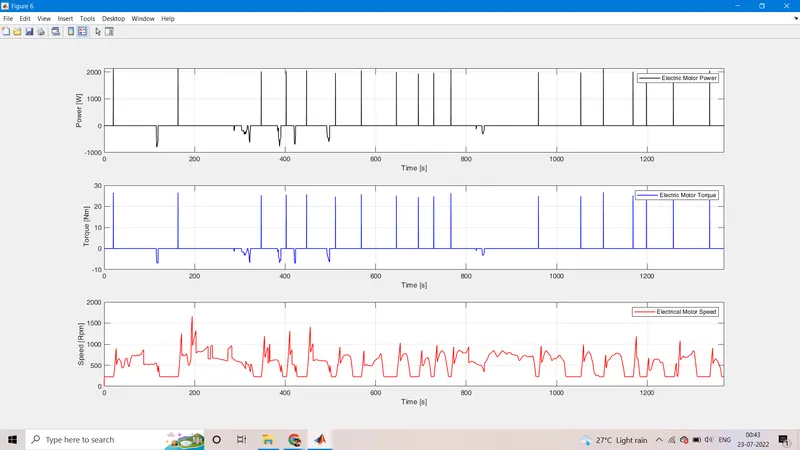
Power & torque of motor are directly proportional to the pack current & follow the same trend as the current.
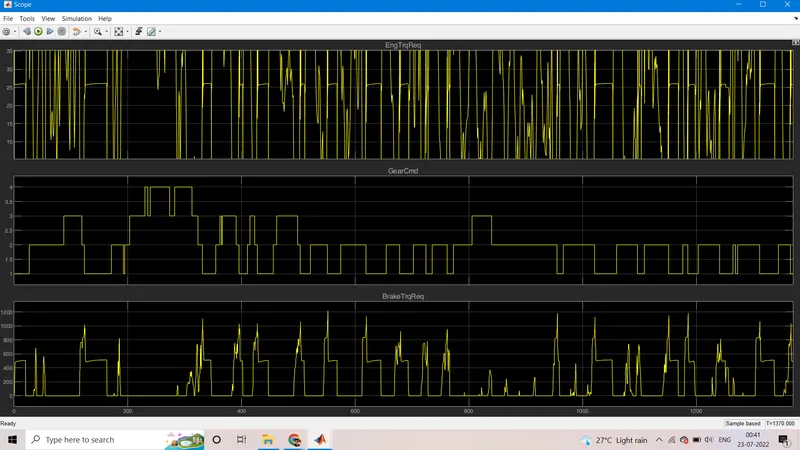
The gear varies with respect to the cycle requirement and it is in the form of a step function.
2. HWFET
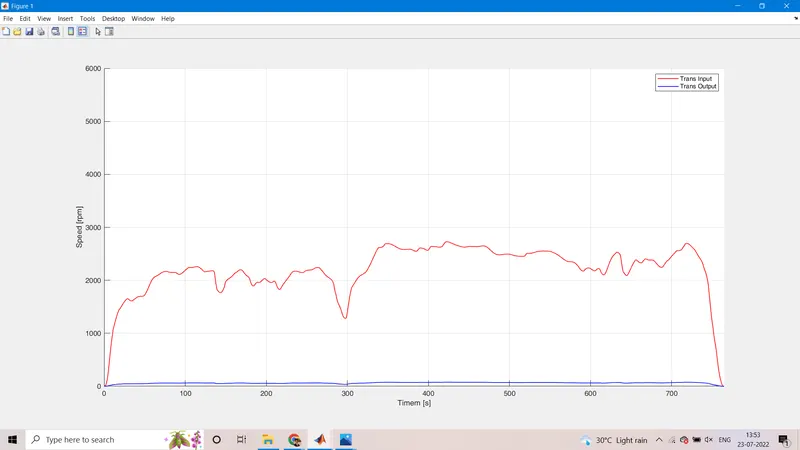
The transmission input speed follows the drive cycle & output speed is comapratively lower but seems to follws the drive cycle as well.
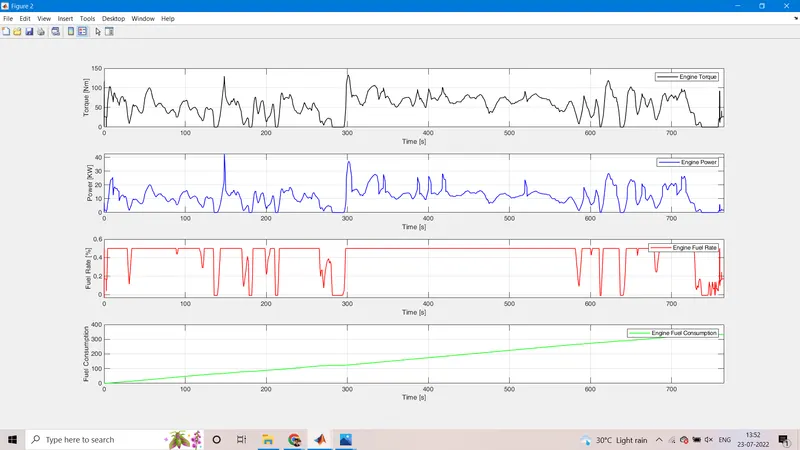
The engine torque & power are proportional to the drive cycle, whereas the fuel consumption rate peaks as the velocity increases but flattens at about 50% due to the saturation limit set. The fuel consumption increases linearly with time.
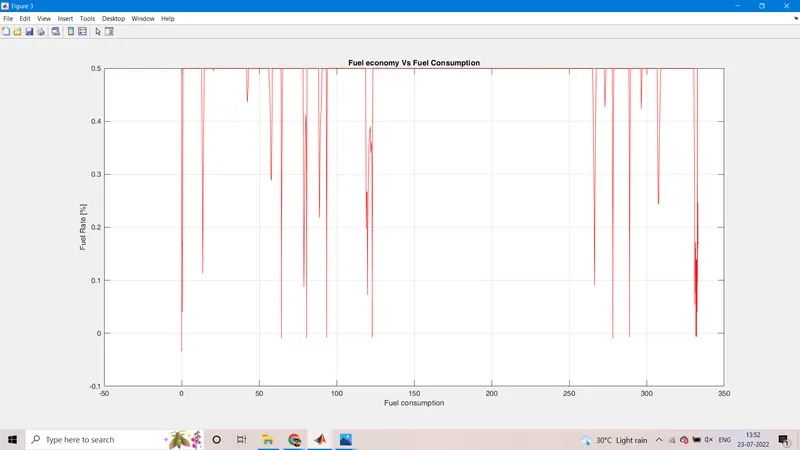
The rate of fuel consumption can be any value within the saturation limit as long as the fuel consumption is possible & is independent of the fuel already consumed.
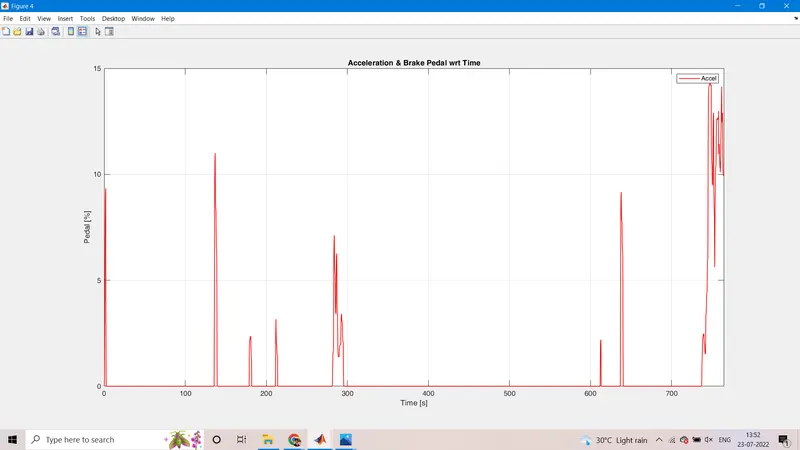
The pedalling is directly proportional to velocity requirement & spikes & valleys with respect to the speed requirements.
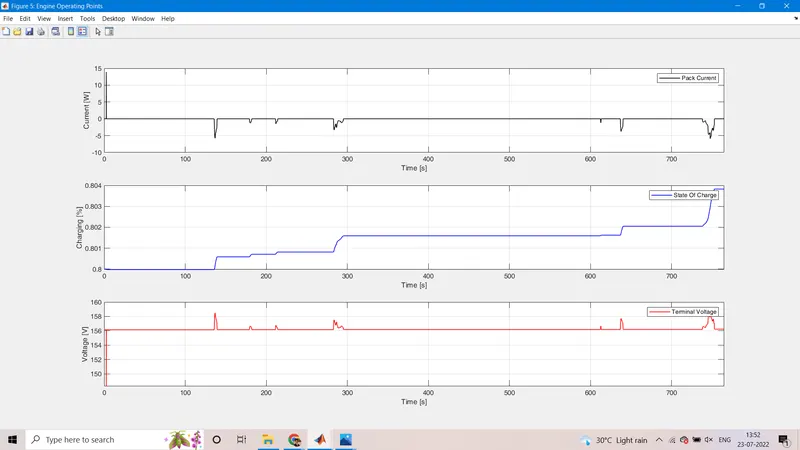
For the given setup, the pack current remains zero for most of the cycle & would only chip in for a short period of time when engine alone cannot fulfill the torque requirements by design. The battery can charge when braking due to regenration effect & in this periods, pack current can be negative as well. As current for motoring is not utilized for most of the time the charge in the battery keeps increasing in steps due to periods of regeneration. The terminal voltage remains constant near the nominal voltage for most of the time & would drop momentarily to lower values only when higher torque is required & spikes at the time of regeneration.
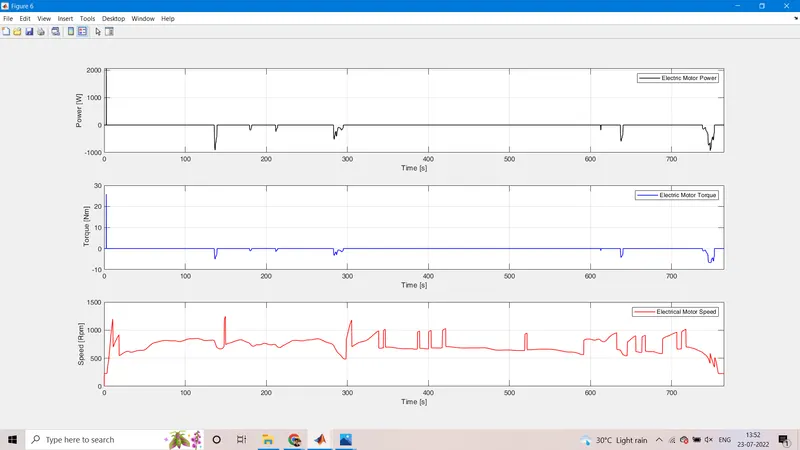
Power & torque of motor are directly proportional to the pack current & follow the same trend as the current.
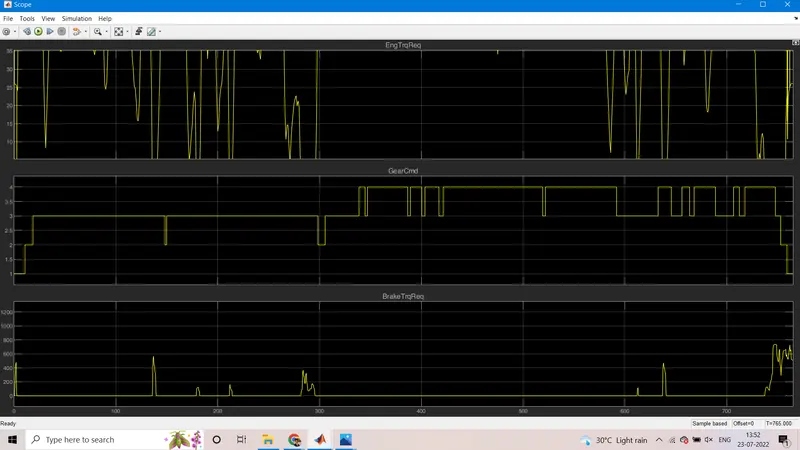
The gear varies with respect to the cycle requirements and it is in the form of a step function.
%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model

%% Vehicle Parameters
M = 1500;       % Vehicle weight [kg]
Cr = 0.015;     % Rolling resistance coefficient
Rw = 0.35;      % Rolling radius [m]
Cd = 0.33;      % Drag coefficient
Af = 2;         % Frontal area [m2]
rhoa = 1.225;   % Air density [kg/m3]
Vwind = 0;      % Wind velocity [kmph]
g = 9.81;       % Gravitational acceleration [m/s2]
theta = 0;      % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface

%% Powertrain Parameters
FDR = 3.73;                         % Final Drive Ratio / Diff Ratio
DiffEff = 0.99;                     % Differential efficiency (assumed independent of operating conditions)

NumGear = 4;                        % Number of gears in transmission
TransGear = [1:NumGear];            % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7];  % Corresponding Transmission ratios
TransEff = 0.90;                    % Transmission efficiency (assumed independent of operating conditions)

TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1];   % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1];   % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]

load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
load Vehicle_Data/EM_Honda_Insight_10kW
load Vehicle_Data/ESS_NiMH6


ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;

Eng_idle_spd = 600;
SOC_max = 0.9;
SOC_min = 0.6;

%% Driver Parameters
Kp = 10;                    % P gain for driver PI model
Ki = 1;                     % I gain for driver PI model
Drive_Cycle_Select = 2;     % Drive cycle selection

% Drive cycle values in m/s

if Drive_Cycle_Select == 1
    load DriveCycles/UDDS;

elseif Drive_Cycle_Select == 2
    load DriveCycles/HWFET;

elseif Drive_Cycle_Select == 3
    load DriveCycles/FTP;

elseif Drive_Cycle_Select == 4
    load DriveCycles/US06;

elseif Drive_Cycle_Select == 5
    load DriveCycles/NEDC;

elseif Drive_Cycle_Select == 6
    load DriveCycles/WLTP;

end

time_end = cyc_time(end);
vel_end = cyc_vel(end);


%Processing file : Hybrid Electric Vehicle
%% Renaming variables
Time = out.tout;
Acc_Pdl = out.Acc_Pdl;          % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl;          % Brake pedal [%]
Gear_Cmd = out.Gear_CMD;        % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi;  % Transmission input speed [rpm]
Trans_Out_Spd = out.TransOutSpd*30/pi;% Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq;          % Engine brake torque [Nm]
Eng_Spd = out.Eng_Spd*30/pi;    % Engine speed [rpm]
Eng_Fuel_Consump = out.Eng_Fuel_Consumption;    % Engine fuel consumption [g]
Veh_Dist = out.Veh_Dist/1000;   % Distance traveled by vehicle [km]
Veh_Spd = out.Veh_Spd*18/5;     % Vehicle speed [kmph]
Wheel_Speed = out.WheelSpeed;     % Wheel speed [kmph]
Eng_Fuel_Rate = out.Eng_Fuel_Rate; % Engine fuel rate [%]
EM_Speed = out.EMSpd*18/5;        % Electric Motor Speed
EM_Power = out.EMPwr;            % Electric Motor Power
EM_Torque = out.EMTrq;           % Electric Motor Torque
Term_Volt = out.term_volt;        % Terminal Voltage of battery
Soc = out.SOC;                    % State Of Charge
Pack_Current = out.Pack_Current;   %Pack current of battery

%% Data Analysis
Eng_Pwr = (pi/30)*Eng_Spd.*Eng_Trq/1000;   % Engine brake power [kW]
rho_petrol = 0.7197;                    % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol);    % Fuel economy [kmpl]


%% Plotting vehicle characteristics time trace transmission IN/OUT and Wheel Speed
figure(1)
hold on
grid on
%plot(Time, Trans_In_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Trans_Out_Spd, 'linewidth', 1, 'Color', 'red');
plot(Time, Wheel_Speed, 'linewidth',1, 'color', 'blue')
ylabel('Speed [rpm]')
xlabel('Timem [s]')
xlim([0, Time(end)]);
ylim([0, 6000]);
legend('Trans Input','Trans Output','Wheel Speed');

%% Plotting Engine speed, Engine Torque, Engine Power,Engine fuel rate,Engine fuel consumption wrt Time
figure(2)
subplot(4,1,1)
plot(Time,Eng_Trq,'linewidth',1,'color','black')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Torque [Nm]')
legend('Engine Torque')
grid on

subplot(4,1,2)
plot(Time,Eng_Pwr,'linewidth',1,'color','blue')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Power [KW]')
legend('Engine Power')
grid on

subplot(4,1,3)
plot(Time,Eng_Fuel_Rate,'linewidth',1,'color','red')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Fuel Rate [%]')
legend('Engine Fuel Rate')
grid on

subplot(4,1,4)
plot(Time,Eng_Fuel_Consump,'linewidth',1,'color','green')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Fuel Consumption')
legend('Engine Fuel Consumption')
grid on

% Plotting fuel economy Vs Engine Fuel consumption
figure(3)
plot(Eng_Fuel_Consump,Eng_Fuel_Rate,'color','r')
xlabel('Fuel consumption')
ylabel('Fuel Rate [%]')
title('Fuel economy Vs Fuel Consumption')
grid on

%% Potting Accelerator pedal, Brake pedal and gear command with respect to time
figure(4)
%subplot(2,1,1)
%hold on
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlabel('Time [s]');
xlim([0, Time(end)]);
grid on
legend('Accel','Brake');
title('Acceleration & Brake Pedal wrt Time')


%% Plotting engine operating points on engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);

%% State of Charge, Pack Current, And Terminal Voltage with respect to Time
figure(5)
subplot(3,1,1)
plot(Time,Pack_Current,'linewidth',1,'color','black')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Current [W]')
legend('Pack Current')
grid on

subplot(3,1,2)
plot(Time,Soc,'linewidth',1,'color','blue')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Charging [%]')
legend('State Of Charge')
grid on

subplot(3,1,3)
plot(Time,Term_Volt,'linewidth',1,'color','red')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Voltage [V]')
legend('Terminal Voltage')
grid on

%% Motor Speed, Torque, Motor input power with respect to Time
figure(6)
subplot(3,1,1)
plot(Time,EM_Power,'linewidth',1,'color','black')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Power [W]')
legend('Electric Motor Power ')
grid on

subplot(3,1,2)
plot(Time,EM_Torque,'linewidth',1,'color','blue')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel(' Torque [Nm]')
legend('Electric Motor Torque')
grid on

subplot(3,1,3)
plot(Time,EM_Speed,'linewidth',1,'color','red')
xlim([0, Time(end)]);
xlabel('Time [s]')
ylabel('Speed [Rpm]')
legend('Electrical Motor Speed')
grid on

%% Plotting EM Operating Points on motor input power Map
figure('Name','Electric Motor Operating Points');
hold on
grid on
title('Electric Motor Operating Points','fontsize',12);
p1=plot(EM_map_spd*30/pi,EM_max_trq,'linewidth',2,'color','r');
p2=line([EM_map_spd(end)*30/pi EM_map_spd(end)*30/pi],[0 EM_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([EM_map_spd(1)*30/pi EM_map_spd(1)*30/pi],[0 EM_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(EM_map_spd'*30/pi,EM_map_trq,EM_inpwr_map');
clabel(c,h);
xlabel('Motor Speed [rpm]');
ylabel('Motor Torque [Nm]');
title('Motor Input Power Map [g/s]');
legend([p1 p3],{'Max Curve','Operating Points'});
axis([EM_map_spd(1)*30/pi EM_map_spd(end)*30/pi 0 EM_map_trq(end)]);