Simulation of CVT vehicle with the Simulink document Model
Objective -
Carry out a system-level simulation of an all-terrain vehicle.
Simulink Model-
It is inbuilt matlab documentation to analyze the functionality of the Cvt model.
Initial conditions to run the model are brake as 0 and throttle as 1.
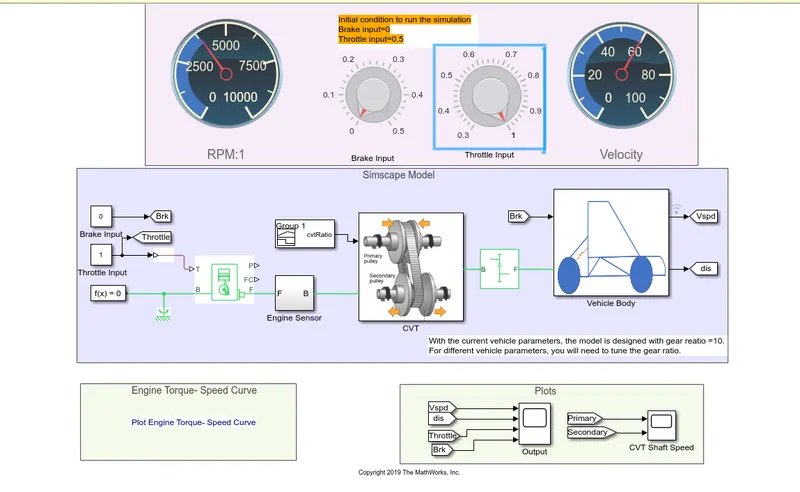
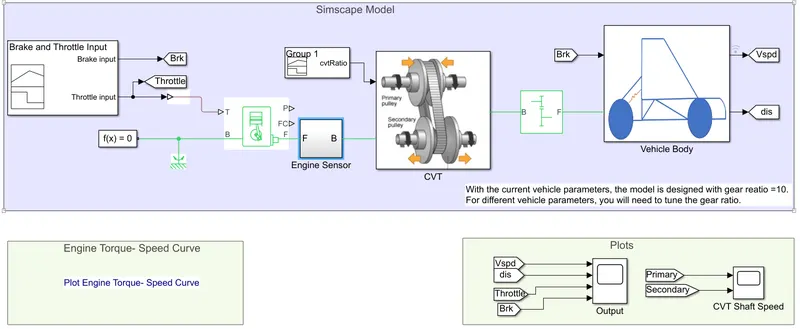
Model Explanation
Blocks-
Signal Builder- There are 2 signal builders used 1 is to input two signals that is throttle and breake, where other one is to provide cvt ratio.
Generic Engine- It is simscape block which acts as typical internal combustion engine and produces rotational movement and output in terms of force
RPM Sensor - It is not simscape block it is user defined subsystem to to sense the force from the engine and give output in terms of angular moment.
Cvt Subsystem - Cvt system is not simscape block which is subsystem created with the help of simulink blocks, It takes the rpm and Cvt ration as input and give the two output one when the Cvt ration is not applied and the other one is when ratio is applied that is basically output shaft.
Simple Gear- Simscape block acting as the gear.
Vehicle body- It is consists of several vehicle simscape parts connected to each other which takes gear power and break as input and get vehicle speed and distance as output.
Scope - It is typical simulink block to plot the graphs against time.
Observation of model
-If initially we change the brake value to some other than zero and keep throttle constant then the initial speed is little lesser than the 60
-If we go according to the initial condition and run the model simulation it will show contant initial speed
-Again if we lower throttle value and increase break value speed will lower again if increase throttle with same break the speed increased upto 60
-There is some error with model as we increase the break value an reduce the throttle it will go down to slower speed and eventually to zero but again if we increase the throttle and lower the breaking value to zero speed will not increase and remain to zero
Results and Conclusion-
- The CVT simulink model has been studied well.
-The graphs shows the approximately correct values according to input.
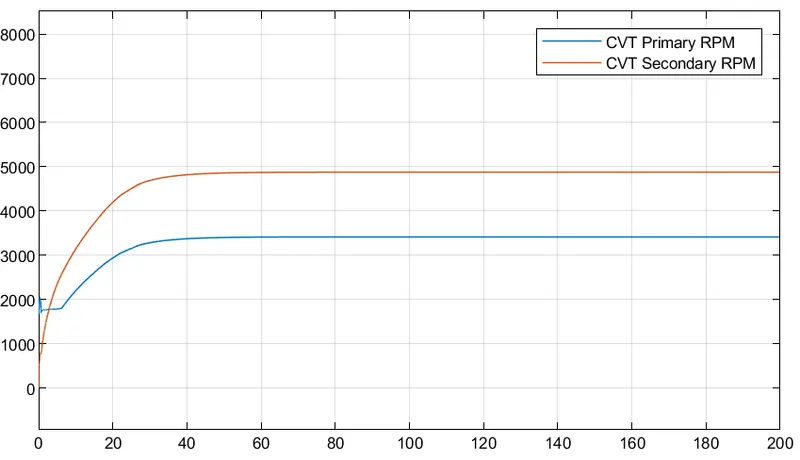
Primary RPM is the input rpm in CVT and Secondary is output.
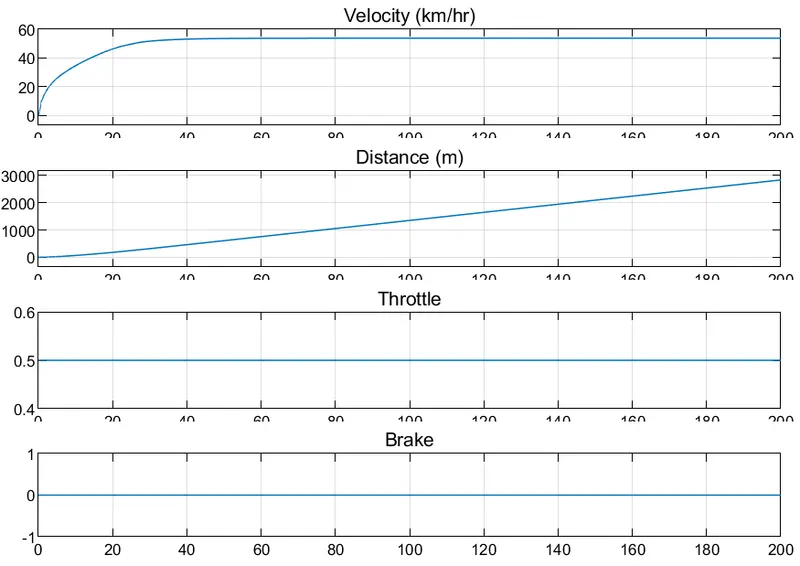
This graph shows the velocity distance and brake throttle values.