Project
BAJA ALL TERRAIN VEHICLE
AIM:- To prepare a technical report on simulation of Baja All- Terrain vehicle (ATV) under different conditions.
OBJECTIVE:-
- Study the ATV model without dashboard.
- Study the ATV model with dashboard.
- Study the ATV model using lookup table without dashboard.
- Study the ATV model using lookup table with dashboard.
All – terrain vehicle mainly design to operate on a rough road or surface, it can be single sitter or double sitter it has four low pressure or non – pneumatic tires and handlebar for steering control. It is also light in weight as compare to all traditional vehicle.
An automatic transmission, continuously variable transmission (CVT) that provide more useable power, better fuel economy and a smoother driving experience than a traditional automatic transmission. A continuously variable transmission (CVT) draws top engine power from a small engine, which gives drivers quicker acceleration than standard automatic transmission because of their greater ability to control the engine speed range. Continuously variable transmission (CVT) Produce fewer emission.
STUDY -1 BAJA ALL TERRAIN VEHICLE WITHOUT DASHBOARD MODEL
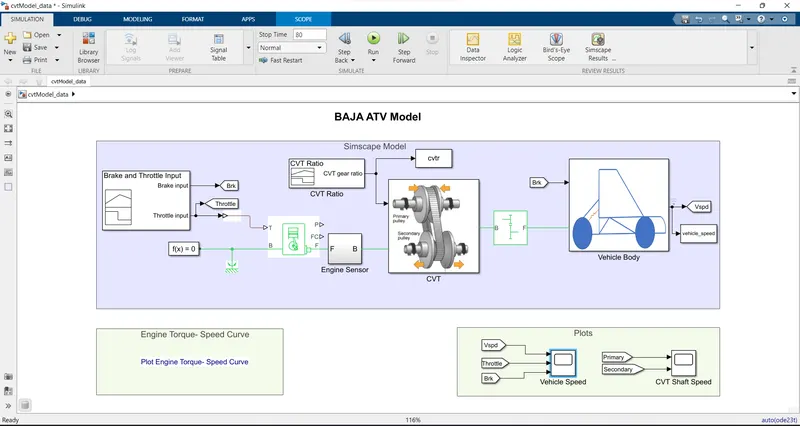
In this Simulink model of CVT consist of signal builder, generic engine, motion sensors, vehicle transmission, vehicle body, tyres and solver configuration blocks are used.
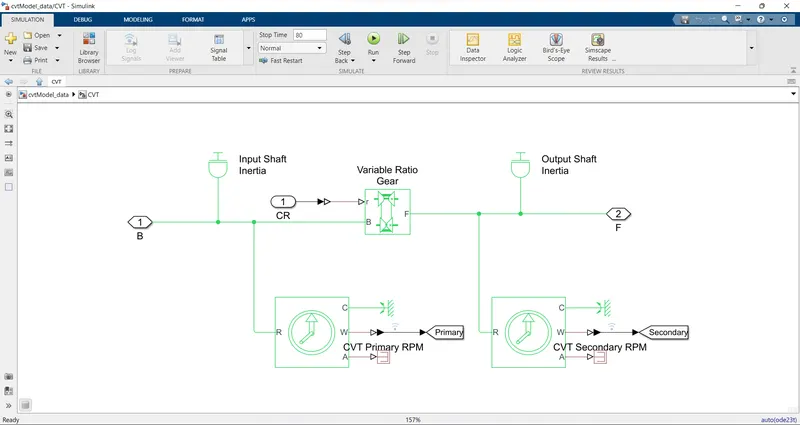
CVT SUBSYSTEM WITHOUT DASHBOARD
The CVT subsystem includes transmission block, input and output shaft inertia and motion sensor.
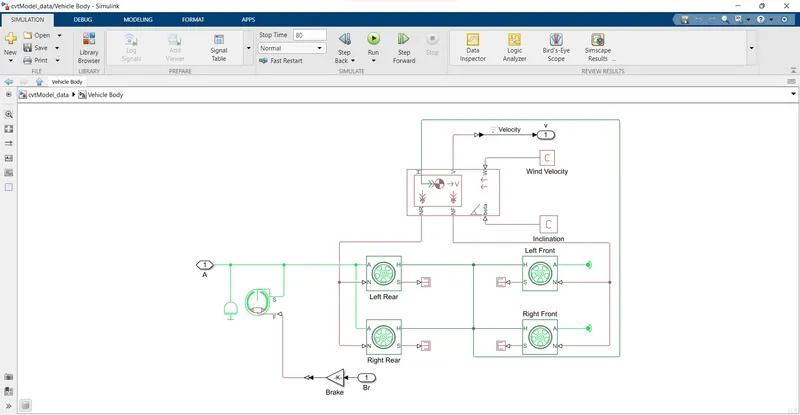
VEHICLE BODY SUBSYSTEM WITHOUT DASHBOARD
The vehicle body subsystem includes vehicle body block, double drum brake and tyres.
EXPLANATION & RESULT-
The initial engine speed is given as 2100 rpm, mechanical rotation for driven pulley and driver pulley as 0.8 & 0.7 respectively. The mass of the vehicle as 250kg and 2 axels which connects 4-wheel accordingly. The signal builder block is used to provide input for brake throttle and gear ratio. Brake input is maintained as 0(zero) for overall simulation. The throttle input is given as 0.3 for 20 sec and increase to 1 for overall simulation. The throttle value is mainly to control the flow or amount of fuel into the engine, If the throttle value increase, the flow of fuel increase to the IC engine which in turn increase the power of the engine. The gear ration is maintained as 2.3 for 5 secs and linearly decrease to 1.8 and maintained constant for overall simulation.
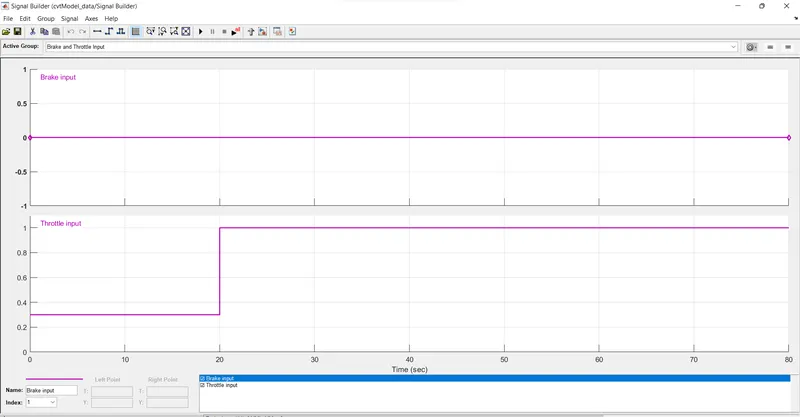
BREAK AND THROTTLE INPUT DATA WITHOUT DASHBOARD
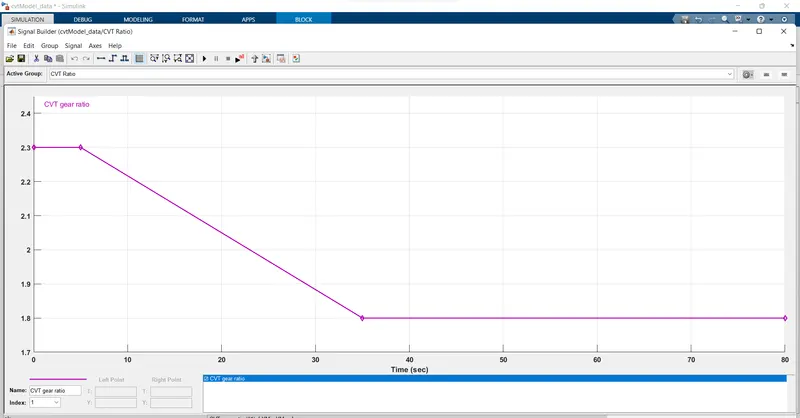
CVT RATIO INPUT WITHOUT DASHBOARD
RESULT/OUTPUT-
Variation of velocity & Shaft speed
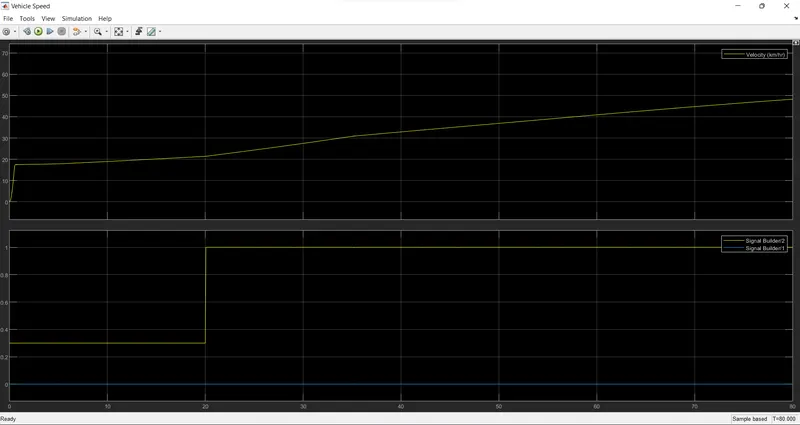
In the above figure, the brake is maintained as constant and increase in throttle which shows increase in velocity. The flow of fuel is increses when the throttle increases from 0.3 to 1, thus the power in the engine increases. The torque reaches approximately 7N-m at 1.8 gear ratio, which defines that gear ratio is directly proportional to the torque. By this gear ratio, the speed & velocity can achieve maximum.
In the above figure, the primary shaft reaches high speed and secondary shaft as low rotational speed because the radius of the primary shaft as more than the secondary shaft, the speed is directly proportional to the radius of the shaft. As the radius increases the speed of the shaft also increases.
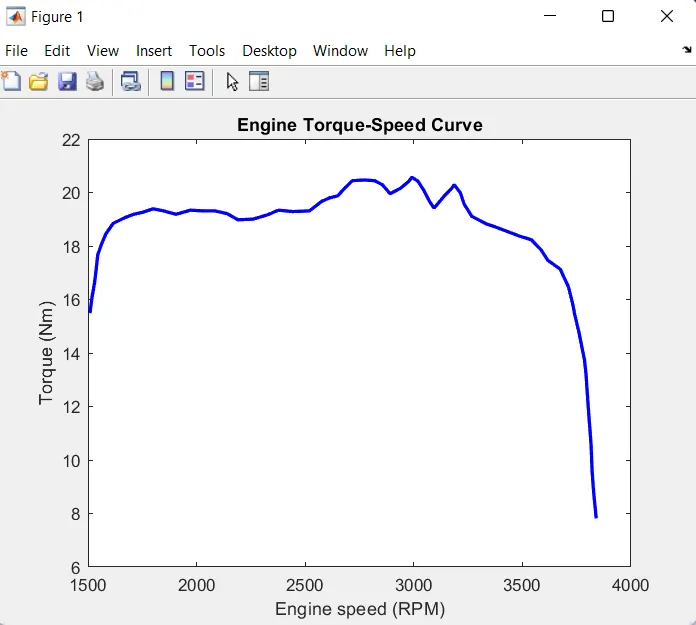
ENGINE TORQUE SPEED CURVE-
STUDY-2 BAJA ALL TERRAIN VEHICLE WITH DASHBOARD MODEL
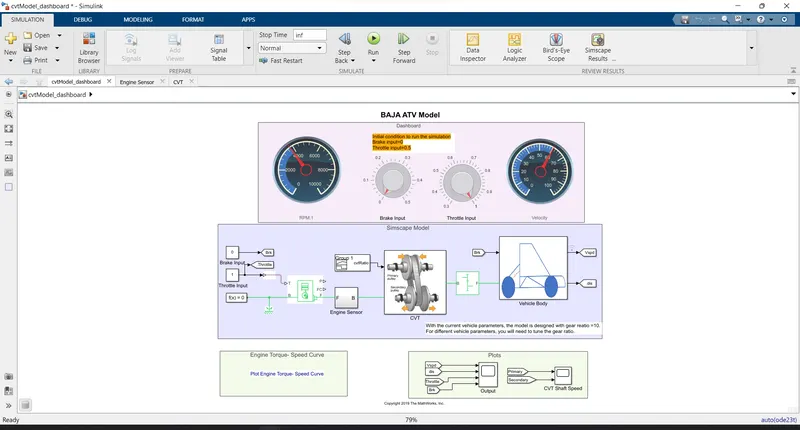
The above figure shows 'Baja ATV with dashboard' model which consists throttle meter and brake input in the dash board instead of giving input through signal builder. Rest of the blocks and subsystems are common in the above Baja ATV model without dash board as shown in above figures. The main concept of using dash board is study the result by varying the input of brake and throttle, which shows that the velocity and speed of the engine. The gear ratio is maintained as 2.3 for 5 secs and linearly decreases to 1.8 and maintained constant for overall simulation as show in above figure. As the brake input varies from 0 – 0.5, the velocity and speed decreases accordingly. By increasing the throttle, the velocity and speed of the engine & shaft increases.
RESULT/OUTPUT-
Variation of velocity & Shaft speed
In the above figure, the velocity of the vehicle is maintained as constant for constant throttle value as 0.3 and varying by increasing the value of throttle which increases the velocity of vehicle. By increasing the brake input, the velocity of the vehicle decreasing accordingly.
In the above figure, the primary shaft speed increases by increasing throttle and decreasing by increasing brake input value, which defines that the throttle can flow more amount of fuel which increases the power of the engine and similar to the secondary shaft. The radius of the primary shaft as more than the secondary shaft, the speed is directly proportional to the radius of the shaft. As the radius increases the speed of the shaft also increases.
SPEED-3 BAJA ALL TERRAIN VEHICLE USING LOOKUP TABLE CHART WITHOUT DASHBOARD
A lookup table is an array of data that maps input values to output values, thereby approximating a mathematical function. Given a set of input values, a lookup operation retrieves the corresponding output values from the table. If the lookup table does not explicitly define the input values. Simulink can estimate an output value using interpolation, extrapolation, or rounding.By using Simulink model of CVT consists of step time, generic engine, motion sensors, vehicle transmission, vehicle body, tyres and solver configuration blocks etc. The CVT subsystem includes look up table, Transmission block, input and output shaft inertia and motion sensors. The vehicle body subsystem includes vehicle body block, double drum brake and tyres. The initial engine speed is given as 2100 rpm, mechanical rotation for driven pulley and driver pulley as 0.8 & 0.7 respectively.The mass of the vehicle as 250kg and 2 axles which connects 4-wheel accordingly.
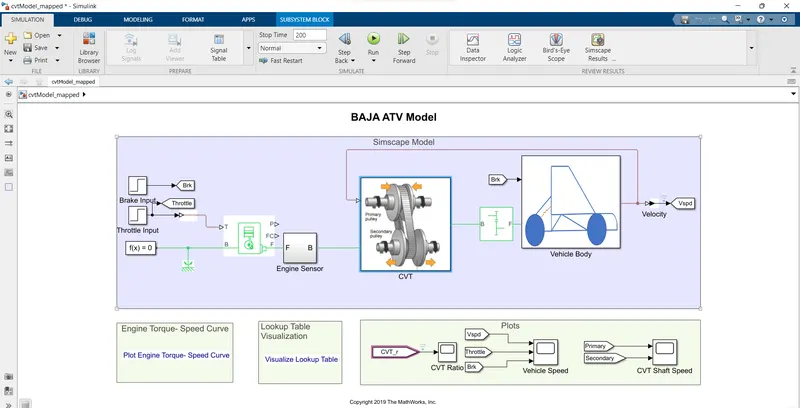
BAJA ALL TERRAIN MODEL WITHOUT DASHBOARD
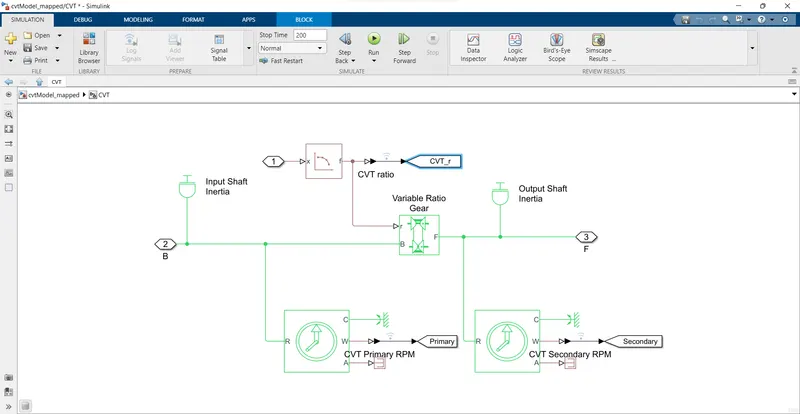
CVT SUBSYSTEM WITHOUT DASHBOARD
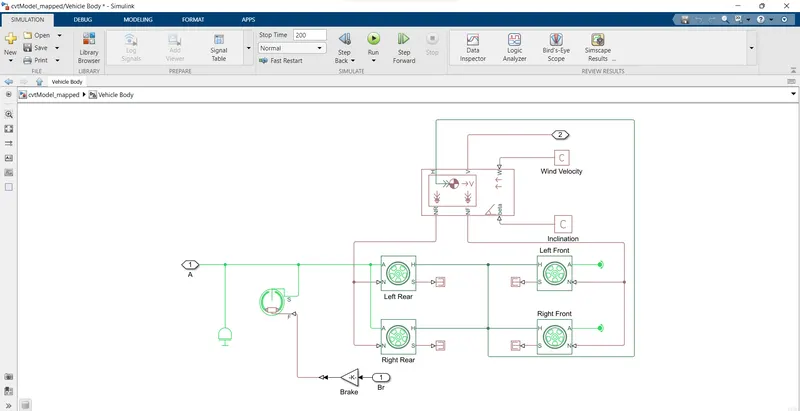
VEHICLE BODY SUBSYSTEM WITHOUT DASHBOARD
The brake input and throttle input is given by step time, which depends on the run time and varies accordingly. By using Lookup table for gear ratio which takes as input to the CVT and works according to the input gear ratio and obtained the output. This method is very effective which can avoid the unusual torque at the certain speed and very easy to achieve greater velocity & engine speed. It works as closed loop when the input is given by lookup table. The simulink get the input value from lookup table and obtain the result according to the input values of gear ratio. The gear ratio varies from 2.3 to 1.8 as taken as input and output interms of velocity. The maximum velocity reached as 57 kmph approximately.
RESULT/OUTPUT-
Variation of velocity & Shaft speed
In the above figure, the brake is maintained as constant and increase in throttle which shows increase in velocity. The flow of fuel is increses when the throttle increases from 0.3 to 1, thus the power in the engine increases. The torque reaches approximately 7N-m at 1.8 gear ratio, which defines that gear ratio is directly proportional to the torque. By this gear ratio, the speed & velocity can achieve maximum. The gear ratio is assigned in lookup table and given as input to the simulink which reads every input value and obtain the result according to the input.
In the above figure, the primary shaft speed increases by increasing throttle and decreasing by increasing brake input value, which defines that the throttle can flow more amount of fuel which increases the power of the engine and similar to the secondary shaft. The radius of the primary shaft as more than the secondary shaft, the speed is directly proportional to the radius of the shaft. As the radius increases the speed of the shaft also increases.
STUDY 4- BAJA ALL TERRAIN VEHICLE USING LOOKUP CHART WITH DASHBOARD
BAJA ALL TERRAIN VEHICLE LOOKUP TABLE MODEL WITH DASHBOARD
The above figure shows 'Baja ATV with dashboard' model using lookup table which consists throttle meter and brake input in the dash board and indicated as constant block. Rest of the blocks and subsystems are common in the above baja ATV model without dashboard. The main concept of using dash board is study the result by varying the input of brake and throttle, which shows that the variation of velocity and speed of the engine. The gear ratio is given by lookup table, simulink get the input value from the lookup table and obtain the result according to the lookup table. As the brake input varies from 0 - 0.5, the velocity and speed decreases accordingly which inturn the gear ratio also decreasing. By increasing the throttle, the velocity and speed of the engine & shaft increases. The transmission as primary pulley and secondary pulley, in which the radius of primary pulley increses by compacting and the radius of secondary pulley decreases. As the gear ratio varies, the torque also varies. Gear ratio is directly proportional to the torque, which increases by increasing the gear ratio. At the max torque, the speed and velocity is decreases.
RESULT/OUTPUT-
Variation of velocity & Shaft speed
In the above figure, the velocity of the vehicle is maintained as constant for constant throttle value as 0.3 and varying by increasing the value of throttle which increases the velocity of vehicle. By increasing the brake input, the velocity of the vehicle decreasing accordingly. By using lookup table, it works as closed loop by recording the velocity value and we can get at any particular value of gear ratio which is beyond the range or any random value within the range by using extrapolation and interpolation by lookup table.
In the above figure, the primary shaft speed increases by increasing throttle and decreasing by increasing brake input value, which defines that the throttle can flow more amount of fuel which increases the power of the engine and similar to the secondary shaft. The radius of the primary shaft as more than the secondary shaft, the speed is directly proportional to the radius of the shaft. As the radius increases the speed of the shaft also increases. The throttle value and brake input value can be varying in dashboard, so we can get any particular value for input.
CONCLUSION-
The throttle increases, the velocity also increases which inturn the power in the engine also increases.
The brake input increases, the velocity decreases and engine power also decreases. At a certain brake input value the engine may shut down and there is no power output. The engine power is inversly proportional to the brake input.
The gear ratio increases, torque increases which inturn the velocity decreases.
In the above figure, the velocity is varying wrt the gear ratio. For the high gear ratio, the torque is more which decrease the velocity. By changing to high gear, the gear ratio become less paralelly the torque also less which can get high velocity.