Project 1- Traffic Jam Assistant Feature
Aim:
To develop the traffic jam assistant feature that can assist driving in highway traffic jams while the host vehicle automatically follows the vehicle ahead
Objectives:
- This model must be developed in MATLAB Simulink as per MBD guidelines.
- Code Generation Profile must be in Embedded Coder.
- Simulink Data Dictionary must be created for the model & must be linked to the model.
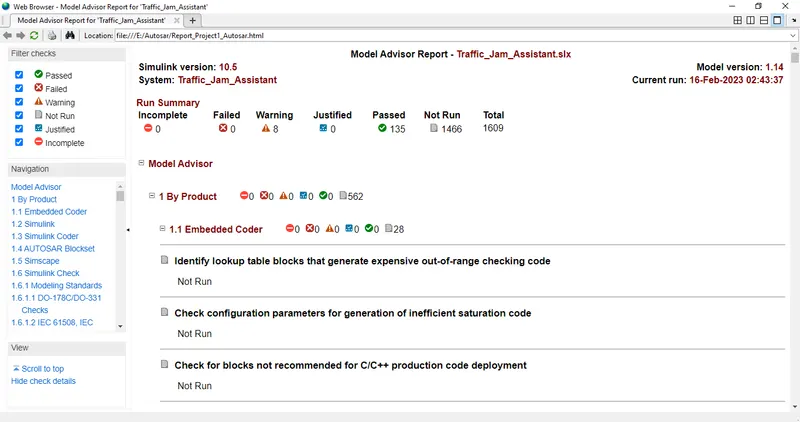
- Model Advisor Report is mandatory & this will be followed by Code Generation.
Project 1-Traffic Jam Assistant Feature
Traffic Jam Assistance is an active safety system as part of the comprehensive range of intelligent assistance systems. These are grouped together under the name MG Pilot. These so-called Advanced Driver Assistance Systems (ADAS) are standard for all MG models and includes 12 to 15 different features, depending on the model.
These MG Pilot safety systems warn the driver of potential hazards and even intervene if necessary. Think of Lane Keep Assistance, Rear Traffic Alert, Blind Spot Monitoring, Drowsiness Warning System and Front Collision Warning with Automatic Emergency Braking. The purpose of this is to make driving easier, more enjoyable and above all, safer. But MG Pilot also includes driver assistance systems which partly take over driving, like Traffic Jam Assistance
Traffic Jam Assistance (TJA) is an advanced driver assistance system that continuously measures the speed of the surrounding vehicles when Adaptive Cruise Control is switched on. That speed is compared with your own driving speed. If Traffic Jam Assistance detects many surrounding vehicles at speeds below 60 km/h – and you are therefore very likely to be in a traffic jam – the driver can activate Traffic Jam Assistance. With this, your MG partly takes over the driving.
With Traffic Jam Assistance switched on, the car automatically follows the vehicle in front. It accelerates and brakes all by itself, at all speeds below 60 km/h to a standstill and further. In addition, the intelligent technology continuously keeps the distance you set to the vehicle in front of you. But there is more: with Traffic Jam Assistance, your MG also steers automatically to stay neatly in the middle of the lane. Even in gentle corners! Very comfortable, carefree and safe driving, regardless the visibility, the weather conditions and the amount of traffic on the road.
Basic Working Principle:
Traffic Jam Assistant is based on the sensors and the functionality of the Adaptive Cruise Control (ACC) with stop & go and Lane Keeping Support (LKS). When ACC ‘Stop & Go’ is turned ON, the Traffic Jam Assistant continuously analyses the speed of the surrounding vehicles and compares it with the own driving speed. If the system detects dense traffic or a traffic jam at speeds less than 60 kmph, the driver can activate the functionality by press of a button. The vehicle will now automatically follow the vehicle in front, takes over driving off, acceleration, braking and steering within same lane.
Information regarding the Traffic Jam Assistant will be available to be displayed to the driver in the Instrument Panel Cluster (IPC). The Algorithm which the students need to implement here in this project is predominantly based on IPC units.
Problem Statement:
To develop one specific requirement of Traffic Jam Assistant algorithm which would predominantly feature in the IPC algorithm.Please note that the whole Traffic Jam Assistant is a very huge algorithm & only one small part of the logic is implemented here. Idea is to familiarize with concepts of Model Based Development in MATLAB Environment. The Project must be done keeping in mind the following processes & steps.
- This model must be developed in MATLAB Simulink as per MBD guidelines.
- Code Generation Profile must be in Embedded Coder.
- Simulink Data Dictionary must be created for the model & must be linked to the model.
- Model Advisor Report is mandatory & this will be followed by Code Generation.
Input Signals:
|
Name of the Signal |
Data Type |
Range |
|
Input_Voltage |
uint8 |
0 - 255 |
|
Input_Switch |
boolean |
0 – 1 |
|
Enable_Display |
uint8 |
0 - 255 |
Output Signal:
|
Name of the Signal |
Data Type |
Range |
|
Output_Display |
uint8 |
0 - 255 |
Calibration Signals:
|
Name of the Signal |
Data Type |
Range |
Initial Value |
|
VOLTAGE_MINIMUM_RANGE |
uint8 |
0 – 255 |
30 |
|
VOLTAGE_MAXIMUM_RANGE |
uint8 |
0 – 255 |
50 |
|
OFF_MODE |
uint8 |
0 – 255 |
2 |
|
ON_MODE |
uint8 |
0 – 255 |
1 |
|
STANDBY_MODE |
uint8 |
0 – 255 |
3 |
|
INTERRUPT_1 |
boolean |
0 – 1 |
1 |
|
INTERRUPT_2 |
boolean |
0 - 1 |
1 |
|
NO_DISPLAY |
uint8 |
0 – 255 |
0 |
Local Signal:
|
Name of the Signal |
Data Type |
Range |
|
Optimum_Voltage |
boolean |
0 - 1 |
Simulink Data Dictionary:
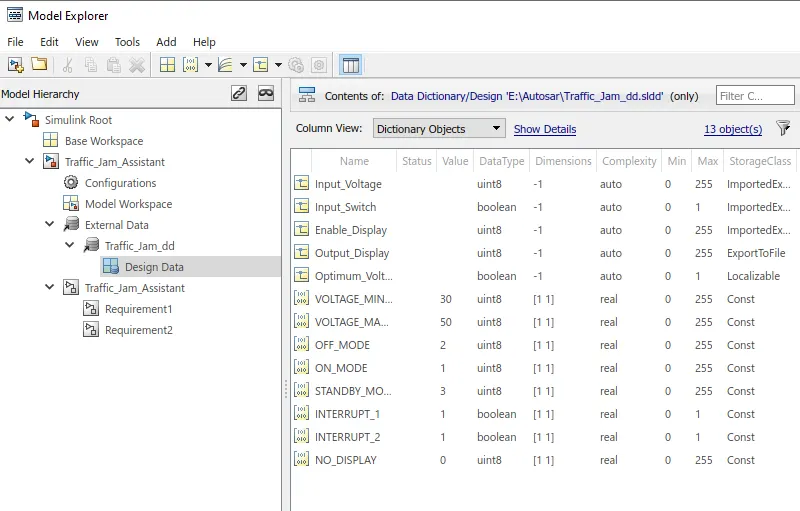
Simulink Model:
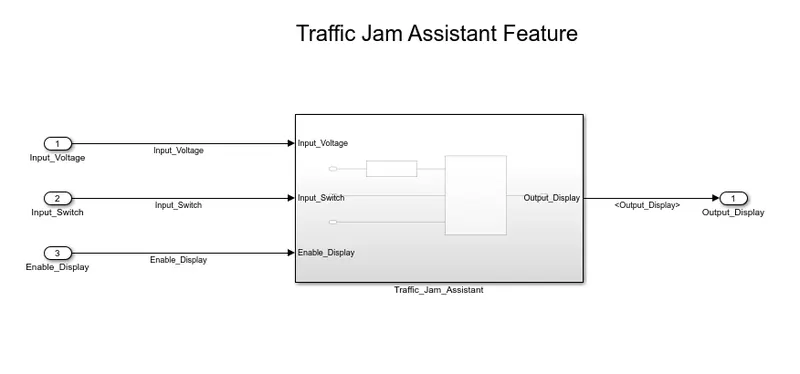
Requirement No 1:
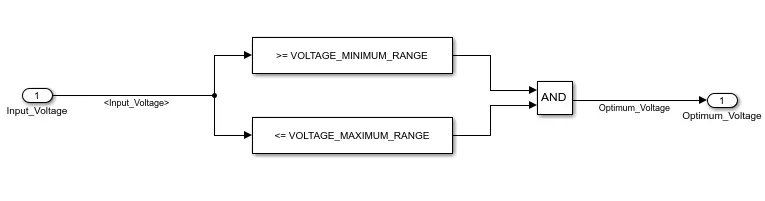
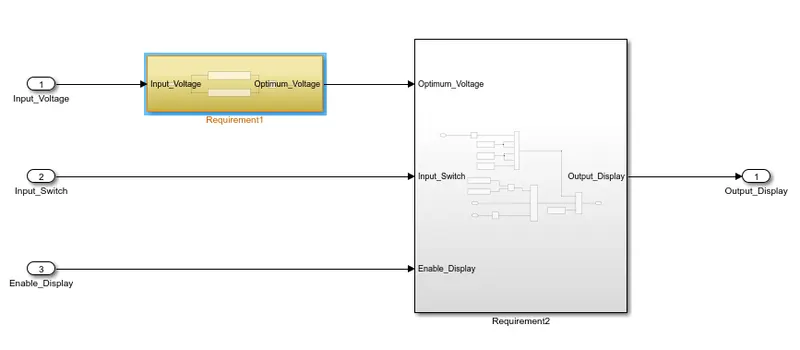
- Input Signal “Input_Voltage” is compared against voltage values “VOLTAGE_MINIMUM_RANGE” & “VOLTAGE_MAXIMUM_RANGE”.
- Incoming input signal “Input_Voltage” must be greater than – equal to “VOLTAGE_MINIMUM_RANGE” and less than – equal to “VOLTAGE_MAXIMUM_RANGE”.
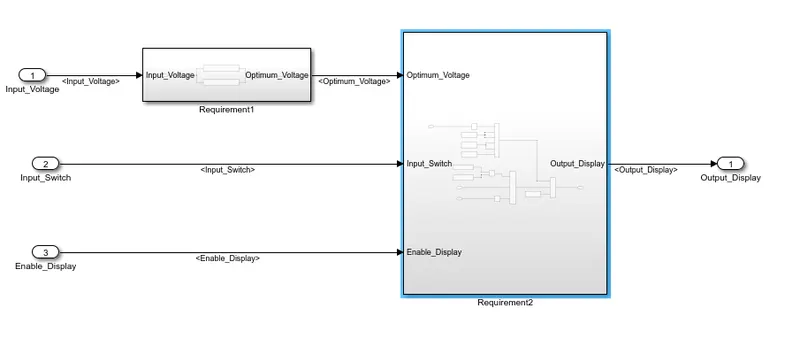
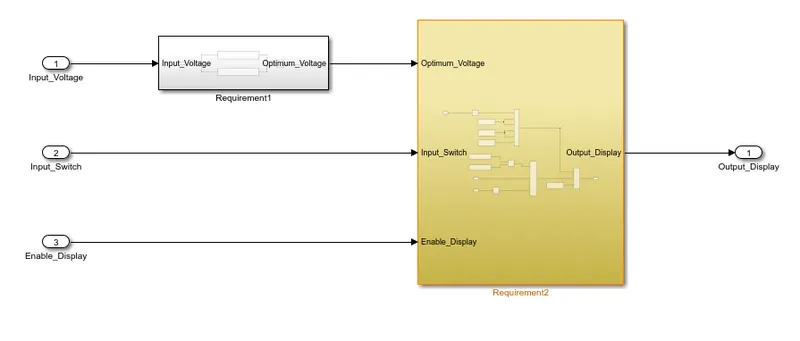
- Output signal from here is “Optimum_Voltage” which will be one of the inputs to the subsystem “DisplayUnit”.
Requirement No 2 (DisplayUnit Subsystem):
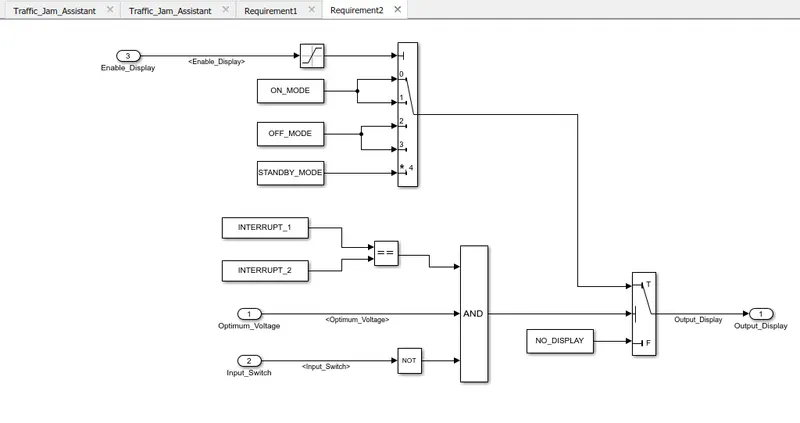
- Input Signals are “Optimum_Voltage”, “Input_Switch”,“Enable_Display”. Signal “Enable_Display” must be saturated between the range 0 – 7. Output signal from the subsystem is “Output_Display”.
- Input Signal “Enable_Display” is compared against pre – defined set of values in a multiport switch. Total data ports in the multiport switch is 5.
- Multiport switch inputs 1 & 2 is connected to calibration signal “ON_MODE”, Multiport switch inputs 3 & 4 is connected to calibration signal “OFF_MODE” while Multiport switch input 5 is connected to calibration signal “STANDBY_MODE”.
- The output from Multiport switch is connected to the first input port of the Switch block. The third input port of the Switch block is connected to the calibration signal “NO_DISPLAY”.
- Meanwhile NOT value of input signal “Input_Switch” is compared in an AND gate against input signal “Optimum_Voltage” and the output from comparing if calibration signals “INTERRUPT_1” & “INTERRUPT_2” are equal. The output of the AND gate is the second input of the switch block.
- The output from the switch block is “Output_Display”.
Requirement Tagging:
Model Advisor Report:
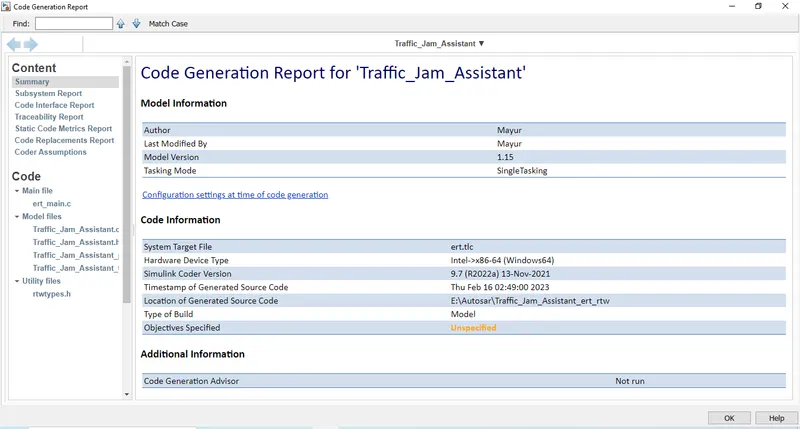
Code Generation Report:
Conclusion: "Traffic Jam Assistant Feature" model is successfully implemented.All compliant changes pertaining to MBD, linking the model to SLDD code generation and generation of Model advisor report is done.All the related documents C Files, SLDD files Model Advisor Report are attached.