Project 1 (Mini Project on Vehicle Direction Detection
Mini Project - Vehicle Direction Determination
Requirement - 1:
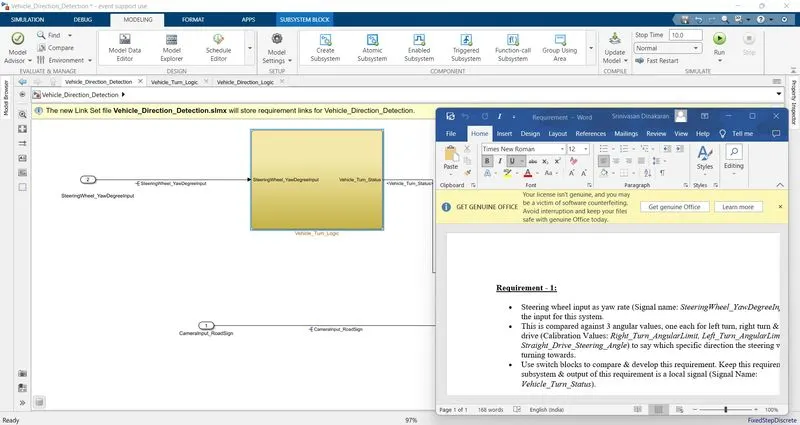
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
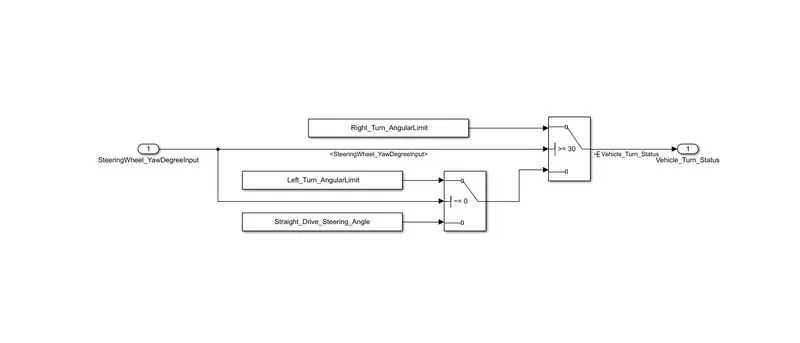
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
-
Requirement – 2:
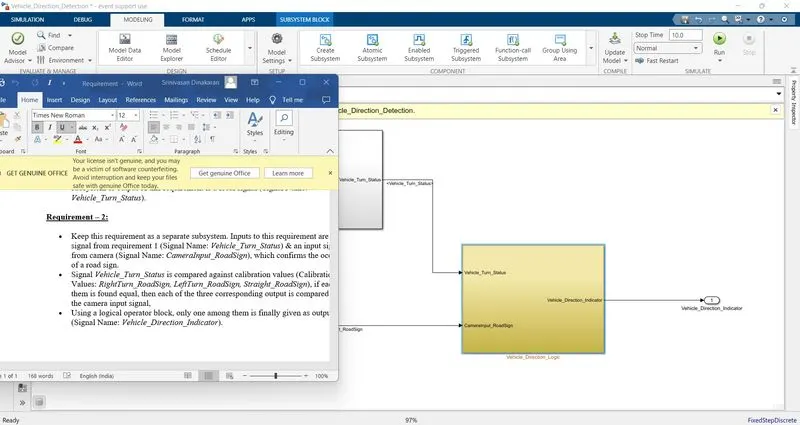
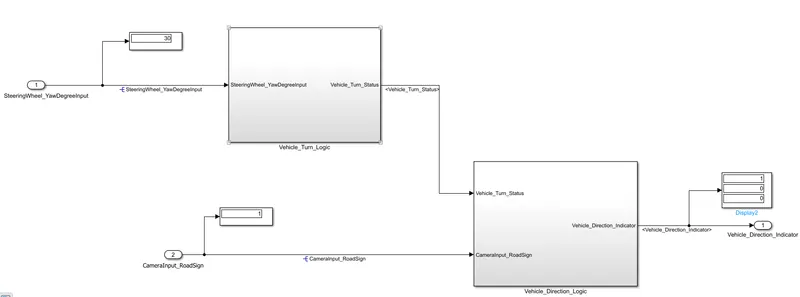
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
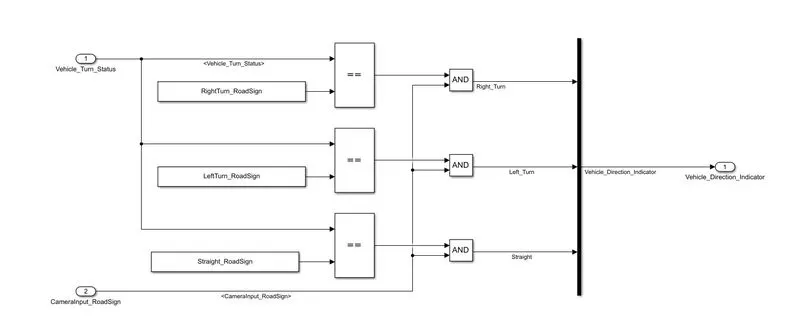
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator).
Aim:
Identifying the direction of the vehicle is one of the important & diverse features in Autonomous driving & Advanced Driver Assistance Features. This particular sub-feature of identifying the direction of vehicle is basically identifying the direction the vehicle is taking based on the camera input.
Steps:
1. Requirement analysis
2. Developing model
3. Creation of Data Dictionary
4. Resolving signals
5. Requirement tagging
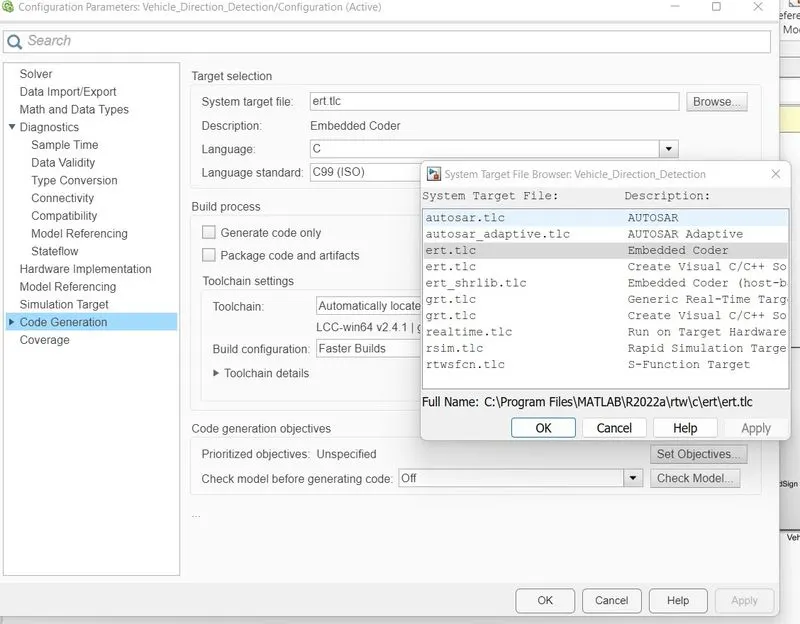
6. configuration parameter update
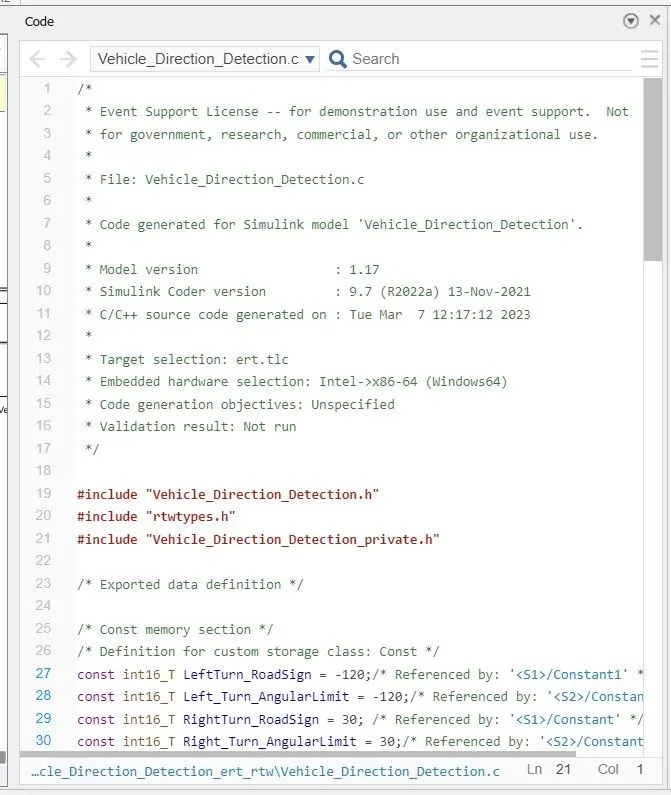
7. Code generation
MODEL:
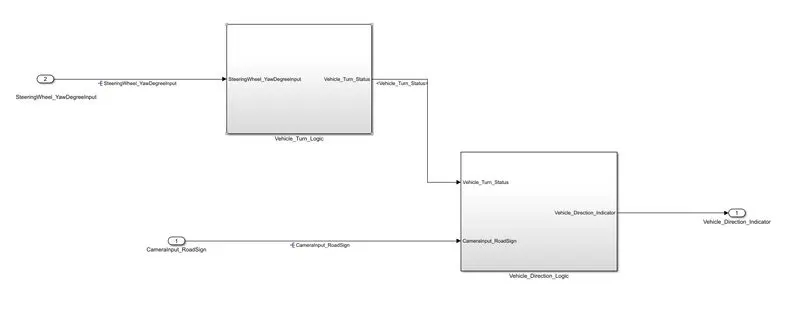
Requirement - 1:
The steering wheel yawangle input is comapre with the three different values, namely Right turn, left turn and Straight drive angular limit values, using the switch block. so, that we know the status of the vehicle turn.
Requirement – 2:
The Vehicle turn status compared with the three different values, right turn left turn and straight road sign. any one among three signal will get matched. then each of the signal is compared with the camera input
SLDD CREATION:
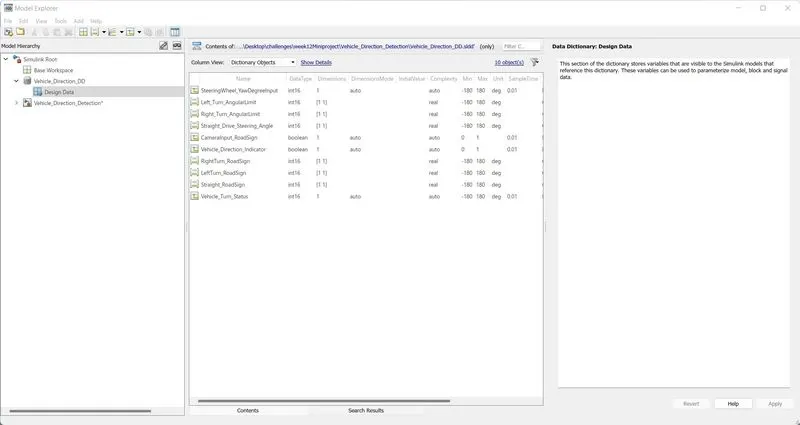
SIGNAL RESOLVING:
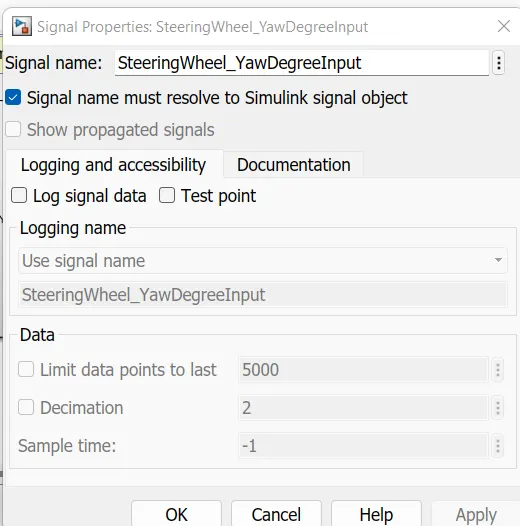
Requirement tagging:
the reqirement document should be saved in the corresponding folder.
select the text which has to be tagged with the subsystem. place the cursor on the subsystem and right click, click on requirements and select link with word. the text tagged with the subsystem.
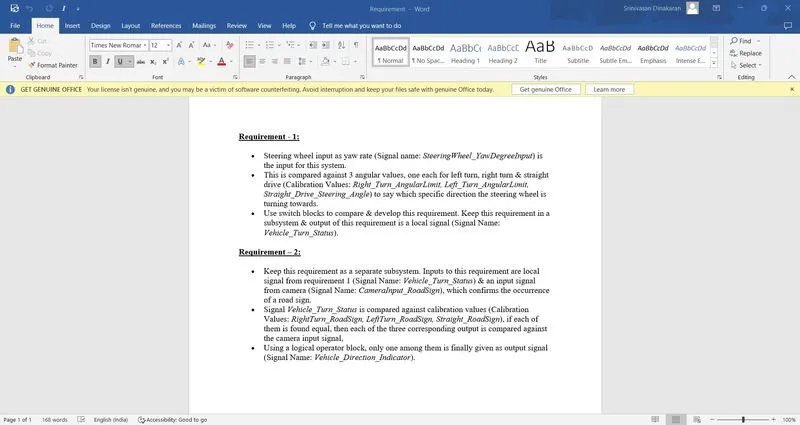
once it get tagged the colour of the subsystem block get changed.
requirement tagging for vehicle_turn_logic subsystem:
requirement tagging for vehicle_Direction_indicator:
CONFIGURATION PARAMETERS UPDATE:
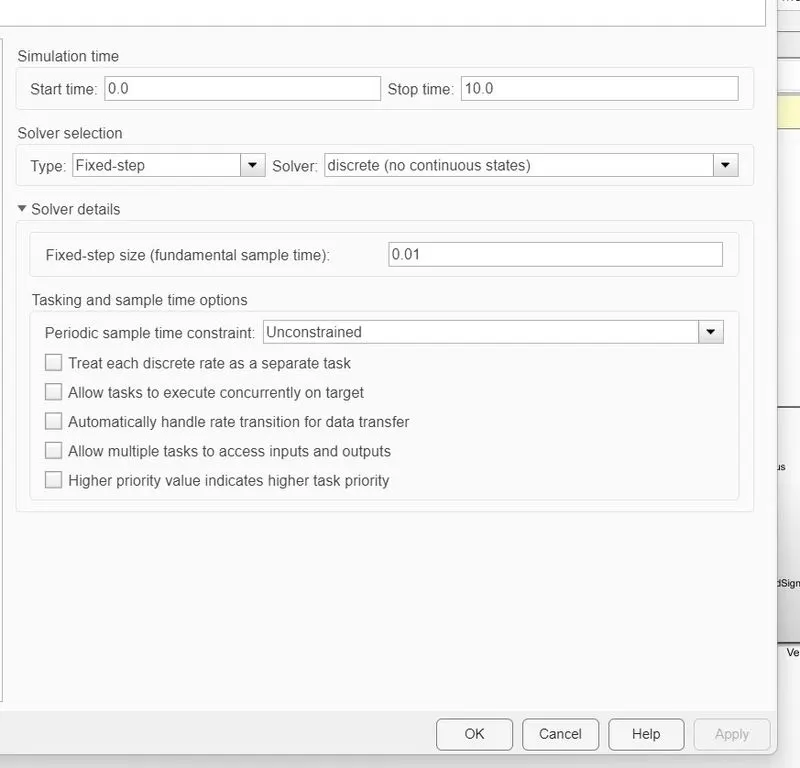
SOLVER:
CODE GENERATION:
Code:
RESULT:
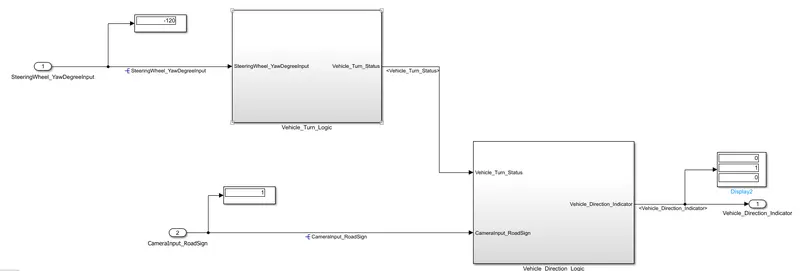
RIGHT TURN:
LEFT TURN:
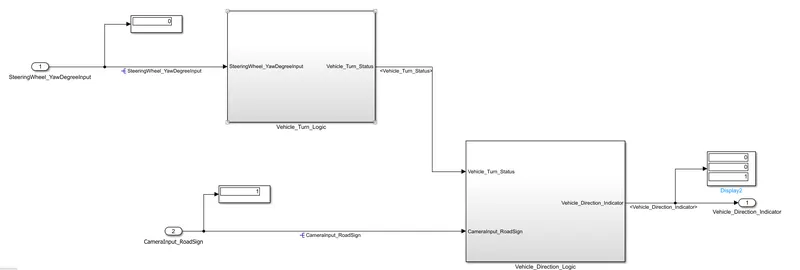
STRAIGHT:
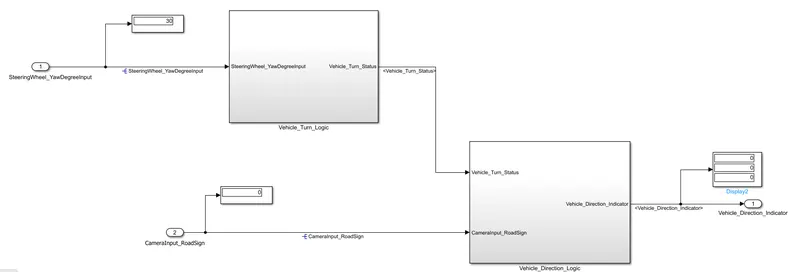
if there is no camera input road sign
conclusion:
Based on the Steering wheel yaw angle input and camera input, the vehicle direction is determined. when the road sign is captured by camera, it gives boolean value 1, in accordance with this value and steering wheel yawrate input, we can determine, the vehicle turns in which direction.