Project 1 (Mini Project on Vehicle Direction Detection
AIM:
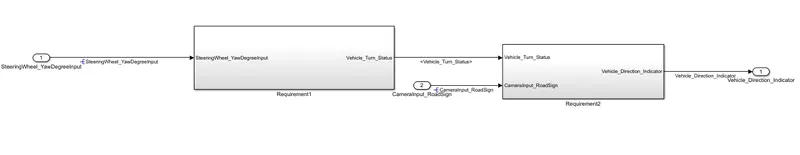
The aim of this project is to identify the direction of the vehicle. Camera input is fed as input and direction of the vehicle is identified.
DESCRIPTION:
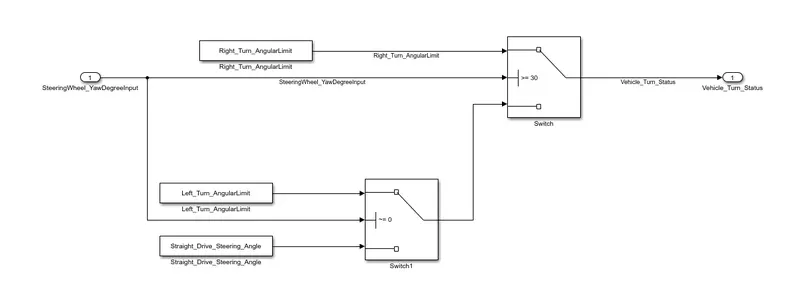
The input signal to the requirement1 is steeringWheel_YawDegreeInput.
Whenever the input value is equal to or greater than 30, the vehicle steering is towards right. If it is less than 30, the false condition executes.
Whenever the input value is not equal to 0, the vehicle steering is towards left. If it is equal to 0, the false condition executes which is the vehicle steering is driving straight. The output signal is Vehicle_Turn_Status.
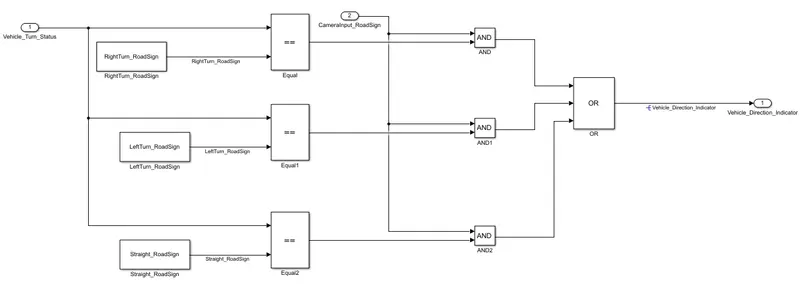
The logic for requirement2 is to compare the “ Vehicle_Turn_Status1” with “RoadSign” and an input from the camera to get thr vehicle direction indication.
After comparison with the “Vehicle_Turn_Status” if each of them is found equal, then each of the three corresponding output is compared against the camera input signal. Using AND operator, the output signal is chosen from the three blocks and the name is Vehicle_Direction_Indicator.
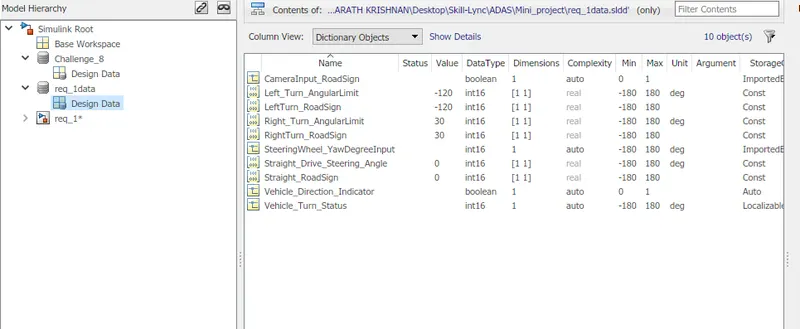
SLDD is created and by loading the input, output and calibration values are defined.
SIMULINK MODEL:
RESULT:
The simulink model is created and successfully executed. When the input value is greater than 30, steering is towards right side, when the value is 0 the vehicle is driving straight and when it is other than 0, it is driving left.