Project 1 (Mini Project on Vehicle Direction Detection
DETECTION OF VEHICLE DIRECTION
OBJECTIVE:
To design a MATLAB SIMULINK model for detecting the VEHICLE DIRECTION.
SIGNALS USED:
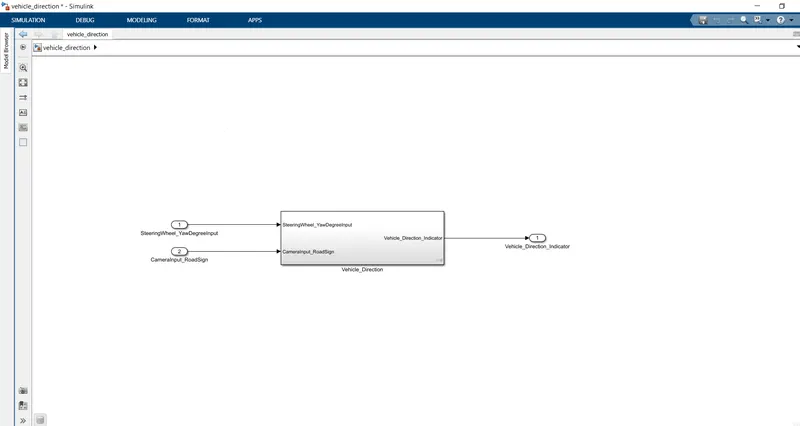
SteeringWheel_YawDegree INPUT to REQUIREMENT 1
CameraInput_RoadSign INPUT TO REQUIREMENT 2
Vehicle_Turn_Status Localaizable which acts as output to requirement 1 and input to requirement 2
Right_Turn_AngularLimit
Left_Turn_AngularLimit
Straight_Drive_Steering_Angle
RightTurn_RoadSign
LeftTurn_RoadSign
Straight_RoadSign The above six are calibration signals which has a value.
Vehicle_Direction_Indicator Final output
SLDD was created and the above signals are fed into DATA LIBRARY with Storage class as IMPORTEDEXTERN for INPUT, EXPORT TO FILE for OUTPUT, LOCALAIZABLE for LOCAL and CONSTANTS for Calibration values and for all signals sampling time is given as 0.01secs.
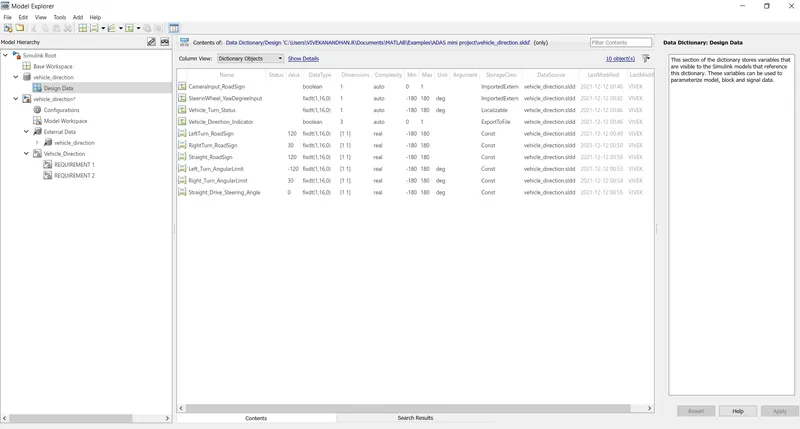
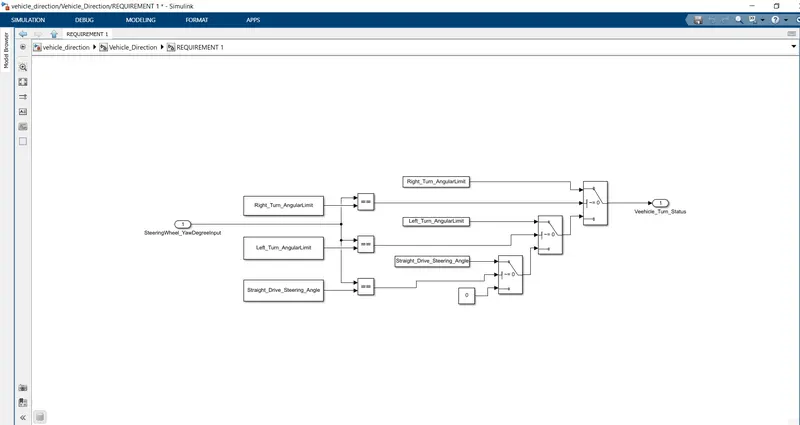
REQUIREMENT 1:
Steering wheel degree is taken as input and given to relational operator EQUAL TO and compared with the Calibration value of TURN ANGULAR LIMIT, and given to SWITCH, the corresponding operator activated the switch and switch has either options of RIGHT or LEFT, LEFT or STRAIGHT and STRAIGHT or ZERO and the output value will be VEHICLE TURN STATUS which will be used as inout to REQUIREMENT. The calibrated values are assigned in SLDD.
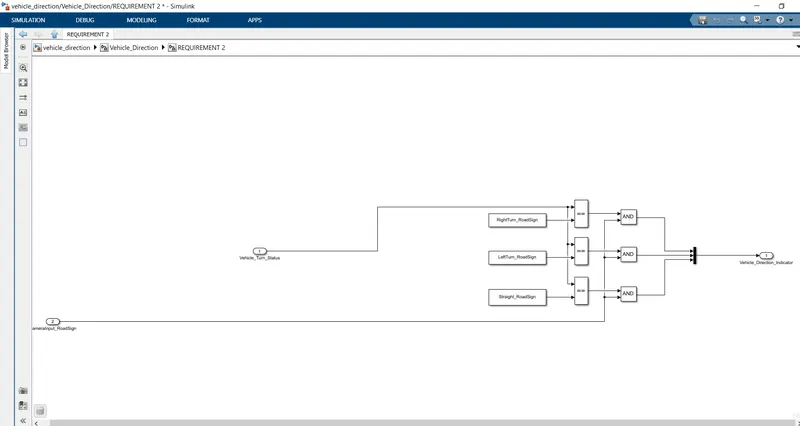
REQUIREMENT 2:
For this Vehicle yurn status and Camera road signal are taken as inputs. First the vehicle turn status is compared using relational operator EQUAL TO with Road Sign stored as calibrated values, if both are equal then it gets to AND logical operator where it is compared to CAMERA INPUT ROAD SIGN, the output of the LOGICAL OPERATOR will be ONE if both values are 1 if not it will 0 which is false.
EXAMPLE:
If steering wheel input is 30 then it gets compared to Right angular which is 0, so using switch it gives OUT for vehicle turn status as 30, which then is given as input to Road sign in which RIGHT TURN ROAD SIGN has a stored value of 30, as both are equal it gives 1 to AND gate and if CAMERA INOUT ROAD SIGN is also 1 the vehicle turns to right is detected.
MIL is created for this model with INPUT as SIGNAL BUILDER, So we can vary the Steering and Camera road sign inputs as per our convenience and see the different outputs. The screen Snaps are attached.
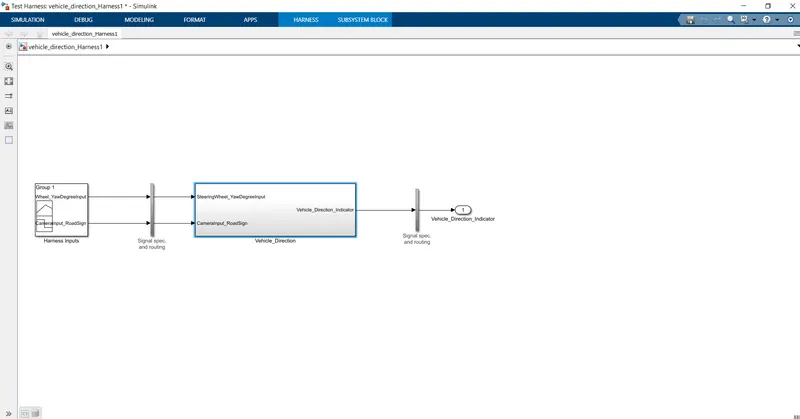
.slx and .sldd files are attached for reference.