Planetary Gear
AIM :- Design a planetary gear with all given constrain and make a motion analysis.
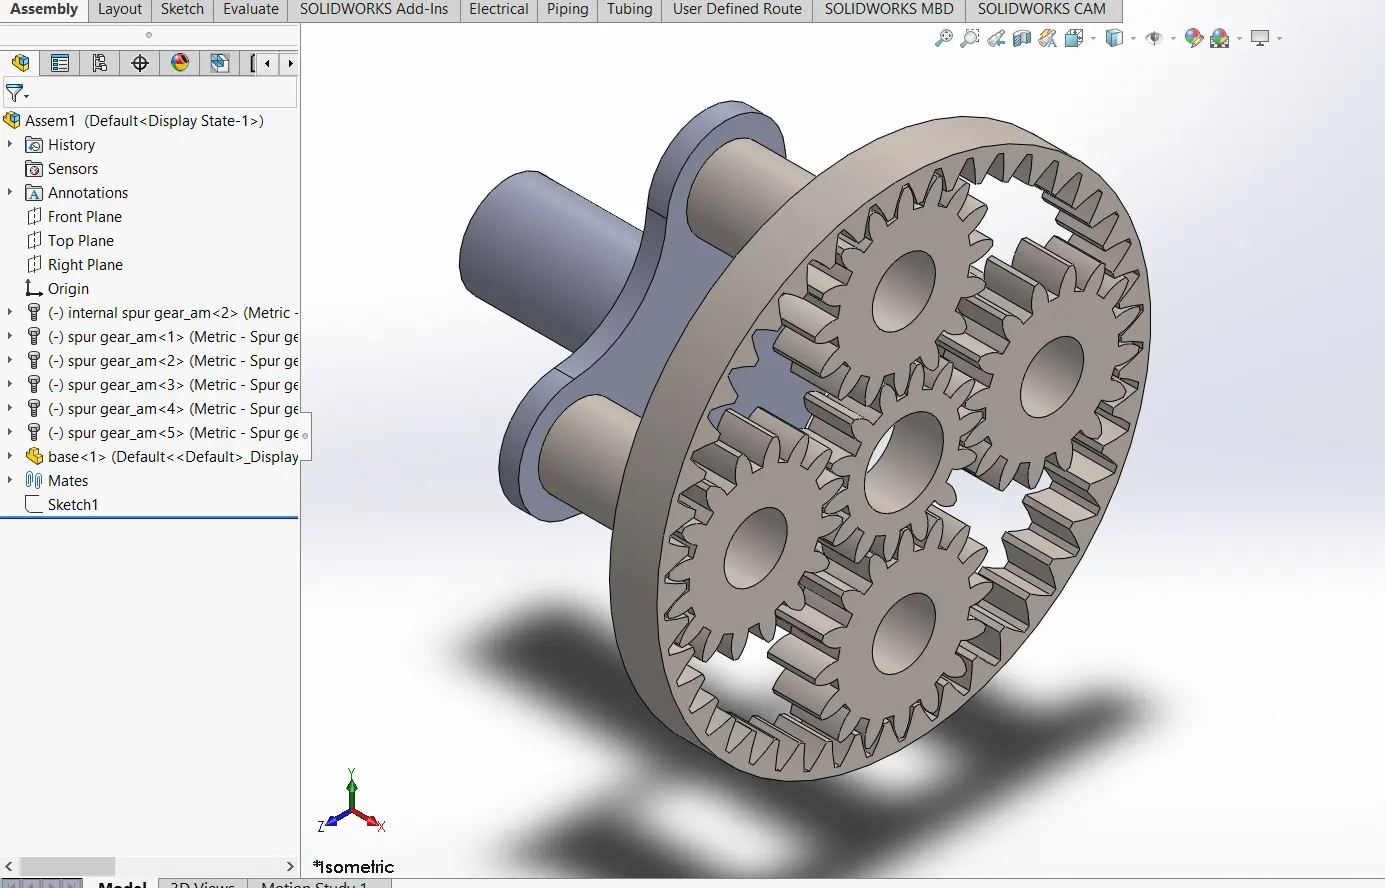
PLANETARY GEAR: In this project, the main objective is to model a planetary gear which consists of a ring gear, a sun gear, four planetary gear and a carrier. After assembling the all gear and carrier we make a motion analysis at 200rpm for all parameters. Then plot the angular velocity graph for carrier and ring gear.
An epicyclic gear train (also known as planetary gear) consists of two gear mounted so that the center of one gear revolves around center of the other. A carrier connects the centers of two gears and rotates to carry one gears, called the planet gear or planet pinion, around the other, called the sun gear or sun wheel. The planet and sun gears meash so that there pitch circles roll without slip. A point on the pitch circle of the planet gear traces an epicycloid curv. In this simplified case, the sun gear is fixed and the planetary gear role around the sun gear.
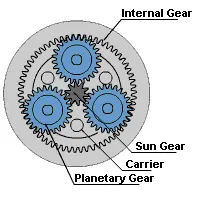
An epicyclic gear train can be assembled so the planet gear role on the inside of the pitch circle of a fixed, outer gear ring, or ring gear, sometimes called an angular gear. In this case, the curve traced by a point on the pitch circle of a planet is a hypocycloid.
The combination of epicycle gear trains with a planet engaging both a sun gear and a ring gear is called a planetary gear train. In this case, the ring gear is usually fixed and the sun gear is driven.
INPUT FOR DESIGN OF GEAR :- Use the following inputs for designing the planetary gear.
Ring Gear
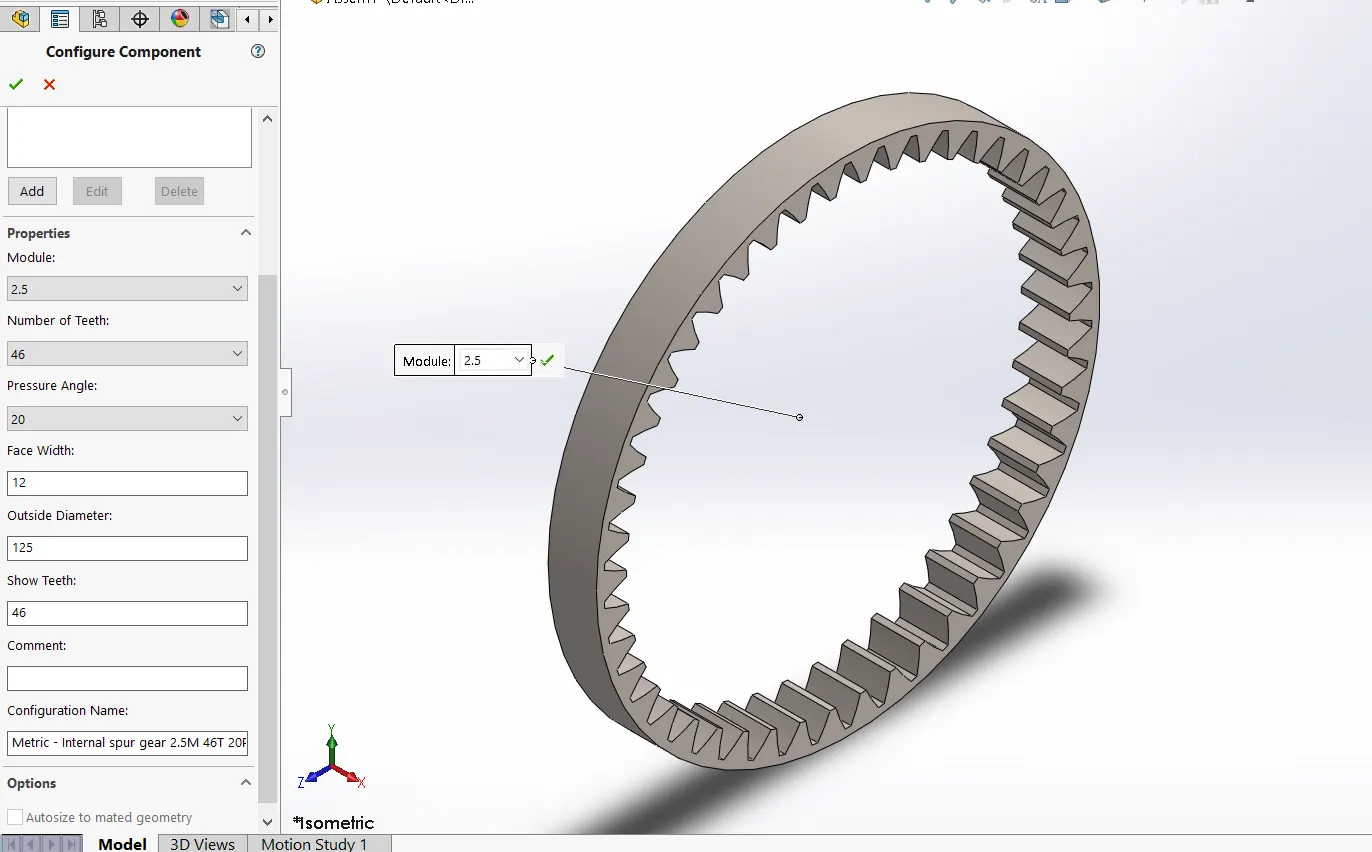
Module = 2.5 (You must use the metric system in design modeler)
Number of teeth = 46
Sun Gear
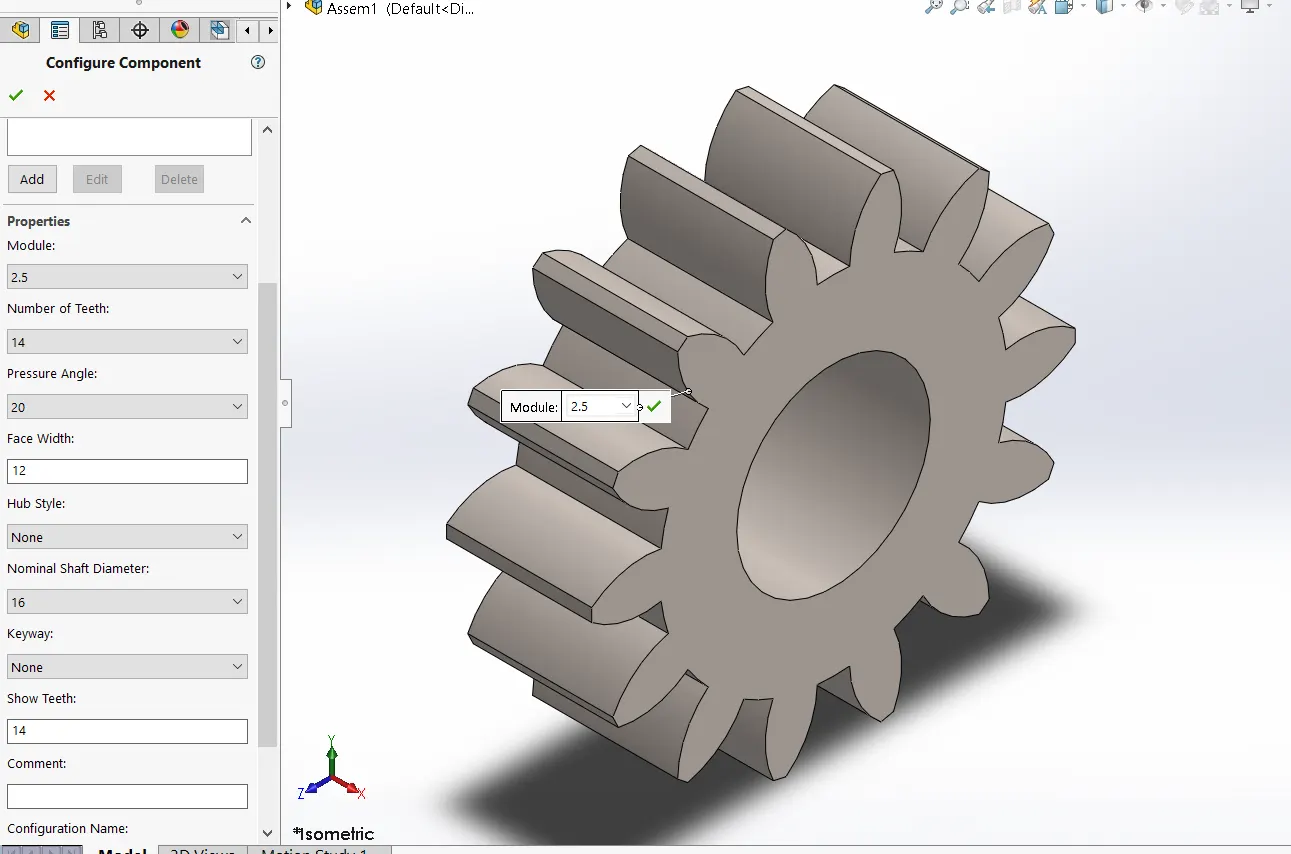
Number of teeth = 14
Input Speed of the Gear = 200 rpm.
Number of planet gears = 4
To calculate the pitch circle diameter and the number of teeth for the planet gear
Diameter of the Planet gear:
Radius of Ring gear=Diameter of the Planet gear+radius of Sun gear
Rr = Dp+RsTherfore,
Do = Rr - Rs
Do = 115/2 - 35/2 = 40mm
D = 40mm
Number of teeths of planet gear:
Pitch Diameter, D=m*T where m=module
T = Number of teeth therefore,
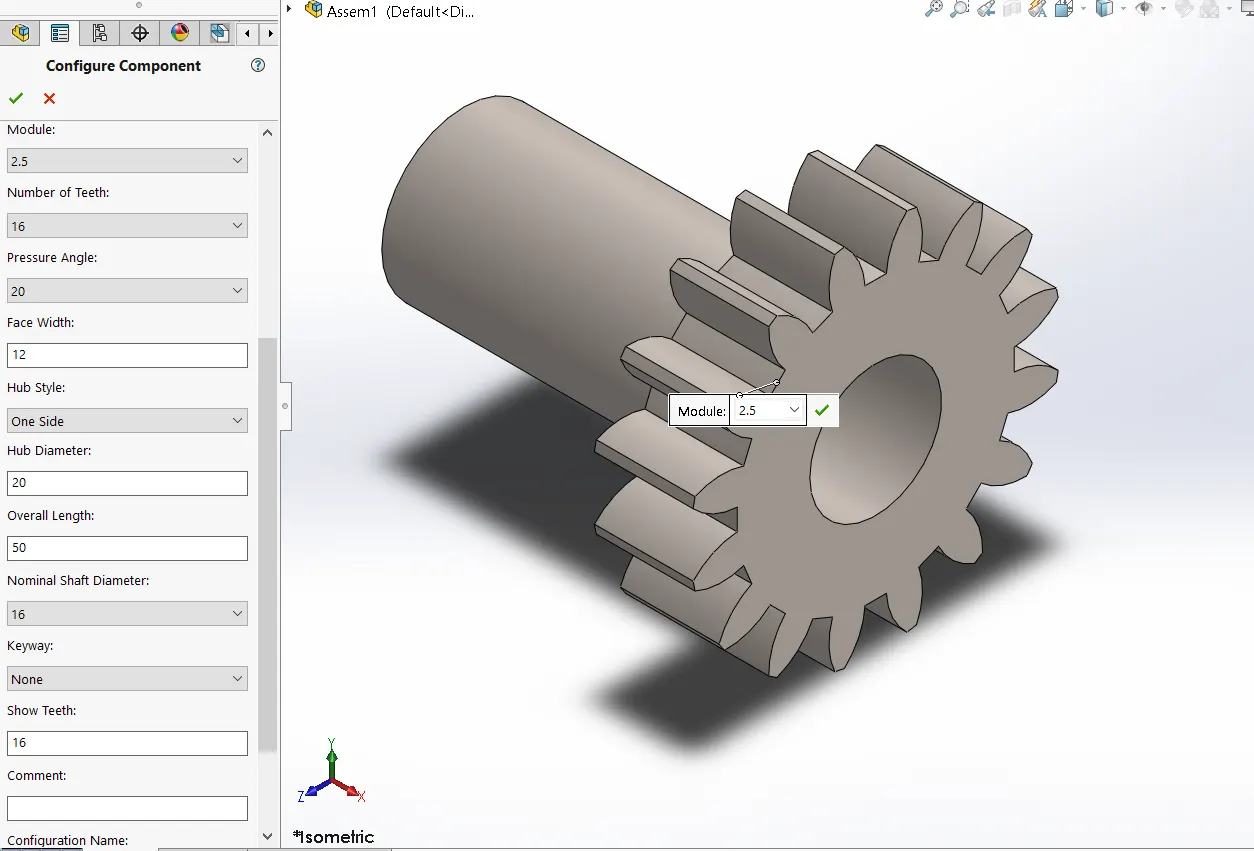
T= D/m = 40/2.5 = 16
T= 16 teeths
| Sl.No | Type of Gear | Module | Pitch Diameter (mm) | No. to Teeth |
| 1 | Sun Gear | 2.5 | 35 | 14 |
| 2 | Ring Gear | 2.5 | 115 | 46 |
| 3 | Planet Gear | 2.5 | 40 | 16 |
Creating the geometry and the assembly:
For creating gear from Toolbox - go to design library - Toolbox - ANSI metric- Power transmission - gear
For sun and planetary gear choose Spur Gear
For ring gear to choose internal Spur Gear
Pressure angel = 20
Face Width = 20mm
1. RING GEAR (Internal Spur Gear)
2. SUN GEAR
3. PLANET GEAR
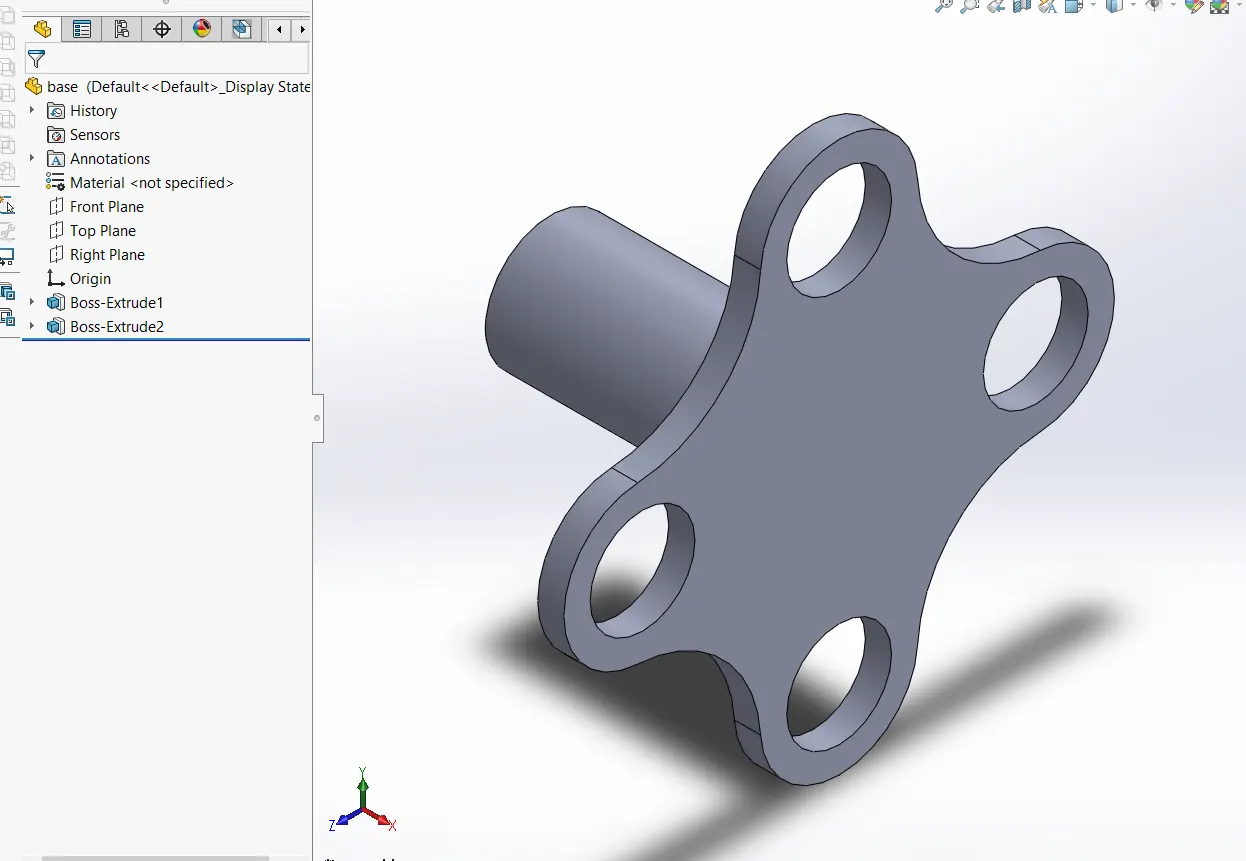
4. CARRIER MODEL
5. FINAL ASSEMBLY
Motion Analysis
In the motion study make contacts between the followings.
- Carrier and the Planet Gears
- Sun gear and the Planet Gears
- Ring gear and the Planet Gears
The material for each contact is Steel (Dry)
The input speed to the motor in each case is 200 RPM
There are 3 cases,
| Sl.No | Input | Output | Fixed |
| 1 | Sun Gear | Carrier | Ring Gear |
| 2 | Ring Gear | Carrier | Sun Gear |
| 3 | Sun Gear | Ring Gear | Carrier |
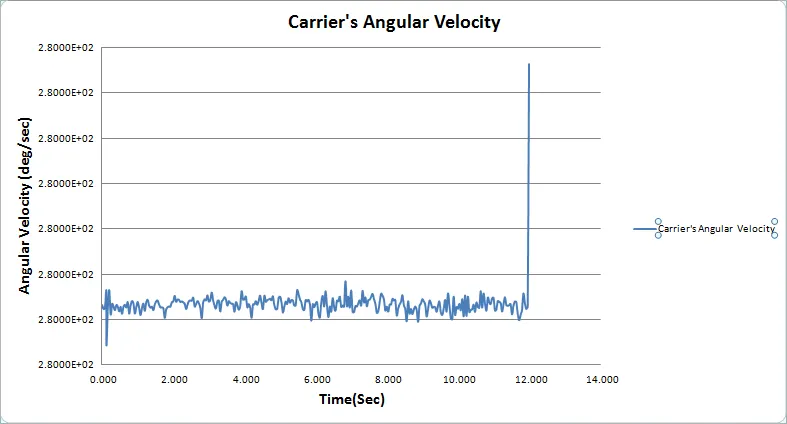
Case 1: Ring gear fixed
Motor - sun gear.
The plot of an angular velocity of the carrier against time.
Case 2: Sun gear fixed.
Motor - Ring gear.
The plot of an angular velocity of the carrier against time.
Angular velocity is lies between 9.2-9.2000E+02 it means angular velocity is constant.
CASE3. Carrier fixed.
Motor - Sun gear.
The plot of an angular velocity of the Ring against time.
RESULT & OBSERVATION :-
1. In first case, when the input is given to the sun gear and output is obtained at the carrier keeping the ring gear fixed, the planet gear not only rotates about their axis but are also forced to roll on the inside of the ring gear along with the carrier as the Ring gear is fixed. The angular velocity obtained for this case is 279.999 deg/sec and varies in a very small fraction.
2. In second case, when the input is given to the ring gear and output is obtained from the carrier keeping the sun gear fixed. The angular velocity achieved is maximum since the internal gear is big and planet gears are small comparatively so when a large gear meshes with a small gear the velocity achieved from the small gear is high because the velocity ratio is high. The angular velocity obtained for this case is 920.00005 deg/sec and varies in a very small fraction.
3. In third case, the carrier is fixed and output is to be obtained from the ring gear with the input given to Sun gear, all the gears rotate about their axis. The planet gears rotate only about their axis and transmit motion from sun to the ring and since the ring gear is big in diameter the angular velocity achieved is less. The deviations that are visible in the graphs show that there are points where sliding is occurring between the gears. For making the graph more smoother we can use precise contact. The angular velocity obtained for this case is around 365.217 deg/sec and varies in a very small fraction