Simulink Model - Electric Rickshaw modelling
Objective:
Create a detailed MATLAB model of an electric rickshaw (three-wheel passenger vehicle) as per details below:
Rear wheels driven by PM brushed type motor
Assume efficiency points of motor controller and motor
Make an excel sheet of all input and assumed data
Results: For any three standard driving cycles show energy consumption, temperature rise of motor and controller for 100 km constant speed driving at 45 kmph.
Introduction:
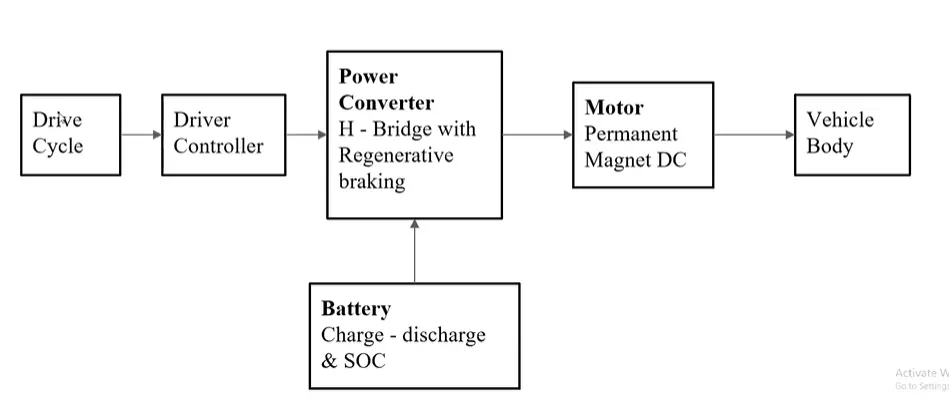
The battery, drive cycle, controller, DC motor, vehicle chassis, and transmission system are the key components of the Electric Rickshaw. FTP75, WOT, and Excel are the input data for the drive loop, which is how a person drives his actual car (Manually Prepared in Excel sheet) Drive cycles are used to create the performance of how the engineered vehicle responds to the drive loop. The main goal is to determine the driver's speed, measure the temperature of the motor and controller, calculate the state of charge (SOC), and calculate the distance travelled by the car. For all three Drive cycles, there is a SOC block that estimates the state of charge of a battery, and distance is measured using speed and time parameters.
Simulink Model:
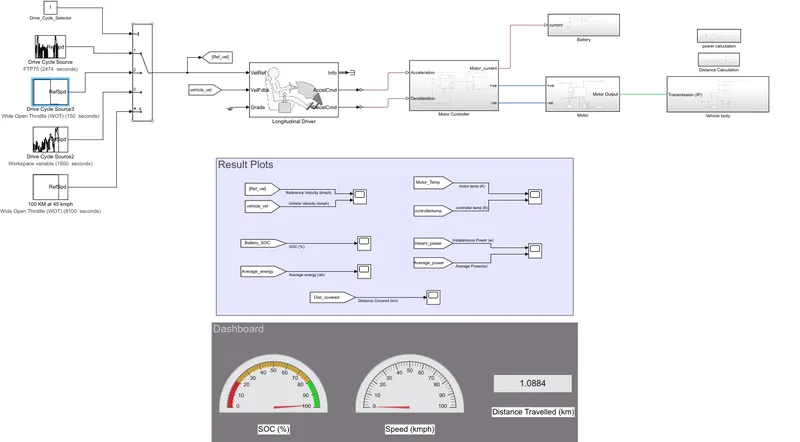
Drive Cycles:
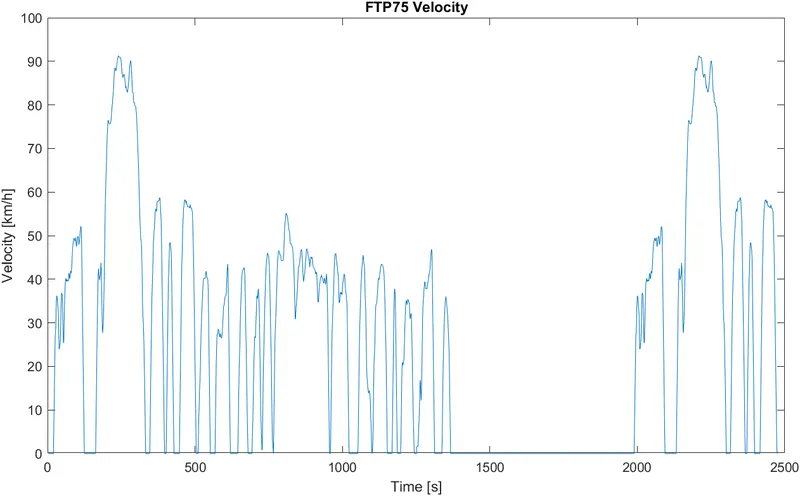
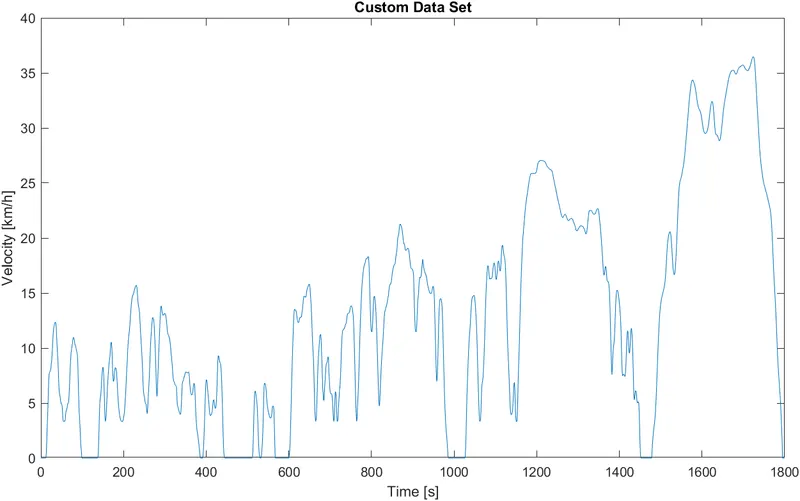
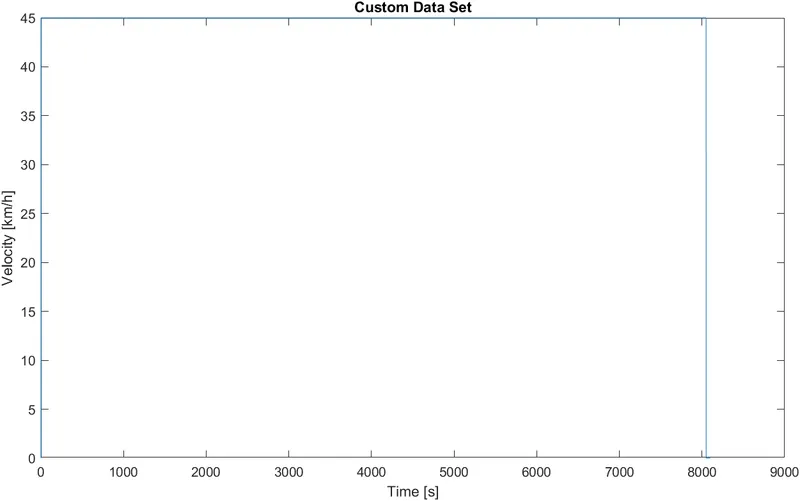
For this model 4 drive cycles are considred, FTP75,WOT, Custom Drive Cycle, WOT to record the tempurature of motor and motor controller for a 100km distance with 45kmph as velocity.
FTP75:
WOT:
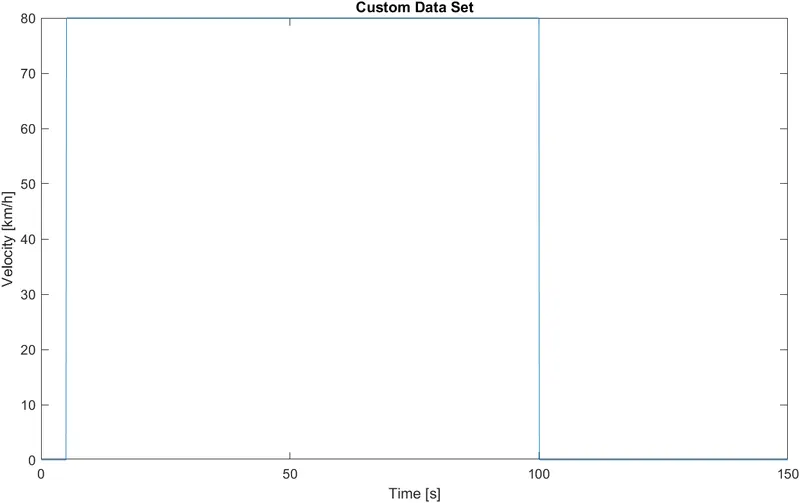
Custom Drive Cycle:
WOT for tempurature readings:
All 4 Drive cycles are controlled by the controller provided above by constant through Multi-port switch.
Driver Controller:
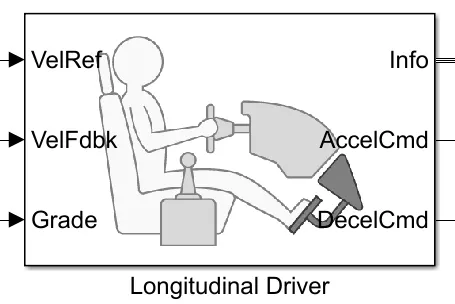
A parametric longitudinal speed tracking controller for generating normalized acceleration and braking commands based on reference and feedback velocities.
VelRef is given by the drive cycle data and VelFdbk is given by the output of the motor. These two will get compare and the acceleration or deceleration output will be given to the motor controller. Accelcmd is given the PWM generator block and deccelcmd is given to the regenerative port of the h-bridge which uses to generate regenerative braking. Info is used to get any other data from a longitudinal driver block. The grade is to give the input of gradeability to the driver block. This block helps to generate regerate the driver's conditions of the vehicle using the driver cycle block.
Default parameters are used for the controller
Motor Controller subsystem:
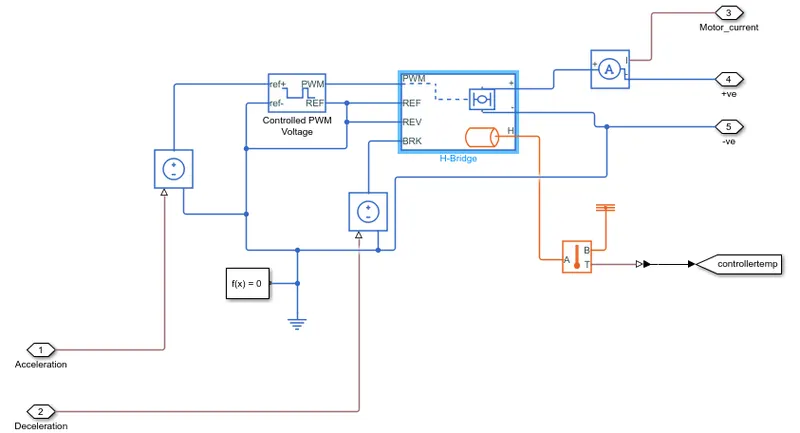
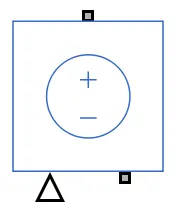
- Controlled Voltage Source:
-
The Controlled Voltage Source block represents an ideal voltage source that is powerful enough to maintain the specified voltage at its output regardless of the current flowing through the source.
-
The output voltage is V = Vs, where Vs is the numerical value presented at the physical signal port.
-
- Controlled PWM Voltage:
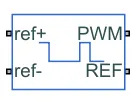
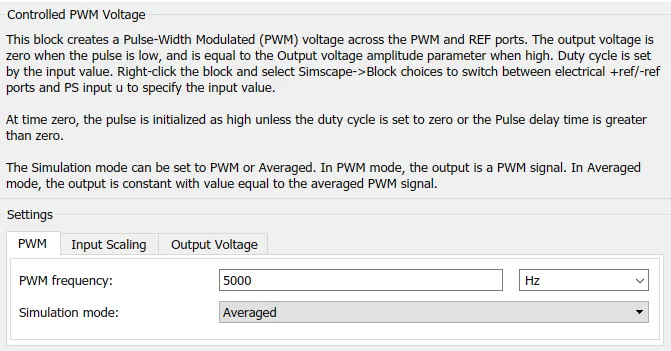
- The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source. The block has two modeling variants,
-
Electrical input ports — The block calculates the duty cycle based on the reference voltage across its ref+ and ref- ports. This modeling variant is the default.
-
PS input — Specify the duty cycle value directly by using an input physical signal port.
-
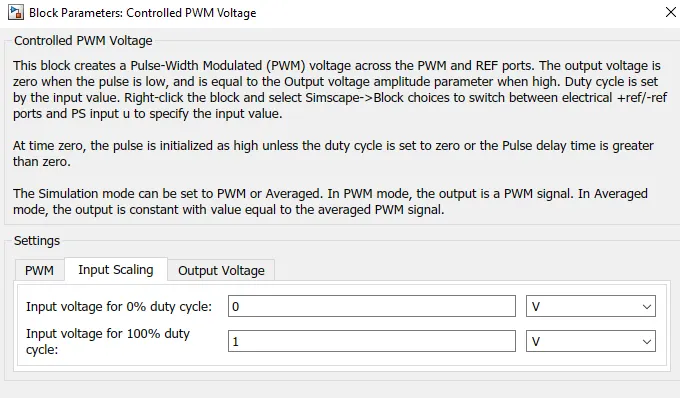
For the Electrical input ports variant of the block, the demanded duty cycle is
`100∗ {V_{ ref} −V_{min}}/ {V _{max} −V_{min}} %`
where:
-
Vref is the reference voltage across the ref+ and ref- ports.
-
Vmin is the minimum reference voltage.
-
Vmax is the maximum reference voltage.
-
- H-Bridge:
-
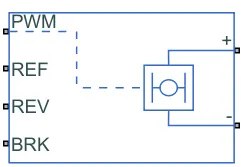
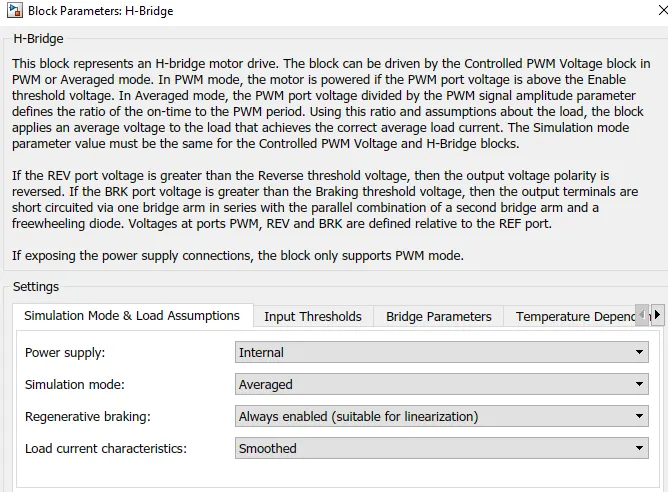
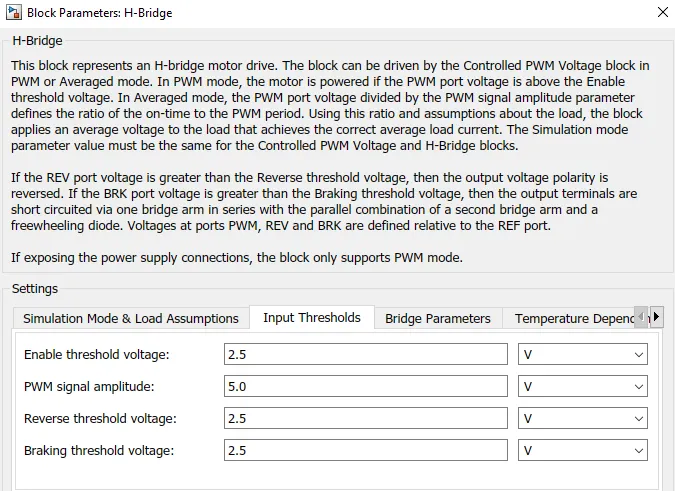
This block is used to change the polarity of the voltage applied across the DC motor so as to run the motor in forward and reverse direction as per the input command.
-
- Current Sensor:
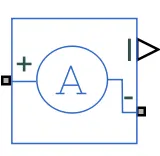
- This block is used to measure the flow of current through a circuit
- End of Subsystem
- Voltage Sensor:
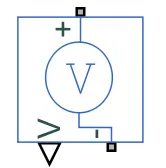
- This block is used to measure voltage across in a circuit.
- Temperature Sensor:

- This block measures the temperature in a thermal network.
Motor Subsystem:
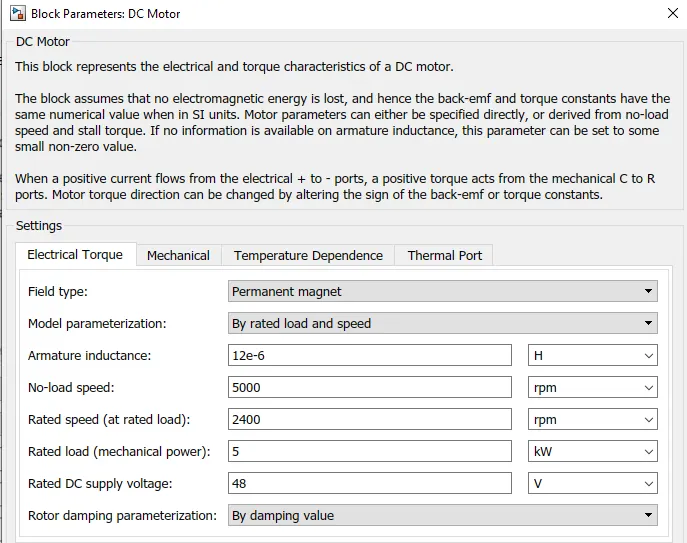
- DC motor:
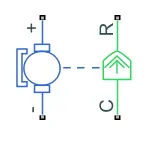
- To convert the electrical energy to mechanical energy we use motors. In this electric vehicle model we have used DC motor. This motor can act as a generator also in case of regenerative braking.
Battery Subsystem:
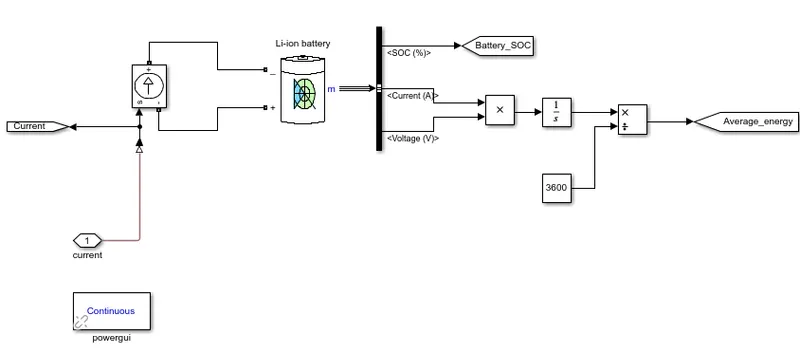
- Controlled Current Source:
- The Controlled Current Source block converts the Simulink input signal into an equivalent current source. The generated current is driven by the input signal of the block.
- Li-ion battery:
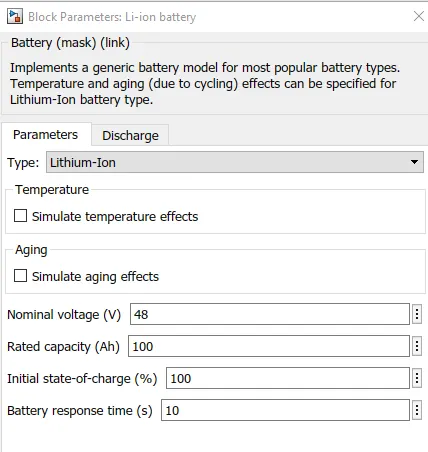
- The Battery block implements a generic dynamic model that represents most popular types of rechargeable batteries.
Vehicle Body:
- Fixed Gear:
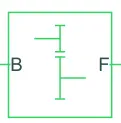
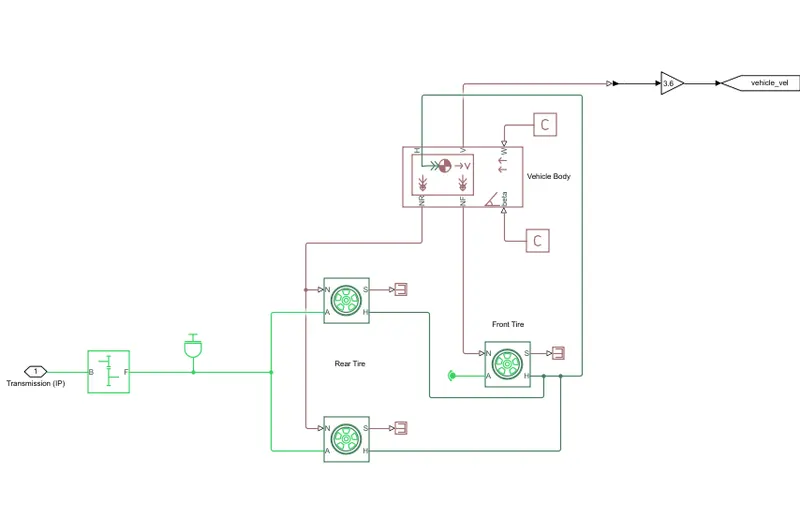
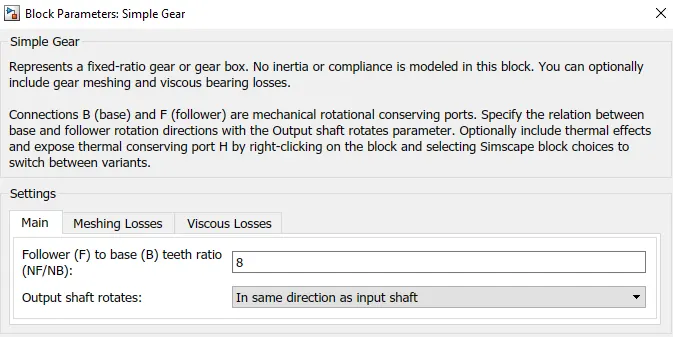
- The Simple Gear block represents a gearbox that constrains the connected driveline axes of the base gear, B, and the follower gear, F, to corotate with a fixed ratio that is specified.
- Inertia:
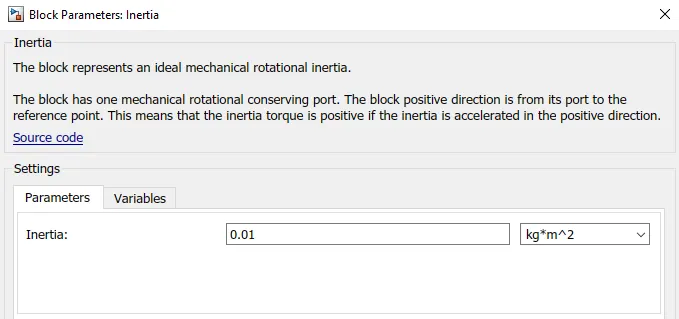
- The Inertia block represents an ideal mechanical rotational inertia.
- Tire (Magic Formula):
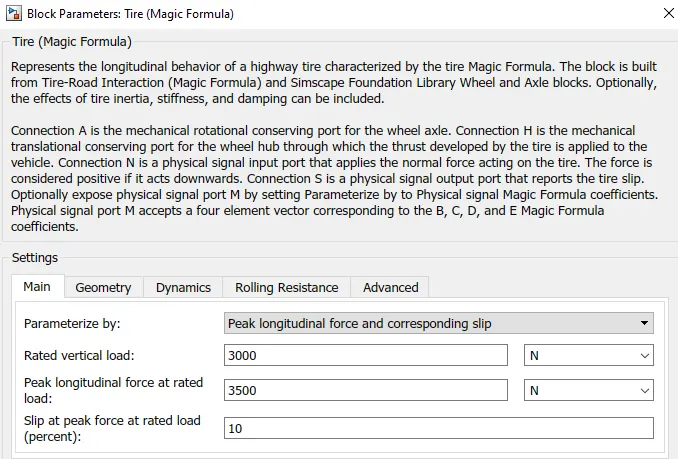
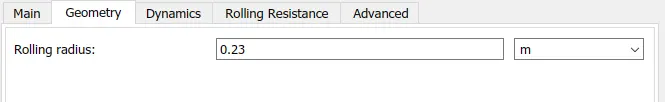
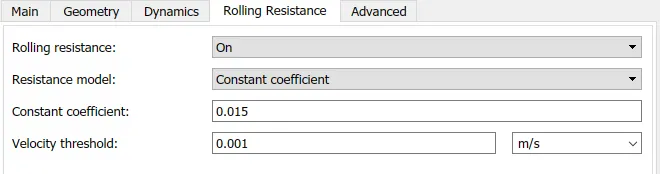
- The Tire (Magic Formula) block models a tire with longitudinal behavior given by the Magic Formula an empirical equation based on four fitting coefficients. The block can model tire dynamics under constant or variable pavement conditions.
- Vehicle Body:
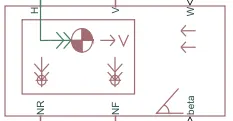
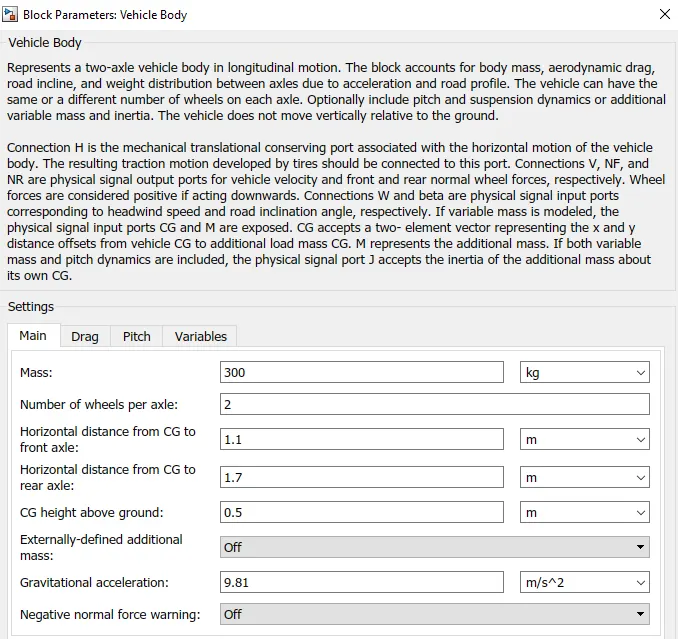
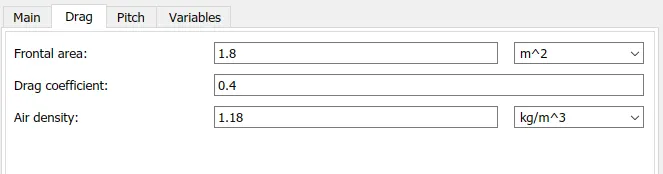
- The Vehicle Body block represents a two-axle vehicle body in longitudinal motion. The vehicle can have the same or a different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size. The vehicle can also have a center of gravity (CG) that is at or below the plane of travel.
- The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. Optionally include pitch and suspension dynamics. The vehicle does not move vertically relative to the ground.
- The block has an option to include an externally-defined mass and an externally-defined inertia. The mass, inertia, and center of gravity of the vehicle body can vary over the course of simulation in response to system changes.
- Distance Calculation:
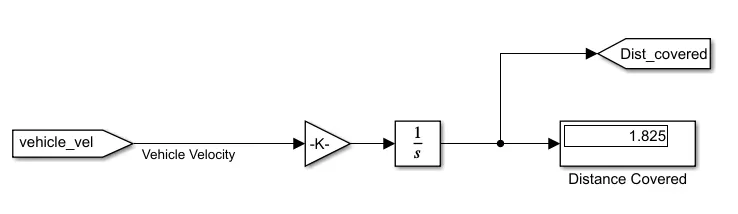
- The Velocity from the vehicle body is taken, converter to km per sec and passed through an integrator block to get distance.
- Power Calculation:
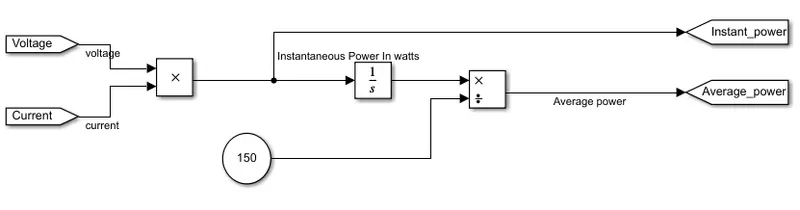
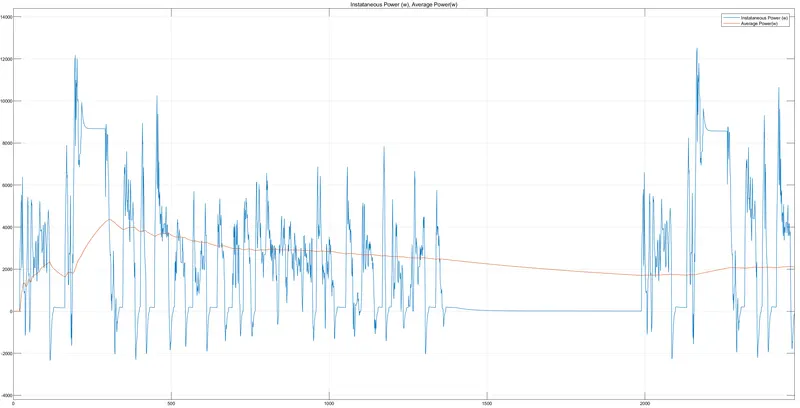
- Voltage and current are taken from the supply to the motor, then they are multiplied together to get instantaneous power, the result is divided by time to get average power.
Result:
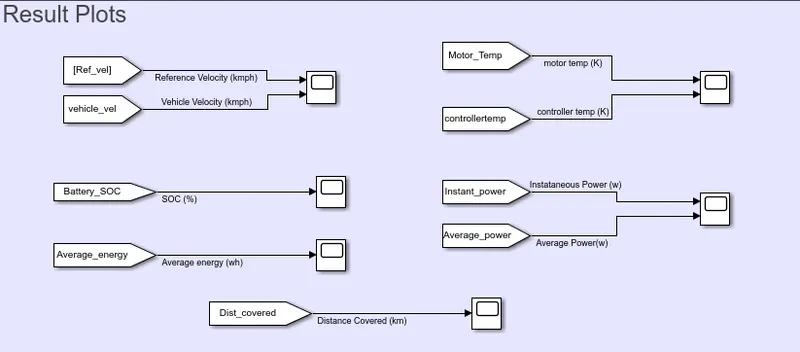
Dashboard:
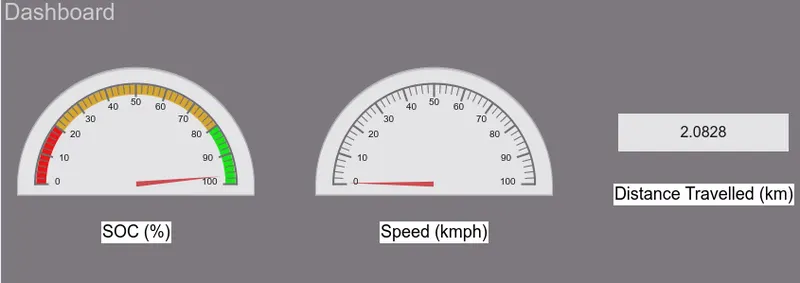
Result Plots:
Drive Cycle: FTP75
Reference Velocity (Drive cycle) vs Vehicle velocity:
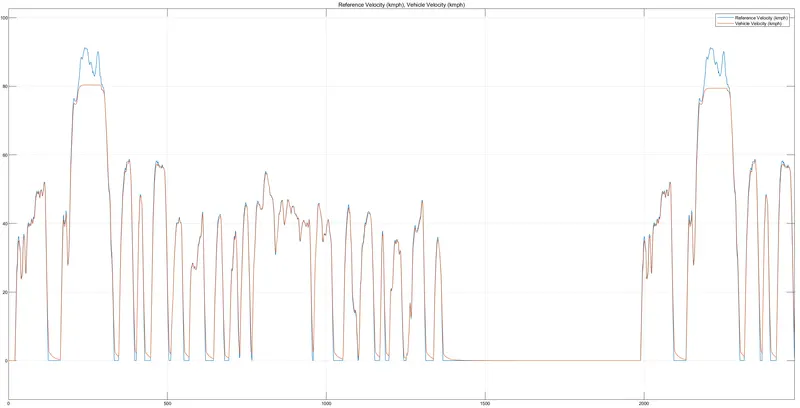
The constant velocity observed at the peaks of the drive cycle, where the reference velocity is more than 80, this is due to the power limitation of the motor. to avoid this a high-power capacity motor can be used.
%SOC:
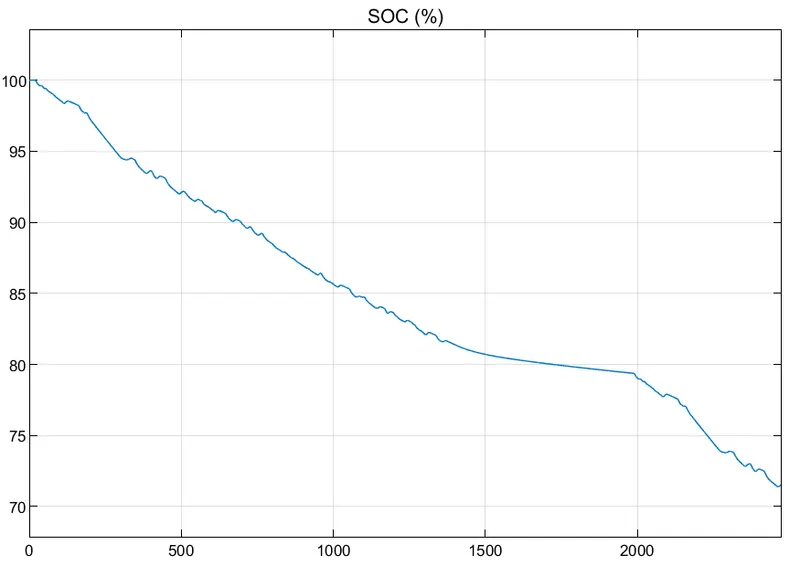
By the end of drive cycle the SOC of the battery is around 71%
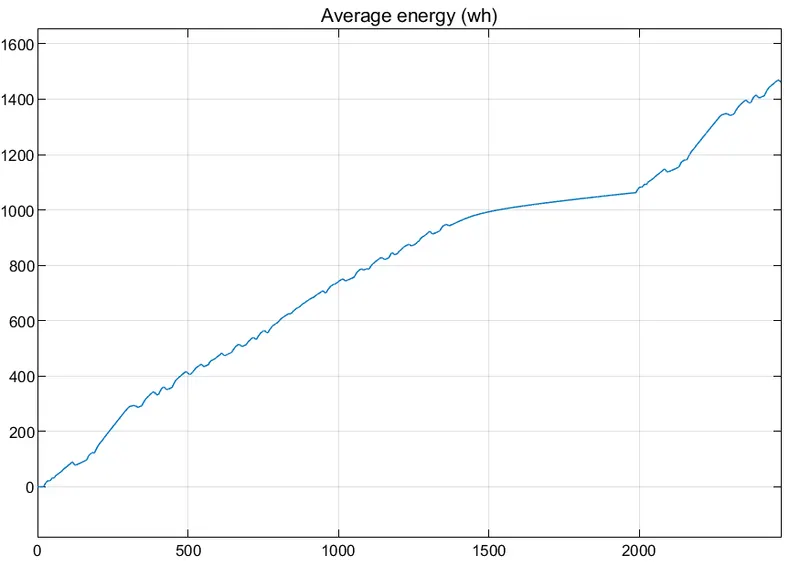
Average Energy consumed:
Instantaneous power and Average power:
Distance Covered:
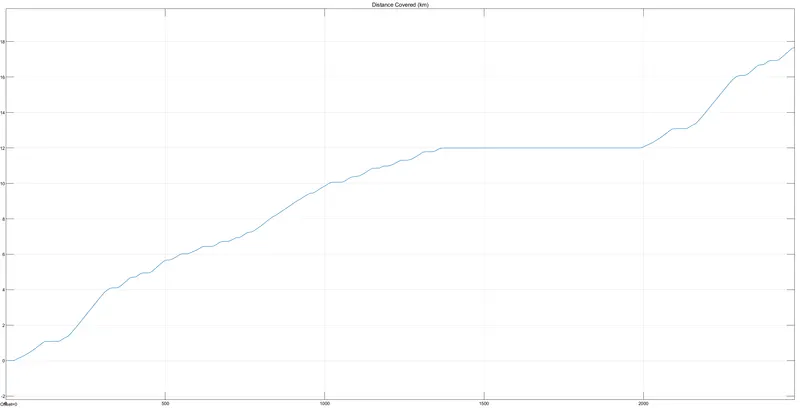
The distance covered is 17.65km
Motor and Controller temp:
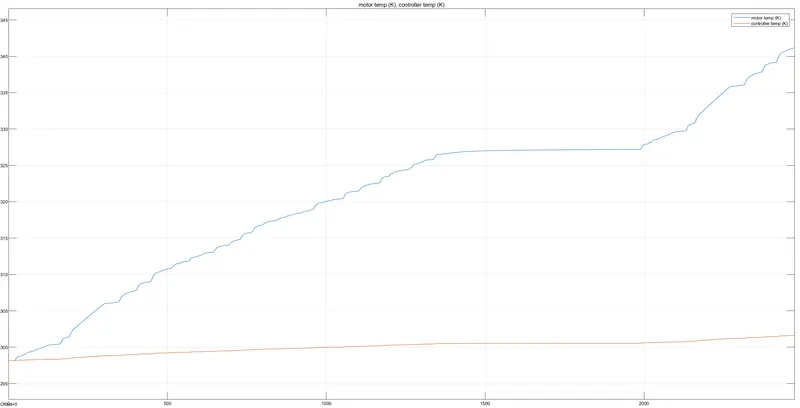
The max motor temp is 341K
Max Controller temp is 302K.
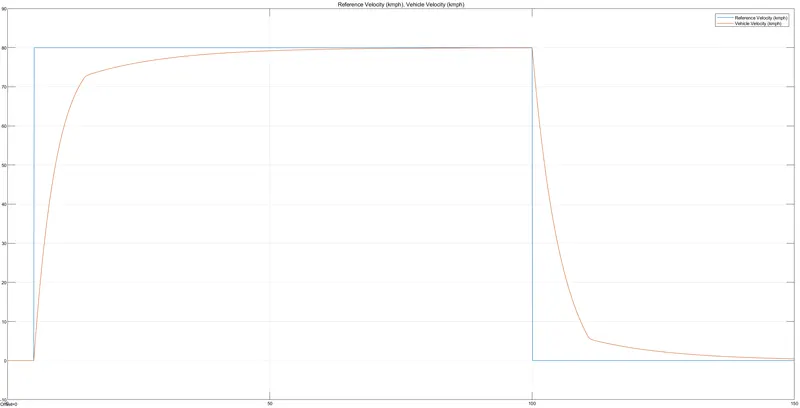
Drive Cycle: WOT
Reference Velocity (Drive cycle) vs Vehicle velocity:
%SOC:
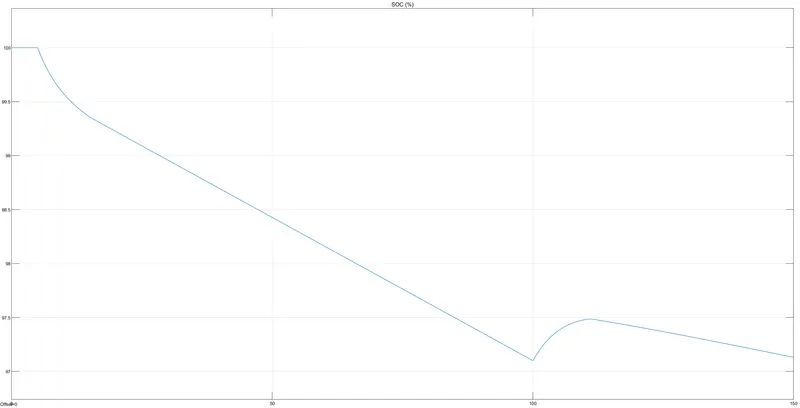
By the end of drive cycle the SOC of the battery is around 97.2%
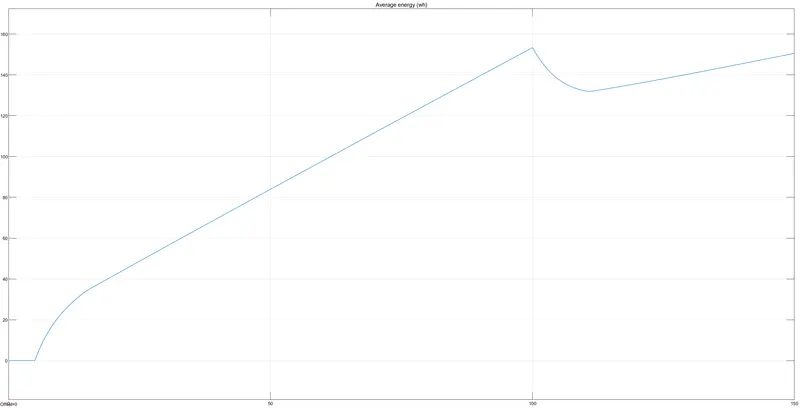
Average Energy consumed:
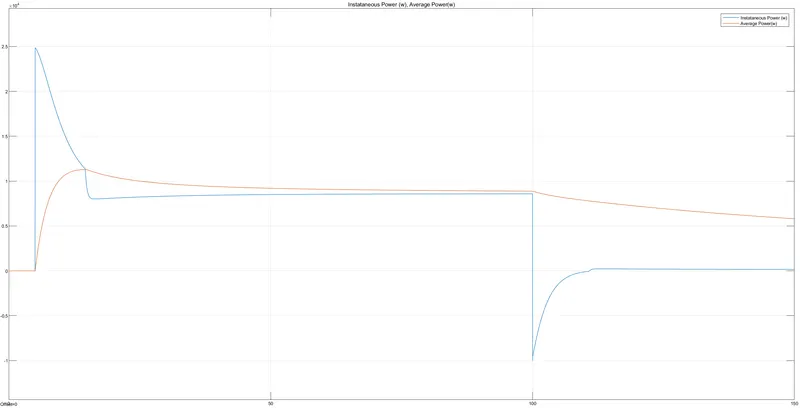
Instantaneous power and Average power:
Distance Covered:
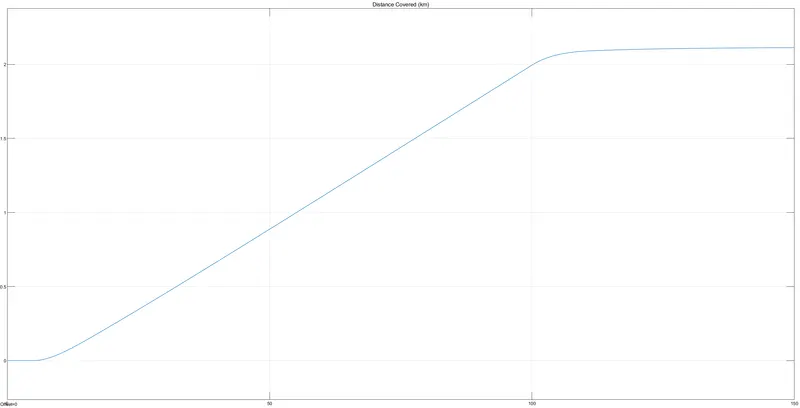
The distance covered is 2.1km
Motor and Controller temp:
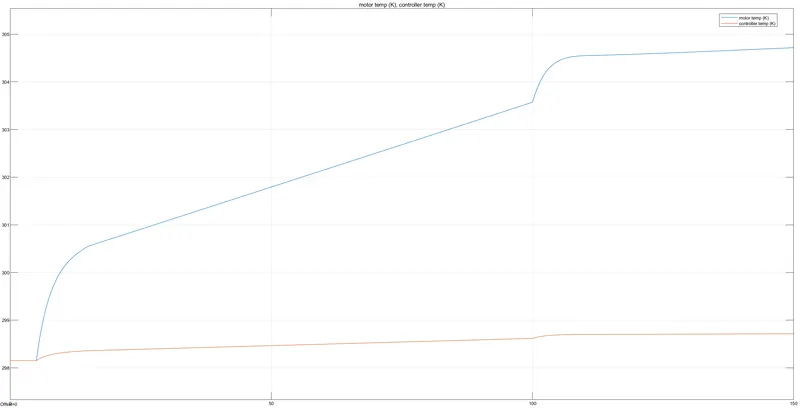
The max motor temp is 305K
Max Controller temp is 299K.
Drive Cycle: WOT (45kmph for 100km)
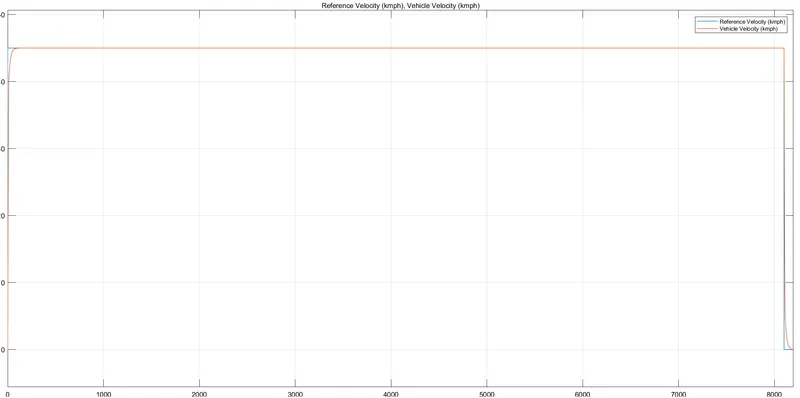
Reference Velocity (Drive cycle) vs Vehicle velocity:
%SOC:
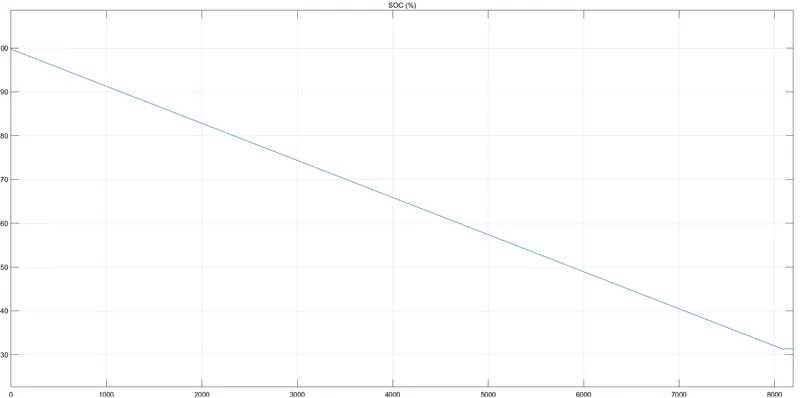
By the end of drive cycle the SOC of the battery is around 31%
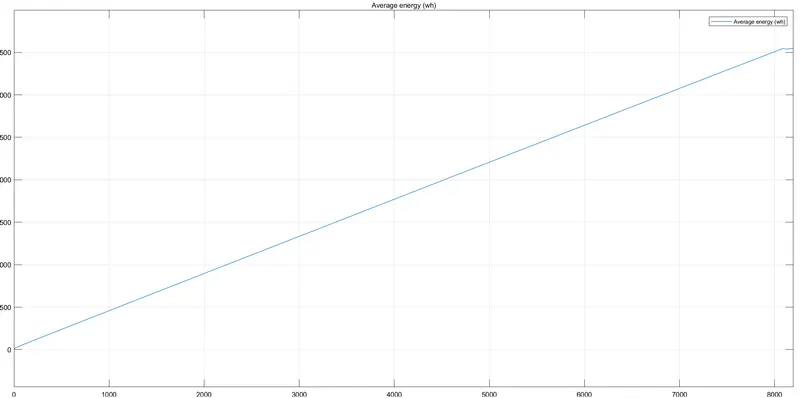
Average Energy consumed:
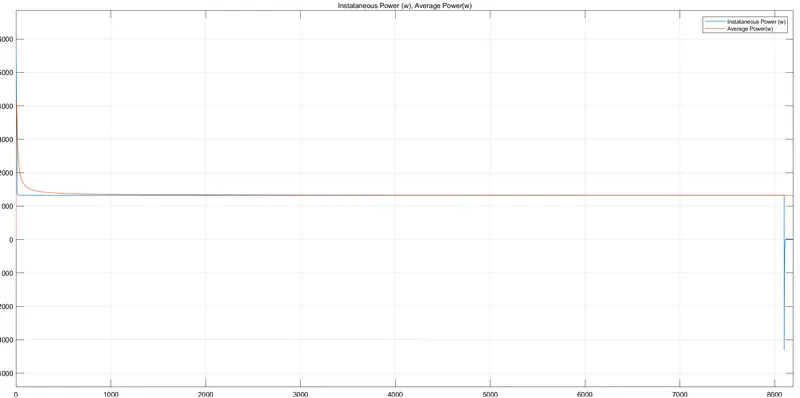
Instantaneous power and Average power:
Distance Covered:
The distance covered is 101.24km
Motor and Controller temp:
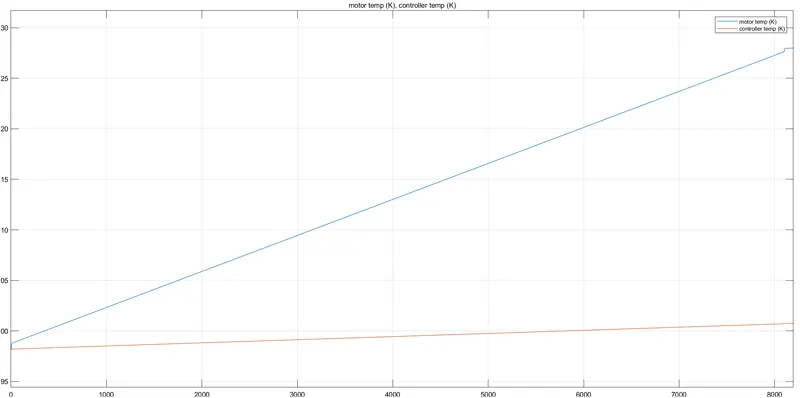
The max motor temp is 328K
Max Controller temp is 301K
Conclusion:
An electric Rickshaw model is developed using MATLAB. Three driving cycles are simulated and the effects are analyzed.