Final Project: Electric Rickshaw modelling
Create a detailed MATLAB model of an electric rickshaw (three wheel passenger vehicle) as per details below:
Rear wheels driven by PM brushed type motor
Assume efficiency points of motor controller and motor
Make an excel sheet of all input and assumed data
Results: For any three standard driving cycles show energy consumption, temperature rise of motor and controller for 100 km constant speed driving at 45 kmph.
(Note- The simulink model file should be compulsorily attached)
Answers
AIM ---electric rickshaw design (three-wheel passenger vehicle)
In this project, we going to build the MATLAB model of the ELECTRIC RICKHAEW by using a PM brushed type DC motor and a suitable Lithium-Ion battery for the motor. Before that, we will know about what is Electric RICKHAEW, how it works, and its benefits of EV RICKHAE. Then we make an actual EV RICKHAEW model in SIMULINK with suitable blocks from the powertrain block set.
The rear wheels are driven by PM brushed-type motor
Electric Rickshaws are eco-friendly battery-operated three-wheelers that have a better economy and lower operational cum maintenance costs. These e-rickshaws does not emit toxic pollutants into the air during operation and hence, does not have any tailpipe. These vehicles have gained popularity amongst Indian rickshaw drivers and commuters.
There are numerous players in India who are involved in the assembly of electric rickshaws. Most of these vehicles are assembled using sub-standard Chinese parts, which compromises the quality and performance of the vehicles. We, at GEMEV use premium quality components and raw materials to manufacture our vehicles. As a result, our products are more durable and give superior performance.
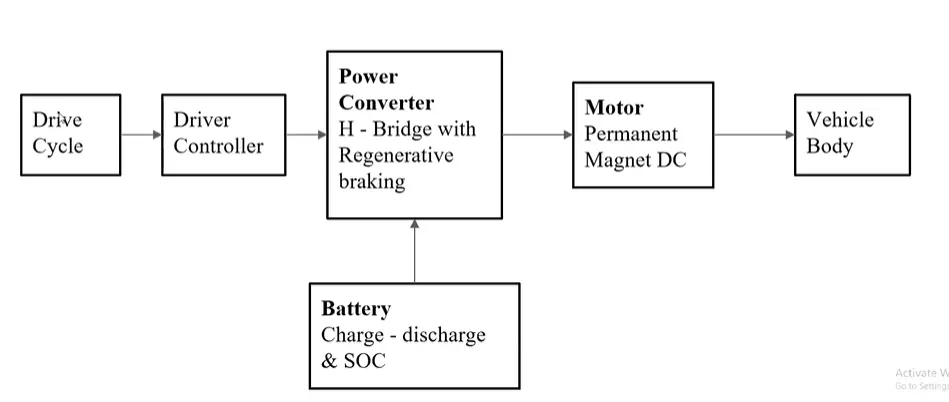
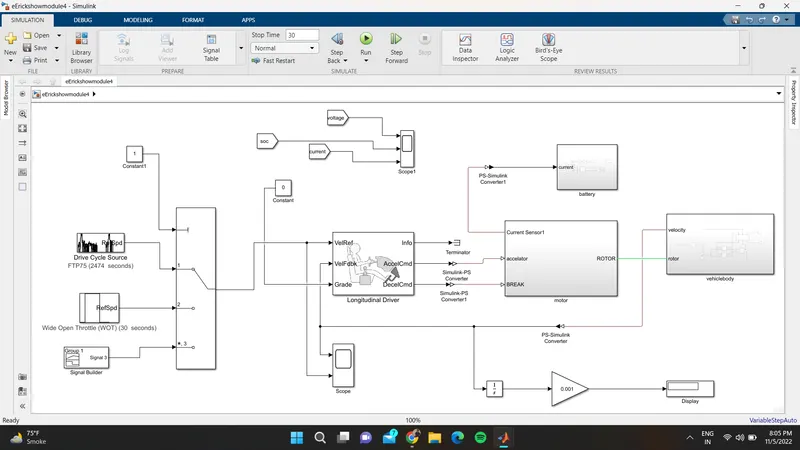
In the designed Electric Rickshaw main blocks are Battery, drive cycle, controller, DC Motor, Vehicle body & Transmission system. Drive cycle is the input data like how a human drive his actual vehicle here FTP75, WOT
drive cycles are used to make the designed vehicle to give the output how it reacts to the drive cycle. The main objective is to obtain the speed by the driver, to estimate the temperature of the Motor and Controller, estimate the states of charge (SOC), and the distance traveled by the vehicle. There is a SOC block that will estimate the state of charge of a battery, distance is calculated by speed and time parameters for all three Drive cycles.
E Rickshaw in India are built over tubular chassis, the body is kept light in weight to increase the life and performance of the battery. The main electronic components which make the powertrain are motor, controller, harness, batteries and the throttle. Any mismatch among any of these components is undesirable and may compromise vehicle performance.
The chassis is the main part which ensures drive quality and safety of the vehicle. It is made of mild steel. These days, most of the locally-made chassis are often built without proper design, leading to an imbalance in the drive, and often causing the vehicle to pivot or topple very easily. The chassis manufactured by a professional E Rickshaw Manufacturer is robust as the design adheres to all quality / technical parameters, which are often ignored by others. The chassis, if inaccurately made, will have handling problems, will be damaged easily, and corrode if not treated for resisting certain chemicals (from the battery or otherwise) or moisture.
The low weight of a body is desirable, which can be achieved with good product design, quality check, using materials such as F.R.P, aluminium, composite materials, and low-density metals. A very good alternative is F.R.P which is strong, non-conducting, cheap, lightweight, highly durable, resistant to fire, withstands weather and is easily repaired in case of damage. The body is attached to chassis by bolts, and in some cases welded, which is not recommended. The body should be built keeping in mind the quality and design which is aerodynamic and ensures driver safety. Better quality bodies last for years whereas low-quality body will last no longer than 10 to 15 months. In this case, F.R.P is extremely desirable since the life of the body runs in multiple decades. Electrical parts are recommended to be tight, use high-quality couplers to ensure proper connection and insulate connection to prevent water and moisture.
Usage of high quality electrical components will lower resistance and heat losses and increase efficiency.
The motor power used in most e rickshaws is 650W to 1250W, the latest government norms allow it to be 650W, most of them run on 850W and higher, which adversely affects the battery life. The controller used is ~ 40A, 48V output, uses 14, 18 or 24 MOSFETs and powers all electric components.
A good quality controller must be used to increase the performance of the motor and other overheating issues. A controller should be installed with electrical brake cut off, and which usually are removed by common rickshaw mechanics in order to achieve a continuous torque or improper functioning of the brakes.
The braking system is mechanical drum brakes. Service and maintenance are required for proper vehicle functioning as the improper brake adjustments may heat up the motor and controllers and damage brake shoes. It may also reduce the mileage of the vehicle.
The batteries used in e rickshaws are lead acid as they provide low-cost alternative. They range from 80A to 120A nowadays. A larger battery with more capacity can be used, but adversely it can increase weight and reduce mileage. To prevent it, the ratio of weight and AH (measure of battery capacity) must be maintained, so we recommend to use not more than 110AH batteries as they exceed 125 kgs. Deep discharge batteries made for electric vehicles may be used depending on the customer’s preference. To maintain long life, a low amperage charger ~10 to 15A should be used, a charger with current and voltage maintained is preferred to prevent bulging and higher cycles.
Every aspect of an electric vehicle, if engineered, designed and manufactured with quality will improve battery life, vehicle life and contribute to a higher profit over time.
model of the E-rickshaw
(1) Vehicle Body Subsystem Model :
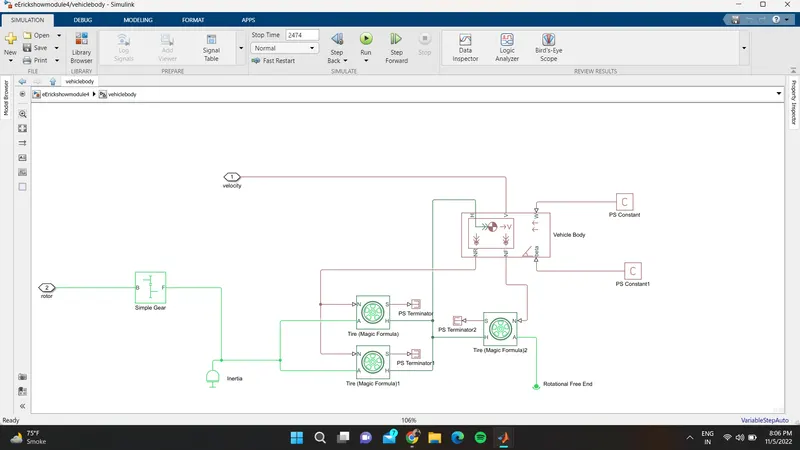
simple gear---------
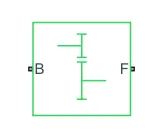
- Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
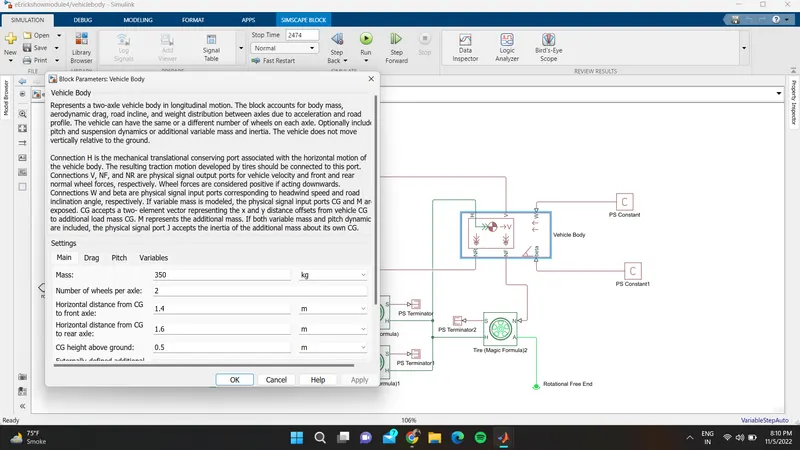
vehicle body----------
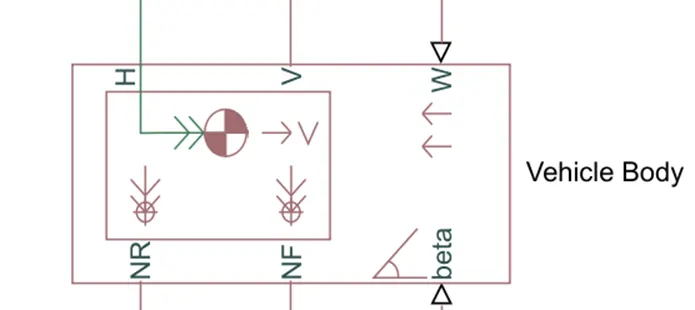
- Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. Wheel forces are considered positive if acting downwards.
- Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively.
Tire:
The Simple Gear block represents a gearbox that constrains the connected driveline axes of the base gear, B, and the follower gear, F, to corotate with a fixed ratio that you specify. You choose whether the follower axis rotates in the same or opposite direction as the base axis. If they rotate in the same direction, the angular velocity of the follower, ωF, and the angular velocity of the base, ωB, have the same sign. If they rotate in opposite directions, ωF and ωB have opposite signs. You can easily add and remove backlash, faults, and thermal effects.
Ideal Gear Constraint and Gear Ratio
The kinematic constraint that the Simple Gear block imposes on the two connected axes is
rFωF=rBωB
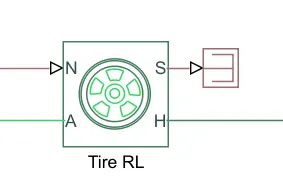
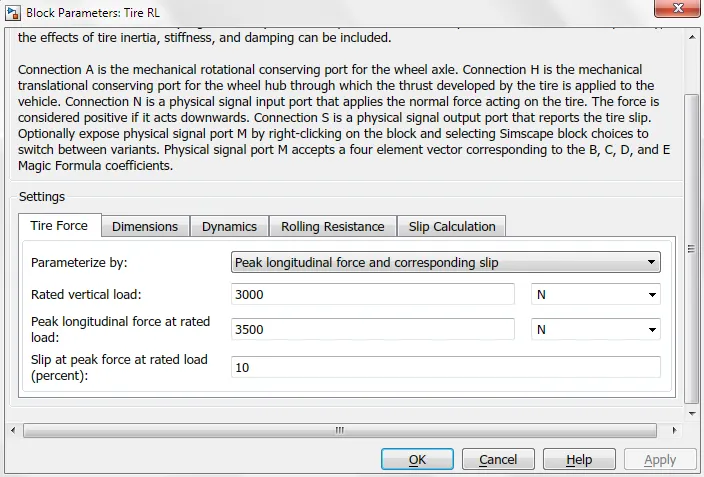
Connection A is the mechanical rotational conserving port for the wheel axle
Connection N is a physical signal input port that applies the normal force acting on the tire
Connection S is a physical signal output port that reports the tire slip.
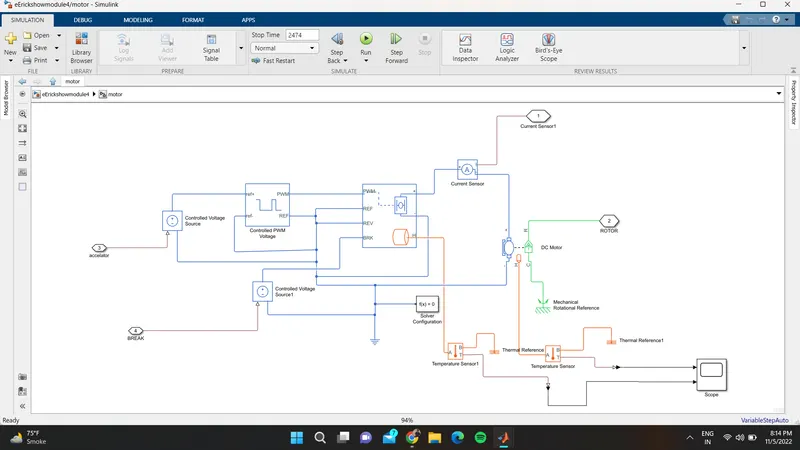
Motor & Power Converter Subsystem Model (With Temperature Sensor) :
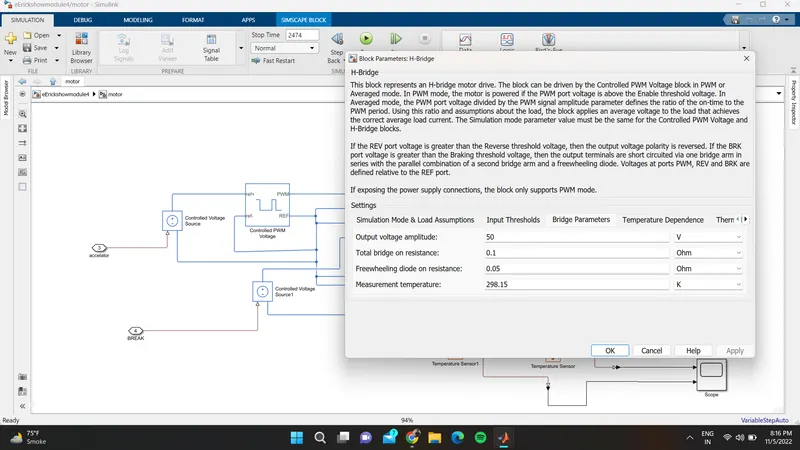
H-Bridge :
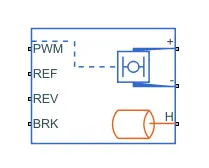
The H-Bridge block represents an H-bridge motor driver. The block has the following two Simulation mode options:
-
PWM— The H-Bridge block output is a controlled voltage that depends on the input signal at the PWM port. If the input signal has a value greater than the Enable threshold voltage parameter value, the H-Bridge block output is on and has a value equal to the value of the Output voltage amplitude parameter. If it has a value less than the Enable threshold voltage parameter value, the block maintains the load circuit using one of the following three Freewheeling mode options:-
Via one semiconductor switch and one freewheeling diode -
Via two freewheeling diodes -
Via two semiconductor switches and one freewheeling diode
The first and third options are sometimes referred to as synchronous operation.
The signal at the REV port determines the polarity of the output. If the value of the signal at the REV port is less than the value of the Reverse threshold voltage parameter, the output has positive polarity; otherwise, it has negative polarity.
-
-
Averaged— This mode has two Load current characteristics options:-
Smoothed -
Unsmoothed or discontinuous
The
Smoothedoption assumes that the current is practically continuous due to load inductance. In this case, the H-Bridge block output is:VOVPWMAPWM−IOUTRON
where:
-
VO is the value of the Output voltage amplitude parameter.
-
VPWM is the value of the voltage at the PWM port.
-
APWM is the value of the PWM signal amplitude parameter.
-
IOUT is the value of the output current.
-
RON is the Bridge on resistance parameter.
The current will be smooth if the PWM frequency is large enough. Synchronous operation where freewheeling is via a bridge arm back to the supply also helps smooth the current. For cases where the current is not smooth, or possibly discontinuous (that is, it goes to zero between PWM cycles), use the
Unsmoothed or discontinuousoption. For this option, you must also provide values for the Total load series resistance, Total load series inductance, and PWM frequency. During simulation, the block uses these values to calculate a more accurate value for H-bridge output voltage that achieves the same average current as would be present if simulating in PWM mode. -
Set the Simulation mode parameter to Averaged to speed up simulations when driving the H-Bridge block with a Controlled PWM Voltage block. You must also set the Simulation mode parameter of the Controlled PWM Voltage block to Averaged mode. This applies the average of the demanded PWM voltage to the motor. The accuracy of the Averaged mode simulation results relies on the validity of your assumption about the load current. If you specify that the current is Unsmoothed or discontinuous, then the accuracy also depends on the values you provide for load resistance and inductance being representative. This mode also makes some simplifying assumptions about the underlying equations for the case when current is discontinuous. For typical motor and bridge parameters, accuracy should be within a few percent. To verify Averaged mode accuracy, run the simulation using the PWM mode and compare the results to those obtained from using the Averaged mode.
Braking mode is invoked when the voltage presented at the BRK port is larger than the Braking threshold voltage. Regardless of whether in PWM or Averaged mode, when in braking mode the H-bridge is modeled by a series combination of two resistances R1 and R2 where:
-
R1 is the resistance of a single bridge arm, that is, half the value of the Total bridge on resistance parameter.
-
R2 is the resistance of a single bridge arm in parallel with a diode resistance, that is, R1 · Rd / ( R1 + Rd ), where Rd is the diode resistance.
As the name indicates that the H symbol in the block is connected to the DC motor and the PWM, REF, REV, and BRK are used to control the block DC motor.
The block can be driven by the Controlled PWM Voltage block in PWM or Averaged mode. In PWM mode, the motor is powered if the PWM port voltage is above the Enable threshold voltage
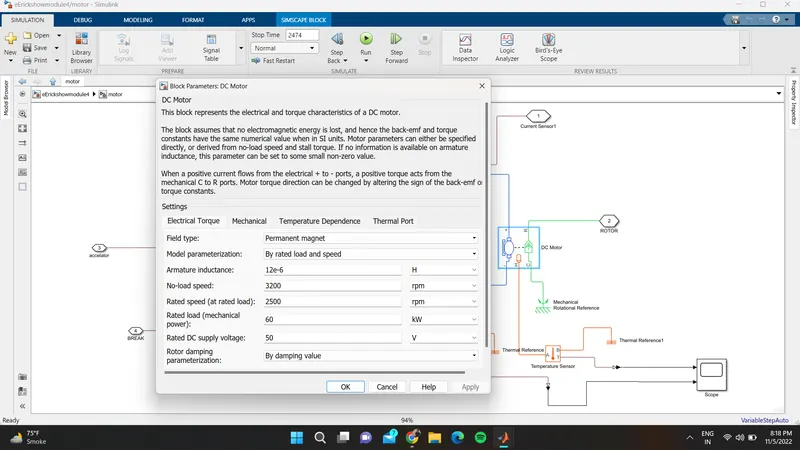
DC Motor :
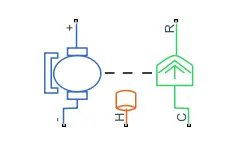
The DC Motor block represents the electrical and torque characteristics of a DC motor using the following equivalent circuit model:
You specify the equivalent circuit parameters for this model when you set the Model parameterization parameter to By equivalent circuit parameters. The resistor R corresponds to the resistance you specify in the Armature resistance parameter. The inductor L corresponds to the inductance you specify in the Armature inductance parameter.
You can specify how to generate the magnetic field of the DC motor by setting the Field type parameter to the desired option. The permanent magnets in the motor induce the following back emf vb in the armature:
vb=kvω
where kv is the Back-emf constant and ω is the angular velocity. The motor produces the following torque, which is proportional to the motor current i:
TE=kti
where kt is the Torque constant. The DC Motor block assumes that there are no electromagnetic losses. This means that mechanical power is equal to the electrical power dissipated by the back emf in the armature. Equating these two terms gives:
TEω=vbiktiω=kvωikv=kt
As a result, you specify either kv or kt in the block parameters.
If the magnetic field is generated from the current flowing through the windings, the Back-emf constant depends on the field current If:
kv=LafIf
where Laf is the Field-armature mutual inductance.
The torque-speed characteristic for the DC Motor block is related to the parameters in the preceding figure. When you set the Model parameterization parameter to By stall torque & no-load speed or By rated power, rated speed & no-load speed, the block solves for the equivalent circuit parameters as follows:
-
For the steady-state torque-speed relationship, L has no effect.
-
Sum the voltages around the loop and rearrange for i:
i=V−vbR=V−kvωR
-
Substitute this value of i into the equation for torque:
TE=ktR(V−kvω)
When you set the Model parameterization parameter to
By stall torque & no-load speed, the block uses the stall torque and no-load speed to determine values for R and kt (and equivalently kv).When you set the Model parameterization parameter to
By rated power, rated speed & no-load speed, the block uses the rated speed and power to calculate the rated torque. The block uses the rated torque and no-load speed values to determine values for R and kt.
The block models motor inertia J and damping λ for all values of the Model parameterization parameter. The resulting torque across the block is:
T=ktR(V−kvω)−J˙ω−λω
It is not always possible to measure rotor damping, and rotor damping is not always provided on a manufacturer datasheet. An alternative is to use the no-load current to infer a value for rotor damping.
For no-load, the electrically-generated mechanical torque must equal the rotor damping torque:
ktinoload=λωnoload
where inoload is the no-load current. If you select By no-load current for the Rotor damping parameterization parameter, then this equation is used in addition to the torque-speed equation to determine values for λ and the other equation coefficients.
The value for rotor damping, whether specified directly or in terms of no-load current, is taken into account when determining equivalent circuit parameters for Model parameterization options By stall torque and no-load speed and By rated power, rated speed and no-load speed.
When a positive current flows from the electrical + to - ports, a positive torque acts from the mechanical C to R ports.
It is used to convert electrical energy to mechanical energy. In this electric vehicle model, we have used a type is permanent magnet DC motor. This motor can also act as a generator in the case of regenerative braking.
In this block, the motor's electrical side is represented with the blue color and the mechanical side is represented with green as well with the combination of shaft which is in the dotted line. here the motors +ve and -ve terminals are connected to the H-Bridge +ve and -ve terminals respectively with the electrical reference in the -ve side.
Controlled PWM Voltage :
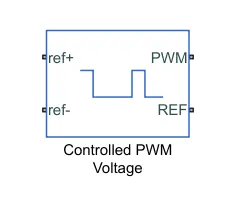
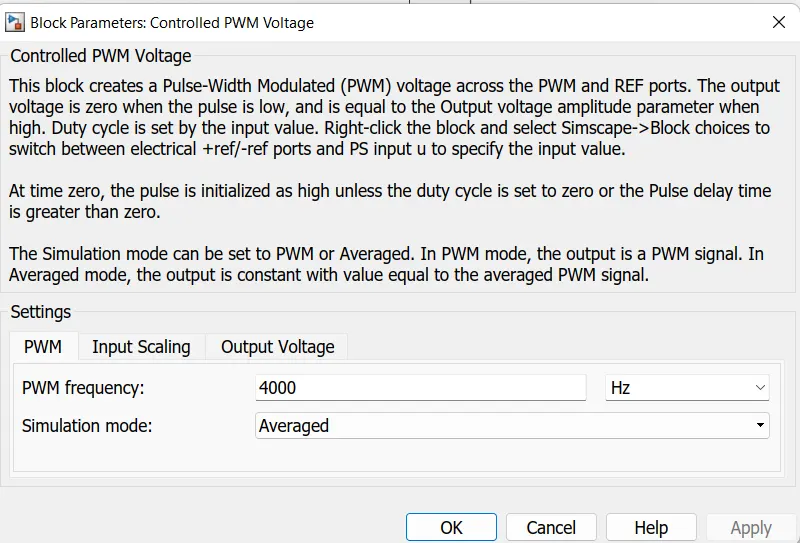
The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source. You can model electrical or physical signal input ports by setting the Modeling option parameter to either:
-
Electrical input ports— The block calculates the duty cycle based on the reference voltage across its ref+ and ref- ports. This option is the default. -
PS input— Specify the duty cycle value directly by using an input physical signal port.
If you set Modeling option to Electrical input ports, the demanded duty cycle is
100∗Vref−VminVmax−Vmin percent
where:
-
Vref is the reference voltage across the ref+ and ref- ports.
-
Vmin is the minimum reference voltage.
-
Vmax is the maximum reference voltage.
The value of the Output voltage amplitude parameter determines amplitude of the output voltage.
At time zero, the pulse is initialized as high, unless the Pulse delay time parameter is greater than zero, or the demanded duty cycle is zero.
You can use parameters Pulse delay time and Pulse width offset to add a small turn-on delay and a small turn-off advance. This can be useful when fine-tuning switching times so as to minimize switching losses.
In PWM mode, the block has two options for the type of switching event when moving between output high and output low states:
-
Asynchronous – Best for variable-step solvers— Asynchronous events are better suited to variable step solvers, because they require fewer simulation steps for the same level of accuracy. In asynchronous mode the PWM switching events generate zero crossings, and therefore switching times are always determined accurately, regardless of the simulation maximum step size. -
Discrete—time – Best for fixed-step solvers— Discrete-time events are better suited to fixed-step operation, because then the switching events are always synchronized with the simulation step. Using an asynchronous implementation with fixed-step solvers may sometimes result in events being up to one simulation step late. For more information, see Simulating with Fixed Time Step — Local and Global Fixed-Step Solvers.
If you use a fixed-step or local solver and the discrete-time switching event type, the following restrictions apply to the Sample time parameter value:
-
The sample time must be a multiple of the simulation step size.
-
The sample time must be small compared to the PWM period, to ensure sufficient resolution.
It is used to give the Pulse Width Modulation signals to the H bridge circuit at the PWM terminal. The +ve reference terminal of the block is connecter to the controlled voltage source and -ve is connected to the electrical reference, the PWM is connected to the H bridge PWM as said above and REF is connected to the REF and REV terminals of the H bridge.
Electrical reference:
It is used to connect all the terminals of the negative signals and the reference values as the ground.The Electrical Reference block represents an electrical ground. Electrical conserving ports of all the blocks that are directly connected to ground must be connected to an Electrical Reference block. A model with electrical elements must contain at least one Electrical Reference block.
Ps-Simulink converter:
Unit Conversion and Checking
The Output signal unit parameter lets you specify the desired units for the output signal. These units must be commensurate with the units of the input physical signal coming into the block. If you specify a desired output unit, the block applies a gain equal to the conversion factor before outputting the Simulink signal. For example, if the input physical signal coming into the block is displacement, in meters, and you set Output signal unit to mm, the block multiplies the value of the input signal by 1e3 before outputting it. If the output signal unit is the same as the input signal unit, no gain is applied.
The default value of the Output signal unit parameter, inherit, automatically sets the unit at the block output port to match the unit of the input physical signal coming into the block, based on unit propagation rules. This way, you can easily connect a PS-Simulink Converter block to any signal, without worrying about setting the commensurate output unit.
In the diagram below, the input signal for the PS-Simulink Converter block is torque in N*m, and if you do not specify the output signal unit, the Display block shows the value of 10. If you change the Output signal unit parameter value in the PS-Simulink Converter block to N*cm, the torque value in the Display block changes to 1000, as shown in the diagram.
It is used to connect the line from the physical signal to Simulink which act as a converter.
Mechanical rotational reference:
It is represented as a mechanical ground reference point that is as a frame part that is used to connect rotational parts to the groundThe Mechanical Rotational Reference block represents a reference point, or frame, for all mechanical rotational ports. All rotational ports that are rigidly clamped to the frame (ground) must be connected to a Mechanical Rotational Reference block.
Temperature Sensor :
- A temperature Sensor is used to measure the temperature of the H-Bridge and Motor.
- This block measures temperature in a thermal network. There is no heat flow through the sensor. The physical signal port T reports the temperature difference across the sensor.
- The measurement is positive when the temperature at port A is greater than the temperature at port B.
Battery And Soc Subsystem Model :
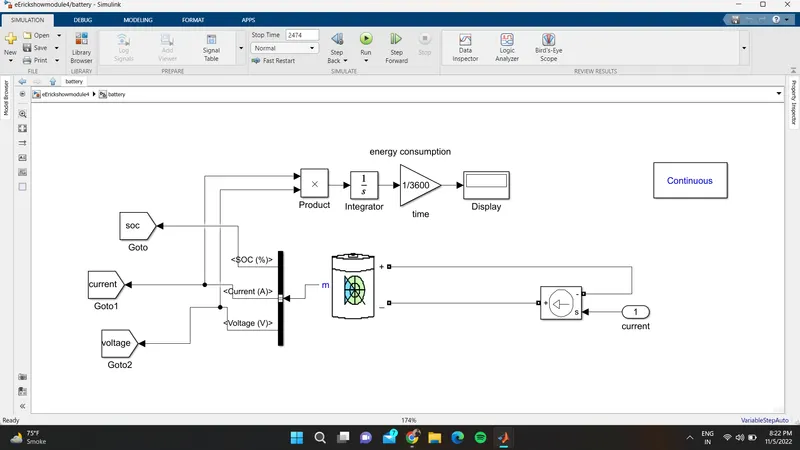
Battery :
We can say that the battery is one of the main important parts or the block in the vehicle and model as well. By connecting this terminal to the controlled voltage source it supplies controlled signals to discharge and also charging in the regenerative type as well
BUS selector
The bus selector is used to block the output signals which are given as an input to that bus selector block
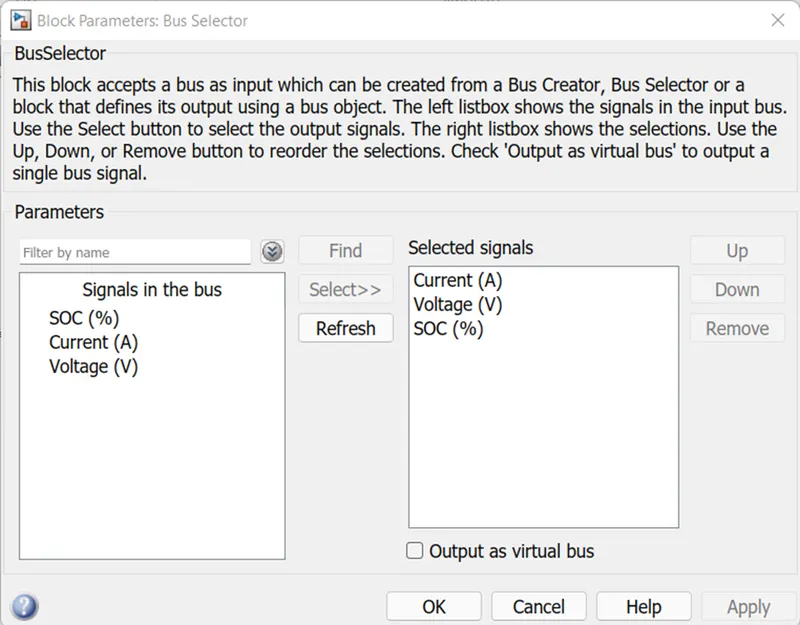
Solver configuration:
It is placed in the power control unit for the mathematical values in the model solver settings at the simulation time
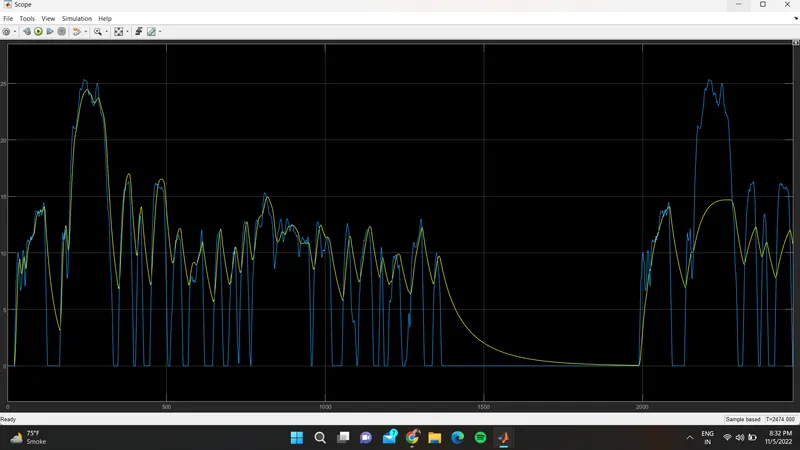
To get the results of this model we have to keep the stop time to 2474 sec or above because of the given drive cycle source with FTP (2474 seconds).
Longitudinal Driver :
- Longitudinal Driver is an inbuilt block provided by the powertrain blocks.
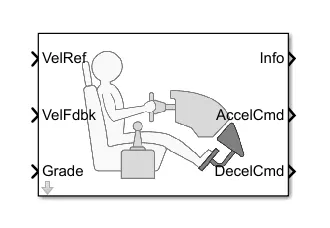
It like a driver which is used to take the charge of driving its acceleration breaking commands as per the given conditions which is called as a reference.
VEL Ref is used to take the reference values for the driver to drive the vehicle.
Vel Fdbk is used to take the feedback from the output of the given data from the vehicle speed which is called as a velocity.
Accel Cmd is an output signal that gives as an input to the power control unit-controlled voltage source 1 which is connected to the PWM for the purpose of acceleration when the output is reduced to lower than the given reference value.
Decel Cmd is also an output signal that gives as an input to the power control unit-controlled voltage source 2 which is connected to the BRK for the purpose of breaking when the output is becoming higher than the given reference value.
Reference Velocity (Drive Cycle) :
in this, we have taken three drive cycle
one is FTP75
one wot(wide open throttle)
single builder
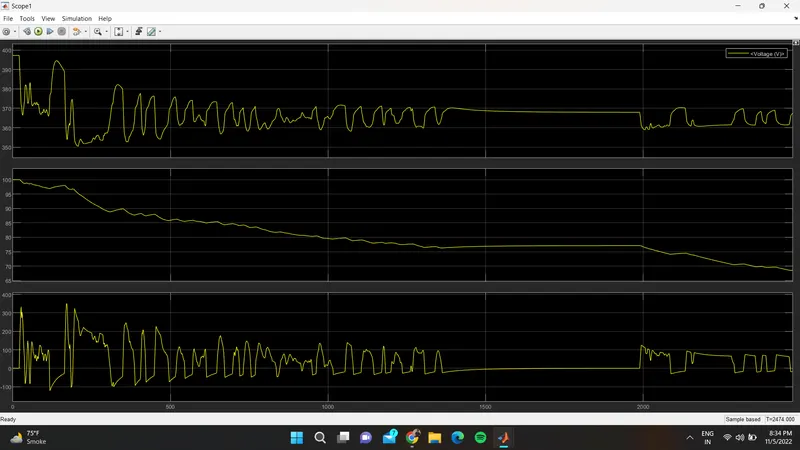
result for FTPF75 drive cycle
result for voltage ,soc,current
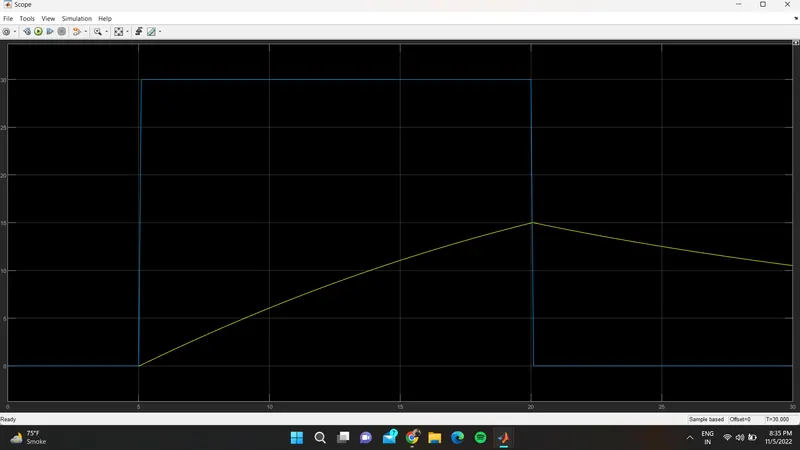
graph for WOT CONDITION
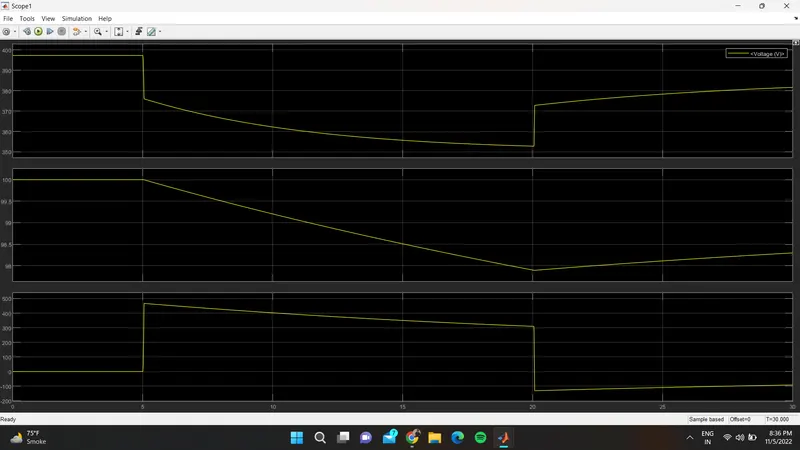
DRIEV CYCLE
SOC,VOLTAGE,CURRENT
Here I have compromised with the temperature of the Motor and controller to achieve vehicle speed is near to reference speeds. Since I haven’t used any cooling system in the model. In the real-time application
THE REFERENCE DRIVE CYCLE CANT NOT PROPERLY OVERLAP THE VEHICLE SEPPED