Final Project: Design of an Electric Vehicle
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
Objectives:
1. System level configurations
2. Model parameters
3. Results
4. Conclusion
Theory:
An electric vehicle(EV) is defined as a vehicle that uses an electric motor or a traction motor for propulsion instead of internal combustion used by conventional vehicles. Electric vehicles use electricity for power instead of fossil fuels like conventional vehicles. So, they do not produce any exhaust gases and pollution. The power needed in the EV comes from batteries, generators, or any collector system. Batteries fitted in the EV are of high energy densities to meet the power requirements and range.
The power of a vehicle's electric motor, as in other vehicles, is measured in kilowatts (kW). 100 kW is roughly equal to 134 horsepower but electric motors can deliver their maximum torque over a wide RPM range. This means that the performance of a vehicle with a 100 kW electric motor exceeds that of a vehicle with a 100 kW internal combustion engine, which can only deliver its maximum torque within a limited range of engine speed. Energy is lost during the process of converting electrical energy to mechanical energy. Approximately 90% of the energy from the battery is converted to mechanical energy, the losses being in the motor and drivetrain. Usually, (DC) electricity is fed into a DC/AC inverter where it is converted to (AC) electricity, and this AC electricity is connected to a 3-phase AC motor. For electric trains and some electric cars, DC motors are often used. In some cases, universal motors are used, and then AC or DC may be employed. In recent production vehicles, various motor types have been implemented; for instance, induction motors within Tesla Motor vehicles and permanent magnet machines in the Nissan Leaf and Chevrolet Bolt.
Most large electric transport systems are powered by stationary sources of electricity that are directly connected to the vehicles through wires. Electric traction allows the use of Regenerative braking, in which the motors are used as brakes and become generators that transform the motion of, usually, a train into electrical power that is then fed back into the lines. This system is particularly advantageous in mountainous operations, as descending vehicles can produce a large portion of the power required for those ascending. This regenerative system is only viable if the system is large enough to utilize the power generated by descending vehicles. For EV,s to dominate the automotive industries, There need to be more convenient ways for consumers to able to charge their vehicles. There need to be several charging stations on highways and this can be supported if most of the houses are solar-powered. EV,s cost more than conventional vehicles because of the high cost of batteries and electric components.
HEVs combine an IC engine with an electric propulsion system to produce a hybrid between the two types of vehicles. The purpose of this is to use the power available from the electric power train to improve the fuel economy of the vehicle so that it does not rely solely on petrol/diesel for the fuel. This in turn will also improve the overall performance of the HEV. The IC engine can be used to power the electric motor to charge the battery or use directly in the electric drive motor with a combination of motor and generator in one. HEVs also implement regenerative braking to recharge their batteries. EVs are still a relatively new technology and account for 2-3%of the worldwide market. Whereas HEVs represent more of the market with a 19% market share on all automobiles. The all-time best-selling HEV to date is the Toyota Prius.
In this report, I will be modeling an electric vehicle with a DC motor and battery system using the SIMULINK software. The model will run for a drive cycle and measure the velocity characteristics, current, and state of charge characteristics of the battery system. The components I need to exist as blocks in the Simulink block library.
COMPONENTS:
The main components of the EV are:
- Wheels/tires
- Battery
- Motor/generator
- Motor controllers
- Power converters
- Transmission system
Main simulation diagram:
In the below picture, we have done the simulation of an electric vehicle using various drive cycles by using the powertrain blocks available in the Simulink library. First, there are the inputs where we have connected two different drive cycles which provide the reference for the longitudinal driver which compares the two speeds and gives accelerator and braking commands to the motor controller block. battery block and vehicle body blocks are further attached and scopes are used for displaying the working status
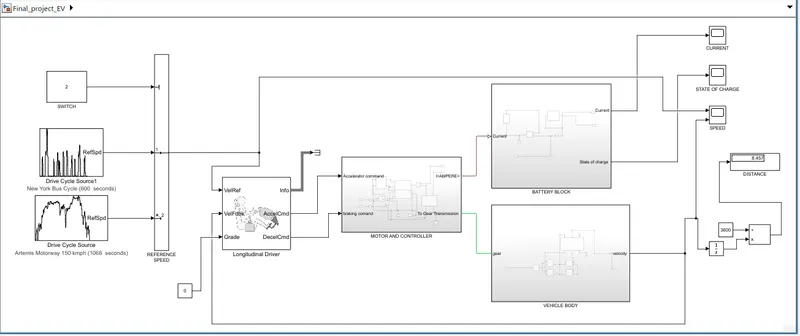
System level configuration:
For modeling the whole vehicle in SIMULINK. we need to model the above-mentioned components separately and make them work together>. All the main components are available in the library of SIMULINK blocks. so we add components and configure the parameters to fit the working requirements of the model.
Vehicle body:
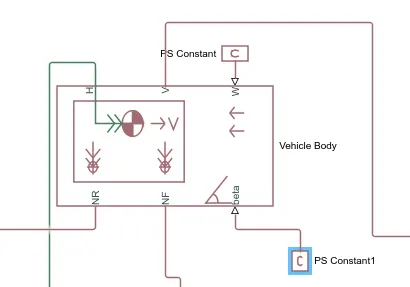
This block contains 6 ports that can be used to model various aspects of the vehicle body. The ports are mentioned below;
- H- This stands for hub and is used to connect the hubs of the wheels to the main body of the vehicle.
- V-Physical signal output port which stands for 'velocity' and is used the output the velocity of the vehicle.
- W- Physical signal input port and allows us to model a wind velocity that acts against the vehicle.
- NR- Physical signal output port to connect the rear wheels
- NF- Physical signal output port to connect the front wheels of the vehicle.
- Beta- Physical signal input port that allows the vehicle to undergo an inclination of hill climbing force.
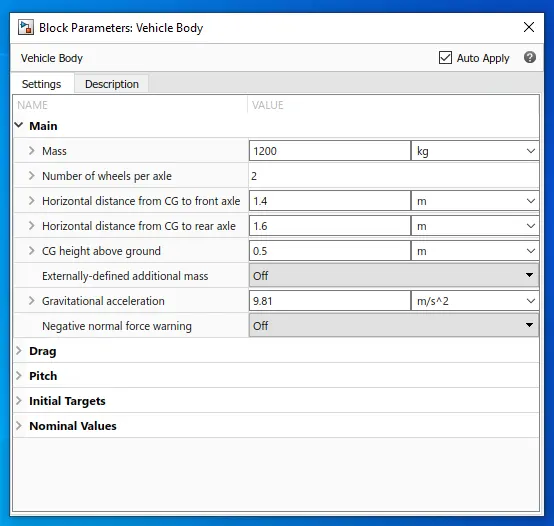
- Model parameters to set up mass, frontal area, and others.
VEHICLE BODY SUBSYSTEM:
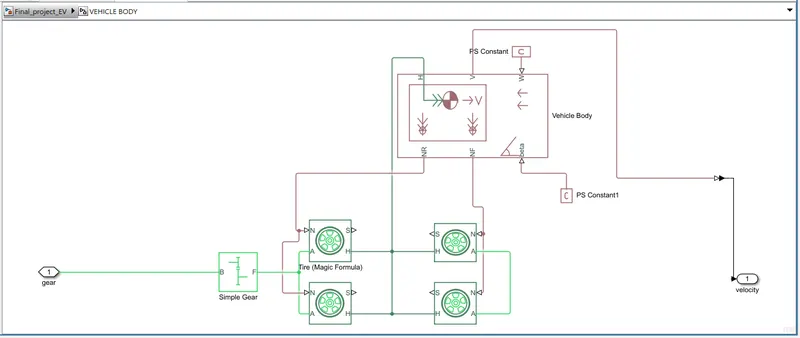
The above blocks are forming a subsystem that serves as a part of the whole vehicle. Four tires are connected, where the right two tires are the rear wheels and the remaining two are the front wheels. they are interconnected to the hub of the vehicle body block. and their respective axles are connected accordingly. We here have connected the rear axle with the gear as we want the model to be a rear-wheel drive vehicle. Here the wind velocity port and hill-climbing angle ports are connected to physical constant blocks which are kept as zero.
Tire block parameters:
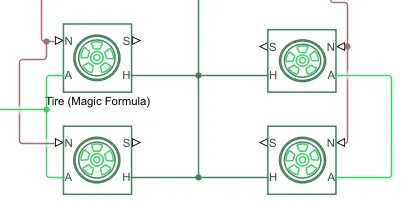
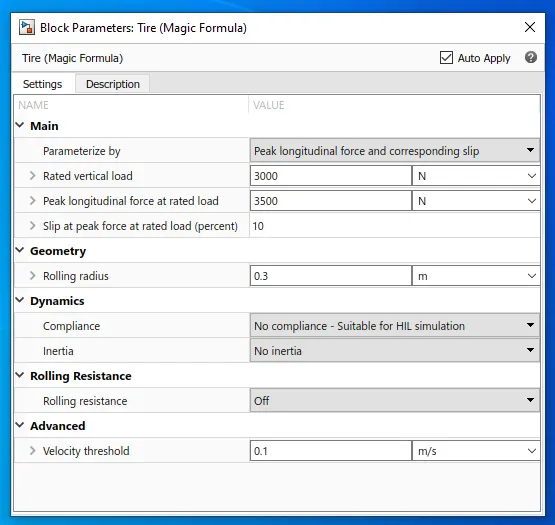
Here we can also change the geometry, dynamics, rolling resistance other characteristics if we want
Simple gear block parameters:
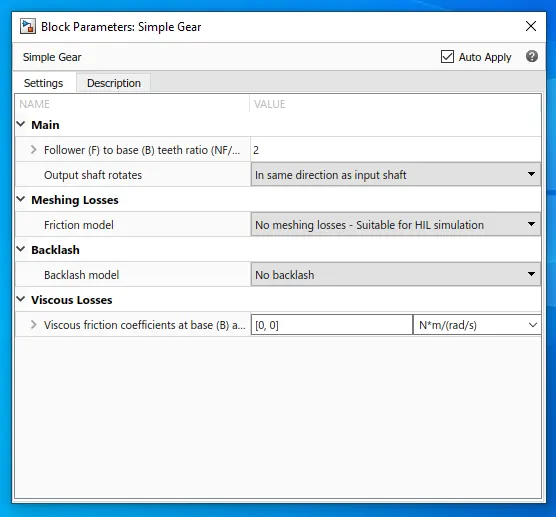
This block model a gear system with a fixed gear ratio with no inertia effects. However, we can modify the messing of the gear teeth, Here The follower to base teeth ratio has been set to 2 and the output shaft rotates in the same direction as the input shaft.
All these blocks are categorized into a single subsystem which we have named as vehicle body block, which takes the mechanical input from the motor and controller block into the gear and displays the velocity at which the vehicle body moves.
MOTOR AND CONTROLLER SUBSYSTEM:
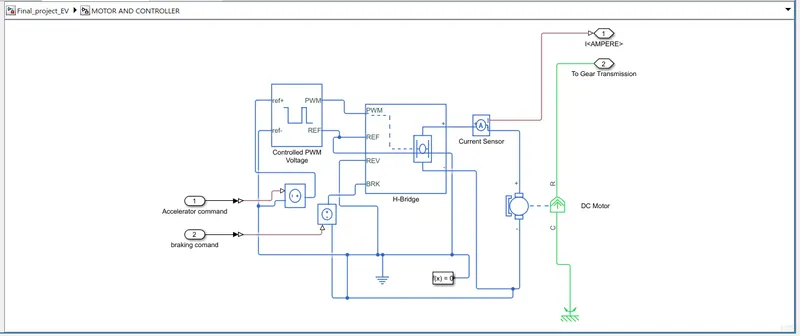
Components:
- DC Motor
- H-bridge
- Controlled PWM voltage
- Controlled voltage source
- Current sensor
DC-Motor-
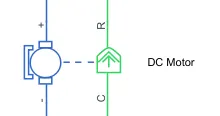
For the EV model, I have selected to use a DC motor block because DC motors are easy to model and have very few parameters to run for a particular application. There are two sides to the block, the mechanical side is on the right and the electrical side is on the left. the mechanical side has two ports C and R, C stands for casing and is the stable part and R is the rotor that produces a torque. The electrical side has a positive and negative side for the voltages to be applied. If a positive voltage is applied to the motor block from the positive to the negative terminal then a positive torque will act from C to R port. The direction of the torque can be changed by changing the sign of the back emf or the torque constant. Here I have connected the c port to the mechanical rotational reference because it will be stationary. The R port is connected to the gear in the vehicle body block.
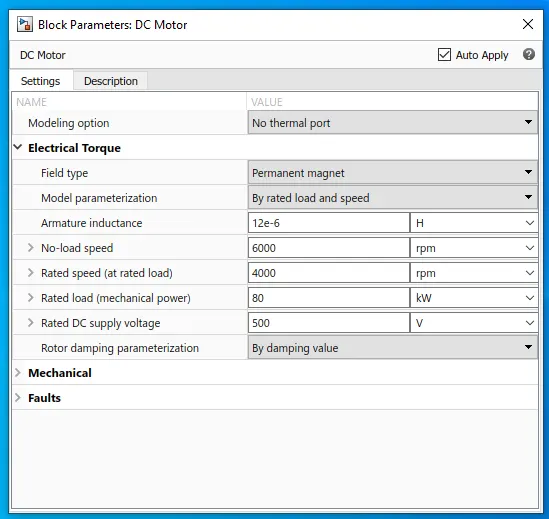
Here I have chosen to parameterize the block by rated power, rates speed, and no-load speed. This lets us modify the parameters such as DC supply voltage, and rated load. I have kept all values default except for the no-load speed, rated speed, and rated load.
H-bridge:
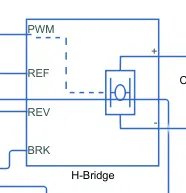
This is a power converter that is needed to provide the power of the correct form and magnitude from one component to another. In the case of EVs,s a power converter is needed to provide a DC voltage from the battery of the EV to the DC motor, so that it can function properly at the required parameters. Here I have used an H-bridge motor drive as my power converter. The left side is for controlling the voltage signals and the right side terminals provide the controlled voltage to the DC motor the left side ports are:
- PWM- Pulse width modulation
- REF- Reference
- REV- Reverse
- BRL- Brake
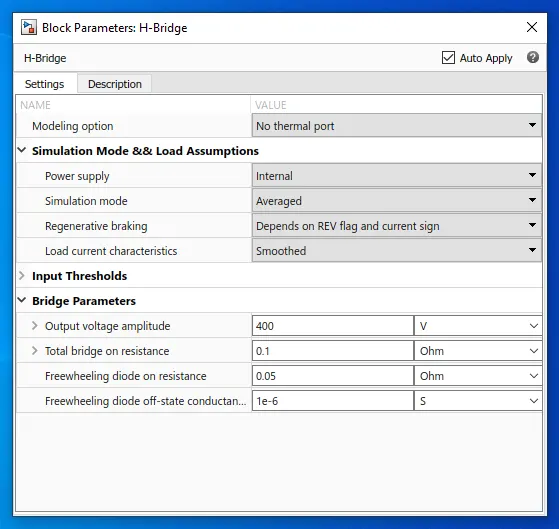
The simulation is kept in the average mode because PWM mode will take longer durations of simulation. In the section on bridge parameters, the output voltage amplitude was modified to 400 volts according to the DC motor.
Controlled Pwm voltage :
Next, I used a 'controlled PWM voltage' to provide a controlled pulse width modulated voltage to the H-bridge block. The pulses of voltage created by this block are dependent on the duty cycle which is the ratio of the time that the switch is ON to the time taken for one cycle. The duty cycle formula is given by:- Duty cycle= Ton/Ton +Toff= Ton /Tcyc. where Ton = On time,Tcyc=Time taken for one cycle.
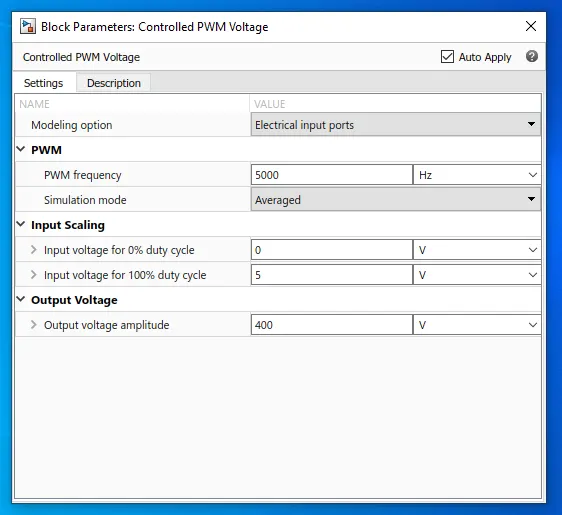
Here all the parameters are set to their default values. I have chosen the averaged simulation mode so that it will feed voltage pulses within quicker simulation times to the H-bridge. The remaining parameters of input scaling and output scaling are unchanged.
Controlled voltage source:
This block provides the necessary voltage that is powerful enough to maintain the voltage at the output regardless of the current that passes through it. In this subsystem @ control, voltage blocks have been used. One block is used for acceleration and the other to provide the voltage for deacceleration.
An electrical reference block is used to create a grounding effect for electrical circuits. In my model, we have used it in 2 parts. First to create an electrical ground between the Controlled voltage source, controlled PWM voltage, and H-bridge blocks. The second is for the battery system which will be modeled afterward.
A solver configuration block is used to solve any necessary equations in a model. I Have used them in the connection to the REV port of the H-Bridge block.
Battery Subsystem:
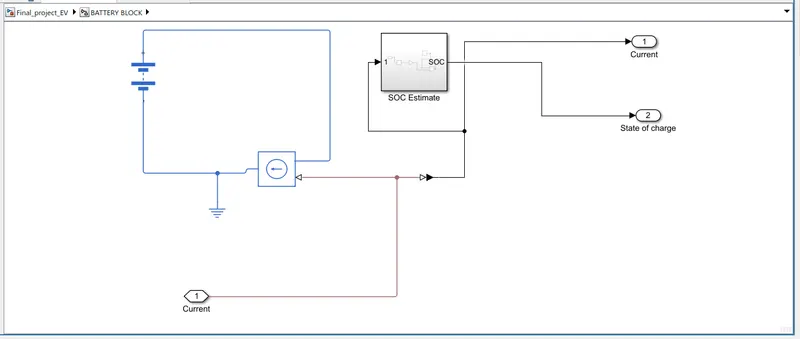
Battery: The battery will be the energy store of the EV and will contain the electrical energy in DC form and provide this energy to operate.
The nominal voltage has been set to 600 volts, internal resistance has been set to 0.2 ohms, and an infinite charging capacity
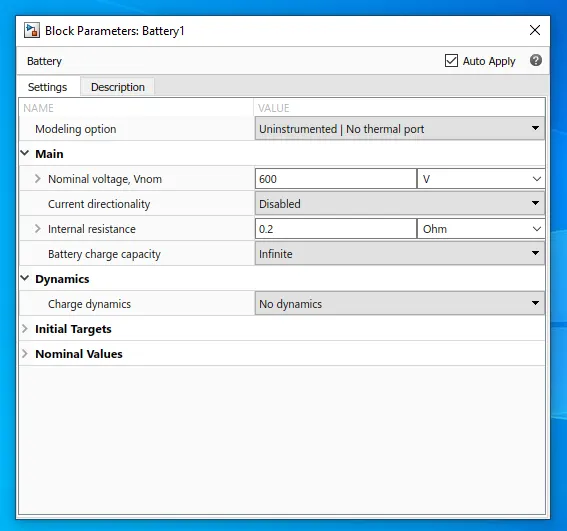
Nominal voltage is sufficient for supplying the voltage to DC-motor and-bridge blocks.
Controlled current source:
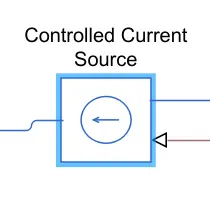
This block is a part of the battery sub-system. Similar to a voltage source, this block produces an ideal current that is powerful enough to maintain the specified current regardless of the voltage across it.
Current sensor:
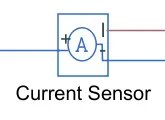
This current sensor block represents an ideal current sensor and is used to convert the current measured in an electrical circuit to a physical signal that is proportional to the current. It measures the current in the battery circuit and the DC motor. The positive and negative terminals across which the current sensor is inserted into the circuit. The third port outputs the physical signal, In my model, it sends the signal to the controlled current source.
SOC (state of charge) estimate subsystem:
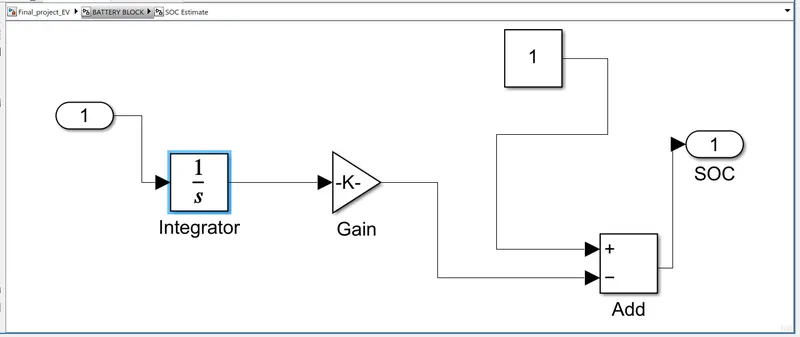
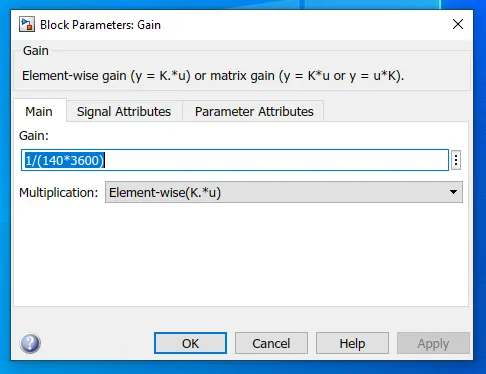
To measure the state of charge of the battery, a sub-system was created of various blocks. The first block is the integrator block used to handle data transfer and integrate the value of the current signal concerning time and next is the Gain block is used to multiply and vide the signal coming from the integrator block. This block will divide the current signal with the ampere rating of the battery which is 140(Ah)*3600(secs an hour). Assuming the battery is always fully charged I have added the constant block with a value of 1 representing 100%. Next, a sum block is used to perform addition and subtraction operations these blocks are made into a subsystem called SOC estimate. A scope block is used at the junction of the PS-Simulink converter block to plot the output signal of the current from the battery.
Block parameters of the gain block:
Speed measurement :
To measure the speed. I have modified the scope block to have two input ports where one port takes the output velocity signal from the vehicle sub-system block and another port takes the output signal from the drive cycle to the reference velocity port on the longitudinal driver block. This has been done to compare the two speeds and check whether they overlap and achieve the same speed.
Distance measurement:
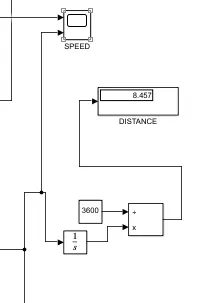
Mathematical blocks and scope block is used to measure the distance traveled by the vehicle. First, we had to implement the integrator block to integrate the velocity signal that is output from the velocity sub-system. A dividend block along with the constant block having a value of 3600 is used to divide the integrated seed. This will give us the distance traveled in kilometers.
Longitudinal driver and drive cycle:
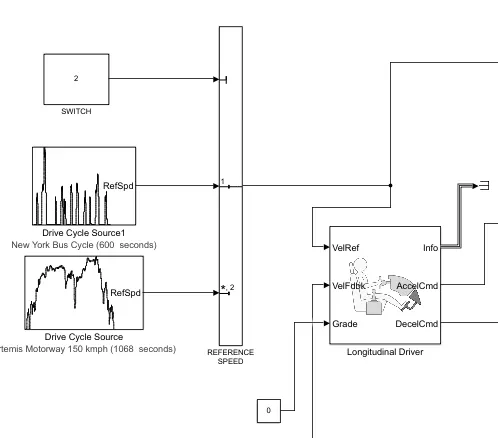
The longitudinal driver block is used for giving normalized acceleration and deacceleration comments to a controller based on two sets of data. The first data is the reference velocity and the second data is the feedback velocity. The reference velocity data comes from the drive cycle source and is compared to the feedback velocity data coming from the vehicle body. If the reference velocity is greater than the feedback velocity, an acceleration command will be given as an output to the controlled voltage source. If the reference velocity is lesser than the feedback velocity, a deacceleration command is given as output to another control voltage source. For the output acceleration and deacceleration commands, I have used a Simulink-PS converter block. In this case, the input signal; is velocity data and this is logic data which have to be converted to a voltage signal The ports in this block are:
- Velref- This stands for the reference velocity and it is the velocity data provided from a drive cycle source.
- Velfdbl- This stands for feedback velocity and it is coming from the vehicle's body velocity port
- Grade- This port provides a grade or inclination angle on which the vehicle is traveling in degrees.
- Info- This port is for the bus signals which consists of block calculations
- Accelcmd- This port provides the acceleration command to a controlled voltage source
- Deacclcmd- This port provides the deacceleration command to another voltage source.
Drive cycle:
A drive cycle is a data set that contains velocity and time data to model the motion of a vehicle. It is a plot of the vehicle velocity against the time and it is made to resemble typical driving conditions that a consumer may experience themselves. For example, here I have used two types of drive cycle data one is the 'newyork bus cycle' and the other is the tArtemisemis motorway of 150kmph'. Drive cycles are for by various testing procedures such as mileage, pollution tests, and acceleration and top speed tests. There are three ways of implementing a drive cycle. One method is to create your drive cycle with a spreadsheet or excel sheet. Another method uses a signal builder and creates signals according to the user and the method that we used is to implement industry standard drive cycles which are previously used to test the parameters of the vehicle.
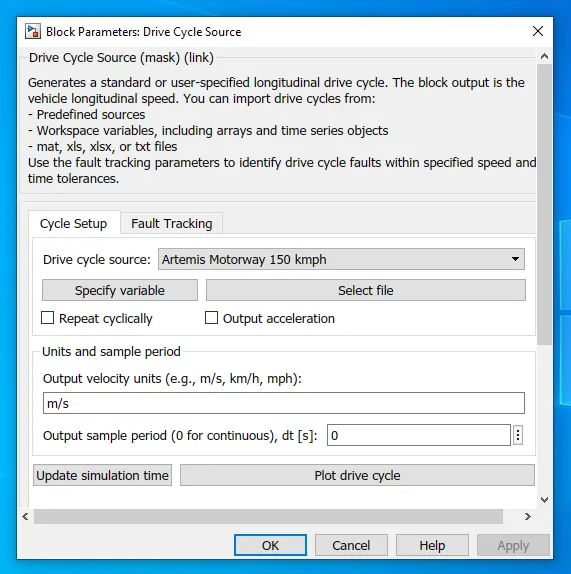
Artemis Motorway 150kmph Drive cycle graph is given as input to the vehicle model-->
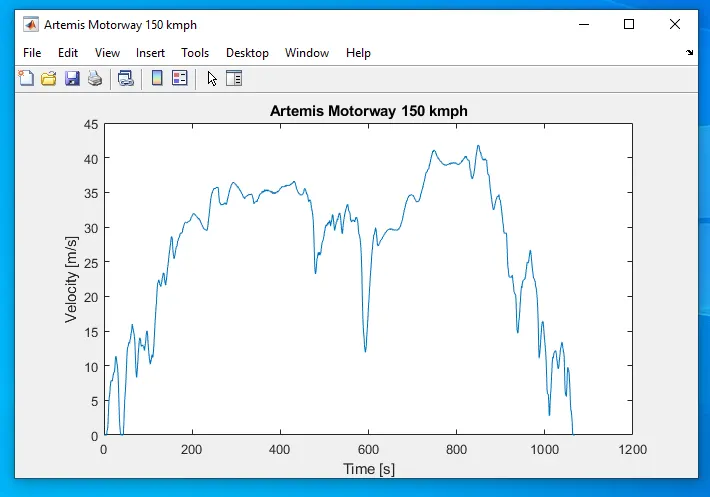
Results: I ran the above drive cycle for my EV model and took the outputs given from speed, current, and SOC scopes. The distance traveled by the vehicle in the drive cycle is also measured using the display block. Before the simulation, the run time was updated according to the drive cycle time of 1068secs.
Speed scope:
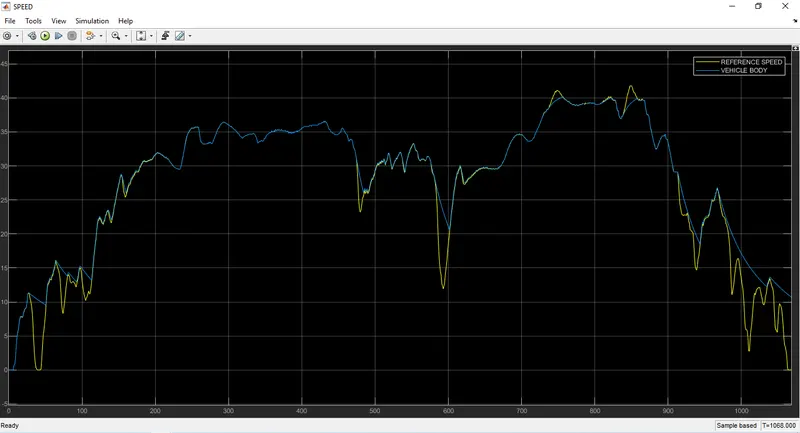
From this scope, we can see two signals. The blue signal represents the vehicle's body speed and the yellow signal is the Artemis drive cycle data. As we can see that the longitudinal driver successfully maintains the drive cycle data process it and controls the vehicle's speed according to the reference speed. the graph overlaps each other effectively during acceleration and deacceleration.
Current scope:
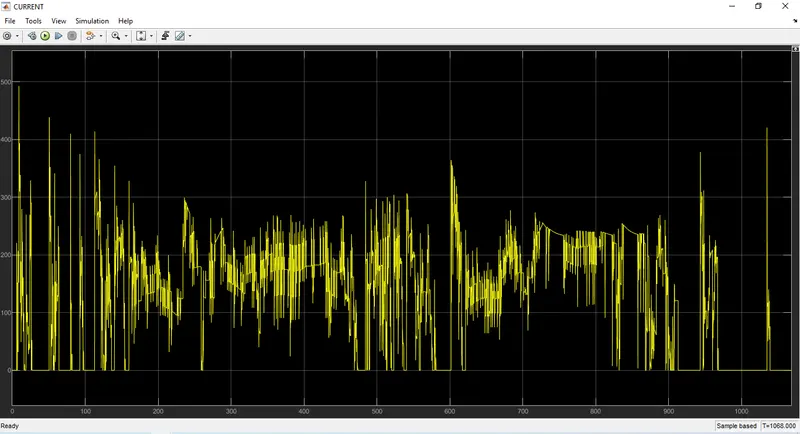
This scope shows how the current flowing from the battery to the motor varies with the drive cycle.
SOC scope:
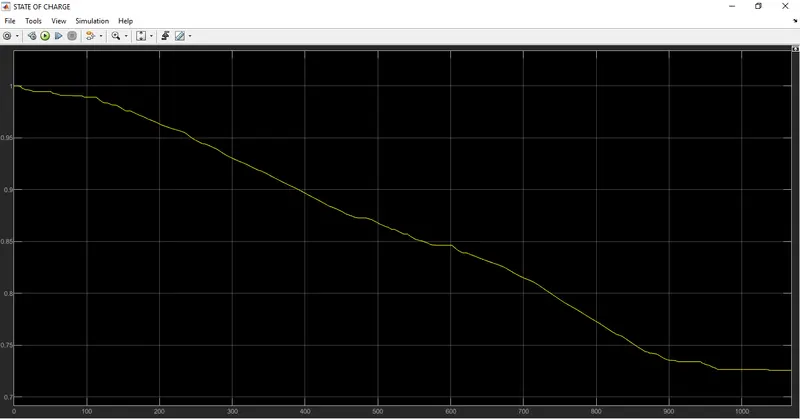
The SOC scope shows how the state of the battery varies over the drive cycle time, The batter was modeled, to begin with, a SOC pof1 that is 100%. As the simulation starts the charge of the battery gets decreased and when the vehicle is in braking mode the uplift in the graph shows that regenerative braking is working to maintain the battery charge. Here we can see that after the whole simulation is over the State of charge percent lies at 75% after 1068 secs.
Distance traveled:
Results: I ran the above drive cycle for my EV model and took the outputs given from speed, current, and SOC scopes. The distance traveled y the vehicle in the drive cycle is also measured using the display block. Before the simulation, the run time was updated according to the drive cycle time of 1068secs.
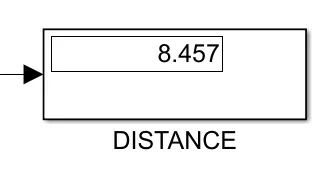
From the above image, the display block measured the distance as 8.457km in 1068secs and charge the remaining 72%.
Conclusion:
The EV model has been created with necessary block components using the SIMULINK software and the model has been simulated for an industrial drive cycle "Artemis motorway 150kmph" The simulation has produced the results of the velocity of the vehicle, the current flowing from the battery and state of charge as well as the distance traveled in the simulation time. The EV model was able to follow the commands given by reference velocities from the drive cycle data. The distance traveled by my EV model was 8.457km which seems to be an appropriate value based on the Artemis motorway drive cycle. The soc of the battery was discharged efficiently to 72% from full charge. This model has also included some features like regenerative braking which was evident in the current scope and state of charge scope. My Ev model has been attached to this report as a .mdl file version R2022a.