Final Project: Design of an Electric Vehicle
Final Project: Design of an Electric Vehicle
AIM -Create a MATLAB model of electric car which uses lithium ion battery and induction motor. Choose suitable blocks from Powertrain block set.
Introduction - The vehicles which get their driving power source from a Battery are known as Pure Electric Vehicles. Whereas the vehicles which uses 2 power sources such as Battery and IC Engine could also be called as Hybrid Electric Vehicles and so on. There are only a few vehicles in our country which come with the option of HEV such as Toyota Prius, Lexus LS 500h, BMW i8. From all these vehicles we have not seen higher demand as they have a higher initial range and the consumers in India usually fall to purchase the cars in the price bracket of 6 to 12 Lakhs and in that range they do not get an option to experience any Hybrid/Electric options.
Advantages of EV.
There are majorly 5 reasons why one should opt for an EV
1. Low Maintenance
2. Eco Friendly 3. Silent operation
4. Low running cost
5. Incentives from Government
Out of all these 5 reasons the major which should be considered before making the decision for vehicle purchase are that the initial cost for an EV might be higher but when the vehicle is used for subsequent years like 3-4 years the initial cost would surely by compensated as the fuel efficiency nearly falls at 1-2 Rs per km as the charging cost per kW in India ranges nearly to Rs 7-15 which includes as Metro Cities and in this range if the vehicle is set at charging the vehicle usually delivers the efficiency of 6-7km per kW of charging. The battery has a life of nearly 10-12 years and then the batteries could be scrapped for a use of any low energy required resource. This in general is going to account for the overall smart purchase as currently the government is also promoting the purchase of EV at higher levels as the EV are the future. Dependency upon Fossil Fuels could not be cosidered for long duration as we do not have an assurance for the cost to remain constant. Taking an example of our country the cost is booming at highest peak and in the coming years it might change as well. The journeys travelled in an EV are worth the ride as it electrifies all your journeys and gives you the joy while driving.
Block Diagram of EV
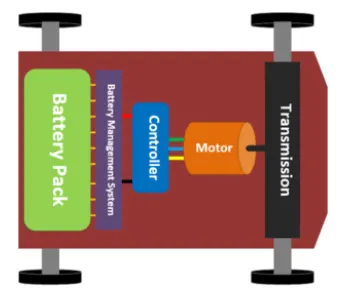
Simulink Model
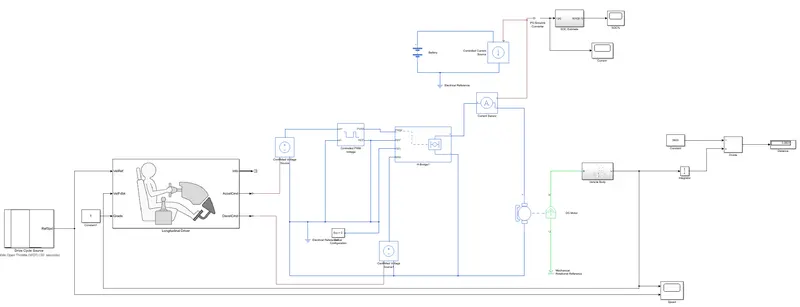
System Level Configuration
To model an EV in SIMULINK, we will need to model the aforementioned components separately and then have them work together. All the main components are available in the library of SIMULINK blocks and we will be adding each component and configuring its parameters to fit the requirements of the model. First, I have modelled the vehicle main body.
Drive Cycle :-
A drive cycle is a data set that contains velocity and time data for the purpose of modelling the motion of a vehicle. The drive cycle will be a plot of the velocity against the time and it is made to resemble typical driving conditions that a consumer may experience themselves in. For instance, they can model highway driving situations, driving in urban areas, or driving with full power etc. Drive cycles are used by automotive companies for various testing procedures such as mileage, pollution tests, and acceleration and top speed tests. There are various different drive cycles that are industry standard e.g. Urban Dynamometer Driving Schedule (UDDS), FTP 75.
In my EV model, a drive cycle is used as the reference velocity data for the longitudinal driver block to send acceleration or deceleration commands according to the drive cycle. There are 3 ways of implementing a drive cycle. One method is to create or own drive cycle with a spreadsheet of velocity data in one column and time data in another column. Another method is to use a signal builder block and create signals that represent the velocities at which the vehicle should travel and the durations for which those velocities are to be maintained. The last method is to use the industry standard drive cycles which are in-built in to the SIMULINK library. In my case, I have used an industry standard WOT drive cycle. This drive cycle stands for Wide Open Throttle' and it models the situation where the vehicle is made to accelerate at full power and maintained at a particular speed and made to decelerate back to rest.
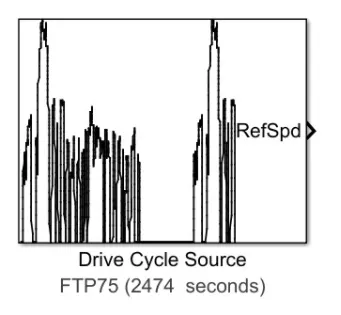
when the WOT drive cycle is chosen some extra parameters are available for modification
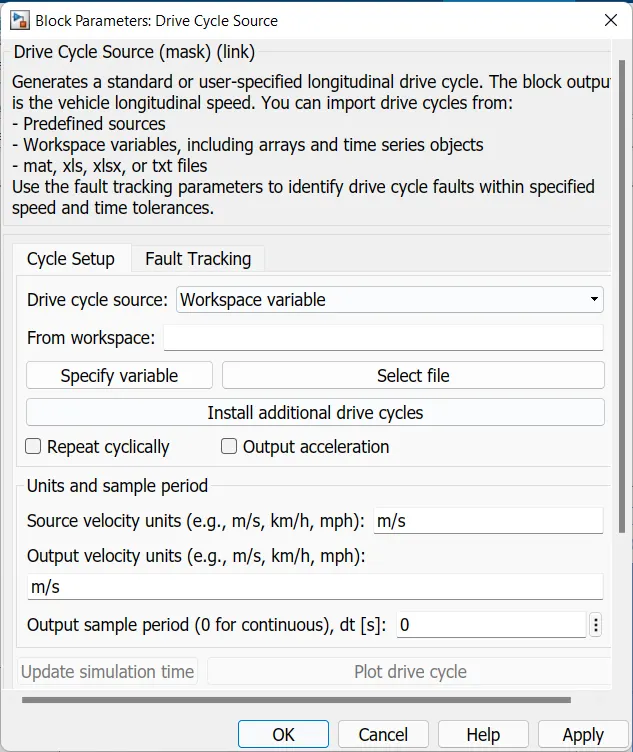
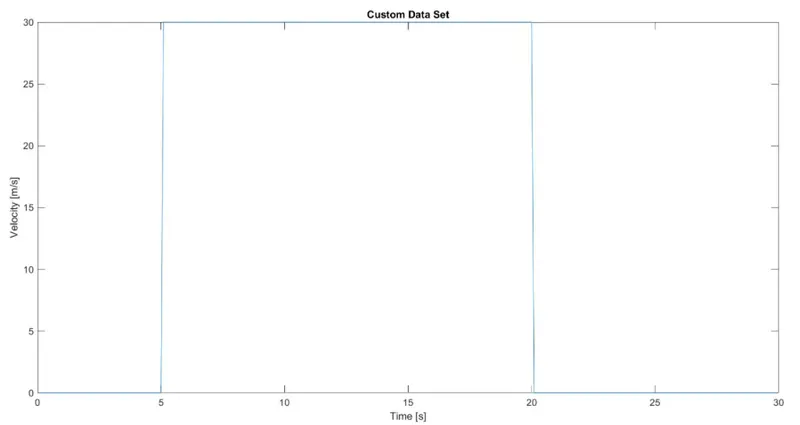
As we can see, with the WOT' drive cycle, we can modify the start time, time to start deceleration and the entire duration of the drive cycle. I have used a start time of 5 seconds meaning that the vehicle will begin acceleration after 5 seconds of starting simulation. I have used a nominal reference speed of 30m/s and this refers to the maximum speed the vehicle should achieve. I have set the deceleration to begin at t = 20 seconds and the whole cycle is set for a duration of 30 seconds. The input and output velocity units are both set to m/s.
The plot below shows the custom WOT drive cycle I have created.
Longitudinal Driver :-
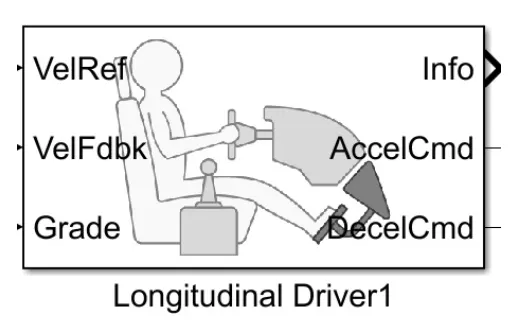
The longitudinal driver block has the following ports:
- VelRef - This stands for the reference velocity and it is the velocity data provided from a drive cycle source.
- VelFdbk - This stands for the feedback velocity and it is the velocity data provided from the vehicle body's velocity port which outputs the velocity data.
- Grade - This port provides a grade or inclination angle for the surface on which the vehicle is travelling in degrees.
- Info - This port is for the bus signals which consist of block calculations e.g. acceleration/deceleration command, difference between reference and vehicle speed.
- AccelCmd - This port provides the acceleration command to a controlled voltage source
- DecelCmd - This port provides the deceleration command to another controlled voltage source.
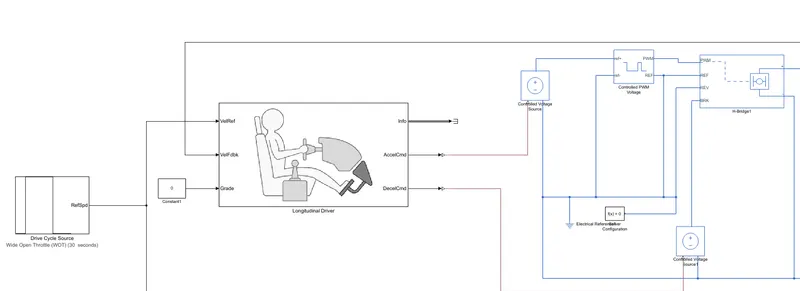
The working of the longitudinal driver block is simple. The reference velocity data coming from a drive cycle source is compared to the feedback velocity data coming from the vehicle body block. If the reference velocity is greater than the feedback velocity, an acceleration command will be given as an output to the controlled voltage source. If the reference velocity is lesser than the feedback velocity, a deceleration command is given as the output to another controlled voltage source instead. For the acceleration and deceleration commands to be given as output signals, I have used a Simulink - PS converter block. This block is needed whenever we wish to connect a Simulink input signal to a physical signal. In this case, the input signal is velocity data and this is logic data which we want to convert to a physical signal i.e.. voltages to the controlled voltage source.
Power Converter :-
The power converter is needed to provide power of the correct form and magnitude from one component to another. In the case of EVs, a power converter is needed to provide a DC voltage from the battery of the EV to the DC motor so that it can operate properly with the required parameters, As mentioned earlier. I have used an H-Bridge motor drive as my power converter. Its block is shown below:
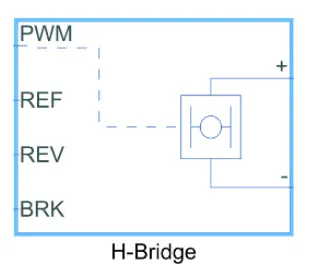
The H Bridge has 2 sides to it: the left side is for the controlling of the voltage signals and the right side is for the terminals to provide the controlled voltage to the DC motor. The left side ports of the H-Bridge block are:
- PWM-This stands for Pulse Width Modulation which will provide the voltage pulses to the H-Bridge either in the PWM or average mode.
- REF-This stands for Reference.
- REV- This stands for Reverse.
- BRK -This stands for Brake.
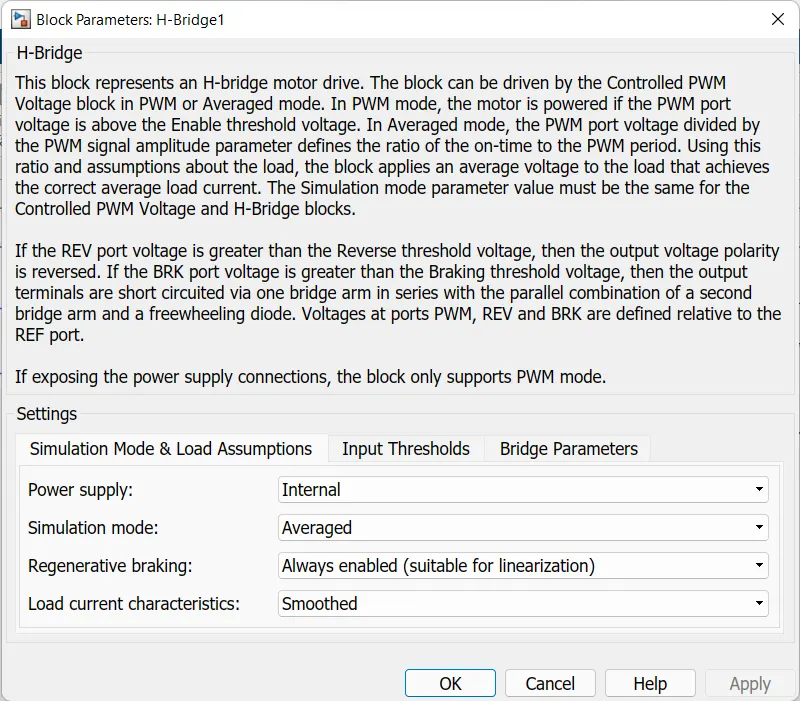
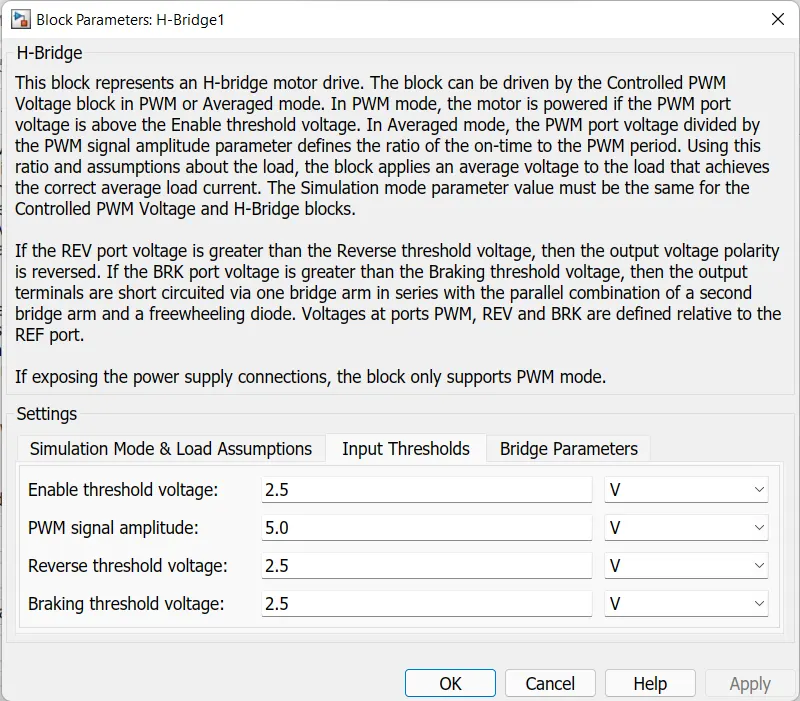
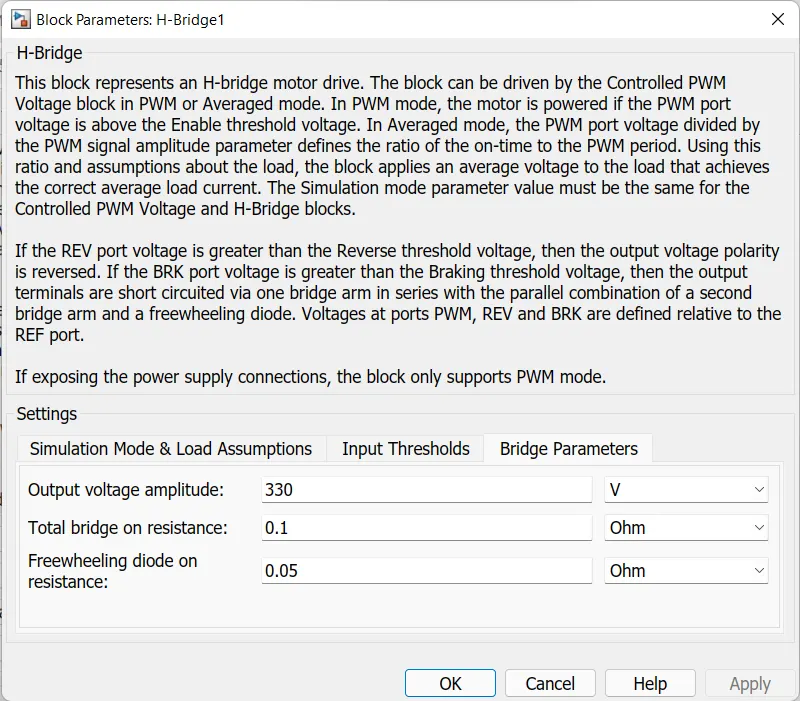
Opening the H-Bridge block will take us to its parameters shown below:
Input Thresholds
Bridge Parameter
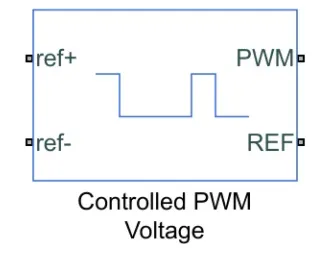
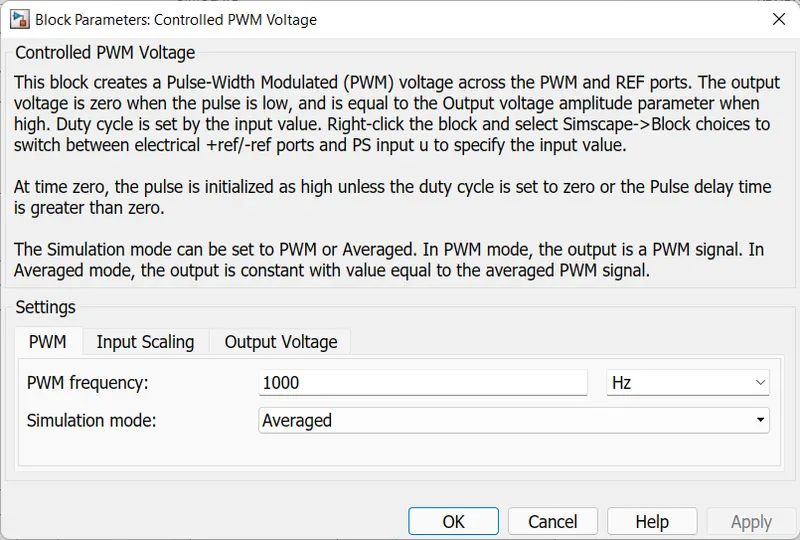
Controlled PWM Voltage
Next, I have used a 'Controlled PWM Voltage' block to provide a controlled pulse width modulated voltage to the H-Bridge block. The block will output the PWM voltage through its 'PWM' and 'REF ports which will feed in to the same ports found on the H-Bridge block. If the pulse is low the output voltage is considered OV whereas if the pulse is high, the output voltage will be equal to the output voltage amplitude which was set to 330V in the H-Bridge block. The pulses of voltage created by this block are dependent on the duty cycle which is the ratio of the time that the switch is ON to the time taken for 1 cycle (which is the time for which the switch is ON and OFF). The duty cycle is set by the input of the controlled PWM voltage block.
Block Parameter Controlled PWM Voltage
Controlled Voltage Source
The input ports of the controlled PWM voltage block are still unconnected and that is because they require a controlled voltage source to provide the voltages to produce the voltage pulses to be fed in to the H-Bridge. For this, I have used the controlled voltage source block. This block is useful because it will provide the necessary voltage that is powerful enough to maintain the voltage at the output regardless of the current that passes through it. This controlled voltage source block is shown below:
In this model, 2 controlled voltage sources have been used. One block is to provide the voltage for the acceleration of the vehicle and the other is to provide the voltage for the deceleration of the vehicle.
This image shown below the electrical Connections:-
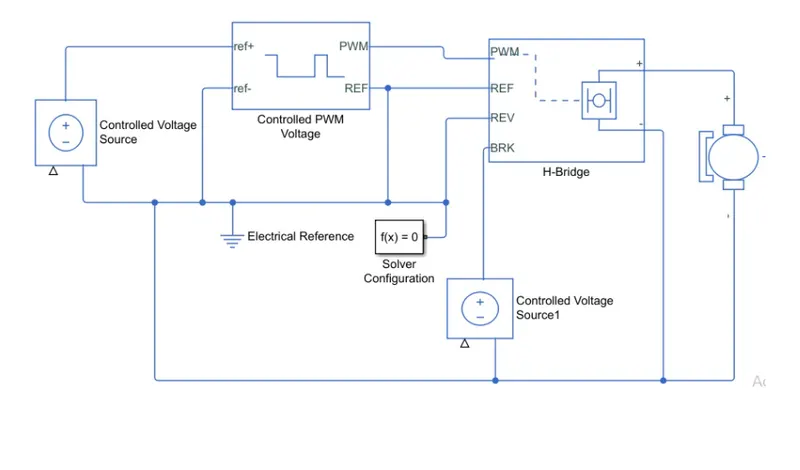
Connection of Drive Cycle , Longitudinal Driver and Other Electrical Block
Vehicle Body
To model a vehicle's body, we need to first add the vehicle body block and this is shown below:
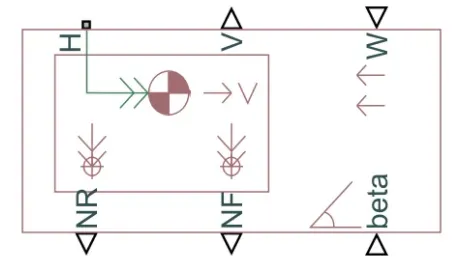
This block contains 6 ports which can be used to model the various aspects of the vehicle body. The ports are mentioned and elaborated
below:
- H - This stands for 'Hub' and is used to connect the hubs of the wheels to the main body of the vehicle.
- V - This is a physical signal output port which stands for 'Velocity and is used to output the speed/velocity at which the vehicle is moving at.
- W - This is a physical signal input port and allows us to model a 'headwind' acting on the vehicle by giving a speed for it.
- NR - This is a physical signal output port to model the rear wheel normal forces.
- NF - This is a physical signal output to model the front wheel normal forces.
- beta - This is a physical signal input port and allows us to model the vehicle on an inclination angle to create the effect of a hill climbing force.
If we double click the vehicle body block, we can see and modify its parameters and this is shown in the image below:
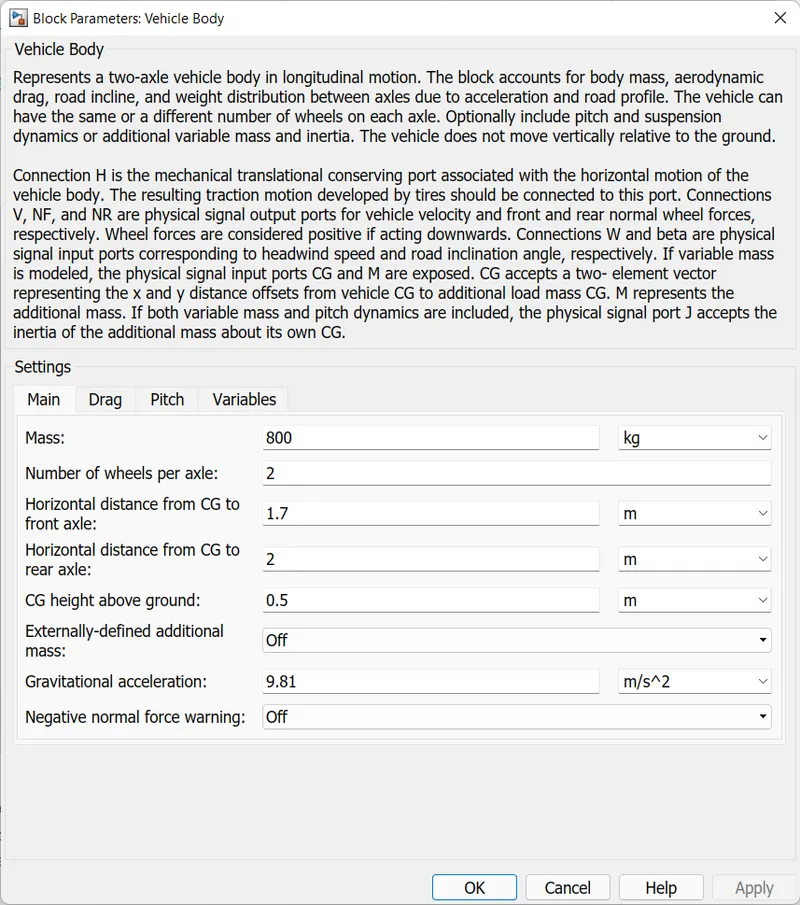
you can see, we are able to modify various parameters of the vehicle body e.g. mass, number of wheels per axle, distance of the center of gravity to the front and rear axles. These are the main parameters and have been left with the default values assigned when the block was added to the workspace. The next tab shows the parameters for 'Drag and this is shown below:
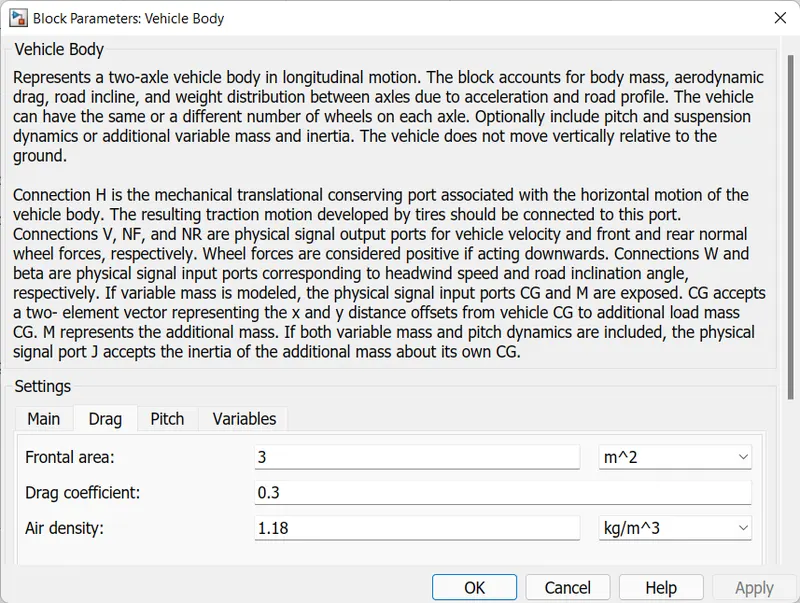
We can see from this image that the parameters of frontal area, drag coefficient and air density can be modified in order to effect the drag force acting on the vehicle. In my case, I have only changed the drag coefficient to 0.3 from the default value 0.4 in order for the model to resemble a typical sedan. Air density and frontal area are normal for this type of vehicle.
Tires
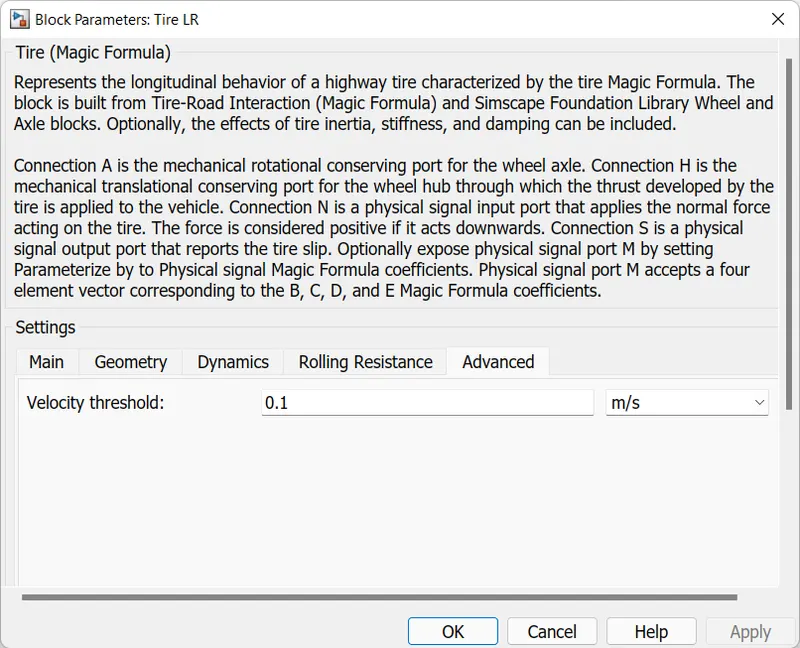
The tires used in this EV model are the 'magic formula' tires. There are several tire blocks that can be used for modelling a vehicle but I have used the magic formula ones because it allows us to model the longitudinal behavior of vehicle tires on highways. They also allow us to model extra effects such as tire inertia, stiffness which allow for greater accuracy of real world conditions. The magic formula tire block is shown below:
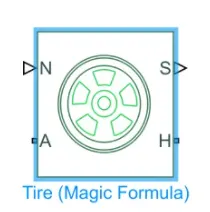
We can see that it has 4 ports and they are:
- N- This port stands for Normal' and is the physical signal input port for the normal force acting on the tire and is considered positive in the downwards direction.
- S - This port stands for 'Slip' and is the physical signal output port is that reports the slip acting on the tire.
- A - This port stands for 'Axle' and is the mechanical rotational conserving port for the wheel axle.
- H- This port stands for 'Hub' and is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tires is applied to the vehicle body.
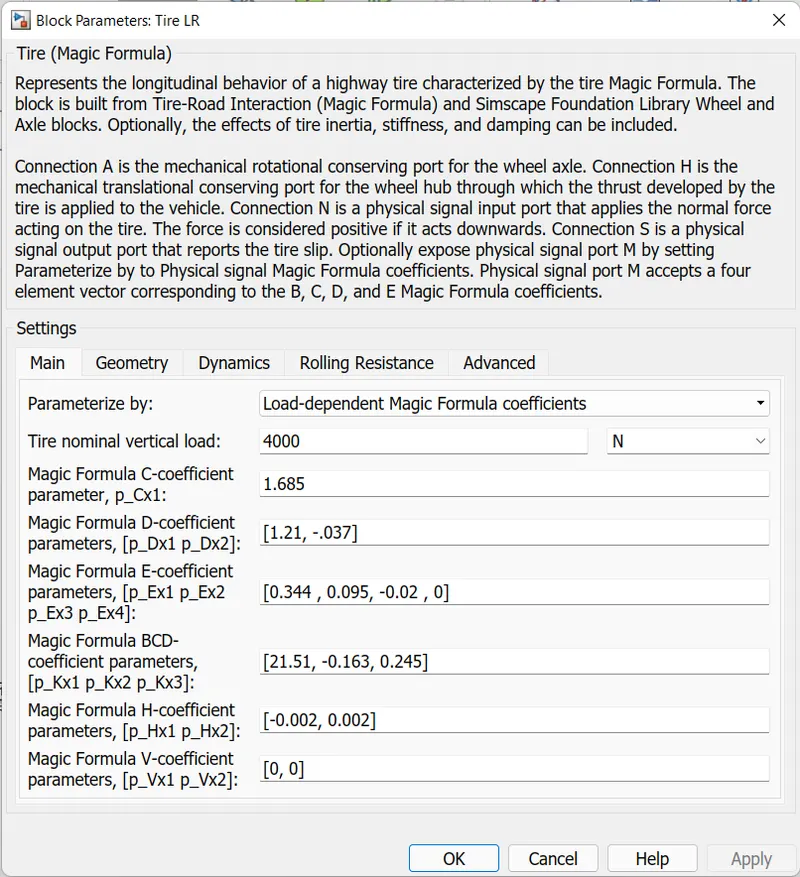
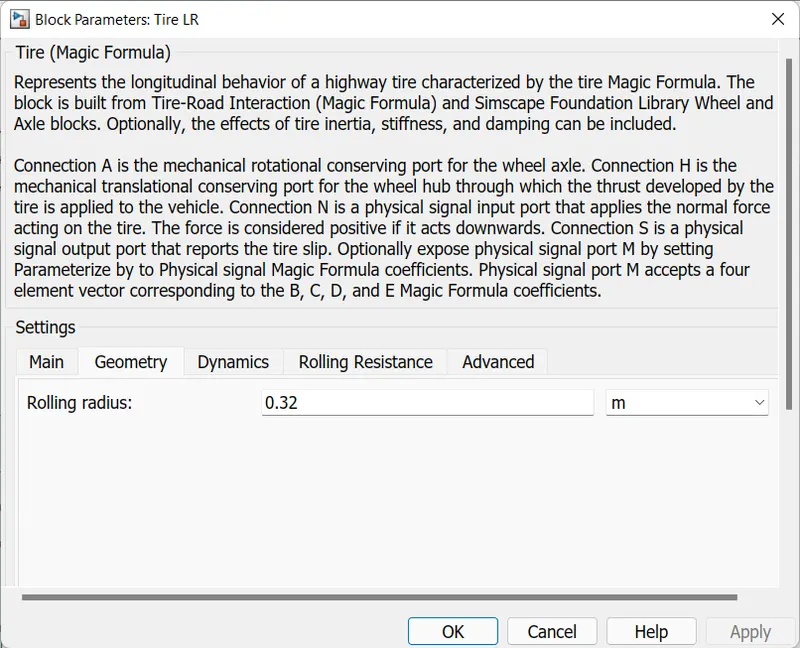
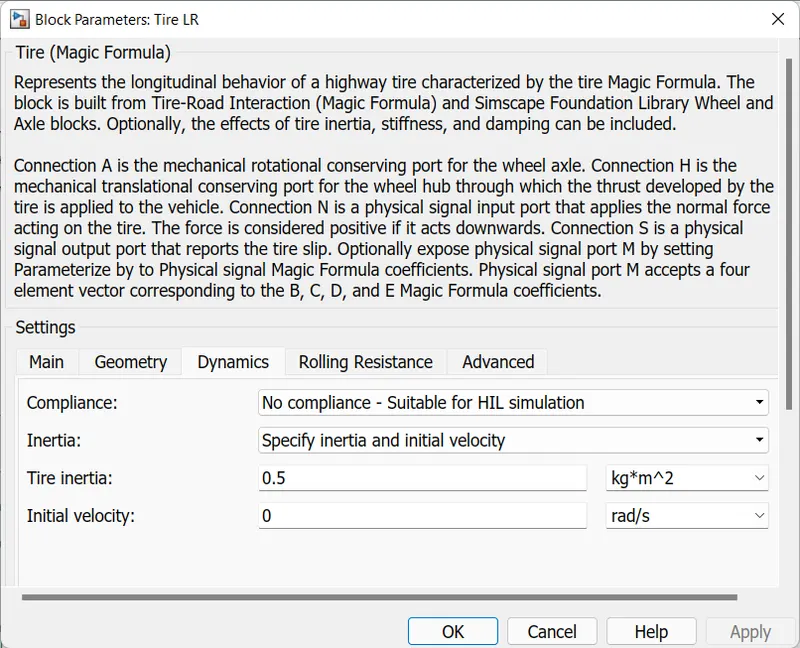
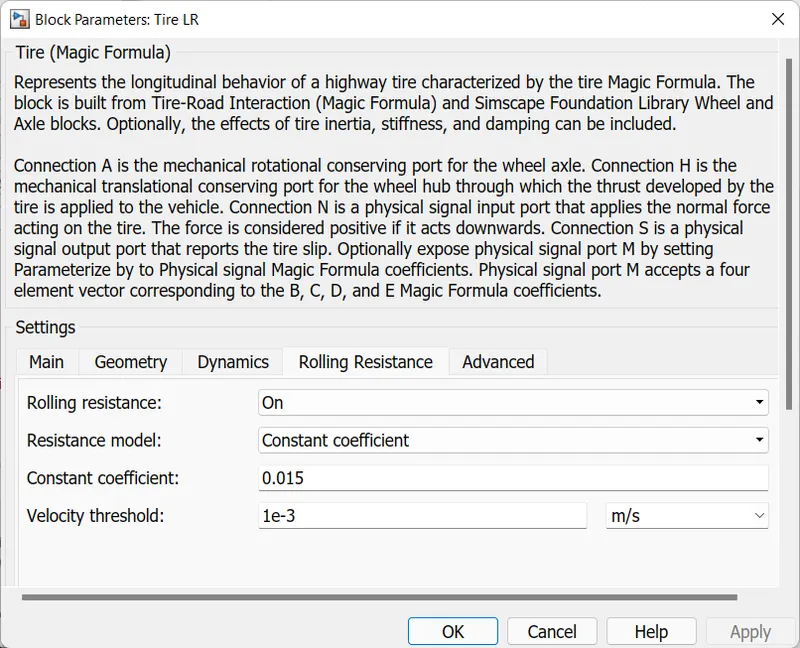
Double clicking the magic formula tire block takes us to its parameters.
Main parameter
The image below shows the settings for the main parameters of the magic
Geometry parameter
Dynamics parameter
Rolling Resistance parameter
Advanced parameter
Gear
Next, we will model the transmission system of the EV. I have decided to use a 'Simple Gear' block so as to simplify the transmission system parameters. This block models a gear system with a fixed gear ratio with no inertia effects, however we can modify the effects of the meshing of the gear teeth. The simple gear block is shown below:
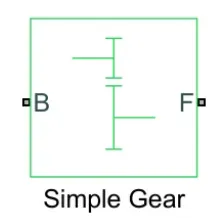
Double clicking the simple gear block takes us to its parameters.
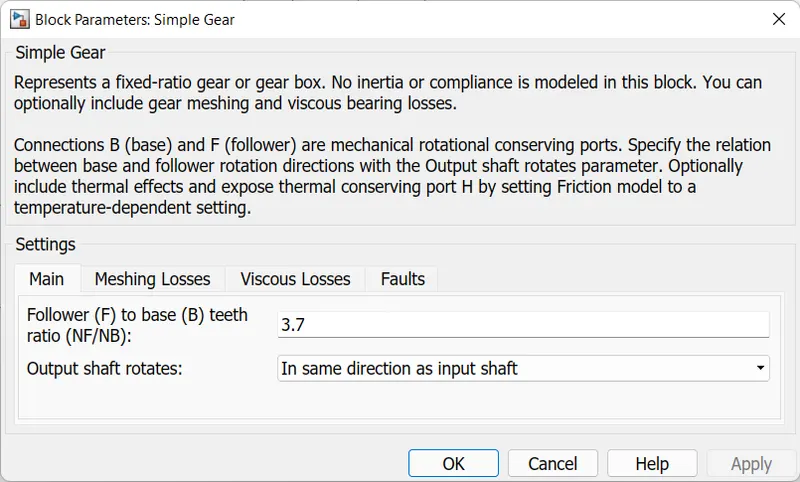
Main parameter
The main parameters of the simple gear are the follower to base teeth ratio and this has been set to 3.7. I have also specified that the output shaft rotates in the same direction as the input shaft as opposed to the opposite direction of the input shaft.
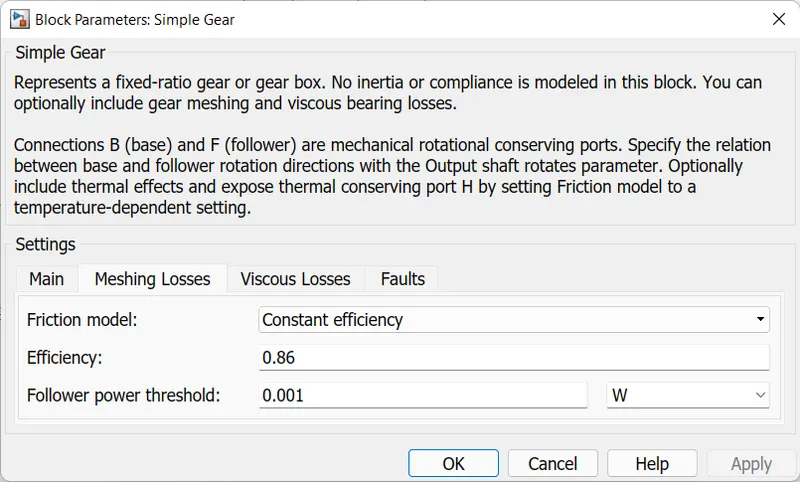
Meshing Losses parameter
The meshing losses I have selected follow a constant efficiency friction model with an efficiency of 0.86 and follower power threshold of 0.001W.
Side Shaft
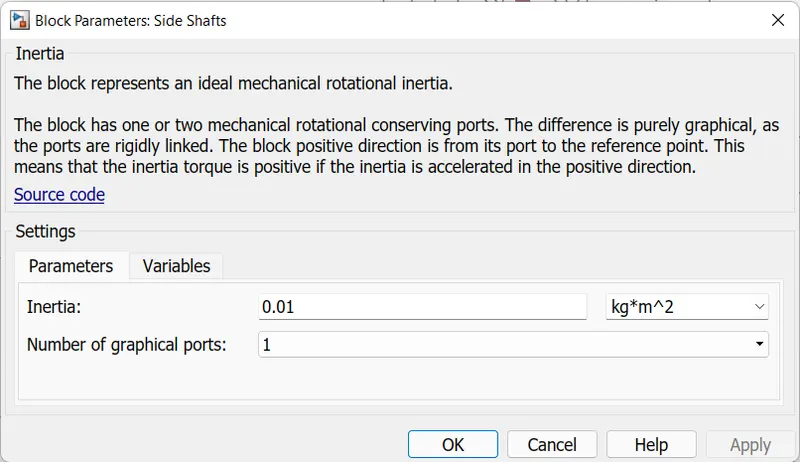
An inertia block has been added to the workspace to provide an ideal mechanical rotational inertia for the simple gear block. This block has: only one mechanical rotational conserving port and the positive direction of the block is from the port to the reference point which would be the simple gear in this case. The inertia torque acts in the positive direction is the inertia is accelerated in the positive direction. The inertia block is shown below:
Wind and Slope
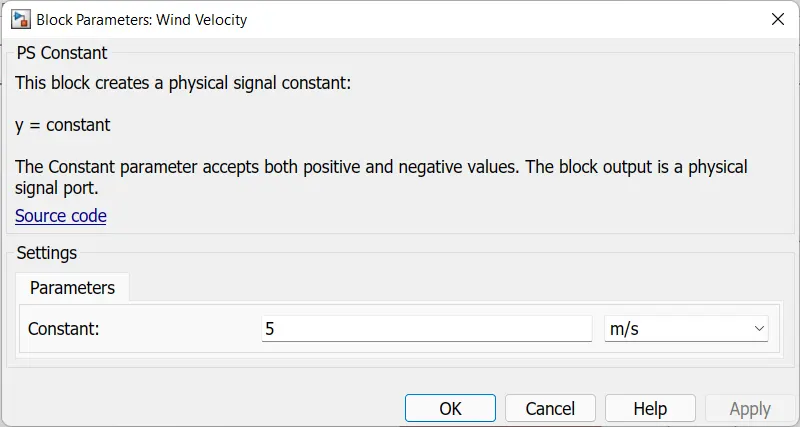
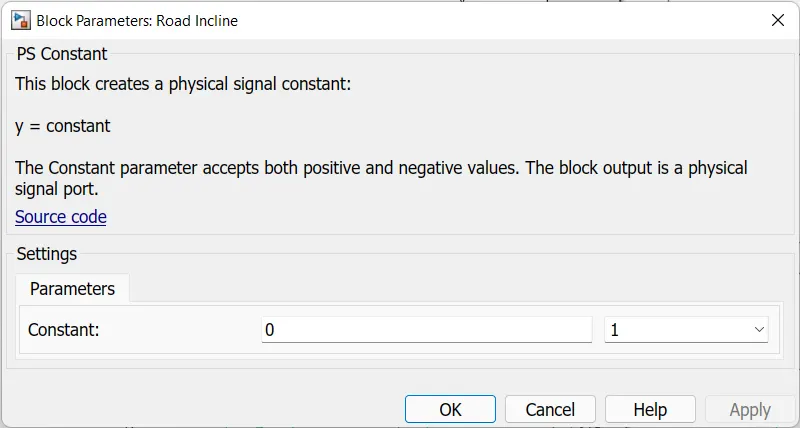
As mentioned earlier, the velocity block allows us to model the effects of wind resistance and road inclination through the 'W' and 'beta' ports respectively. In my model, I have used a 'PS - Constant' block to model the parameters of wind and road inclination on the vehicle's motion. For the wind effect, I have given a constant signal of 5m/s and this acts in the opposite direction to the direction of motion i.e... headwind. For the road inclination, I have given a constant signal of O. The block parameters of the wind and slope effects are shown in the images below:
Road Incline Parameter
Velocity Subsystem
The velocity port which outputs the velocity signal of the vehicle body block has been modified. By default, the velocity signal that is output from the vehicle body block is measured in miles per hour. To change these units, I have implemented a small subsystem from the output of the velocity port. This subsystem uses the following blocks:
- PS - Simulink converter - this block will convert the physical signal of velocity to a logic signal.
- Gain - This block uses a multiplication factor of 1.6 to convert the miles per hour units to kilometres per hour.
- Zero - Order Hold - This block is used implement a zero order hold sample period.
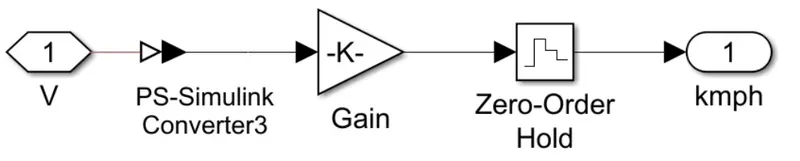
Vehicle Body Subsystem :-
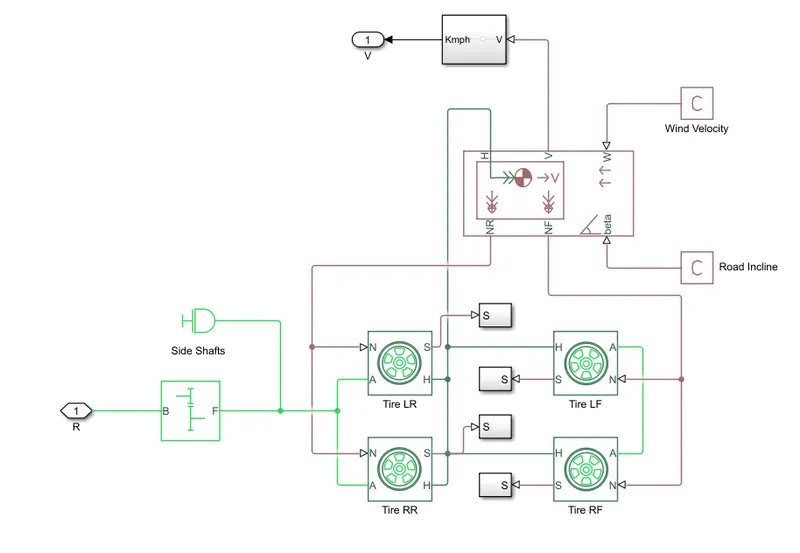
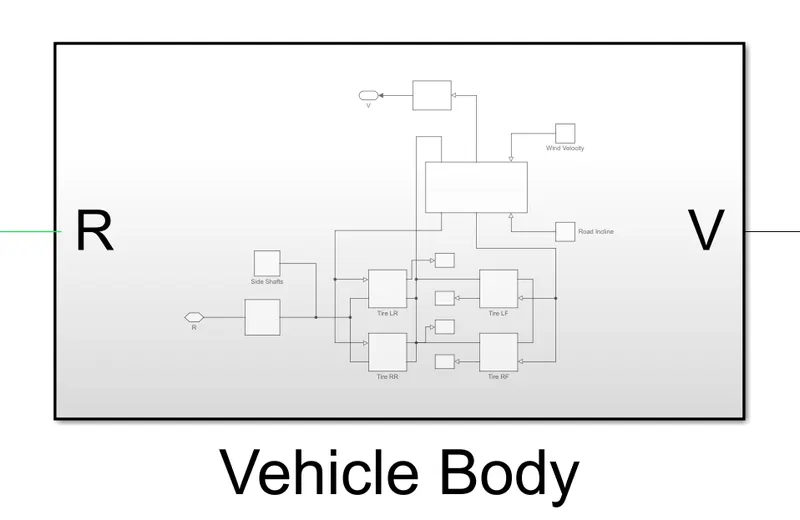
As seen in the diagram above, the various blocks are connected to model the vehicle body. 4 magic formula tire blocks are used as the vehicle will have 4 tires, 2 on each axle. The tires are LR, LF, RR and RF (left rear, left front, right rear, and right front). The normal ports of each tire are connected to the appropriate NR and NF ports on the vehicle body block. The hubs of each tire are connected together and an extra connection is made from them to the vehicle body block. The 'S' ports of the LR and LF tires have been modelled with a slip using a small subsystem. The simple gear and inertia blocks are connected to the axle port of the tires. The wind velocity and road incline are provided with constant physical signals of 5m/s and O degrees respectively. The velocity port has been connected to the velocity subsystem and the connection from the subsystem is open to the 'v' port. The base port of the simple gear has been left open to the 'R' port to take in a rotational signal. If all these connections are made, all of these components can be selected and made in to a subsystem shown below:
Motor :-
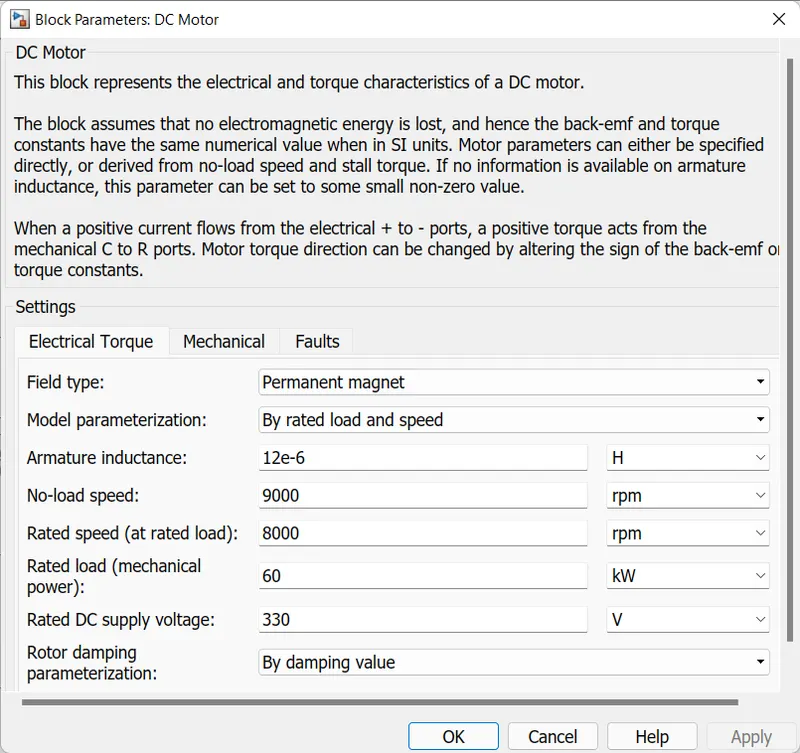
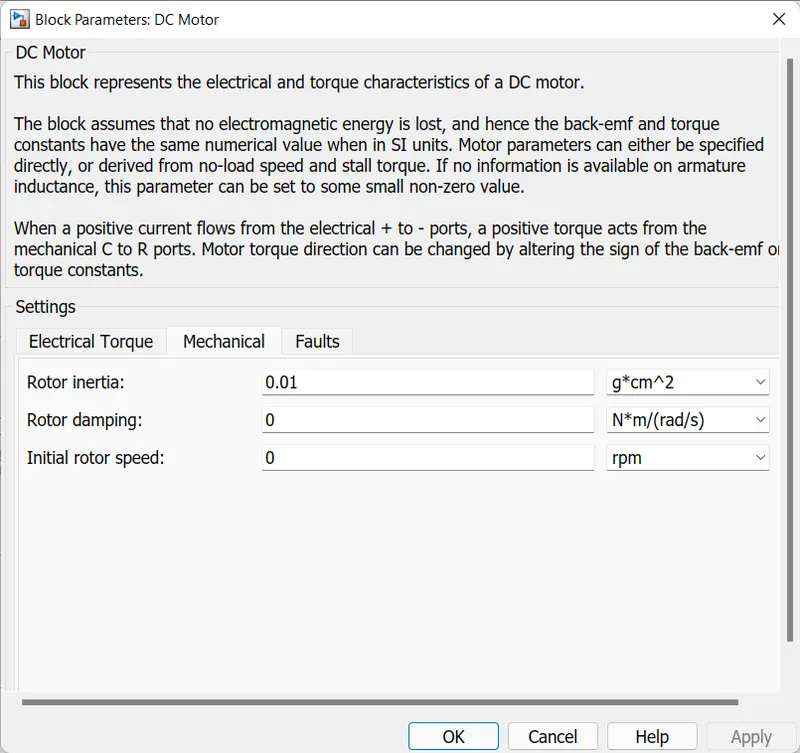
For the EV model, I have selected to use a DC motor block as the motor. This is because DC motors are easier to model and have fewer parameters to modify for a particular application. For this model, a DC motor will do just fine. The DC motor block is shown below:
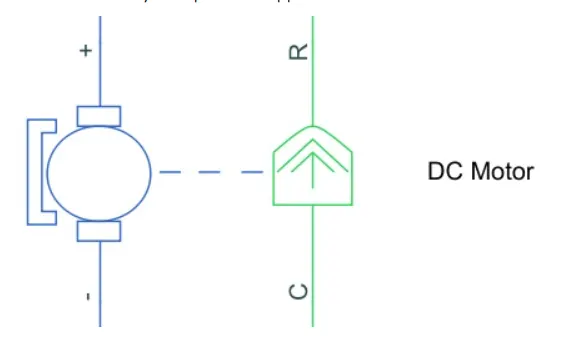
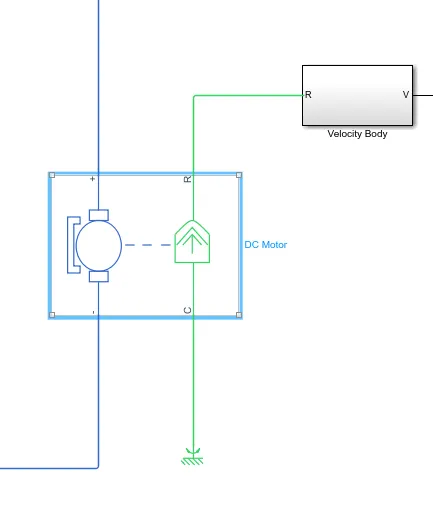
As we can see, there are 2 sides to the block: the mechanical side on the right and the electrical side on the left. The mechanical side has 2 ports, C and R. The C refers to the casing and the R for the rotation of the rotor which produces a torque. The electrical side has a positive and a negative terminal for the voltages to be applied. If a positive voltage is applied to the DC motor block from the positive to the negative terminal, a positive torque will act from the C port to the R port. The direction of the torque produced by the DC motor can be changed by changing the sign of the back emf or the torque constant. The C port of the mechanical side needs to be connected to a mechanical rotational reference because it will be stationary. The R port will be connected to the open connection of the simple gear from the vehicle body block. The positive terminal on the electrical side is connected to the positive terminal of a power converter which in my case will be an 'H bridge.
The mechanical rotational reference block is shown below:
Extenal Torque Parameter
Mechanical Parameter
Connection of DC Motor
Battery Subsystem :-
Battery
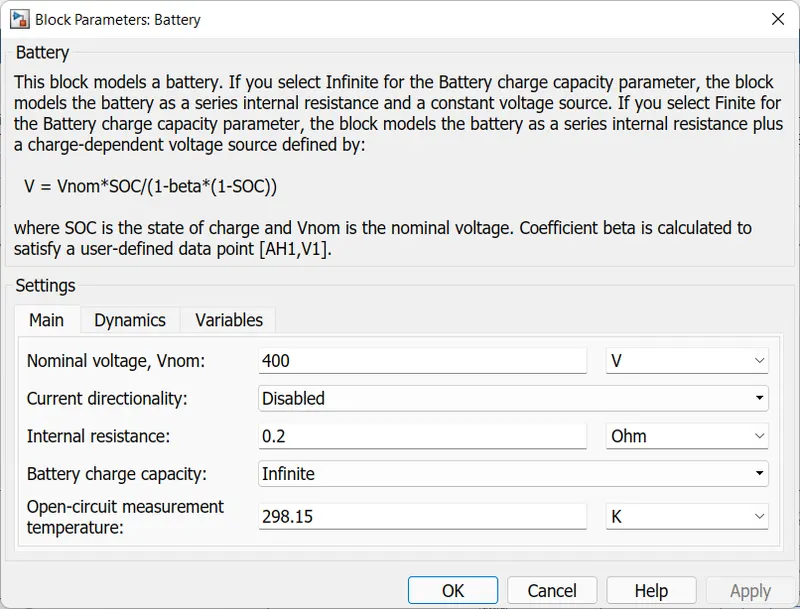
Block Parameters of Battery
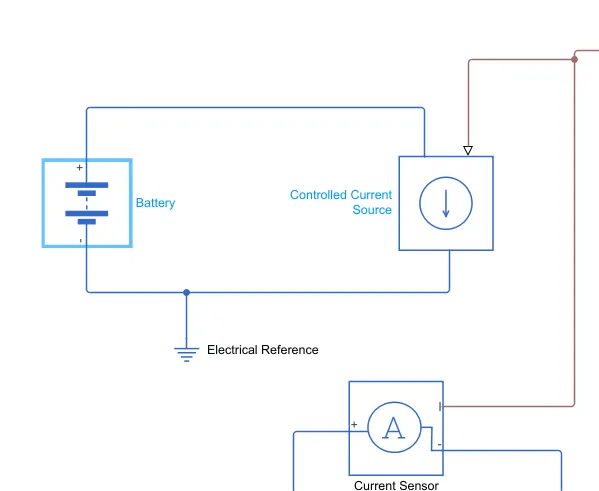
Controlled Current source
Current Sensor
From the image above, we can see that the current sensor is embedded in between the electrical side of the DC motor and the H-Bridge. The current sensor can be connected from its physical signal port to the remaining components in the battery system including an electrical reference block. This is shown in the image below:
SOC & Current :-
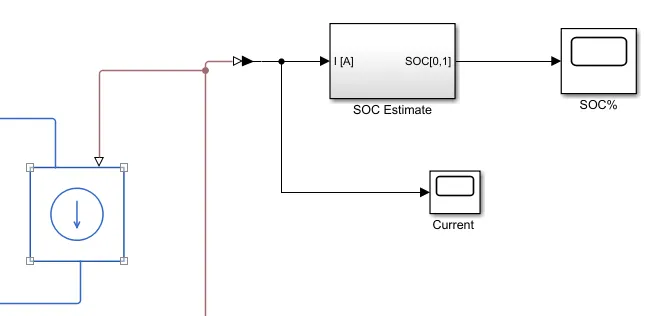
SOC stands for state of charge and it is a measurement of the available charge in a battery. When a battery is fully charged, it is considered to have a 100% charge and conversely 0% charge if fully discharged. In this EV model, I want to measure the current and the SOC of the battery as the simulation is run. For this, I have used a scope block which shows the output signal we wish to measure as a plot against time. 2 scopes have been used, one for the current and the other for the SOC. In order for this to be measured, we need to use a 'PS- Simulink converter' block. This is because the current signal is a physical one and we are measuring it as a logic signal in the SIMULINK workspace.
The PS-Simulink converter block is shown below:
SOC Subsystem :-
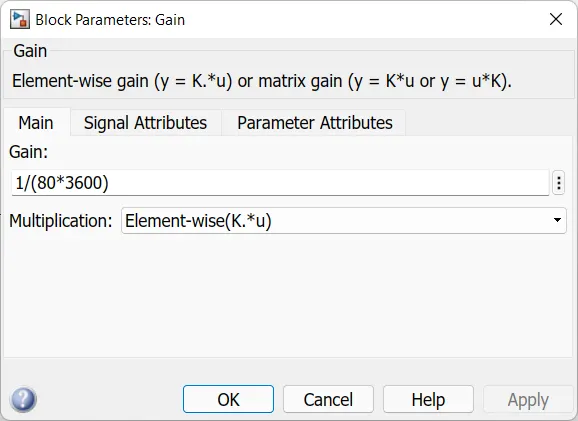
To measure the state of charge of the battery, a subsystem was created of various blocks. The first block is the Rate Transition' block and it is used to handle data transfer between different rates and tasks. Next, a Gain block is used in order to multiply or divide the signal coming from the rate transition block. In this case, the gain block will divide the current signal with the ampere rating of the battery which has been taken as 80Ah multiplied by 3600 (seconds in an hour). This is shown in the gain block parameters below:
Then, a 'Discrete - Time Integrator block is used to perform a discrete integration of the current signal with respect to the time. A constant block is used to represent the initial SOC of the battery. Assuming that the battery is always fully charged when performing simulation, I have altered the constant block with a value of 1 representing 100%. Next, a 'sum' block is used to perform addition and subtraction operations. The signal from the 'discrete time integrator' block will be subtracted from the constant block representing 100% charge. These components are connected as shown below:
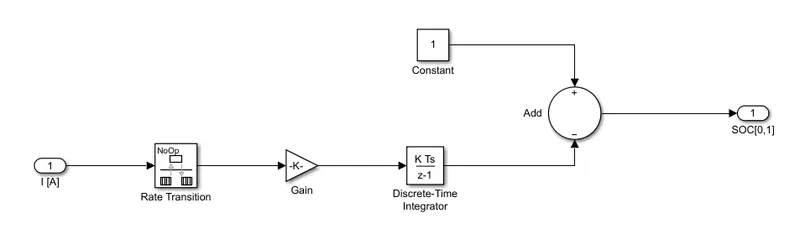
These blocks are then made in to a subsystem called 'SOC Estimate' and linked with the battery circuit using the PS-Simulink converter block. A scope block is used at the junction of the PS-Simulink converter block to plot the output signal of the current from the battery. Another scope is used to plot the output signal of the SOC from the SOC subsystem. This is shown in the image below
Distance and Measurement :-
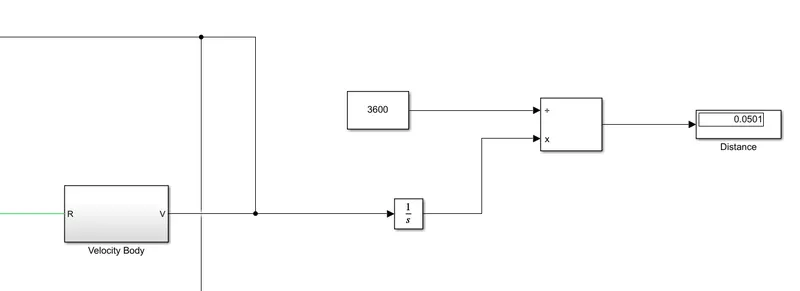
From the image above, we can see that the display block has measured the distance travelled by my EV model for the customized WOT cycle to be 0.0501km. This measurement seems appropriate and correct since the WOT drive cycle is very short in duration and only requires acceleration for half of the drive cycle's overall duration. The area under the velocity time graph tells us the displacement of an object. From looking at the speed scope, a rough calculation indicates that this distance measurement is correct.
Displacement is defined as distance in a given direction and is a vector quantity meaning it has both size and direction. So, if the velocity data in a drive cycle was negative, this would indicate that the vehicle is moving in the reverse direction and this would correspond to a negative displacement. The display block would indicate the same if the velocities in the drive cycle data were of that Nature
Results :-
Speed Scope
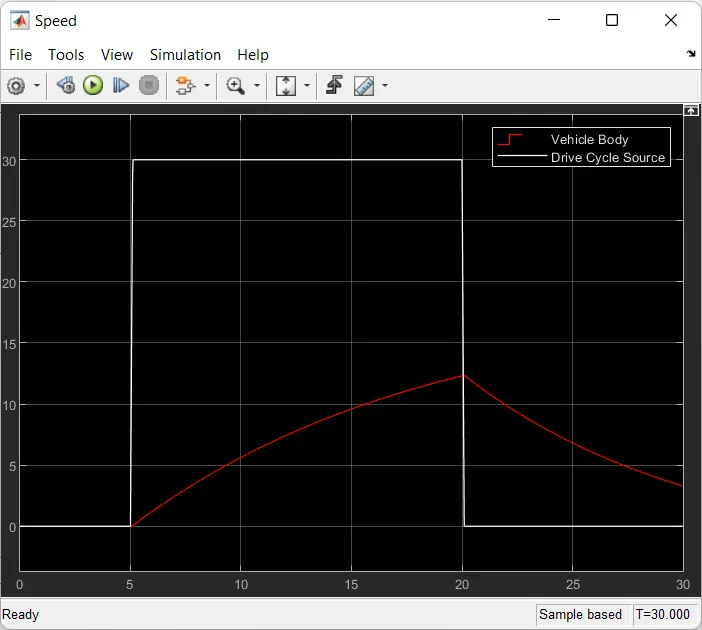
From this scope, we can see 2 signals. The blue signal represents the reference signal which originates from the drive cycle data whereas the yellow signal shows the actual velocity of the vehicle. The WOT drive cycle had been customized so that the vehicle begins acceleration under the WOT condition (i.e. full power) at t = 5 seconds. This is supposed to be maintained till t = 20 seconds when the vehicle is supposed to begin deceleration. From t = 20 seconds to t = 30 seconds, the vehicle speed is back to Om/s i.e.. rest. Because this is a reference signal, all the commands are instantaneous. This is why the increase and decrease in speed is very sudden within a fraction of a second. However, this effect will not be observed on the actual velocity of the vehicle. This is because in real world conditions, there are more considerations to factor in which will not make it possible for a vehicle to accelerate and decelerate as instantaneously as the drive cycle commanded. In the real world, the effects of rolling resistance, drag and road inclination make a difference because their presence would cause the vehicle's motion to deviate from the drive cycle commands. Other factors include, the vehicle's inertia and the inertia of the transmission system.
Observing the vehicle's actual velocity, as commanded, the vehicle begins at rest before accelerating under the WOT condition at t = 5 seconds. This acceleration is maintained till t = 20 seconds as the drive cycle commanded. At t= 20 seconds, the vehicle achieves a top speed of 26.8m/s. After t=20 seconds, the vehicle begins to decelerate gradually till t = 30 seconds where the vehicle finishes with a velocity of approximately 7m/s. As mentioned earlier, the actual velocity could not match the drive cycle commands perfectly and this is due to several factors which were discussed above. In my model, I have not modelled a road inclination but I have used a wind velocity of 5m/s. I compared the effect of this wind resistance on the top speed of the vehicle to when there was no wind resistance. The effect was very insignificant, only affecting the top speed by 0.5m/s. However, the vehicle velocity has accelerated and decelerated as the drive cycle commanded. Obviously, the model is limited to the simulation tirne allotted. So if a longer simulation time is used, the vehicle may reach a higher top speed and may even decelerate back to rest.
Current Scope
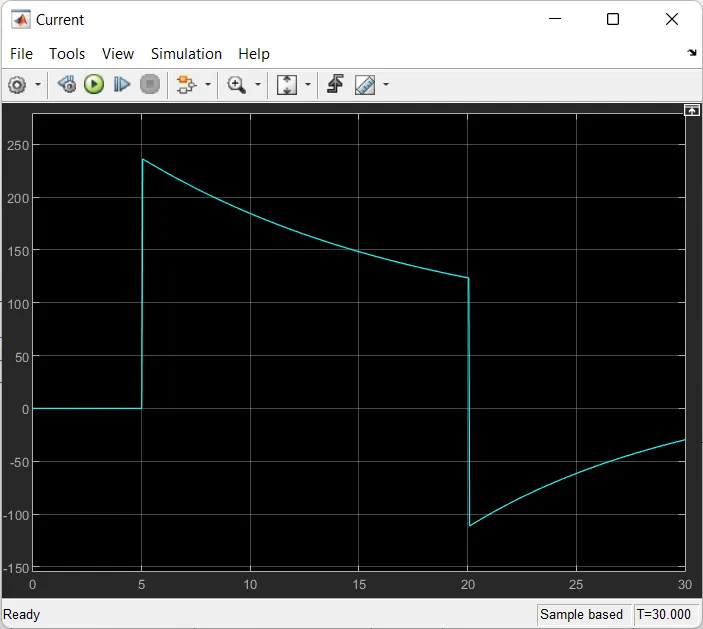
The current scope shows how the current flowing from the battery to the motor varies with the drive cycle time. As we can see, initially the current flowing through the circuit is OA and this corresponds to the drive cycle commanding the vehicle to be at rest for this time period. At t = 5 seconds, when the vehicle is commanded to accelerate, the current instantaneously increases to a maximum current of 235.8A. This maximum current is achieved because at t = 5 seconds, the vehicle accelerates at maximum power under the WOT condition and so this will demand a high current from the battery. From t = 5 seconds to t = 15 seconds, the current decreases gradually to 134.3A. The current must have decreased over time because as the vehicle was accelerating, it required lesser current from the battery to continue accelerating. The highest current is always required when accelerating from rest due to the inertia of the vehicle. But once the vehicle is already in motion, it requires significantly lesser energy to continue accelerating. From t = 15 seconds to t = 20 seconds, the current flowing from the battery decreases more rapidly to 85.6A. This is because at this time, the acceleration of the vehicle began to level off meaning that the increase in speed in those 2.5 seconds was lesser than the increase from t = 5 seconds to t=15 seconds.
After t = 20 seconds, the vehicle decelerates, causing the current to drop instantaneously to the negative axis to a value of -107.4A. There is now a negative current flowing due to regenerative braking. When the vehicle decelerates, the throttle is no longer applied and so the kinetic energy from the motion is converted to electrical energy fed back to the battery of the EV. This reverse flow of current is what causes the negative current measurement. From t = seconds, the deceleration continues, however the current flowing through the battery decreases in magnitude. This is because at t = 20 seconds, the vehicle had reached its top speed and hence its maximum kinetic energy. So, at that point there was more kinetic energy which could be converted to electrical energy for regenerative braking. However, as the vehicle decelerates, there was lesser energy available for regenerative braking causing the magnitude of the current to decrease. The polarity of the current hence moves towards the positive direction because regenerative braking happens lesser and lesser until the vehicle comes to rest. At t = 30 seconds, the vehicle is still decelerating and finished with current measurement of -27.9A showing that regenerative braking is still occurring.
SOC Scope
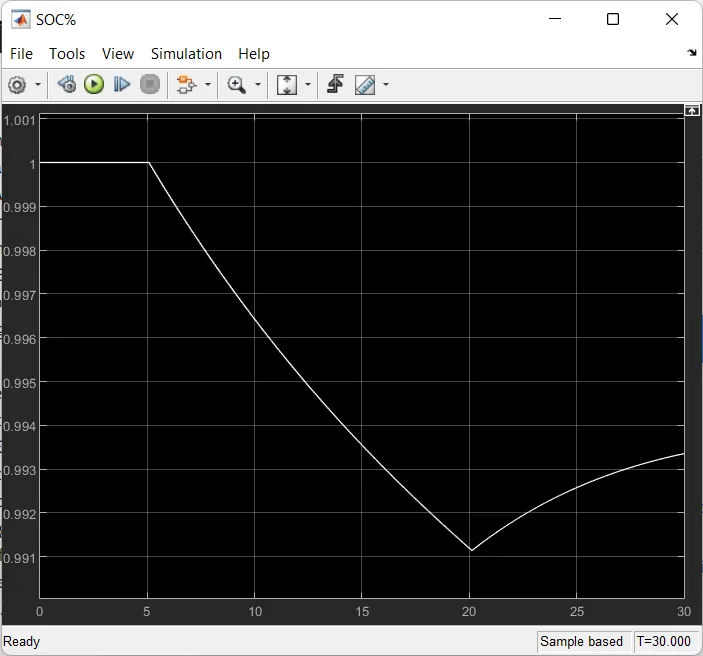
The SOC scope shows how the state of charge of the battery varies over the drive cycle time. The battery was modelled to begin with an SOC of 1 (100%) and so when the simulation begins, the SOC is at 1 until t = 5 seconds. This is because the drive cycle commands the vehicle to be at rest for that duration and so no discharge occurs from the battery. At t = 5 seconds, the vehicle is commanded to accelerate under the WOT condition and so the SOC of the battery decreases. Because the vehicle is accelerating at full power, the SOC falls from 1 but the rate of discharge decreases over the acceleration period eventually settling at a minimum SOC of 0.9914 at t = 20 seconds. This corresponds to the current flow from the battery because as the vehicle accelerates, lesser energy is demanded to increase the speed. As mentioned before, the greatest discharge occurs when the greatest current flows from the battery and this is during the initial acceleration period. As the vehicle speed increases, the acceleration decreases causing the current and hence the rate of discharge to decrease but in a mild fashion. At t= 20 seconds, the vehicle is commanded to decelerate and so the vehicle velocity decreases. This results in regenerative braking to occur which causes a negative flow of current back to the battery. Because this effect charges the battery, the SOC of the battery. increases during the deceleration period. The SOC increases very gently from 0.9914 to 0.9935 and this is because the gets charges by the regenerative braking effect. The negative flow of current corresponds to the increase in the SOC of the battery. Since the vehicle is commanded to decelerate until t = 30 seconds, the vehicle speed decreases but does not reach Om/s, so the vehicle is under regenerative braking for the entire period after t = 20 seconds.
Conclusion
In conclusion, the EV model has been created with the necessary block components using the SIMULINK software and the model has been simulated for a customized WOT drive cycle. The simulation has produced results of the velocity of the vehicle, current flowing from the battery, and the SOC of the battery as well as the distance travelled by the EV. Since the EV model was parameterized to simulate averaged voltage pulses in the H-Bridge and Controlled PWM voltage blocks to be fed in to the DC motor, the simulation was run very quickly within a matter of seconds. The EV model was able to follow the commands given by the reference velocities from the drive cycle data, although it could have followed the reference signals more closely. The discrepancy between the reference velocity and actual velocity of the vehicle may be attributed to a variety of factors e.g. vehicle inertia, transmission system, transmission inertia. If the EV model was designed in such away as to improve upon those factors, the model would follow the reference signals more closely and would improve the performance charactenstics as well. The distance travelled by my EV model was measured at 0.0501km and seems to be an appropriate value based on the WOT drive cycle used.
I had observed that the SOC of the battery used in my EV model did not get discharged in a way I had expected it to. This could be because the drive cycle commands did not push the EV model to its limits or it could be due to the fact that the battery model was very efficient and was suitable for the driving application. My EV model had also included some actual features of EVs such as regenerative braking and this was evident in the current-time and SOC-time graphs whenever the EV decelerated. If the duration of the WOT drive cycle was modified to be longer, I could have seen my EV model exhibit its true performance characteristics. For instance, the EV model may achieve its top speed and it may also have been possible to see the time it takes for the vehicle to decelerate from that top speed and hence the time taken for the acceleration e.g. 0 to 60 kmph.
My EV model has been attached to this report as a six file along with the velocity, current and SOC plots obtained from their respective scopes.