Assignment 7-Side Pole Crash Simulation Challenge
Aim: To run a simulation for the neon slide pple crash and to obtain the results in the post processing.
Objective:
- To check the unit system in the solver.
- To create an appropriate interface with friction 0.2 and recommended parameters.
- To check for the penetrations and intersections in the component.
- To create cylindrical rigid wall with a friction 0.1.
- To add extra mass to attain a target mass of 700 kg.
- To apply initial velocity to the car.
- Keep the min time step of 0.1 micron sec and max of 0.5 micro sec.
- Run the model up to 80 milliseconds.
- To find the sectional force in the cross member.
- To calculate the intrusions at the b-pillar,hinge pillar and fuel tank region.
- To calculate the peak velocity of an inner node of the door.
- To request TH for all the inputs created.
- To run the simulation.
- To plot the graphs in the post processing.
Theoretical framework:
- A side collision is a vehicle crash where the side of one or more vehicles is impacted.These crashes typically occur at intersections and in parking lots and when two vehicles pass on a multi-lane roadway.
- In the side pole impact collision cases,when the car gets crashes to the pole the load goes transferred to the car.So because of the load,it starts to deform and its contact with dummy pelvis location.Pelvis location and orientation are important aspects of a ehicle accupant's posture.Measurements of driver's or passenger's pelvis locations are used for ergonomic or crush safety studies such as the development of posture prediction models,analysis of lap belt fit and development of computational human models.
- Due to this structure to pelvis contact,the load has transferred to the occupant.As only a very small crumble zone is available during a side pole impact,so we have to ensure that the impact forces are distributed over a wide area.The B-pillars and side members along the flanks of the vehicle are mainly responsible for this.
- The impact forces are transferred from B pillar to the opposite side of the vehicle first and foremost via the transversely rigid seat and the centre console.A further load dissipation path runs from the base of the pillar to cross member under the seat and transmission tunnel braces.
- As per baseline study,identified the important load transfer path members are B-pillar and its reinforcements,roof bows,sill,transfers cross members.These parts stiffness increased by the way of design change and material grade up.
- In this test,we are going to give the vehicle to be 24km/h and we are going to take the diameter of the pole to be 254mm as the standard diameter value according to the FMVSS 214 standards.
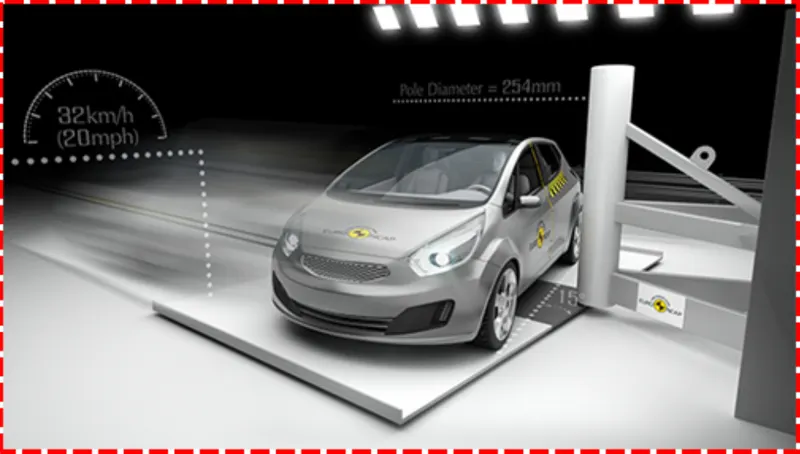
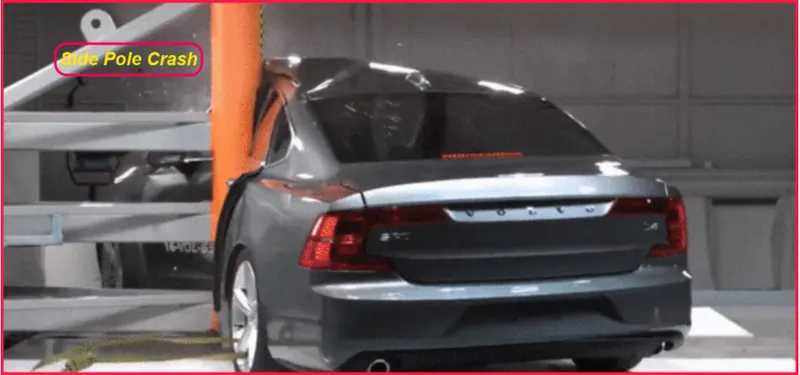
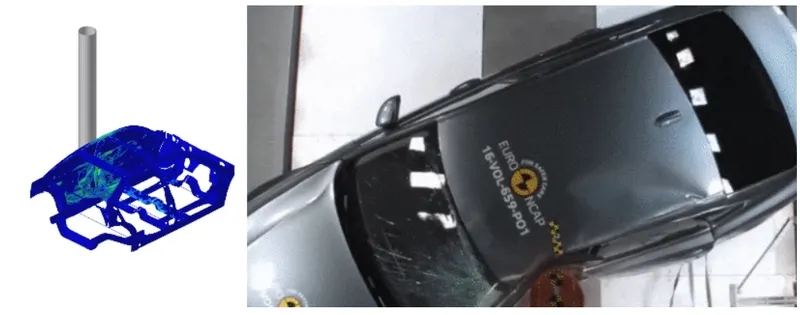
[Note: According to FMVSS {Federal motor vehicle saftey standard},Assign a initial velocity of 20mph,1mph=0.44704 m/s=20x0.4470= 8.94 m/s]
Procedure:
Phase 1- Check unit system and either follow [Mg mm s] or [Kg mm ms]
- While opening hypermesh software,A user profile window will pop up,switch to the radioss user profile as shown in below figure and start importing the model into the solver deck.
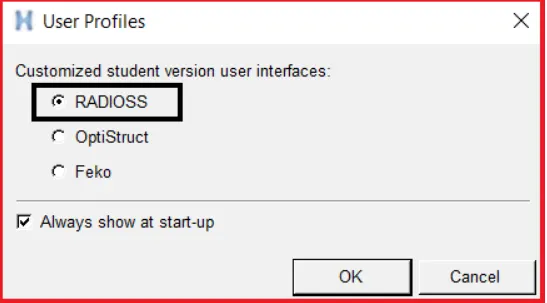
- Now after switch the user profile to radioss,import the model into the radioss solver deck.
- To import the model,go to standard panel>>import>>import solver deck.
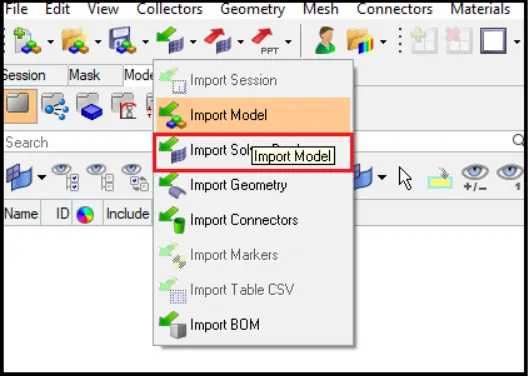
- Import solver deck option should be selected to import the radioss starter file.
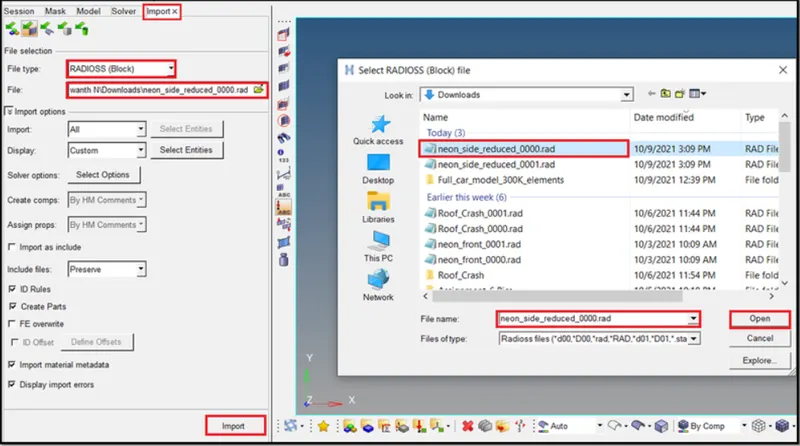
- Here the import browser will appear as shown in above fig,select the appropriate starter file to import into GUI.
- Switch the file type to radioss block and import the model into GUI.
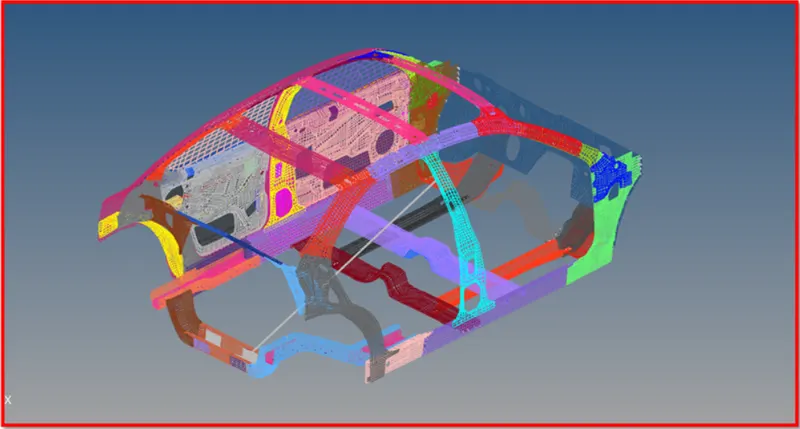
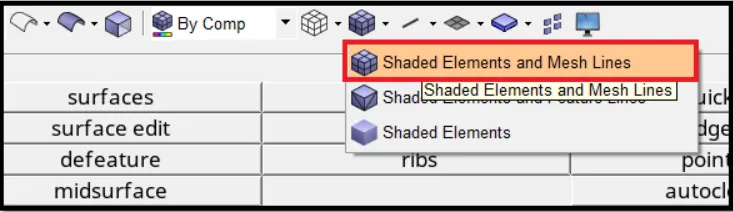
- Here the model is in wireframe mode,switch to the shaed mode as shwon in below fig.
- To switch to shaded model,go to visualization tab>>shaded elements and mesh lines.
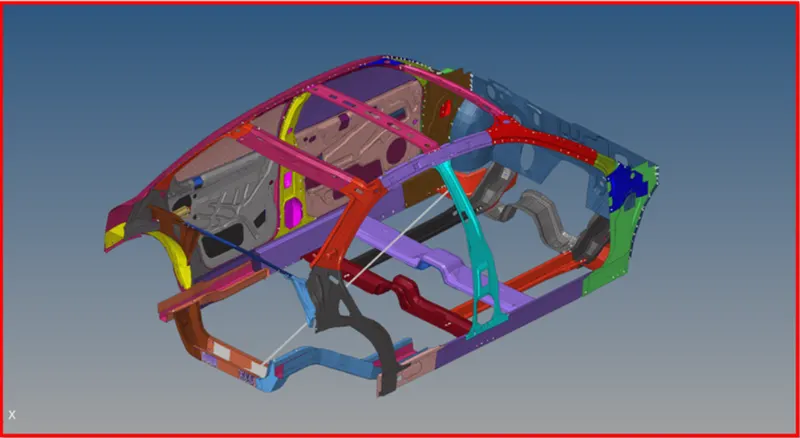
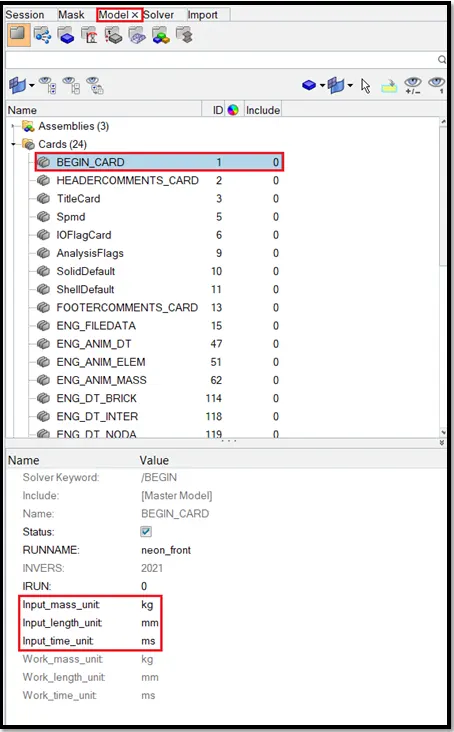
- Now go and check for the unit system of the model.To check for the unit system,go to the model browser>>control cards>> BEGIN_CARD.
- Check for the unit system is shown in below fig.
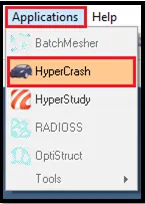
- Now go to the hypercrash,to go,go to the Menu bar>>application>>hypercrash.which is shown in below fig.
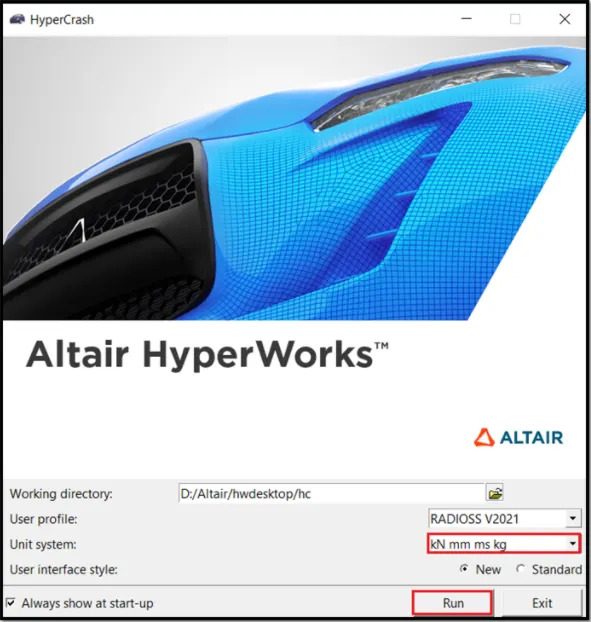
- Make sure whether the unit system in hypermesh is [KN,KG,MM,MS],Which is shown in below fig.
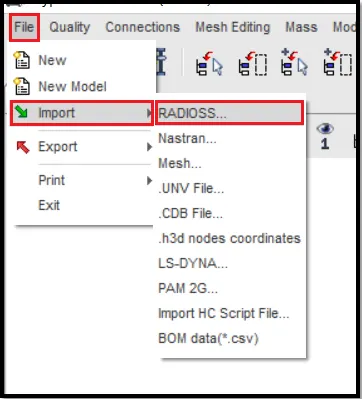
- Now import the model in hypercrash,to import the model,go to menu bar>>file>>import>>radioss,which is shown in below fig.
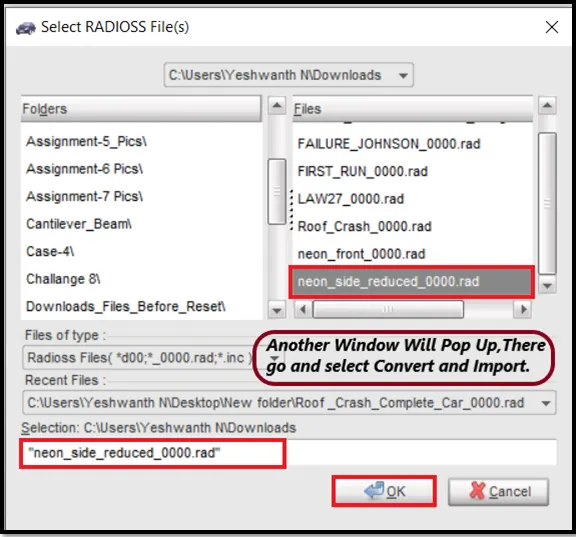
- Here select the appropriate radioss file and import the model into hypercrash,which is shown in below fig.
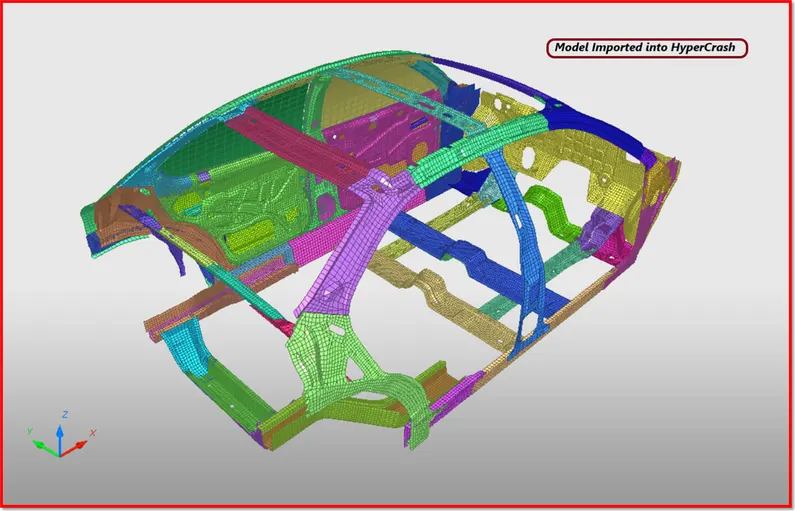
Phase 2- Mass balancing [Adding mass to the model to get COG at proper poasition]
- Here the COG is not in proper position which is shown in below fig,so we need to add mass to get COG at proper position.Its like balancing.
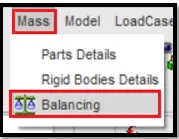
- To check the mass and COG [Centre of gravity],Go to hypercrash menu bar>>mass>>balancing,which is shown in below fig.
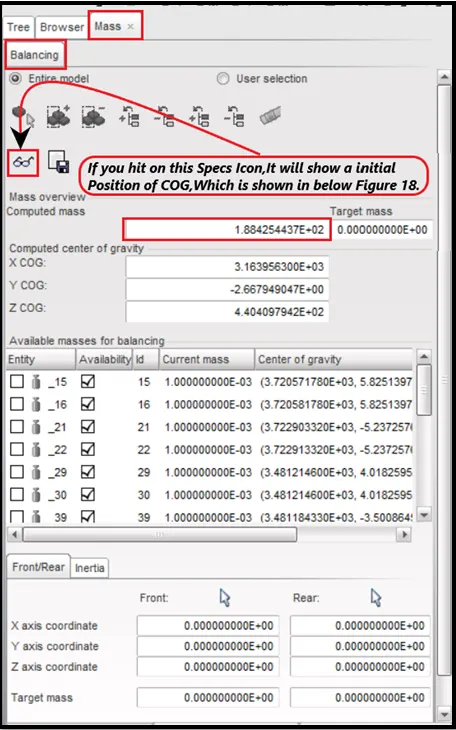
- After hitting on the icon which is shown in below fig,The initail poaition of COG will appear which is shown in below fig.
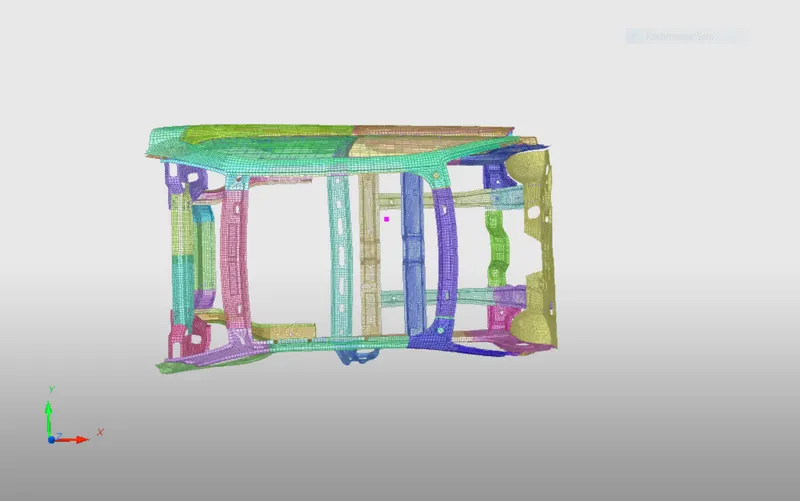
- Now mass should be added to get COG in proper position.It should be in centre of the cross member.
- To bring COG to the centre of the cross memeber,we should add a mass.
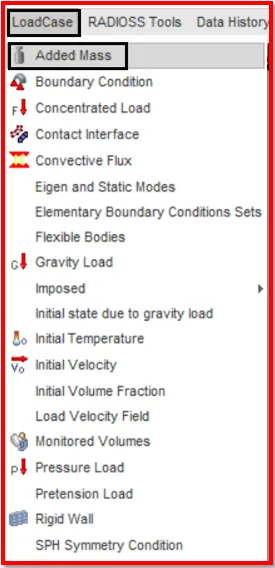
- To add mass, go to load case>>added mass.Which is shown in below fig.
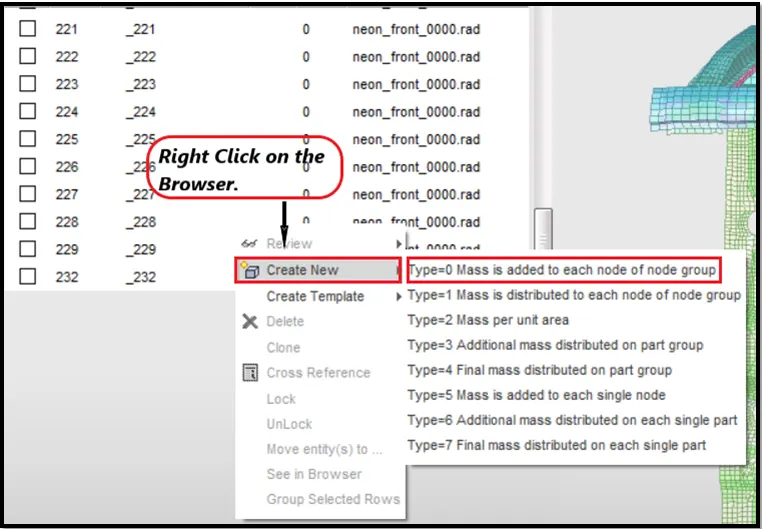
- Now right click on the added mass browser and select TYPE=0 where the mass will be added to every single node,which is shown in below fig.
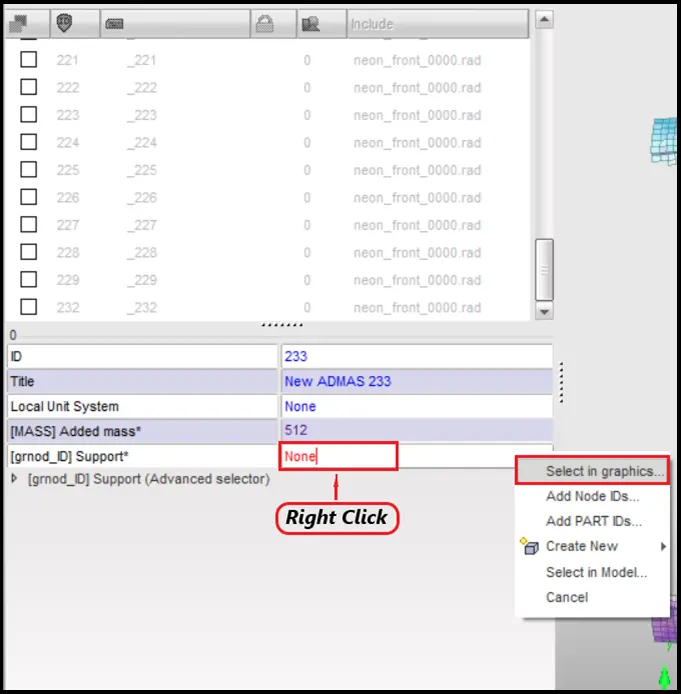
- Here right click on the [grnod_ID] support to pick the nodes to add mass,which is shown in above fig.
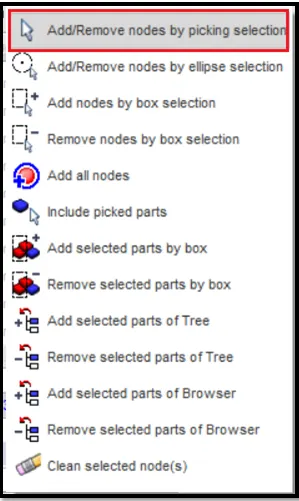
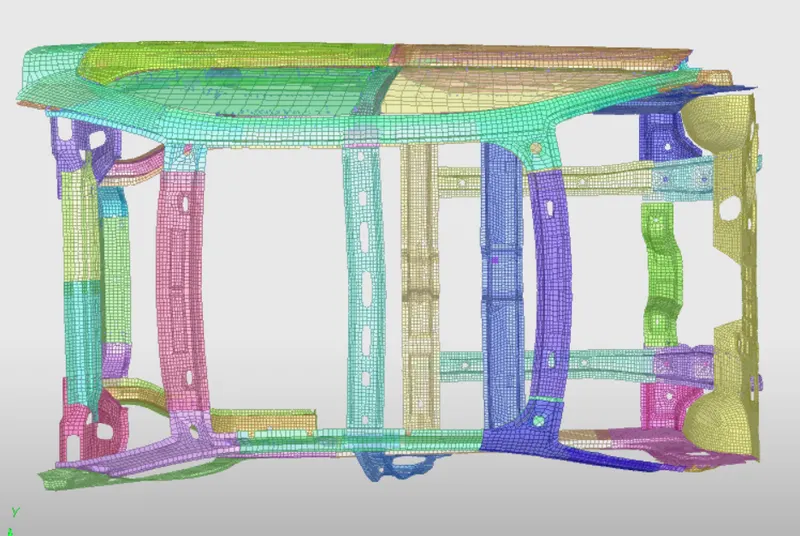
- Here in the above fig.The nodes were picked on the model to add mass.
- Here after adding mass on the nodes,The COG position is changed which is shown in above fig.
- Here,similarly pick the nodes on the other side of the model and add mass to bring the COG at centre of the cross-member.
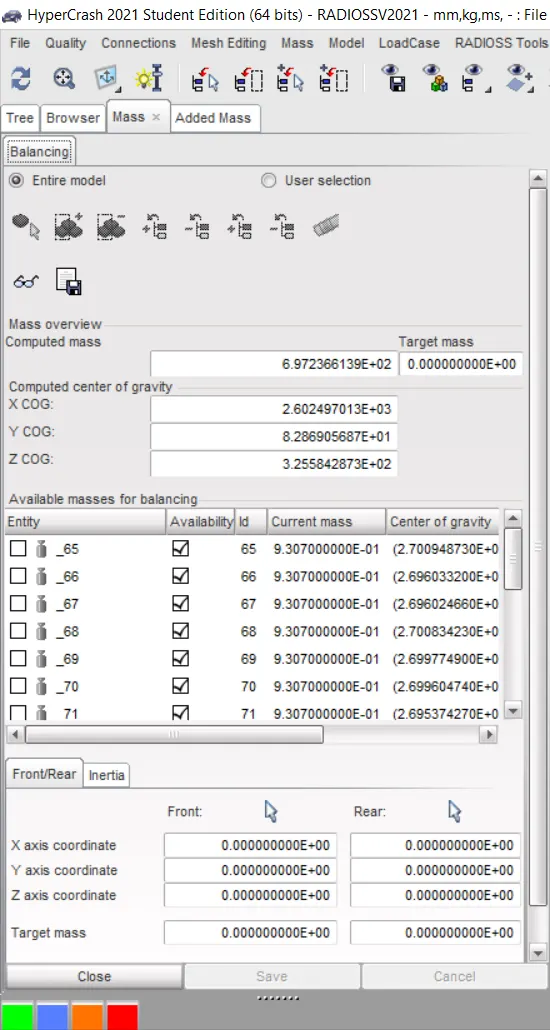
- The nodes have been picked and mass added to the other side of the model,which is shown in below fig.
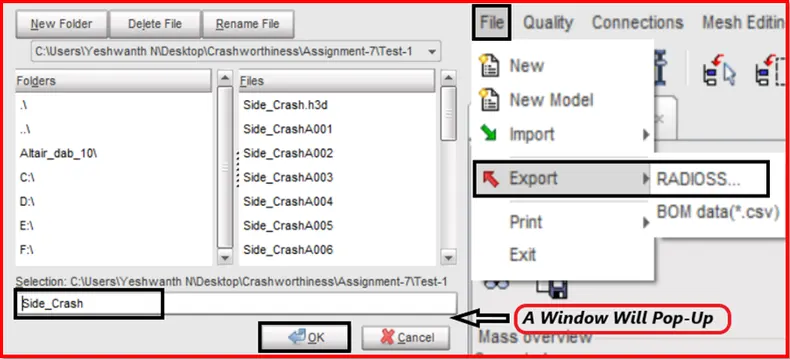
- We have attained the mass by adding the mass to the nodes,which is shown in below fig.
- Now export this file and save it in a specified location and import this model into hpermesh and check the total mass.
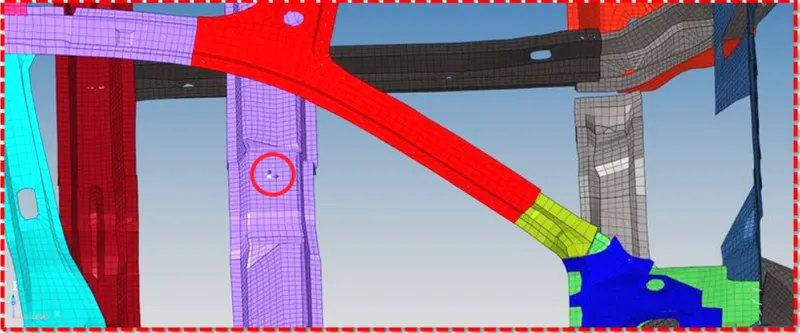
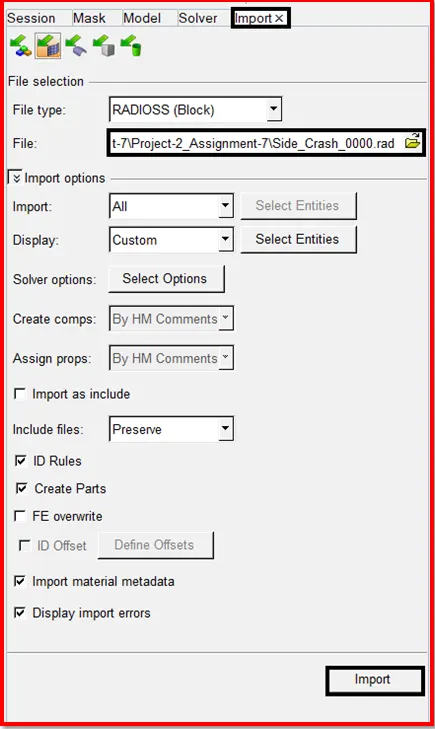
- Now import the exported model from hypercrash to the hypermesh.
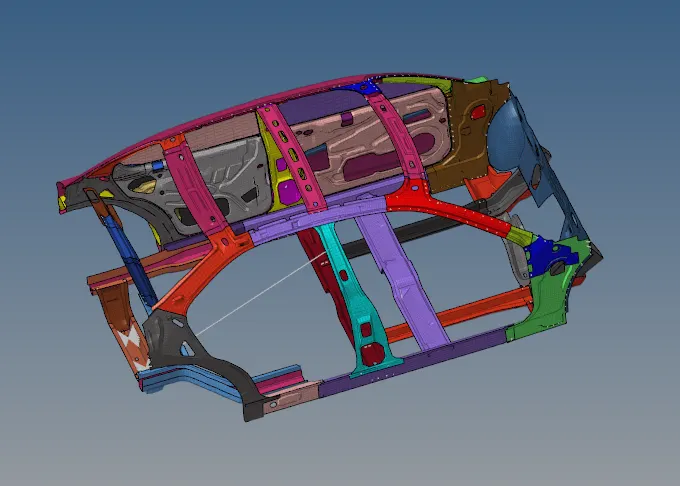
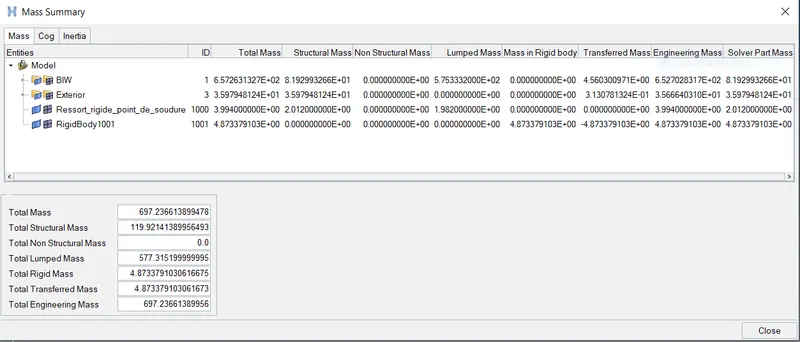
- Next go and check in hypermesh,whether the we have attained 700kg mass.
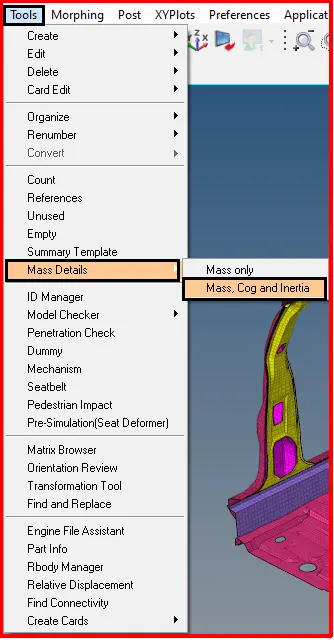
- To check, Go to menu bar>>tools>>mass details>>mass, COG, Inertia.Which is shown in below fig.
Phase 3- Check for the Penetration:
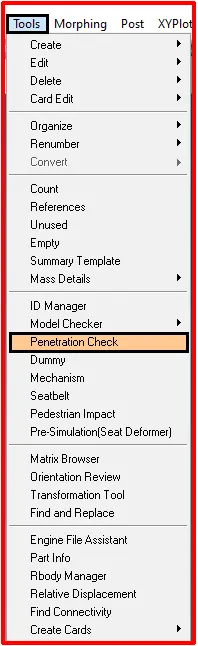
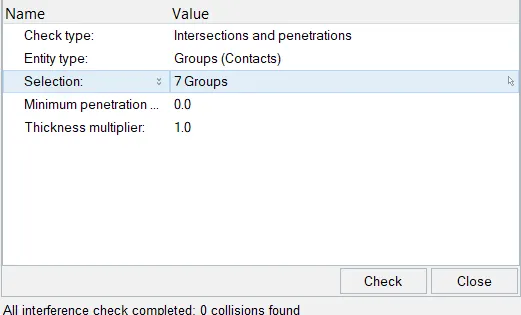
- Here check for the penetration,to check go to menu bar>>tools>>penetration check.Which is shown in below fig.
- Next select the groups [Interfaces] to define,which is shown in below fig.
- Then click on the check to check penetrations in model.If the penetration exist,it throw a error in the status bar,if the penetration does not exist,it will display No collision found which is shown in below fig.
Phase 4- Create the interfaces:
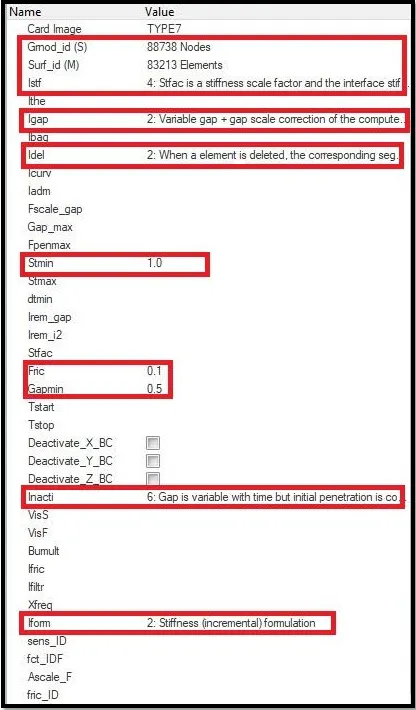
- Here for this model.TYPE7 contact interface is created with the recommended parameters,which is shown in below fig.
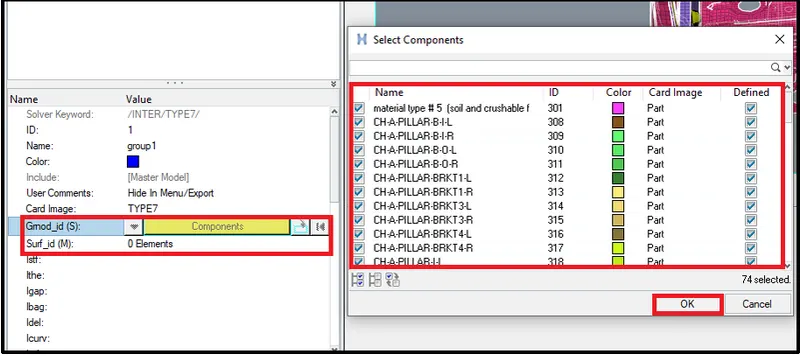
- Select the slave and master nodes by switching to the components and select all the componenets for slave and master nodes which is shown in bwlow fig.
Phase 5- Creation of sections at cross member:
- Here we have to create a section,the section should be created at the cross member.
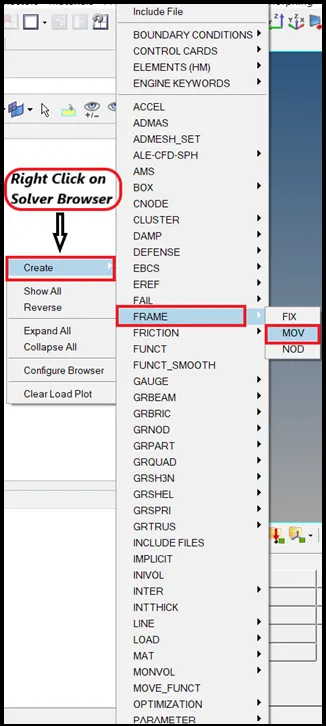
- Next for creating section,we need frame.so we need to create frame first.To create frame right click on the solver browser>> create>>frame>>mov.which is shown in below fig.
- Next select the nodes to specify the location of the frame to be created on model.
- Switch to the create by node reference,now select the node at origin>>node at z-axis>>node at YZ plane,which is shown in below fig.
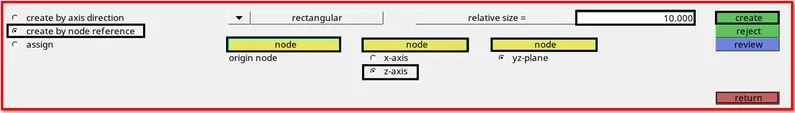
- The nodes selected to create a frame at a specified location is shown in below fig.
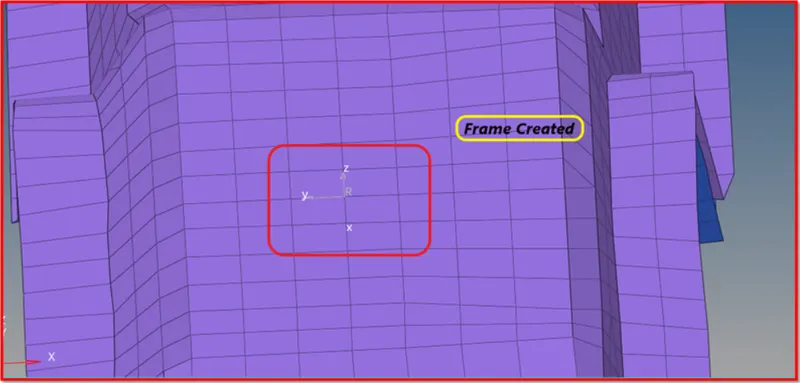
- The frame created is shown in below fig.
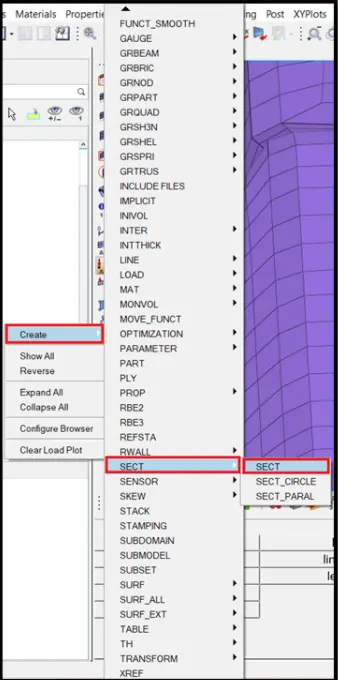
- Then create a section,to create a section right click on the solver browser>>SECT>> which is shown in below fig.
- After selecting the SECT to create section, A parameter window will be opened left side.
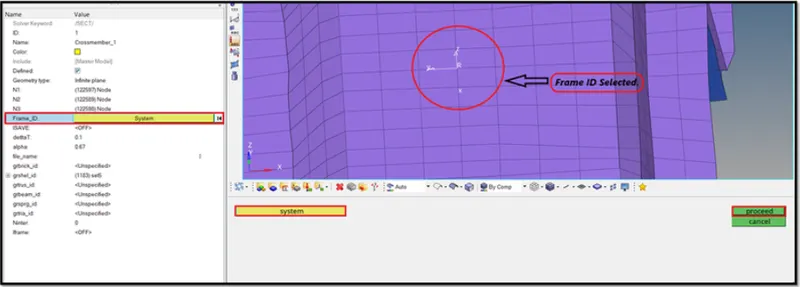
- There will be nodes [N1,N2,N3] Select the nodes to create a section which is shown in below fig.
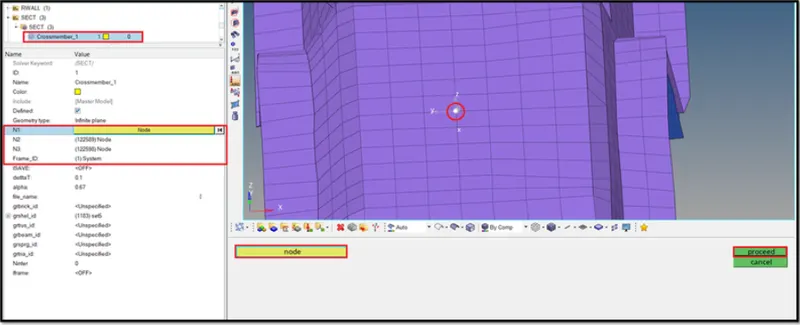
- Next select the frame ID which is shown in below fig.
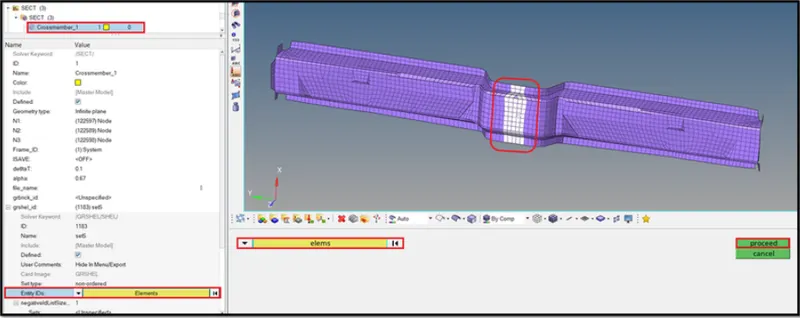
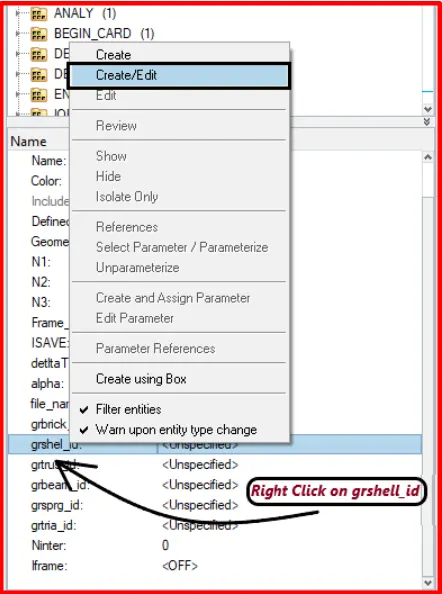
- Next right click on the grshell_id to select the elements,where we created the section,which is shown in below fig.
- Enter the values for delta and alpha.
- Coefficient of filtering (alpha=0.67)
- Time step for saving the data (deltaT=0.001)
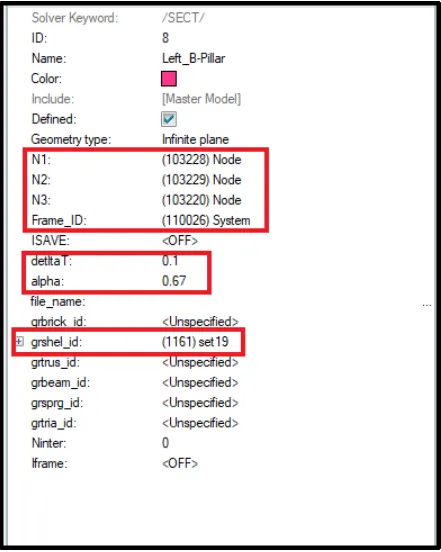
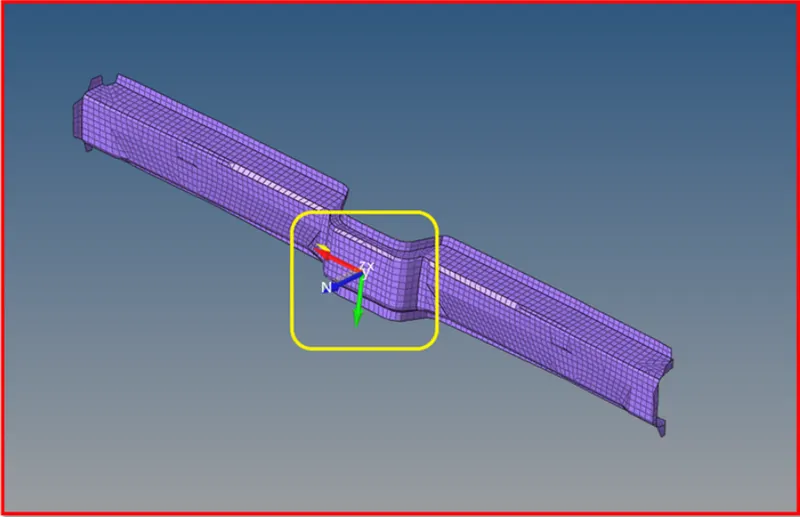
- Every parameters have been specified which is shown in below fig.
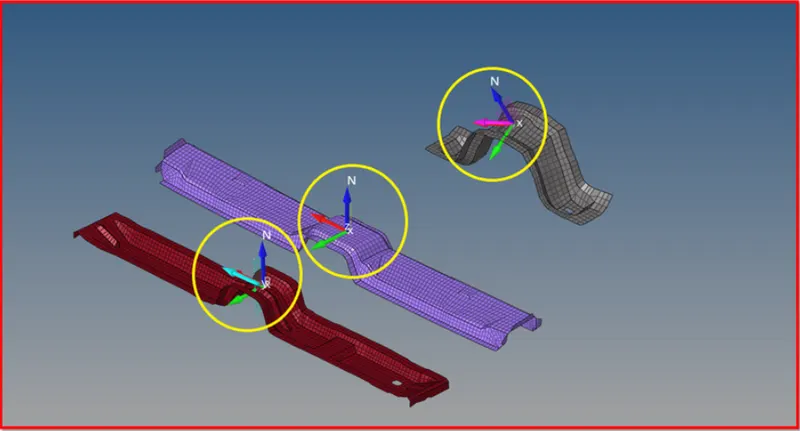
- A section has been created which is shown in below fig.
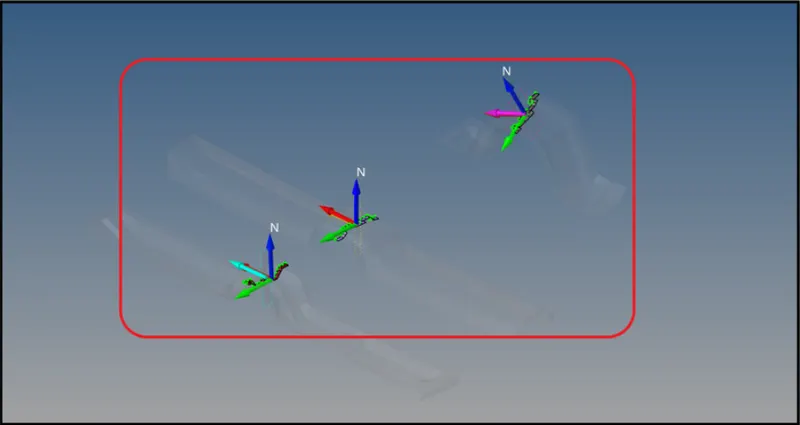
- Now we have to check whether the section created for the rail componenet is fine or not.
- If all the nodes get realized in the elements,then the section created for rail componenet is fine,which is shown in below fig.
- A one row of elements should be maintained.
- To check,right click on the section in the model browser>>review.
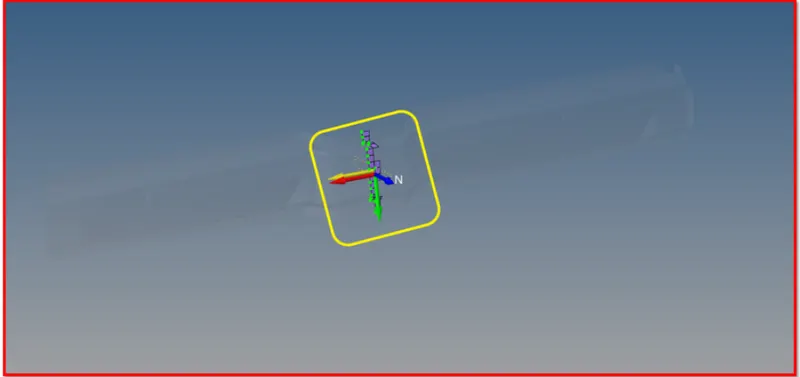
- Similary,we have to create a other two sections in the other cross members,which is shown in below fig.
Phase 6- Creation of intrusion at B-pillar,hinge and fuel tank region:
- Here we have to create intrusion at B-pillar,hinge pillar and fuel tank region.
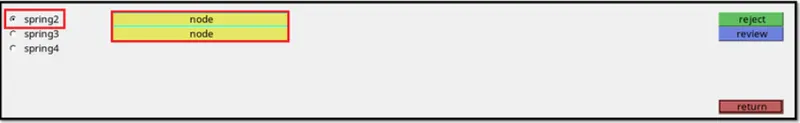
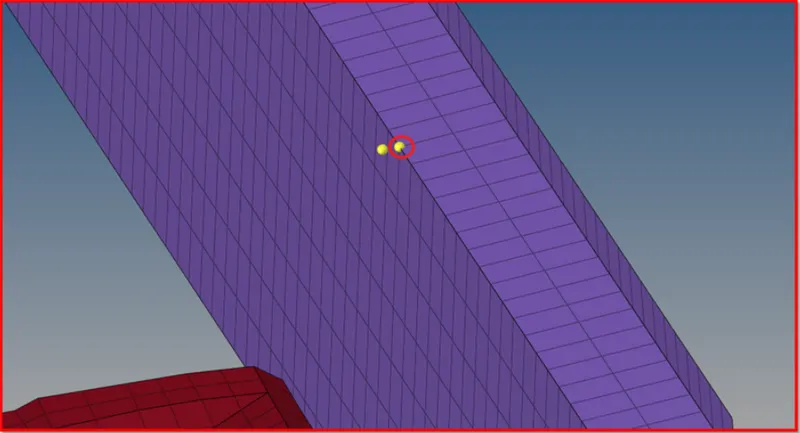
- First we have to create spring 1D element,to create first create a temp node on the B-pillar base component which is shown in below fig.
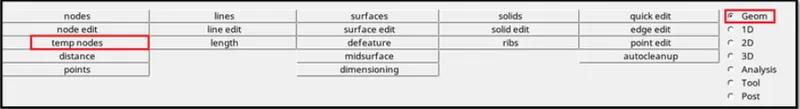
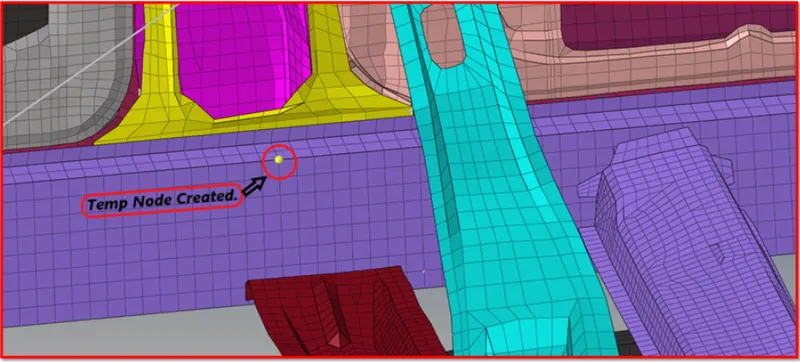
- Next step is translate this node to other left B-pillar,cause to create spring,we need two nodes,so translate the node and create a temp node parallel to the where the node created on the right side of B-pillar,create a temp node with the reference of translated node,which is shown in below fig.
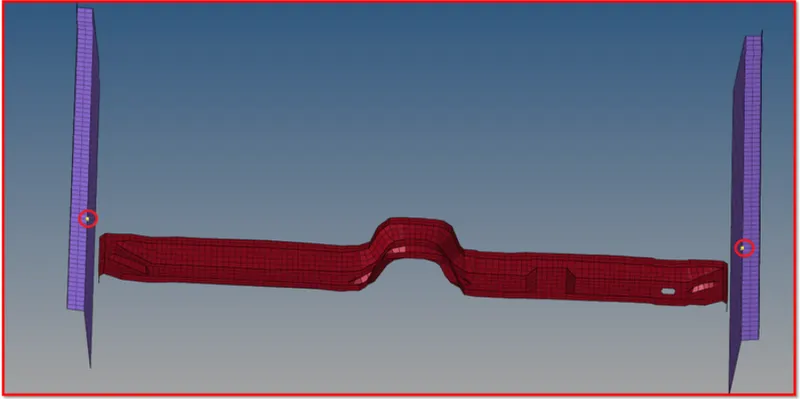
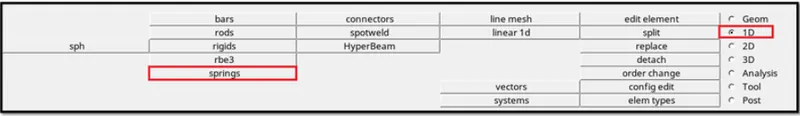
- Now create a spring,to create element,go to 1D>>spring>>select node 1 and node 2,which is shown in below fig.
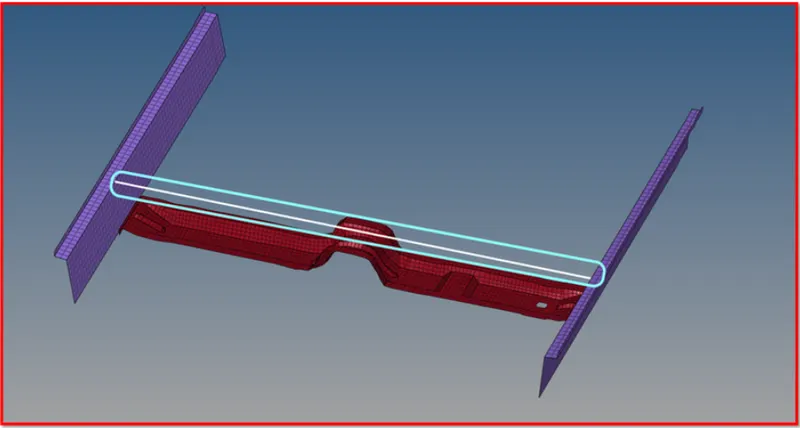
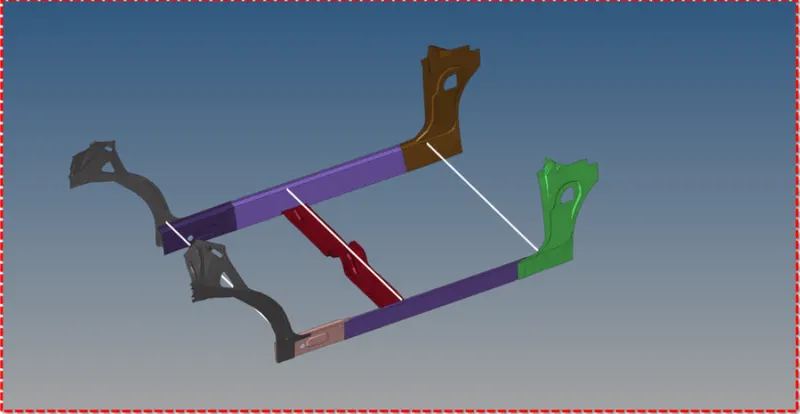
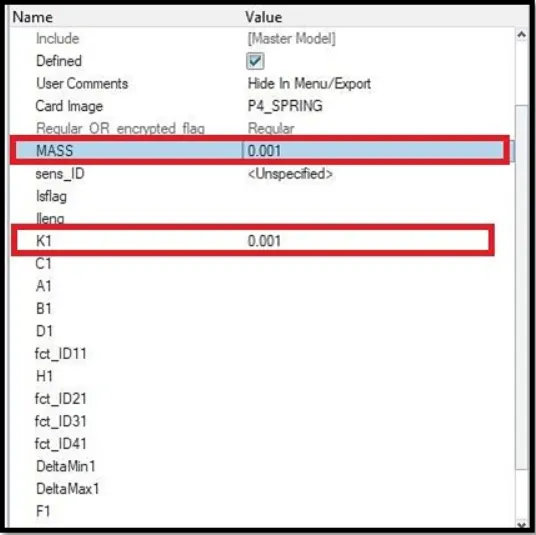
- The next one is to assign the mass and stiffness values for the created springs,in the parameter region,as shown in below fig.
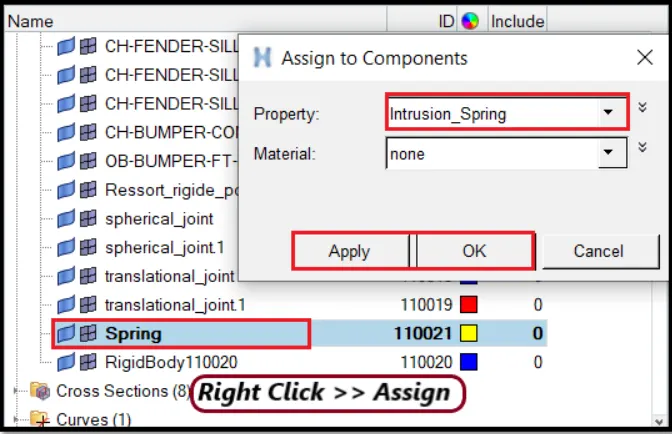
- Next create new collector and rename it as spring which is shown in below fig.
- Create a property and assign the property to the spring collector which is shown in below fig.
Phase 7- Give the initial velocity:
- Now we have to give the initial velocity to the car.
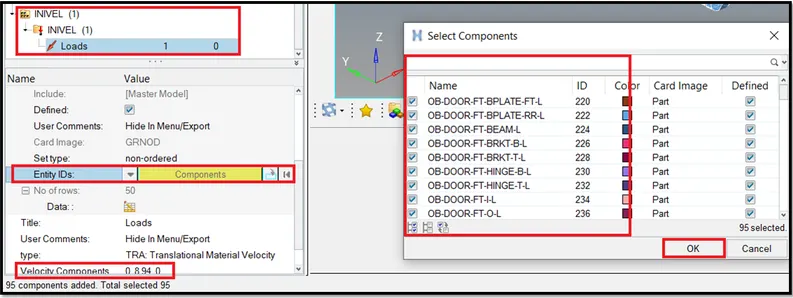
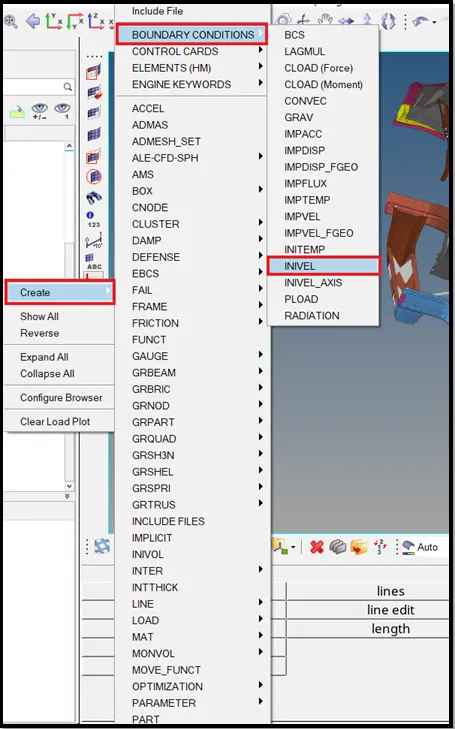
- So to give the initial velocity we have to create INIVEL.
- To create,go to solver browser>>right click>>create>> boundary condition>> INIVEL which is shown in below fig.
- So, we want the car body to move in the X- direction so we have to give the velocity in the X-direction only.
- We need to give the velocity as 20 mph,which we have to convert into the m/s,so after coverting the velocity we got the velocity as 8.94 m/s.
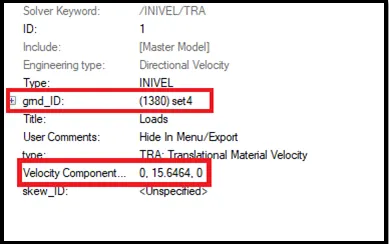
- Right click on the grnd_ID and select all the components,cause whole car body want to move in x direction which is shown in below fig.
Phase 8- Create peak velocity of inner node of the door:
- Here we have to create a peak velocity,to create a peak velocity,first we have to create a node.
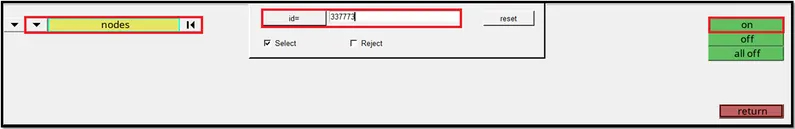
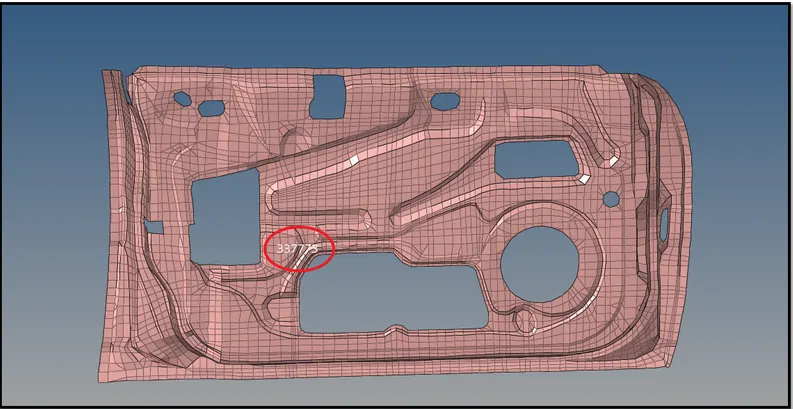
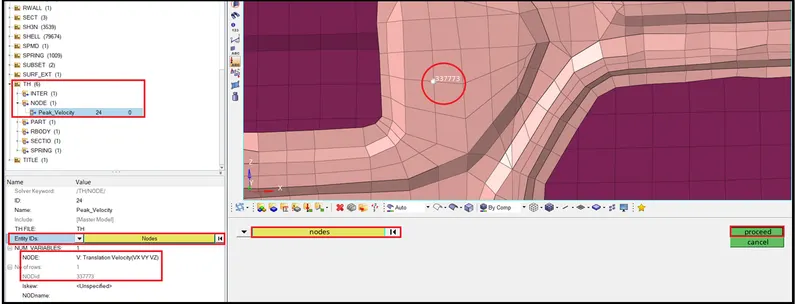
- We have to give peak velocity at the given node [337773]
- To find the node,go to display panel,to find we have to display the numbers in the display panel which is shown in below fig.
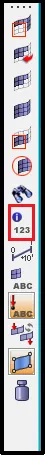
- Select the node by ID and enter the ID number and click on which is shown in below fig,The node number will be displayed,we have to create a node there and to request TH for that node.
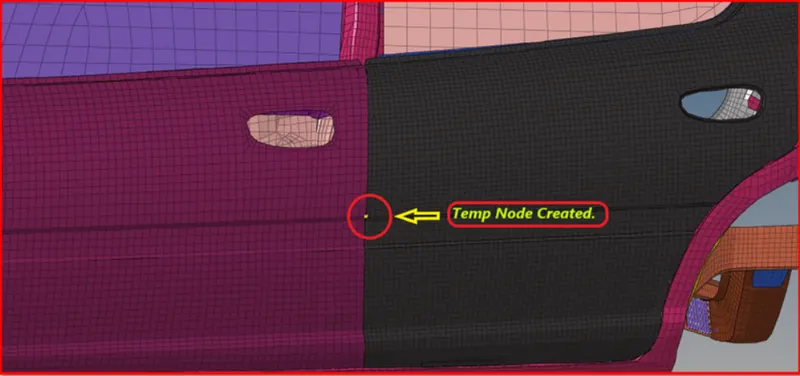
- The node number is displayed,which is shown in below fig.
- Next,create a TH for the node because to know the peak velocity at that node.
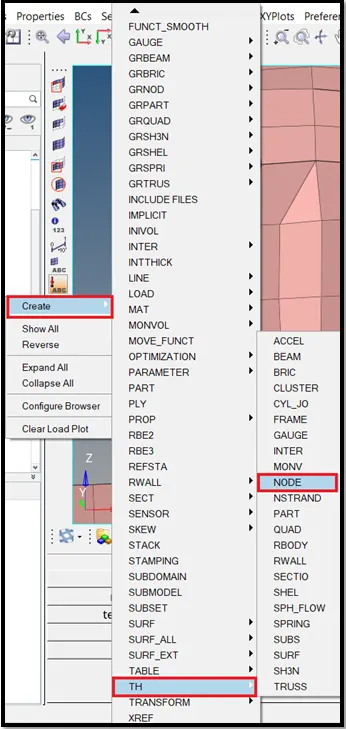
- To create a TH for that node,right click on the solver browser>>Create>>TH>>Node,which is shown in below fig.
- The TH is requested for the node,which is shown in below fig.
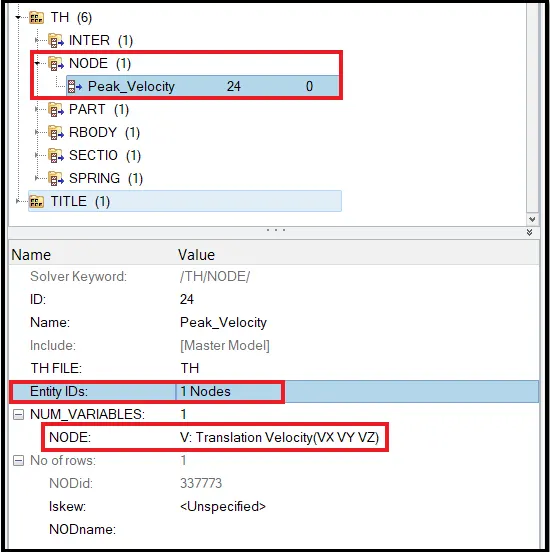
- In the entity IDs option,selection the node which is shown in below fig.
Phase 9-Create rigid wall with friction 0.1:
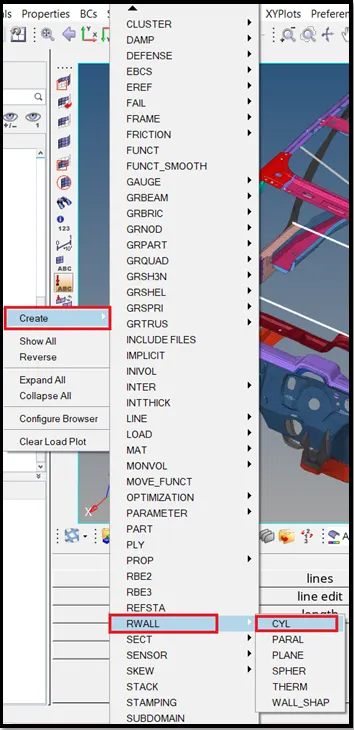
- Here we have to create cylindrical rigid wall,cause this side pole crash,so
- To create rigid wall right click on the solver browser>>create>>RWALL>>CYL which is shown in below fig.
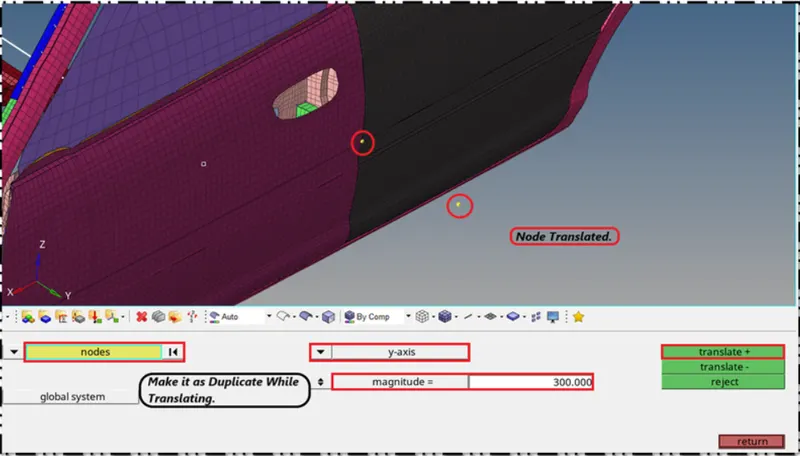
- Next we have to create a temp node on the car door to make a cylindrical rigid wall.
- After creating a temp node,translate that node to the 300mm.
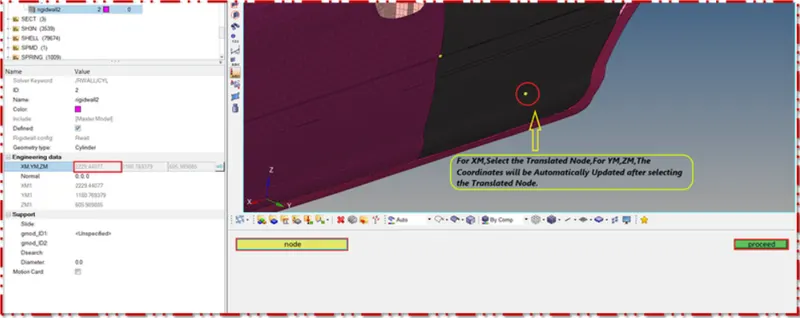
- After translating a node,in the RWALL parameter window,we have to select(XM,YM,ZM),it is selected by clicking on the node which was translated which is shown in below fig.
- And the few parameters such as friction,diameter of the cylinder pole(rigid),searching tolerance (Dsearch) should be given which is shown in below fig.
- Create a temp node which is shown in below fig.
- Translate the node which is shown in below fig.
- Now for XM, select the node translated which is shown in below fig.
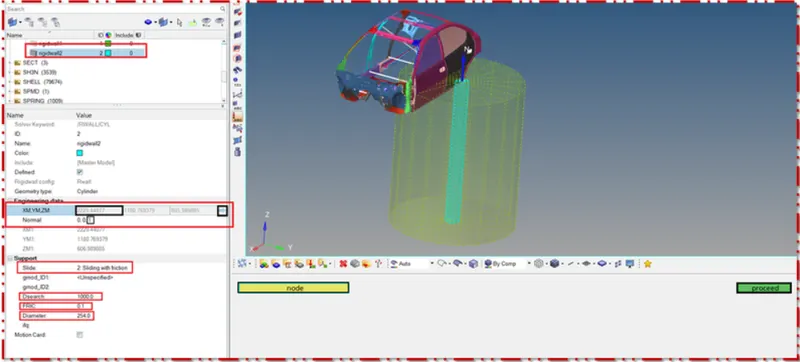
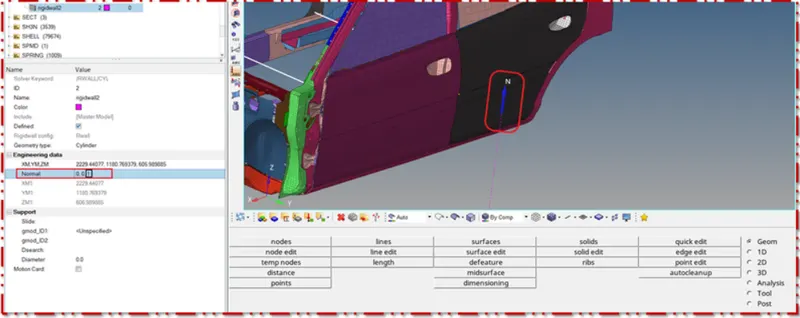
- Now for normal,in the z axix,give the values as 1 which is shown in below fig.
- Now give the values for all the parameters which is shown in below fig.
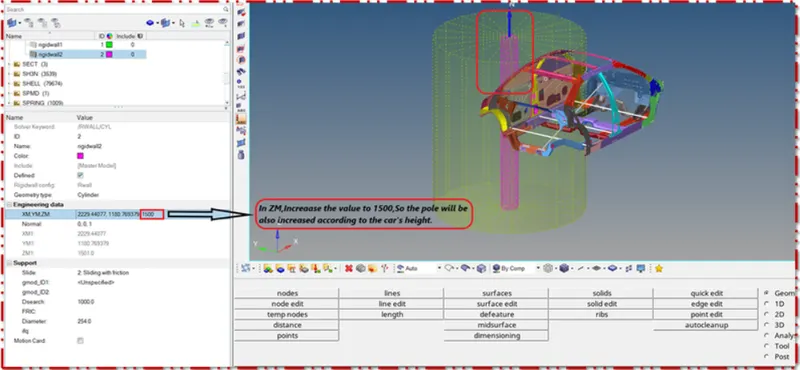
- Here increase the value of ZM to 1500 to increase the height of the rigid pole to the car's height which is shown in below fig.
Phase 10- Request TH file for the required outputs and give time step value:
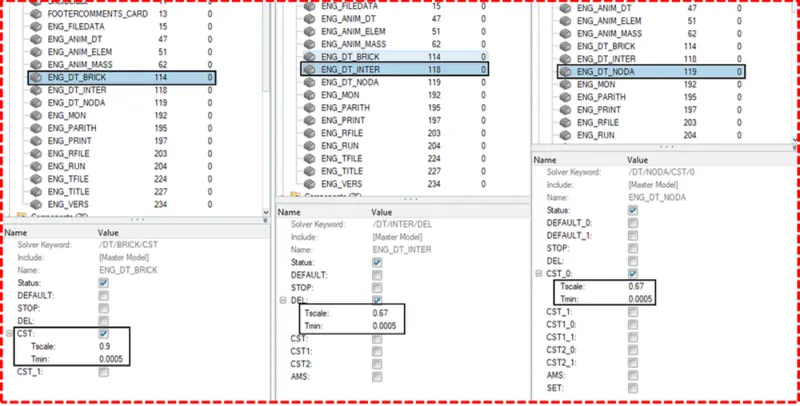
- Here the timestep should be assigned to the model to run the simulation.
- The required values to be entered in the ENG_DT_BRICK,ENG_DT_INTER,ENG_DT_NODA Control cards which is shown in below fig.
TH for interface:
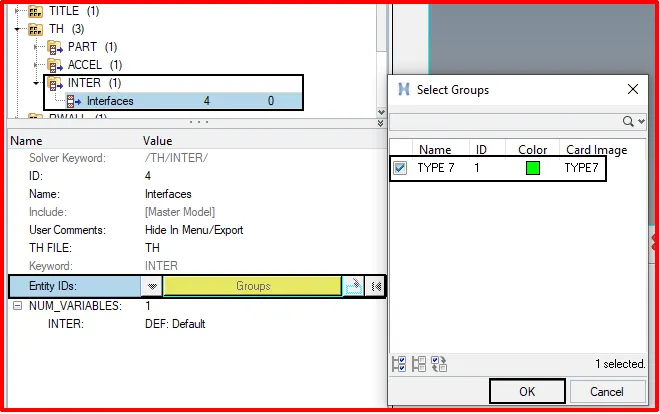
- Second request TH for the interface,to request TH for interface,right click on the solver browser>>create>>TH>>INTER,which is shown in below fig.
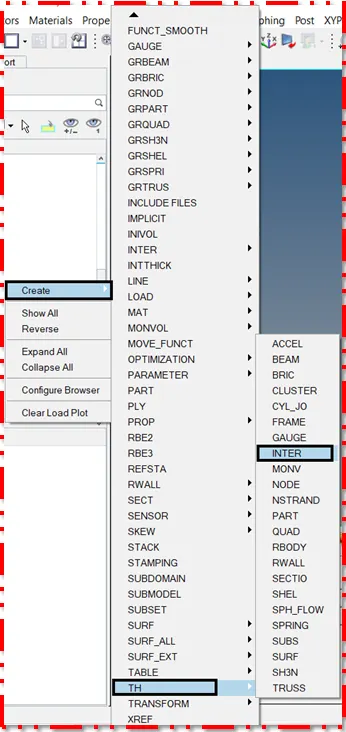
- Next at the bottom,there will be a window,there go to the entity IDs option and select the group A window will pop up,select all and hit on ok,which is shown in below fig.
TH for the sections:
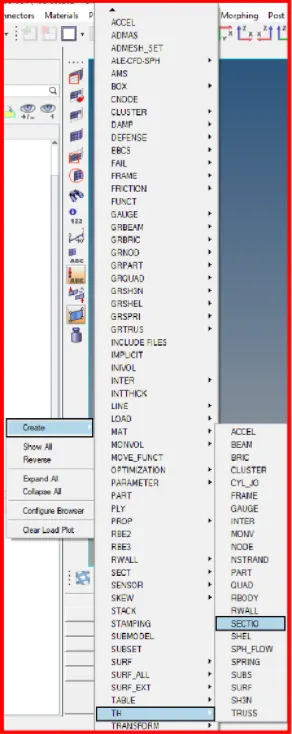
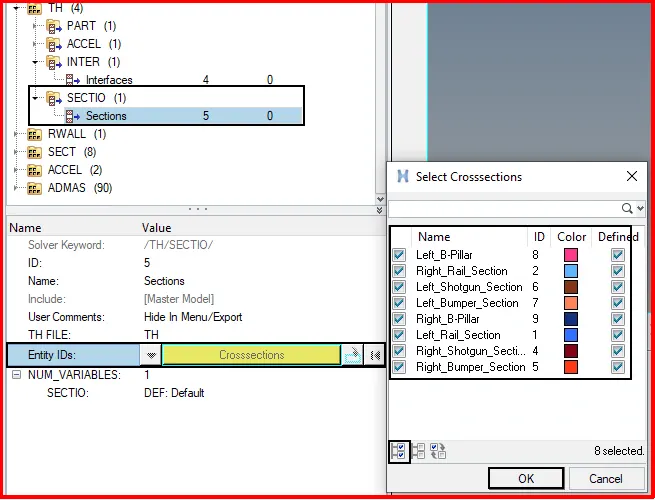
- Similarly create the TH for sections as created for previous case,which is shown in below fig.
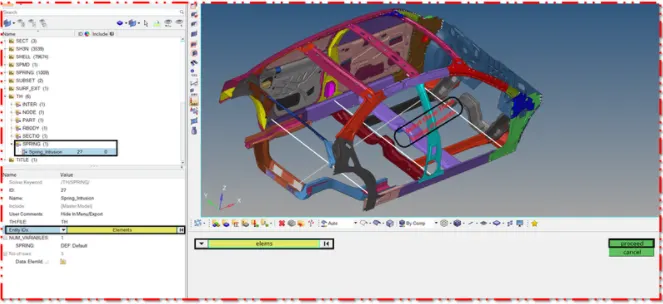
TH for the intrusions(spring):
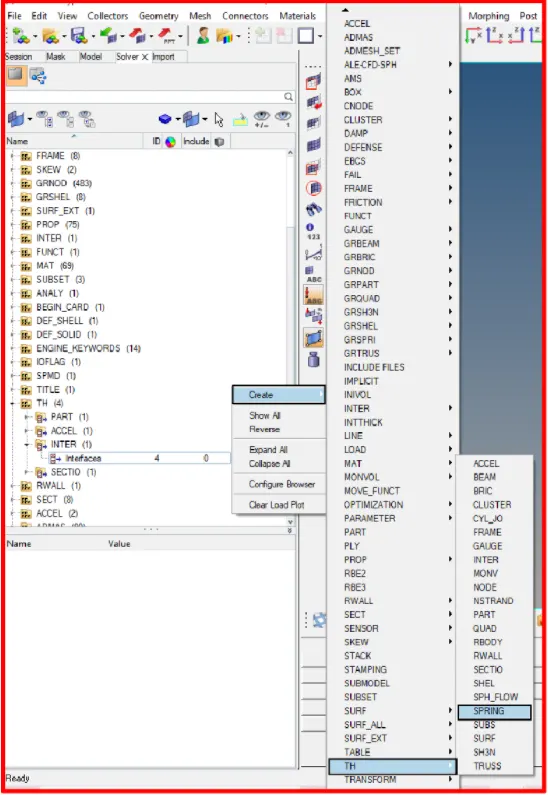
- Similarly create the TH for spring as created for previous case,which is shown in below fig
Phase 11- checks:
- Finally,after doing all the load case setup,we have to check for the error,whether every load case setup is fine or not.
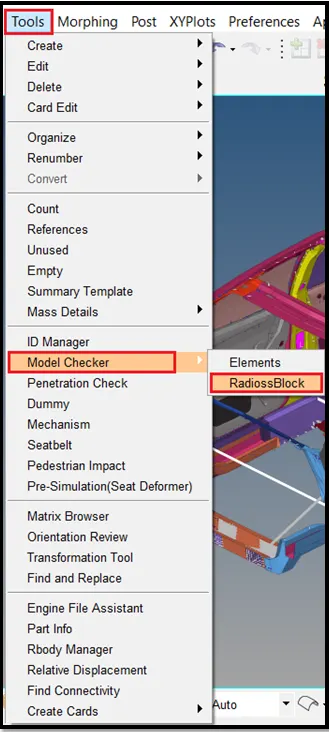
- To check go to tools>> model checker>> radioss block,which is shown in below fig.
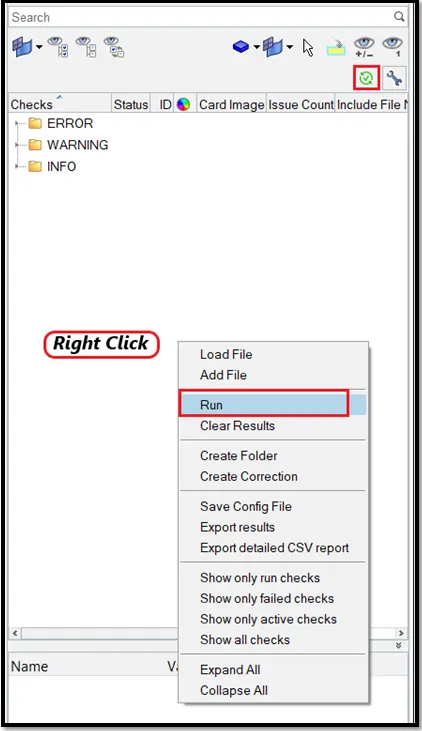
- Next the model checker window will be open which is shown in below fig.
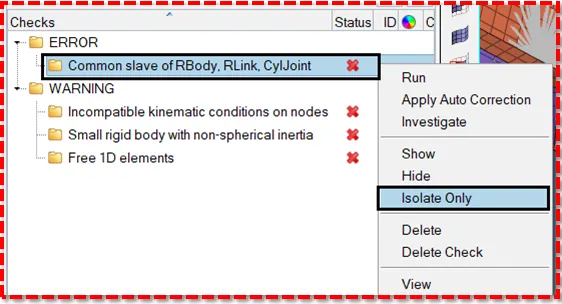
- There right click on the browser and click run or hit on green check mark in the window,which will run and identify if the error exist in the model load case setup.
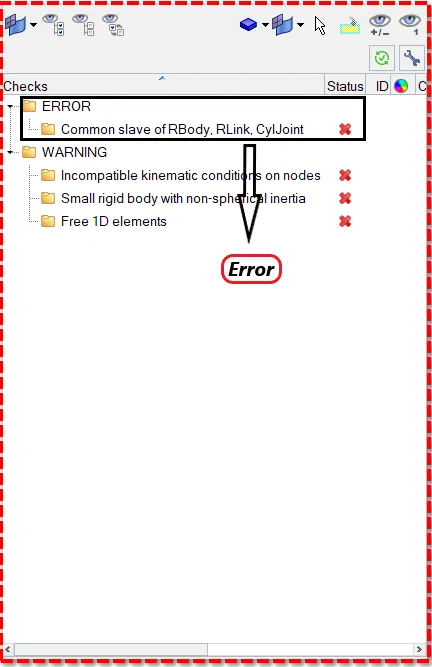
- To fix the error shown in above fig.
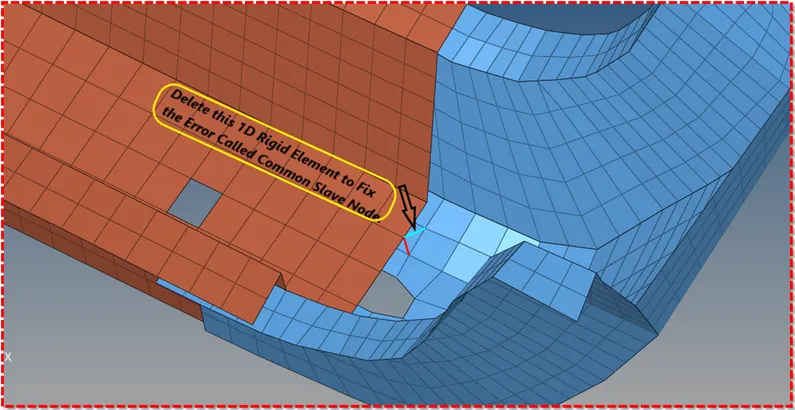
- Isolate that error which is shown in below fig and see where the error has occured,the error occur is shown in below fig.
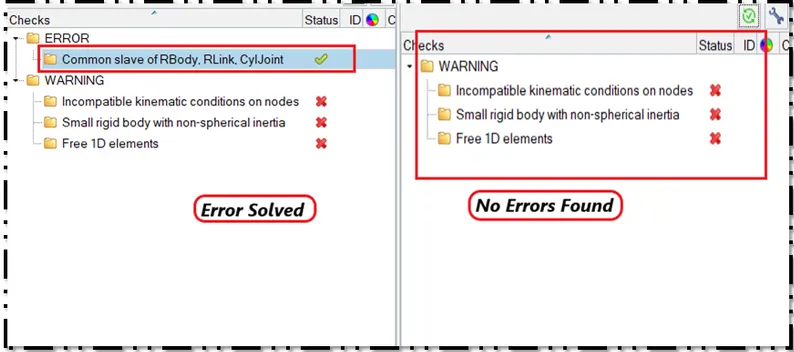
- To fix the error which is shown in below fig,to fix this delete the 1D rigid element to fix this erro which shown in below fig
Phase 11- Run the simulation:
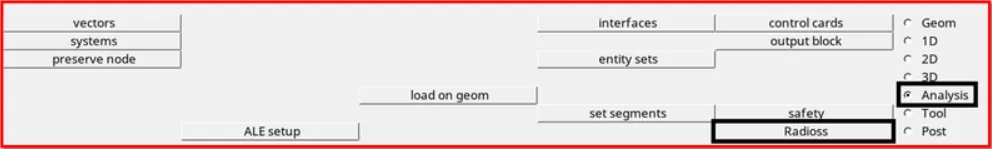
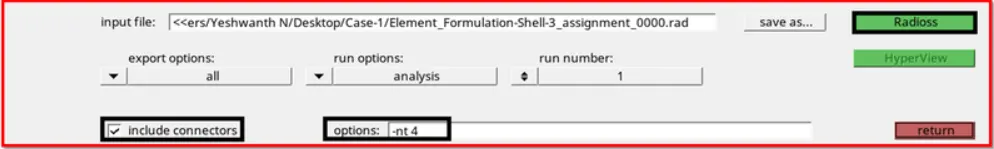
- Now run the simulation,to run the simulation,go to analysis panel as shown in below fig.
- Go to analysis panel>>radioss>>select the input file>>save it in different folder and rename it as test-1>>run.
- Check the include connectors,if there are any connectors in the model,the connectors will also be taken into account.
- Type -NT4 in options tab,this will make simulation faster.
- Where NT indicates no of threads,4 indicates assigning the task to 4-cores in the system.
- After completing the simulation,the radioss will pop up a solver window stating radioss job completed which indicates the simulaion has been completed.
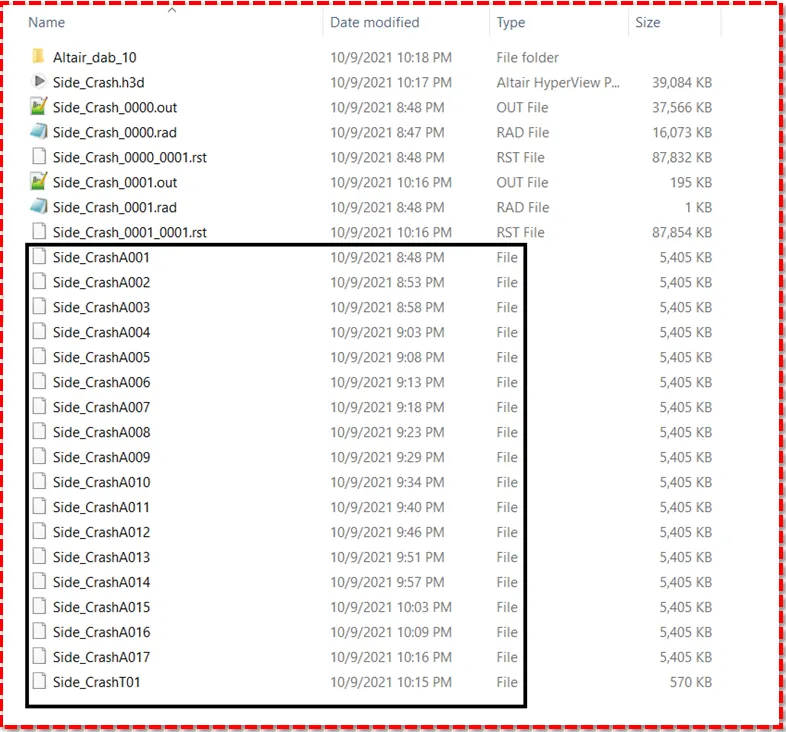
- Here the number of animation steps obtained are shown in below fig.
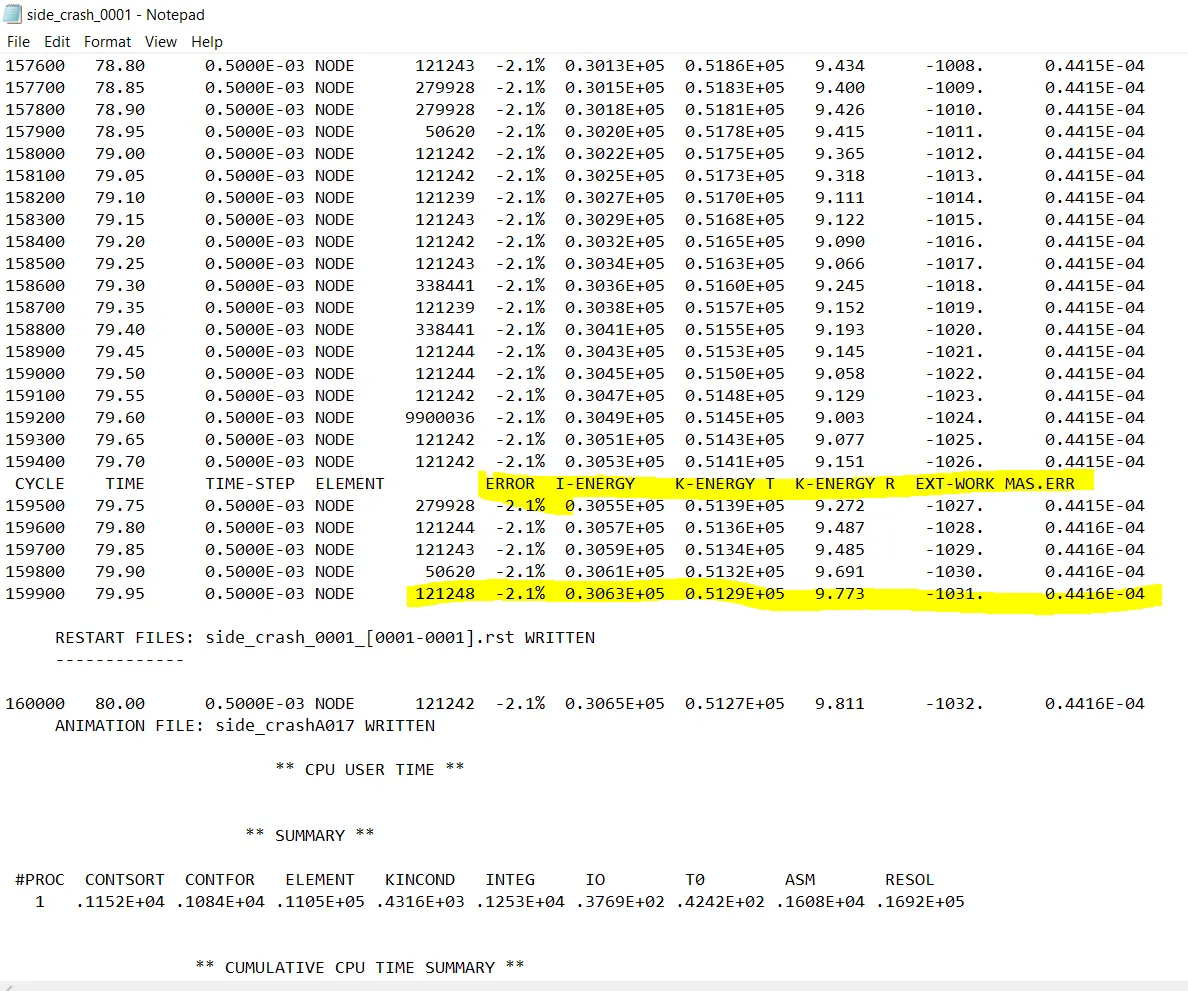
- Now go and open the 0000.1 out file with notepad.
- The obtained values for Energy error,mass error,internal energy error,kinetic energy error and contact energy error has been shown in below fig.
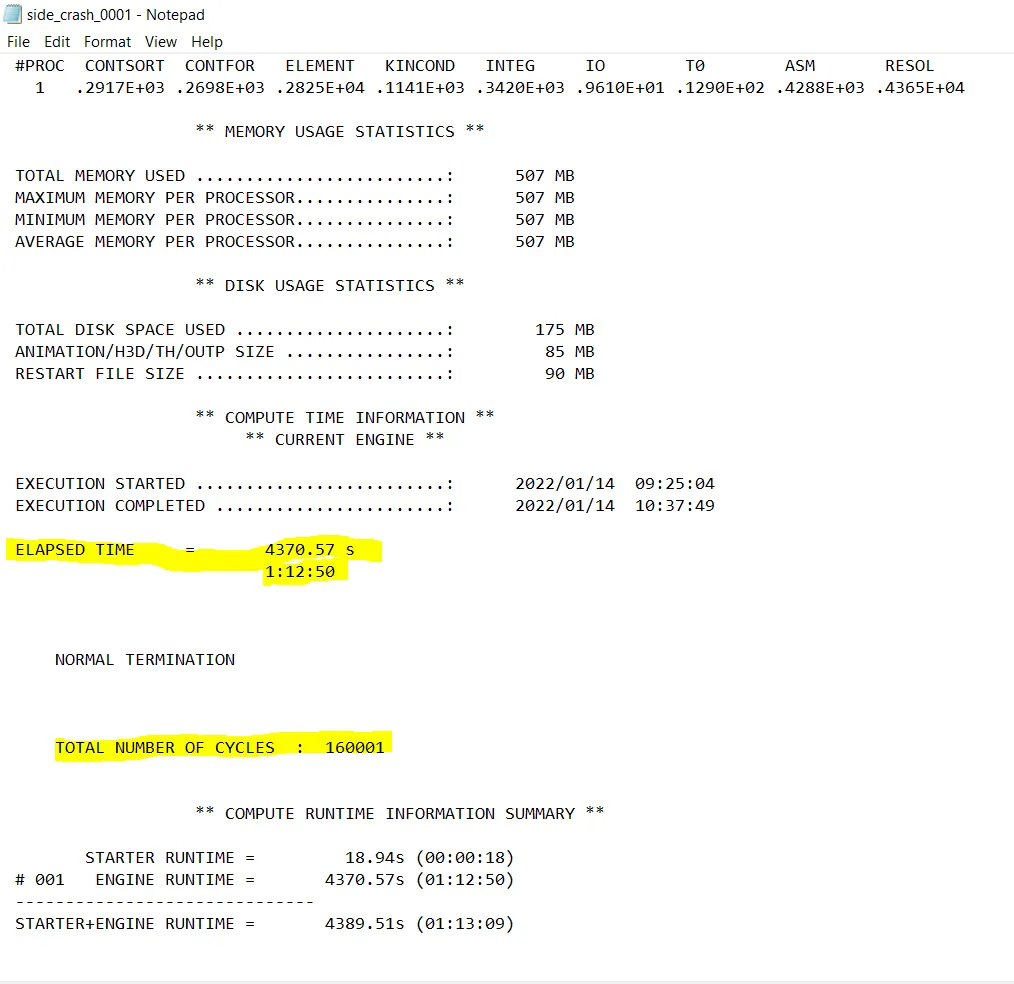
- The time taken to complete the simulation and the elapsed time is shown in below fig.
Phase 12-Post Processing:
1) Review the simulation using-Hyperview
2) Plot the graph using-Hypergraph 2D
1) Review the simulation using hyperview:
- Hyperview allows for loading and viewing result files obtained from several sources.
- Based on the solver type of the files and results you would like to visualize and analyze,there are different ways to load the input deck and their corresponding results into hyperview.
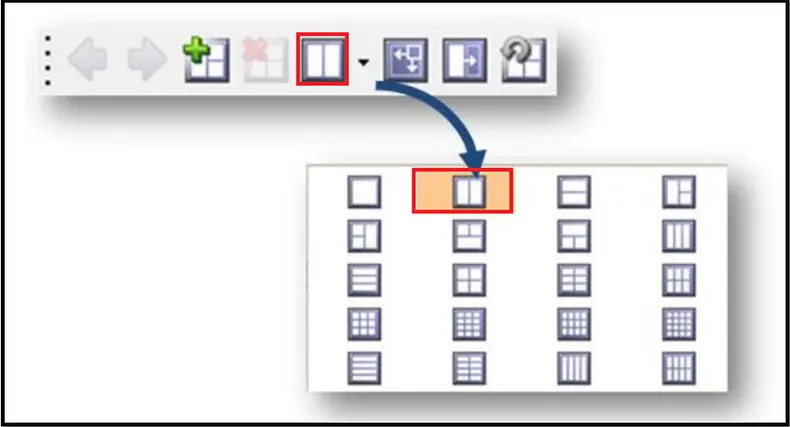
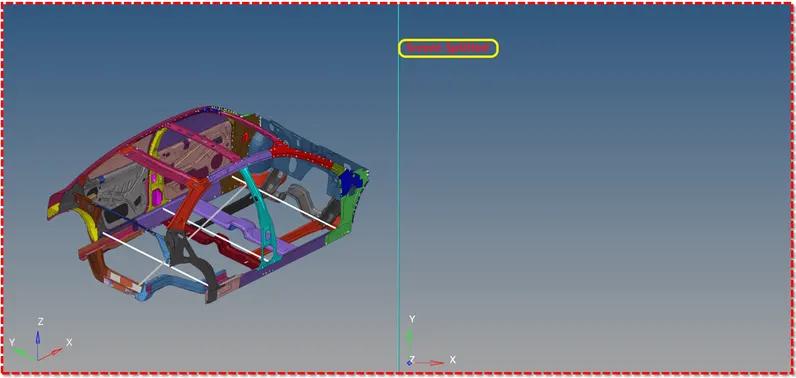
- First to begin the postprocessing in the hypermesh,split the screen as shown in below fig.
- Importing the animation file.h3d into the hyperview.
- And then activate the client hyperview.
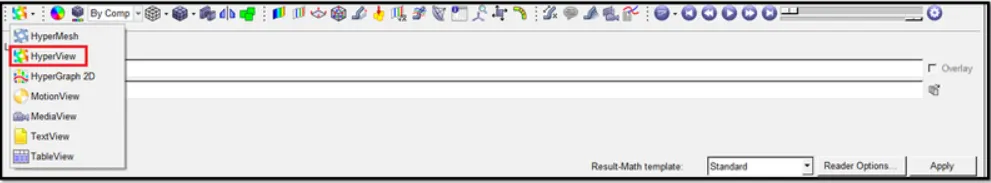
- To access the load model panel
- Select load model button from the hyperview panel and open.h3d file as shown in below fig.
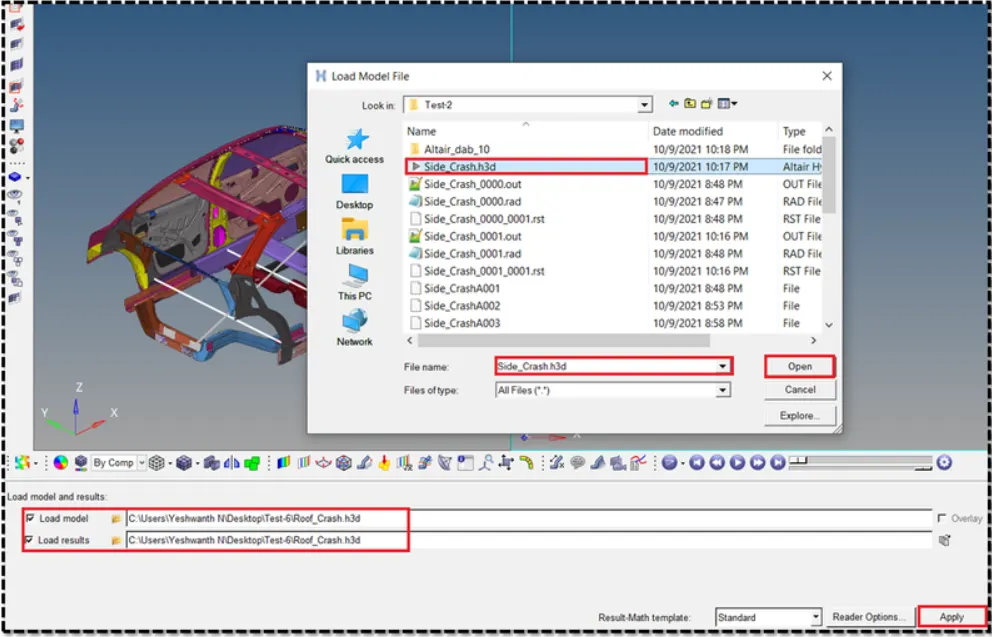
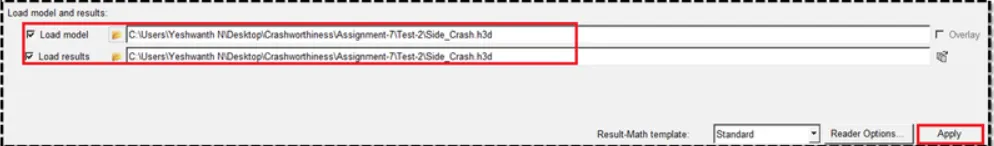
- After loading the model into hyperview,it will be represented as shown in below fig.
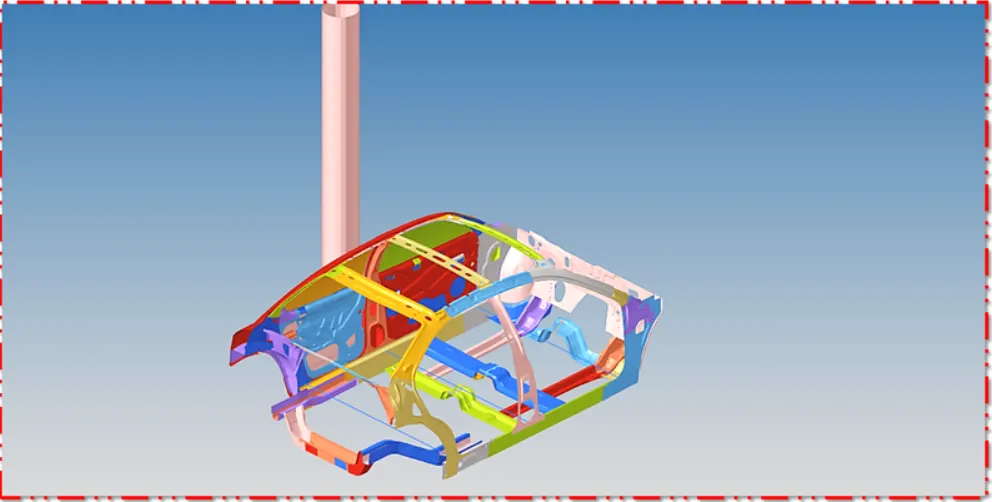
- After importing the .h3d file into the GUI,enable the contour.
- The contour tool create contour plots of a model graphically visualize the analysis results.
- To enable contour,go to results toolbar>>contour.
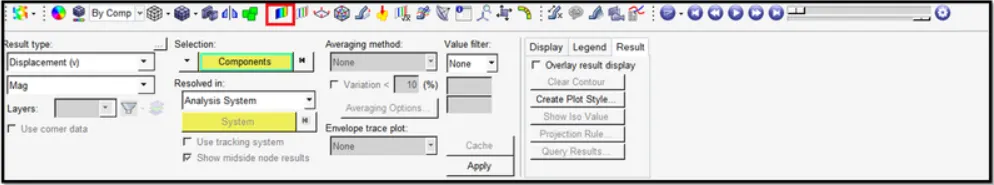
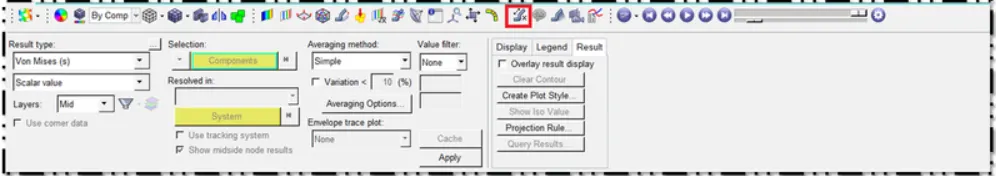
- Now switch to the Von misses stress in result type and select the component,select the averaging method as simple and then click apply as shown in below fig.
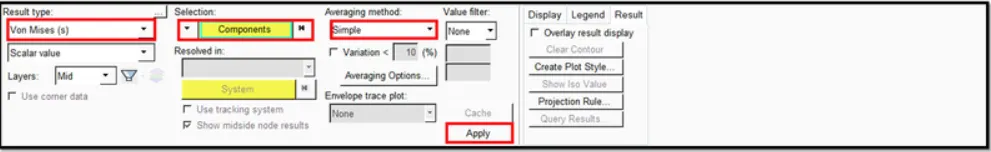
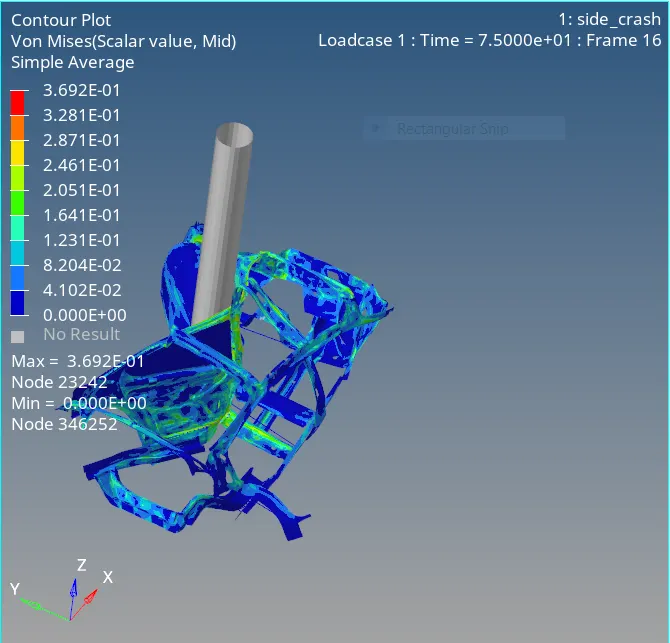
- After applying,run the simulation,the simulation animation in terms of von misses stress and displacement is shown in below fig.
- Here the contour plot displays the displacement of each node of the BIW model of a car in a GUI.
- Displacements are computed with respect to the global co-ordinate system.
- As the model crashes into the rigid pole,the deformation occurs to each nodes and the nodes gets displaced from their initail position.
- During the simulation,maximum displacement occured at node 190233 which is shown in above fig.
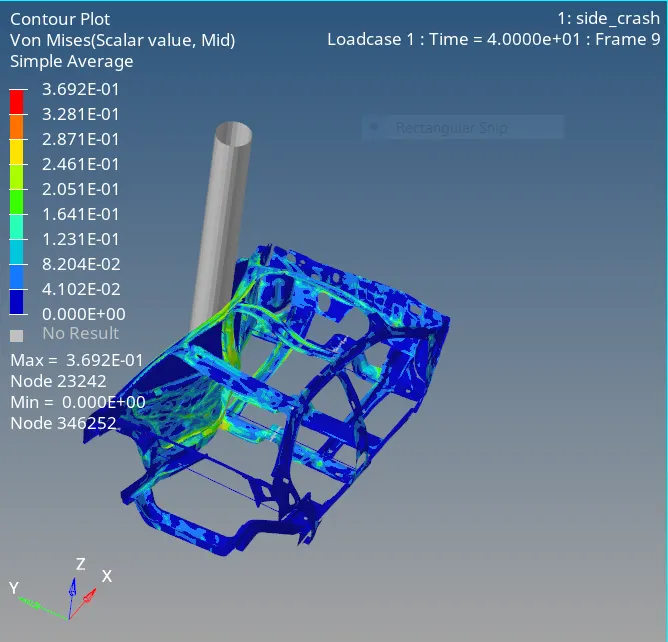
- Here the contour plot gives the stress induced at each node in the BIW model of the car.
- As the model crashes,internal stress is developed in the model due to the material behaviour.
- During this simulation,the maximum stress developed at each node is 23242 which is shown in above fig
Check for the Intrusions:
- After running the simulation,we have to check for the intrusions.
- Note: The allowbale intrusion is 15 cm.
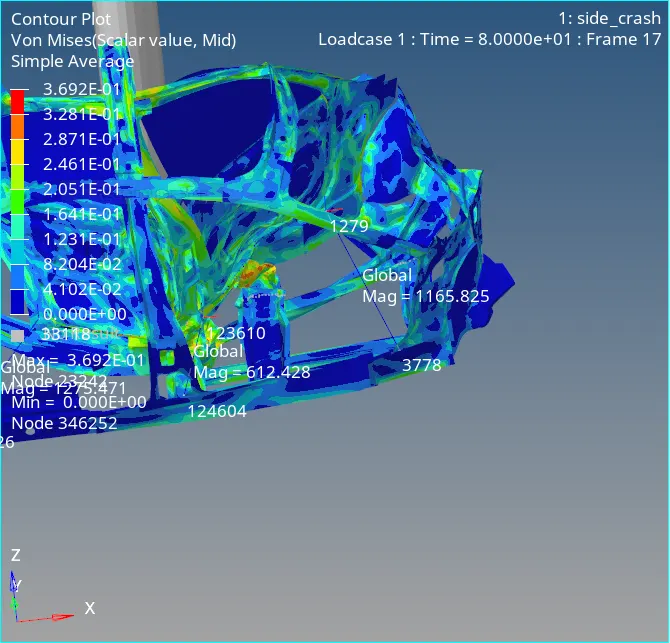
- To check for the intrusion,measure the distance between the springs where we created.
- To measure,go to measure tool from hyperview and select the end node of the spring to know the distance between them,which is shown in below fig.
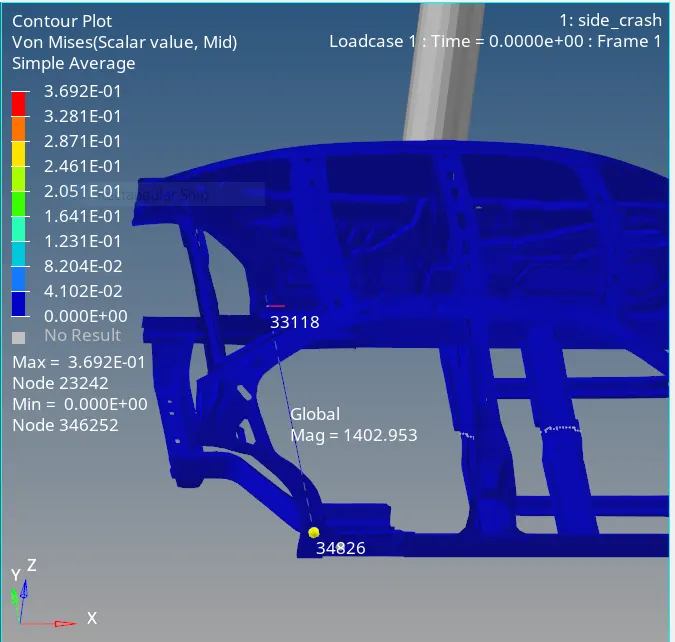
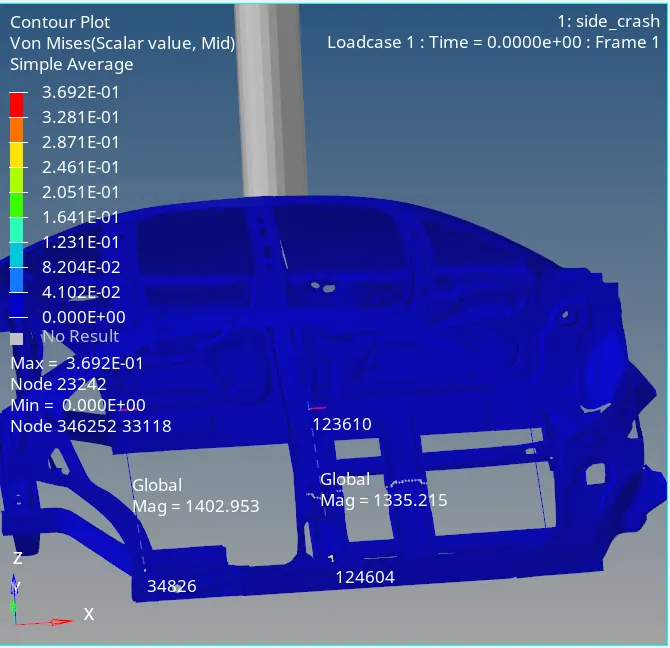
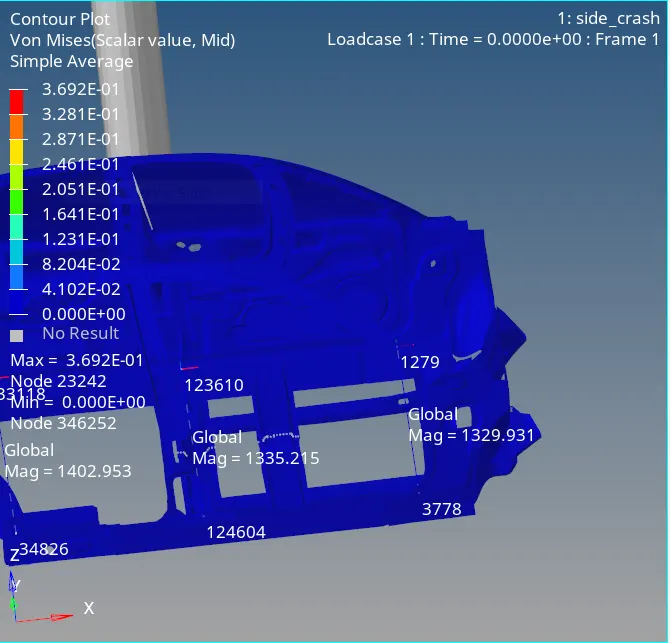
- After defining the nodes at the end of the spring at the initial position before the collision.
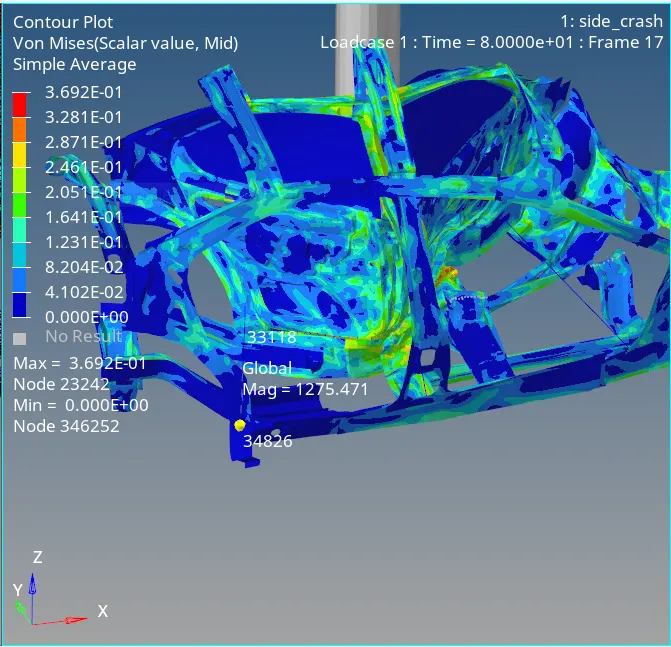
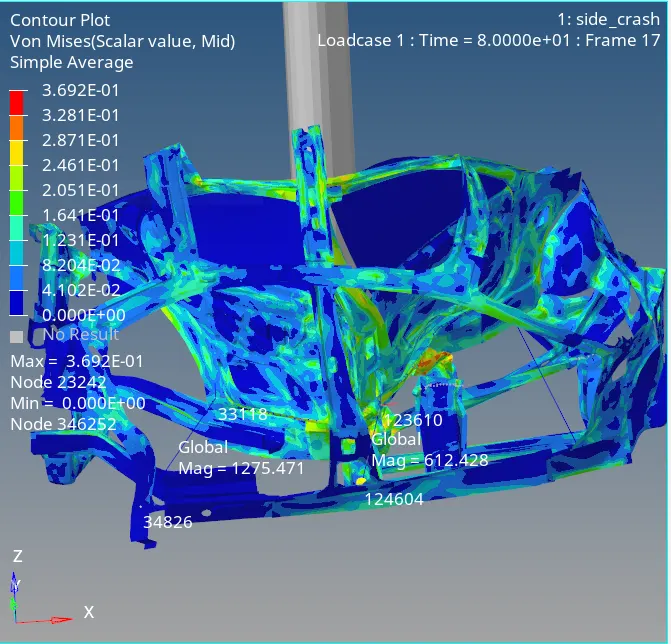
- After defining the nodes at the end of the spring after the collision.
Intrusion at fuel tank region:
- Intrusion at fuel tank region is 1402.953-1275.471= 127.482.
Intrusion at B- pillar region:
- Intrusion at B pillar region is 1335.215-612.428=722.787
Intrusion at hinge-pillar region:
- Intrusion at hinge-pillar region is 1329.931-1165.825=164.106
2) Plot the graph using-hypergraph 2D:
- Now plot the graph using hypergraph 2D,we are plotting the graphs to see what is happening in the rail component.
- Hypergraph 2D is powerful data analysis and plotting tool with interfaces to many popular file formats.
- It is sophiscated math engine capable of processing even the most complex mathematical expressions.
- Hypergraph 2D combines these features with high quality presentation output and customization capablities to create a complete data analysis system for any organization.
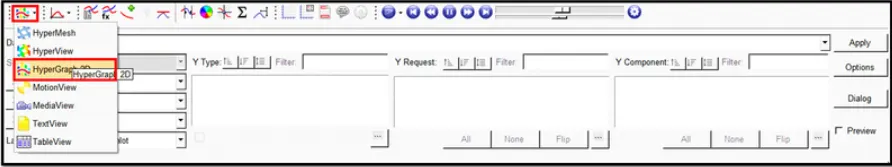
- Here switch to the hypergraph 2D to the plot the graphs.
- To switch,go to client selector>> choose the hypergraph 2D as shown in above fig.
- [Note: Before plotting the graphs,make sure to split the screen into three or four then plot the graphs.
- The first graph is plotted for the right rail at the created section.
- To plot the graph,go to hypergraph 2D>>Data file>> frontal_crashT01>>Apply.
Intrusion graph for the fuel tank region:
- Here the graph is obtained for the fuel tank region which is shown in below fig.
- In the begining,the length of the spring was 1402.953 mm and after when the car crash the pole,the length of the spring is 1275.471 mm so the total deflection of the spring is= 127.482..
Intrusion graph for B- pillar region:
- Here the graph is obtained for the B-pillar region which is shown in below fig.
- In the begining the lenth of the spring was 1335.215mm and after when the car crash the pole,the length of the spring is 612.428mm so the total deflection of the spring is 722.787mm.
Intrusion graph for hinge-pillar region:
- Here the graph is obtained for the hinge-pillar region which is shown in below fig.
- In the begining,the length of the spring was 1329.931mm and after when the crash the pole,the length of the spring is 1165.825mm,so the total deflection of the spring is 164.106mm.
Peak velocity:
- The graph obtained for the peak velocity is shown in below fig.
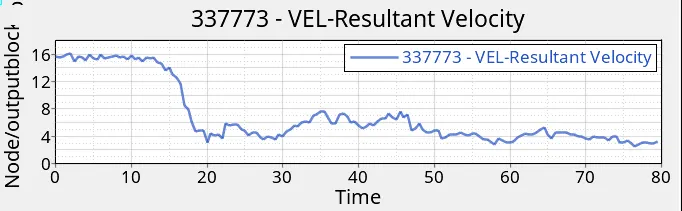
- When the car hits the pole the door will be deformed so due to the deformation the inner portion of the door will hit the passengers inside the car and it may cause severse injuries to the passengers.
- so it is important to calculate the peak velocity at the door region.
- The peak velocity of the node on the door is 15.663 m/s,the graph is zig-zag form,due to the noise and vibration,when the car hita the pole.
- Here the velocity is starting from the peak due to the initial velocity is given and it goes on decreasing cause the car goes and hits the pole,due to deformation,its decreasing.
- We gave the inital velocity as 14.912 m/s but in the graph,the initial velocity is 15.663m/s It's increased little bit,beacuse due to inertia.
Interface [TYPE 7]:
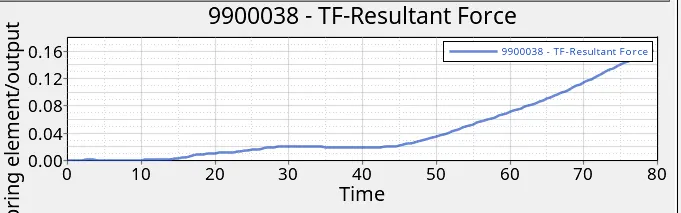
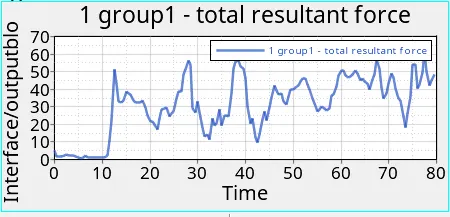
- The graph obtained for the type-7 total resulatant force interface is shown in below fig.
- Here the interface curve starts from origin and reaches peak due to collision.
- And it increases and decreases before it reaches to peak value,cause there will be a contact forces acting with in the car before collision.
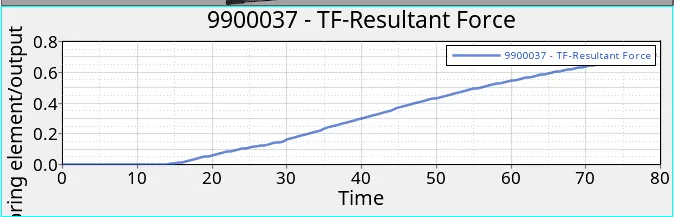
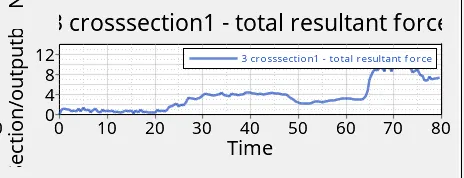
Sectional force at the cross member 1:
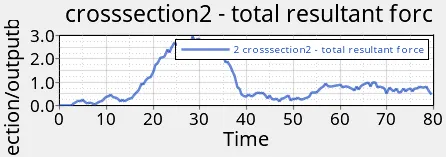
- The graph obtained for the sectional force at cross member 1 which is shown in below fig.
- The maximum sectional force on the cross member is 2.938 KN
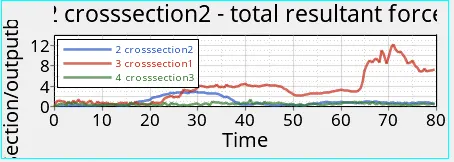
Sectional force at cross member 2:
- The graph obtained for the sectional force at cross member 2 which is shown in below fig.
- The maximum sectional force on the cross member 2 is 12.237 KN
- Here the sectional force is more than the cross member 1.
Sectional force at cross member 3:
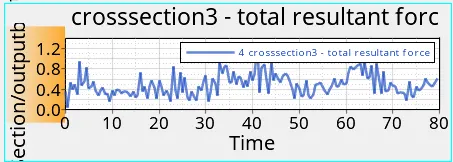
- The graph obtained for the sectional force at cross member 3 which is shown in below fig.
- The maximum sectional force on the cross member 3 is 0.884 KN
- Here for this cross member,the sectional force is very low when compared to the previous two cross members.
Variation in sectional forces:
All energies:
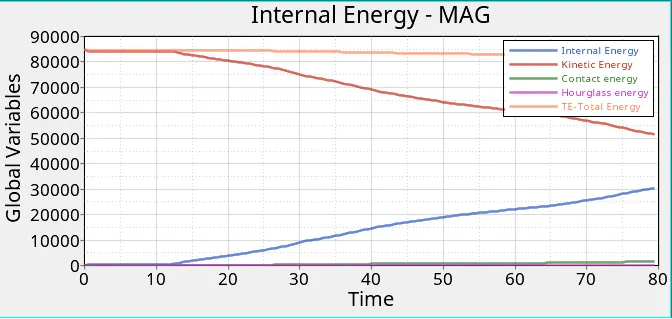
- All the energies have been plotted which is shown in below fig.
Kinetic energy:
- The graph obtained for kinetic energy is shown in below fig.
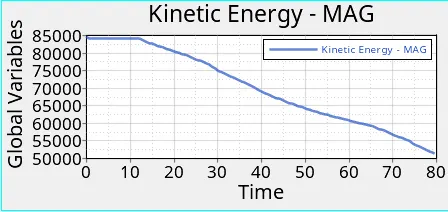
- Kinetic energy is at peak in the starting why because we have huge mass.
- Kinetic energy is lower and decreases why because there is a velocity applied to the car component so its getting deformed and the kinetic energy decreases.
- The kinetic energy will decrease due to the decrease in velocity after the collision,when the car hits the rigid pole so the kinetic energy decreases with respect to time.
Internal energy:
- The graph obtained for the internal energy is shown in below fig.
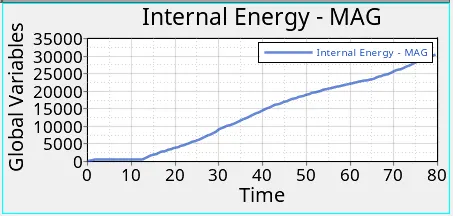
- The formula for internal energy is E= Q+- W
- Here the heat is neglected cause there is no heat transfer we will be having only work done.
- W=FXD
- F=ma
- Here the internal energy is zero because there is no deformation initially so the internal energy is zero and starts from zero and goes on increasing.
- The internal energy increases because the deformation is happening,there is a displacement,so the internal energy increases when the displacement or deformation occurs.
Contact energy:
- The graph obtained for the contact energy is shown in below fig.
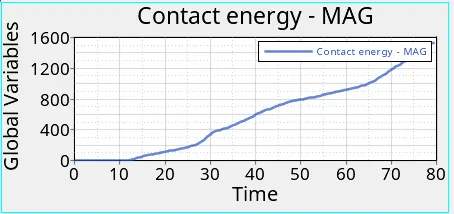
- Here the contact energy starts from the origin cause the car is in initial condition.
- Initially there is noo contact between the car and rigid pole.
- There is also no deformation initially but when the car goes and hits on the rigid pole,the contact energy starts increasing.
- When the deformation or displacement happens to the car,the contact energy inreases cause the car component comes within the contact to the rigid pole,so the contact energy goes on increasing.
Total energy:
- The graph obtained for total energy is shown in below fig.
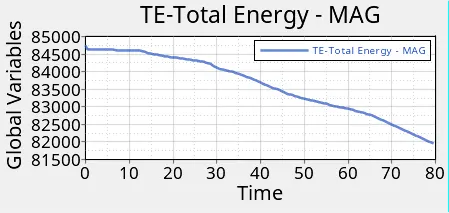
- Total energy is sum of kinetic energy+contact energy+hourglass energy+internal energy
- Here total energy starts from higher value in starting itself its increasing,why because the total energy is sum of kinetic energy+contact energy+hourglass energy+internal energy.
- All energies are in initial condition except kinetic energy so kinetic energy is only there
- Kinetic energy is directly proportional to the total energy.
- So the total energy is increasing in the begining.
- Due to -1.8% of the energy error,the total energy is decreasing.
Hourglass energy:
- The graph obtained for the hourglass energy is shown in below fig.
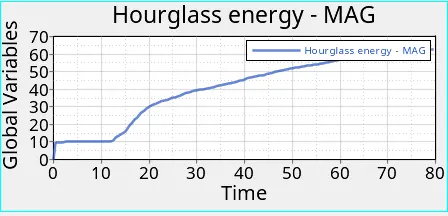
- Here the hourglass energy is less than 5% of the internal energy,so it is fine.
Result:
- Here the COG from the initial position has been changed to the required position by mass balancing.
- Hence the penetration and intersections has been verified successfully.
- Hence the interfaces created newly.
- Hence the peak velocity has been given to the inner node of the door.
- Hence the initial velocity was assigned.
- Hnece the rigid pole was created successfully.
- Hence the springs were created to obtain the intrusions.
- Hence the TH for all inputs were cretaed inorder to obatined otputs.
- Hence the simulation was runned successfully without any errors.
- Atlast all the graphs were plotted with the obtained results.
Conclusion and learning outcome:
- How to change the COG position.
- How to check for the penetration and intersections.
- How to create the interfaces and how to find connectivity,to check whether the free parts exsist in the components.
- How to give peak velocity of the inner node of the door.
- How to assign the initial velocity.
- How to create the springs to obtain intrusions.
- How to create a rigid pole according to FMVSS 214 Standards.
- How to request outputs.
- Learned about the FMVSS 214.
- Learned about the sectional forces,axial forces.
- Sasikumar DharmarajVery nice...