I. OBJECTIVES
- To carry out the Frontal Crash Analysis of a BIW for the given dummy dar model.
- To set up the model as per the below-mentioned case and ensure the correct running of the simulation.
- To extract all the output requests and the mandatory results and document the whole procedure with proper explanations and conclusions.
-
Frontal Crash - BIW:
- Check unit system and either follow[Mg mm s] or [Kg mm ms].
- Create an appropriate interface, friction 0.2, and recommended parameters.
- Make sure of no penetrations and intersections.
- Correct rigid bodies if any issues.
- Create a rigid wall with the friction of 0.1.
- Compare the model weight with the full-scale 300k nodes model and use added masses to reach the target weight of 700kg while getting CG about the required range.
- Initial velocity 35 mph.
-
Add the following Output Requests:
- Sectional force in the rails at the location of indicated node 174247.
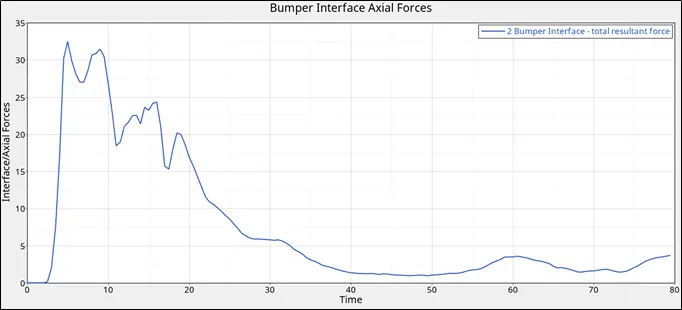
- The axial force received on the rails from the bumper.
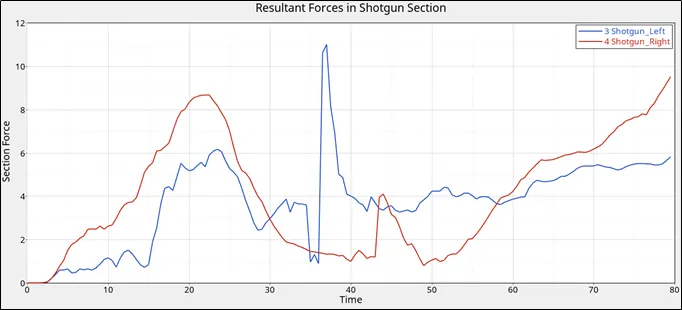
- Shotgun cross-sectional forces.
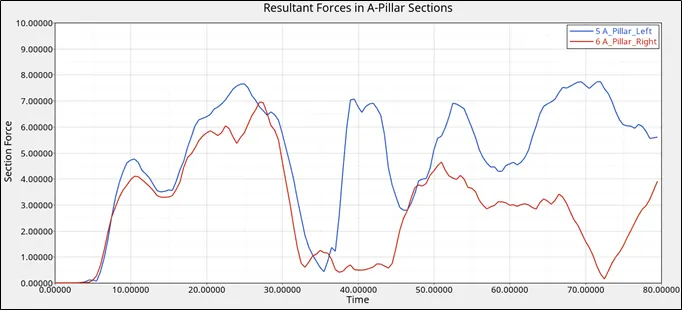
- A pillar cross-section.
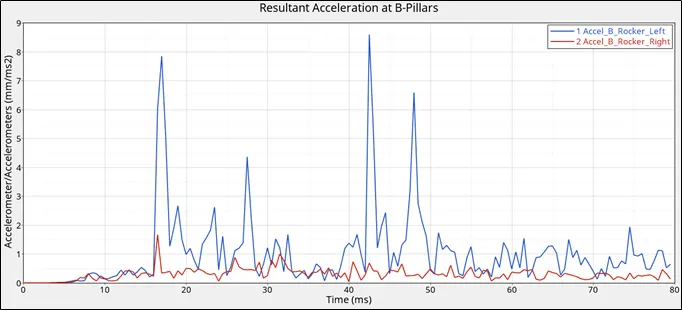
- Acceleration curve received on the accelerometer at base of B pillar (on B pillar rocker).
- Intrusions on the dash wall 66695,66244.
- Use a model checker to ensure good quality.
- Time-step :0.5 to 0.1 microseconds.
- Run 80 ms.
II. GIVEN MODEL
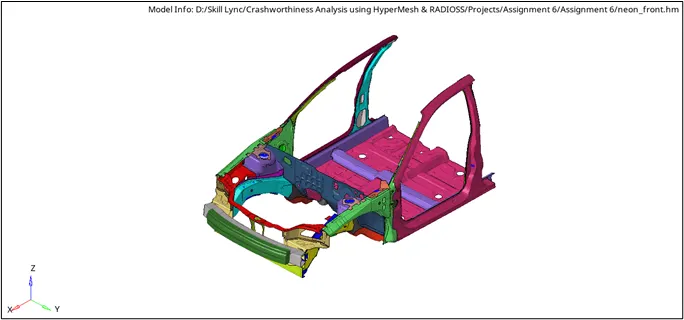
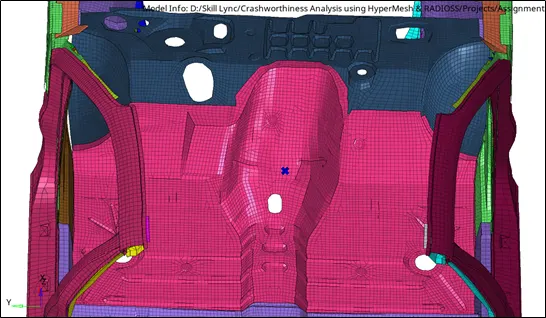
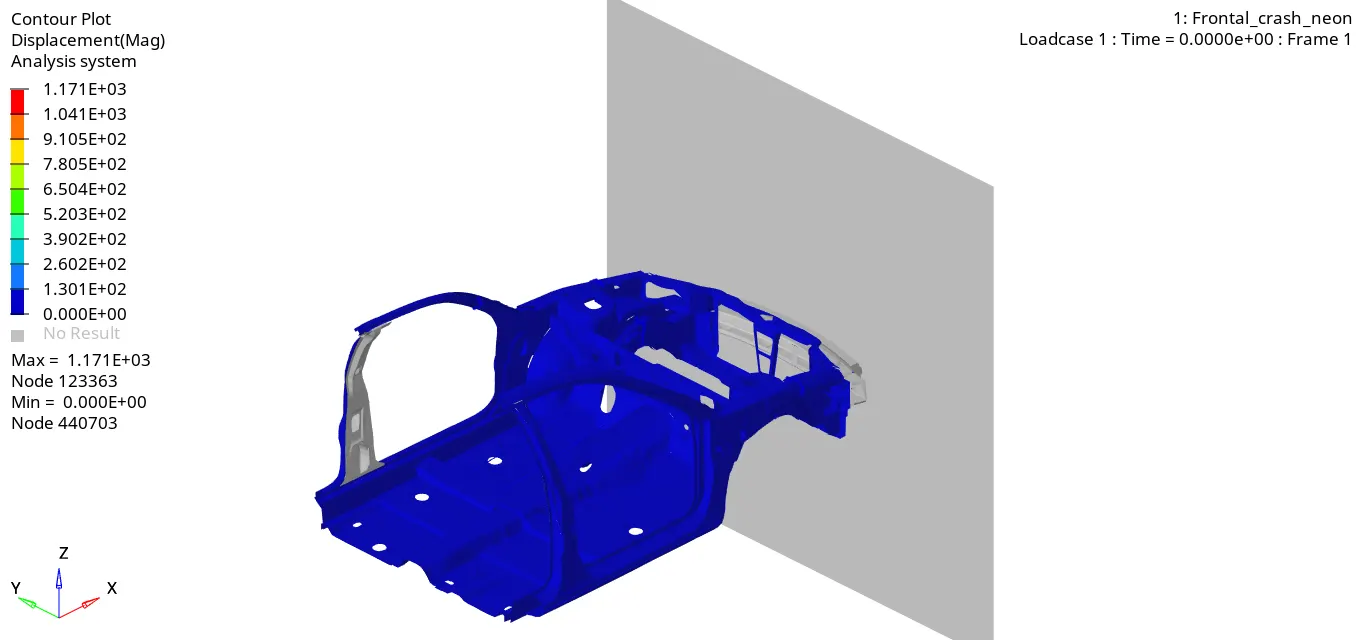
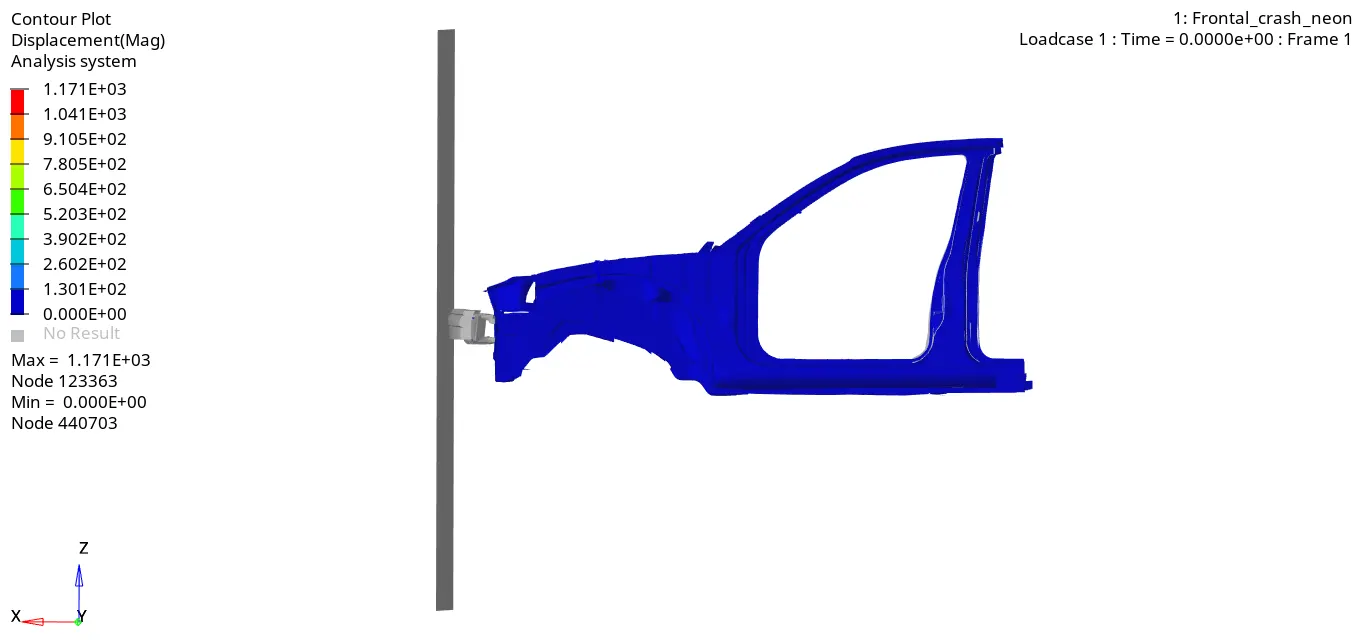
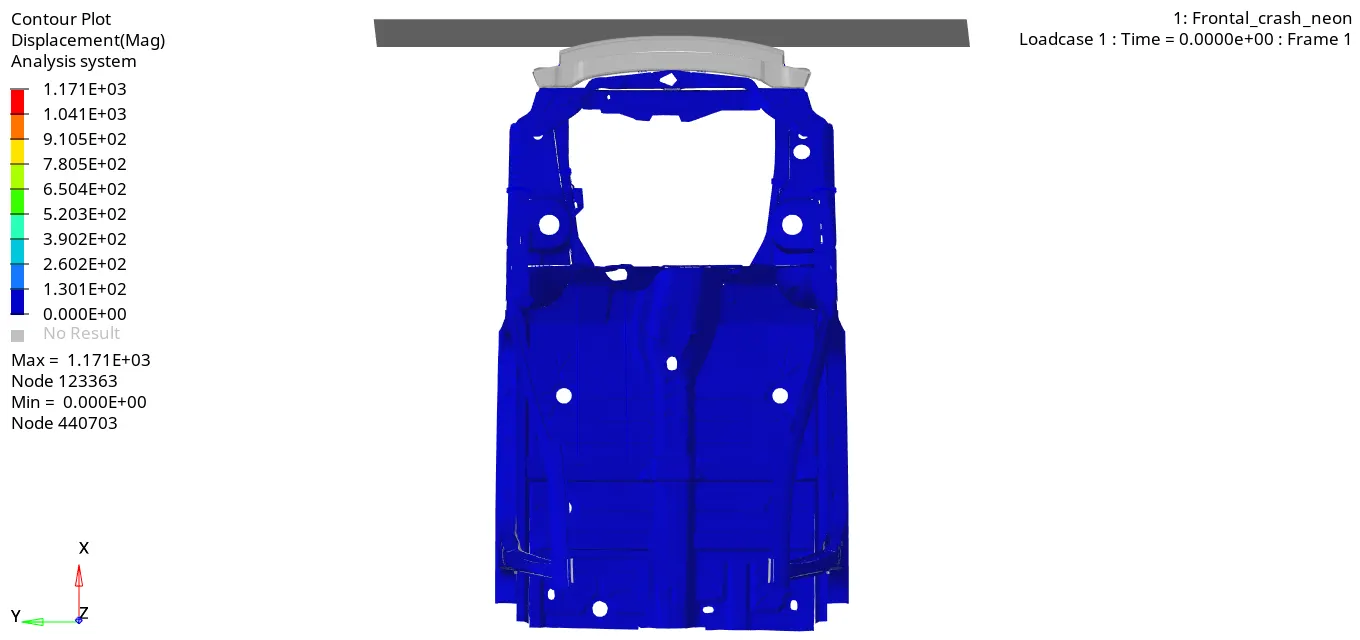
| Fig.1. Neon BIW model for Frontal Crash |
III. PROCEDURE
- The neon_front_0000.rad Starter file and the neon_front_0001.rad Engine file has been provided. For this project, we shall use both HyperMesh as well as HyperCrash for the set-up.
- The starter file is thus imported in HyperMesh via the Import Solver Deck. The model can be seen as shown in figure 1.
- Frontal Crash - BIW
- Check unit system and either follow[Mg mm s] or [Kg mm ms]
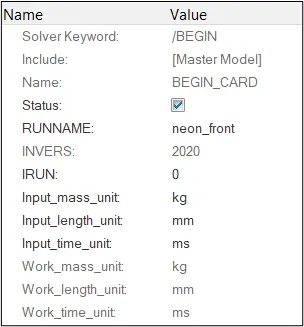
- Once the model is imported, we can navigate to the BEGIN_CARD in the Cards subsection from the model tree. The Input Units would be visible which are set to [Kg mm ms] as seen in figure 2. Hence these are left unchanged.
2. Create an appropriate interface, friction 0.2, and recommended parameters
- We start by removing the default interfaces and replacing them with our custom single Type 7 interface. Present interfaces are simply deleted by selection in the INTER subsection from the Solver Tree.
- By right-clicking on the tree, we can select Create and navigate to INTER → Type 7. A new Interface card will be created which will be renamed as desired.
- All the nodes and elements are selected respectively to set the master and slave. The total number of each entity will be displayed.
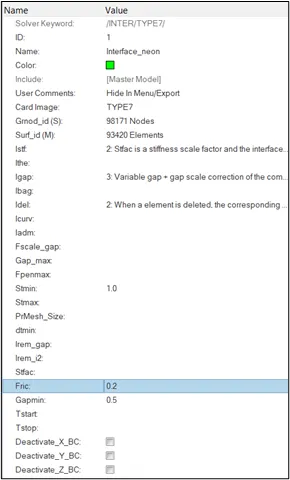
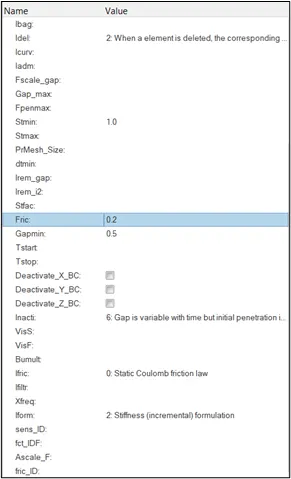
- As per the Friction of 0.2 and the recommended properties are concerned, the values are set as seen in figure 3.
| Fig.3. Type 7 Interface with recommended properties |
3. Make sure of no penetrations and intersections
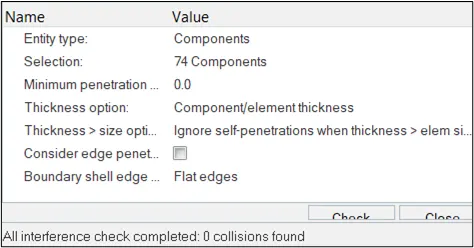
- The Penetration Check can be done by navigating to Tools → Penetration Check.
- Here the check type should be set to Intersections and penetrations. The selection type will be set to components where all the components are selected.
- The Check button is clicked. There was no kind of penetration present in the model.
4. Correct rigid bodies if any issues
- No rigid body corrections were needed.
5. Create a rigid wall with the friction of 0.1
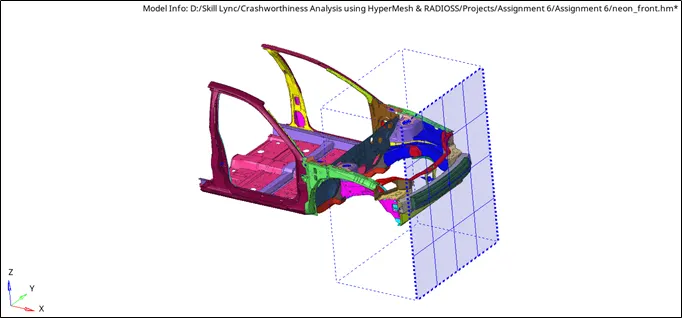
- To create a Rigid wall, we right-click on the Solver tree and navigate to RWall, and select Plane. A new card will get created and can be renamed,
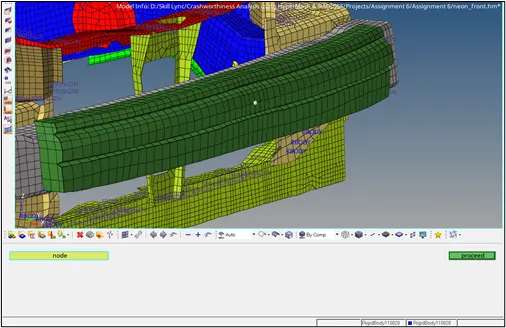
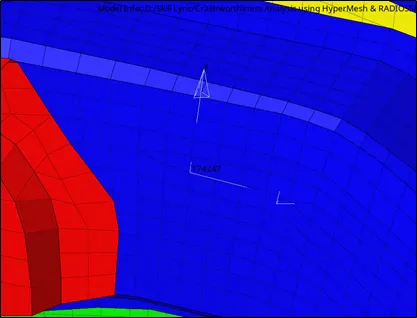
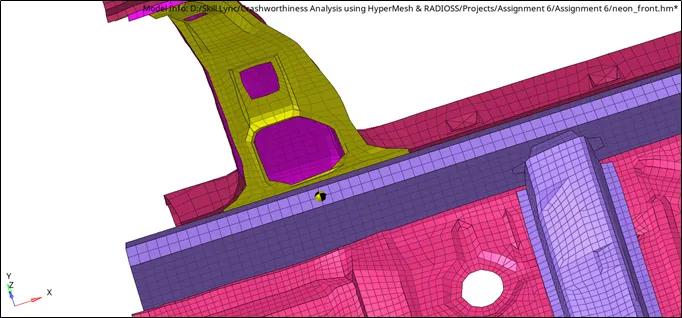
- An appropriate node is selected from the bumper section to get the reference coordinate for the wall. Figure 5 shows the selected node.
| Fig.5. Rigid Wall node placement |
- Since our body should be 5 to 10 mm away from the wall, the XM coordinate is changed from 4596 to 4605 units. The Normal X value is set as -1 to make the wall face against the car front. The Slide option is set to 2:Sliding with friction. With this, we can add our friction value as 0.1. The Dsearch value is set to 1000 and with this, the wall is created.
6. Compare the model weight with the full-scale 300k nodes model and use added masses to reach the target weight of 700kg while getting CG about the required range
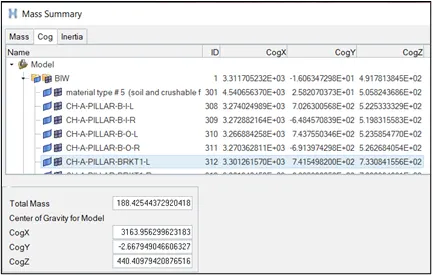
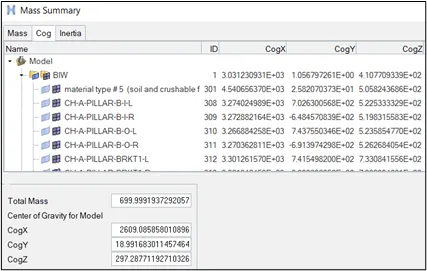
- The full model is opened in HyperCrash and is compared with the model we are working on. The COG of both the models lies on the same spot. Figures 7 and 8 show the CoG and Mass values as well as the point created to display the COG of our model.
| Fig.7. Total Mass & CoG coordinates |
- Our task is to get the total mass of the model up to 700 Kg and move the CoG towards the center in between the seats. The estimated addition of mass is approximately 511.575 kg. Hence, 255.7875 Kg on each side.
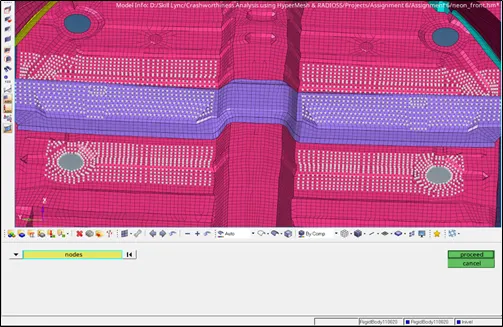
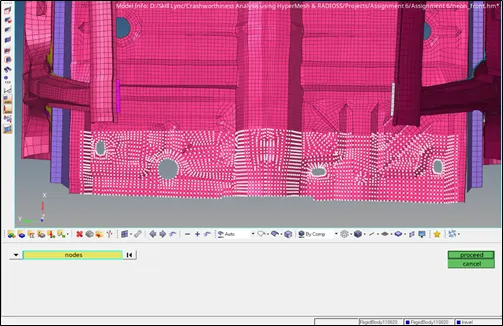
- Now, the positioning of the mass addition and distribution has to be decided. We can assume that the seats will be mounted in a way that the mass will be distributed across the nodes in the area. We will create two mass additions, for front and back respectively.
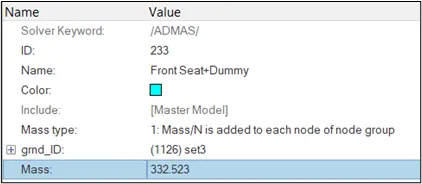
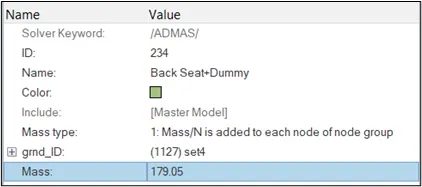
- To create the masses, we right-click on the solver and navigate to Create and select ADMAS card. We create two such cards.
- Since we will be distributing the mass on every node we select, a general mass split can be done. This means that if we can provide a general 65:35 split for the front and rear respectively. With the total mass addition of 511.575 Kg, we calculate the front split as 332.523 Kg and the rear split as 179.05 Kg.
| Fig.9. Node selection for Mass Addition Distribution |
| Fig.10. Mass Addition Cards |
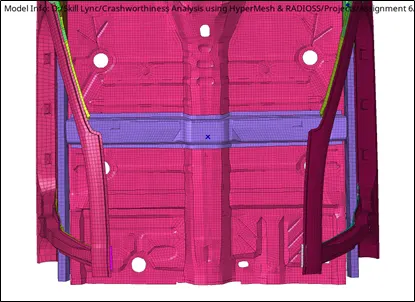
- Once the Mass addition is done, we can check the CoG and total mass from the Tools dropdown menu. We can achieve the final mass of 700 Kg. After plotting the coordinates of the CoG, we get the desired result. The following figures depict the same.
| Fig.11. Total Mass & final CoG coordinates |
| Fig.12. The final point of CoG |
7. Initial velocity 35 mph
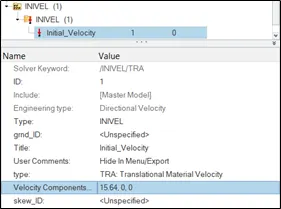
- The initial velocity is a boundary condition that is very straightforward to apply. We again right-click on the Solver tree and navigate to Create → BOUNDARY CONDITIONS → INIVEL. A new card under LOADS will be created. it is renamed accordingly.
- Since the value of the initial velocity of 35 is given in mph, we will convert the units to mm/ms which comes out to be approximately 15.64 mm/ms. Thus, the velocity component will be [15.64,0,0].
| Fig.13. Initial Velocity Card |
8. Adding the Output Requests
- Before getting started with the Output requests, we have to add the sections for forces, accelerometers for the acceleration curve, and intrusions.
- Starting with the sections, we have to create 3 pairs of sections to get the forces on either side of the shotgun, rails, and the A-pillars. To create a section, we need a frame of reference that can act perpendicular to the area. Hence, by right-clicking on the Solver tree, we navigate to FRAME and select Mov, i.e. Moving frame.
- Now, it is given in the question to create one of the sections on Node 174247. Hence, the origin will be selected using this Node ID. For the second reference, the option is toggled to the z-axis and a node is selected in the direction of the crash. The third reference node can be selected as desired. The create button is clicked and a frame with a local coordinate system is created as seen.
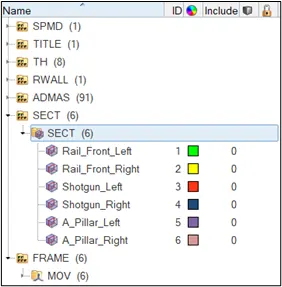
- Once the frame is created, we can make the sections for the output requests. Again, by right-clicking on the Solver tree, we can navigate to SECT to create a section card. A total of 6 cards are created as discussed. Each one is renamed accordingly.
- Now, by clicking on the Frame_ID, we can select the respective frame system and create an infinite cross-sectional plane.
| Fig.15. Cross-section plane created |
- By right-clicking on grshel_id, we create a shell elements group. Clicking on Entity_id, we select two rows of elements to cover the area for output request.
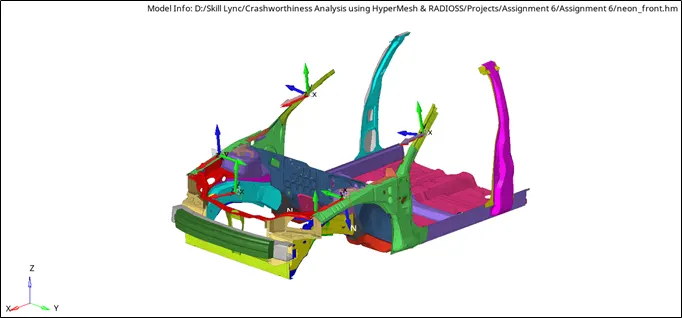
- This will finish the creation of one section. This shall be done for all six sections under discussion. Once created on their designated components, we can see them in figure 17.
| Fig.17. All created Sections |
- To create the accelerometers, we right-click on the Solver tree and select ACCEL. This creates the ACCEL card and is renamed. For convenience. A node on the B pillar rocker is selected and an accelerometer is created. An identical card is created for the right-hand side pillar as well.
| Fig.18. Accelerometer on B-Pillar rocker |
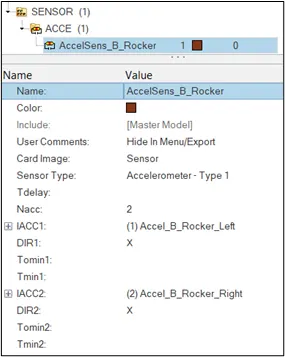
- Now we create the Sensor card for the accelerometers. By right-clicking on the tree, navigating to SENSORS, and selecting ACCE, a card will be created. The value of Nacc is set as 2 because we have 2 sensors. By clicking on lACC, we can select both the accelerometers.
| Fig.19. Accelerometer Sensor Card |
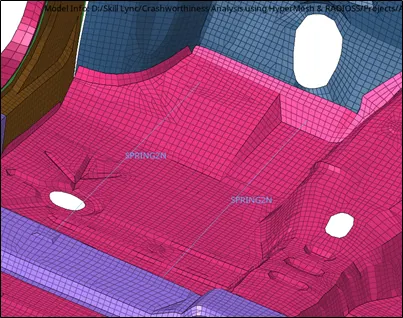
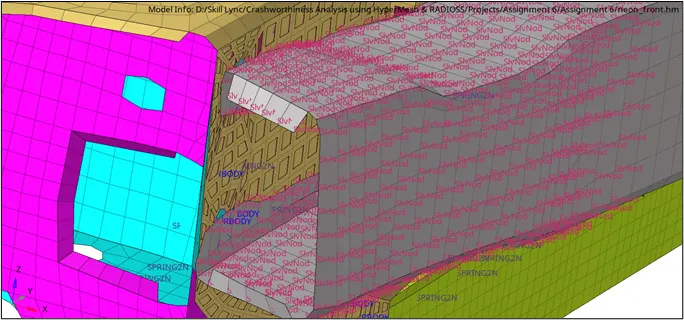
- To get the Intrusions, we will have to create Spring elements on the designated nodes, 66695, and 66244. Spring elements are straightforward elements to create. The following elements were created.
| Fig.20. Spring Elements for Intrusion |
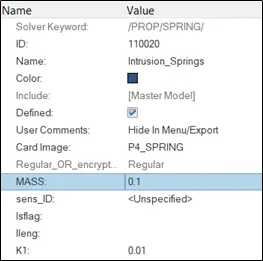
- The Property card for the spring elements is created, and minimal values of mass and stiffness are given. The property is then assigned to the elements component.
| Fig.21. Spring Elements Property card |
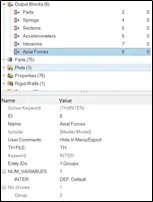
- For the axial forces on the bumper, we can create a new Interface on the required components and add it to the output block. The following interface was created for axial forces.
| Fig.22. Interface for Axial Forces |
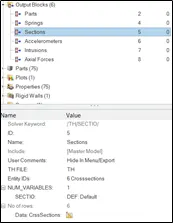
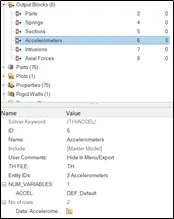
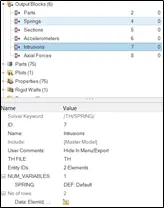
- Now we move on to create the output requests from the above entities. For this, we use the output Block in the Model tree window. We create Output Blocks for the required number of results. The selection of the entities is done based on their types, i.e. sections, groups, etc. The following output blocks are created.
9. Use a model checker to ensure good quality
- We export the current file to HyperCrash to use the model checker. The Export Solver Deck option is used to do so. The name is changed accordingly.
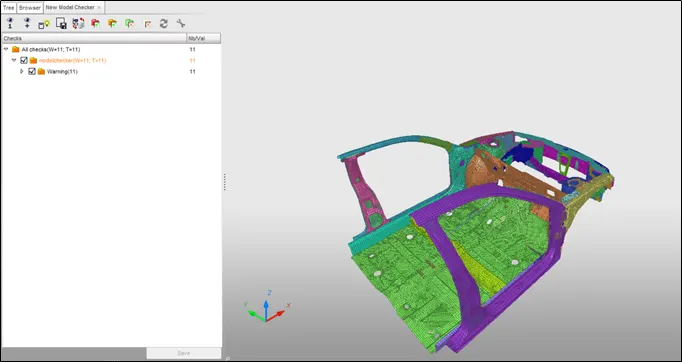
- Once the file is opened in HyperCrash, we navigate to the Model Checker in the Quality dropdown menu and Run the checker. As seen in figure 24, no errors were found. Though some warnings are displayed, they can be ignored since no major hindrance is caused by these warnings.
| Fig.24. Model Checker Results |
10. Time-step: 0.5 to 0.1 microseconds
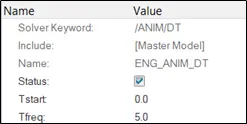
- To add the timestep, we change the value of Tfreq from the ENG_ANIM_DT to 5.
11. Run 80 ms
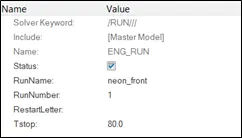
- To run the model at 80 ms, we change the value of Tstop from the ENG_RUN to 80.
- Now we can finally go to Analysis → RADIOSS → Save file as... → Rename file → Radioss. The solver view will open and the simulation will start.
IV. RESULTS
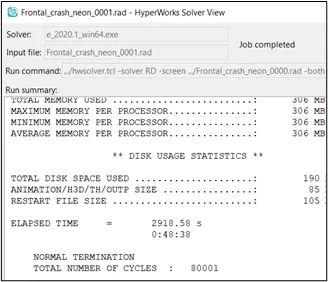
- After the simulation run is over, we get the following elapsed time and number of cycles:
| Fig.27. Solver View Window |
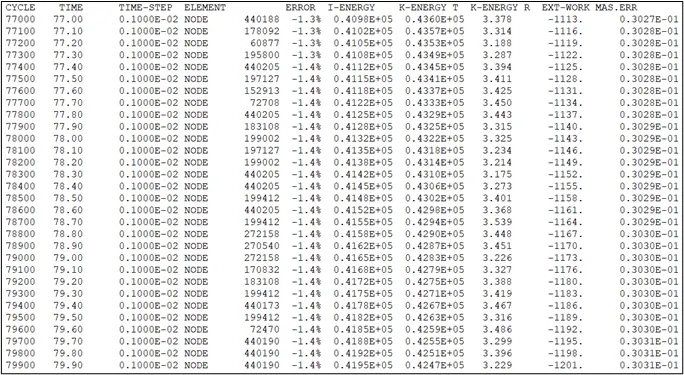
- Energy and Mass Error:
| Fig.28. Output File Errors |
It is clear from the Output file results that the value of the energy error lies between -15% and 5%. Also, the mass error does not exceed 1 which marks it workable.
- Crash Simulation Animations
To create the animations, we use the HyperView tool. The .h3d file from the simulation is extracted and then applied to play the animation. The animation helps us determine how the car's front structure reacts to the crash and how it deforms while dissipating energy.
| Fig.29. Crash Animation with necessary views |
|
- Result Graph Plots
To plot the graphs from the results extracted from the simulation, we use the HyperGraph 2D tool. The T01 file is opened via this tool and the required graphs are plotted by selecting the Y-axis components.
⇨ Energies Plot
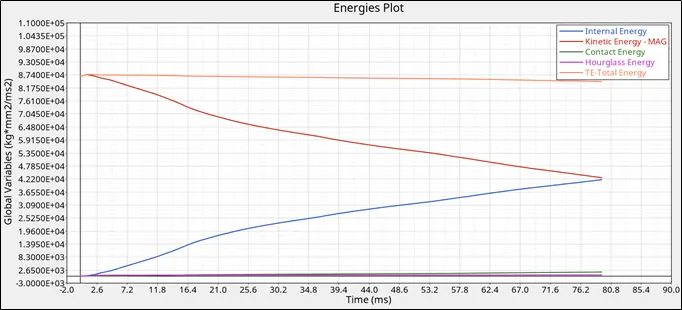
| Fig.30. Energies Plot for Crash |
Here, five kinds of energies are plotted, namely, Internal, Kinetic, Contact, Hourglass, and Total Energy. The graph shows the energy characteristics resulting due to the behavior of the Car BIW during a crash. For the first few milliseconds, there seems to be not much change since there is no contact. Once the body starts to crash into the wall, the internal energy starts to increase since stresses are generated inside the structure resulting in deformation. Understandably, the Kinetic energy decreases due to the decreasing velocity of the structure. All in all, the Total energy is almost constant, but due to the presence of slight Contact energy, the resultant value drops as well. Contact Energy is the energy applied by the system to avoid penetration of elements. After deformation occurs, the system will need to gradually apply more and more energy to avoid penetration of elements. We also avoided Hourglass energy by using the reduced integrated QEPH elements.
⇨ Sectional Force in the Rails
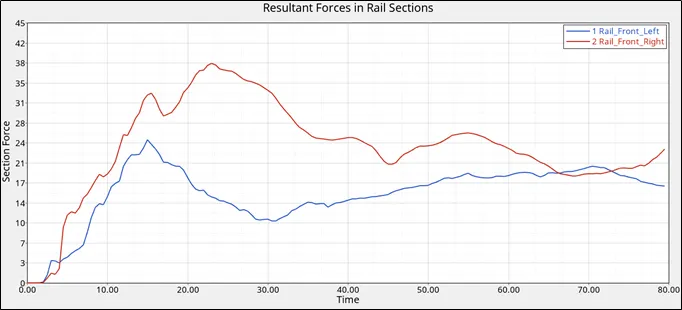
| Fig.31. Resultant Force Plot for Rail Sections |
From the above plot, we can derive the force values. The maximum force value on Left Rail was 24.76 KN and on Right Rail was 37.96 KN. The curve characteristics are different for both the rail sections. Since the energy transferred from the bumpers after the crash varies for both sections, we get different behavior of forces. This can be verified via crash animations.
⇨ Axial Forces from the Bumpers onto the Rails
| Fig.32. Resultant Axial Forces Plot for Bumpers |
From the above plot, we can derive the force values. The maximum force value on the interface was found to be 32.46 KN. This force is generated by the Bumpers that hit the rigid wall and absorb some amount of it. Due to this, the value of the force transferred to the Rails decreases. The value keeps decreasing since there is a lowering of the momentum after deformation.
⇨ Cross-sectional Forces on Shotgun
| Fig.33. Resultant Forces Plot for Shotguns |
From the above plot, we can derive the force values. The maximum force value on Left Shotgun was 11 KN and on Right Shotgun was 9.5 KN.
⇨ Sectional Forces on A-Pillars
| Fig.34. Resultant Forces Plot for A-Pillars |
From the above plot, we can derive the force values. The maximum force value on Left A-Pillar was 7.73 KN and on the Right A-Pillar was 6.95 KN. The A-Pillar is one of the major structural components in a chassis which are made to handle compressive loads since this is a slender structure. There are forces exerted as soon as the crash initiates. The wavering behavior of the graph is due to the slight pitch happening in the structure. Hence, the force characteristics also change
⇨ Acceleration Curve from the Accelerometers on B-Pillars
| Fig.35. Acceleration Plot at B-Pillars |
From the above plot, we can derive the acceleration values. The maximum acceleration value on Left B-Pillar was 8.58 mm/ms2 and on the Right B-Pillar was 1.66 mm/ms2. The acceleration is non-existent till the car hits the wall. Due to inertia, there happens to be a change in momentum which causes the acceleration. The frontal portion decelerates at a higher rate compared to the rear portion. The crash scenario induces a varying amount of vibrations in the whole structure which explains the sudden spikes throughout the time interval.
⇨ Intrusions on the Dash Wall
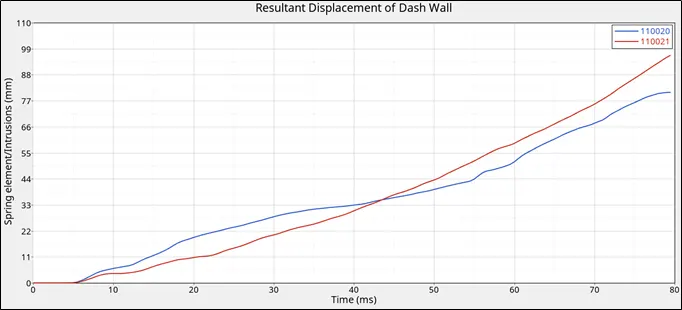
| Fig.36. Intrusion Displacement Plot on Dash Wall |
From the above plot, we can derive the elongation/displacement values. The maximum elongation on the first spring element was 96.2 mm and on the second spring element was 80.57 mm. These values suggest that by how much the dashboard will displace in the direction of the passengers. A lower value is mandatory since passengers are to be kept harmless at the time of a crash. Also, from the animation, it can be verified that how the dashboard elongates to ensure the passengers' safety.
V. CONCLUSIONS
- The following conclusion points can be drawn from the above assignment:-
- The Frontal Crash simulation of the Dodge Neon BIW was successfully carried out.
- The model was properly set up for a successful simulation run without any errors.
- Various Output Requests were created from the simulation to get the mandatory results.
- The behavior of the car structure was studied based on the results extracted from the simulation.