Frontal car BIW crash analysis under FMVSS using Hypermesh & Radioss.
OBJECTIVE: To Study the behaviour of Frontal crash with given loading conditions and boundary conditions. That includes sectional forces t various parts, intrusions at passenger compartment, accelerometers.
(Since due to limitiation of 100k nodes in Student edition calculation is done on BIW model till B-pillar with 99084 nodes in total.)
ABSTRACT:
Front crash, one of the most important parts of testing a new car and making sure it will be safe on the streets, for its driver, its passengers and the other people outside the car, whether we’re talking about pedestrians or other drivers. vehicle is projected towards a solid obstacle at a predesigned velocity. The obstacle can either be a concrete wall or a barrier., NHTSA is amending its safety standard on occupant crash protection to establish 56 km/h (35 mph) maximum speed for frontal barrier crash tests.
Another version of the frontal impact test involves a crash between two vehicles. This type of tests give a better picture about what exactly happens to passengers during the crash, but, as you can probably imagine, are also more expensive and that’s why car manufacturers usually perform more tests that involve a solid obstacle. Thats when proper design and Computed simulations come into picture. Real tests are just for approval of simulation results. Hence save lot of money.
BIW is the important part of whole car which when properly designed handles the forces in crash and saves lives.
Offset Tests: These tests are somehow similar to the frontal impact tests, but the difference is that only a part (smaller or larger, usually around half) of the car impacts the obstacle, whether it’s a wall, barrier or another car. This test is extremely important (perhaps even more important than the frontal crash one), because even though the impact area isn’t as large, the impact forces are almost as high as with the full frontal crash. This means that a smaller part of the car is responsible with absorbing all the impact force and this represents a challenge for car manufacturers, especially with this type of impacts being quite frequent.
ANALYSIS SETUP:
(Operations can be done in Hypermesh and in Hypercrash as well.)
1. Check unit system.
In BEGIN card, we can see the unit system we'll be considering throughout.
(it is important as same numbers with different unit system results in wrong calculations.)
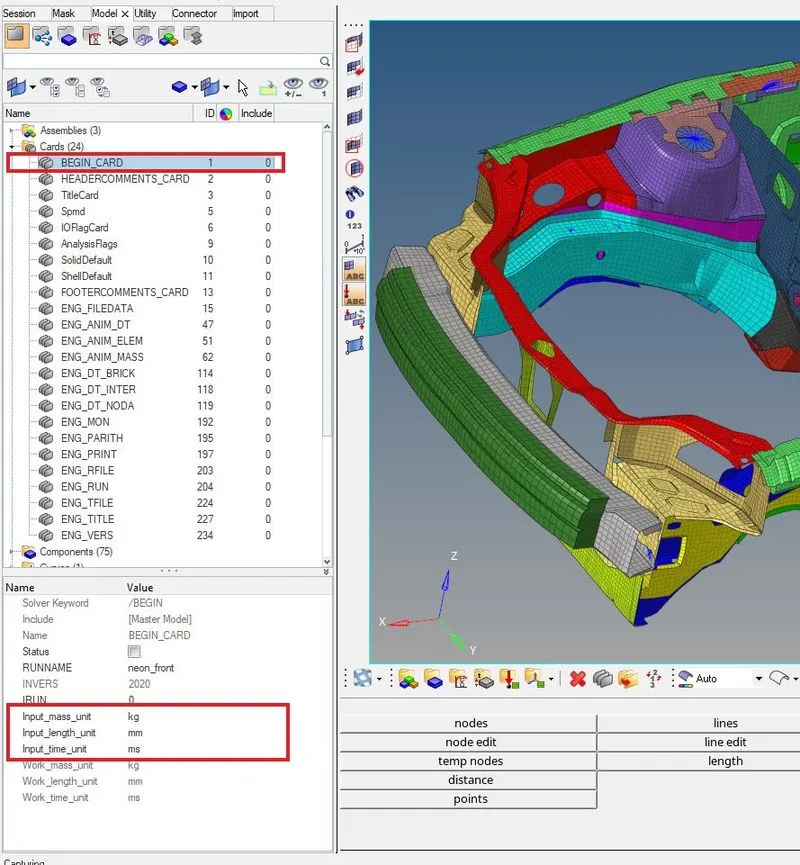
or can be checked or changed from Engine File
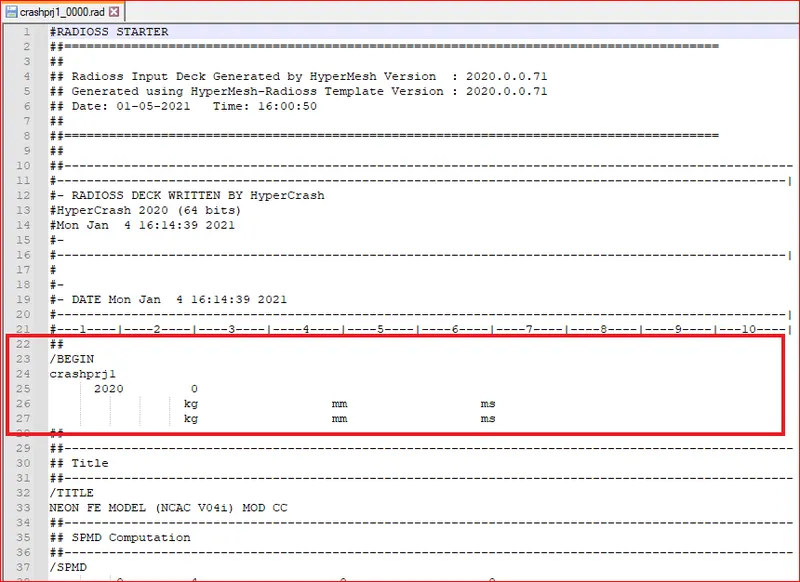
Here we will follow [Kg mm ms].
2. Use added masses to reach target weight 700kg while getting CG about the required range. (Done in Hypercrash)
- Browser > Added Masses > create new object
Type=1 Mass is distributed to each node of the node group (to randomly select nodes in some area)
Type=4 Final mass is distributed on part group. (to assign it to whole part)
- Add mass to target weight 700 kg.
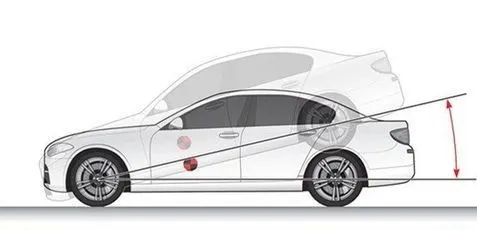
CG matters most during crash. CG, during a crash deccides whether your car is going to roll forward or yaw.vehicles with higher centers of gravity are at a greater risk of rollovers even when another car is not involved. The risk is even higher when these types of vehicles travel at high speeds. like Bus.
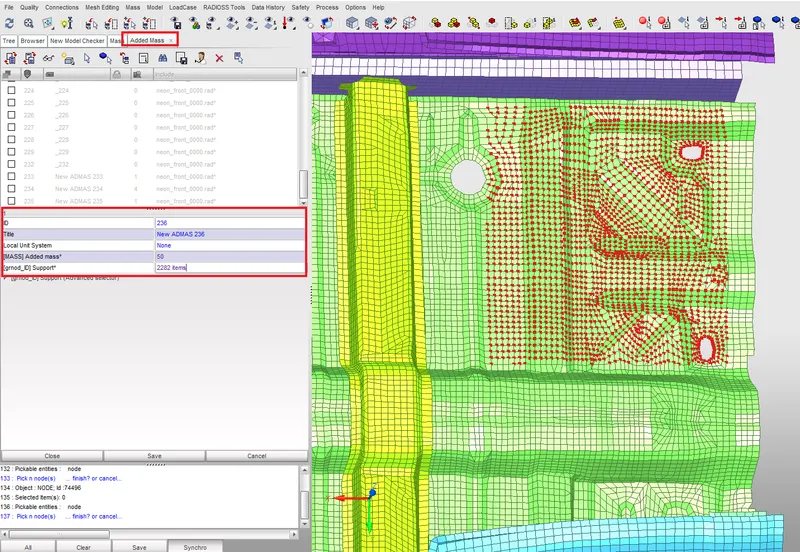
[Note: while adding mass check the unit Ton or kg, as it will change whole results. ]
Usually Ideal place of Cg in Car is under driver seat. As shown below.
3. Create appropriate interface ,friction 0.2 and recommended parameters.
(interface can be made in hypermesh also.)
The more interfaces we create more time will it take to compute. so no unnecessory interface should be ctreated.
Here we will create self impact contact interface as during front crach there are high chances of parts self impacting.
[Process :in Browser tab right click Create new> A-C > contact interface>Multi usage (type 7) ]
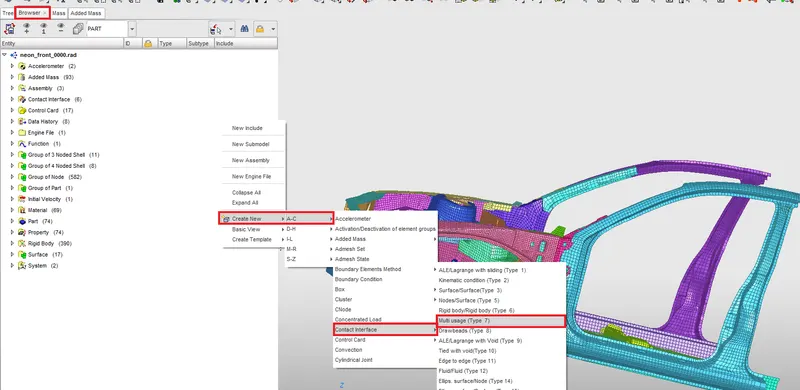
Type 7 interface:
(what is type 7 interface? )
It is a general purpose interface and can simulate impact between a set of nodes and master surface. Non oriented and slave nodes can belong to same master surface, hence self impact possible with type 7.
Recomended parameters
- Remove all intersectons to get physical results and to avoid solver error.
- Igap=2 Set varialble gap to take into account the true distance between parts
- Gapmin = 0.5 Minimum thickness of the model to avoid errors.
- Inacti=6 Remove initial penetrations where possible else where. reduce to lessthn 30% of the defined gap value.
- Istiff= 4 Stiffness of interface based on the surface of master & slave.
-Stmin=1 Specify a minimum stiffness in the contact to avoid too soft contact.
- Idel=2 Remove slave nodes sfrom contact because of element deletion.
- Iform=2 Sliding forces are computed using stffness parameters of interface.
4. Make sure of no penetrations and intersection.:
Quality> Check all solver contact interfaces.
Here we check penetrations after assigning the Type 7 properties as we define gap minimum which is used to check penetrations.
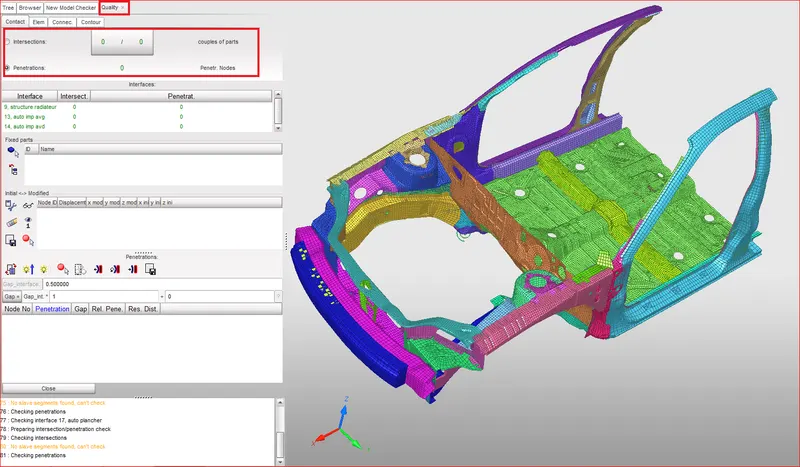
[ Exporting the file and continuing in Hypermesh.]
5. Create rigid wall with friction 0.1.
What is rigid wall?
Rigid Walls allow for an easy way to define an interface between a rigid surface and nodes of a
deformable body. A rigid wall is a nodal constraint applied to a set of slave nodes in order to
avoid the node penetration to the wall. If contact is detected, then the slave
node acceleration and velocity are modified.
The slave nodes to a rigid wall can be defined as a group of nodes and/or as nodes initially at a
distance less than the distance (Dsearch) from the rigid wall
• Each wall can be fixed (point M) or moving (node N)
• A Rigid Wall is a Kinematic Condition
• If a slave node penetrates the rigid wall surface a new velocity is computed
• From this velocity, the impulse and rigid wall force are determined
Rigid Walls /RWALL: Limitations
Some limitations with Rigid Walls
• Can only be fixed or have initial velocity – may want to move rigid object with an imposed
displacement function
• Can result in Incompatible Kinematic Condition – a result of nodes belonging to another
kinematic condition and the rigid wall
On bumper at front, create tempnodes and translate a duplicate of that node with 100 magnitude in x direction.
Now Create Rwall from Model and in the tab Engineering data XM,YM,ZM select the translated node and proceede
in Normal select X axis and proceede. since the direction of wall is opposite, make x coordinate value negative in normal.
In Support > Slide> 2: Sliding with friction.
in FRIC add 0.1.
Give dsearch as 1000.
What is Dsearch?
It is the search tolerance by master node for slave node. Node withing the range will follow master. A slave which is not in search tolerance may get deleted.
6. Initial velocity 35 mph.
In solver tab right click and select create> Boundary conditions >INIVEL
New INIVEL will be created. in grnd_ID, right click and select create & edit and select nodes of car body from extended entity selection displayed.
converting 35 miles per hour to m/s (i.e., 15.646 m/s or mm/ms).
In velocity component We give 15.64,0,0 with respect to x axis and 0 velocity in y and z derection.
7. Use model checker to ensure good quality.
Go to Tools in menu tab and from drop down list select Model checker> Radioss.
Model checker tab will open up. Run checke. Errors and Warning will be shown in the tab.
Note No more than 4-5 Warning should exist and only one those one which can be ignored.
8. Time-step :0.5 to 0.1 microseconds.
In model > Control cards Check
ENG_DT_NODA
ENG_DT_BRICK
ENG_DT_INTER
Change Tmin value to .001 (The actual value is supposed to be 0.0001 but to get simulations quickers just to check with the results we'll be running at 0.001
9. Run 80 ms.
In Model> Control cards> ENG_RUN
Give Tstop as 80.
10. Creating Sections. What are Sections?
- Sectional force in the rails at location of indicated node 174247.
- Shotgun cross sectional forces.
- A pillar cross section.
To create Section at Left Rail, isolate parts that are going to be assigned under that section. one way is to Call display panel (shortcut D) and select parts and reverse display.
Now in Solver tab Create Local Moving frame. Right click CREATE>FRAME>MOV
- Select Origin node, Z-axis in direction toward rigid wall, and select Y node.
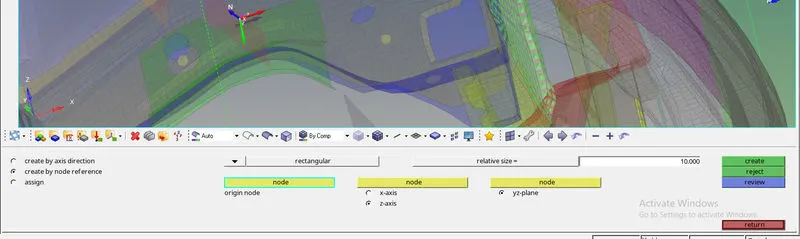
Create Section
- Right click ar solver and select Create > SECT > SECT.
Geometry type: infinite plane
Select N1, N2, N3 same nodes as selected for frame
Frame_ID : select the Frame arrow we created.
deltaT : 0.1 (it is time step for saving the data)
alpha : 0.67 (it is coefficient for filtering, it should be less than 1)
gr_shelid: select the elements around the section (atleast 2 rows on bothsides of the section)
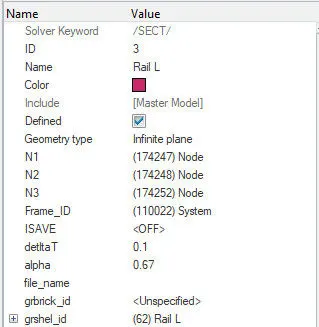
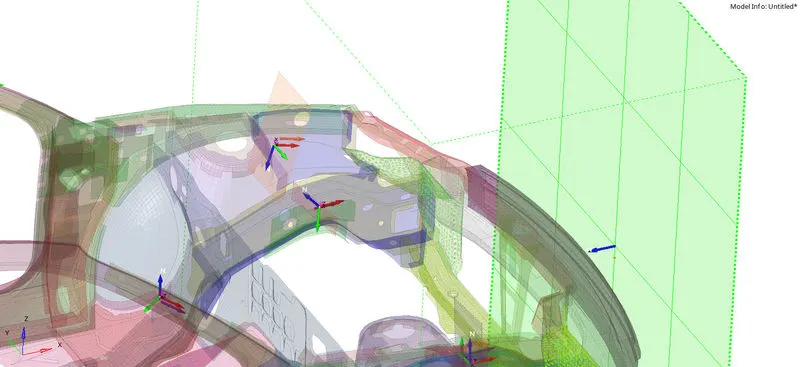
Do same for the rest of sections
11. Acceleration curve received on the accelerometer at base of B pillar (on B pillar rocker).
These devices measure the acceleration in a particular direction. This data can be used to determine the probability of injury. Acceleration is the rate at which speed changes.
- In Solver Right click and select create > Acc.
In ACC node_id: select node where acceleration has to be calculated.
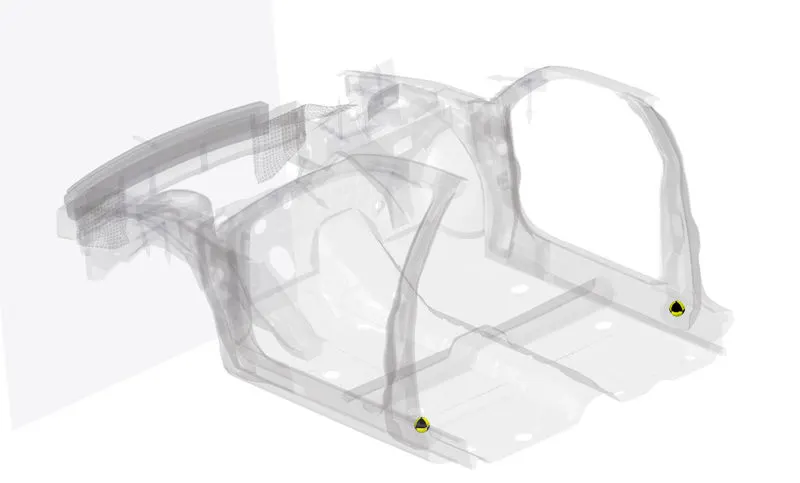
12. Intrusions on the dash wall 66695,66244.
What are intrusions?
Intrusion results when the energy of the crash exceeds the strength of the vehicle frame, resulting in a violation of the occupant compartment. Injury may then occur either from direct contact with the vehicle structure, or passenger movement as a result of the acceleration imparted to the occupant from the vehicle.
Process:
Create temp nodes at the points given & 121739 , 122048 by id. from 1D> Spring, Spring2 create spring by selecting 2 nodes 66695-121739 & 66244-122048.
Here We are taking spring element to calculate the change in distance between two nodes and since it is spring it should have some property, to avoid error we assign negligible mass of 0.001 and negligible stiffness of 0.001
13. Axial force received on the rails from bumper.
To measure the force received on rails we need to create interface between rail and bumper, with slave nodes on bumper and master on rail with Type 7.
RESULTS
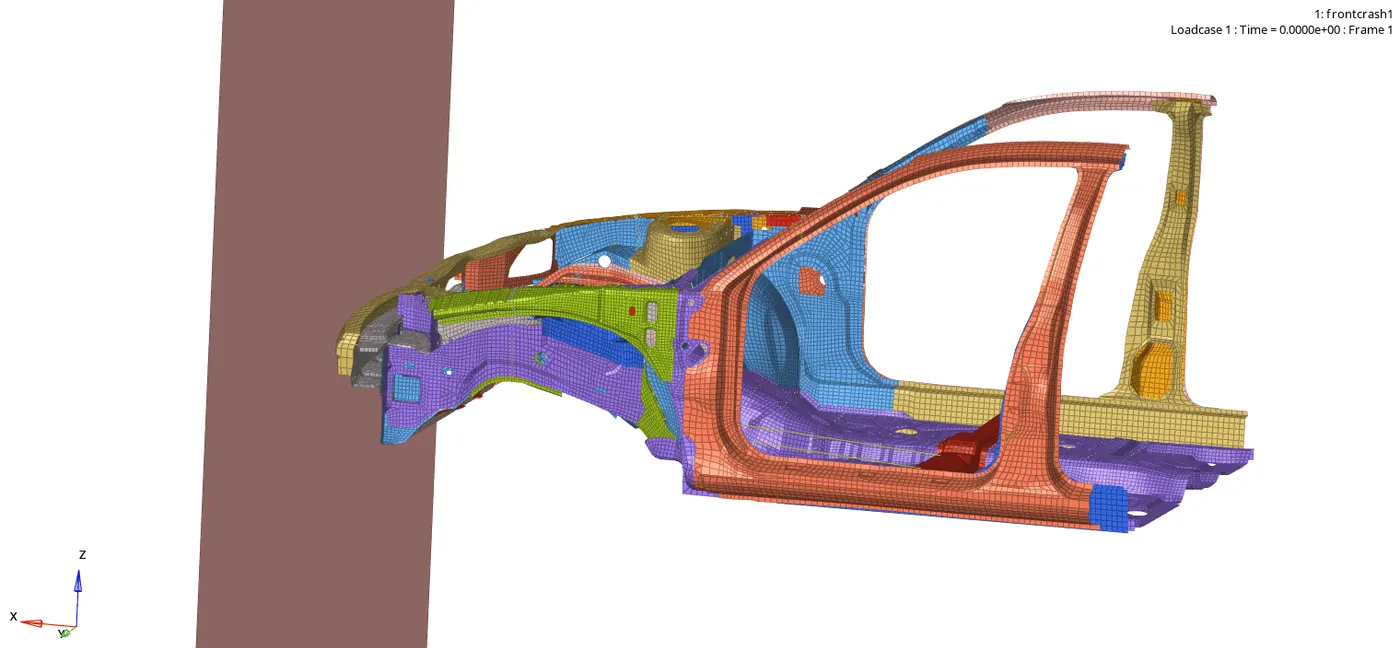
INTERFACE BUMPER-RAIL
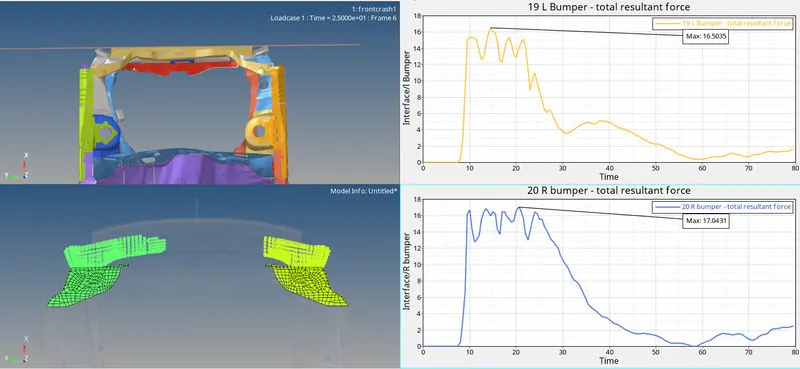
Here There is slight difference in Left and right Forces on bumper. This is due to multiple factors like:
No of components differ on both side of BIW, so does number of nodes and mass applied on both sides.
Connection between adjacent parts may differ here .
not all component be symmetric on both sides, hence the elements nodes differ and stress generated differs.
so max Force from Bumper to rail is about 16.5 N/mm.
SECTION FORCE
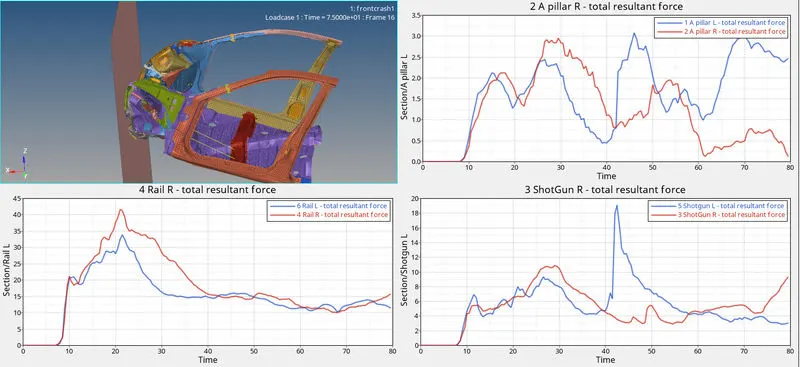
Here, we see
- Total resultant forces in A pillar Left are slightly greater than Right.
- Total resultant forces in Shotgun Left jumps greater than Right.
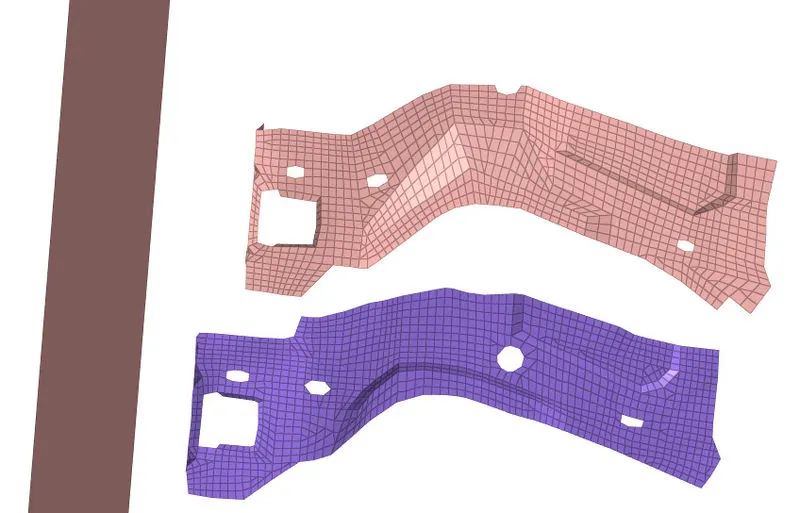
this is because the shape of CH-RAILS-FT-L-O and CH-RAILS-FT-R-O, Due to such shape L part deforms more hence generating more force than right side.
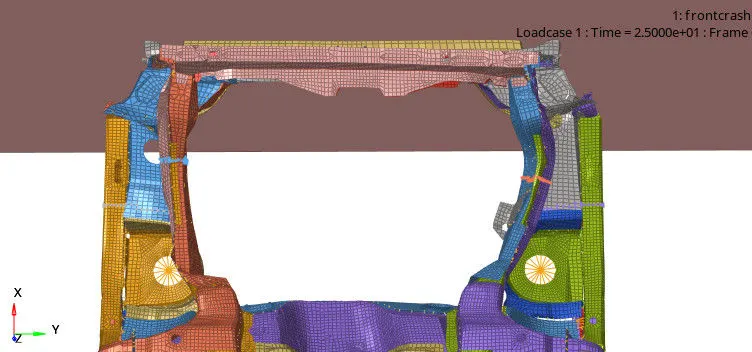
BUT, in case of Rails
- Total resultant forces in Rail Right are slightly greater than Left. this is also due to shape and deformation.
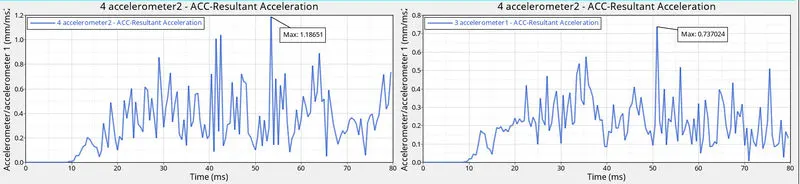
Accelerometer
It is not a steady value, but fluctuates up and down during the crash. This reflects the way the node slows down during a crash, with the highest values coming when the node strikes hard.
MOTION, VIBRATION, SHOCK
- The recommended value for Fcut is 1650 Hz (1.65 ms-1) to obtain a class 1000 SAE filtering.
Intrusion:
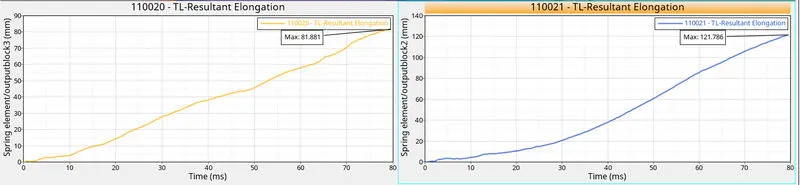
110020- Left spring ; 110021- Right spring.
Here the values for spring on Left and spring on right is too much varying and that is also due to shape of the components and deformation. CH-CBN-FLOORBRD-FT has deformed in such a way that the intrusion is high on right spring 110021 and a little less on left spring.
Energies:
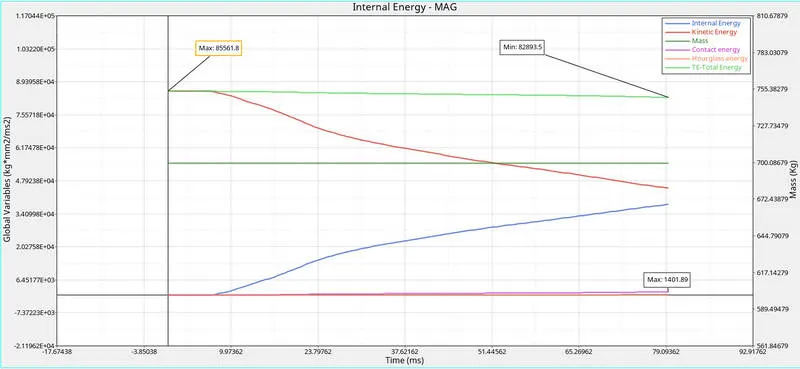
Kinetic energy: Here the car is in motion and has some kinetic enery in it. Which reduces at it crashes with barrier.
Internal energy: The Kinetic energy is converted to internl enegy. It is also called as strain energy. during impact the resistive force by wall is absorbed by elements as internal energy to deform.
Hourglass energy: It is the force applied to resist the node to enter into hourglass mode. It usually happens in underintegrated element formulation. Since we are using QEPH 24 Modified under integrated formulation it uses Pertubation method based on stiffness. It applies stiffness before even hourglass arises. Hence Zero Hourglass energy.
Contact energy: It is energy used by Master node of Rigidwall to rsist slave nodes to penetrate through it.
Total energy: Ideall total energy should be constant. Since due to interface type 7 some energy is being used to push away the nodes tring to penetrate and some energy is dissipated during vibrations hence reduction in total energy.
Mass error
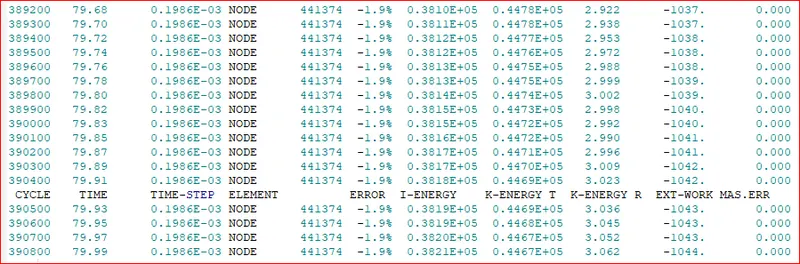
It should be less than 5%.
Usually to get a constant time step and to avoid instability during computation tiny mass is added to node. It is allowable till 5% but should be as minimum as possible.
Here we have zero mass error whish is good.
Load Path:
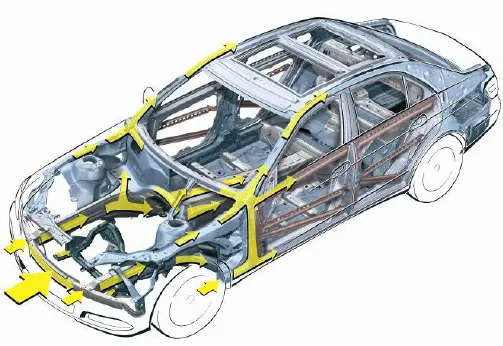
The principle function of the vehicle architecture is easily demonstrated using the USNCAP frontal impact test, where the majority of the kinetic energy of the vehicle has to be dissipated in the structure to decelerate the vehicle. Lower deceleration, often referred to ascrash pulse, reduces the likelihood and severity of secondary impacts of occupants in the interior. The incoming load is often taken up by the forward bulkhead and from there diverted into the undercarriage and into the A-pillar and door sill. After the barrier has reached the engine, this is pushed into the forward bulkheadand the steering rack and front axle module have to deform in a controlled manner, to dissipated energy and mitigate the intrusions into the occupant space. Finally, the collapse of the forward bulkhead and the A-pillar has to be prevented and the incoming loads have to be transferred towards the rear of the vehicle.
In the rigid barrier test, the vehicle changes velocity very quickly upon hitting the barrier. The crash produces a high deceleration crash pulse of short time duration – frequently referred to as a “stiff” pulse. It has high chances of injury than soft pulse.
CONCLUSION:
From FMVSS 208 for a full frontal crash max allowed intrusions are 15cm. Since our intrusions are 81.8mm and 121.7 mm which is less than 150mm. It can be concluded as Safe.