2R Robotic Arm Simulator
OBJECTIVE:
To create a program in python to simulate the forward kinematics of a 2R Robotic Arm and to create a animation file of the plot.
PROBLEM STATEMENT:
To find the end-tip position of a manipulator in a coordinate space given its joint parameters (i.e., joint angles for revolute joints and link offset for prismatic joints).This means that given a certain pose of a robotic arm, the xy coordinates of the hand must be determined.
THEORY:
Forward kinematics refers to the use of the kinematic equations of a robot to compute the position of the end-effector from specified values for the joint parameters.
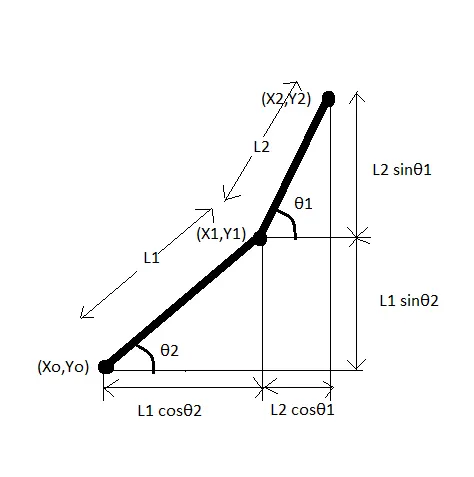
Drived Formulae,
X1=Xo+L1 cosθ1
Y1=Yo+L1 sinθ1
X2=X1+L2 cosθ2
Y2=Y1+L2 cosθ2
PROCEDURE:
Step 1: Firstly , we have to import the requried module . Here I have imported 'math' and 'matplotlib.pyplot' as py inorder to perform maths calculation and to plot the result respectively.
Step2: Then we have to define the set of values for angles and initial using variables
Step 3: We have to introduce a empty array inorder to store different value of angles
Step 4: We introduce a counter variable inorder to make the result plot filenames in order.
Step 5:We use for loop to calculate the desired and answers.And then we convert counter variable to string inorder to give a filename.
Step 6: Then we indroduce figure(),plot() ,title(),grid(),xlim() and xlim() inorder to create a image of the plot with a title and with x and y axis limits.
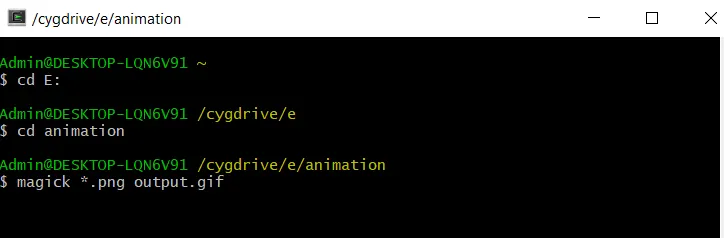
Step 7 : I have installed cygwin and imagemagick inorder to animation the obtained pictures as a gif
PYTHON CODE:
#program in python to simulate the forward kinematics of a 2R Robotic Arm and to create a animation file of the plot.
#importing module
import math
import matplotlib.pyplot as py

#defining the set of values for angles
n=10
start=0
end=math.pi/2

#initial condition
Xo=0
Yo=0
L1=1
L2=0.5

#empty arrays for angles
theta1=[]
theta2=[]

#assigning counter variable
ct=1

for i in range(0,n):
	tmp=start+i*(end-start)/(n-1)
	theta1.append(tmp)
	theta2.append(tmp)

for t1 in theta1:
	for t2 in theta2:
		X1=Xo+L1*math.cos(t1)
		Y1=Yo+L1*math.sin(t1)
		X2=X1+L2*math.cos(t2)
		Y2=Y1+L2*math.sin(t2)

		filename=str(ct)+".png"
		ct=ct+1

		py.figure()
		py.title('Forward Kinematics Of 2R Robotic Arm')
		py.plot([Xo,X1],[Yo,Y1])
		py.plot([X1,X2],[Y1,Y2])
		py.xlim([0,2])
		py.ylim([0,2])
		py.grid()
		py.savefig(filename)
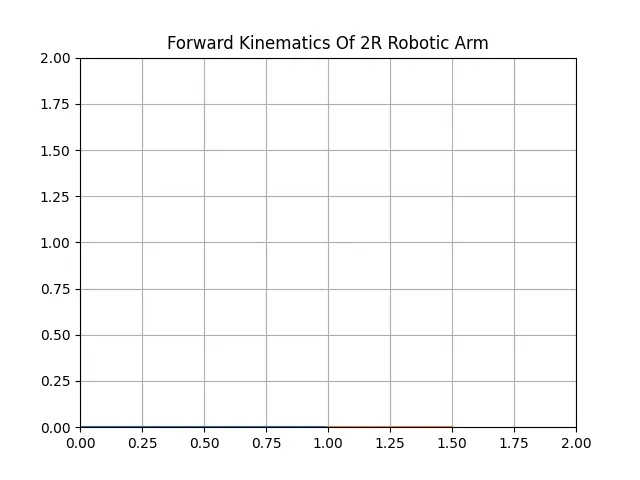
OUTPUT:
RESULT:
We have create a program in python to simulate the forward kinematics of a 2R Robotic Arm and created a animation gif file of the plot.