Week-7 Challenge: DC Motor Control
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
First of all, let us understand the basic concept of speed control using H bridgeconfiguration.
Most DC motors have two terminals because they are series type (armature and field windings are connected in series) DC motors.
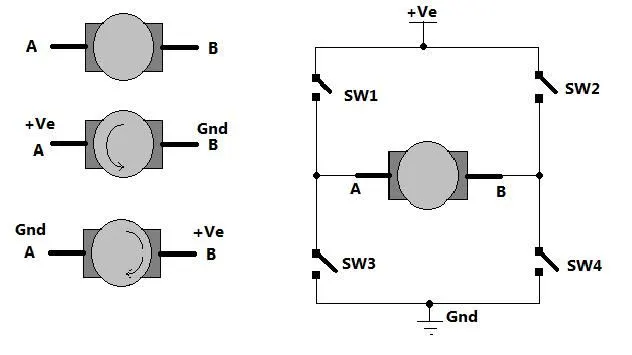
Fig. 1: Image showing H-Bridge circuit used for controlling direction of rotation of a DC Motor
As shown in figure there are two terminals ‘A’ and ‘B’ of DC motor. Now if we connect terminal A with +Ve supply and terminal B with –Ve supply or ground the current will flow from motor from A to B and motor will rotate in one direction – say clockwise (CW) or forward direction. Now as shown in second figure we change the supply terminals. Now B is connected with +Ve and A is connected to ground. The current will flow from motor from B to A and motor will rotate in other direction (counter clockwise – CCW or reverse).
The arrangement to get reversible supply is shown in right side of figure. Four switches are connected in between +Ve supply and ground and DC motor is connected in between two switches as shown. Such circuit arrangement is known as H-bridge because it looks like letter ‘H’ (H-bridge circuits are most widely used in DC motor drivers). Let us see how it gives reverse supply to motor.
If SW1 and SW4 are pressed simultaneously then current will flow from +Ve – SW1 – A – B – SW4 – Gnd. So motor will rotate in one direction. Open (release) SW1 and SW4 to stop motor. Now if SW2 and SW3 are pressed current will flow from +Ve – SW2 – B – A – SW3 – Gnd. So motor gets reverse supply and it will rotate in another direction.
(Caution: care has to be taken that SW1 and SW3 or SW2 and SW4 must not be pressed simultaneously otherwise it will short circuit the supply)
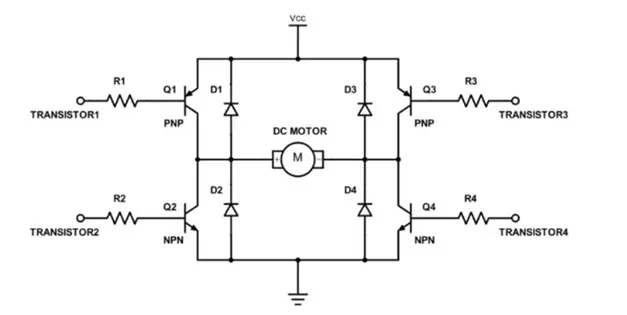
Fig. 2: Circuit Diagram of H-Bridge built by transistor for controlling DC motor speed and rotation
The circuit replaces the switches with NPN type transistors. Diodes are given for the current to free wheel as the DC motor is a RLE load where the current cannot change direction instantaneously.We all know that transistor works as switch. For NPN transistor if we give enough +Ve input to base it will turn ON (Saturation region) and if we give 0 input it will be turned OFF (Cut off region). So in this circuit if Q1 and Q4 are turned ON simultaneously the motor will rotate forward and if Q2 and Q3 are turned ON then motor will rotate in reverse direction.
In order to vary the speed of the DC motor, We have to change the voltage applied to the DC motor. This could be achieved with the help of Pulse width modulation.
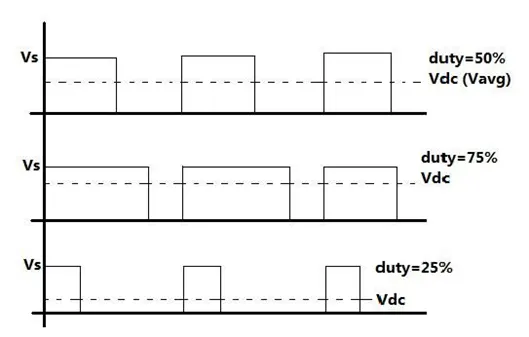
Fig. 3: Graph showing Pulse Width Modulation for controlling speed of DC Motor
Pulse width modulation means varying the width (duty) of pulse. Width means ON time Ton of pulse. The average output voltage (Vdc or Vavg) is given by equation
Vdc=TonTon+Toff⋅VsVdc=TonTon+Toff⋅Vs
⇒Vdc=δ⋅Vs⇒Vdc=δ⋅Vs where δδ is the duty cycle.
The voltage directly depends upon Ton. As shown in above figure if duty is 50% the average output voltage Vdc is exactly the half of Vs. If duty is increased to 75%, Vdc also increases to 3/4th of Vs and if duty is decreased to 25%, Vdc reduces to 1/4th of Vs. Thus as pulse width varies the average output voltage varies. So we have to apply PWM to DC motor to vary its speed.
The example below shows the simulink model of an H-bridge used to generate a chopped voltage and to control the speed of a DC motor.
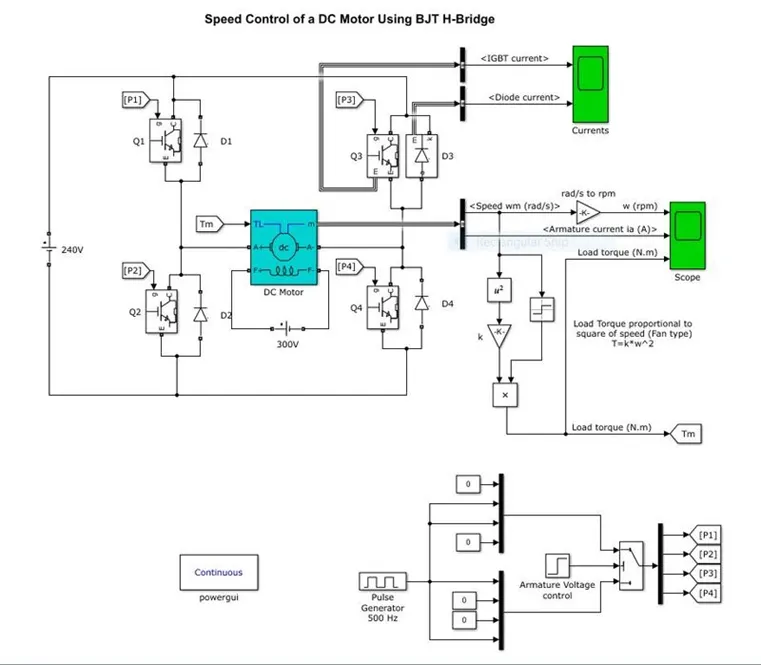
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Note: The DC motor used in the simulink model is a separately excited DC motor and NOTa DC series motor. That is the reason why a DC voltage of 300V is given to the field windings.
B. Comment on the armature current shoot-up from the scope results.
Simulation Output:
1.) Pulse Generator Parameters:
Period: 2 milli seconds
Pulse Width (% of period) : 75%
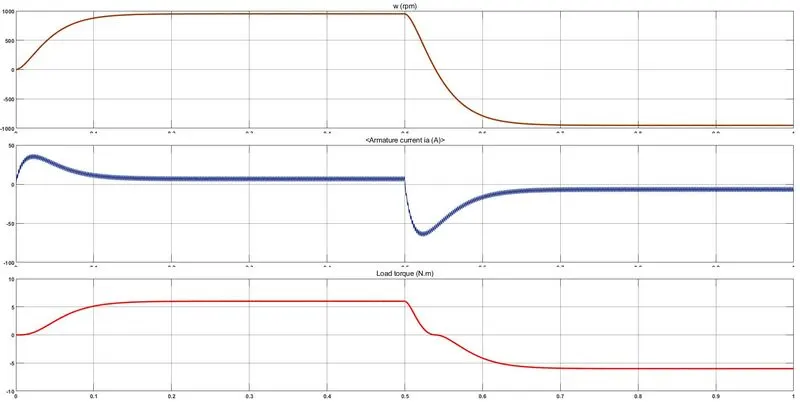
Initially, there is a spike in armature current. This is because, in a DC motor,
Ia=V−EbRaIa=V-EbRa where IaIais the armature current, VVis the supply voltage , EbEbis the back emf and RaRais the armature resistance.
At starting, Eb=0 as speed=0 at starting.
Therefore Ia=VRaIa=VRa and RaRais a very small value. Hence IaIais huge and that reflects in the graph.
2.)
Period: 2 milli seconds
Pulse Width (% of period) : 50%
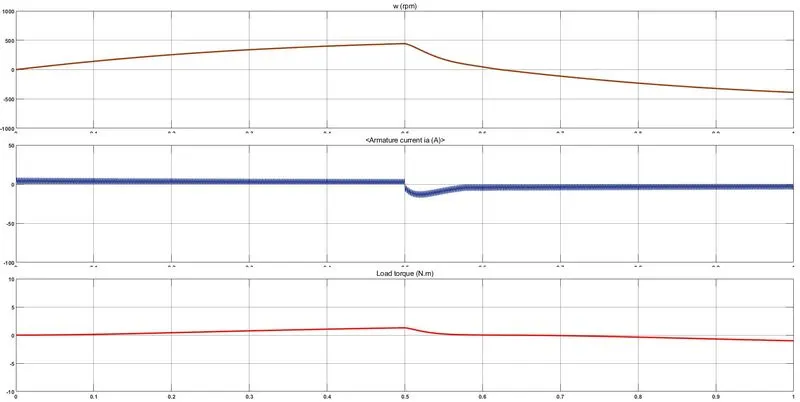
Therefore when pulse width decreases, the voltage applied across the DC motor decreases and the armature current finally decreases.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The Four-Quadrant Chopper DC Drive block uses these blocks from the Electric Drives/Fundamental Drive Blocks library:
- Speed Controller (DC)
- Regulation Switch
- Current Controller (DC)
- Chopper
The above figure shows the schematic of the 4 quadrant chopper DC drive
|
H bridge |
Four Quadrant chopper DC drive |
|
Only Two quadrants of operation are possible. They are Forward motoring and reverse motoring |
It can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration) |
|
Higher armature current ripple. |
Lower armature current ripple due to high switching frequency of DC-DC coverters |
|
Less complex |
More complex |
|
Simulation is continuous and simulation time is more |
Discrete and Simulation time is less |
|
Widely Used in Robotics |
Widely used in Automobile |
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
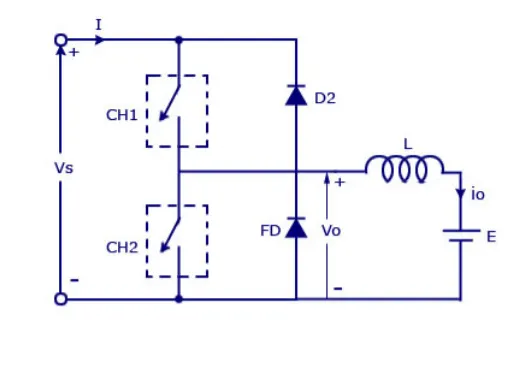
Circuit Diagram of a 2-quadrant chopper:
Developed 2-quadrant chopper using Simulink:
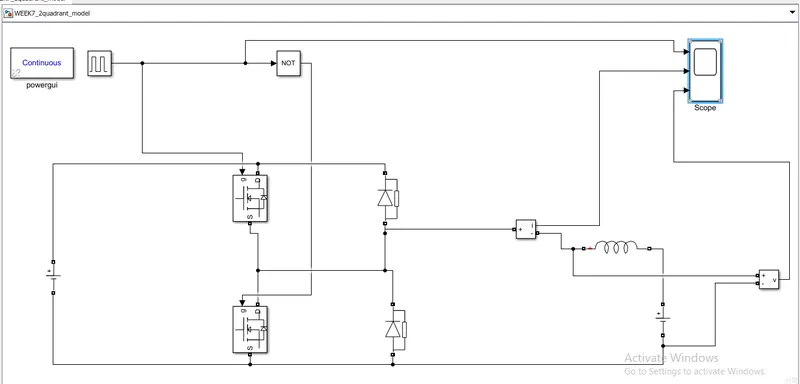
Model Construction :
Click on Simulink Browser and open Library to Search for Component required to Build C-Class chopper as follows:
- Power GUI
- Pulse generator
- Current measurement
- Voltage measurement
- Diode
- MOSFET
- Logical operator (NOT)
- Series RLC
- Scope
- Arrange the Blocks as per the circuit connection shown above in the Model.
- Double click on MOSFET and DIODE Block to Disable (uptick show measurement port), and rotate the diode in upward direction as per our requirement (source should be facing in Downward direction for MOSFET and for DIODE source should be in upward direction)
- Open series RLC block and Change the branch type to (L) with default value 1 mill H, once done arrange according to circuit diagram.
- Open logical operator and select NOT in Operation options, connects its Input to output of PULSE Generator block. The reason we use NOT gate to ensure both the Switches does not conduct simultaneously if they do so supply will be short-circuited.
- We will be giving the tapping for the PULSE gate terminal for 1 switch MOSFET1 and from NOT gate we are giving it to other switch MOSFET2. So if MOSFET1 is conducting MOSFET2 will not conduct because we are using the NOT gate.
- Once done we will be measuring the voltage by connecting its 1st port at staring of inductor and other to DC2 supply which is connected adjacent.
- And output is connect to 1st of the 3 port of scope input, current Measurement port is also connected to 2nd port of Scope and 3rd port is taken from output of PULSE Generator.
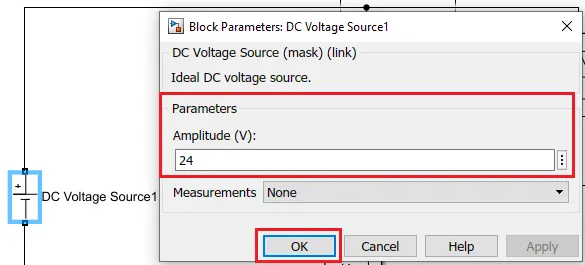
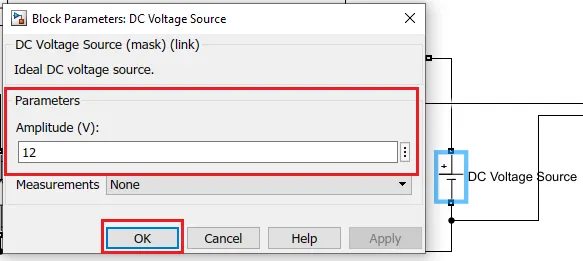
- Double click on main DC Voltage supply and set amplitude (V) to 24v and for adjacent DC2 supply set amplitude as 12v.
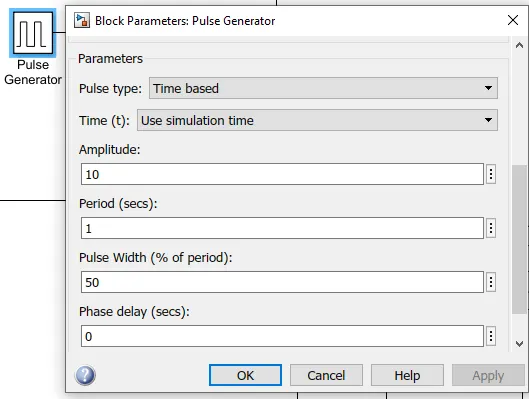
- Open Pulse generator block set amplitude to 10 for better viewing, time period set to 1 sec, pulse width is 50 (because we 50% to be ON and 50% to be OFF) .i.e. NOT gate is ON when 50% OFF
The working of the Model is given below:
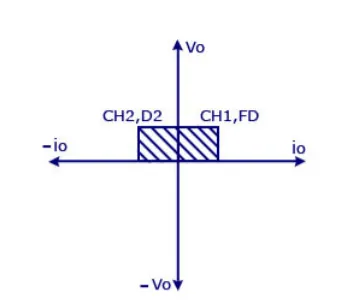
Type C chopper is obtained by connecting type –A and type –B choppers in parallel. We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper is on the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs. The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source and it will be positive regardless of the chopper is on or the FD conducts. The load current will be negative if the chopper is or the diode D2 conducts. We can say the chopper and FD operate together as a type-A chopper in the first quadrant. In the second quadrant, the chopper and D2 will operate together as type –B chopper.
The average voltage will be always positive but the average load current might be positive or negative. The power flow may be like the first quadrant operation i.e from source to load or from load to source as the second quadrant operation. The two choppers should not be turned on simultaneously as the combined action may cause a short circuit in supply lines. For regenerative braking and motoring, this type of chopper configuration is used.
Let the voltage of the DC voltage source be 24 volts.
Let us consider an series RLC branch block and select inductor L . Thus block works as a load.
To consider LE load i.e motor load , and dc voltage source of 12 volt is also connected in series with inductor.
The pulse generator block is used to create gate pulse.
The not gate is used in the model so that the two MOSFET will not get closed at the same time otherwise short circuit will occur. Due to use of not gate, when one mosfet is ON the other mosfet will get OFF and when other mosfet is ON the first mosfet will get OFF .
The amplitude of pulse generator is kept 10 so that we can clearly see the pulses at scope and let period be 1 seconds and let pulse width be 50%.
Output:
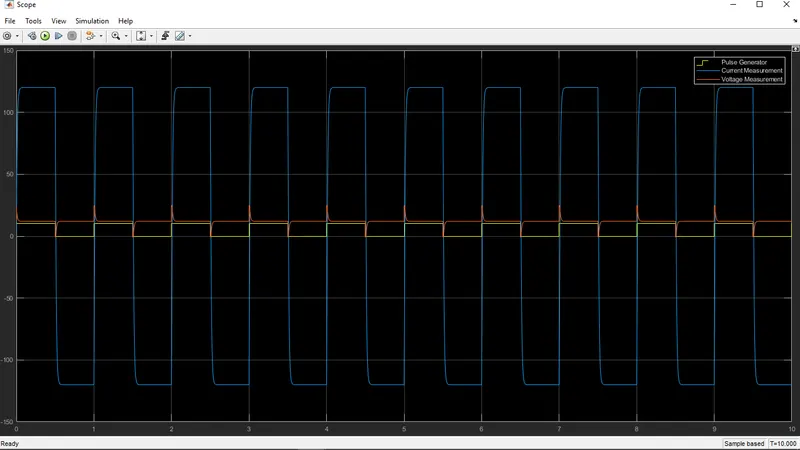
The voltage waveform is not going less than zero, the minimum value of voltage is zero and maximum value is always in the positive direction.
However in current waveform, the current increases and decreases, current may be positive as well as negative.
The pulse amplitude is 10 thus from pulse waveform we can see that the pulse amplitude is 10.
3. Explain in a brief about operation of BLDC motor.
BLDC Motor: A brushless DC motor (also known as a BLDC motor) is an electronically commuted DC motor that does not have brushes. The controller provides pulses of current to the motor windings that control the synchronous motor's speed and torque.
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary. In conventional Brushed DC Motors, the brushes are used to transmit the power to the rotor as they turn in a fixed magnetic field. A BLDC motor used electronic commutation and thus eliminates the mechanically torn brushes.
Before explaining the working of a brushless DC motor, it is better to understand the function of a brushed motor. In brushed motors, there are permanent magnets on the outside and a spinning armature that contains an electromagnet inside. These electromagnets create a magnetic field in the armature when the power is switched on and help to rotate the armature.
The brushes change the polarity of the pole to keep the rotation on of the armature. The basic working principle for the brushed DC motor and brushless DC motor is the same i.e. internal shaft position feedback.
A Brushless DC motor has only two basic parts: the rotor and the stator. The rotor is the rotating part and has rotor magnets whereas the stator is the stationary part and contains stator windings. In BLDC permanent magnets are attached to the rotor and move the electromagnets to the stator. The high-power transistors are used to activate electromagnets for the shaft turns. The controller performs power distribution by using a solid-state circuit.
3. Explain in a brief about operation of BLDC motor.
- Explain in a brief about operation of BLDC motor.
BLDC Motor: A brushless DC motor (also known as a BLDC motor) is an electronically commuted DC motor that does not have brushes. The controller provides pulses of current to the motor windings that control the synchronous motor's speed and torque.
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary. In conventional Brushed DC Motors, the brushes are used to transmit the power to the rotor as they turn in a fixed magnetic field. A BLDC motor used electronic commutation and thus eliminates the mechanically torn brushes.
Before explaining the working of a brushless DC motor, it is better to understand the function of a brushed motor. In brushed motors, there are permanent magnets on the outside and a spinning armature that contains an electromagnet inside. These electromagnets create a magnetic field in the armature when the power is switched on and help to rotate the armature.
The brushes change the polarity of the pole to keep the rotation on of the armature. The basic working principle for the brushed DC motor and brushless DC motor is the same i.e. internal shaft position feedback.
A Brushless DC motor has only two basic parts: the rotor and the stator. The rotor is the rotating part and has rotor magnets whereas the stator is the stationary part and contains stator windings. In BLDC permanent magnets are attached to the rotor and move the electromagnets to the stator. The high-power transistors are used to activate electromagnets for the shaft turns. The controller performs power distribution by using a solid-state circuit.
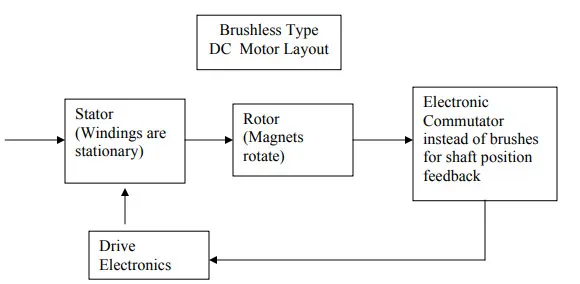
Construction of BLDC motors:
The main design difference between brushed and brushless motors is the replacement of a mechanical commutator with an electric switch circuit. Keeping that in mind, a BLDC motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
Brushless Motors are available in three configurations: single-phase, two-phase, and three-phase. Out of these, the three-phase BLDC is the most common one.
The following image shows the cross-section of a BLDC Motor.
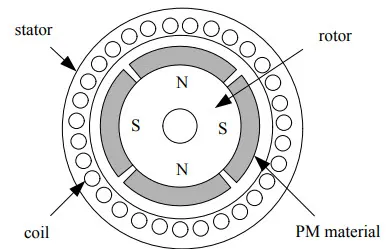
As we can see in the image, a BLDC motor consists of two main parts: a stator and a rotor.
Stator:
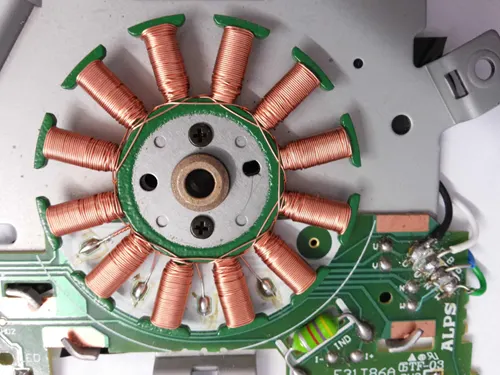
The structure of the stator of a BLDC motor is similar to that of an induction motor. It is made up of stacked steel laminations with axially cut slots for winding. The winding in BLDC is slightly different from that of the traditional induction motor.
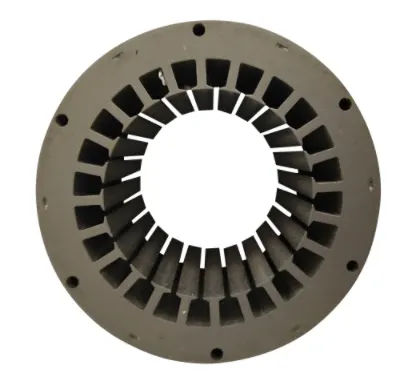
Generally, most BLDC motors consist of three stator windings that are connected in star or ‘Y’ fashion (without a neutral point). Additionally, based on the coil interconnections, the stator windings are further divided into Trapezoidal and Sinusoidal Motors.
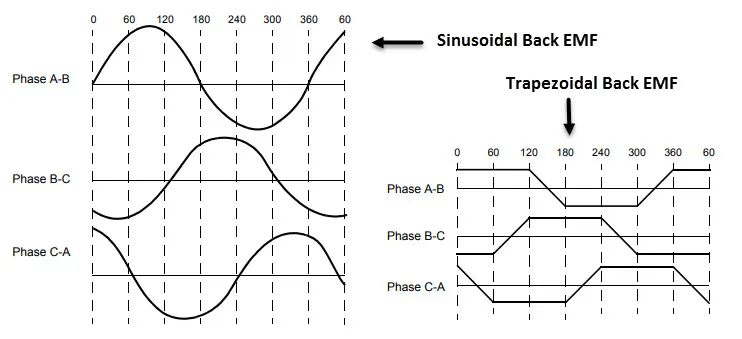
In a trapezoidal motor, both the drive current and the back EMF are in the shape of a trapezoid (sinusoidal shape in case of sinusoidal motors). Usually, 48 V (or less) rated motors are used in automotive and robotics (hybrid cars and robotic arms).
Rotor:
The rotor part of the BLDC Motor is made up of permanent magnets (usually, rare earth alloy magnets like Neodymium (Nd), Samarium Cobalt (SmCo), an alloy of Neodymium, Ferrite, and Boron (NdFeB)).
Based on the application, the number of poles can vary between two and eight with North (N) and South (S) poles placed alternately. The following image shows three different arrangements of the poles. In the first case, the magnets are placed on the outer periphery of the rotor.
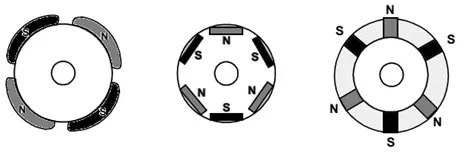
The second configuration is called a magnetic-embedded rotor, where rectangular permanent magnets are embedded into the core of the rotor. In the third case, the magnets are inserted into the iron core of the rotor.
Now, some crucial things are a must to have in the case of BLDC motors i.e. its sensors.
The BLDC motor has no Brushes, the commutation is controlled electrically. To rotate the motor, the windings of the stator must be energized in a sequence and the position of the rotor which the North poles and South poles of the rotor must be known to precisely energize a particular set of stator windings.
A Position Sensor, which is usually a Hall Sensor is generally used to detect the position of the rotor and transform it into an electrical signal.
HALL-EFFECT SENSOR:
A Hall-effect sensor (or simply Hall sensor) is a device to measure the magnitude of a magnetic field. Its output voltage is directly proportional to the Magnetic field strength through it. The Hall-sensor is used for, Proximity Sensing, Positioning Sensor, Speed Detection, and Current Sensing.
Most BLDC Motors use three Hall Sensors that are embedded into the stator to sense the rotor’s position. The output of the Hall Sensor will be either Low or High. Depending on whether the North or South pole of the rotor passes near it. By combining the results from the three sensors, the exact sequence of energizing can be determined.
THE WORKING PRINCIPLE OF BLDC MOTOR:
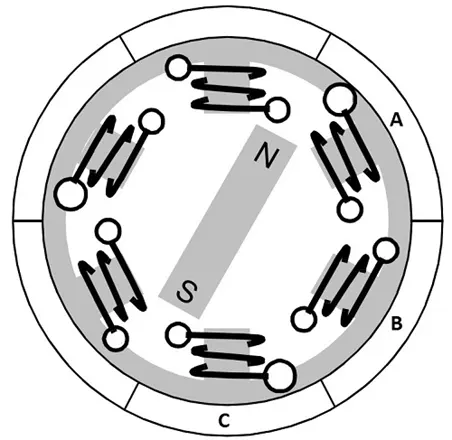
Consider the following setup of three windings in the stator designated A, B, and C. For the sake of understanding, let us replace the rotor with a single magnet.
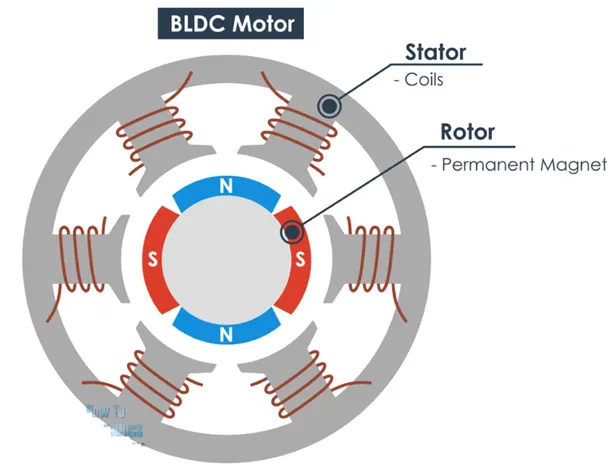
- We know that when a current is applied through a coil, a magnetic field is generated and the orientation of the field lines i.e. the poles of the generated magnet will depend on the direction of the current flowing through the coil.
- Now, by supply current to coil A, it will generate a magnetic field and attract the rotor magnet. The position of the rotor magnet will shift slightly clockwise and will align with coil A. similarly for coil B and coil C the magnet rotates in the clockwise direction
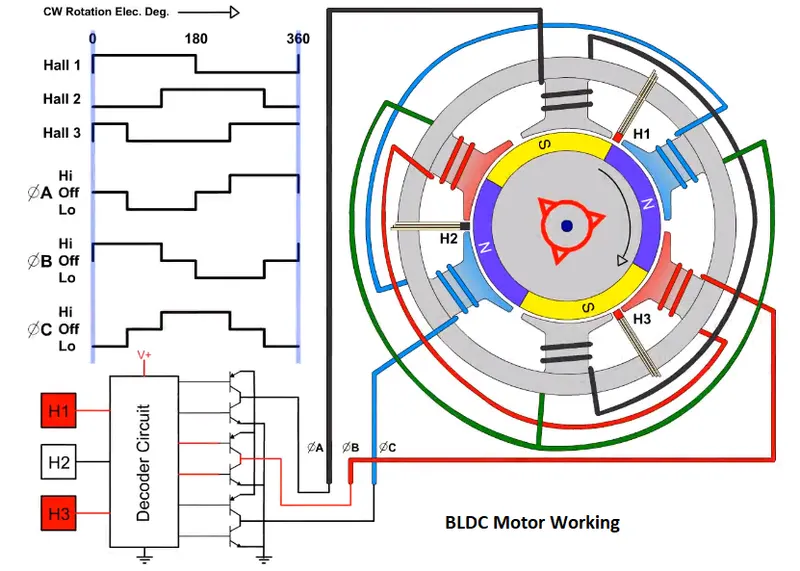
- Here, the Three-phase BLDC motor is used and the phases are A, B, &C.
- These phases are connected to an Electronically commutator which is a power electronic controller which acts as an Inverter.
- The Hall sensor is placed between poles to sense the position of the rotor.
- Here three Hall sensors are placed in Stator.
- Each phase signal is combined with High, Low, and OFF.
- The hall signal is taken as the frequency of 0 to 360 degrees.
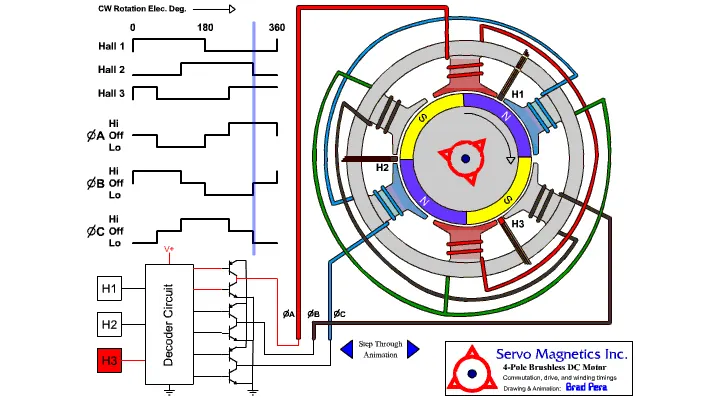
- When The Hall-1 is OFF to ON, Hall-2 is OFF, and Hall-3 is OFF to ON. So Hall-1 and Hall-3 are present.
- Then phase A is in the OFF signal, phase B is OFF to High, and phase C is Low.
- Similarly, in three phases if one phase is of the other two phases are acts as positive and negative.
To understand it more easily a gif of the same above circuit is given below:
Advantages of BLDC Motor:
- Brushless motors are more efficient as their velocity is determined by the frequency at which current is supplied, not the voltage.
- As brushes are absent, the mechanical energy loss due to friction is less which enhanced efficiency.
- BLDC motor can operate at high speed under any condition.
- There is no sparking and much less noise during operation.
- More electromagnets could be used on the stator for more precise control.
- BLDC motors accelerate and decelerate easily as they are having low rotor inertia.
- It is a high-performance motor that provides large torque per cubic inch over a vast speed range.
- BLDC motors do not have brushes which make them more reliable, high life expectancies, and maintenance-free operation.
- There are no ionizing sparks from the commutator, and electromagnetic interference is also get reduced.
- Such motors cooled by conduction and no airflow are required for inside cooling.
Limitations of BLDC Motors:
- These motors are costly compared to brushed motors
- The need for additional sensors
- The electronic controller required to control this motor is expensive
- Complex Driver-Circuit is required
- The limited high power could be supplied to the BLDC motor, otherwise, too much heat weakens the magnets and the insulation of winding may get damaged.
Application of BLDC Motors:
- Electric vehicles, hybrid vehicles, and electric bicycles can be constructed.
- Industrial robots, CNC machine tools, and simple belt-driven systems
- Fans, pumps, and blowers with a low noise-inducing environment.
CONCLUSION:
- MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge and the armature current shoot-up is studied.
- ‘The Four-Quadrant Chopper DC Drive (DC7) block is also studied and compared it with the H-bridge model.
- 2-quadrant chopper is developed using simulink model and obtained the results.
- Operation of BLDC motor is studied.