Week-7 Challenge: DC Motor Control
Solution to Question1:
A) The matlab demo model can be opened by using the command: power_Hbridge
The model is as shown below:
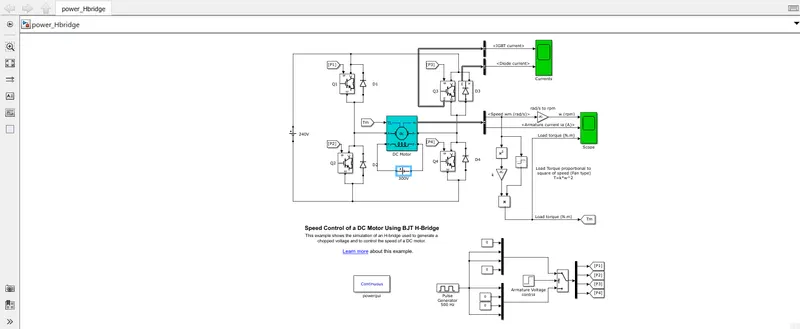
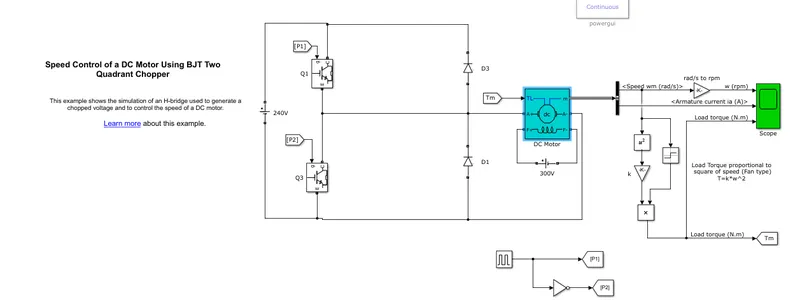
In the model a total of four IGBT switches & four Diodes are used for obtaining the four quadrant operation of the DC motor drive.
In this model the load torque is considered as fan load type, the load will automatically change with the change in direction of rotation of motor. The logic used for obtaining the behaviour is as shown below:
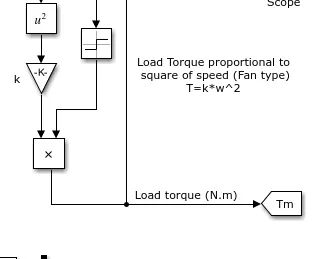
There the sign block is used to have the load torques with both signs + and -.
Working of H-bridge model:
- Here H-bridge DC chopper circuit is designed to control the speed of the motor.
- IGBT acts as BJT in power switching devices.
- Four IGBT switches are used for controlling the speed of DC motor, the DC voltage is regulated from0 to 240 v supply.
- The gate are controlled by the pulses(0 and 1) according to the armature voltge of motor given by pulse generator.
- In first state, Q1 and Q4 are closed by giving 1V to IGBT'S,current from supply passes through Q1 and Q4.Diode D2,D3 are used as free wheeling diode in this state.In this case Forward motoring and forward breaking are held.
- In Second state,Q2 and Q3 are closed by giving 1V to IGBT's,current from supply passes through Q2 and Q3.Diode D1,D4 are used as free wheeling diode in this stateIn this case reverse motoring and reverse breaking are held.The current direction change its direction in this state.
- Both the states are occuring in 0.5 seconds respectively.
- In motor operation, armature terminals are connected with a 240V along the inverter circuit and field winding is excited with 300 V DC suppy to act as a electro magnet for the motor.
- The load torque is given as mechanical input to the motor for its referance.
The output results obtained are as follows:
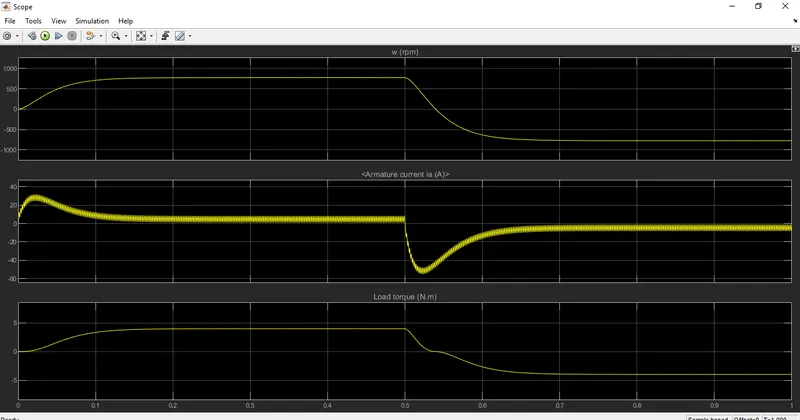
The above image shows the motor output voltage and current.
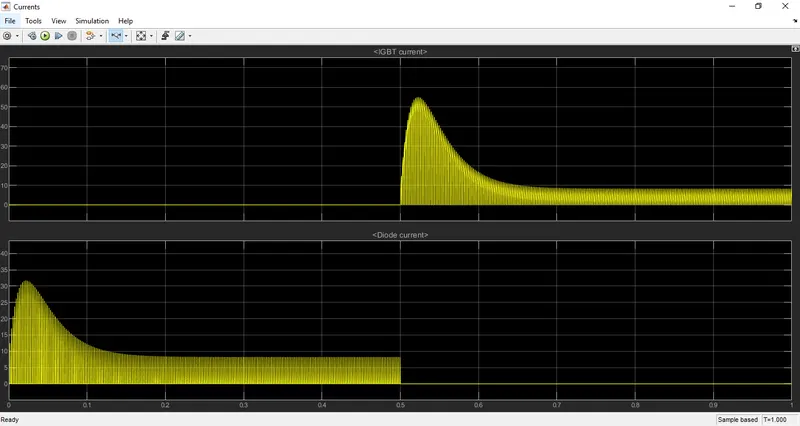
The above image shows the current through the Switch CH3 and diode D3 respectively. From the graph we can observe that the switch and diode are operating exactly for half the on time.
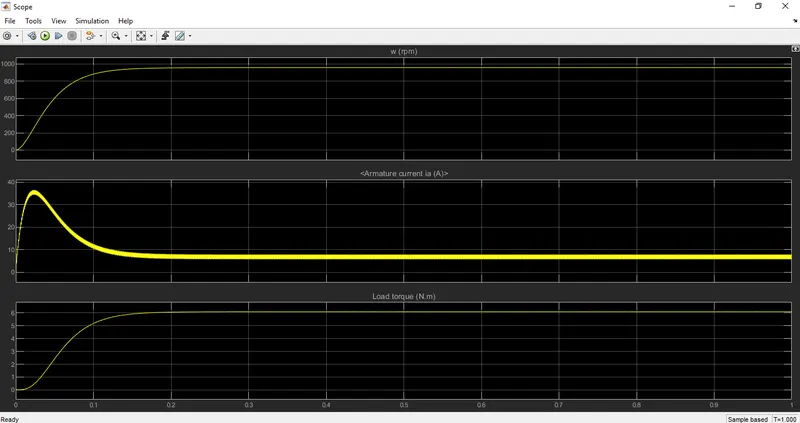
From the results we can observe that with a duty of 75% motor is able to reach a speed of arounf 900 rpm with in a duration of 0.5 sec. After this the voltage applied to the armature terminals is reversed which resulted in reversal of the motor direction speed and torque respectively.
B)
Current of the motor has an overshoot as observed in the figure 1. This is because of the fact that initially the motor is started with more voltage which resulted in huge inrush current. By varying the initial voltage applied across the armature terminals the overshoot of the current can be reduced as observed here:
The duty ratio of the pulses is changed from 75% to 30% and the results obtained are as shown here:
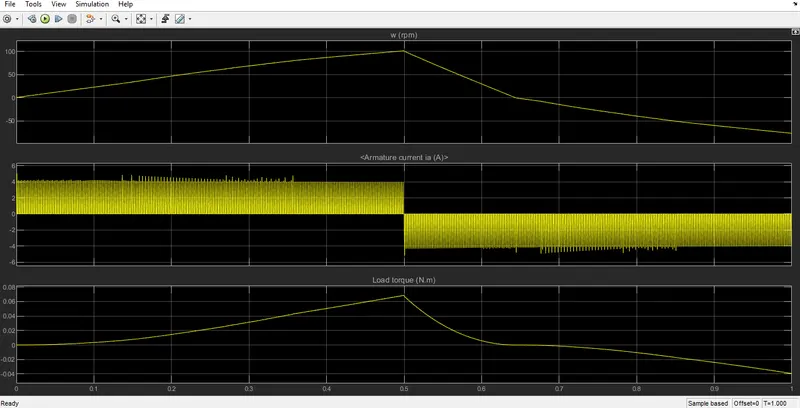
Here the overshoot is very less, so we can slowly increase the duty ratio in order to have a smooth operation of the motor with out sudden increment in the currents.
C)
Comparision of four quadrant chopper drive with the H-Bridge Drive:
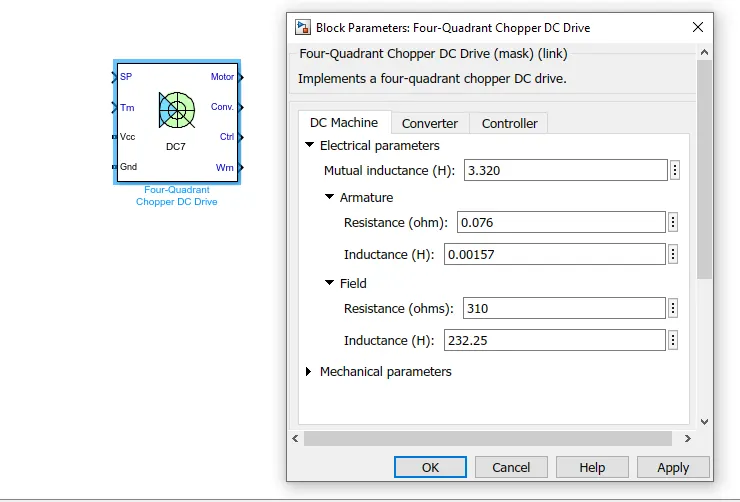
The block of the four quadrant DC drive is as shown in the figure. The drive will take the inputs as speed or torque set [oint and also the mechanical torque to be applied on the motor.
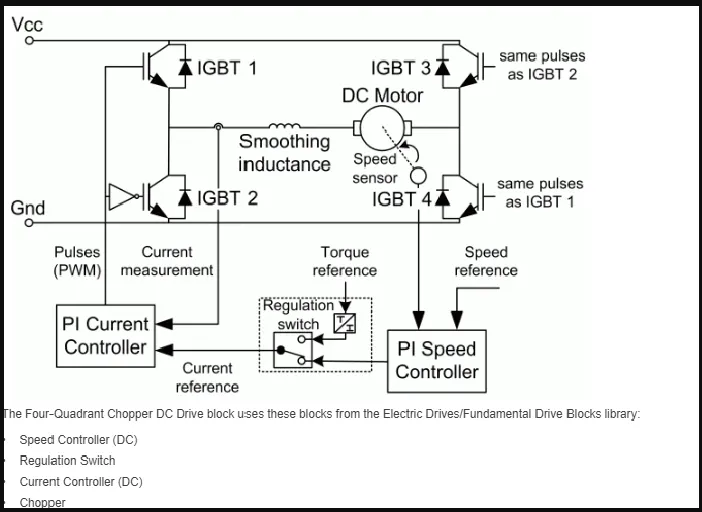
Inputs and outputs:
Armature voltage ,speed referance ,motor torque referance are given as inputs.
Motor,convertor,controller,motor angular speed are get as outputs.
Working:
- Here Four Igbt switches are used.
- Here pulses are given from PI current controller, that controles the pulses by comparing armature current measurement and current referance.
- Current referance can be generated by using regulation switch in that torque referance and PI speed controller pulses,that internally compared by speed of motor and refrance speed given as input.
- Mainly speed controlled by current controller.
- In this case Four quadrant operations are performed.
- Forward motoring mode,forward regenerative breaking mode: Q1,Q4 are on and Q2,Q3 are in off.
- Reverse motoring mode,reverse regenerative breaking mode: Q2,Q3 are on and Q1,Q4 are in off.
Comparisons:
- In DC7 chopper model speed controlled by varying current pulses from PI current controller and in H-brige model speed controlled by varying duty cycles voltages.
- Here regenerative breaking in occring while in H-bridge model breaking is occured by changing polarity of current flow,dynamic breaking occurs in it.
- In four quadrant DC chopper model smoothing inductance is used for smooth increase and decrease in current flow which inturns controlling the motor speed smoothly,while in
- H-bridge it is not present.
- Here the operation is discreat and in H-bridge model it is continuous.
- Hence 4 quadrant DC choppers are used mostly in electric vehicles.
Solution to question 2:
To create a model for control of DC motor using two quadrant type C model DC chopper.
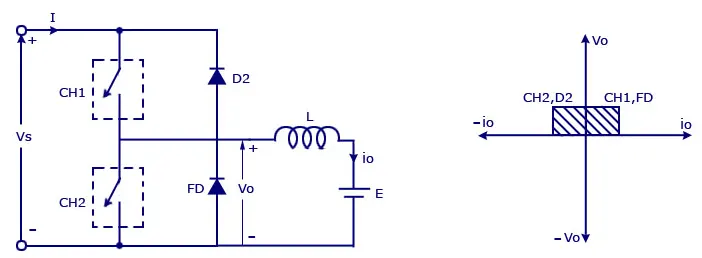
Where,
Vs=DC voltage source.
CH1= Power electronic switch 1.
CH2= Power electronic switch 2.
D2,FD = Free wheeling diodes.
L=Inductor load.
E Back emf from load.
Circuit modelled in Simulink, here the back emf od the motor is not greater than the input supply, so the regenerative operation is not visible in the result. If the switching frequency is very less let us say like 1hz pr 10 hz then the regenerative action can be seen
Mode of operation:
- Here either one should be ON at a time,either CH1 or CH2.
- If CH1 is ON the current flows from source +ve to load(here DC motor),passes through L and E to -ve terminal of source.(1st quadrant)
- If CH1 is OFF the, FD diode conducts and complete the circuit (L-E-FD-L) as stored energy in inductor L.The voltage across is also positive voltage,current direction also positive.
- Now If CH2 is ON,Current flow from E(Load current) completes the circuit(L-CH2-E).
- If CH2 gets OFF,the current passes through D2 towards source completes the circuit(E-L-D2-+ve source- -ve source-E).
- In this stage regenerative breaking occurs.(2nd quadrant).
Solution to question 3
3) BLDC Motor:
BLDC motor named as brushless dc motor having high effenciency than other types of motors.
Construction:
Most of the motors are having brushes in their rotor as it transfers current into the rotor circuit.But in BLDC the rotor is placed with permanent magnet.
The stator is wounded with coils,they are stationary but produce variable DC voltages which rotates the permanent magnet as changing the magnetic field of stator poles continuously.
The controlling of motor is by changing the magnitude and direction of current flowing through the stator windings.
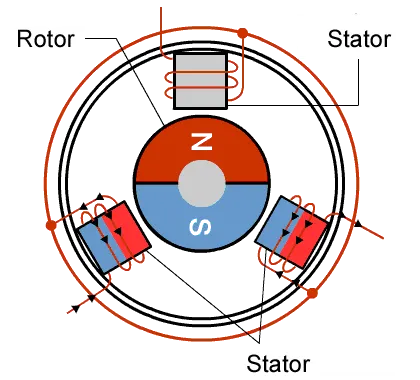
A BLDC motor with three coils on the stator will have six electrical wires (two to each coil) extending from these coils. In most implementations three of these wires will be connected internally, with the three remaining wires extending from the motor body. Wiring in the BLDC motor case is more complicated than simply connecting the power cell’s positive and negative terminals. we will look more closely at how these motors work in the second session of this series.
Operation of BLDC motor:
We can consider three winding trminal are comming out as U,V,W and their another ends are connected in single point as shown in below figure.The angle shift between two coils makes 120 degree.
The current moves from U to W makes magnetizing the coils attracts the rotor consisting of permanent magnet makes moment as shown above to align with the resultant arrow(larger arrow).
North pole of magnet towards arrow mark of resultant arrow.
Rotation is maintained by continually switching the flux so that the permanent magnet is constantly chasing the rotating magnetic field induced by the coils. In other words, energizing of U, V, and W must be
continually switched so that the resultant flux keeps moving, producing a rotating field that continually pulls on the rotor magnet.
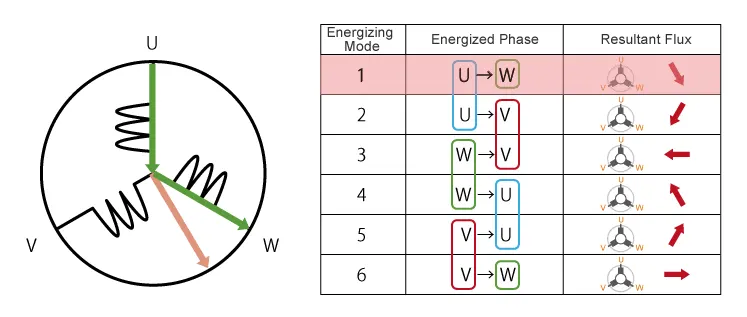
s we have seen, we drive BLDC motors by continually changing the directionality of the flux produced by the coils. The permanent magnets on the rotor continually chase the shifting rotating magnetic field,
causing the rotor to turn.
This is the working of BLDC motor.
Advantages of BLDC motor:
- One big advantage is efficiency, as these motors can control continuously at maximum rotational force (torque).
- Even small BLDC motors can deliver considerable power.
- BLDC motors can be controlled, using feedback mechanisms, to delivery precisely the desired torque and rotation speed.
- Reduce energy consumption and heat generation.
- BLDC motors also offer high durability and low electric noise generation.
- The sparks will not be produced as brushed motor between brushes and commutators.
Control of BLDC motor:
By using the inverter circuitry to also adjust the voltage into each coil, we can control the magnitude of the current.
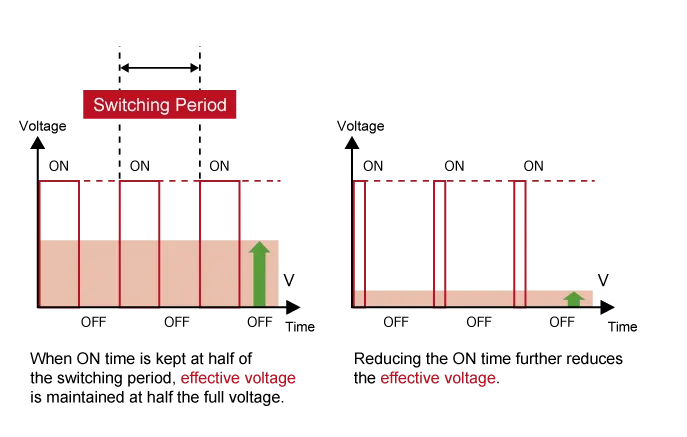
A typical way to adjust the voltage is with pulse width modulation (PWM). We alter the voltage by lengthening or reducing the pulse ON time ( “Duty cycle”: the ON time
expressed as a ratio of the ON+OFF switching interval). Increasing the duty cycle has the same effect as raising the voltage,reducing the duty cycle has the same effect as lowering the current.
PWM can be implemented using MPUs equipped with dedicated PWM hardware. While 120-degree conductiong control only requires two-phase voltage control.
sinusoidal control uses three-phase voltage control and is considerably more complicated as appropriate inverter circuitry is therefore essential for driving BLDC motors.