Week-7 Challenge: DC Motor Control
Answer to Qno-1:
A)
The speed of dc motor using H-bridge has a motor whose supply is givenusing the H-Bridge. The H-Bridge consists of 4 nos. of BJTs Q1,Q2,Q3& Q4 alongwith its respective Freewheeling diodes D1,D2,D3 & D4. These BJTs are switched ON in pairs alternately like – first Q1& Q4 will be ON and then after sometime Q3 & Q2 will be on. The time interval for which the BJTs remain On is known as Duty cycle for a specific interval. The operation can be explained in the following way-
- Say for the first Time interval ‘T’ ,Q1&Q4 will turned on for 25% of T and then Q1 & Q4 will be off and D2 & D3 will freewheel for 75% of T during.
- Then for the second time interval ‘T’ Q2 & Q3 will turn on for 25% of T and then D1 & D2 will freewheel for 75% of T.
- For Q1 & Q4 +ve voltage will be applied to the motor and for Q2 & Q3 –ve voltage will be applied across the motor thus, the motor will rotate in the forward direction for +ve voltage and reverse in for –ve voltage.
- Here D=25% is the duty cycle of the BJTs.
B) From the scope of the model of it is seen that the motor armature current shoots up to a peak value initially at every switching and then settles down to a lesser steady value for each cycle. This is because of the switching surges. As the motor armature is inductive in nature switching initially leads to high voltage across the BJTs as voltage across inductor VL= L*(di/dt). Which is why there is a large shoot up of current at every switching of BJTs and then it settles down to a steady state value.
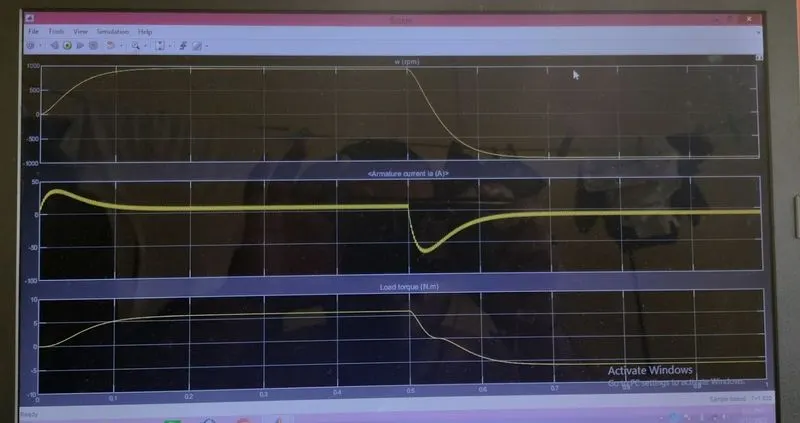
The picture depicts the plot of speed, armature current & torque respectively.
C)
The comparison of Four quadrant Chopper and H,-bridge are as follows-
I) In four quadrant Chopper we can perform all four types of operation like- Forward Motoring, Forward regenerative braking, Reverse motoring and reverse regenerative braking. But in H-Bridge only forward and reverse motoring are possible.
II) Normally efficiency of Four quadrant Chopper is higher than H-Bridge.
III) EV chargers normally use H-Bridge circuit and Four quadrant choppers are used in Industrial and commercial applicantions.
Answer to Qno.-3:
A Brushless DC Motor(BLDC) as the name suggest does has the brushes as the conventional brushed dc motor.Here the commutation takes place electronically, which iswhy they are also referred to as ‘Electronically commuted motor’. Here an integrated inverter switching circuit is used to achieve unidirectional torque. Here the rotor is a permanent magnet and the stator represent the electromagnet poles. A typical electronic controller provides the 3-phase controlled supply to the stator windings to make the rotor rotate.
The controller energizes proper winding at the proper time in a pattern such that the rotor keeps rotating. The permagnet rotor tries to align with the energized electromagnets of the stator and as soon as it aligns , the next poles of the stator gets energized leaving the previous poles de-energized. In this way the rotor gets pulled by the alternately exited poles and the rotor keeps rotating.
The controller knows which poles to energize at the proper moment with the help of Hall Effect sensors. These sensors keep providing feedback to the controller about the position of the rotor and which poles to energize next.
Answer to Qno.-2:
I have attached the simulink file for two quadrant chopper in the name as "twoquadrantchopper.slx". Kindly find the attached file.