Week-7 Challenge: DC Motor Control
Question:1
Aim: To Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model
Answer:
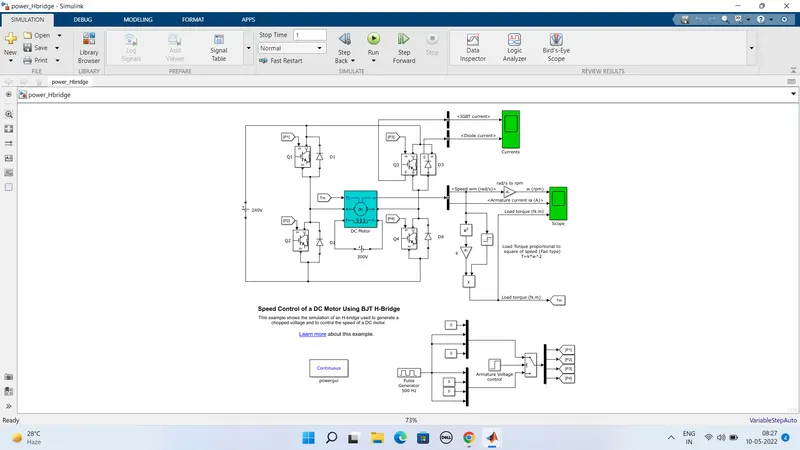
The above figure shows the example of simulation of H bridge used to genreate chopped voltage and to control the speed of the motor.
Here the Bipolar Junction Transistor (BJT) is used for power switching applications operates as an IGBT. When it is conducting BJT operating in the saturated region in a forward voltage Vf is developed between collector and emitter . so the IGBT block can be used to model the BJT device.
For the above circuit the input siginal is generated by using the pluse generator.Here the IGBT block does not simulate the gate current controlling the BJT or IGBT.
The bridge used in the above circuit is H- Bridge It consists of four BJT/Diode pairs . Two transistors are switched simultaneously: Q1 & Q4 or Q2 &Q3.
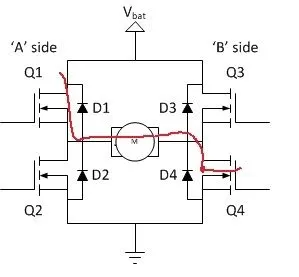
So it works When Q1 and Q4 is triggered a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes .
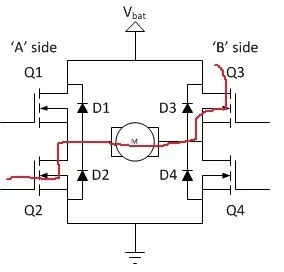
Similarly when Q1 and Q4 are switched off. then Q2 and Q3 are triggered a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes then Q2 and Q3 are switched off.
Here the Q1&Q4 act as one pair and Q2&Q3 act as one pair. And Q1&Q4 act as forward motoring,Q2&Q3 act as reverse motoring
Q1& Q4 When act as fowardmotoring: Q2& Q3 When act as reverse motoring:
B. Comment on the armature current shoot-up from the scope results.
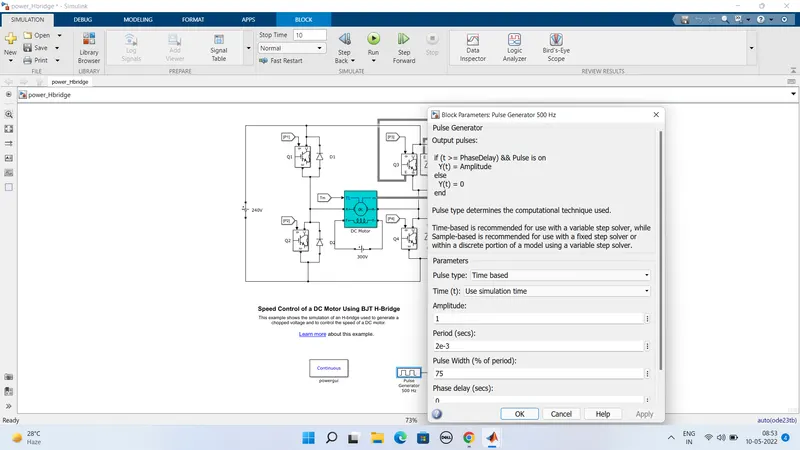
Here the pluse width is set to 75 as show in below figure:
Armature current output results:
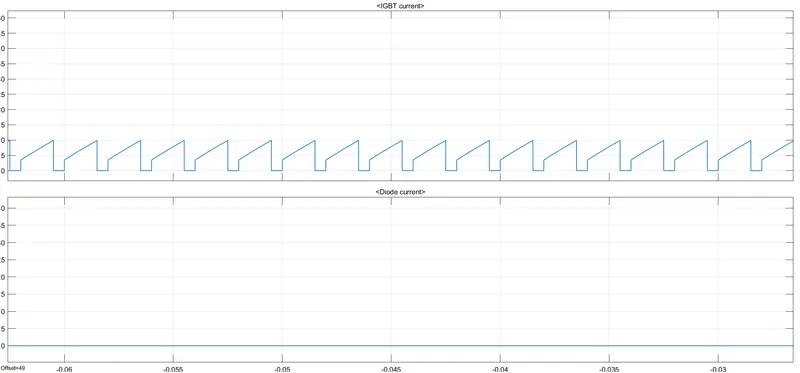
In the above graph it shows that the IGBT current and diode current is obtined when the current passed in the qudrant Q3 and D3.when the Q3 is off the diode current is zero as shown in the above figure.
Scope results:
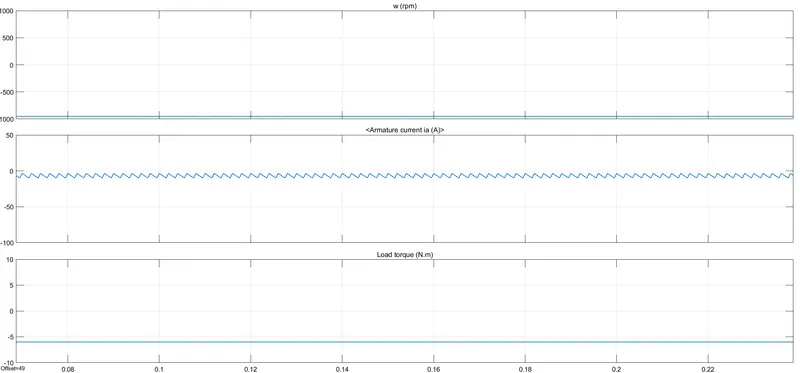
In the starting stage there is sudden shootup in the aramture current and the load torque is aslo changed with the aramture current.
By changing the pluse generator input value:
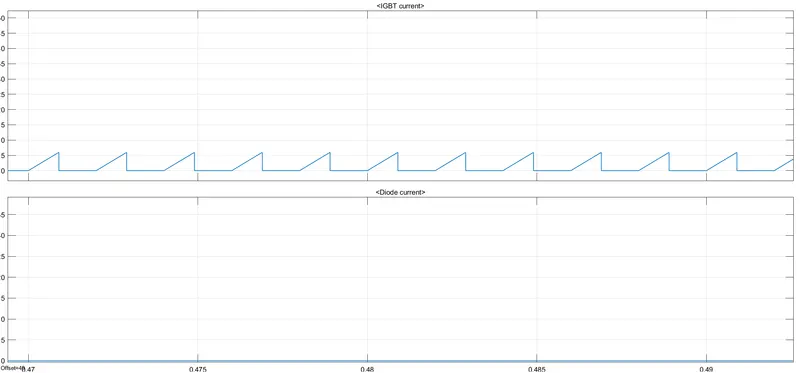
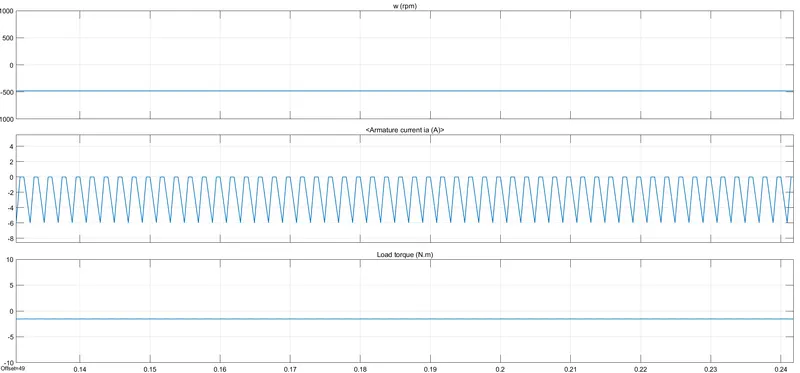
C.Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
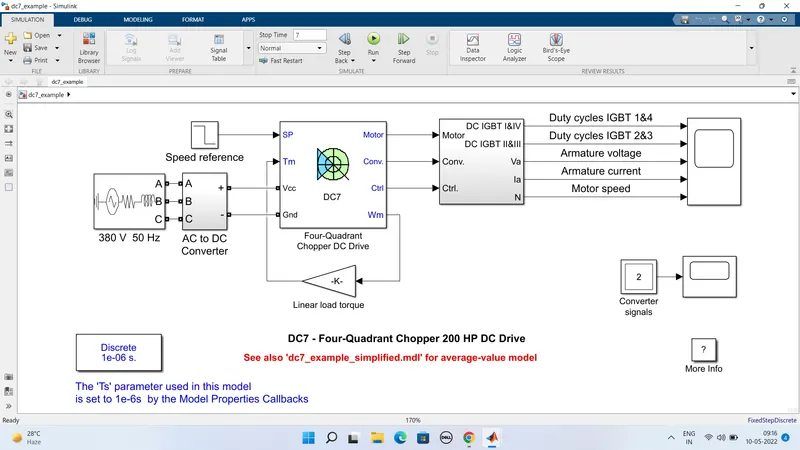
The above figure shows the DC7 four quadrant chopper 200 HP DC drive here the four quadrant operation means the machine operates in 4 quadrants
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. And the converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
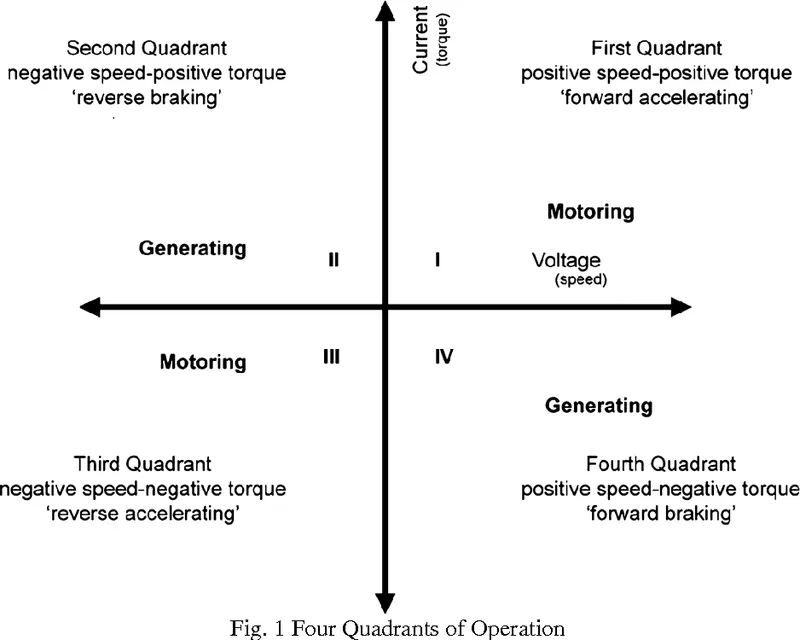
In the 1st quadrant it gives positive speed and positive torque (i.e forward accelerating),In the 2nd quadrant it gives negative speed and postive torque (i.e reverse braking)
In the 3rd quadrant it gives negative speed and negative torque (i.e reverse accelerating),In the 4th quadrant it gives postive speed and neagtive torque.
Comprision between Four-Quadrant Chopper DC Drive (DC7) block with the H-bridge.
- In the H- bridge model the forward motoring and reverse motoring operates in 1st amd 3rd qudarants where as in DC-7 drive it operates in all the 4 quadrants.
- Pi controllers are used for the control of pluse width,in dc7 drive we need to provide the fixed value of pluse width for the output results
- feedback circuit is present in h-bridge there in no feedback in the dc7 drive
- H- bridge is closedloop whereas dc7 drive is open loop chopper
- continue calculation is require in h-bridge,dc7 drive it need discreat calculation
- h- bridge operates slowly compare to the dc7 drive model
- armature current osccilations are reduced by smoothing inductance connect in series but in dc7drive need to lower the duty cycle for eliminating armature ripples.
regenerative braking is absent in h-bridge,but in case of dc7drive it is present.
Question:2
Aim: To Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
Simulink model to develop 2-quadrant chopper:
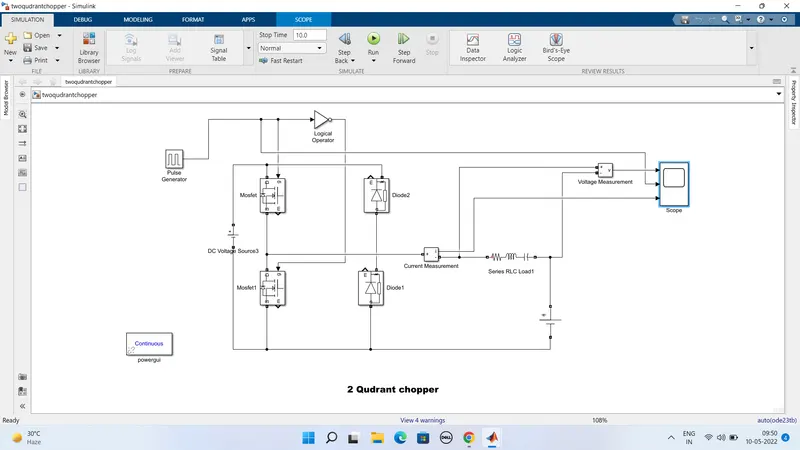
The above circuit shows about the model of 2- quadrant chopper,it is also called as the class-c chopper it mainly operates in the 1st and 2nd quadrants.
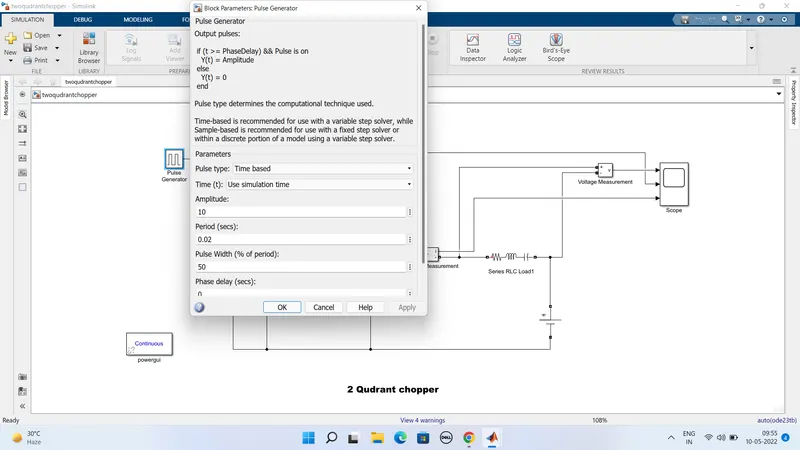
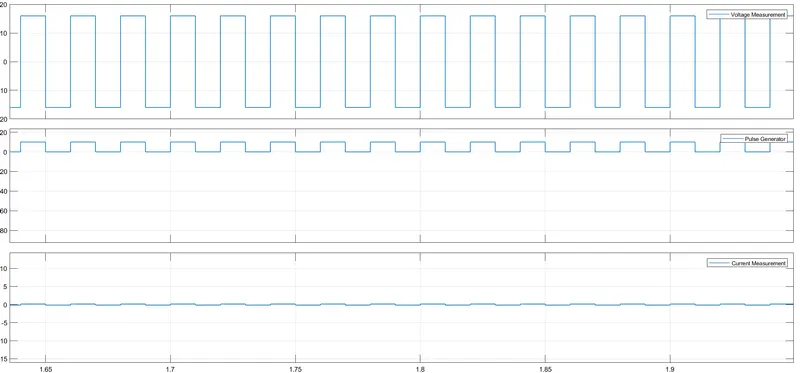
Intially we have given the 30v to the dc volatge source and also we have given the pluse generator values is pluse width is 50% and amplitude is 10 duty cycle is 0.02
Working: During starting stage the two switches should not operate at same time which causes the short circuit among the bridge.
so in first step we need to switch on the CH1 chopper 1 so that current flows from soucre to the load .at the same time inductors tires to store the energy.
In the next step i.e when the CH1 is off then the freewheelimg diode comes into the action and starts conducting then ouput voltage euqals source voltage.here the the direction of current will be reverse when the inuductor starts discharging then current will goes to the source
So for the regenerative braking the CH2 chopper will be operated then the complete current onlys flows through the chopper2 to the negtive side of the secound diode
Output results:
Question:3
Aim:To Explain in a brief about operation of BLDC motor.
It mainly works on the principle same as that of the induction motor when the current carrying conductor is placed in magentic field it exprience a force as because of this force the magnet also experience a euqal amount of the opposite force.in this motor the current carrying conductors are constant where permanent magnet moves.
A brushless DC motor is a permanent magnet synchronous electric motor which is driven by direct current electricity and it achive electronically controlled commutation system instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors.
Construction:
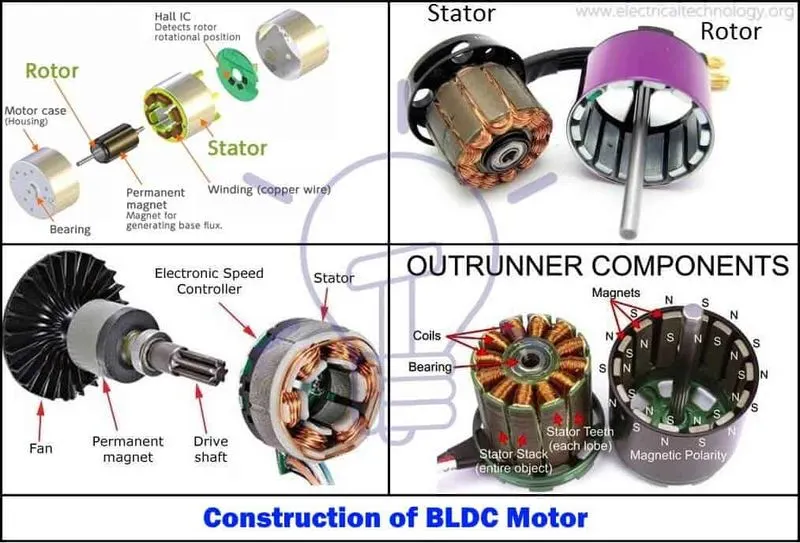
BLDC motors are constructed in different types. Depending on the stator windings : these can be configured as 1-phase2-phase and 3-phase motors. Howeverthis three-phase BLDC motors with permanent magnet rotor are most commonly used.The construction of this BLDC is same as the 3-phase induction motor.
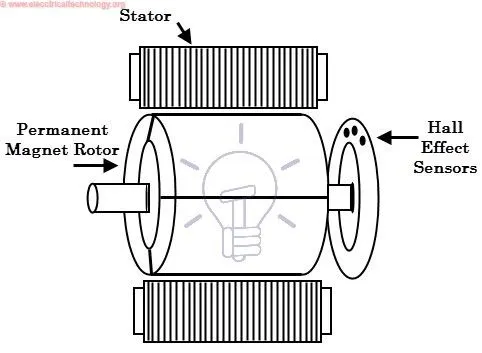
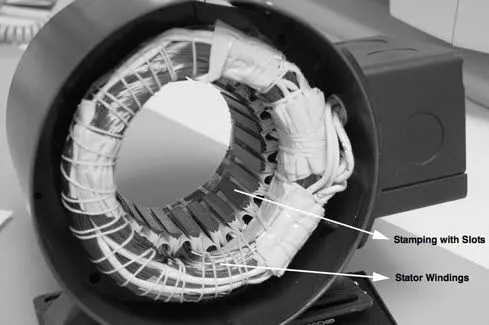
The Stator of the BLDC motor is made up of a steel laminations to carry out the windings. These windings are placed in slots which are axially cut along the inner periphery of the stator. These windings are can be connected in either star or delta . Mainly the most BLDC motors have three phase star connected stator.here the winding is constructed with number of interconnected coils where one or more coils are placed in each slot.
The voltage should be chossen correctly according to the required voltage
Rotor:
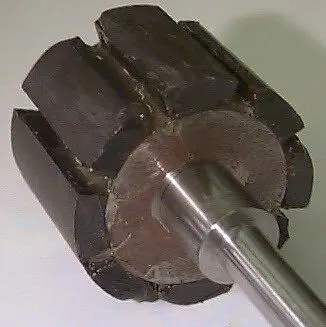
The rotor used in this BLDC motors are parement magent material the numer of poles in the rotor are changes from 2-8 depending upon the applications ,to achieve the high amount of torque the flux density of the material should aslo be high this helps to produce the magentic field density.
Working of BLDC motor:
It mainly works on the principle same as that of the induction motor when the current carrying conductor is placed in magentic field it exprience a force as because of this force the magnet also experience a euqal amount of the opposite force.in this motor the current carrying conductors are constant where permanent magnet moves.
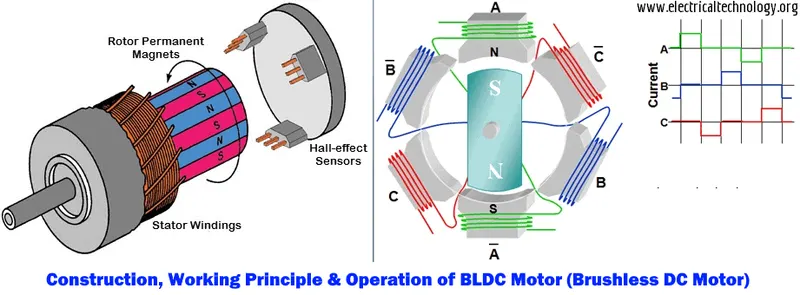
Here when the stator coils are given the supply voltage it act as electromagnet then starts producing the uniform feild in airgap,then due to intreaction betwwen the electro magnet and parement magnet the rotor rotates continously .By obesrving the below fig we can say that the motor is excited based upon the different switching stages .ie north and south poles. when the motor produce torque becacuse of the attraction of forces and reulsion of forces then this way motor moves in clockwise direction.
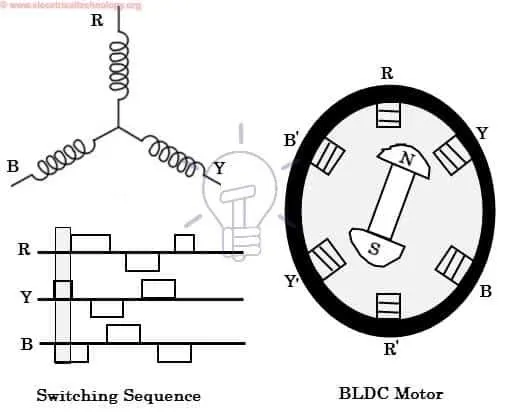
Brush less motor drive:
The figure shown below is the BLDC motor drive circuit which consists of MOSFET bridge electronic controller hall effect sensor and BLDC motor.
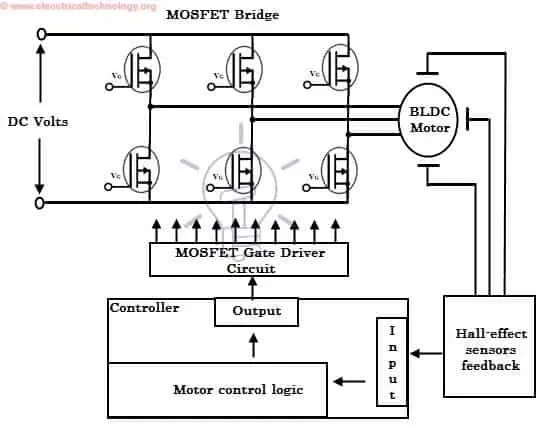
Advantages of BLDC motors:
- It as high efficiency because of use of permanent magent motor
- It has high speed operation even the fully loaded conditions
- It as no mechincal commutator problems
- It as higher dynamic response
- The opertion is quite due to the absence of brushes.
Disadvantages of BLDC motors:
- These are very costly compare to other type of motors
- It requires additional sensors
- The drive used in this is complex
Applications:
- Used in the hard disc drives and dvd players
- Used in electrical vehicles and hybrid vehicles
- Used in washing machines and dryers
- Used in fans pamps
Conclusion:
we have completed the above tasks
In case-1 we have explained the demo of matlab model of speed control of dc motor using BJT
In case-2: we have commented on the aramture current shoot-up results
In case-3: we have explained the brife operation about BLDC motor