Week-7 Challenge: DC Motor Control
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.?
BJT- A bipolar transistor consists of three-layer "sandwich"of doped semiconductor materials,(a & c)either P-N-P or N-P-N (B & C). Each layer forming the transistor has a specific name, and each layer is provided with a wire contact for connection to a circuit. the schematic symbols are given below.
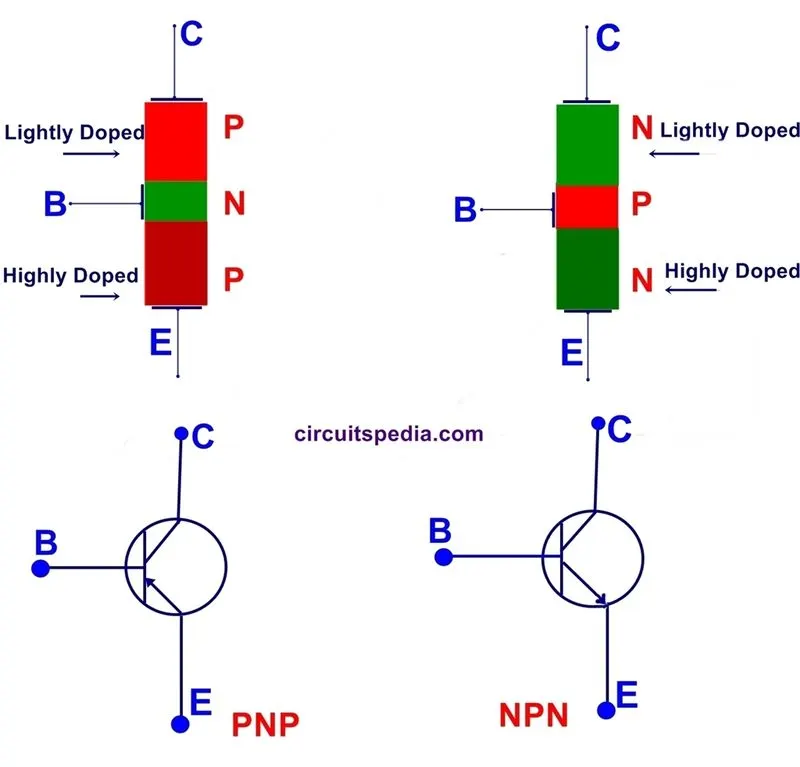
bipolar transistor work as current-controlled current regulators.In other words,transistor restrict the amount of current passed according to a smaller, controlling current. the main current that is controlled goes from collector to emitter ,or from emitter to collector depending on the type of transistor it is (NPN ,PNP).the small current that controls the main current goes from base to emitter, or from emitter to base ,once again depending on the kind of transistor it is (NPN,PNP,respectively).
MOSFET- The MOSFET (METAL OXIDE SEMICONDUCTOR FIELD EFFECT TRANSISTOR) transistor is a semiconductor device which is widely used for switching and amplyfying electronic signals in the electronic devices. the MOSFET is a four terminals device with source(s),gate(G),drain(D) and body (B) ternimals. the body of the MOSFET is frequently connected to the source terminal so making it a three terminal device like field effect transistor.
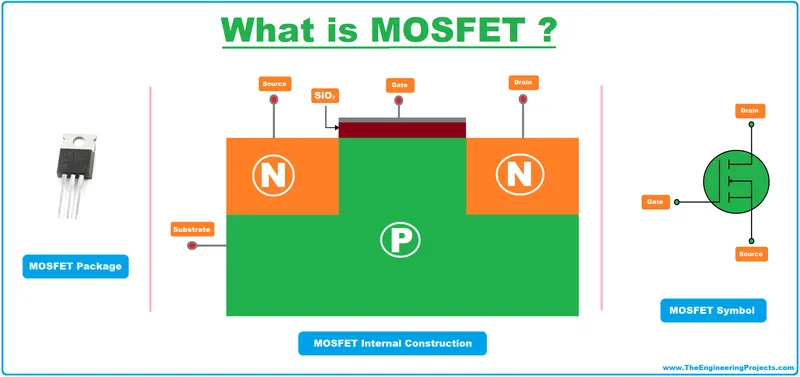
The MOSFET can function in two ways:
1. Depletion mode: When there is no voltage on the ,the channel shows its maximum conductance. as the voltage on the gate is either positive or negative,the channel conductivity decreases.
2. Enhancement mode: When there is no voltage on the gate the device does not conduct. more is the voltage on the gate ,the better the device can conduct.
WORKING PRINCIPLE
The aim of the MOSFET is to be able to control the voltage and current flow between the source and drain.its works almost as a switch. the working of MOSFET depends upon the MOS capacitor.the MOS capacitor is the main part of MOSFET. the semiconductor surface at the below oxide layer which is located between source and drain terminal.it can be inverted from p-type to n-type by applying a positive or negative gate voltages respectively. when we apply the positive gate voltage the holes present under the oxide layer with a repulsive force and holes are pushed downward with the substrate.the depletion region populated by the bound negative charge which are associated with the acceptor atmos. The electrons reach channel is formed. The positive voltage also attracts electrons from the n+ source and drain regions into the channel. now ,if a voltage is applied between the drain and source , the current flow freely between the source and drain and the gate voltage controls the electrons in the channel. Instead of positive voltage if we apply negative voltage, a hole channel will be formed under the oxide layer.
IGBT-The insulated gate bipolar transistor also called IGBT for short,is something of a cross between a conventional bipolar junction transistor,(BJT) and a field effect transistor,(MOSFET) making it ideal as a semiconductor switching device.
The IGBT Transistor takes the best part of these two types of common transistor, the high input impedance and high switching speeds of a bipolar transistor, and combines the them together to produce another type of transistor switching device that is capable of handling large collector-emitter currents with virtually zero gate current drive.
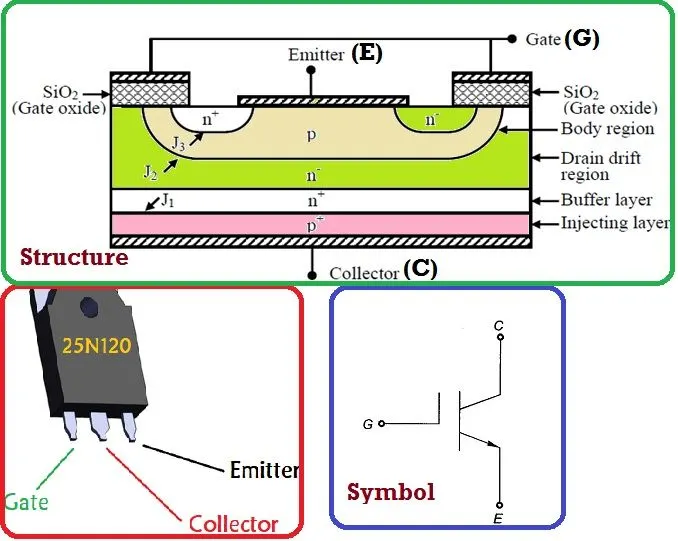
COLLECTOR,EMITTER and GATE. Two of its terminals (C-E) are associated with the conductance path which passes current, while its third terminal (G) controls the device.
the amount of amplification achieved by the insulated gate bipolar transistor is a ratio between its output signal and its input signals. For a conventional bipolar junction transistor ,(BJT) The amount of gain is approximately equal to the ratio of the output current to the input current, called beta.
For a metal oxide semiconductor field effect transistor or MOSFET ,there is no input current as the gate is isolated from the main current carrying channel. therefore ,an FET's gain is equal to the ratio of output current channel change to input voltage change ,making it a transconductance device and this is also true of the IGBT . then we can treat the IGBT as a power BJT whose base current is provided by a MOSFET.
COMPARISON
| DEVICE CHARACTERISTICS | POWER BIPOLAR | POWER MOSFET | IGBT |
| 1.voltage rating | high<1kv | high<1kv | very high>1kv |
| 2.current rating | high<500A | low<200A | high<500A |
|
3.input drive |
current 20-200 Hfe |
voltage Vgs=3-10v |
voltage Vge=4-8v |
| 4.input impedance | low | high | high |
| 5.output impedance | low | medium | low |
| 6.switching speed | slow (ns) | fast (us) | medium |
| 7.cost | low | medium | high |
BJT H-Bridge DC Controller
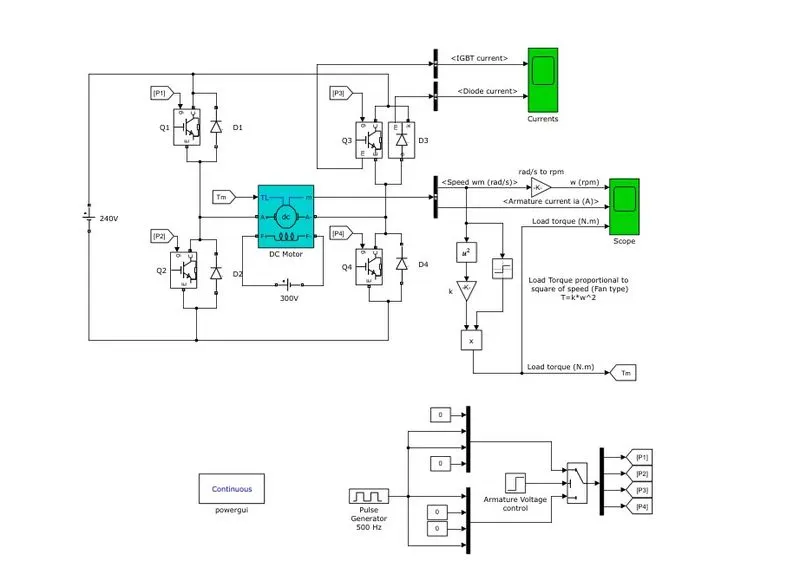
The bipolar junction transistor (BJT) when used for power switching application,operates as an IGBT. when it is conducting (BJT operating in the saturated region),a forward voltage Vf is developed between collector and emitter.therefore the IGBT block can be used to model the BJT device.
the IGBT block does not simulated the gate current controlling the BJT or IGBT.the switch is controlled by a simulink signal (1/0). the dc motor uses the preset model (5 HP 24V 1750 rpm). it simulated a fan type load (where load torque is proportional to square of speed). the armature mean voltage can be varied from 0 to 240 V when the duty cycle is varied from 0 to 100%.
the H-bridge consist of four BJT/diode pairs (BJT simulated by IGBT models). Two transistor are switched simultaneously: Q1 and Q4 or Q2 and Q3. when Q1 and Q4 are fired, a positive voltage is applied to the motor and diode D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. when Q2 and Q3 are trigger a negative voltage is applied to the motor and diodes D1-D4 operate as free wheeling when Q2 and Q3 are switched off.
Duty cycle at 75% upload blow,
result at 75% duty cycle -we see that there is changed of direction for motor the armature current shoots up.image upload below.
so in order to reduce the armature current we reduce the duty cycle to 50%.upload below,
result at 50% duty cycle-we see the current shoot up has reduced but there is still some increase in current when the direction of the motor changes.
we reduce the duty cycle to 25% and see that there is a very little bit change in the current when the direction change.
The Four-Quadrant Chopper DC Drive (DC7) block:
the 200HP DC motor is seperately excited with a constant 150 V DC field voltage source. the armature voltage is provided by an IGBT converter controlled by two PI regulators.
the converter is fed by a 515 V DC bus obtained by rectification of a 380V DC 50Hz voltage source. in order to limit the DC bus voltage during dynamic braking mode , abraking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. the speed regulator outputs the armature current reference used by a current controlled in order to obtain the electromagnetic torque needed to reach the desired speed.
The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference change that could cause armature over-current and destabilize the system.
THE CURRENT REGULATOR controls the armature current by computing the appropriate duty ratios of the 5 KHz pulse of the four IGBT device (pulse width modulation). for proper system behavior, the instantaneous pulse values og IGBT devices 1 and 4 are opposite to those of IGBT device 2 and 3. this generate the average armature voltage needed to obtain the desired armature current.
In order to limit the amplitude of the current oscillations,a smoothing inductance is placed in series with the armature circuit.
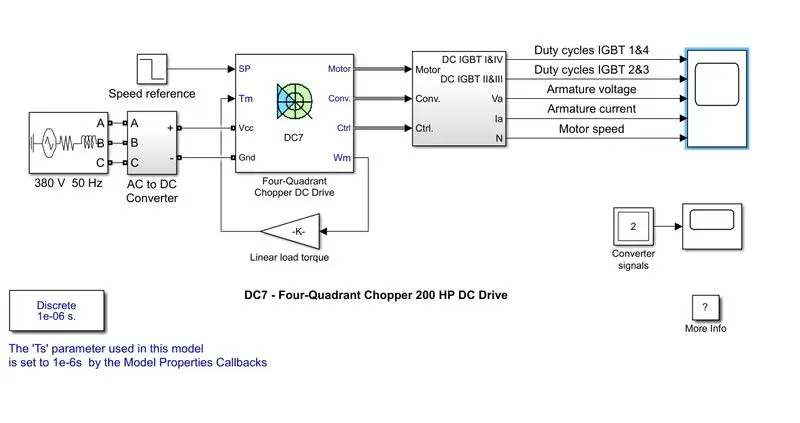
COMPARISON:
Four-quadrant chopper DC drive
1. To change the motor direction the polarity is changed.
2. It has broader torque and power output ranges.
3. Up to 400V can be achieved.
4. In this the current has chopped values.
5. Regenerative braking is possible.
H-BRIDGE MODEL:
1. To change the motor direction the current signal has to be interrupted.
2. It uses single pulse generator which gives narrow torque and power output ranges.
3. Up to 350V can be achieved.
4. In this the current has continuous values.
5. Regenerative braking is not possible.
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
A DC-to-DC converter, also know as dc chopper,is a static device which is used to obtaine a varialbe dc voltage to constant dc voltage source. chopper are widely used in trolly cars,battery-operated vehicles,traction motor control of large number of dc motors,etc.they are also used as dc voltage regulators. chopper are 2-types ,1.step-up chopper and 2.stepdown chopper,output voltage will be less than the input voltage ,stepup chopper output voltage more than the input voltge.
IN the type of chopper,the average voltage will be always positive but the average load current might be positive or negative. The two switches CH1 and CH2 should not be turned on simultaneously asthe combined action may cause a short circuit in supply lines. For regenerative braking and motoring these type of chopper configuration is used.
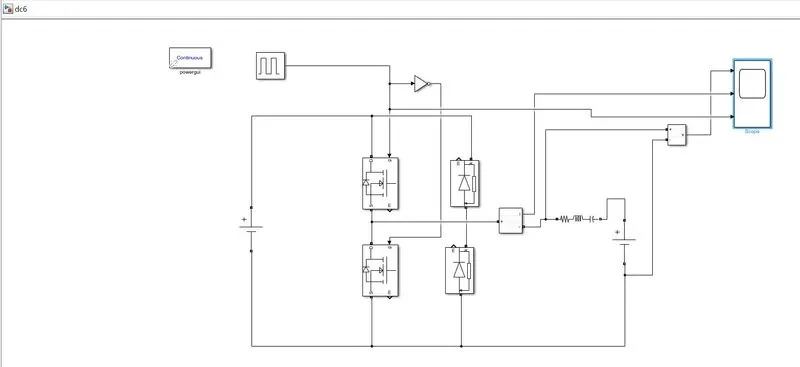
We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper CH1is on the current flows from source to load. The induction stores energy. When CH1 turn off the freewheeling diode starts conducting and the output voltage V0 will be equal to Vs.
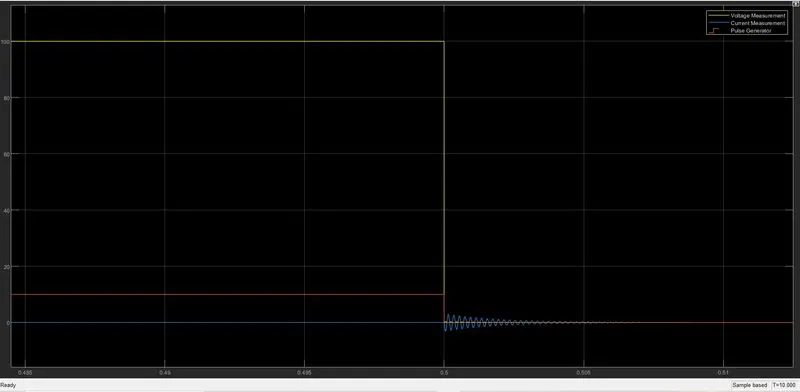
The direction of the load current i0 will be reversed.the current i0 will be flowing towards the source. the load current will be negative when the Ch2 is on. the current completes its path through diode D2.
3. Explain in a brief about operation of BLDC motor.
A BRUSHLESS DC MOTOR is a electronically commuted DC motor which does not have brushes. the controlled DC provides pulse of current to the motor winding which control the speed and torque of the synchronous motor.
these type of motor are highly efficient in producing a large amount of torque over a vast speed range. i brushless motors ,permanent magnet rotate around a fixed armature and overcome the problem of connecting current to the armature.commutation with electronics has a large scope of capabilities and flexcibility. they are know for smooth operation and holding torque when stationary.
HOW DOES A BRUSHLESS MOTOR WORK
Before explaination the working of a brushless DC motor,it is better to understand the function of a brushed motor.In brushed motors,there are permanent magnets on the outside and a spinning armature which contains electromagnet is inside. these electromagnets creat a magnetic field in the armature when the power is switched on and help to rotate the armature.
the brushes change the polarity of the pole to keep the rotation on of the armature. the basic working principle for the brushed DC motor and for brushless DC motor are same i.e.internal shaft position feedback.
Brushless DC motor has only two basic parts: rotor and stator . the rotor is the rotating part and has rotor magnets where as stator is the stationary part and contains stator windings.In BLDC permanent magnets are attached in the rotor and move the electromagnets to the stator. the high power transistor are used to activate electromagnets for the shaft turns. the controller performs power distributed by using a solid-state circuit.
CONSTRUCTION OF BRUSHLESS DC MOTOR:
In this motor,the permanent magnet attach to the rotor. the current -carry conductor or armature winding are located on the stator. they use electrical commutation to convert electrical energy into mechanical energy.
the main desing difference between a brushed and brushless motor is the replacement of mechanical commutator with an electric switch circuit. A BLDC motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
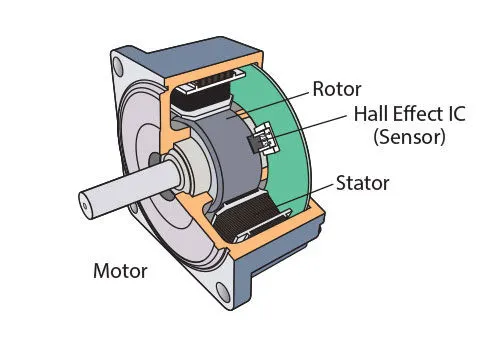
Brushless motor does not have any current carrying commutators. the field inside a brushless motor is switched through an amplifier which is triggered by the commutation device like an optical encoder.
the layout of a DC brushless motor can vary depending on whether it is in "out runner"style or "Inrunner"style.
working principle of brushless dc motor:
BLDC motor works on the principle similar to that a brushsd dc motor. the lorentz force law which state that whenever a current carrying conductor placed in a magnetic field it experience a force. as a consequence of reaction force,themagnet will experience an equal and opposite force. In the brushless DC motor the current carrying conductor is stationary.
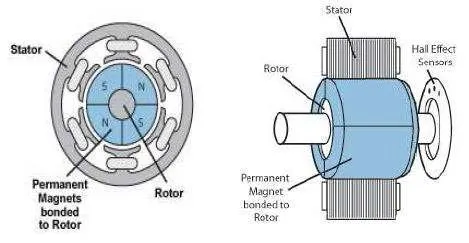
When the stator coil get a supply from source,it becomes electromagnet and starts producing the uniform field in the air gap.though the source of supply is DC ,switching makes to generate an AC voltage waveform with trapezoidal shape.due to the force of interaction between electromagnet stator and permanent magnet rotor ,the rotor continues to rotate.
Types of Brushless DC motor
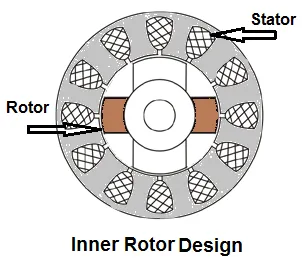
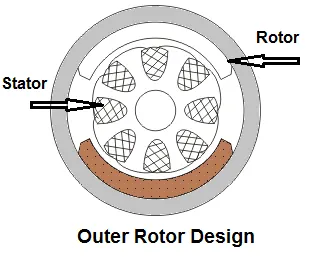
Basically ,BLDC are two types ,one is outer rotor motor and other is inner rotor motor. the basic different between the two is only in designing , their working principle are same.
Inner rotor design
In an inner rotor design ,the rotor is located in the centre of the motor and the stator winding surround the rotor. As the rotor is located in the core , the rotor magnet do not insulated heat inside and heat get dissipated easily.due to this reason, inner rotor designed motor produces a large amount of torque and widely used.
Outer rotor design
In outer rotor design , the rotor surrounds the winding which is located in the core of the motor.the magnets in the rotor trap the heat of the motor inside and do not allow to dissipate from the motor.such type of designed motor operated at lower rated current and has low cogging torque.
Advantages of brushless DC motor:
1. brushless motor are more efficient as its velocity is detemined by the frequency at which current is supplied,not the voltage.
2. as brushless are absent ,the mechanical energy loss due to friction is less which enhanced efficiency.
3. BLDC motor can operate at high-speed under any condition.
4. There is no sparking and much less noise during operation.
5. More electromagnets could be used on the stator for more precise control.
6. BLDC motors accelerate and decelerate easily as they are having low rotor inertia.
7. Its high performance motor that provide large torque per cubic inch over a vast sped rang.
8. BLDC motor do not have brushes which make it more reliable ,high life expectancies and maintenance free operations.
9. There is no ionizing sparks from the commutator and electromagnets interference is also get reduce.
10. Such motors cooled by conduction and no air flow are required for inside cooling.
Disadvantages:
1. BLDC motor cost more than a brushed DC motor.
2. the limited high power could be supplied to BLDC motor, otherwise too much heat weakens the magnet and the insulation of winding may get damaged.