Week-7 Challenge: DC Motor Control
Week 7: Speed control of Dc motor
Introduction
An H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load. These circuits are often used in robotics and other applications to allow DC motors to run forwards or backwards.
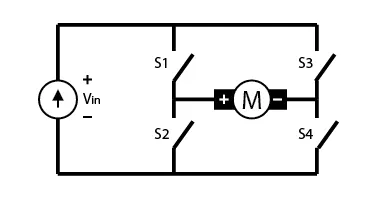
A four quadrant chopper is a chopper which can operated in all the four quadrants. The power can flow either from source to load or load to source in this chopper. This type of chopper is also known as Class-E or Type-E chopper.
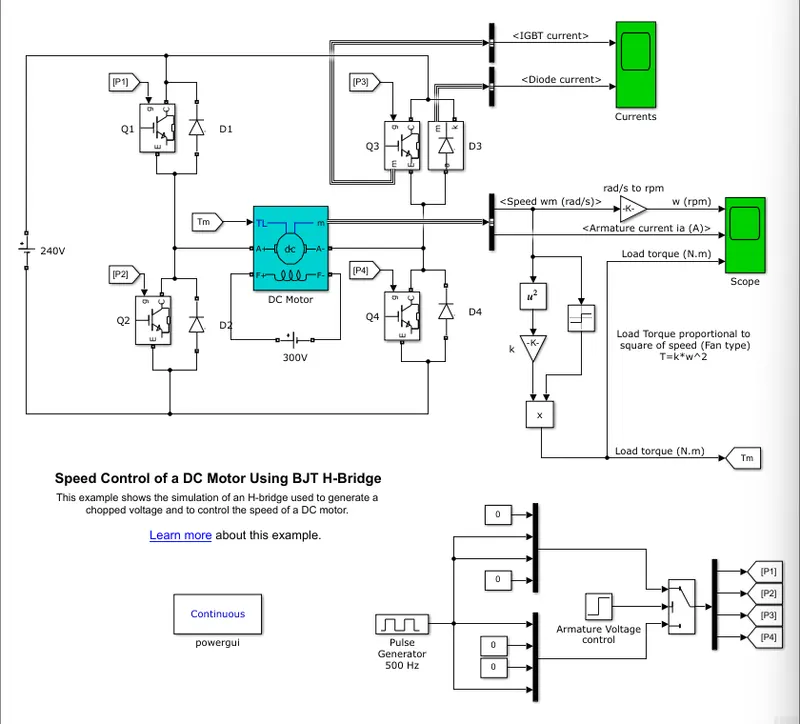
Study Case 1 a: Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
Explanation:
Blocks used:
-
Separately excited DC motor
-
BJT - Bi polar Junction Transistors
-
Diodes
-
Scope
-
Pulse Generator
Operational Procedure:
-
Here BJT transistors are used as switches where their on off states are determined by pulse generator block and they are connected in a H pattern and load is connected in middle, here load is sedately excited Dc motor where 300v are used to excite the motor.
-
The four switches are used namely Q1,Q2,Q3,Q4 any two are operated at once and like Q1 and Q4 for forward movement of vehicle and Q2 and Q3 are for reverse movement of vehicle.
-
When Q1 and Q4 are in On state the current from source passes through Q1 and then to Armature of motor and the to Q4 and from Q4 to back to source again.This makes motor to rotate which leads in forward motion.
-
When Q2 and Q3 are in on state the current from source gets to Q3 and from there it goes to motor and from there it goes to Q2 and then back to source this makes motor to cause reversing of vehicle.
-
Here The switches Q1 and Q2 or Q3 and Q4 are not to be in On state at exact same time as this will case short circuit which leads to burn down of equipment.
-
Diodes are placed after BJT because The diodes represented in the H-Bridge are called “fly back diodes.” These diodes provide a path for the current to dissipate when the motor switches from on to off.
-
Pulse Generator is used to activate Gates for switches for current to pass.
Results from Scope:
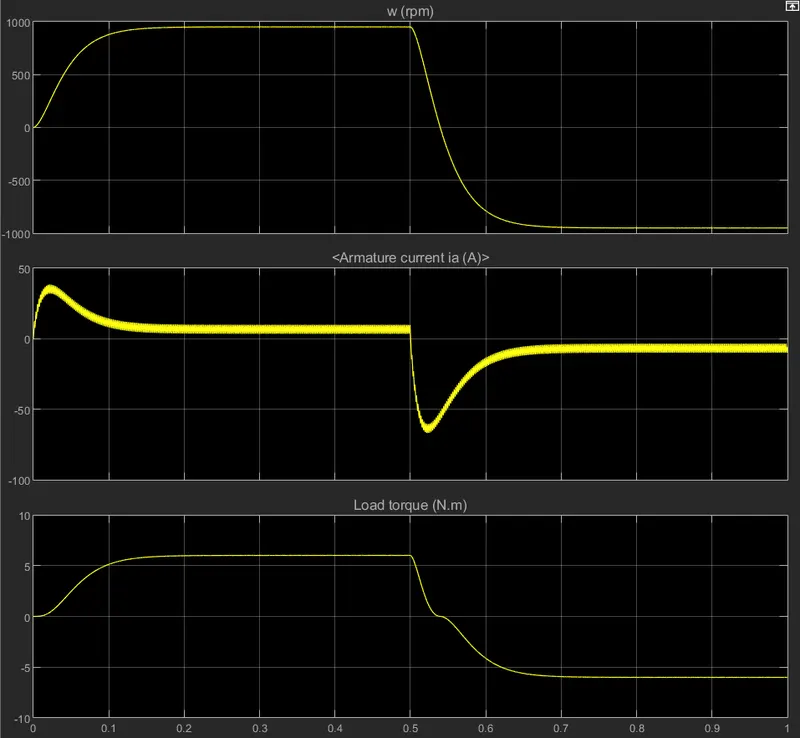
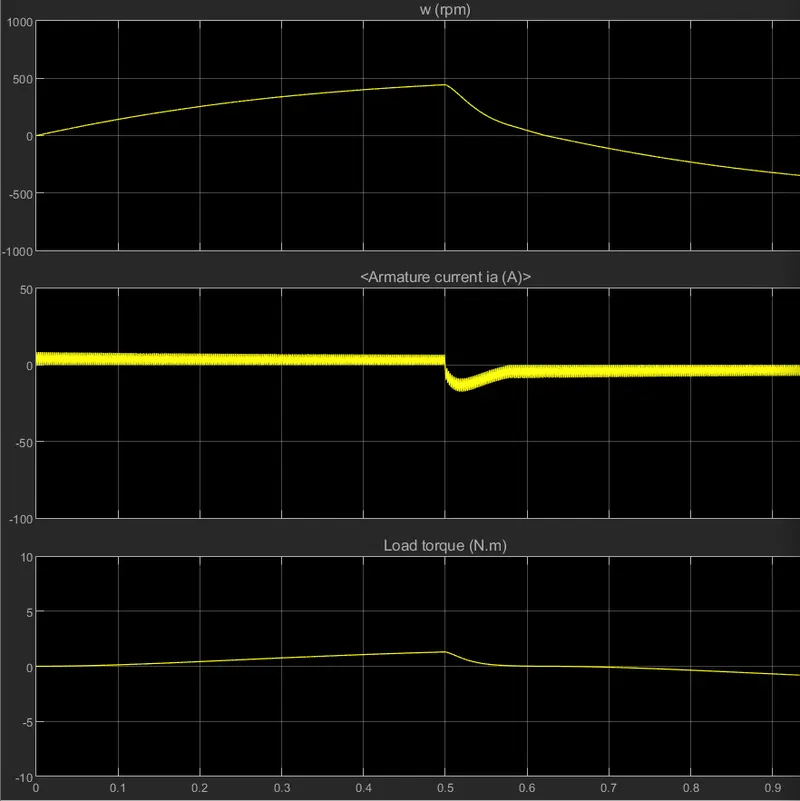
Here There is a spike in armature current after first forward cycle. It depends on the duty cycle, below is the image of same characteristics but with changed duty cycle.
Study Case 1 c:
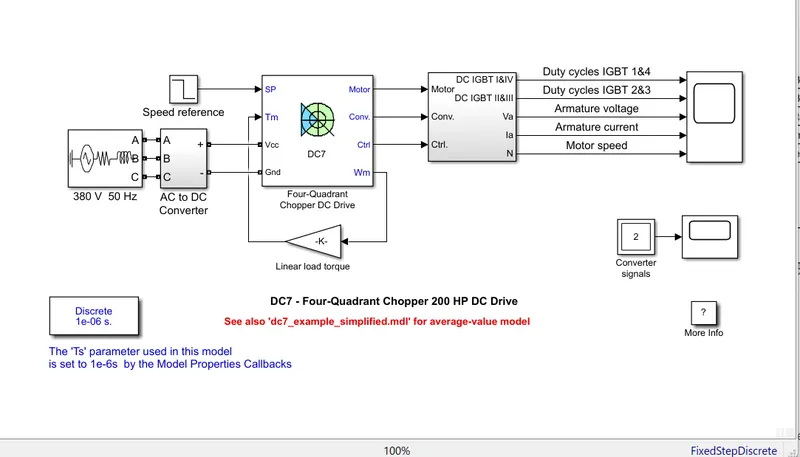
Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
The four quadrant chopper: DC7 Block
Working of a 4 Quadrant chopper:
A four quadrant chopper is a chopper which can operated in all the four quadrants. The powercan flow either from source to load or load to source in this chopper. In first quadrant, a Class-E chopper acts as a Step-down chopperwhereas in second quadrant it behaves as a Step-up chopper. This type of chopper is also known as Class-E or Type-E chopper. This article describes the working principle and operation of Class-E chopper with the help of circuit diagram.
Working Principle / Operation of Class-E Chopper:
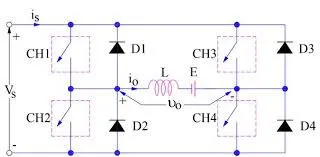
The circuit of a four quadrant chopper or class-E chopper basically consists of four semiconductorswitches CH1 to CH4 and four diodesD1 to D4. The four diodes are connected in anti-parallel. The circuit diagram of this type of chopper is shown below.
In the above circuit diagram, the choppersare numbered CH1 to CH4. For first quadrant operation CH1 is made ON, for second quadrant operation CH2 is made ON and so on. To better understand the working of four quadrant chopper, we will discuss its operation separately for each quadrant.
First Quadrant Operation:
For first quadrant operation, CH4 is kept ON, CH3 is kept OFF and CH1 is operated. When both CH1 & CH4 are ON simultaneously, the load gets directly connected to the source and hence the output voltage becomes equal to the source voltage. This essentially means that vo= vs. It may be noted that the load current flows from source to load as shown by the direction of io.
When CH1 is switched OFF, the load current free wheels through CH4 and D2. During this period, the load voltage and current remains positive.
Thus, both the output voltage vsand load current ioare positive and hence, the operation of chopper is in first quadrant. It may be noted that, Class-E chopper operates as a step-down chopper in this case.
Second Quadrant Operation:
To obtain second quadrant operation, CH2 is operated while keeping the CH1, CH3 & CH4 OFF. When CH2 is ON, the DC source in the load drives current through CH2, D4, E and L. Inductor L stores energy during the On period of CH2.
When CH2 is turned OFF, current is fed back to the source through D1, D4. It should be noted at this point that (E+Ldi/dt)is more than the source voltage Vs. As load voltage Vo is positive and Io is negative, it is second quadrant operation of chopper. Since, the current is fed back to the source, this simply means that load is transferring power to the source. Kindly read Step-up chopperfor detailed analysis and better understanding.
For second quadrant operation, load must contain emf E as shown in the circuit diagram. In second quadrant, configuration operates as a step-up chopper.
Third Quadrant Operation:
To obtain third quadrant operation, both the load voltage and load current should be negative. The current and voltage are assumed positive if their direction matches with what shown in the circuit diagram. If the direction is opposite to what shown in the circuit diagram, it is considered negative. One important thing to notice is that the polarity of emf E in load must be reversed to have third quadrant operation. Circuit diagram of Class-E chopper for third quadrant operation is shown below.
Polarity of Load emf E reversed
For third quadrant operation, CH1 is kept off, CH2 is kept ON and CH3 is operated. When CH3 is ON, load gets connected to source and hence load voltage is equal to source voltage. But carefully observe that the polarity of load voltage vo is opposite to what shown in the circuit diagram. Hence, vois assumed negative. Let us now see what is the status of load current io. It may be seen that iois flowing in the direction opposite to shown in the circuit diagram and hence negative.
Now, when CH3 is turned OFF, the negative load current free wheels through the CH2 and D4. In this manner, voand ioboth are negative. Hence, the chopper operates in third quadrant.
Fourth Quadrant Operation:
To obtain fourth quadrant operation, CH4 is operated while keeping CH1, CH2 and CH3 OFF. The polarity of load emf E needs to be reversed in this case too like third quadrant operation.
When CH4 is turned ON, positive current flows through CH4, D2, L and E. InductanceL stores energy during the time CH4 is ON. When CH4 is made OFF, current is fed back to the source through diodes D2, D3. Here load voltage is negative but the load current is always positive. This leads to chopper operation in fourth quadrant. Here, power is fed back to the source from load and chopper acts as a step-up chopper.
The operation of a four quadrant chopper or Class-E chopper is summarized in the figure below.
Comparisons between H bridge and 4 Quadrant chopper:
-
In chopper speed is controlled by varying pulses from PI current controller abd H bridge model speed controlled by varying duty cycle voltages
-
Regenerative braking is possible in chopper
-
H bridge is continuous in operation while chopper is discreate in nature
-
h bridge mostly used in robotics where as Dc chopper mostly used in electric vehicles.
Study Case 2:
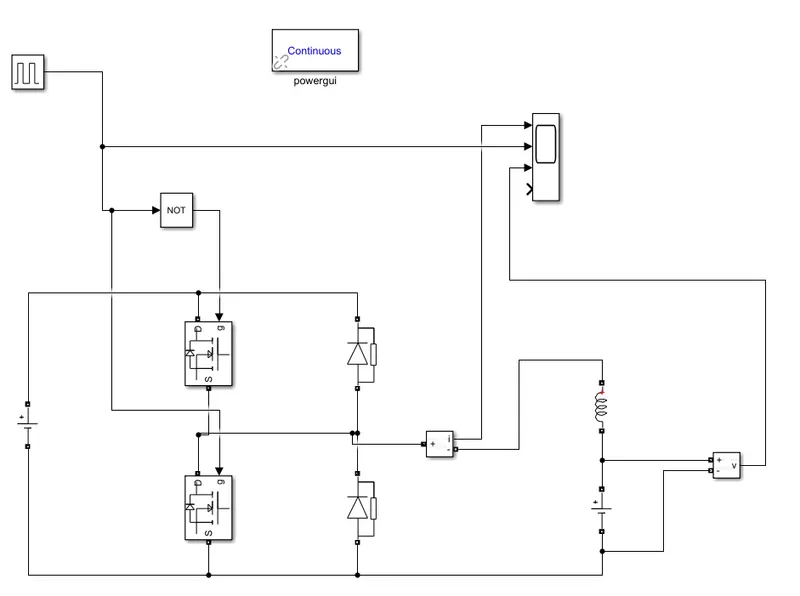
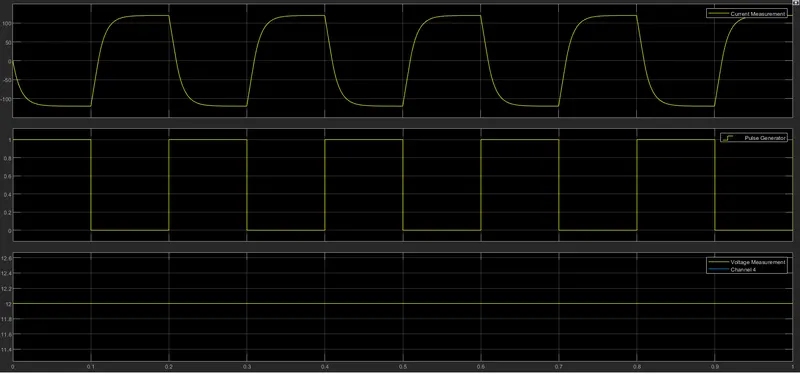
Develop a 2-quadrant chopper using Simulink & explain the working of the same with the relevant results.
Results:
Working:
Sometimes a chopper may be required to provide a two quadrant operation by retaining the current direction in both motoring and braking modes. Such a Two Quadrant Chopper is shown in Fig. 3.86, and its waveforms in Fig. 3.87. The chopper permits a change in the polarity of terminal voltage keeping the direction of current constant. In Fig. 3.86 S1 and S2 are the choppers working as electronic switches and D1 and D2 are the feedback diodes. Assuming continuous conduction, both S1 and S2 operate simultaneously.
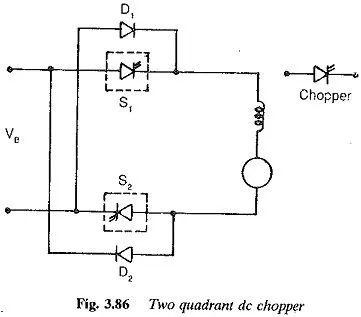
When they are ON, the load current Id increases, with the rate of rise depending upon the back emf and torque of the machine. When they are OFF, the load current is fed to the supply through the diodes D1 and D2. The current decreases in this stage. From Fig. 3.87, it is clear that the load voltage is effectively negative when the diodes conduct. The average value of the output voltage of the chopper
Vd
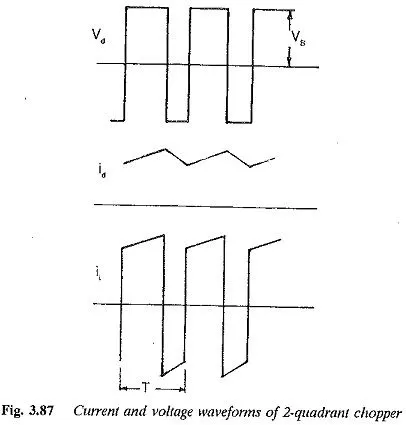
a is zero for a = 0.5, the output voltage is an ac waveform with average voltage equal to zero. For a > 0.5 the average value of the dc voltage is negative. The chopper works in the regeneration mode. The power flows from the load to the supply and the dc machine operates as a generator. For control ratios a c 0.5, the operation is similar to the inversion of a line commutated converter (α > 90°). For a > 0.5 the chopper has normal operation. The power flows from the supply to the load. This operation of the chopper is similar to rectification of a line commutated converter (α < 90°). For, a = 0.5 the load voltage is zero. The control characteristic of a two quadrant chopper is shown in Fig. 3.87.
Study Case 3:
Explain in a brief about operation of BLDC motor.
Brushless DC electric motors also known as electronically commutated motors (ECMs, EC motors).
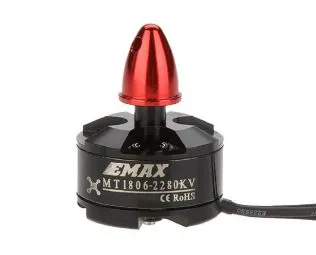
Primary efficiency is a most importent feature for BLDC motors. Because the rotor is the sole bearer of the magnets and it doesn't require any power. i.e. no connections, no commutator and no brushes. In place of these, the motor employs control circuitry. To detect where the rotor is at certain times, BLDC motors employ along with controllers, rotary encoders or a Hall sensor.
Construction of Brushless DC motor
In this motor, the permanent magnets attach to the rotor. The current-carrying conductors or armature windings are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy.
The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit. A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
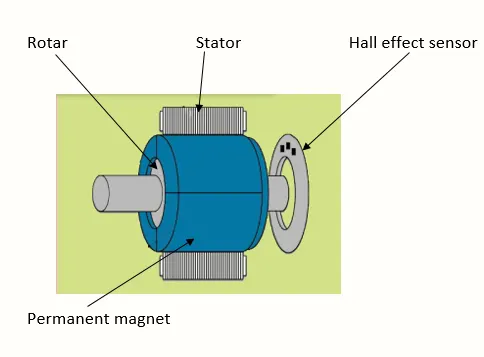
Brushless motor does not have any current carrying commutators. The field inside a brushless motor is switched through an amplifier which is triggered by the commutating device like an optical encoder.
The layout of a DC brushless motor can vary depending on whether it is in “Out runner” style or “Inrunner” style.
-
Outrunner – The field magnet is a drum rotor which rotates around the stator. This style is preferred for applications that require high torque and where high rpm isn’t a requirement.
-
In runner – The stator is a fixed drum in which the field magnet rotates. This motor is known for producing less torque than the out runner style, but is capable of spinning at very high rpm.
MUST READ BLOG POSTS ON DC MOTORS
Working Principle of Brushless DC motor
BLDC motor works on the principle similar to that of a Brushed DC motor. The Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current carrying conductor is stationary and the permanent magnet is moving.
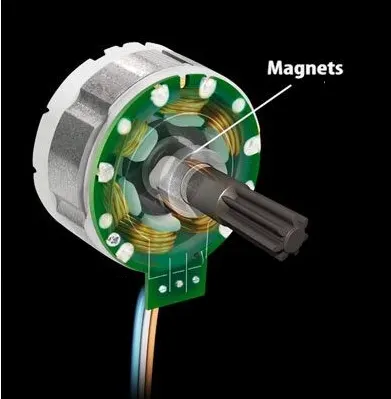
When the stator coils get a supply from source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles which causes the motor to rotate.
Advantages of Brushless DC motor
-
Less overall maintenance due to absence of brushes
-
Reduced size with far superior thermal characteristics
-
Higher speed range and lower electric noise generation.
-
It has no mechanical commutator and associated problems
-
High efficiency and high output power to size ratio due to the use of permanent magnet rotor
-
High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed
-
Smaller motor geometry and lighter in weight than both brushed type DC and induction AC motors.
-
Long life as no inspection and maintenance is required for commutator system
-
Higher dynamic response due to low inertia and carrying windings in the stator
-
Less electromagnetic interference
-
Low noise due to absence of brushes
Limitations of Brushless DC motor
-
These motors are costly
-
Electronic controller required control this motor is expensive
-
Requires complex drive circuitry
-
Need of additional sensors
Applications of Brushless DC motor
Brushless DC motors (BLDC) use for a wide variety of application requirements such as varying loads, constant loads and positioning applications in the fields of industrial control, automotive, aviation, automation systems, health care equipments etc.
-
Computer hard drives and DVD/CD players
-
Electric vehicles, hybrid vehicles, and electric bicycles
-
Industrial robots, CNC machine tools, and simple belt driven systems
-
Washing machines, compressors and dryers
-
Fans, pumps and blowers.