Week-7 Challenge: DC Motor Control
Tasks:
- Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that the armature current doesn’t shoot up when the motor changes direction from forward to reverse.
- Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
- Make a suitable EV model using the DC7 block and make a result report.
- Explain in a brief the operation of the BLDC motor.
Tasks 1
Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that the armature current doesn’t shoot up when the motor changes direction from forward to reverse.
Diode

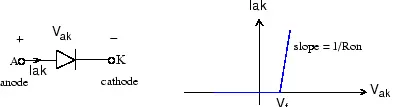
The diode is a semiconductor device that is controlled by its own voltage Vak and current Iak. When a diode is forward biased (Vak > 0), it starts to conduct with a small forward voltage Vf across it. It turns off when the current flow into the device becomes 0. When the diode is reverse biased (Vak < 0), it stays in the off state.
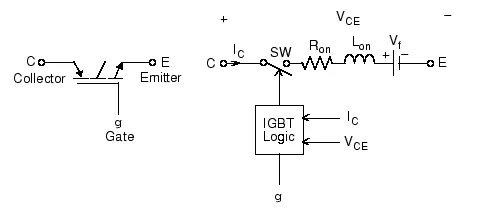
IGBT block

The IGBT block implements a semiconductor device controllable by the gate signal. The IGBT is simulated as a series combination of a resistor Ron, inductor Lon, and a DC voltage source Vf in series with a switch controlled by a logical signal (g > 0 or g = 0).
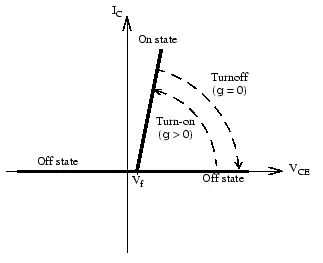
The IGBT turns on when the collector-emitter voltage is positive and greater than Vf and a positive signal is applied at the gate input (g > 0). It turns off when the collector-emitter voltage is positive and a 0 signal is applied at the gate input (g = 0).
The IGBT device is in the off state when the collector-emitter voltage is negative. Note that many commercial IGBTs do not have the reverse blocking capability. Therefore, they are usually used with an antiparallel diode.
The IGBT block contains a series Rs-Cs snubber circuit, which is connected in parallel with the IGBT device (between terminals C and E).
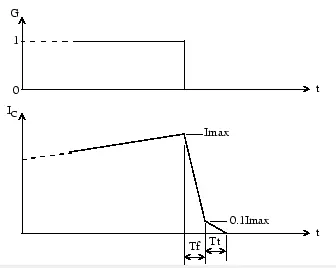
The turnoff characteristic of the IGBT model is approximated by two segments. When the gate signal falls to 0, the collector current decreases from Imax to 0.1 Imax during the fall time (Tf), and then from 0.1 Imax to 0 during the tail time (Tt).
Speed control of a DC motor using BJT H-bridge
Description
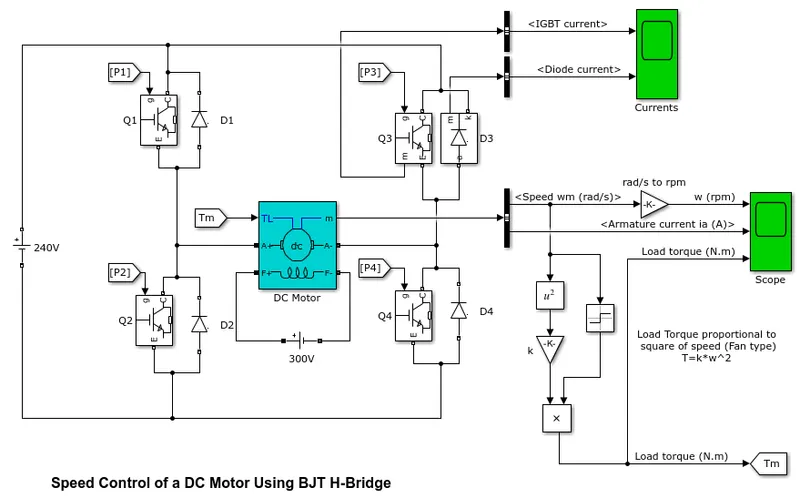
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
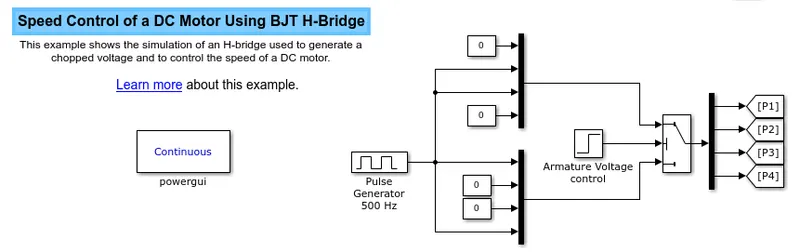
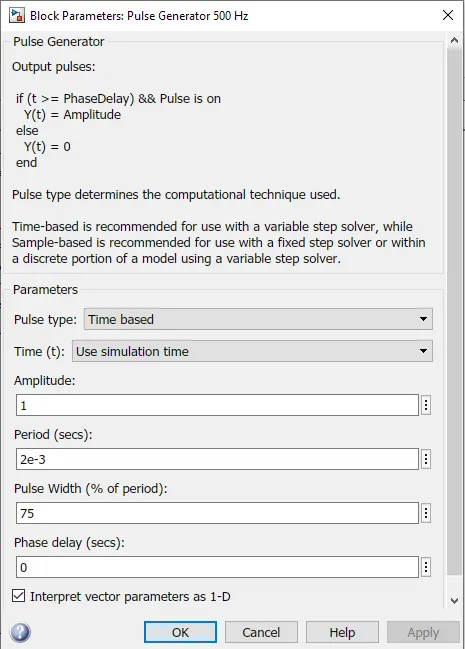
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to the square of speed). The armature means voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Simulation
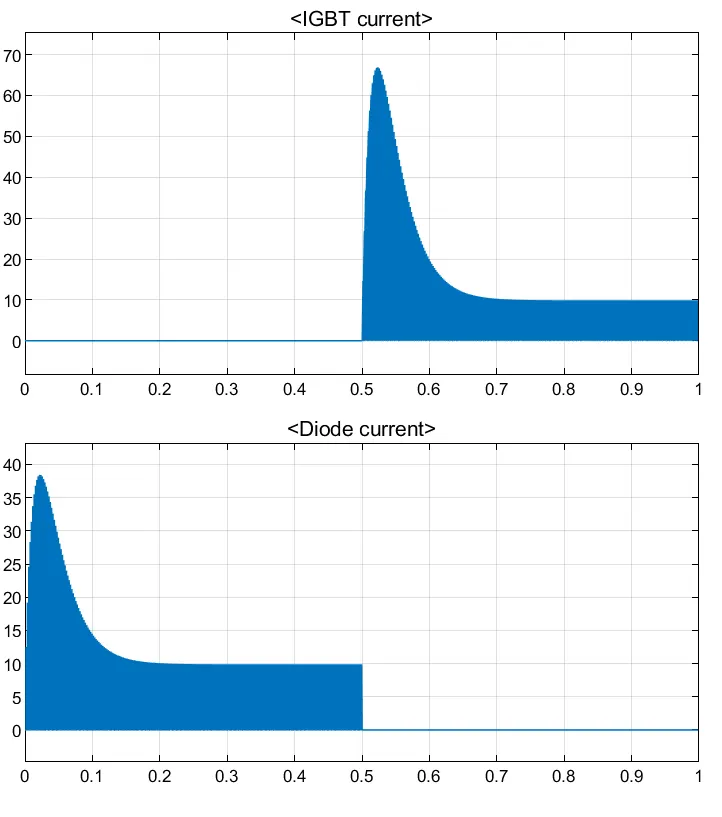
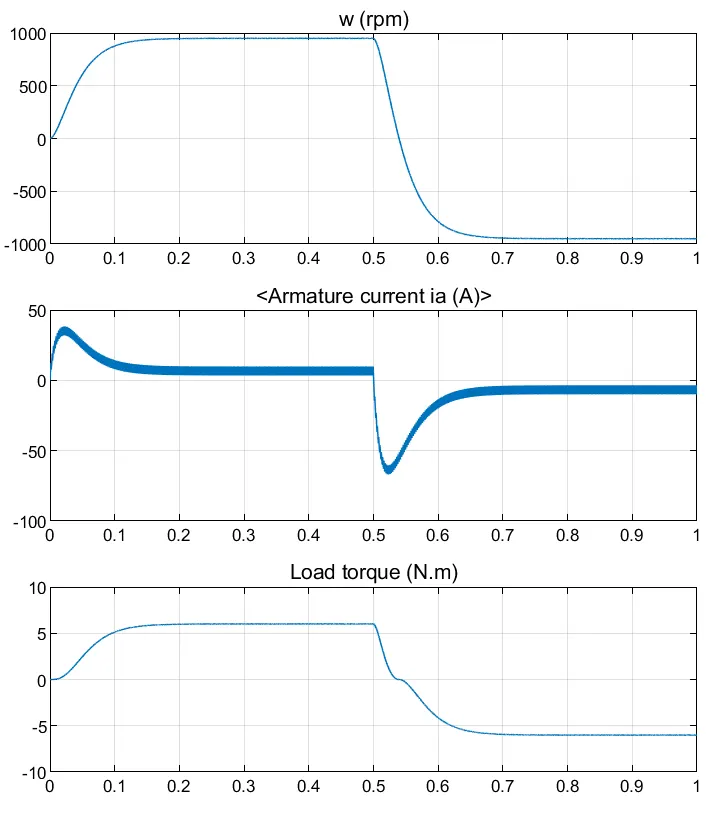
The motor starts in a positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
'Currents' shows currents flowing in BJT Q3 and diode D3.
'Scope' shows motor speed, armature current and load torque
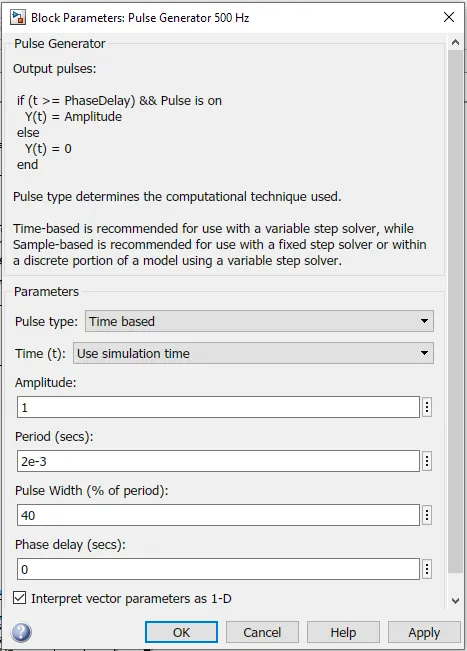
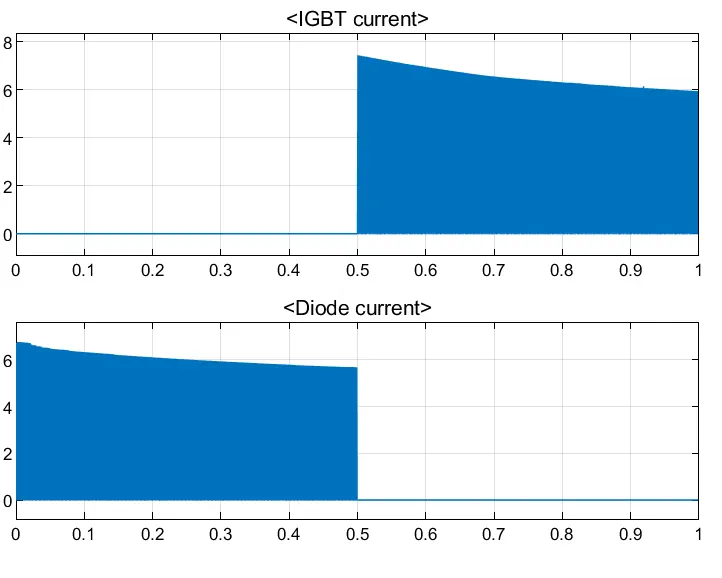
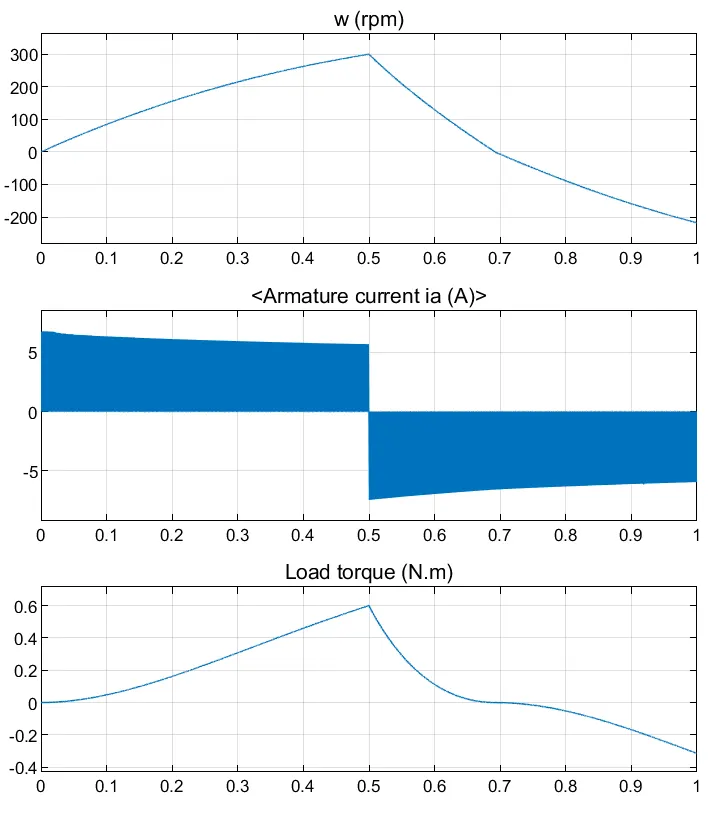
Here, The motor starts in a positive direction with a duty cycle of 40% (mean DC voltage of 96V). At t= 0.5 sec., the armature voltage is suddenly reversed to -7V and the motor runs in the negative direction.
Output
'Currents' shows currents flowing in BJT Q3 and diode D3.
'Scope' shows motor speed, armature current and load torque
Task 2
Compare Four-Quadrant Chopper DC Drive with the H-bridge model.
DC7 four-quadrant chopper DC drive
Description
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
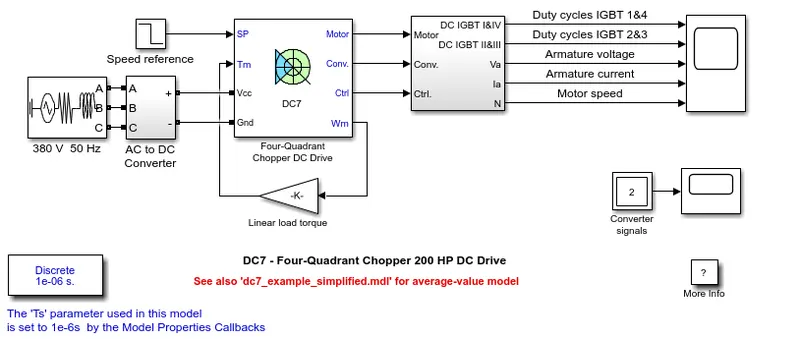
Simulation
Before starting the simulation, set the initial bus voltage to 515 V via the GUI block ('The Initial States Setting' button and 'Cbus' variable).
Start the simulation. You can observe the motor armature voltage and current, the four IGBT pulses and the motor speed on the scope. The current and speed references are also shown.
The motor is coupled to a linear load, which means that the mechanical torque of the load is proportional to the speed.
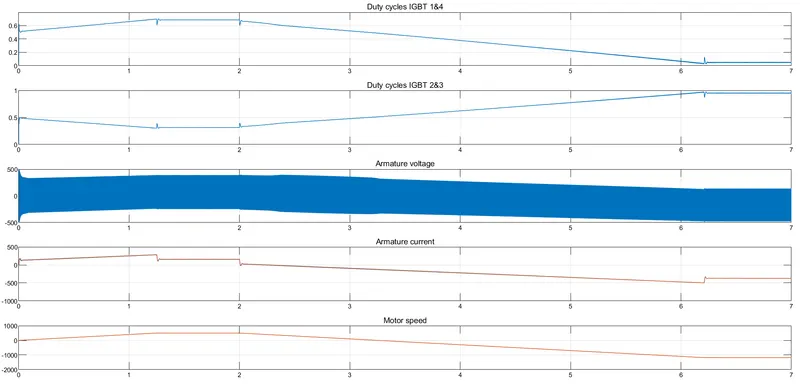
The speed reference is set at 500 rpm at t = 0 s. Observe that the motor speed follows the reference ramp accurately (+400 rpm/s) and reaches steady-state around t = 1.3 s.
The armature current follows the current reference very well, with fast response time and small ripples. Notice that the current ripple frequency is 5 kHz.
At t = 2 s, speed reference drops to -1184 rpm. The current reference decreases to reduce the electromagnetic torque and causes the motor to decelerate with the help of the load torque.
At t = 2.2 s, the current reverses in order to produce a braking electromagnetic torque (dynamic braking mode). This causes the DC bus voltage to increase.
At t = 3.25 s, the motor reaches 0 rpm and the load torque reverses and becomes negative. The negative current now produces an accelerating electromagnetic torque to allow the motor to follow the negative speed ramp (-400 rpm/s). At t = 6.3 s, the speed reaches -1184 rpm and stabilizes around its reference.
Scope Result :
four-quadrant chopper
- It converts electrical energy to mechanical energy which supports its motion. In braking, it works
as a generator converting mechanical energy to electrical energy and opposes the motion. - The motor can be providing motoring and braking operating for both forward and reverse direction.
- The torque and speed coordinates for both forward and reverse motions are shown in fig
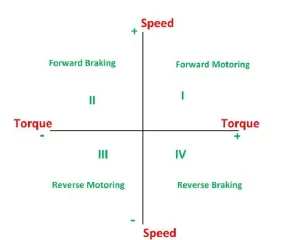
- Power developed by a motor is given by the product of speed and torque.
- In quadrant 1st developed power is the +ve and called forward motoring mode.
- In quadrant 2nd developed power is -ve hence machine works under braking opposing the motion
and this is knowns as forward braking mode. - Similarly, quadrant 3rd known as reverse motoring and
- quadrant 4th known as reverse braking
Comparison of Four-Quadrant chopper DC7 block and H-bridge model :
- Four-Quadrant Chopper can operate in all four modes (Forward Motoring, Forward Braking, Reverse Motoring and Reverse Braking), but H-bridge can function only in two modes (Forward and Reverse).
- In Four-Quadrant Chopper Regenerative Braking is possible, but H-bridge Regenerative Braking is not possible.
- In Four-Quadrant Chopper Two PI regulator (Speed Regulator and Current Regulator) is used to receive electromagnetic torque needed to reach the wanted speed and control the armature current and stabilize the system, but in the H-bridge model PI regulator is not used.
- H-bridge is an electronic circuit that switches the polarity of the voltage applied to the load and a Four-quadrant Chopper is an electronic switch that is used to interpret one signal under the control of another.
- H-bridge circuit is often used in Robotics and other applications to allow the DC motor to run forward and backwards. Four-Quadrant Chopper circuit is used to refer to various type of electronic switching devices and circuits used in power control and signal applications.
- The four-Quadrant Chopper model gives better performance and high energy(power) storage than the H-bridge model.
Task 3
Make a suitable EV model using the DC7 block and make a result report.
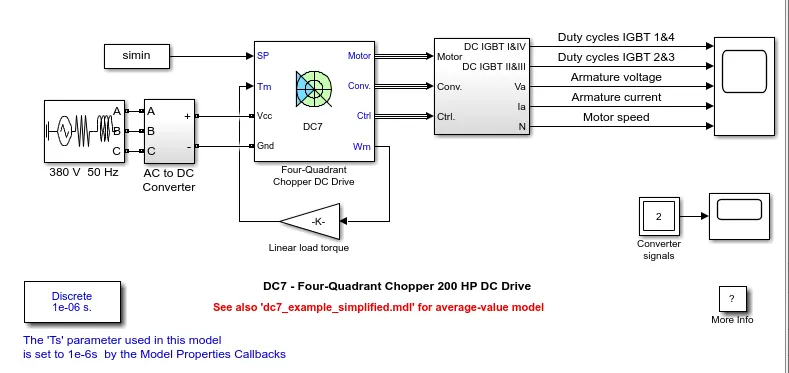
The above Fig shows the EV model using the Four-Quadrant Chopper DC drive DC7 block.
Four Quadrant Chopper DC drive DC7 block which is already discussed in Study-2.
For making a Suitable EV model using Four-Quadrant Chopper DC drive DC7 block following steps are to be followed.
Drive Cycle Source :
Speed reference block is replaced with Drive Cycle Source.
Drive Cycle data is prepared in an excel sheet and imported into the workspace in the name of simin.
Drive Cycle data includes Time and Speed is input to Drive Cycle source.
Results :
Drive Cycle Imported data in Drive Cycle Source :
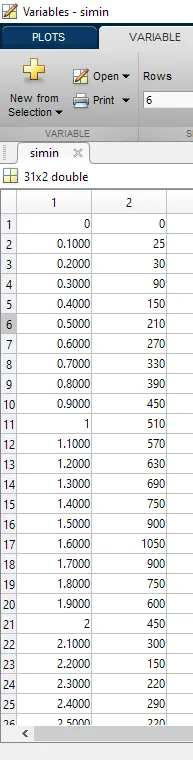
Drive Cycle imported data has shown above. It involves Time (Sec) and Speed (RPM), Motor Speed requirement is in RPM.
Plot Result :
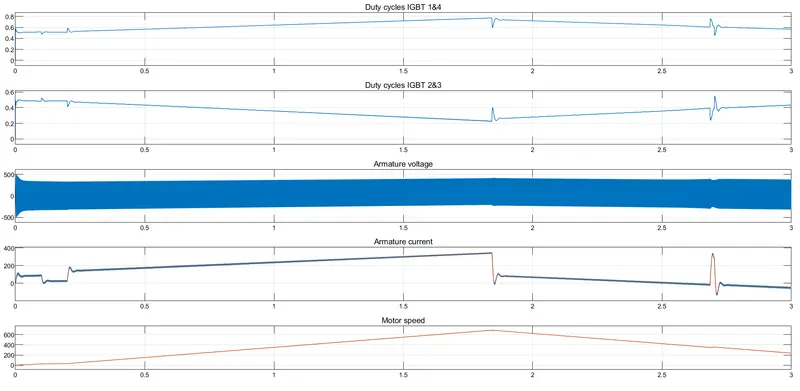
- From plot-1, observed that when the motor Speed rises, the IGBT 1&4 duty cycle also raises.
- From plot-2, IGBT 2&3 is a mirror image of IGBT 1&4. when the motor Speed rises, IGBT 2&3 of the duty cycle reduces.
- In Plot-3, According to the motor speed Voltage level will be supplied from the DC Voltage Source. Whenever Speed develops more voltage will be needed.
- In Plot-4, Observed that Voltage is proportional to Current. when Voltage increases Current increases and the current in positive when the voltage decreases current also decreases and the current goes in negative.
- In Plot-5, Motor Speed has shown, which was input reference speed is given in Drive Cycle Source. Motor Speed rises and reached a maximum speed of 688rpm in (2sec) and decreases to 0rpm in 3sec as per the given input reference speed.
Task 4
As their name implies, brushless DC motors do not use brushes.
With brushed motors, the brushes deliver current through the commutator into the coils on the rotor.
So how does a brushless motor pass current to the rotor coils?
It doesn’t—because the coils are not located on the rotor. Instead, the rotor is a permanent magnet.
the coils do not rotate but are instead fixed in place on the stator. Because the coils do not move,
there is no need for brushes and a commutator. (See Figure)
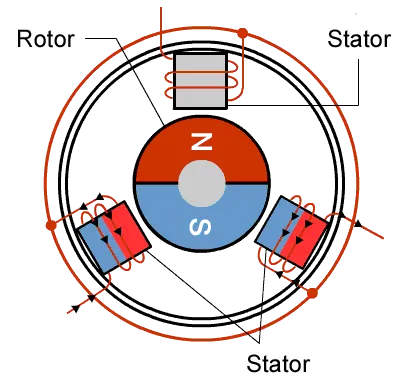
Figure: A BLDC Motor
With the brushed motor, rotation is achieved by controlling the magnetic fields generated by the coils on the rotor, while the magnetic field generated by the stationary magnets endures fixed.
To change the rotation speed, you change the voltage for the coils. With a BLDC motor, it is the permanent magnet that rotates.
rotation is achieved by changing the direction of the magnetic fields generated by the enclosing stationary coils.
To control the rotation, you change the magnitude and direction of the current into certain coils.