Week-4 Challenge WOT Condition Part-2
1. MAPPED models:
Mapped models are used when the behavior of a particular model is not of our interest and can be modeled with predefined values in the form of lookup tables.
eg: mapped motor:
in the below model values are taken from experiments or old data
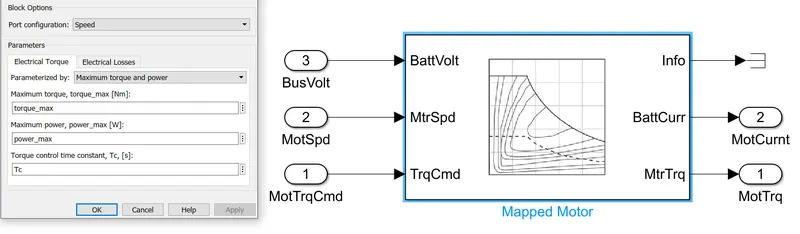
Implements a mapped motor and drive electronics operating in torque control mode. we have to specify electrical torque range with a torque-speed envelope or maximum motor power and torque. Output torque tracks a torque reference demand and includes a motor and drive response time constant. Also have to Specify electrical losses as a single operating point that estimates loss across the operating range, measured loss, or measured efficiency.
DYNAMIC model:
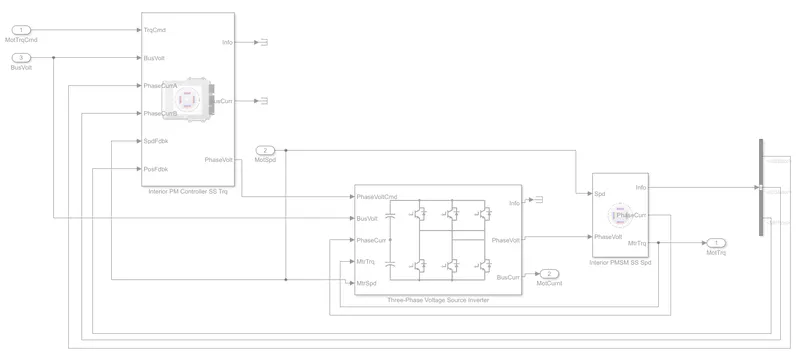
Dynamic models are used when the internal response to a model with respect to its components is needed.
eg. motor model:
in the below model, motor components such as inverter, phase controller, feedback circuits are also modeled.
CHANGING the model type in EV powertrain blocks:
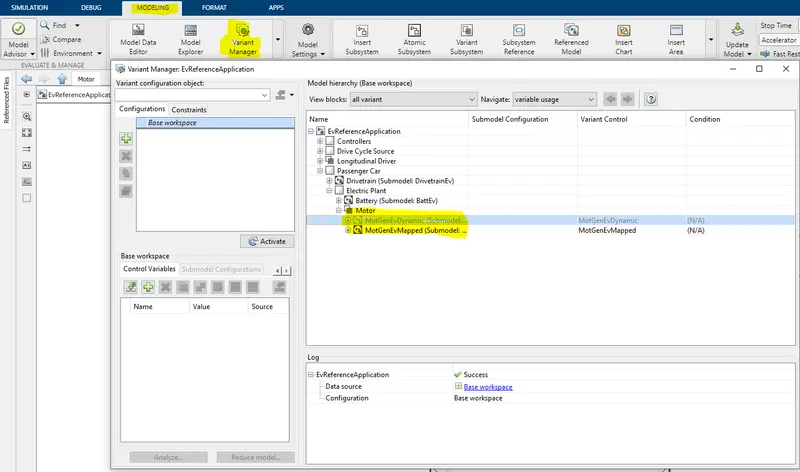
we can use the variant manager in the modeling tab to find the variant systems we have.
right-click on the model you want and use set as Label mode active choice.