Week-4 Challenge WOT Condition Part-2
1)What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Answer:-
1)Mapped and Dynamic model of engine, motor and generator
* Mapped Model
- The mapped model is one type wherever the information features are pre_assigned in lookup tables.
- The engine or motor torque needed is sensed and the motor or engine block generates the needed torque producing just as needed easily without analyzing the real-time motor or engine, parameters
- The output values are collected to the corresponding delivered input values of the engine motor and generator
- The accuracy of this type is not that high but the simulation will be done in much less time as it does not run by real-time parameters.
* Dynamic Model
- The dynamic model on the other hand uses the combination of the outputs from various subsystems to generate the output.
- It runs by real-time simulation where the required input from the drive cycle is taken and for that Individual real-time simulation gets performed and summing all the results of the subsystem gives the output for the simulation.
- As per the drive cycle requirements, the initial Bus voltage and the current are given along with the vehicle feedback so that it runs the actual simulation at that particular moment throughout the drive cycle.
- The accuracy of this model is very high as it considers the real outputs from all the subsystems to generate the output.
- The simulation will take a very long time to complete as it has so many individual simulations running by all the subsystems of the engine, motor/generator.
- The figure below shows the working phase of the dynamic model.
* Changing the model type
-
Open the Explore the Hybrid Electric Vehicle Multimode Reference Application in that click the Simulink model name as autoblkHevStart of the as shown in given below figure
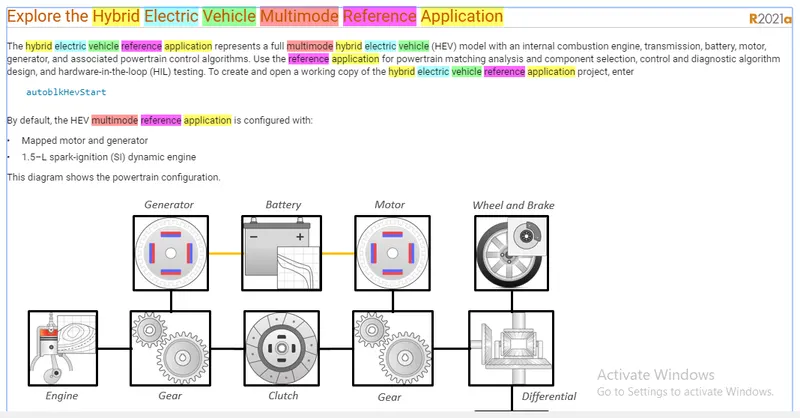
Fig 1: Hybrid Electric Vehicle Multimode Reference Application
-
Then we have to select the HEV_Mm_Reference_Application Simulink block set now we have to select the Passenger Car block is given below figure.
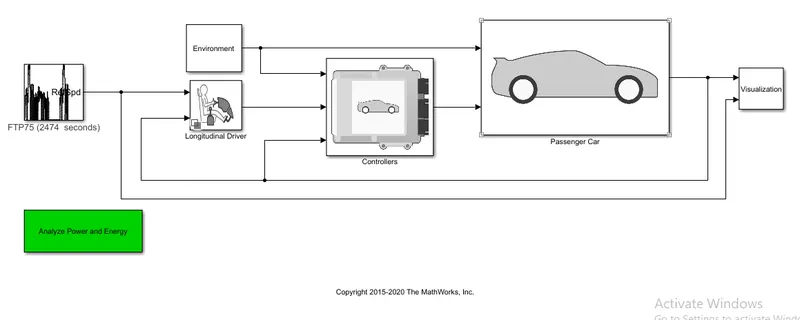
- Then after opening Passenger Car we can see many block sets but we have to select the electric plant block.
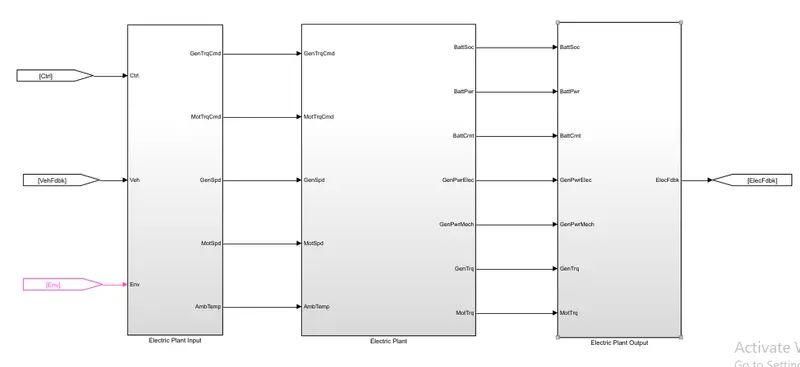
Fig 2: Electric plant block
- After opening the Electric plant, right-click on Generator, then select the variant, open Label Mode Active Choice then select GenDynamic, so that we can change the model type.
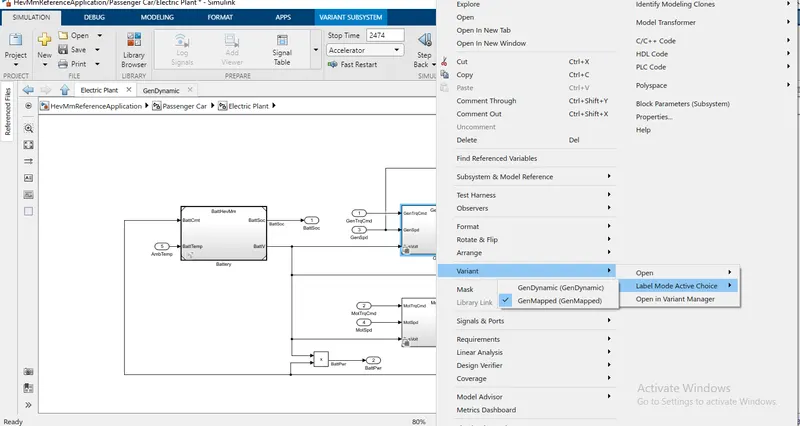
Fig 3: changing the model type
- Thus we can change the model type for motors, generators, and engines.
2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Answer:-
* Miles per gallon
- Miles per Gallon is a fuel economy rating determined by how far a car can travel on a gallon of petrol or Diesel for an Engine powered car.
- In the case of an electric vehicle, it recognizes the energy which is equivalent to that of an engine-powered car to propel the car through a distance.
- The amount of Fuel Energy required to move an engine-powered car through a distance is determined and then it is compared to the equivalent amount of electric energy required to move the car through the same distance and is expressed as the miles per gallon.
- The powertrain block set has a model that calculates the miles per gallon for all kinds of vehicles.
* Model Calculation of Miles per gallon
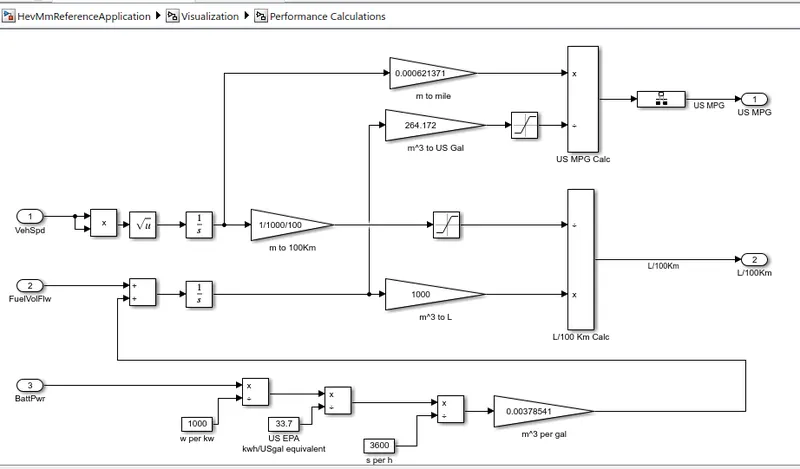
Fig 3: Calculation of Miles per gallon
- Conversion from Cubic Meter to Gallon (m^3 to a gallon), As we know 264.172 US Gallons is 1000L
- The reference model taken here for consideration is HEV and as it operates on both the Battery and the Fuel Injection Engine.
- The final output/Fuel Efficiency is calculated by keeping into consideration of the Battery Output. Fuel Output and the Vehicle Speed/Kilometres are Driven. Therefore the fuel efficiency is calculated and it is converted after the saturation thus the FE is calculated
* Factors considered to model fuel flow
Vehicle Speed and Fuel Flow
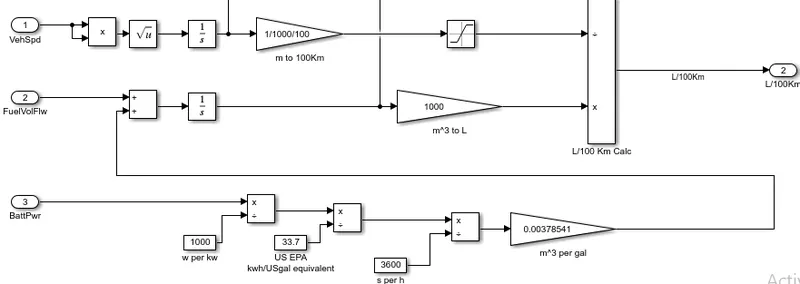
Fig 4: Factors considered to model fuel flow
- The Vehicle speed is an important factor when considering the fuel consumption at that particular time. so to determine the fuel consumption throughout the drive cycle.
- To convert speed to Distance, we can Integrate with time and we are doing the same for converting the velocity to get the distance covered by integrating.
- Then the Fuel flow is expressed as the mass flow rate (i.e) the amount of fuel at each moment in Kg/Sec.
- Now integrating this will result in the mass of the fuel and by using this one we convert it to the volume and multiply by 1000 to get it In Litres.
- By comparing the two results we can get the amount of liter consumed to Run for 100km.
Battery Power
- The amount of energy from battery power required to propel the vehicle Equivalent to that of the Engine is calculated here.
- The battery power is given in watts and it is converted to Kw by dividing by 1000.
- Then we convert the power into energy by multiplying with the time into KWh.
- Then we convert the Energy from kWh to equivalent energy in US gallons of automotive gasoline by dividing by 33.7.
- Since we get the energy in US Gallons equal to KWh we are trying to get the energy of equivalent LIS Gallons per second and we do this by dividing by 3600 and we convert the hour to seconds.
- Then multiplying with 0.00378541 we convert the US Gallons per sec to the volume of the fuel flow in (mA3/s) and then we multiply with 739 (California Phase Il Gasoline density) (l.e) mA3/s. kg/mA3 which gives the result as mass flow rate kg's.
- Then finally the Battery energy equivalent in kg/s is given as an input for the fuel flow parameter to find the equivalent US Gallons of energy and estimate the Miles per Gallon.
3)Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
#Hybrid Electric Vehicle
- A hybrid electric vehicle (HEV) is a type of hybrid type that combines a conventional Internal combustion engine (ICE) system with an electric propulsion system
- The presence of the electric powertrain is intended to achieve either better fuel economy than a conventional vehicle or beer performance. An example of HEV Is Toyota Prius.
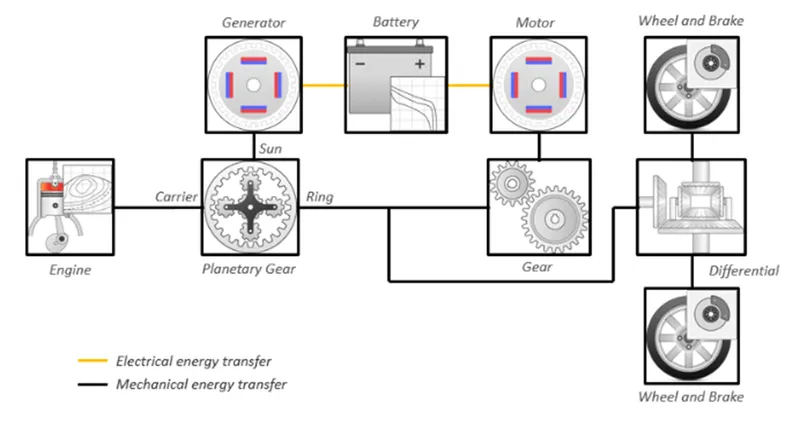
Fig 4: Hybrid Electric Vehicle
- In the powertrain blocks we have selected the hybrid electric vehicle and the Simulink model is given below.
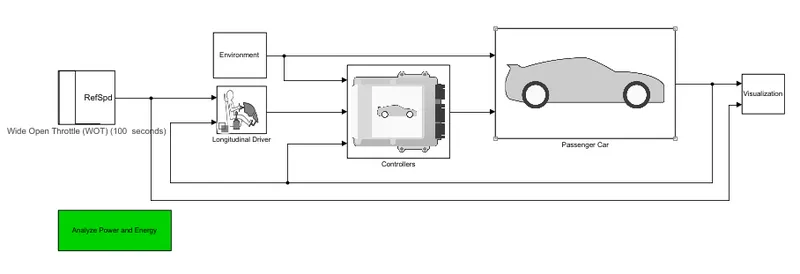
Fig 5: Hybrid Electric Vehicle Model
- Drive Cycle Source Block: Generates a standard drive cycle velocity versus time profile.
- Environmental Subsystem: Creates environmental variables, including road grade, wind velocity and atmospheric temperature and pressure.
- Longitudinal Driver Subsystem: Uses the longitudinal driver or open-loop variant to generate normalized acceleration and braking commands.
- Controller Subsystem: Implements a powertrain control module(PCM) containing an input power-split hybrid control module(HCM) and an engine control module(ECM).
- Passenger Car Subsystem: Implements a hybrid passenger car that contains a drivetrain, electric plant and engine subsystem.
- Visualization Subsystem: Displays vehicle level performance, battery state of charge, fuel economy and emission results.
* WOT Drive Cycle
Wide-open throttle (WOT) can be explained as maximum air and fuel intake that occurs when the throttle plates inside the carburetor or throttle body are wide open, providing the least resistance to the incoming air. In the case of an automobile, WOT is when the accelerator is depressed fully, sometimes referred to as "flooring it."
In the case of a diesel engine, which does not have a throttle valve. WOT is the point at which the maximum amount of fuel is being injected relative to the amount of air pumped by the engine, generally to bring the fuel-air mixture up to the stoichiometric point. At wide-open throttle, manifold vacuum decreases. The higher manifold pressure, in turn, allows more air to enter the combustion cylinders, and thus additional fuel is required to balance the combustion reaction. The additional air and fuel reacting together produce more power
In an Electric vehicle, WOT condition refers to the initial acceleration or time taken by the vehicle to reach maximum velocity. The maximum velocity in WOT conditions can be obtained by the electric motor characteristics of an electric vehicle.
* Case 1 : Without Grade and wind velocity
- The simulation is done for a Hybrid electric vehicle with a Wide Open Throttle Drive cycle.
The Total cycle time=100 seconds
The Top speed of this cycle = 70 m/s=160 mph
Time to start deceleration =40seconds
The Grade angle =0 degrees
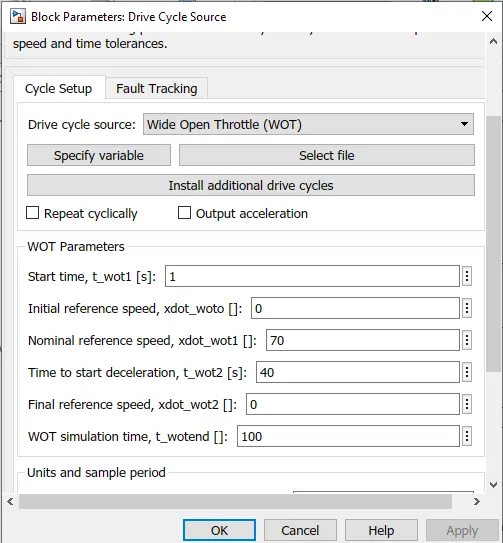
Fig 6: Drive Cycle block
- Environmental Conditions, without Grade and wind velocity
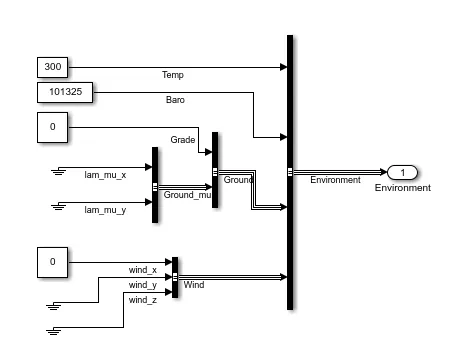
Fig 7: Environmental Conditions
* Simulation results
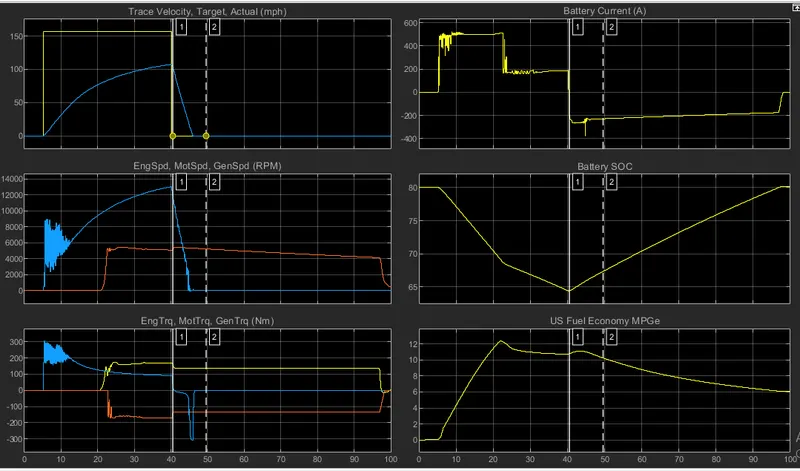
Fig 8: Simulation results
- Plot 1:
Shows the velocity of the vehicle concerning the Drive cycle data with the Time scale on the axis.
The acceleration time to reach a top speed of 110 mph is 40 seconds.
The deceleration from 110 mph to a minimum in 4.06 seconds.
- Plot 2:
Shows the changes in the speed of the engine, motor and Generator in aim throughout the drive cycle
Peak Motor speed=81005 Rpm
Peak Generator speed= 12758.5 Rpm
Peak Engine speed= 5555 Rpm
- Plot 3:
Shows the Torque characteristics and its changes of engine motor and generator in (Nm) throughout the drive cycle
Peak Engine Torque=140.6 Nm
Peak Motor torque=180.4 Nm
Peak Generator torque=300 Nm
- Plot 4:
Shows the Battery Current values (A) and their changes for various per the Drive cycle.
Peak current drawn from the battery to achieve WOT=500A
Peak current drawn after attaining maximum speed=-230.46 A
- Plot 5:
Shows the battery state of charge SOC (%) and its changes corresponding to the driving inputs
The state of charge decreased from 80% to 65.98 % of charge in a time period of 40.3 seconds, for the specified driving conditions
- Plot 6:
Shows the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel equivalent to 12.33 Miles, the given vehicle at the specified driving conditions
* Case 2: With Grade and wind velocity
-
The simulation is done for a Hybrid electric vehicle with a Wide Open Throttle Drive cycle.
The Total cycle time=100 seconds
The Top speed of this cycle = 70 m/s=160 mph
Time to start deceleration =40seconds
The Grade Angle =6 degrees
The Wind Velocity=8 m/s
- Environmental Conditions, with Grade and wind velocity
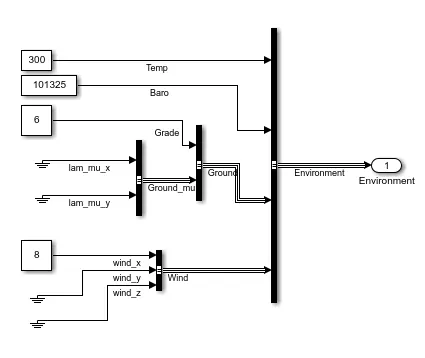
Fig 9: Environmental Conditions
* Simulation results
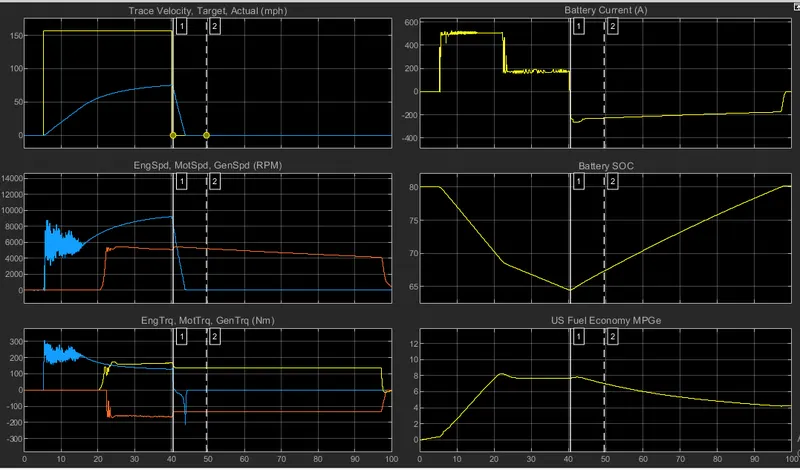
Fig 10: Simulation results with grade and wind velocity
- Plot 1:
Shows the velocity of the vehicle concerning the Drive cycle data with the Time scale on the axis
The top speed of 160 mph cannot be achieved as we have some additional forces acting and so the car can only run up to 80 mph
The acceleration time s reach a top speed of 80 mph=40 seconds
The deceleration the from 80 to a minimum of 4.06 seconds
- Plot 2:
Shows the changes in the speed of the engine, motor and Generator in aim throughout the drive cycle
Peak Motor speed=91005 Rpm
Peak Generator speed 12758.5 Rpm
Peak Engine speed= 5555 Rpm
- Plot 3:
Shows the Torque characteristics and its changes of engine motor and generator in (Nm) throughout the drive cycle
Peak Engine Torque=129.6 Nm
Peak Motor torque=202.4 Nm
Peak Generator torque=300 NM
- Plot 4:
Shows the Battery Current values (A) and its changes for various per the Drive cycle.
Peak current drawn from the battery to achieve WOT=500A
Peak current drawn after attaining maximum speed=-230.46 A
- Plot 5:
Shows the battery state of charge SOC (%) and its changes corresponding to the driving inputs
The state of charge decreased from 80% to 65 % of charge in a time period of 40.3 seconds, for the specified driving conditions
- Plot 6:
Shaws the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel is equivalent to 8 Miles, the given vehicle at the specified driving conditions
* Observation:
- There exist a difference between the actual velocity curve and the input curve due to the limitation on maximum power available for propulsion /Energy sources.
- Limiting factors involves current or the battery modules.
- The maximum speed achieved in case 12 is lesser compared with case 1 because of the presence of grade angle and opposing wind force
- it is observed from the plot that with an increase in grade angle, WOT response time increases and velocity decreases.
- The battery SOC also decreases considerably with an increase in traction forces.
- Fuel Economy falls to a greater extent with an increase in the demanding traction power.
4)Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Answer:-
Pure Electric Vehicle
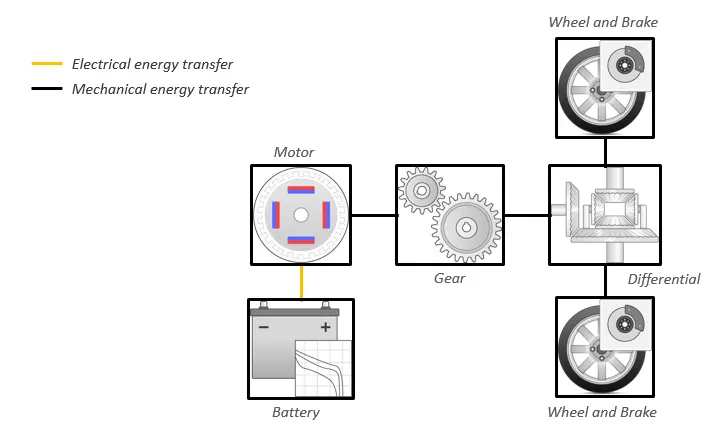
Fig 11: Pure Electric Vehicle
- A battery-electric vehicle or pure Electric vehicle is an EV that exclusively uses chemical energy stored in rechargeable battery packs with no secondary source of propulsion of energy
- BEVS uses electric motors and motor controllers instead of a conventional Internal combustion engine for propulsion. They derive all power from battery packs.
- So they don't produce any emission of waste gas and they are eco friendly
- They also have their own limitations such as range etc.
- Example of a Pure EV is Nissan Leaf.
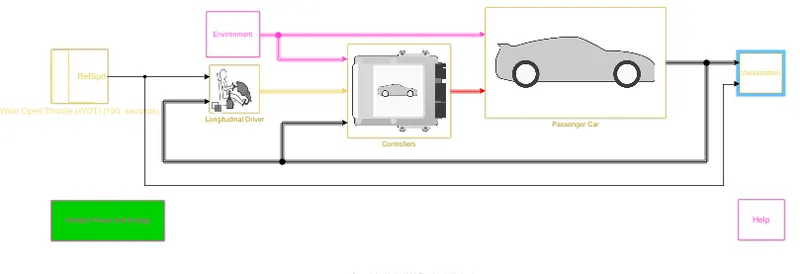
Fig 12: Pure Electric Vehicle model
* Case 1: Without Grade and wind velocity
-
The simulation is done for a pure electric vehicle with a Wide Open Throttle Drive cycle.
The Total cycle time=100 seconds
The Top speed of this cycle = 70 m/s=160mph
Time to start deceleration =40seconds
The Grade angle =0 degrees
The wind velocity=0 m/s
- Environmental Conditions, with no Grade and wind velocity
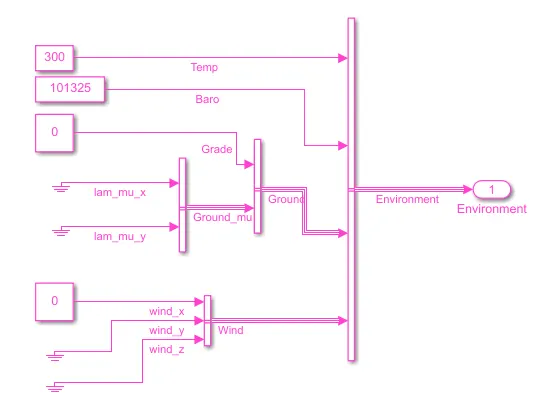
Fig 13: Environmental Conditions
* Simulation Results
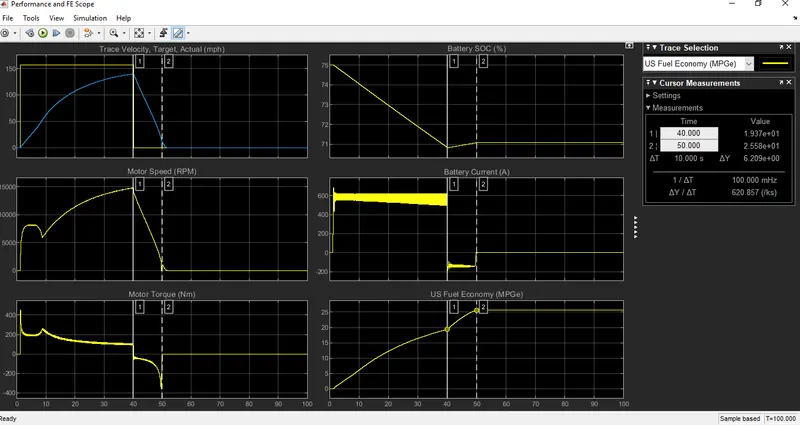 Fig 14: simulation results
- Plot 1:
Shows the velocity of the vehicle concerning the Drive cycle data with the Time scale on the axis.
The acceleration time to reach a top speed of 100 mph is 40 seconds.
The deceleration from 100 mph to a minimum in 4.06 seconds.
- Plot 2:
Shows the changes in the speed of the Motor in Rpm throughout the drive cycle.
Peak Motor speed=1123 pm
- Plot 3:
Shows the Torque characteristics cycle,
Peak Motor torque=260 Nm
- Plot 4:
Shows the battery state of charge SOC (%) and its changes corresponding to the driving inputs
The state of charge decreased from 80% to 76% of charge in a time period of 40.3 seconds, for the specified driving conditions
- Plot 5:
Shows the Battery Current values (A) and their changes for various per the Drive cycle.
Peak current drawn from the battery to achieve WOT=210
Peak current drawn after attaining maximum speed=-150 A
- Plot 6:
Shows the Equivalent Fuel Economy and Mile per Gallons for the corresponding input driving conditions. Here there is no fuel in the pure electric vehicle however this gues equivalent battery energy required that of the fuel energy and calculates the fuel efficiency The maximum miles that the car can run per gallon of fuel is equivalent 40 Miles for the given vehicle at the specified driving conditions
* Case 2: With Grade and wind velocity
-
The simulation is done for a Hybrid electric vehicle with a Wide Open Throttle Drive cycle.
The Total cycle time=100 seconds
The Top speed of this cycle = 70 m/s=160 mph
Time to start deceleration =40seconds
The Grade Angle =6 degrees
The Wind Velocity=8 m/s
- Environmental Conditions, with Grade and wind velocity
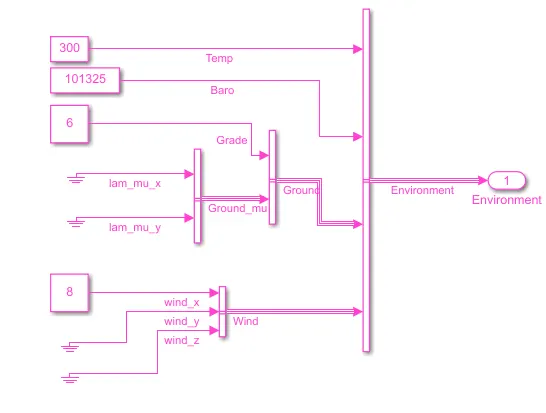
Fig 15: Environmental Conditions
* Simulation results
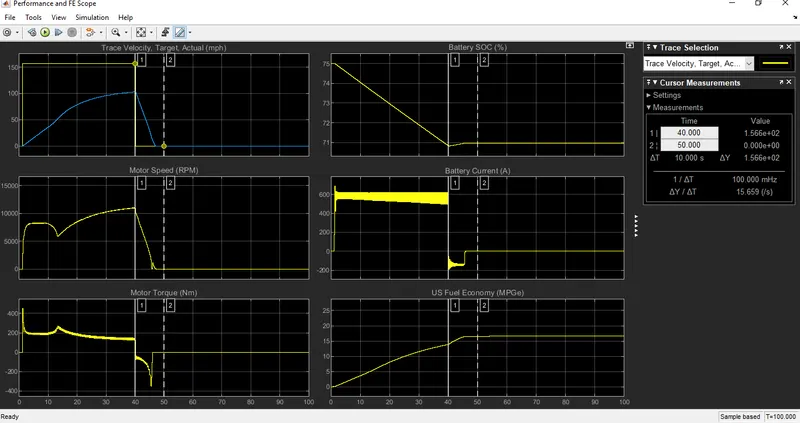
Fig 16: Simulation results with grade and wind velocity
- Plot 1:
Shows the velocity of the vehicle concerning the Drive cycle data with the Time scale on the axis
The top speed of 160 mph cannot be achieved as we have some additional forces acting and so the car can only run up to 70 mph
The acceleration time s reach a top speed of 70 mph=40 seconds
The deceleration the from 70 to a minimum of 4.06 seconds
- Plot 2:
Shows the changes in the speed of the engine, motor and Generator in aim throughout the drive cycle
Peak Motor speed=6254 Rpm
- Plot 3:
Shows the Torque characteristics and its changes of engine motor and generator throughout the drive cycle
Peak Motor torque=280.4 Nm
- Plot 4:
Shows the battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 80% to 76% of charge in a time period of 40.3 seconds, for the specified driving conditions
- Plot 5:
Shows the Battery Current values (A) and their changes for various per the Drive cycle.
Peak current drawn from the battery to achieve WOT=210
Peak current drawn after attaining maximum speed=-150 A
- Plot 6:
Shows the Equivalent Fuel Economy as Mile per Gallons for corresponding input driving conditions.
Here there is no fuel in the pure electric vehicles however this gives equivalent battery energy required to that of the fuel energy and calculates the Fuel efficiency.
The maximum miles that the car can run per gallon of fuel equivalent = 25.45 Miles, for the given vehicle at the specified driving conditions
* Observation(Pure Electric VS Hybrid Vehicle With Same Load Conditions)
- The electric vehicle when contrasted and a mixture of electric vehicles with the equivalent ecological and Drive cycle conditions brings about less maximum velocity accomplishment. The electric vehicle delivers more upsides of Motor speed and engine force contrasted with the half-breed vehicle's engine alone, however, in a crossover vehicle when it joins the force of both engine and its motor it is higher than the electric vehicle's force. This is capable to pull the Hybrid vehicle at a higher maximum velocity contrasted with the unadulterated electric
- As the unadulterated electric vehicle here utilizes a Lithium-particle battery contrasted with the Nickel-metal hydride battery the releasing limit and the pace of charging is higher in the unadulterated electric vehicle. As it can release at a quick rate the engine can deliver a high measure of force immediately contrasted with the mixture vehicle. Likewise, the condition of charge shows the battery productivity of the unadulterated electric to be higher than the mixture vehicle and this is additionally because of the battery type utilized in these vehicles/
- The effectiveness of the Electric vehicle is higher than the crossover vehicle which is apparent from the miles per gallon quantities of both of these vehicles.
- The electric vehicle produces zero outflows while the half-breed one produce squanders gas discharges. These are a portion of the perceptions from the examination of the above recreations utilizing Powertrain Blockset.