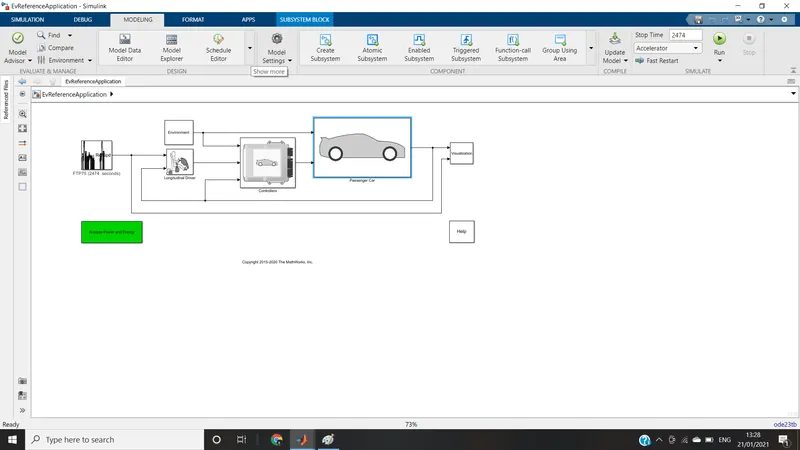
Week-4 Challenge WOT Condition Part-2
1)
Ans ;
Mapped models are used when the behavior of a particular model is not of our interest and can be modeled with predefined values in the form of lookup tables.
eg: mapped motor:
in the below model values are taken from experiments or old data
Implements a mapped motor and drive electronics operating in torque control mode. we have to specify electrical torque range with a torque-speed envelope or maximum motor power and torque. Output torque tracks a torque reference demand and includes a motor and drive response time constant. Also have to Specify electrical losses as a single operating point that estimates loss across the operating range, measured loss, or measured efficiency.
DYNAMIC model:
Dynamic models are used when the internal response to a model with respect to its components is needed.
eg. motor model:
in the below model, motor components such as inverter, phase controller, feedback circuits are also modeled.
- vehicle speed data is used to calculate the distance traveled in meters which is then converted to miles
- Battery power data is used to find power used in kWh which is then converted to gasoline-equivalent using US EPA value by dividing with 33.7
- note: As per the US environmental protection agency(EPA) 1 gallon of gasoline is equal to 33.7 kWh
- Dividing distance traveled in miles by the number of gallons, we can get miles per gallon.
- For HEV this gallon(gasoline-equivalent of battery power) is added with gallon used by IC engine then miles per gallon is calculated.
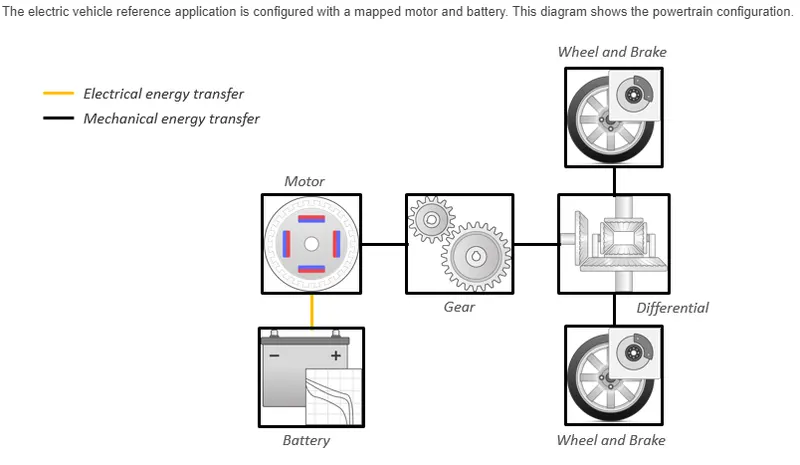
EV model powertrain configuration:
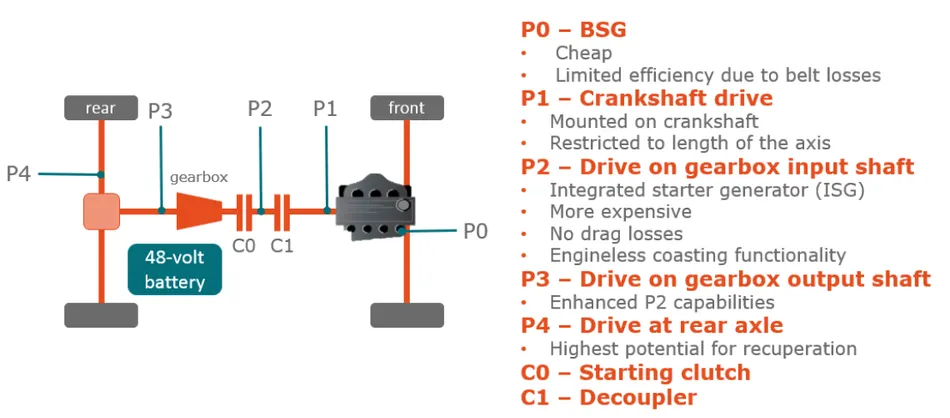
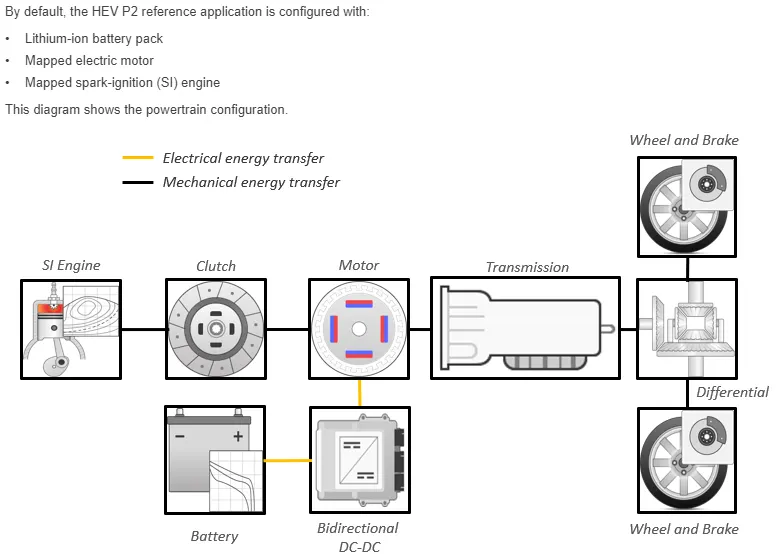
HEV p2 model:
HEV p2 model is chosen because the configuration is similar to our EV model
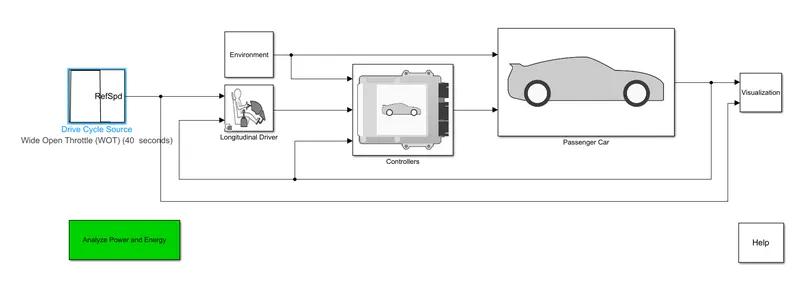
Simulink model:
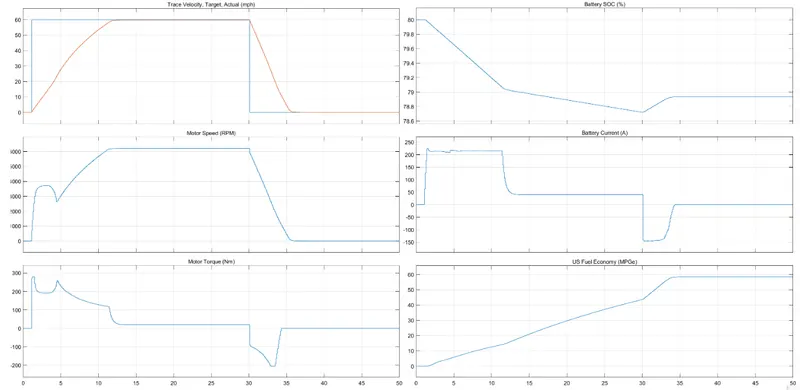
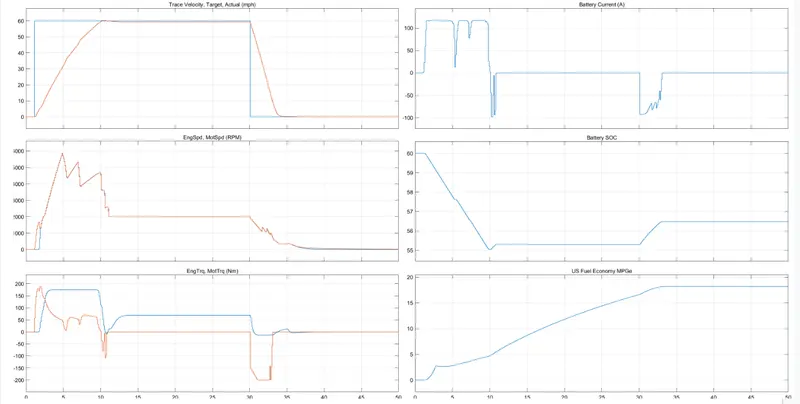
Results:
1.EV model
2.HEV P2 Model
 j
r Engine:-
|
Type |
Implementation |
When to Use |
|
|---|---|---|---|
|
Mapped |
|
Model uses a set of steady-state lookup tables to characterize engine performance. The tables provide overall engine characteristics, including actual torque, fuel flow rate, BSFC, and engine-out exhaust emissions. |
|
|
Dynamic |
|
Model decomposes the engine behavior into engine characteristics that are separated into lower-level components. By combining components in this way, the models capture the dynamic effects. |
|
For motor:-
| Type | Implementation |
| Mapped motor | The Mapped Motor block implements a mapped motor and drive electronics operating in torque control mode. The output torque tracks the torque reference demand and includes a motor-response and drive-response time constant. Use the block for fast system-level simulations when you do not know detailed motor parameters, for example, for motor power and torque tradeoff studies. The block assumes that the speed fluctuations due to mechanical load do not affect the motor torque tracking. |
| Dynamic motor | 1) The DC motor circuit diagram is represented. 2) The system equations are created. 3) The transfer function is calculated. 4) Then the model block diagram is prepared. 5) The is done to simulate the model in programming MATLAB. 6) And finally the performance analysis is carried out. |
for generator:-
| Type of modeling | implementation |
| Mapped Generator | This is also similar to mapped motor modeling where the input values for generator blocks are predefined or taken from the lookup tables here also simulation time is very less |
| Dynamic Generator | This model also represents an actual generator working in a real-time environment, where the output values calculated continuously according to change in input values as the equation is implementing .simulation time is more compared to the mapped generator |
-To changed model type from mapped to dynamic or dynamic to mapped
-After entering into passenger block > electric plant> motor will get this window where MotGenMapped is by default selected as a model type for motor
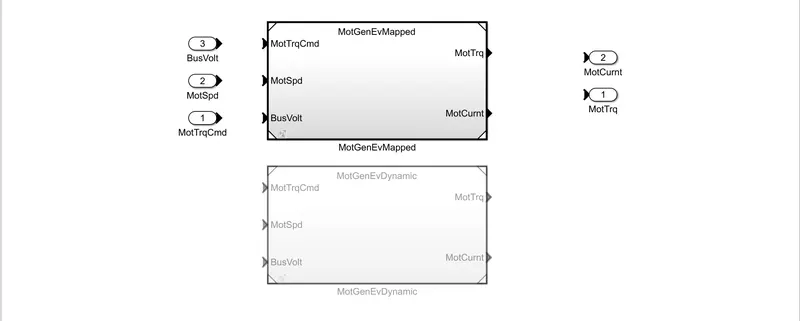
-To change from MotGenEvMapped to MotGenEVdynamic
-first, we open our reference model into Matlab
here we are choosing EV as an example