Week-4 Challenge WOT Condition Part-2
1) What is the
difference between mapped and dynamic model of engine, motor and
generator? How can you change model type?
Mapped model Engine:-
It is static model which is use to show the results on the basic of data which is input by calculated values.
Power train block set provides two types of combustion engine models, mapped and dynamic.
A mapped system refer to one where the performance characteristics of either engine , Generator or Motor are plotted in the model using the mapped data given in the lookup table
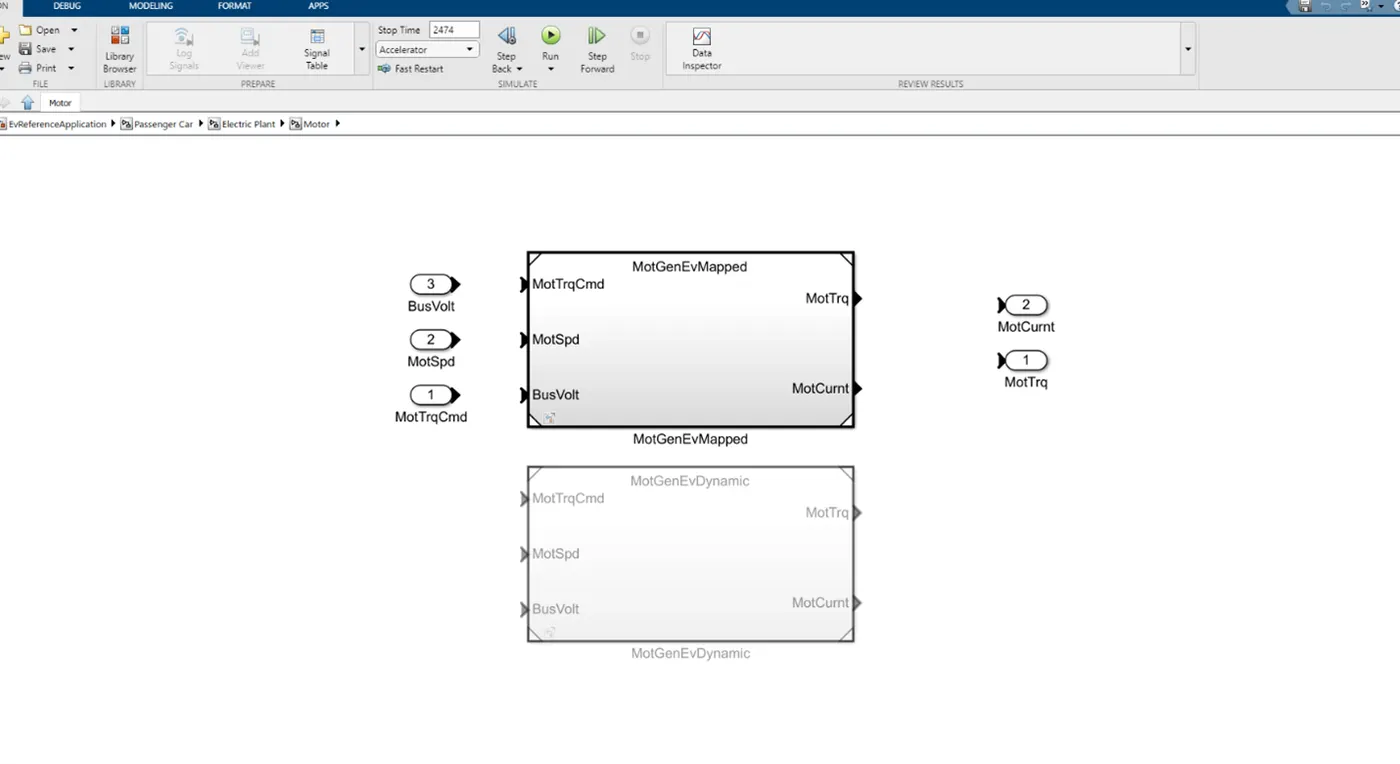
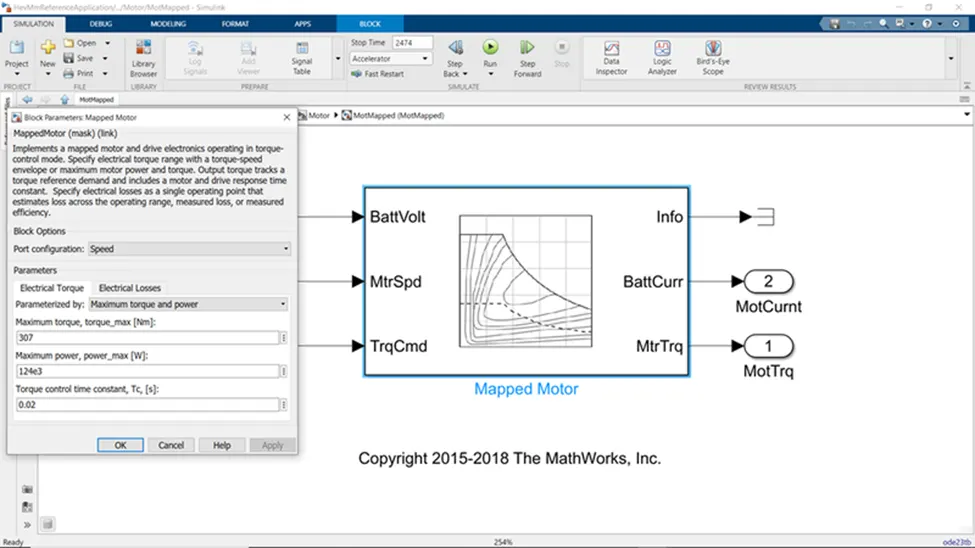
1.Mapped engines represent macro engine behaviour as a set of lookup tables(brake torque,fuel flow,air masflow,exhaust temperature, efficiency and emissions) as functions of commanded load and measured engine speed.
2.Mapped engine models are suitable for analysis and design activities that do not require enigne subsystem dynamic characteristics, for example in engine and transmission powertrain matching analysis for fuel economy,emissions and performance trade-offs.
Dynamic model Engine:
It is the model which is shows result on the basic of actual reading taken in system
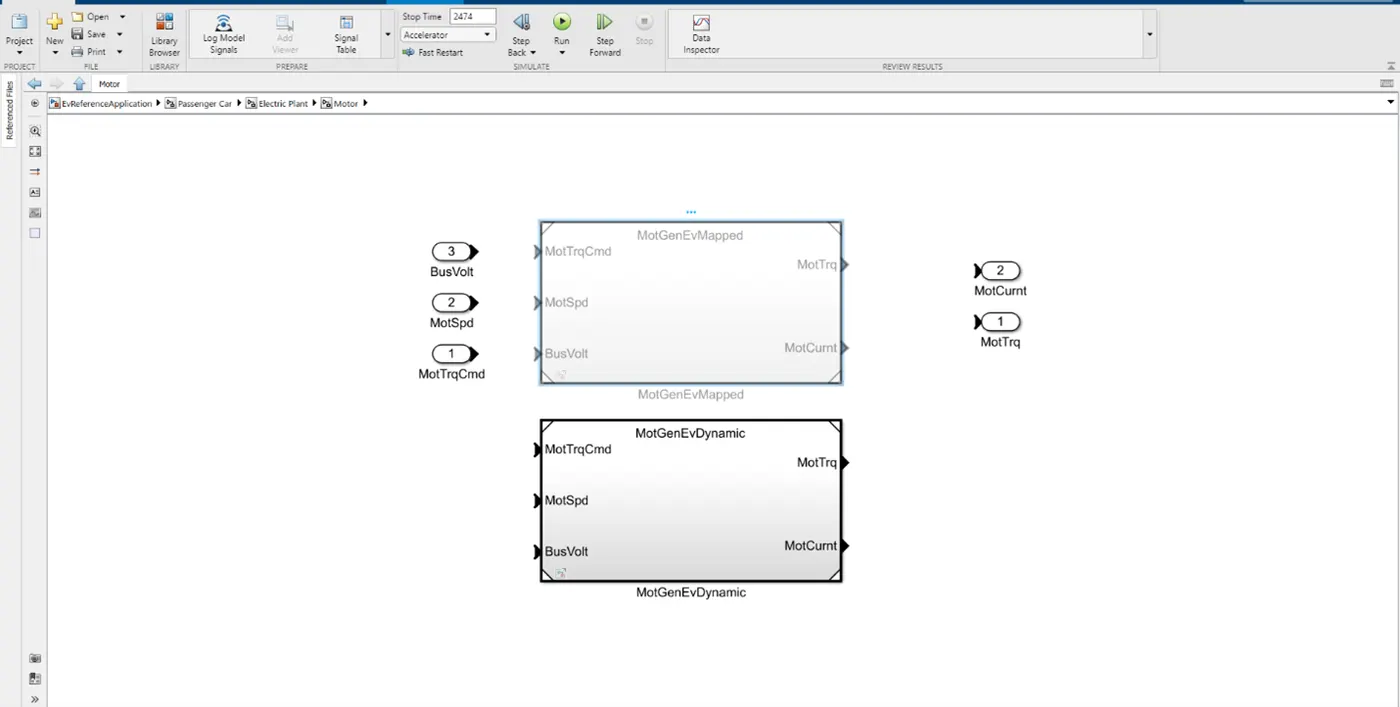
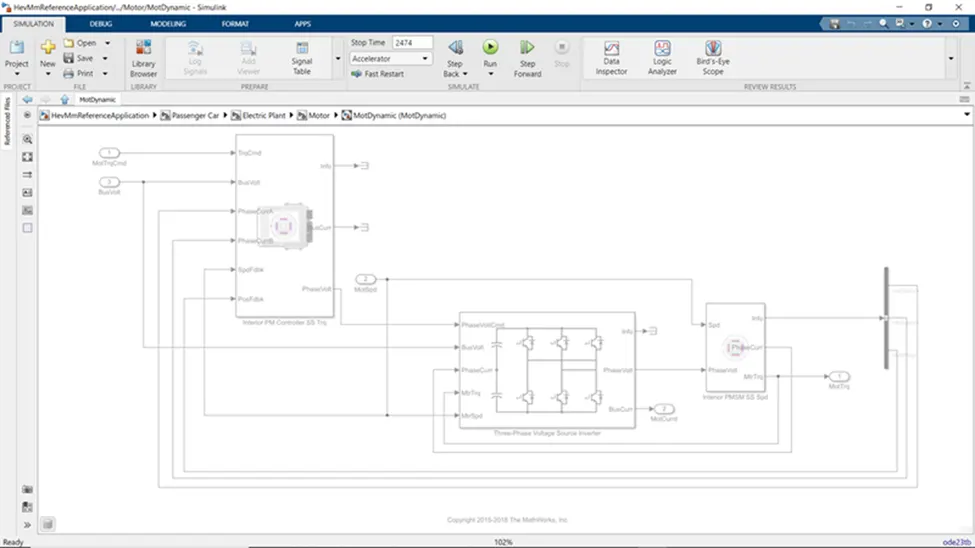
A dynamic system is one in which the running of the motor generator or Engine is simulated in real time and detailed parameter affecting the motor performance can be modified and the results performance characteristic can be use in simulation.
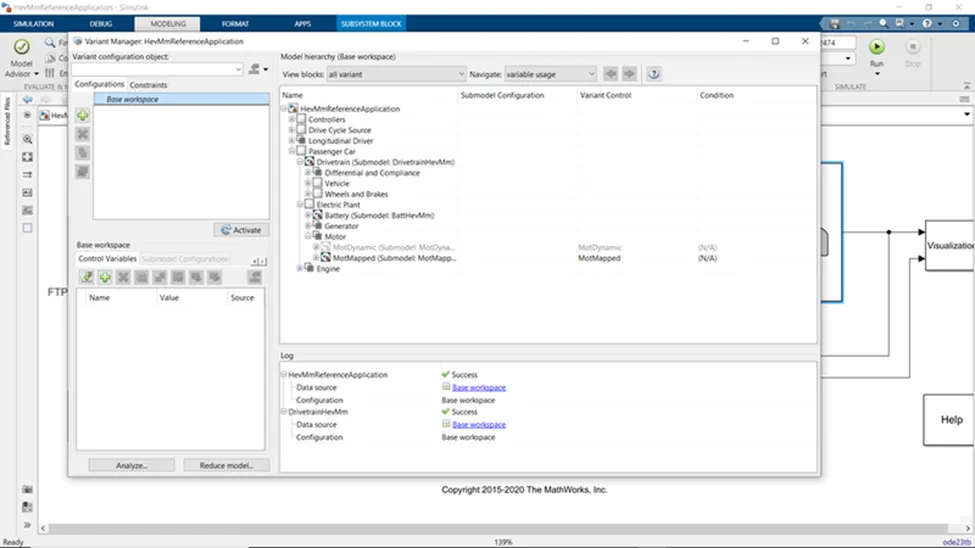
For changing the Model
Click on help
Search getting started with powertrain blockset
Open the Simulink model then click on modeling
Go to variant manager<electric reference application < passenger car<electric plant < motors select which model to run
1.Dynamic engine decompose engine behaviour into individual component models that account for engine dynamics,most notably intake airflow and turbo charger dynamics.
2.Dynamics engine models are suitable for desiging control,estimator and diagnostic,algorthims that depend on dynamic subsysytem states,for example in closed loop AFR(air fuel ratio)control algorithm development.
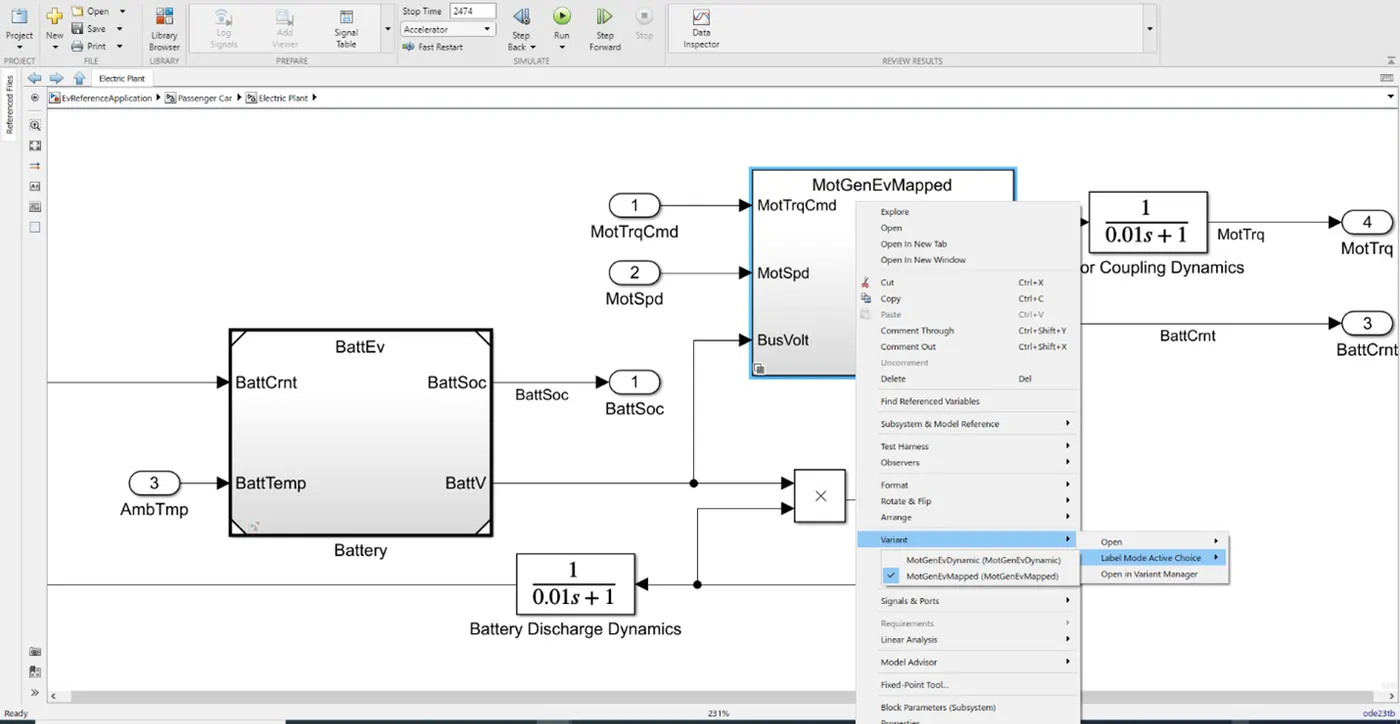
We can switch between mapped and dynamic engines by following below procedures:
1.open the ev model in simulink.
2.enter the passenger car block by double clicking it.
3.then go to electric plant block.
4.inside the motor block right click to find the variant option.
2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Vehicle speed in meter which is converted into miles
Battery data in KWh which is converted into gasoline equalent using US EPA value by dividing with 33.7
1 gallon = 33.7KWH
By dividing distance travel in miles by no of gallons then we get miles per gallon
For HEV this gallon is added with gallon use by IC engine then miles per gallon calculate
· Miles per gallon (mpg) & miles per gallon equivalent (mpge):
· for a conventional gasoline vehicle,the fuel efficiency is calculated via miles per gallon (mpg).however fuel efficiency for hybrid electric vehicles is calculated via miles per gallon equivalent(pge).mpg is the number of miles your car can drive per gallon of gas.figuring out an mpge rating is a littile more complicated.since engines that can use an alternative source of fuel cant be measured by liquid gallons of fuel,the mpge rating is calculated by figuring out the number of milles a vehicle can go using the same energy content as gallon of gas.the epa calculated that 33.7 kilowatt hours of electriccity is equivalent to one gallon of gas.
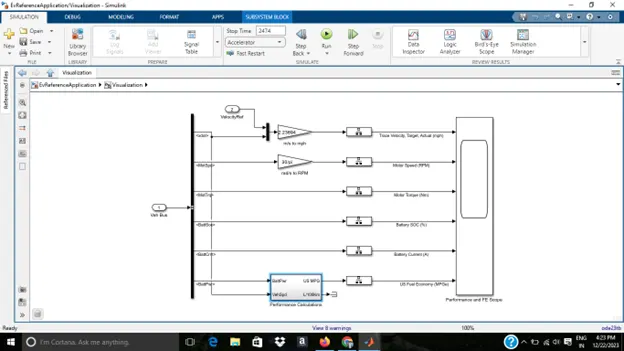
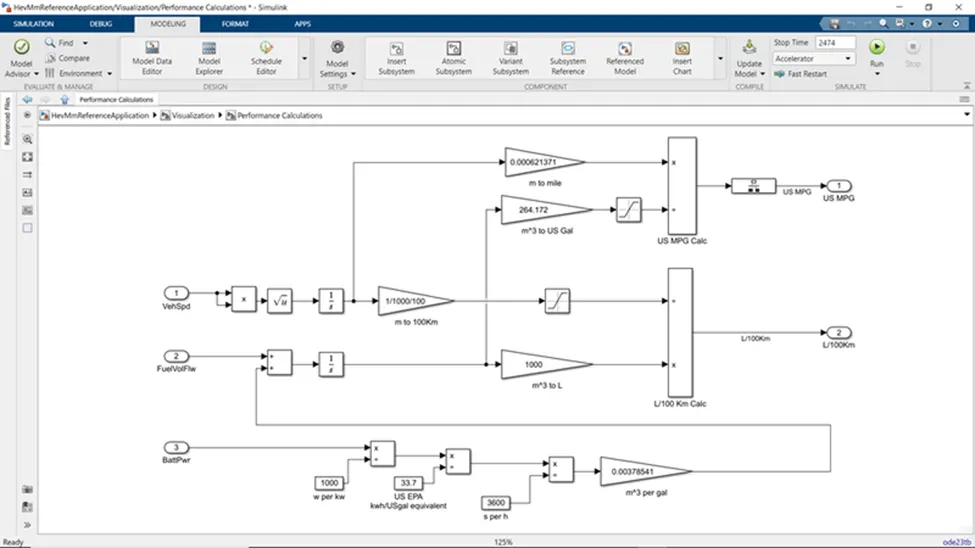
· We should go inside ev reference block that is performance calculations:
· 
· inside this block will get actual mpg calculations:
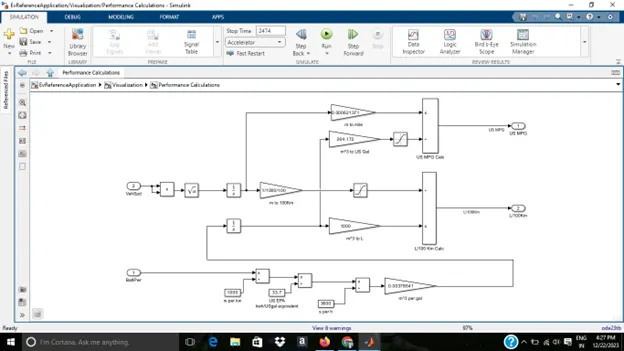
· Here,three different inputs are taken into considerations:
· 1.vehicle speed.
· 2.fuel flow.
· 3.battery power.
· The vehicle speed inputs is in m/s which is converted into miles by multiplying with 0.000621371.
· similarly the kilogram of fuel is converted into cubic meter by multiplying by1/(1000*0.739)
· this cubic meter value is then converted into gallons by multiplying it with 264.172.the mile value and gallon value is used to find mpg of the vehicle.
· now the battery value is initially converted from watts to kwh by dividing with 1000 and then to gallon equivalent by again dividing it with 33.7(sincw 33.7 kwh=1 gallon)
· then divide the value by 3600 to get in per seconds and multiply by 0.00378541nto get the value in cubic meter per gallons.
Q2 B)
As we can see from above block the battery power input signal is converted into an equalent miles per gallon this is along with the value of distance cover from vehicle speed is used to calculate the efficiency of the drive cycle
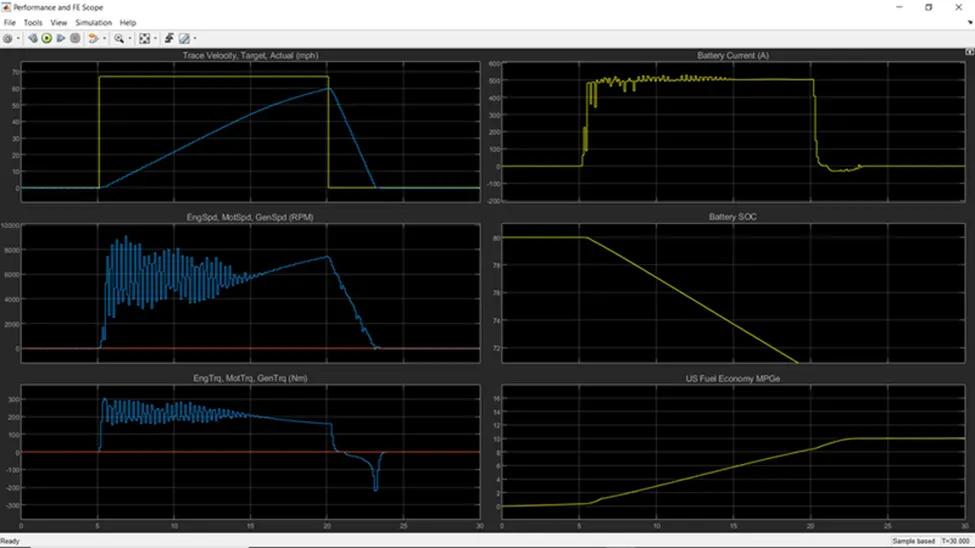
3) Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
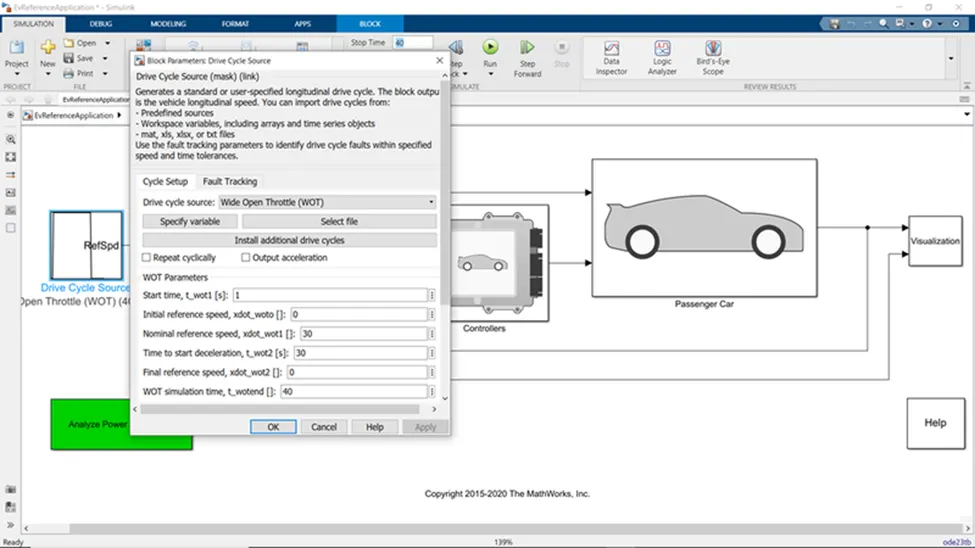
Wide open throttle Simulink block
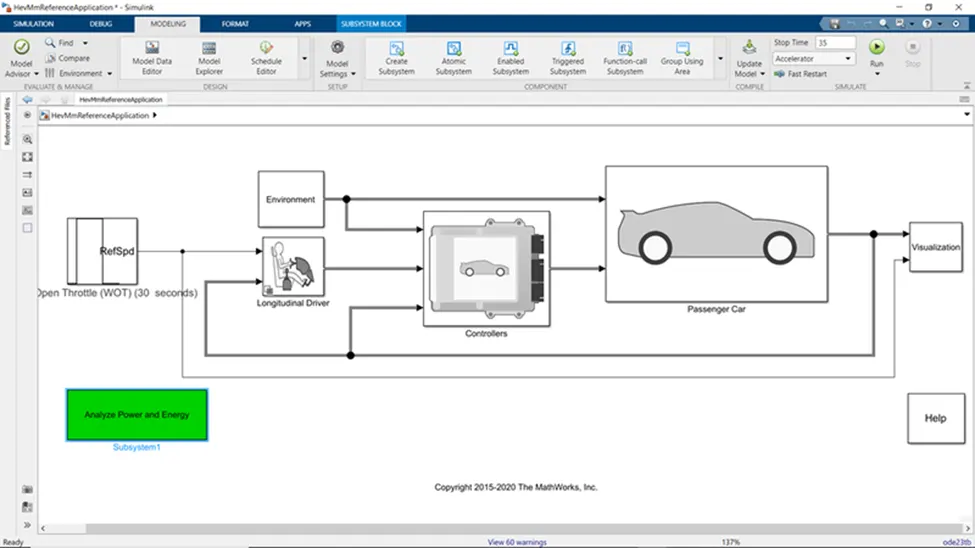
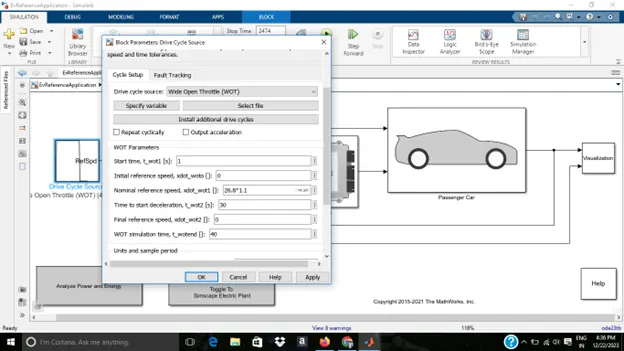
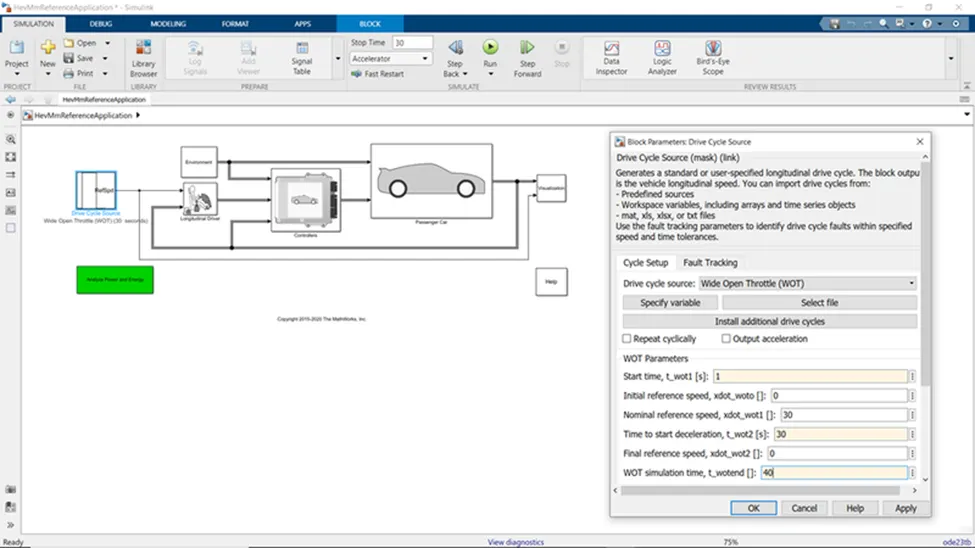
here we have changed drive cycle to wot with a sample time 40 seconds.
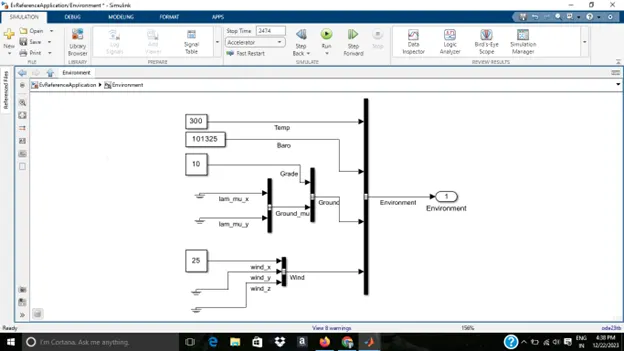
we have also altered environment block and changed wind speed to 25 m/s & grade to 10.
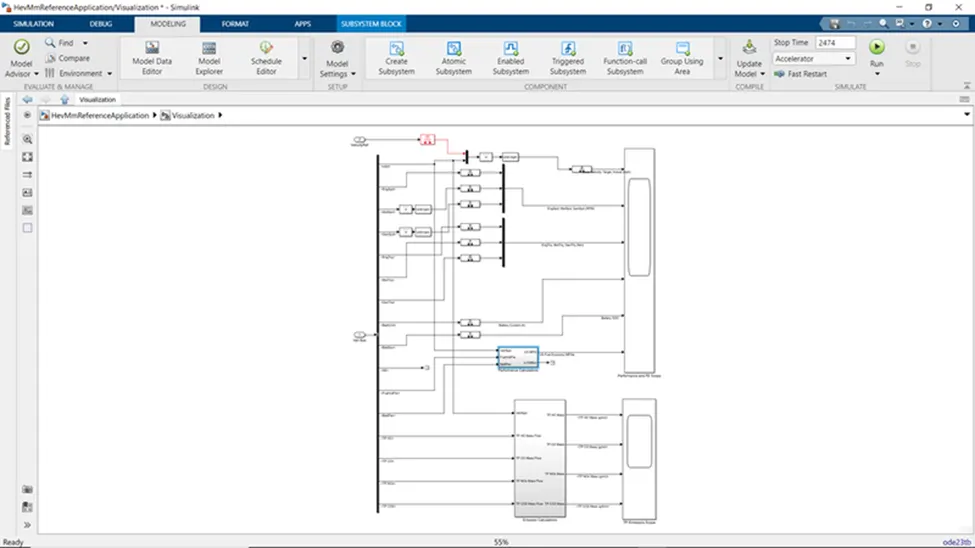
Visualization blockset
No change in Grade and another parameter
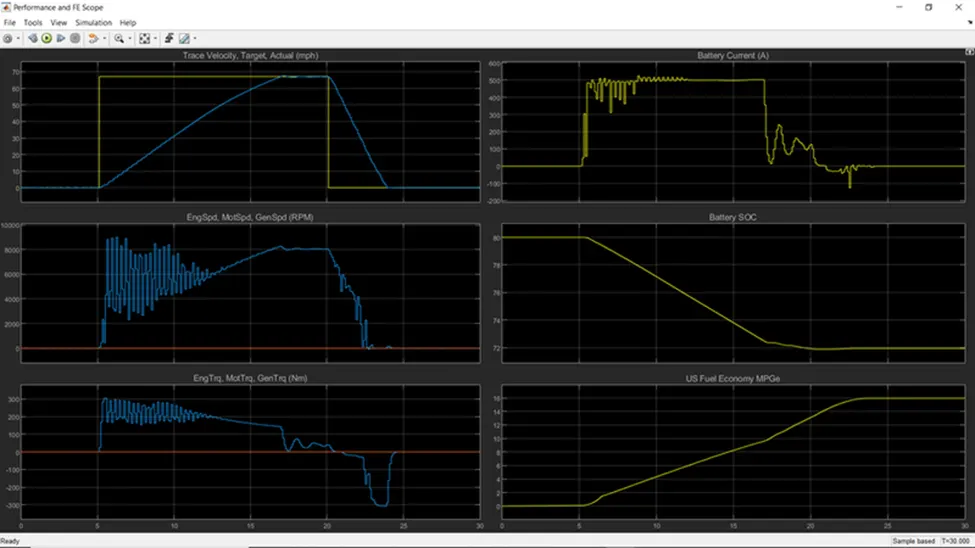
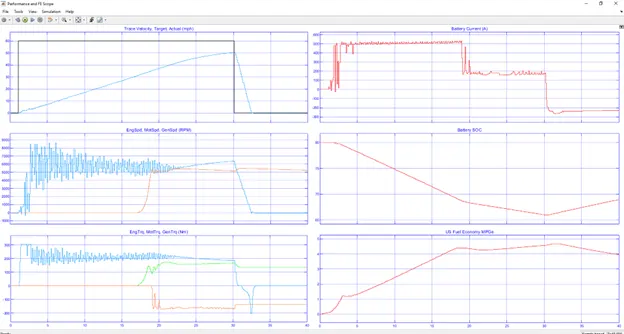
plot 1:trace velocity,target,actual:
top velocity achieved =50.1 mph.
time taken to accelerate = 29.034 sec.
time taken to deaccelerate = 2.471 sec.
plot 2: motor&engine rpm:
top motor rpm=5712 rpm.
top engine rpm = 5451 rpm.
plot 3:motor& engine torque:
maximum motor torque = 306.6 N-m.
maximum engine torque = 174.7 N-m.
plot 4:battery current:
the battery supply current is at its maximum value of 167 ampere when full throttle is applied by the user it reduces drastically to the value of negative 150 during deaccelaration of the vehicle.
plot 5:battery soc:
the battery soc will falls from 80 to 65 % during accelaration of vehicle and it increases slightly to 65 to 70 % during de accelaration due to regenerative braking.
plot 6:fuel economy:
maximum fuel economy achieved = 4.675 .
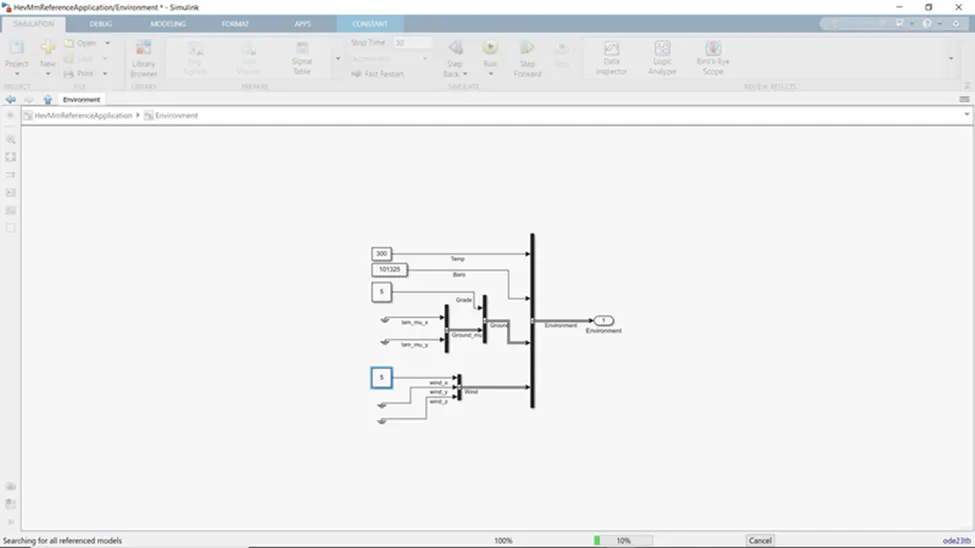
By changing the grade values to 5
4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrain.
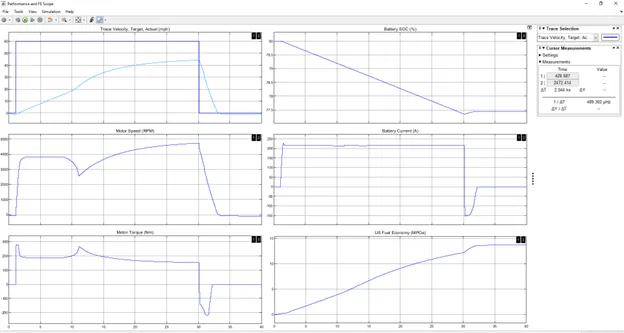
Simulated Results of EV:
Conclusion:
1.The top speed is achieved by hybrid electric vehicle is more than that of EV.
2.The battery current capacity of pure EV is much higher compared to that of HEV since in EV battery is the only driving unit.
3.Higher fuel economy is achieved in case of pure EV.
By changing the environmental factor of HEV
Attained velocity is lower
Motor RPM is light be higher but engine RPM remain same
Fuel economy reduce drastically
SOC is maintain same in both change
Q3B) keeping all the parameter same for HEV and EV
Simulation block of HEV with WOT for 40 sec
Visualization result graph of HEV
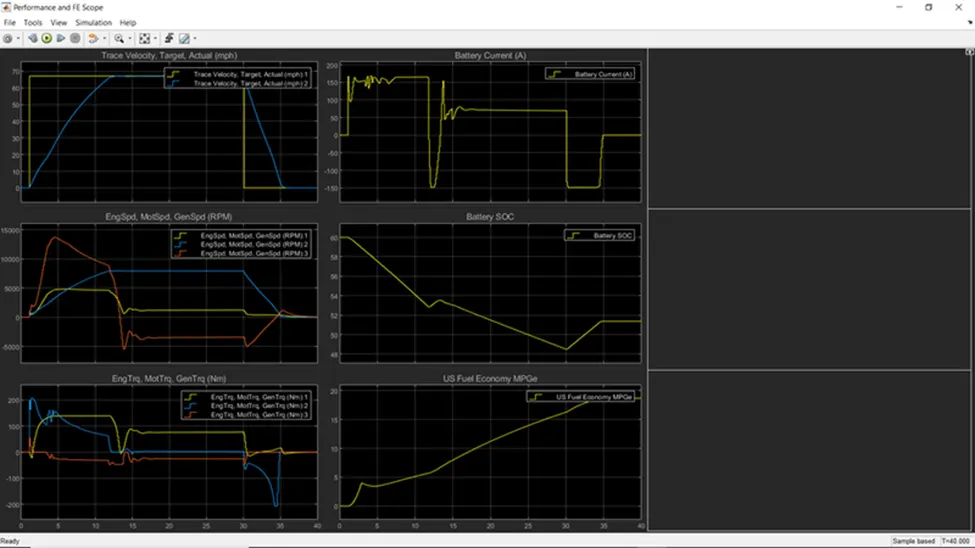
EV blockset with WOT for 40 sec
Visualization Result graph
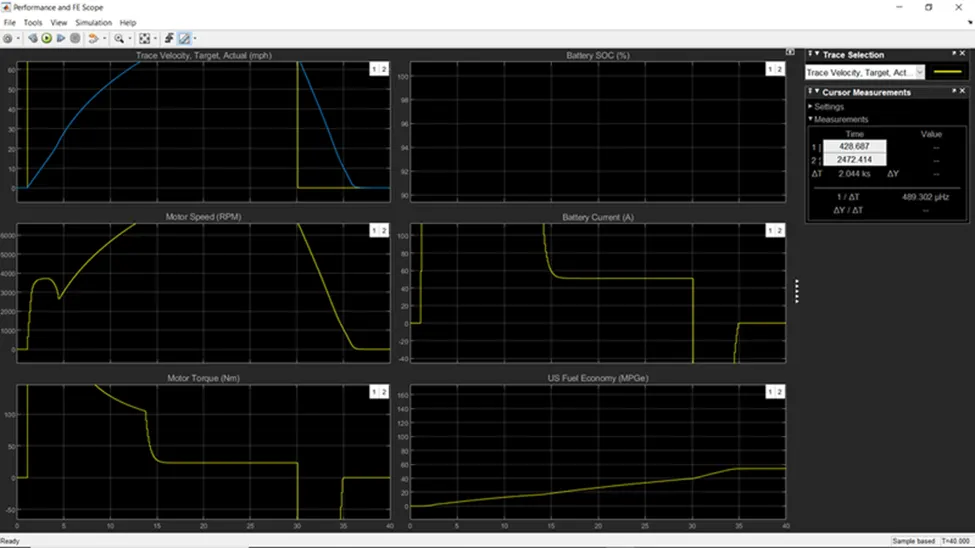
Result:-
Battery discharge is different because of in HEV motor is charge the battery but in HV regenerative breaking system charge the battery
Motor speed is high in HEV as compare to EV
EV powertrain provided a better MPH rating as it is more efficient
Torque provided in HV