Week-4 Challenge WOT Condition Part-2
1.What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
In powertrain blocksets has two types of engine models mapped & dynamic
Mapped models of engines:represent the macro engines behaviour as a set of look-up tables such as brake torque,fuel flow,air mass flow,exhaust temperatue effeicency & emissions,it is a steady state model & simulation takes less time.Mostly suitable for design & analysis of engine characteristics that do not requires engine subsystem characteristics
There are two types of mapped models.1.CI mapped engine & 2.SI Mapped engine,these model uses a steady state lookuptables to simulates the engine performance&provides the overall engine characteristics.
Dynamic models of engines:used check the engine characteristics with taking the individual compenents performances also, used to describe the interactions bewtween the multiple components & simulates accordingly to the real time results.
There are two types of dynamic models.1.CI engine & 2.SI engine,
For motors & generators:
Mapped model:provides a mapped motor or generator according to the need & drive electronics of it by operating in torque control mode,for this we give input ofmotor response & drive response time constants.
this model is a 2-dimensional lookup table where we neede to input motor or generator parameters (like motor rpm starting & generator current ) & it give fast simulation results even thought there mechanical load fluctuatuions do not affect the simulations.
Dynamic model: this model represents actual generator working in a real-time,where the output values calculated conutniously according to changes of the input values,as the equations implementing simulation time is more compared to the mapped models.uses circuit diagram,system equations with that transfer functions calculated simulation done with model block diagram,
this way actual character of the mutliple components can be studied.
Difference between 1.Mapped model & 2.Dynamic model.
1.uses a prebuilt data in lookuptable for the simulation of the powertrainblock set & mapped model calculations are fast,if electrical losses we can add it in simulations.
2.uses a real time data for calculating the vehcile characteristics like speed velocity drag coeffeiceint,fuel etc & time consuming process
Changing the model type steps:
1.open the EV refrence application in powertrain blockset of matlab(matlab:autoblkConVehStart)
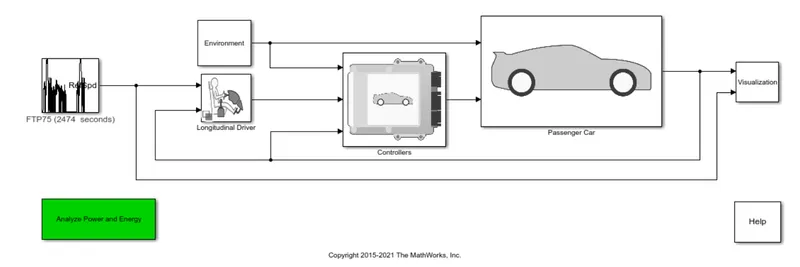
2.Go to the passenger car subsystem then to the electric plant then electric plant subsystem screen appears
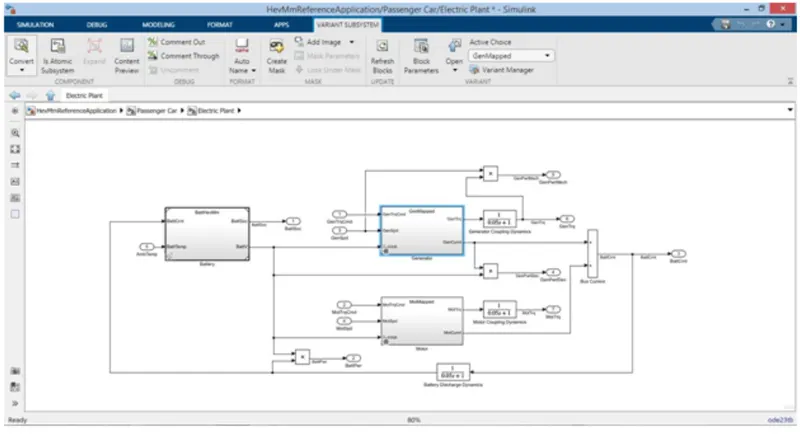
3.Go to the variant subsytems option which is in task bar,click on the varaint manager option,in the variant manager subsystem new window will open
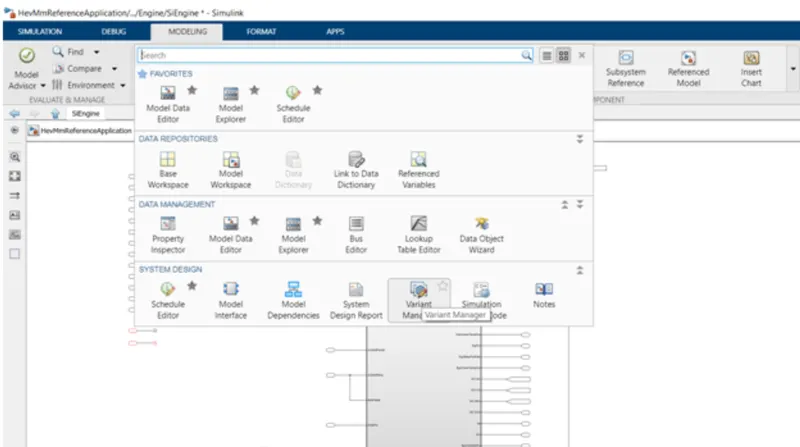
4.Go to variant block slect the generator sub-floders & right click the GENdynamic model & selectset as label mode active choice.
this will change the model type
2.How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
to calcilate the MPG miles per gallons we need the fuel flow,vehcile speed,vechicle network load consumption that is battery current.this procedure certified by USA environmental protections agency & responsible for it.
Actually MPG is car's distance travelled distance measured in miles with fuel consumed in gallons, these measured three different ways.
1.Highway run: a typical highway car driving with minimal stoppage & loads equipped according to summer or winter season profiles.
2.City run: a typical traffic jam with high number stoppage & driving at low speeds.
3.Combination above two.
in eurpean standards they uses homoloagtion proganaistics in WLTC cycles & calculate the fuel efficiency.
Now in MPG the US government expanded testing capabilities which alternative fuelled cars including the EV cars.this allows the user to comapre the fuel efficiency of EV with ICE.with this we can compare different vehicles tells the fuel efficency comparisons
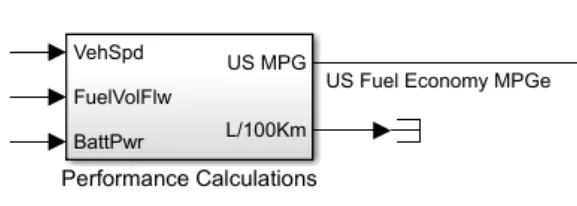
Factors considered to model fuel flow are explained above(1.Vehicle speed,2.fuel flow,3.battery power)
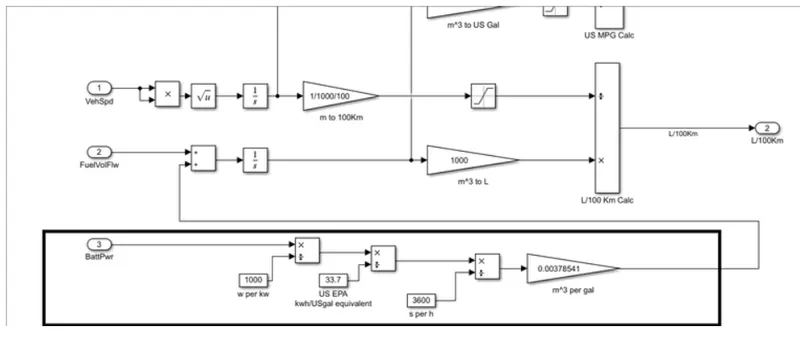
Note:264.172gallons=1000litres & one gallon=33.7KW hours of energy in EV
3.Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
the hybrid electric vehicle refrence application represesnts a full mulitmode(HEV) model with an internal combustion engine ,transmission,battery,motor generator ,powertrain control algorothims.Use the reference application for powertrain matching analysis & component selection control& diagnostic algorithim design & hardware in the loop testing.
Default HEV multimode refrence application is configured with :1.Mapped motor & generator,2.1.5-l spark-ignition dynamic engine.3. diagram
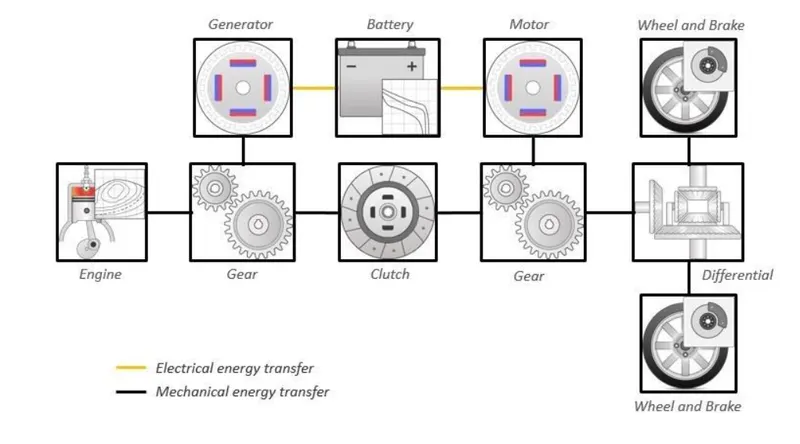
HEV refrence application:
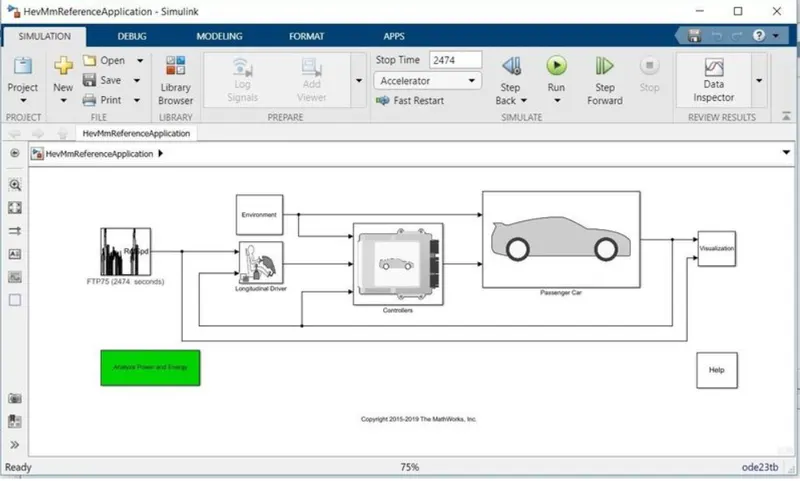
Changing the WOT drive cycle as
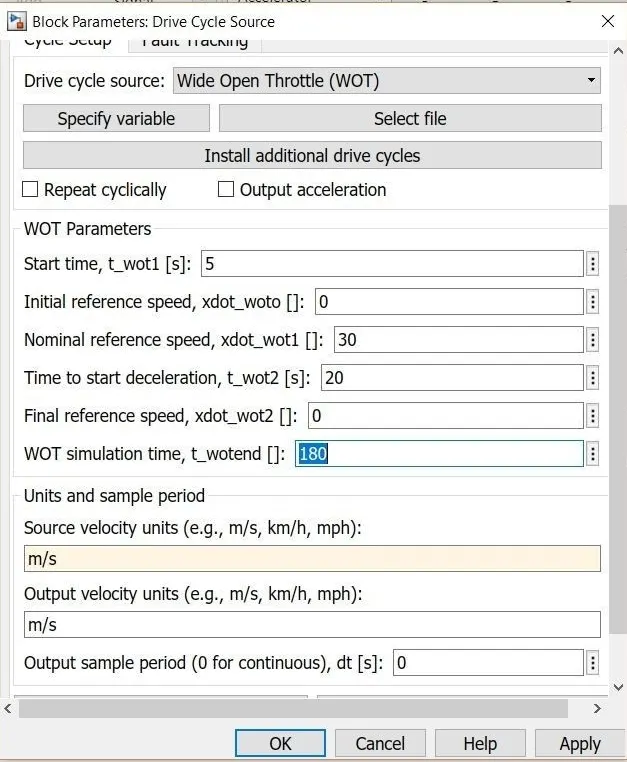
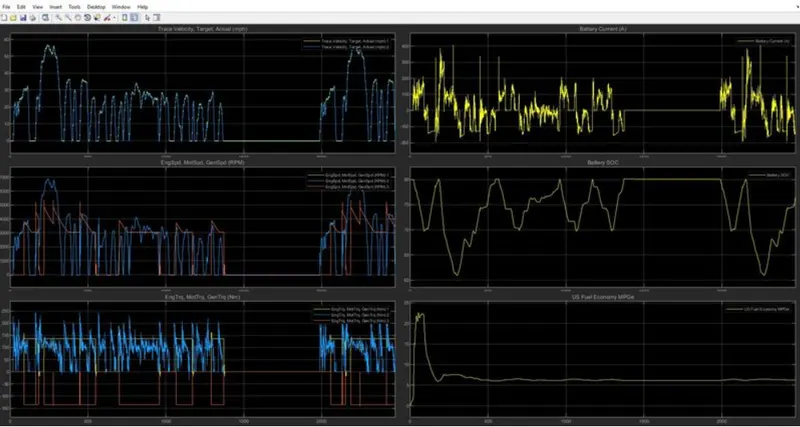
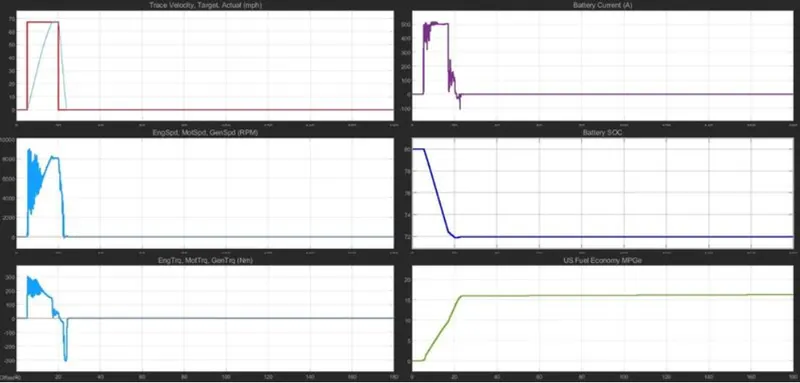
velocity achieved67.1mph,battey current was increased upto 500A & maintained duration of14S,engine speed was8000RPM battery SOC was decrease from 72.
results:
Now changing the environmental Sub-System in case 1 specification HEV refrence application
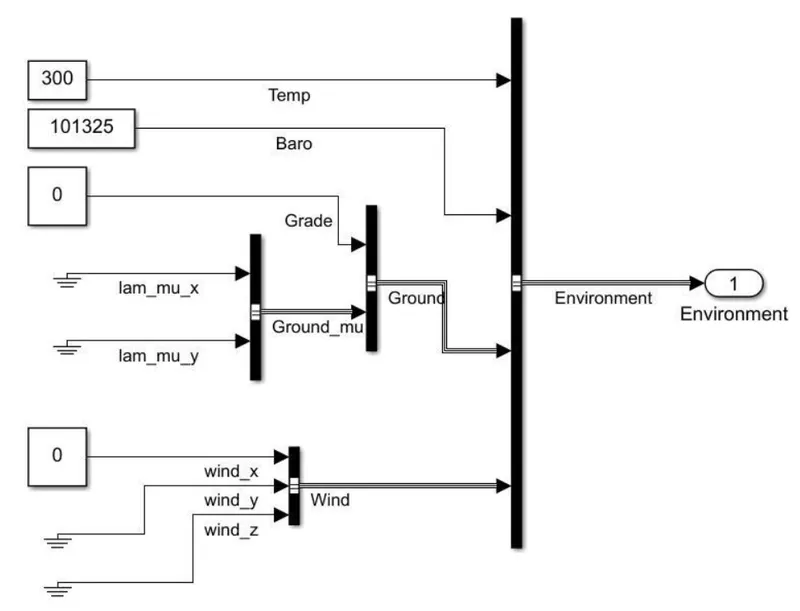
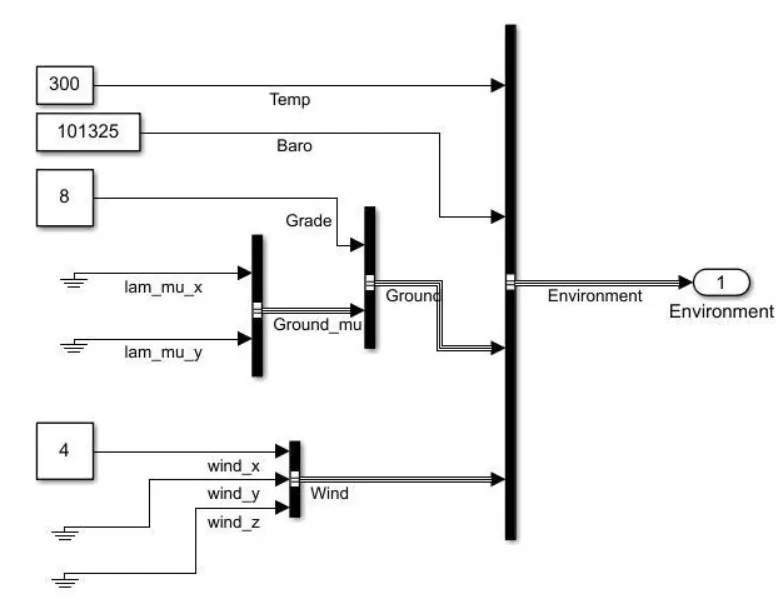
Results
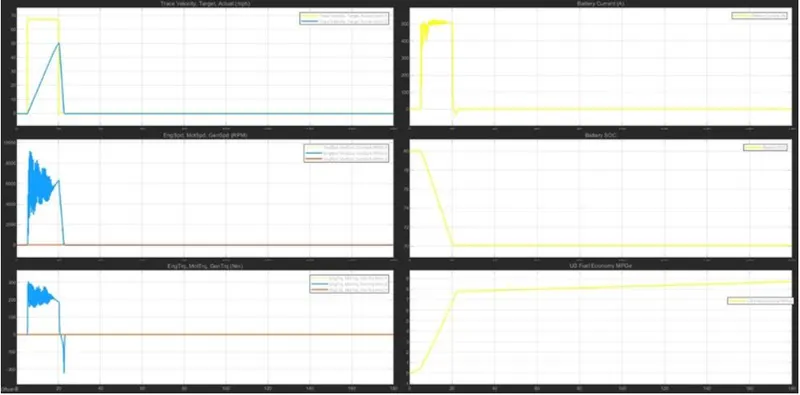
Traget velocity 50.4mph.battery current was incresed upto 500Amp & maintained for 14s,engine speed able to achieve8000rpm
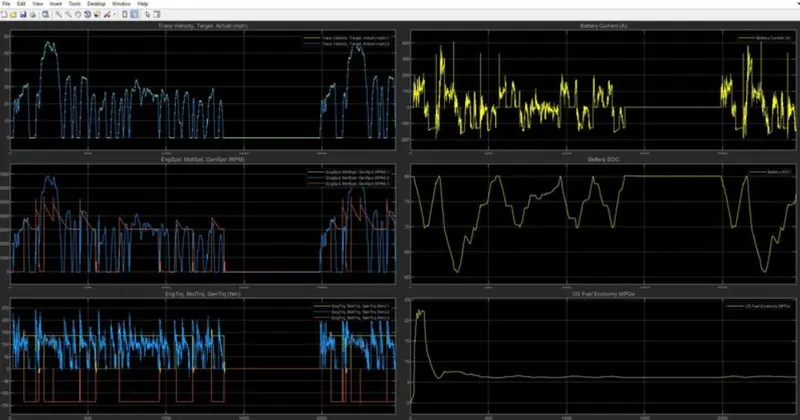
4.Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
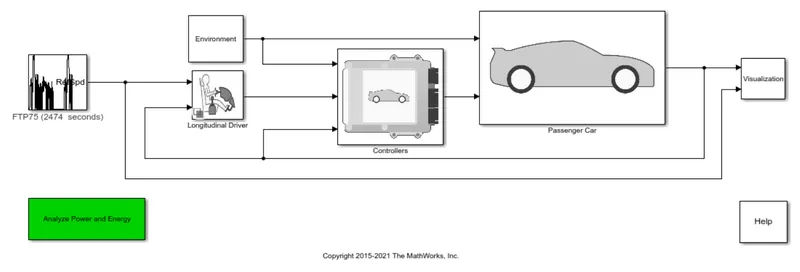
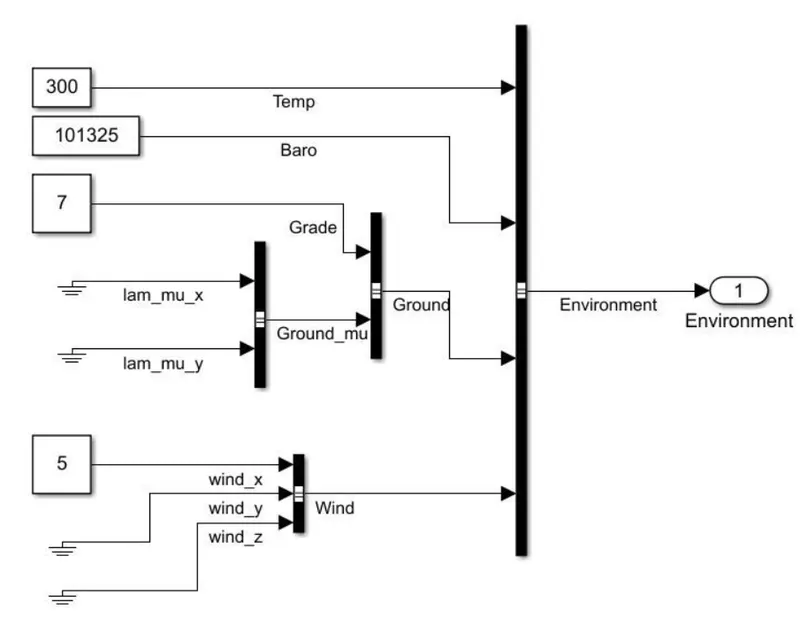
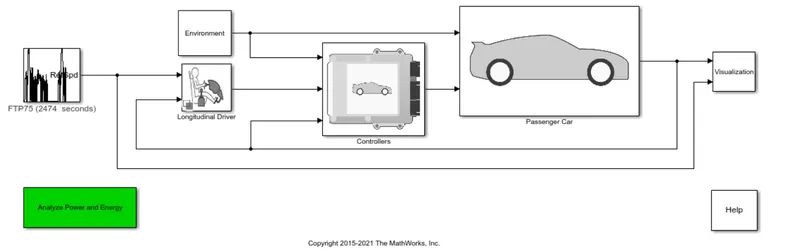
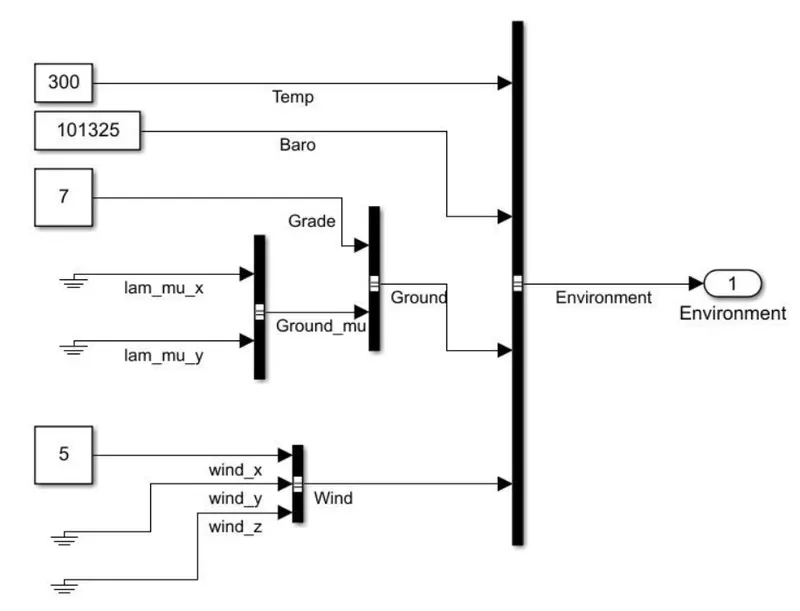
model consist of environmental, drive cycle longitudinal driver passenger & visulation system.open the environment block & change grade value to7 & wind velocity to5,now run simulation.
HEV model
Results
EV model
Results: