Week-4 Challenge WOT Condition Part-2
- What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Mapped engine models:
- Mapped engines represent macro engine behavior as a set of lookup tables (brake torque, fuel flow, air mass flow, exhaust temperature, efficiency, and emissions) as functions of commanded load and measured engine speed.
- Mapped engine models are suitable for analysis and design activities that do not require engine subsystem dynamic characteristics
Dynamic engine models:
- Dynamic engines decompose engine behavior into individual component models that account for engine dynamics, most notably intake airflow and turbocharger dynamics.
- Dynamic engine models are suitable for designing control, estimator, and diagnostic algorithms that depend on dynamic subsystem states
changing model type
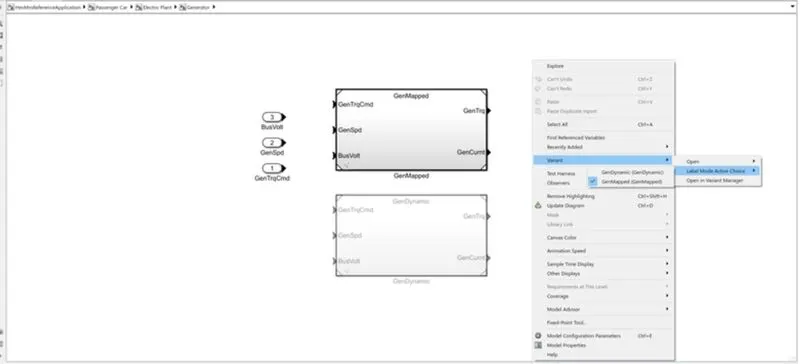
As per the screenshot below of the generator of hybrid electric vehicle, In generator block to select between the mapped generator and the dynamic generator. currently mapped generator is configured, if we wish to change this to the dynamic generator, select the model which you want to configure - choose variant manager- right click the model you wish to choose and then set as label model active choice.
2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
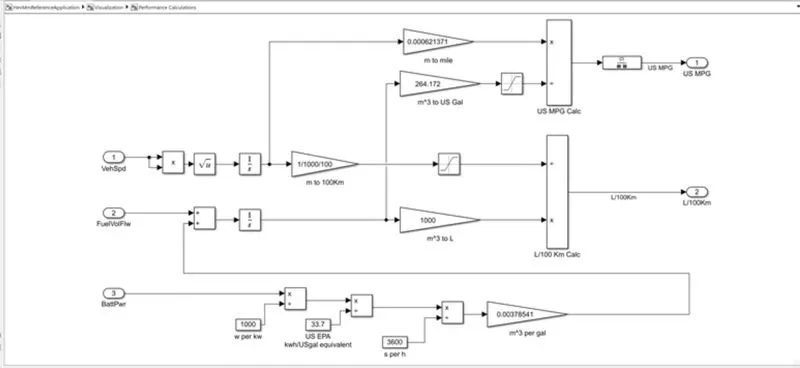
Calculate miles per gallon from cubic meter
The reference model taken here for consideration is HEV and it operates on both battery and fuel injection engine
3.Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
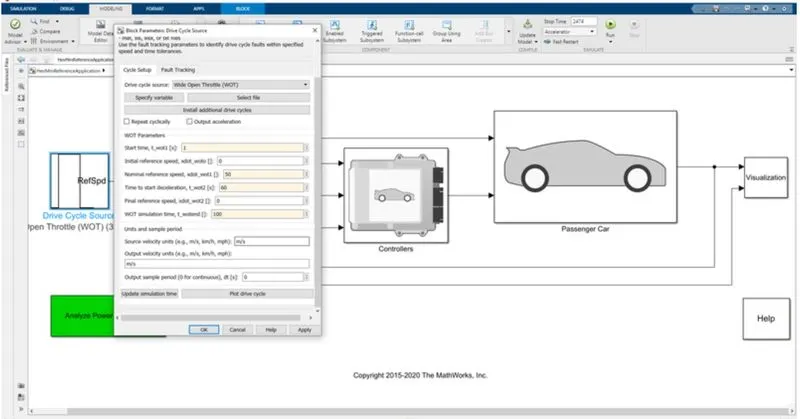
- Go to help and search powertrain blockset and choose explore hybrid electric vehicle multimode reference application. load simulink model.
- Change the drive cycle to WOT and change the parameters accordingly.
- Now we need to change the grade and wind velocity in the environment block and therefore go to environment block and change the parameters.
4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Open HEV reference application model in MATLAB.
The model consist of environment, drive cycle, longitudinal driver passenger and visualisation subsystem.
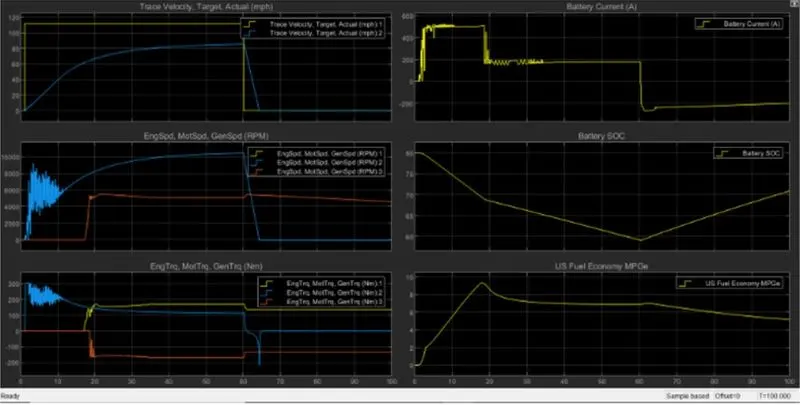
Below mentioned vehicle is simulated for the EV reference.
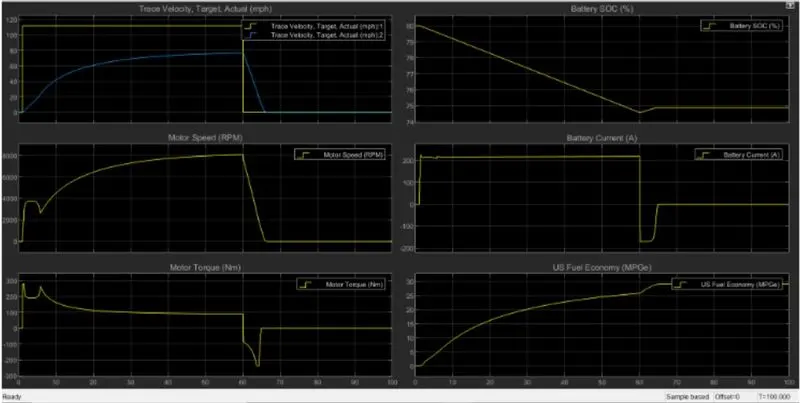
The overall difference in both these simulations are their vehicle operations where the EV is completely operated on battery as the power souece and on the other hand the HEV has two power sources SI and CI engine and battery. The results obtained are varied and the parameters are also differentiated accordingly.