Hybrid Electric Vehicle: WOT Analysis
Q1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Solution:
The powertrain block set provides two types of propulsion models:
- Mapped Model:
- It uses a set of steady-state 2-d lookup tables to characterize engine/motor performance.
- The tables provide overall engine characteristics, including actual torque, fuel flow rate, BSFC, and engine-out exhaust emissions.
- This model leads to faster solving times.
- Dynamic Model:
- It decomposes the engine behaviour into engine/motor characteristics that are separated into lower-level components.
- By combining components in this way, the models capture the dynamic effects.
They are used,
- If you need a more detailed dynamic model and have component-level data,
- To analyse the impact of individual engine components on the overall performance.
- To change between mapped & dynamic model:
- Open the powertrain module block set for the required vehicle.
- Click on passenger car/vehicle block and select electric plant or engine.
- Right click on Engine/EV motor/generator based on vehicle model and select variant.
- Under variant, scroll to label model active choice and choose mapped or dynamic for the required calculation.
Q2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Solution:
- Miles per gallon (MPG) is a fuel economy rating determined by how far a car can travel on a gallon of gasoline or diesel for a conventional IC Engine vehicle.
- In the case of an electric vehicle, this is a measure how much electrical energy is consumed by the battery pack to travel a fixed distance.
- The powertrain block has an inbuilt model for this which can be found inside the visualization block.
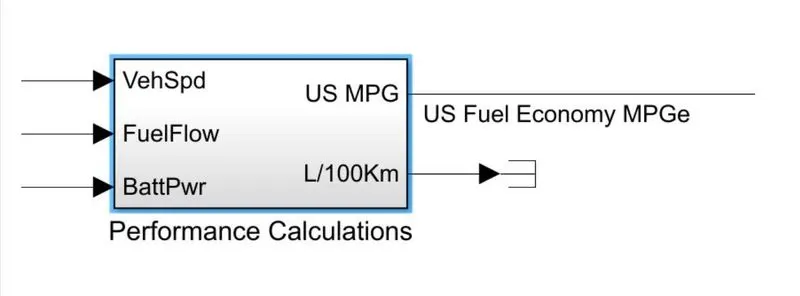
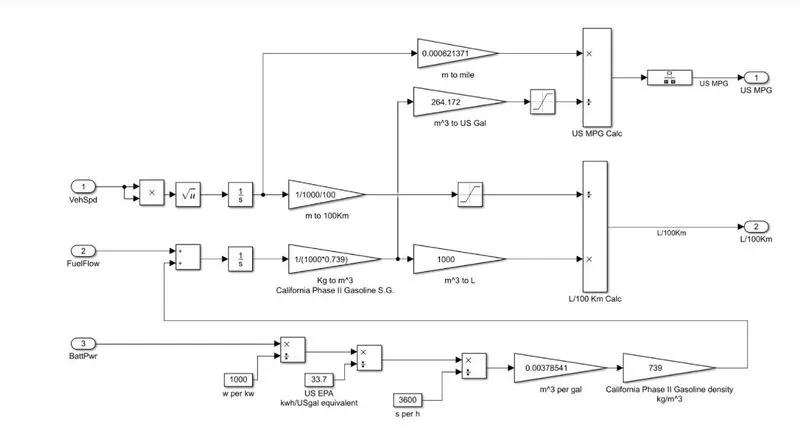
- As observed from the above picture, a hybrid electric vehicle model's visualisation block is explored.
- The fuel flow is calculated using two inputs, that are Vehicle Speed & Battery Power.
Q3. Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
HEV Powertrain configuration
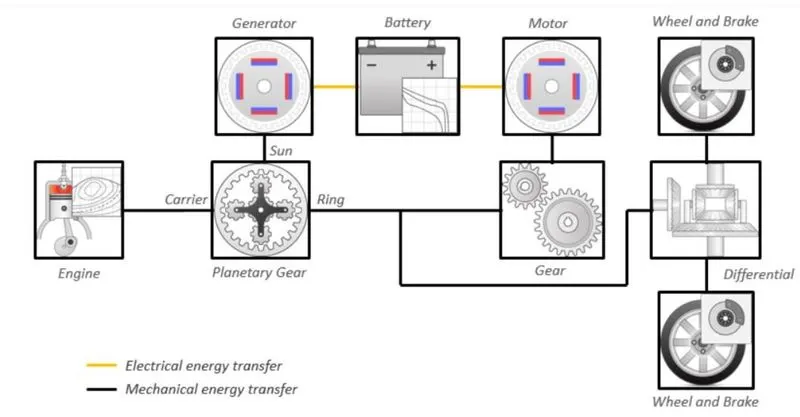
HEV Reference Application Blockset
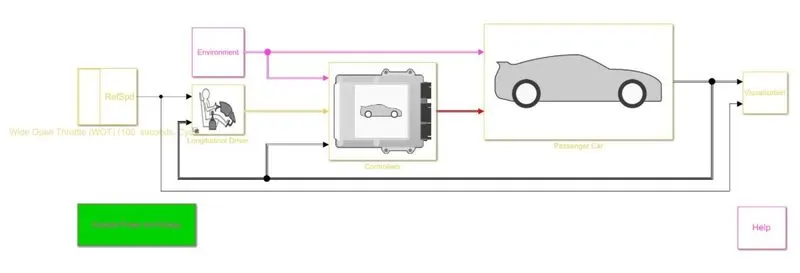
WOT Drive cycle inputs
- Total simulation time = 100s
- Nominal Speed = 50m/s
- Deceleration time = 50s
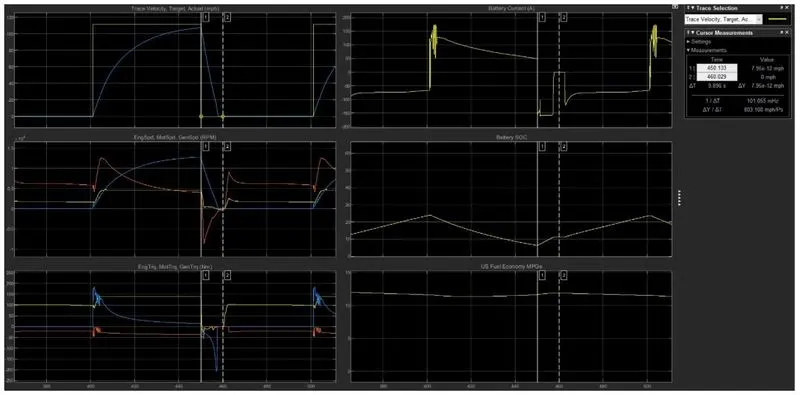
Case 1- Default grade (0 degrees) and wind velocity (0 m/s)
Case 2 - Grade = 5 degrees, wind velocity = 10m/s
Results Comparision
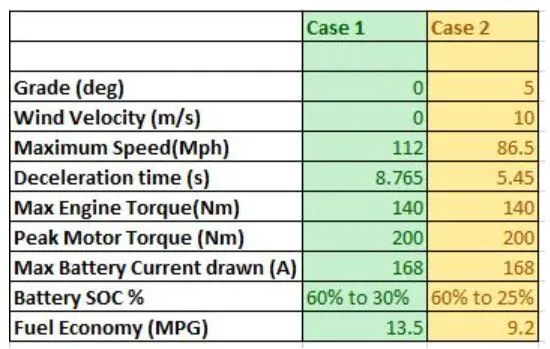
Observations:
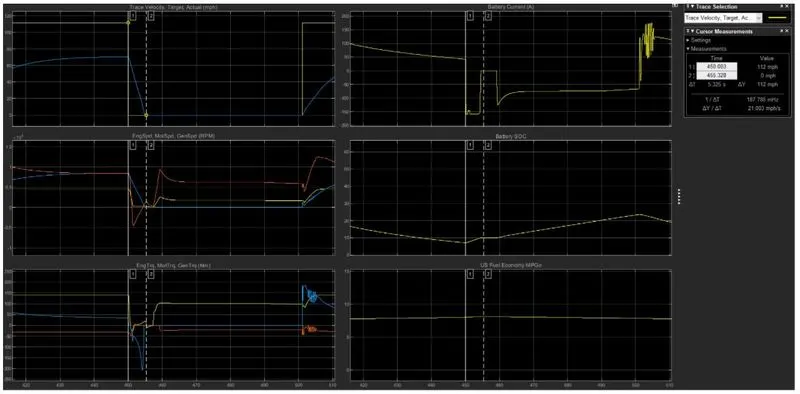
- A visible difference is observed between the actual trace velocity curve and input trace velocity curve due to the limitation of power available from the energy source.
- The maximum speed achieved is lower in case 2 because of the gradient slope considered and also the wind resistance.
- Since more power from the energy source is required to overcome these resistances, the battery SOC and the fuel economy is decreased.
Q4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
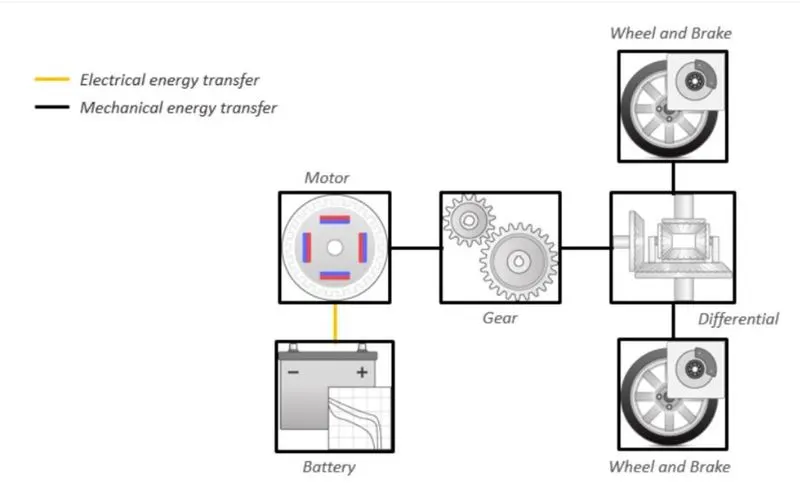
EV Powertrain configuration
EV Reference Application Blockset
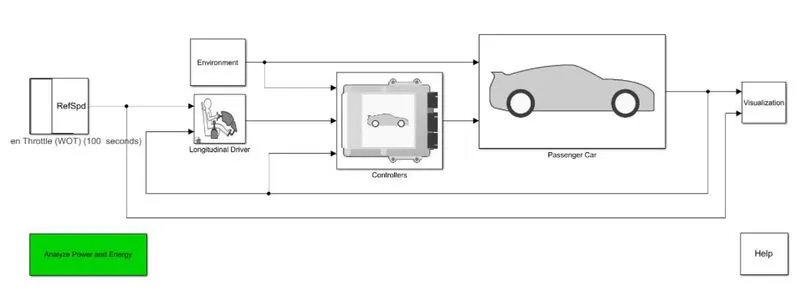
Case 3 - Grade = 5 degrees, wind velocity = 10m/s
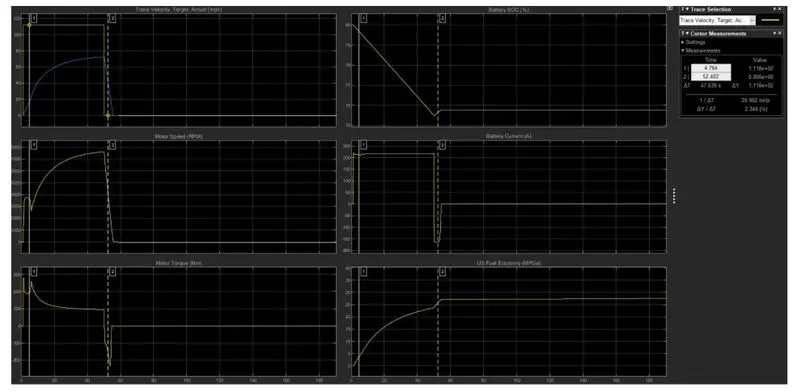
Results comparison:
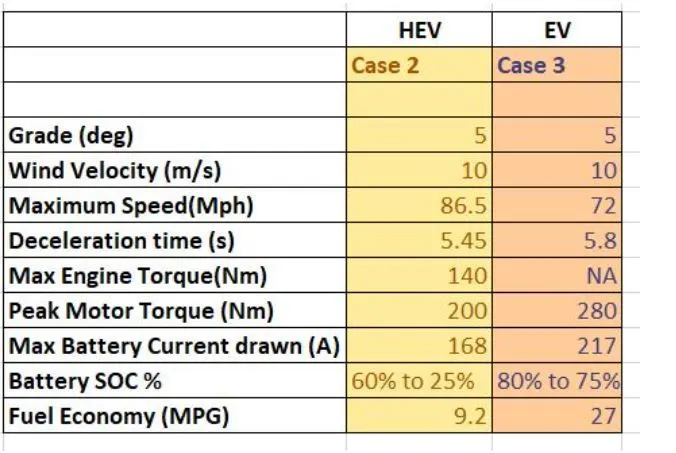
Observations:
- The electric powertrain achieves a lower top speed when compared to a HEV powertrain.
- Since the motor is the only propulsion source in an EV powertrain, the motor needs higher rated power and generate the instantaneous start up torque to propel the vehicle.
- The conventional HEV's use lead acid battery whereas the EV's use lithium-ion cells which have more energy density.
- EV has a superior fuel economy than a conventional HEV.