Week-4 Challenge WOT Condition Part-2
- What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Ans:
Mapped mode:
1.In mapped model the output is given on the basis of some pre defined rules.
2.This rules can be in the form of Formulas or set of conditions.
3.In this model we do not consider any change in parameters in the engine,motor,Generator.
4.This kind of model is mostly used when we need less simulation time.
5.Mapped model does not give the mosy accurate outputs ,and it is used only when there is no need of such accuarte output values.
6.It is faster then dynamic model.
7.Calculation is easy.
Dynamic model:
1.In dynamic model the ouput is on the basis of real time inputs.
2.As its uses the real time inputs so this method gives the most accurate outputs than mapped model.
3.As this model uses all real time data so the model its self get complex and due to its complex calculations the simulaton time increases.
4.It is slower than mapped model.
5.This model is used when we consider all the dynamic data of the vehicle and we need the most accurate calculations.System is more robust to the inaccurate calculations.
2.How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
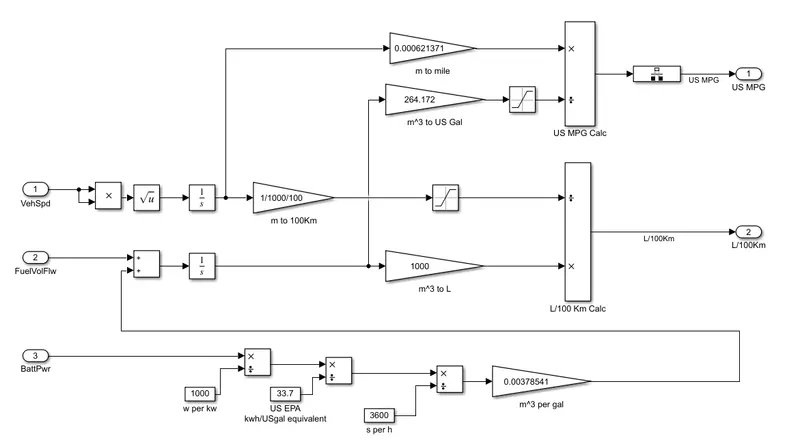
calculate miles per gallon
1.The vehicle speed is square root is taken.
2.The the speed is converted from m to 100km .
3. speed is also converted from m to miles.
4.Battery power is divided by 100 to convert into watt per kw.
5.Then it is divided by US EPA kwh/USgal equivalent.
6.Converted into seconds per h by dividing it by 3600.
7.The it converted in to m^3 per gal.
8.By using US MPG calculator block we can calculate the the us mile per gallon.4
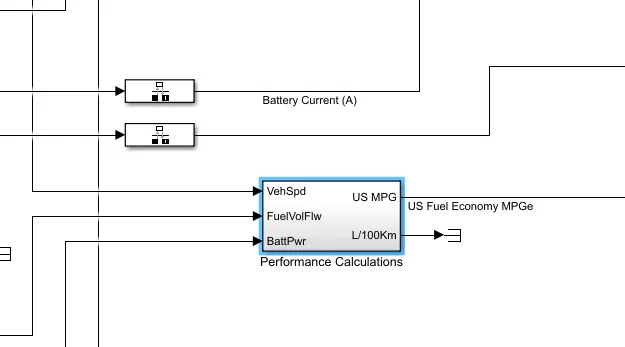
factors are considered to model fuel flow:
Driving:Sudden accelertaion,High speed
Weather:Temperature
Weight of the vehicle:Depending on the total weight of the vehicle the fuel flow model is considered.
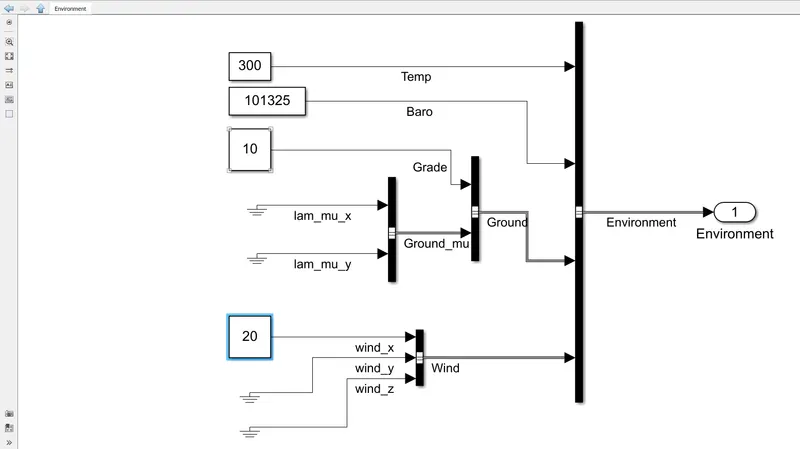
3.Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Ans:In WOT drive cycle tghe vehicle is run on the full throttle.
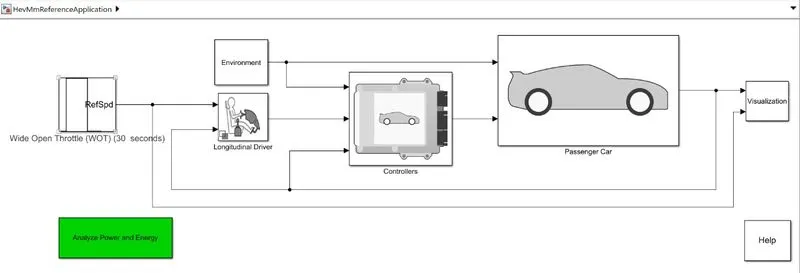
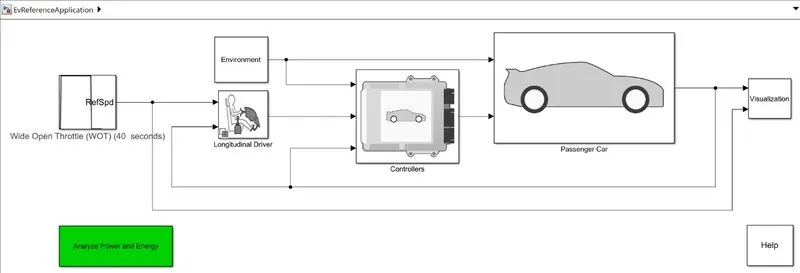
To change the Vehicle garde and the wind velocity we need to enter into the environment block and change to inputs.
In thhis model we have used garde =10 and wind velocity =20
4.Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains:
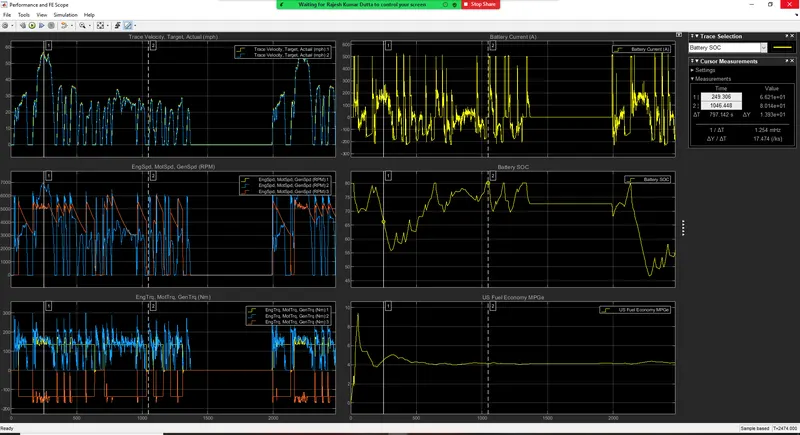
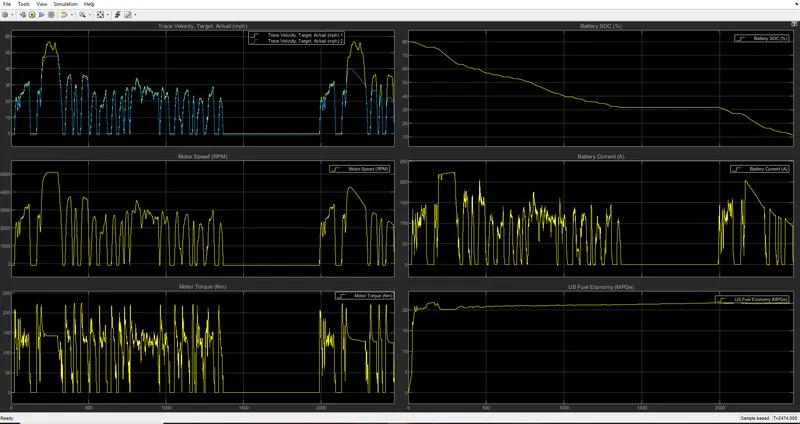
1.For both EV and HEV same driving cycle is considered.
2.Initial for both EV and HEV the initial battery level is at 80(SOC 80)
3.In the EV case we can see the Soc is droped from 80 to 10
4.while in HEV after complete driving cycle the SOC is still at 50.
5.The maximum current (A) in EV is 250 A,While in HEV it is 500A.
6.When the current is in the negative we can say that the regenerative braking or the battery is charging.
7.In HEV the battery SOC max is set at 80 after that engine will not charge the battery.
8.In EV US fuel economy(MPGe) it is upto 20.
9.In HEV the average MPGe is 4.
10.When the engine torque is in negative we can say the generator is charging the battery.