Week 4.1 - Solving second order ODEs
AIM : To write a program that solves the second order ODE
GOVERNING EQUATIONS :
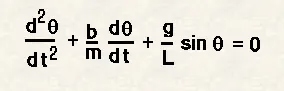
where
g = gravity in m/s2
L = Length of the pendulum in meters
m = mass of the ball in kg
b=damping coefficient
OBJECTIVE : To write a program that solves the following ODE. This ODE represents the equation of motion of a simple pendulum with damping
To Create an image that represents the position of the pendulum for each value of time
BODY OF THE CONTENT :
1)PROGRAMMING LANGUAGE USED :
HTML( default )
2) CODE :
clear all
close all
clc
% Inputs
l=1 ;  % in metres

m=1; % in Kg

b=0.05 ; % damping coefficient

g=9.81 ;  % in m/s^2

% Initial Conditions
theta_0 = [0 ;3];
% time points
t_span=linspace(0,20,500);
% solving ODE
[t,results] = ode45(@(t,theta)ode_func(t,theta,b,g,l,m),t_span,theta_0);

%Plotting

plot(t,results(:,1))
hold on
plot(t,results(:,2))

ylabel('Plot')
xlabel('Time(seconds)')
title('Damped Harmonic Motion of a Pendulum')
legend('Angular displacement ', 'Angular velocity')


ct =1;
 for i = 1:length(results(:,1))
      x_start = 0  ;
       y_start = 0 ;
        x_end = l*sin(results(i,1)) ;
         y_end = -l*cos(results(i,1)) ;

          % plotting the animation
           figure(2)
            plot([-1 1], [0 0], 'linewidth', 5)
             hold on
              plot([x_start x_end],[y_start y_end],'linewidth',3)
               hold on

                plot(x_end,y_end,'O','markersize',10,'markerFacecolor','g')
                 title('Animation of transient behaviour of a Pendulum')
                  axis([-3 3 -3 1])
                   pause(0.05)
                    hold off

                     M(ct) = getframe(gcf)
                      ct = ct+1

 end


 % Animation of the pendulum
  movie(M)
  videofile=VideoWriter('Pendulum Animation.avi', 'uncompressed avi')
  open(videofile)
  writeVideo(videofile,M)
  close(videofile)
SUPPLEMENTARY PROGRAM LIKE FUNCTION USED IN PROGRAMMING :
function [dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1= theta(1)
theta2= theta(2)
dtheta1_dt = theta2
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1)
dtheta_dt = [dtheta1_dt; dtheta2_dt]
end
STEPWISE EXPLANATION OF CODE :
clear all
close all
clc
% Inputs
% defining the inputs as below
l=1 ; % in metres % length of the string = 1 meter
m=1; % in Kg. % mass of the ball=1 Kg
b=0.05 ; % damping coefficient . % damping coefficients of damper system
g=9.81 ; % in m/s^2. % acceleration due to gravity
% Initial Conditions
theta_0 = [0 ;3];. %solution vector consists of values of initial displacement (here it is 0) and initial velocity (here it is 3)
% time points
t_span=linspace(0,20,500);. % creating time array from 0 to 200 with 500 values using linspace command
% solving ODE
[t,results] = ode45(@(t,theta)ode_func(t,theta,b,g,l,m),t_span,theta_0);
%ode45 is inbuilt command that solves ordinary partial differential equations in matlab
@(t,theta). % main inputs where t and theta are dependent and independent variables of ODE system
%Plotting
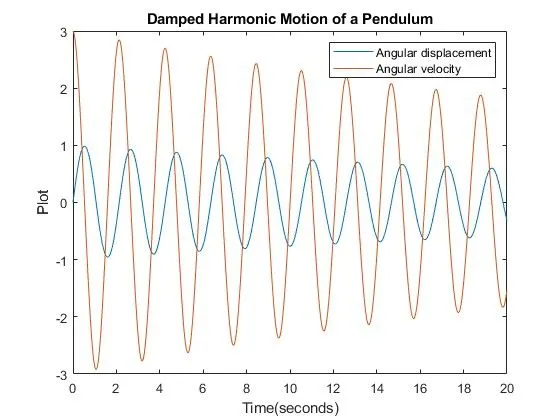
plot(t,results(:,1)) % plots t vs displacement that is stored in results of 1st column
hold on
plot(t,results(:,2)) % plots t vs velocity that stored in results of 2nd column
ylabel('Plot') % labels y axis as plot
xlabel('Time(seconds)') . % time in second is taken as x axis
title('Damped Harmonic Motion of a Pendulum')
% keeps the title of the plot
legend('Angular displacement ', 'Angular velocity')
% command that used to distinguish between angular displacement and angular velocity
ct =1;
for i = 1:length(results(:,1)). % used for loop
to iterate the loop For each value in time
x_start = 0 ; defining starting x coordinate
y_start = 0 ; defining the starting y cordinate
x_end = l*sin(results(i,1)) ; % ending x cordinate
y_end = -l*cos(results(i,1)) ; % ending y cordinate
% plotting the animation
figure(2)
plot([-1 1], [0 0], 'linewidth', 5)
hold on
plot([x_start x_end],[y_start y_end],'linewidth',3)
% plotting using starting and ending cordinates providing first X coordinates and then the Y coordinates of two points
hold on % command that makes plots do not get over return
% to close video file we used close command
FUNCTION CODE EXPLAINATION :
function [dtheta_dt] = ode_func(t,theta,b,g,l,m)
% ode function is the name of the function and the format used is for function definition
t, theta ,b ,g , l, m are the input parameters that are passing
theta1= theta(1) %defining theta (1) as theta1
theta2= theta(2) % defining theta(2) as theta2 to make the second order differential equation into single order differential equation
dtheta1_dt = theta2 % differentiating theta 1 with respect to time gives theta 2
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1)
% after transforming second order differential equation into single order differential equation then dtheta2_dt becomes { -(b/m)*theta2 - (g/l)*sin(theta1)}
dtheta_dt = [dtheta1_dt; dtheta2_dt]
% solution vector for theta is transformed into above when single order differential equation is written in matrix form
end
% end is a keyword that terminate function
PLOTS :
ANIMATION LINK :
CONCLUSION :
Hence , solved the second order differential equation that represents the equation of motion of simple pendulum under damping .